|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
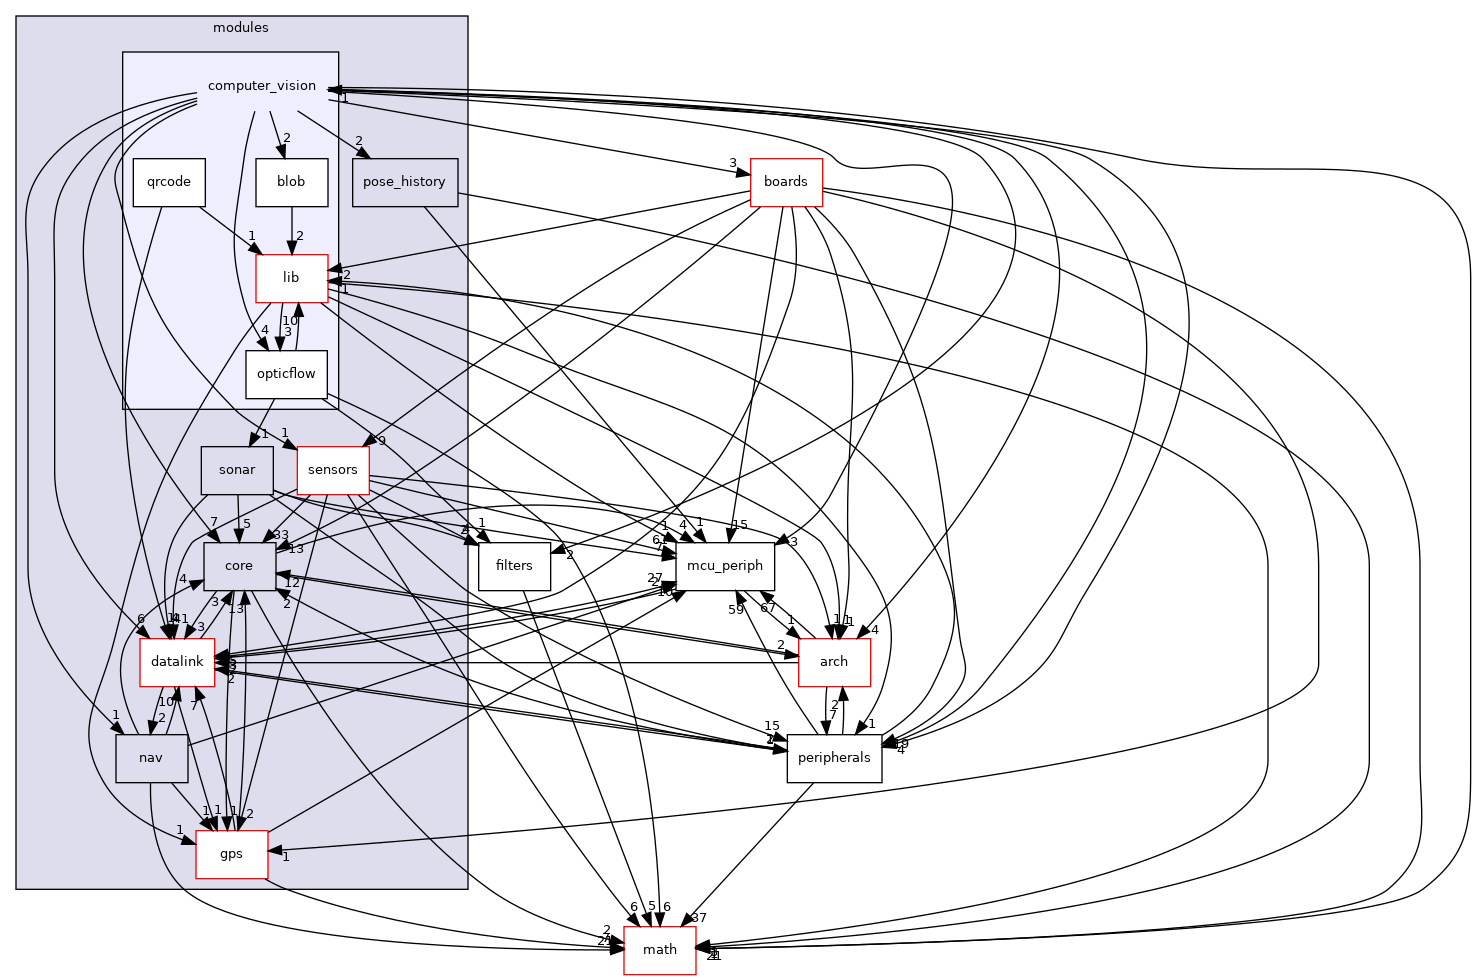
Directories | |
| blob | |
| lib | |
| opticflow | |
| qrcode | |
Files | |
| bebop_ae_awb.c | |
| bebop_ae_awb.h | |
| colorfilter.c | |
| colorfilter.h | |
| cv.c | |
| Computer vision framework for onboard processing. | |
| cv.h | |
| Computer vision framework for onboard processing. | |
| cv_blob_locator.c | |
| cv_blob_locator.h | |
| cv_detect_color_object.c | |
| cv_detect_color_object.h | |
| Assumes the color_object consists of a continuous color and checks if you are over the defined color_object or not. | |
| cv_georeference.c | |
| cv_georeference.h | |
| cv_opencvdemo.c | |
| cv_opencvdemo.h | |
| cv_target_localization.c | |
| cv_target_localization.h | |
| detect_contour.c | |
| detect_contour.h | |
| detect_gate.c | |
| detect_gate.h | |
| detect_window.c | |
| detect_window.h | |
| Detect a bright region surrounded by dark or viceversa - sometimes this corresponds to a window. | |
| opencv_contour.cpp | |
| opencv_contour.h | |
| Detects contours of an obstacle used in the autonomous drone racing. | |
| opencv_example.cpp | |
| opencv_example.h | |
| opencv_image_functions.cpp | |
| A small library with functions to convert between the Paparazzi used YUV422 arrays and the opencv image functions. | |
| opencv_image_functions.h | |
| A small library with functions to convert between the Paparazzi used YUV422 arrays and the opencv image functions. | |
| opticflow_module.c | |
| Optical-flow estimation module. | |
| opticflow_module.h | |
| optical-flow calculation for Parrot Drones | |
| snake_gate_detection.c | |
| Detects gates as used in the IROS drone races, i.e., square colored gates. | |
| snake_gate_detection.h | |
| Detects gates as used in the IROS drone races, i.e., square colored gates. | |
| tag_tracking.c | |
| tag_tracking.h | |
| textons.c | |
| Takes an image and represents the texture and colors in the image with a texton histogram. | |
| textons.h | |
| Takes an image and represents the texture and colors in the image with a texton histogram. | |
| undistort_image.c | |
| undistort_image.h | |
| video_capture.c | |
| video_capture.h | |
| video_thread.c | |
| video_thread.h | |
| Start a Video thread and grab images. | |
| video_thread_nps.c | |
| video_thread_nps.h | |
| This header gives NPS access to the list of added cameras. | |
| viewvideo.c | |
| Get live images from a RTP/UDP stream and save pictures on internal memory. | |
| viewvideo.h | |
| Get live images from a RTP/UDP stream and save pictures on internal memory. | |
 1.15.0