|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "std.h"#include <stdint.h>Go to the source code of this file.
Data Structures | |
| struct | camera_frame_t |
Functions | |
| void | georeference_init (void) |
| void | georeference_run (void) |
| void | georeference_project (struct camera_frame_t *tar, int wp) |
| void | georeference_filter (bool kalman, int wp, int length) |
Variables | |
| int32_t | focus_length |
Definition in file cv_georeference.h.
| struct camera_frame_t |
| void georeference_filter | ( | bool | kalman, |
| int | wp, | ||
| int | length ) |
Definition at line 119 of file cv_georeference.c.
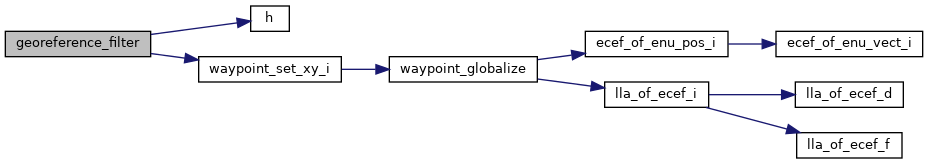
References DefaultChannel, DefaultDevice, geo, h(), VECT3_ADD, VECT3_COPY, VECT3_SDIV, VECT3_SMUL, VECT3_SUB, and waypoint_set_xy_i().
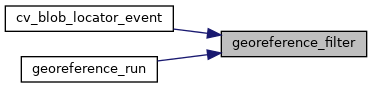
Referenced by cv_blob_locator_event(), and georeference_run().
|
extern |
Definition at line 180 of file cv_georeference.c.
References focus_length, geo, INT32_VECT3_ZERO, and VECT3_ASSIGN.
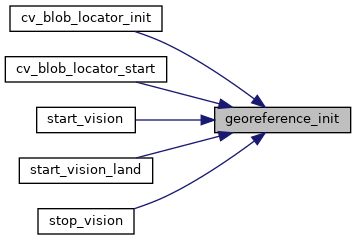
Referenced by cv_blob_locator_init(), cv_blob_locator_start(), start_vision(), start_vision_land(), and stop_vision().
| void georeference_project | ( | struct camera_frame_t * | tar, |
| int | wp ) |
Definition at line 53 of file cv_georeference.c.
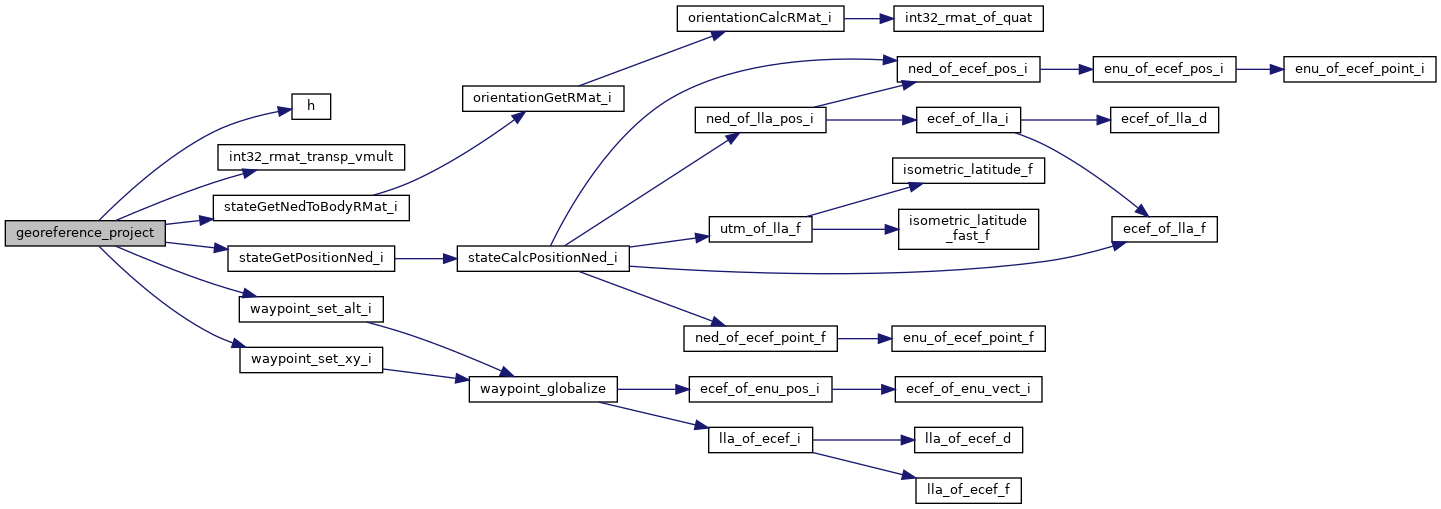
References DefaultChannel, DefaultDevice, camera_frame_t::f, geo, camera_frame_t::h, h(), INT32_MAT33_ZERO, int32_rmat_transp_vmult(), INT32_TRIG_FRAC, INT32_VECT3_LSHIFT, MAT33_ELMT, camera_frame_t::px, camera_frame_t::py, stateGetNedToBodyRMat_i(), stateGetPositionNed_i(), VECT3_ASSIGN, camera_frame_t::w, waypoint_set_alt_i(), waypoint_set_xy_i(), NedCoor_i::x, NedCoor_i::y, and NedCoor_i::z.
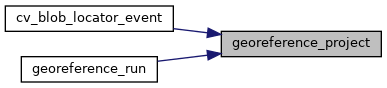
Referenced by cv_blob_locator_event(), and georeference_run().
|
extern |
Definition at line 155 of file cv_georeference.c.
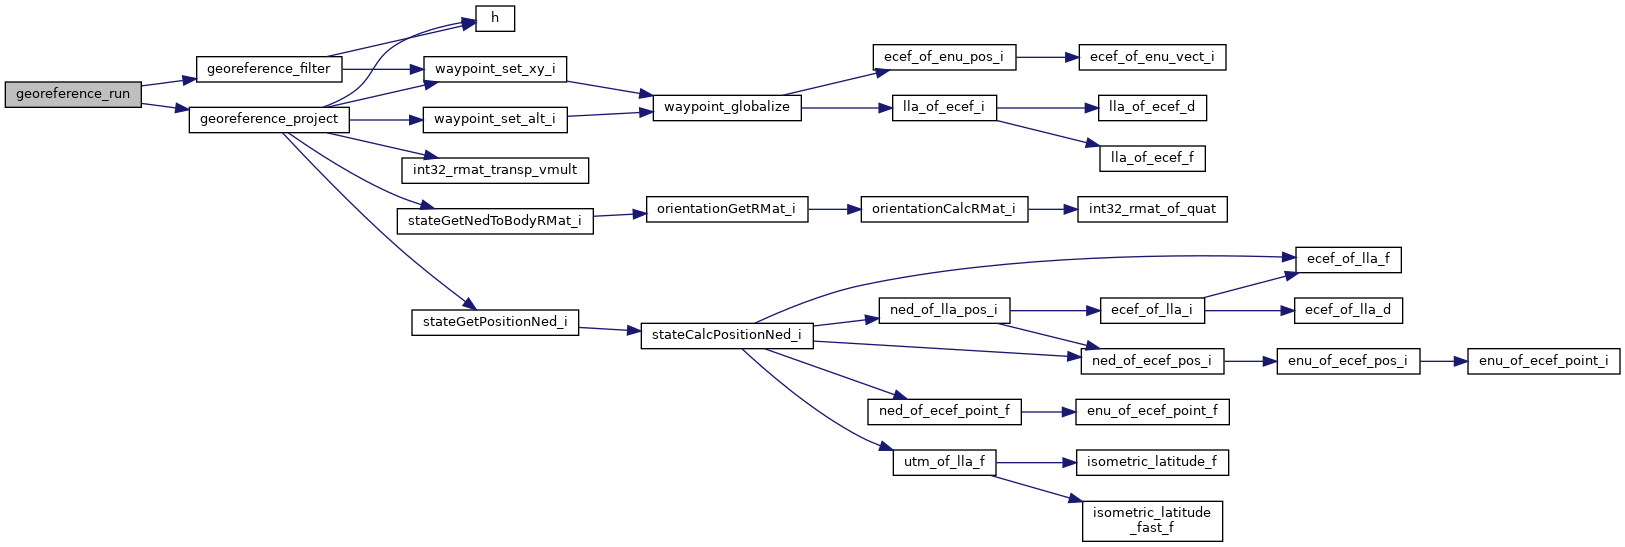
References FALSE, focus_length, georeference_filter(), georeference_project(), and target.
|
extern |
Definition at line 153 of file cv_georeference.c.
Referenced by georeference_init(), and georeference_run().
 1.15.0