|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Optical-flow estimation module. More...
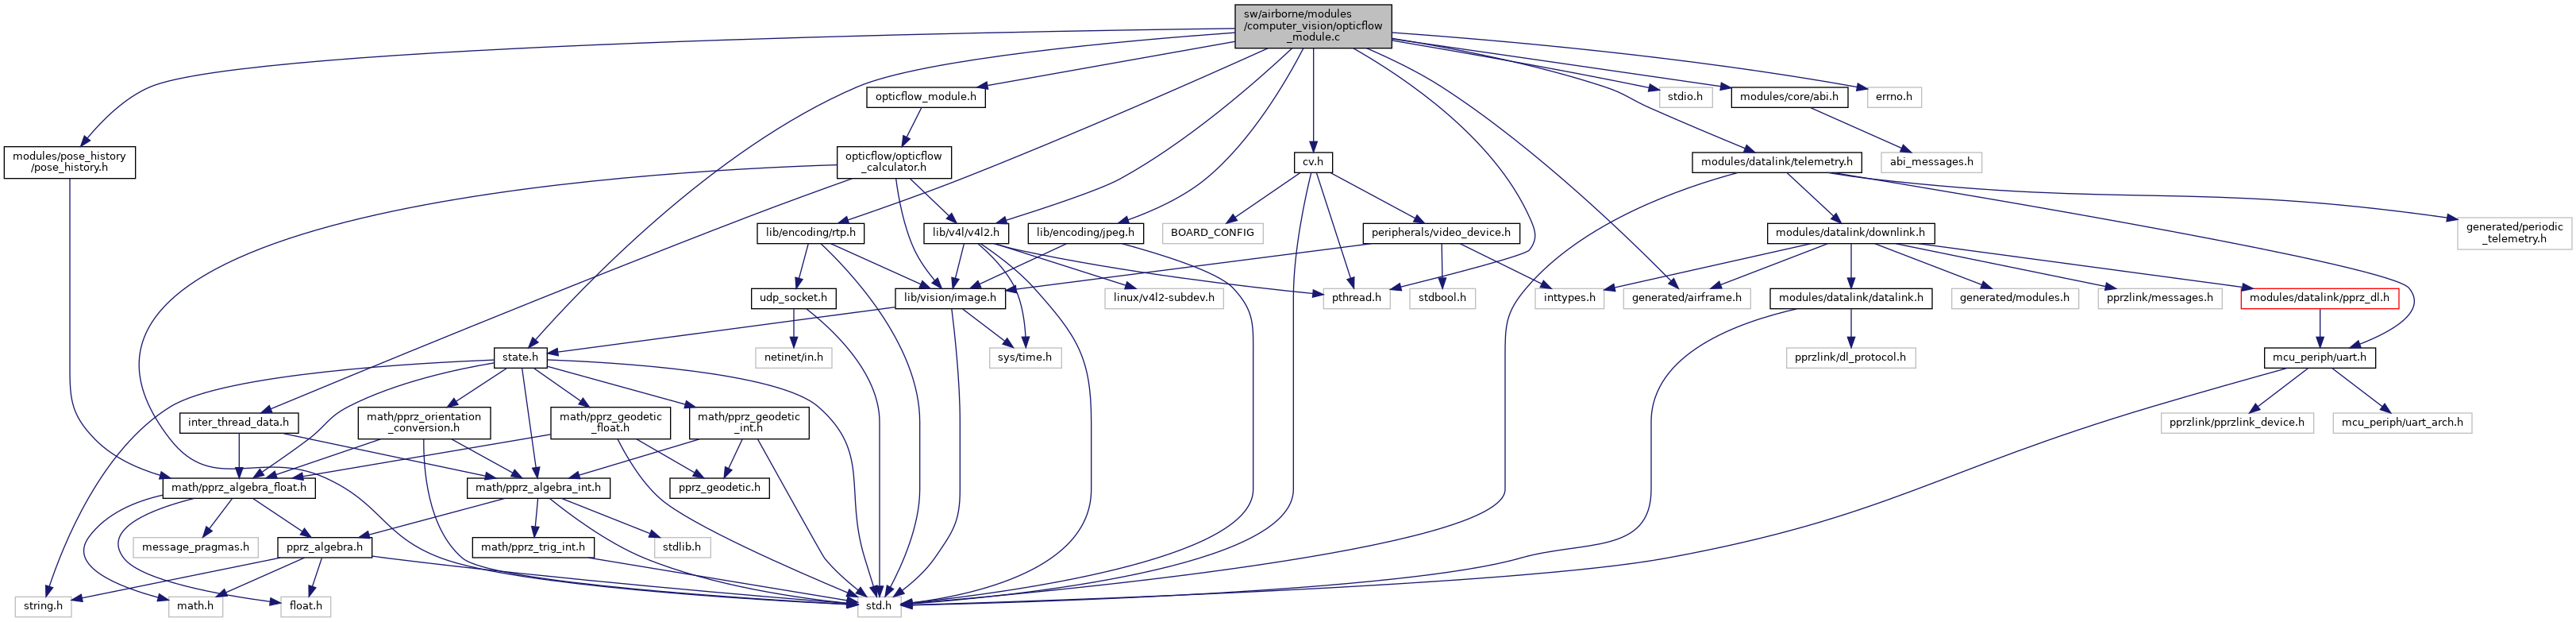
#include "opticflow_module.h"#include <stdio.h>#include <pthread.h>#include "state.h"#include "modules/core/abi.h"#include "modules/pose_history/pose_history.h"#include "lib/v4l/v4l2.h"#include "lib/encoding/jpeg.h"#include "lib/encoding/rtp.h"#include "errno.h"#include "cv.h"#include "generated/airframe.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Macros | |
| #define | OPTICFLOW_AGL_ID ABI_BROADCAST |
| Default sonar/agl to use in opticflow visual_estimator. | |
| #define | OPTICFLOW_FPS 0 |
| Default FPS (zero means run at camera fps). | |
| #define | OPTICFLOW_FPS_CAMERA2 0 |
| Default FPS (zero means run at camera fps). | |
| #define | ACTIVE_CAMERAS 1 |
Functions | |
| struct image_t * | opticflow_module_calc (struct image_t *img, uint8_t camera_id) |
| The main optical flow calculation thread. | |
| static void | opticflow_telem_send (struct transport_tx *trans, struct link_device *dev) |
| Send optical flow telemetry information. | |
| void | opticflow_module_init (void) |
| Initialize the optical flow module for the bottom camera. | |
| void | opticflow_module_run (void) |
| Update the optical flow state for the calculation thread and update the stabilization loops with the newest result. | |
Variables | |
| uint16_t | fps_OF |
| struct opticflow_t | opticflow [ACTIVE_CAMERAS] |
| Opticflow calculations. | |
| static struct opticflow_result_t | opticflow_result [ACTIVE_CAMERAS] |
| The opticflow result. | |
| static bool | opticflow_got_result [ACTIVE_CAMERAS] |
| When we have an optical flow calculation. | |
| static pthread_mutex_t | opticflow_mutex |
| Mutex lock fo thread safety. | |
Optical-flow estimation module.
Definition in file opticflow_module.c.
| #define ACTIVE_CAMERAS 1 |
Definition at line 65 of file opticflow_module.c.
Referenced by opticflow_module_calc(), opticflow_module_init(), opticflow_module_run(), and opticflow_telem_send().
| #define OPTICFLOW_AGL_ID ABI_BROADCAST |
Default sonar/agl to use in opticflow visual_estimator.
Definition at line 48 of file opticflow_module.c.
| #define OPTICFLOW_FPS 0 |
Default FPS (zero means run at camera fps).
Definition at line 53 of file opticflow_module.c.
Referenced by opticflow_module_init().
| #define OPTICFLOW_FPS_CAMERA2 0 |
Default FPS (zero means run at camera fps).
Definition at line 57 of file opticflow_module.c.
Referenced by opticflow_module_init().
The main optical flow calculation thread.
The main optical flow calculation thread This thread passes the images trough the optical flow calculator.
| [in] | *img | The image_t structure of the captured image |
| [in] | camera_id | The camera index id |
Definition at line 176 of file opticflow_module.c.
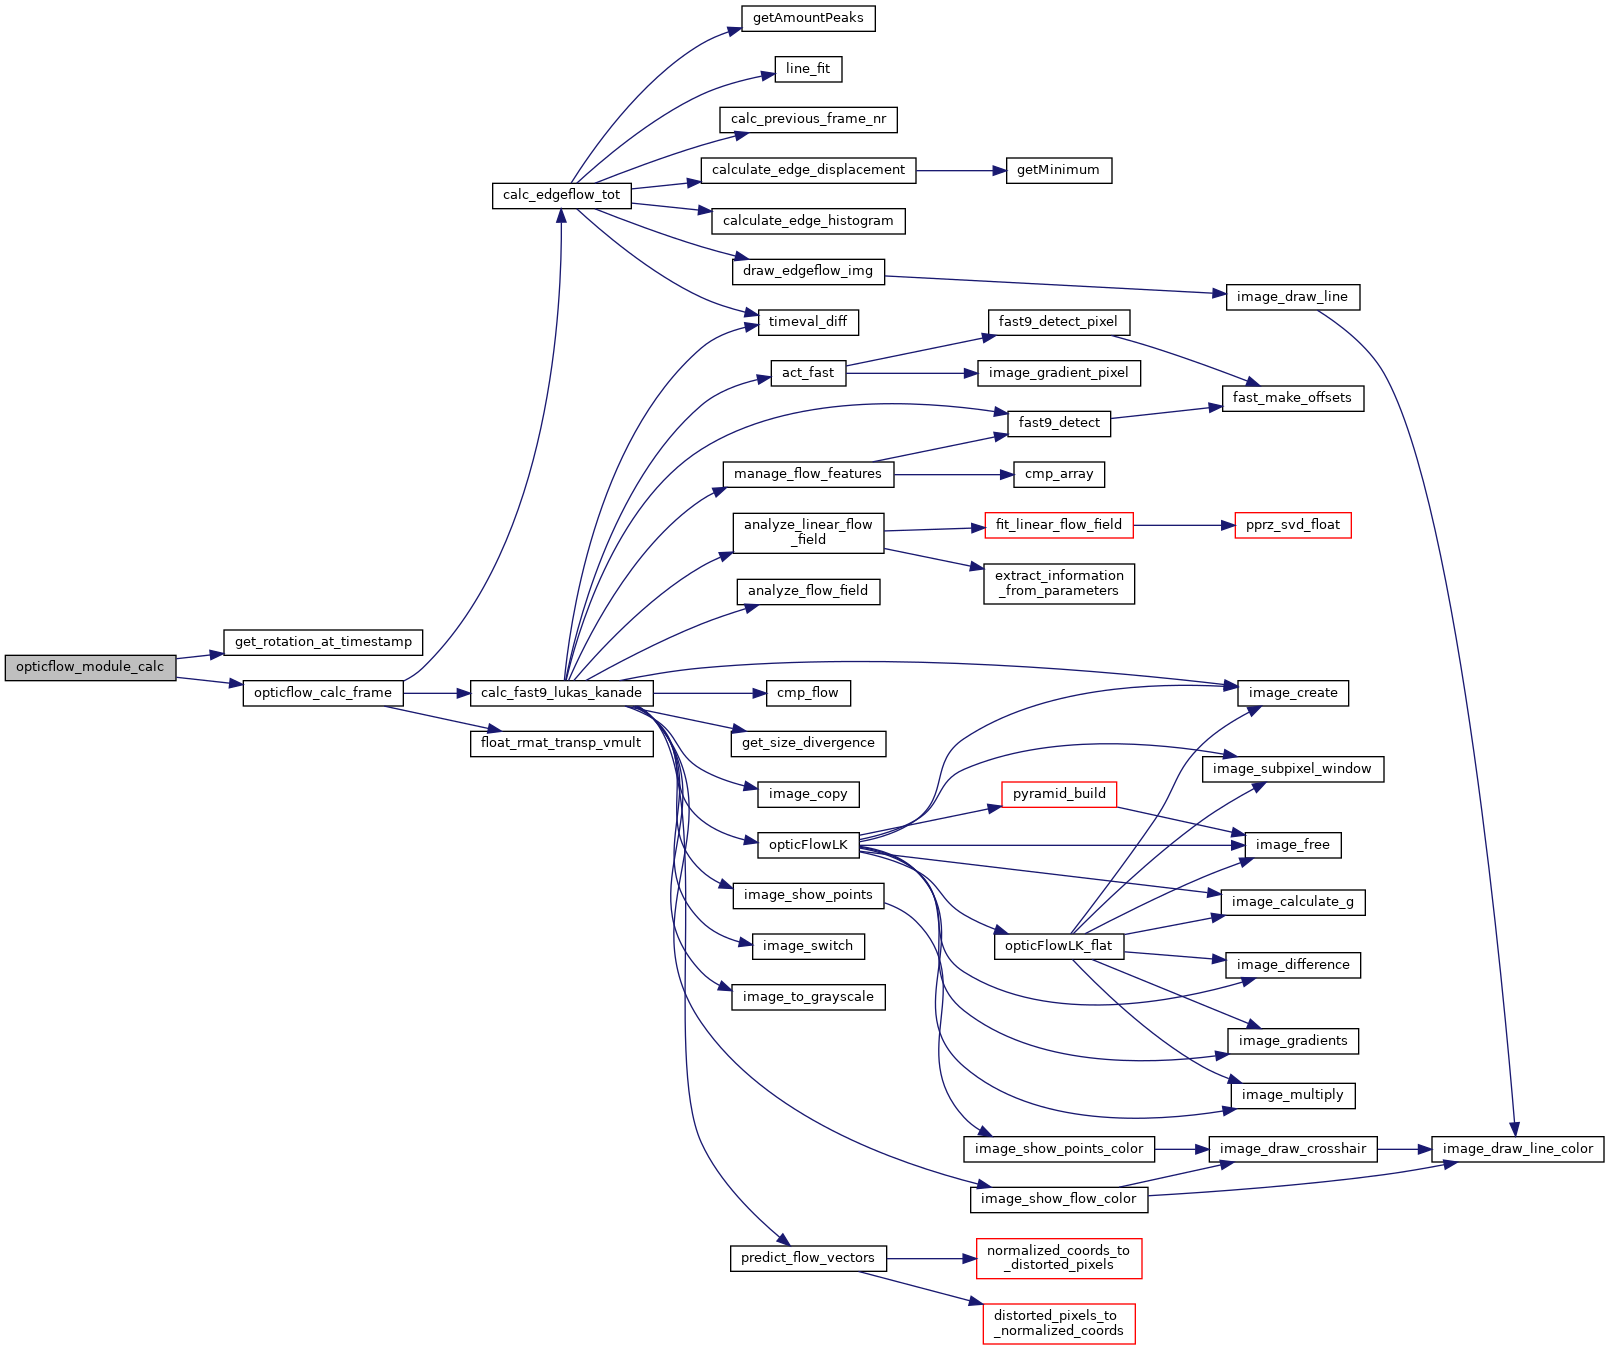
References ACTIVE_CAMERAS, opticflow_result_t::camera_id, image_t::eulers, pose_t::eulers, get_rotation_at_timestamp(), opticflow, opticflow_calc_frame(), opticflow_got_result, opticflow_mutex, opticflow_result, and image_t::pprz_ts.
Referenced by opticflow_module_init().
| void opticflow_module_init | ( | void | ) |
Initialize the optical flow module for the bottom camera.
Definition at line 114 of file opticflow_module.c.
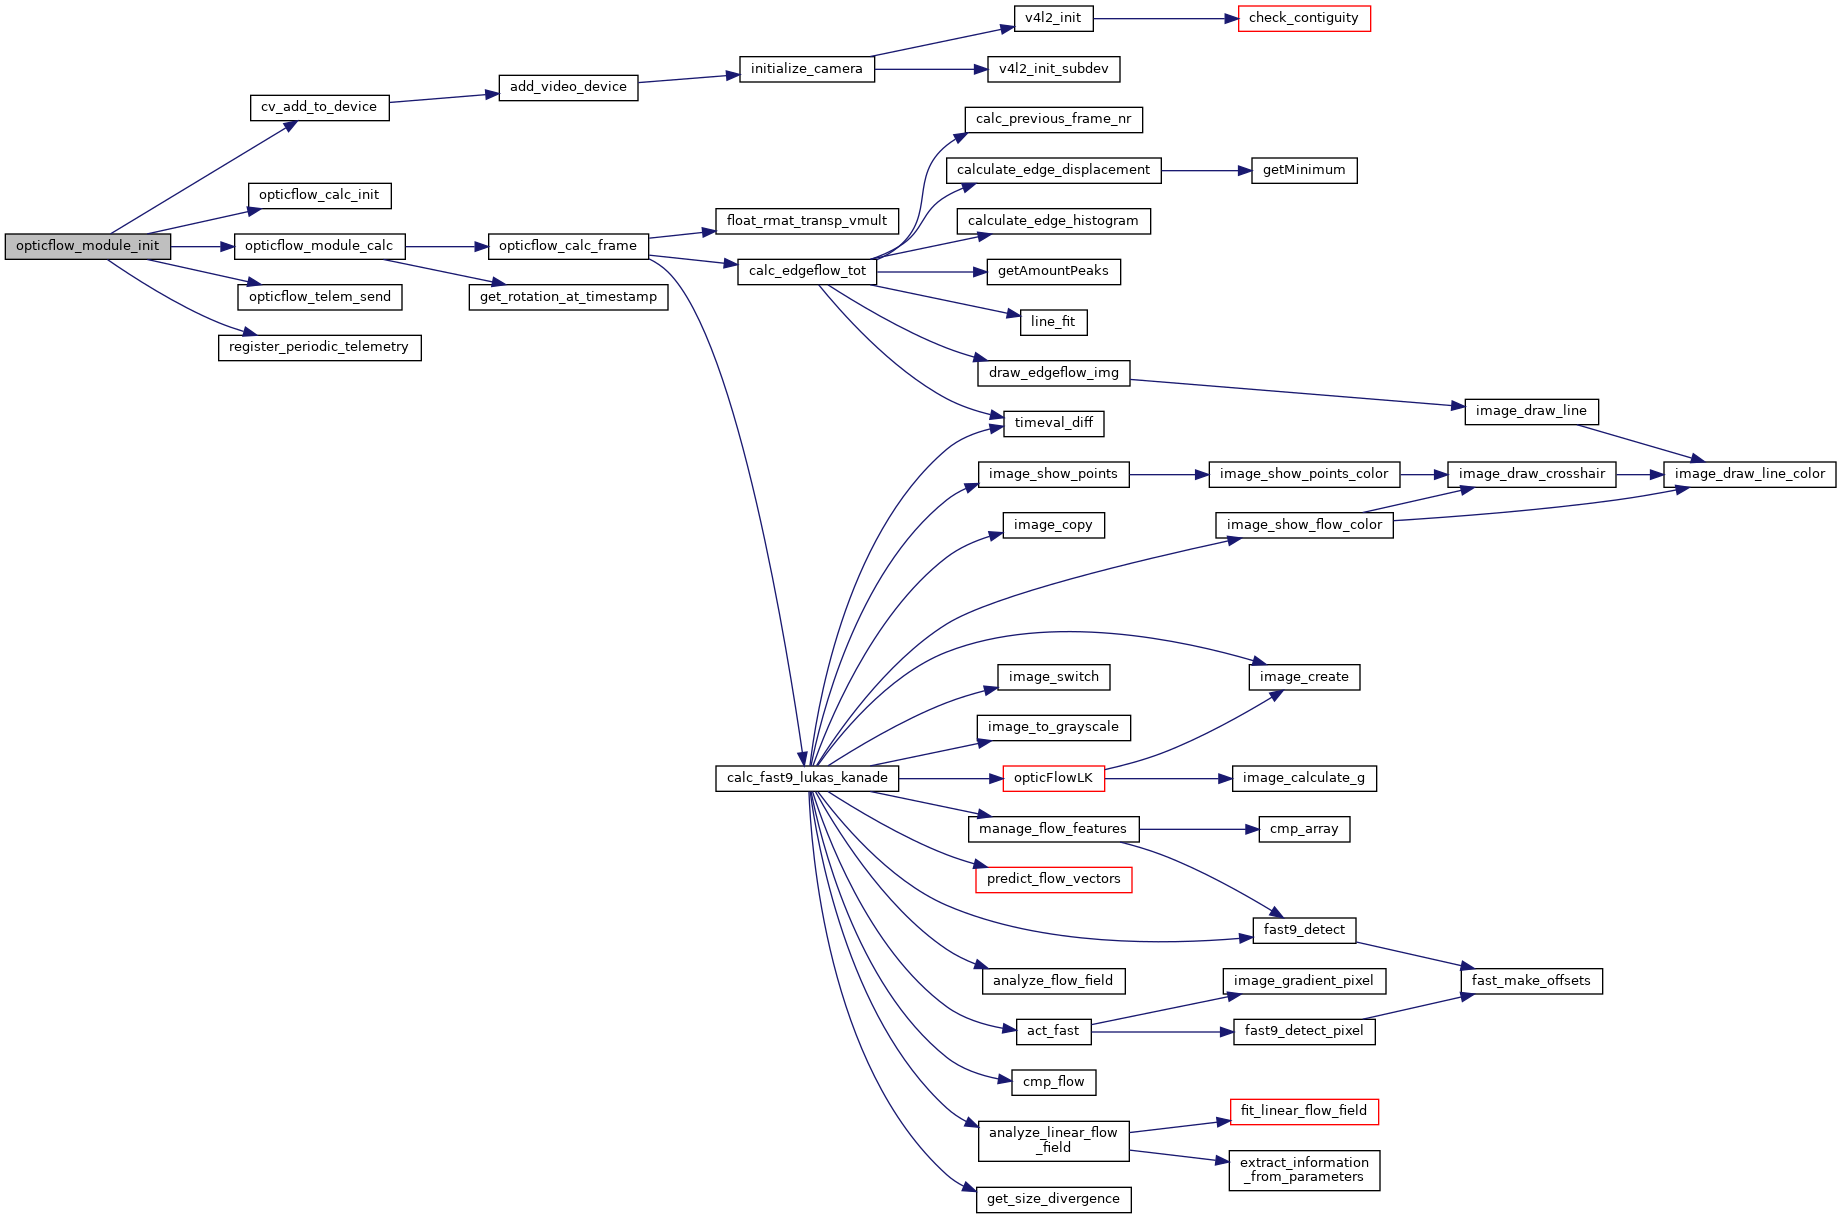
References ACTIVE_CAMERAS, cv_add_to_device(), DefaultPeriodic, opticflow, opticflow_calc_init(), OPTICFLOW_FPS, OPTICFLOW_FPS_CAMERA2, opticflow_got_result, opticflow_module_calc(), opticflow_telem_send(), and register_periodic_telemetry().
| void opticflow_module_run | ( | void | ) |
Update the optical flow state for the calculation thread and update the stabilization loops with the newest result.
Definition at line 137 of file opticflow_module.c.
References ACTIVE_CAMERAS, FLOW_OPTICFLOW_ID, get_sys_time_usec(), opticflow_got_result, opticflow_mutex, opticflow_result, and VEL_OPTICFLOW_ID.
|
static |
Send optical flow telemetry information.
| [in] | *trans | The transport structure to send the information over |
| [in] | *dev | The link to send the data over |
Definition at line 86 of file opticflow_module.c.
References ACTIVE_CAMERAS, dev, opticflow_mutex, and opticflow_result.
Referenced by opticflow_module_init().
| uint16_t fps_OF |
Definition at line 44 of file opticflow_module.c.
| struct opticflow_t opticflow[ACTIVE_CAMERAS] |
Opticflow calculations.
Definition at line 69 of file opticflow_module.c.
Referenced by calc_edgeflow_tot(), calc_fast9_lukas_kanade(), calc_previous_frame_nr(), manage_flow_features(), opticflow_calc_frame(), opticflow_calc_init(), opticflow_module_calc(), opticflow_module_init(), and predict_flow_vectors().
|
static |
When we have an optical flow calculation.
Definition at line 72 of file opticflow_module.c.
Referenced by opticflow_module_calc(), opticflow_module_init(), and opticflow_module_run().
|
static |
Mutex lock fo thread safety.
Definition at line 73 of file opticflow_module.c.
Referenced by opticflow_module_calc(), opticflow_module_run(), and opticflow_telem_send().
|
static |
The opticflow result.
Definition at line 70 of file opticflow_module.c.
Referenced by opticflow_module_calc(), opticflow_module_run(), and opticflow_telem_send().
 1.15.0