|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "std.h"Go to the source code of this file.
Functions | |
| void | target_localization_init (void) |
| void | target_localization_report (void) |
| void | cv_target_localization_report_mark (uint8_t mark) |
Variables | |
| uint8_t | target_localization_mark |
| bool | target_localization_update_wp |
Compute georeferenced position of a target from visual detection assuming that the target is on a flat ground
Definition in file cv_target_localization.h.
|
extern |
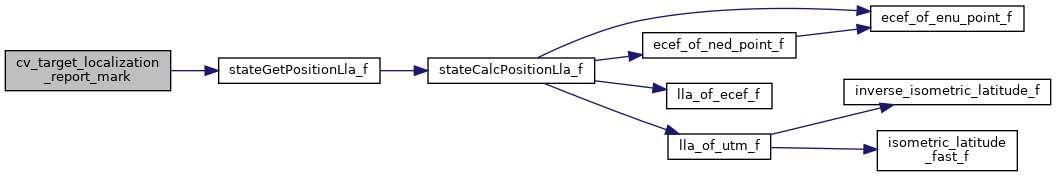
Definition at line 232 of file cv_target_localization.c.
References DefaultChannel, DefaultDevice, LlaCoor_f::lat, LlaCoor_f::lon, stateGetPositionLla_f(), and target_localization_mark.
|
extern |
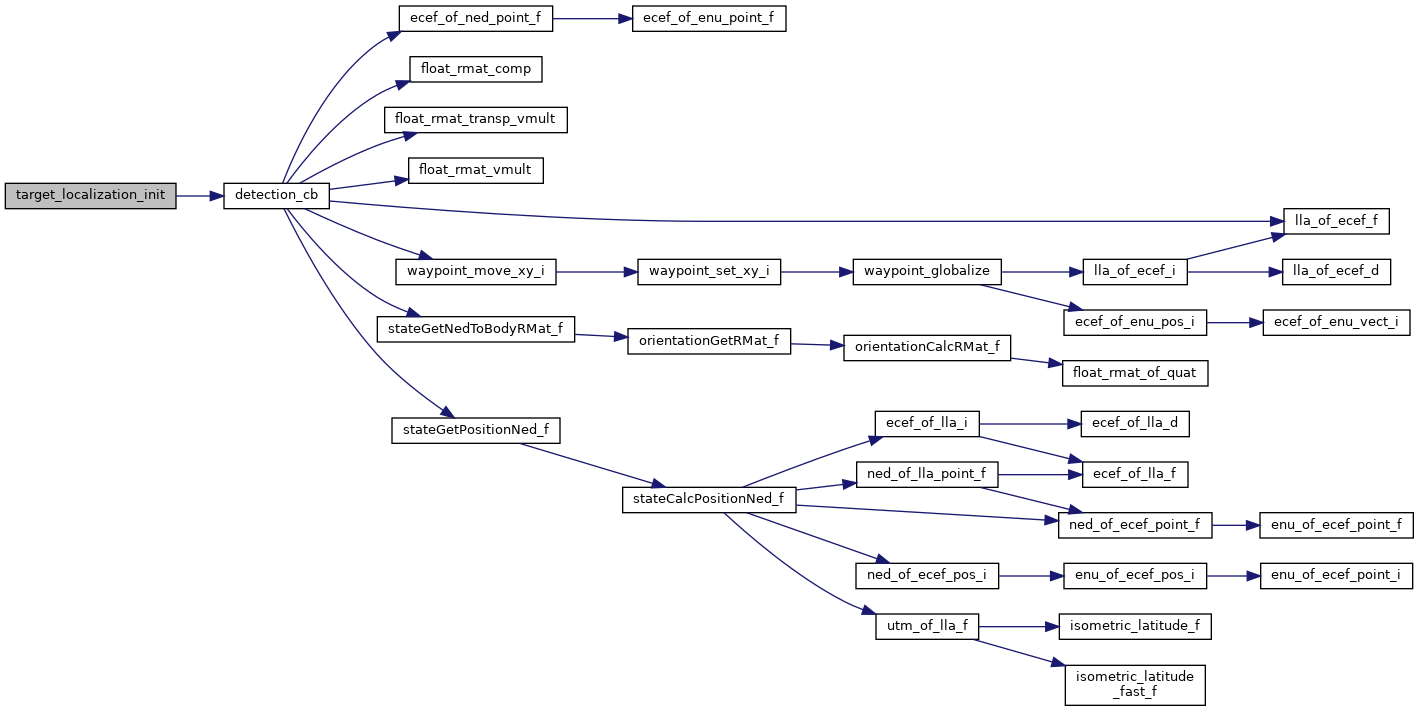
Definition at line 190 of file cv_target_localization.c.
References detection_cb(), detection_ev, float_rmat_of_eulers, FLOAT_VECT3_ZERO, target_loc, TARGET_LOC_BODY_TO_CAM_PHI, TARGET_LOC_BODY_TO_CAM_PSI, TARGET_LOC_BODY_TO_CAM_THETA, TARGET_LOC_CAM_POS_X, TARGET_LOC_CAM_POS_Y, TARGET_LOC_CAM_POS_Z, TARGET_LOC_ID, target_localization_mark, target_localization_update_wp, and VECT3_ASSIGN.
|
extern |
Definition at line 218 of file cv_target_localization.c.
References DefaultChannel, DefaultDevice, and target_loc.
|
extern |
Definition at line 99 of file cv_target_localization.c.
Referenced by cv_target_localization_report_mark(), and target_localization_init().
|
extern |
Definition at line 101 of file cv_target_localization.c.
Referenced by detection_cb(), and target_localization_init().
 1.15.0