|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
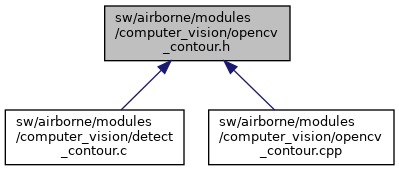
Detects contours of an obstacle used in the autonomous drone racing. More...
Go to the source code of this file.
Data Structures | |
| struct | contour_estimation |
| struct | contour_threshold |
Functions | |
| void | find_contour (char *img, int width, int height) |
Variables | |
| struct contour_estimation | cont_est |
| struct contour_threshold | cont_thres |
Detects contours of an obstacle used in the autonomous drone racing.
Definition in file opencv_contour.h.
| struct contour_estimation |
Definition at line 34 of file opencv_contour.h.
| Data Fields | ||
|---|---|---|
| float | contour_d_x | |
| float | contour_d_y | |
| float | contour_d_z | |
| struct contour_threshold |
Definition at line 40 of file opencv_contour.h.
| Data Fields | ||
|---|---|---|
| int | lower_u | |
| int | lower_v | |
| int | lower_y | |
| int | upper_u | |
| int | upper_v | |
| int | upper_y | |
| void find_contour | ( | char * | img, |
| int | width, | ||
| int | height ) |
Find contours
Draw contours
Definition at line 79 of file opencv_contour.cpp.
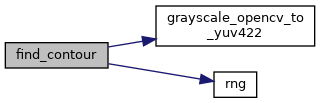
References cont_est, cont_thres, grayscale_opencv_to_yuv422(), moments, and rng().
Referenced by contour_func().
|
extern |
Definition at line 34 of file opencv_contour.cpp.
Referenced by find_contour().
|
extern |
Definition at line 35 of file opencv_contour.cpp.
Referenced by detect_contour_init(), and find_contour().
 1.15.0