|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
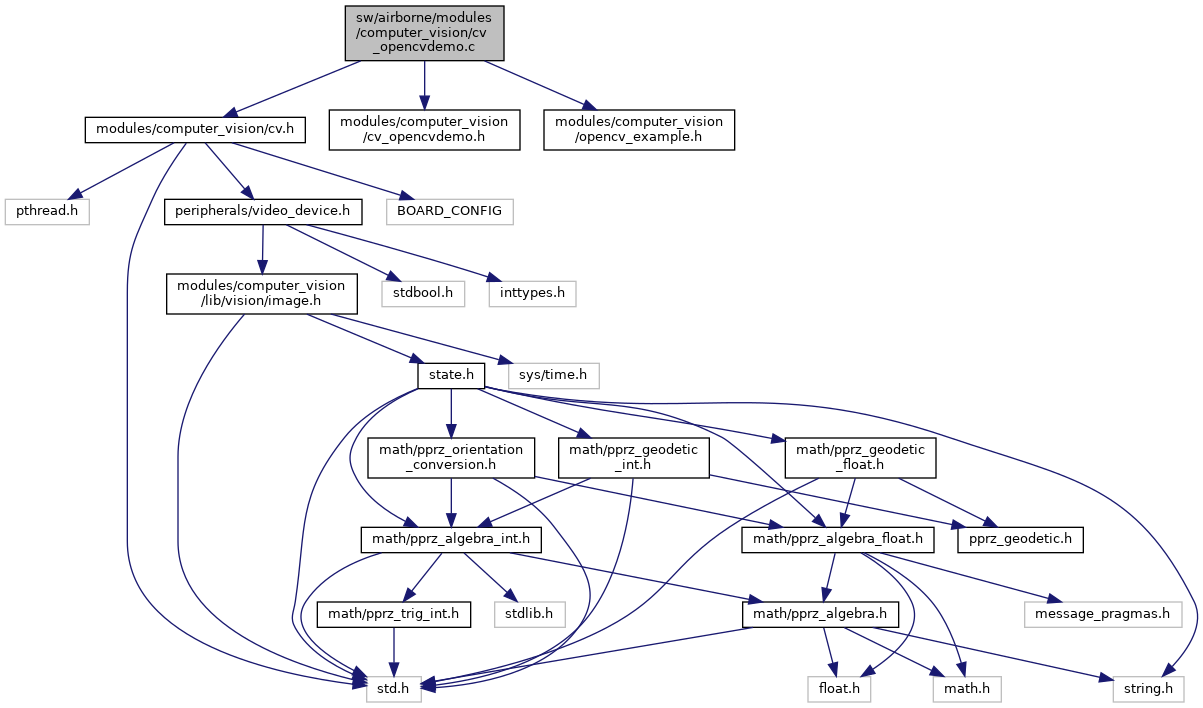
#include "modules/computer_vision/cv.h"#include "modules/computer_vision/cv_opencvdemo.h"#include "modules/computer_vision/opencv_example.h"Go to the source code of this file.
Macros | |
| #define | OPENCVDEMO_FPS 0 |
| Default FPS (zero means run at camera fps). | |
Functions | |
| struct image_t * | opencv_func (struct image_t *img, uint8_t camera_id) |
| void | opencvdemo_init (void) |
Definition in file cv_opencvdemo.c.
| #define OPENCVDEMO_FPS 0 |
Default FPS (zero means run at camera fps).
Definition at line 31 of file cv_opencvdemo.c.
Referenced by opencvdemo_init().
Definition at line 37 of file cv_opencvdemo.c.
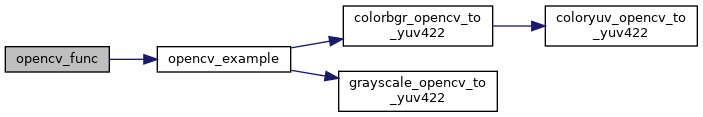
References image_t::buf, image_t::h, IMAGE_YUV422, opencv_example(), image_t::type, and image_t::w.
Referenced by opencvdemo_init().
| void opencvdemo_init | ( | void | ) |
Definition at line 50 of file cv_opencvdemo.c.
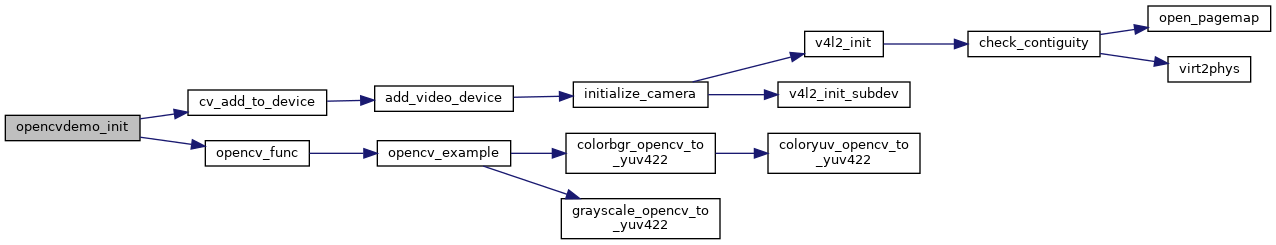
References cv_add_to_device(), opencv_func(), and OPENCVDEMO_FPS.
 1.15.0