|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
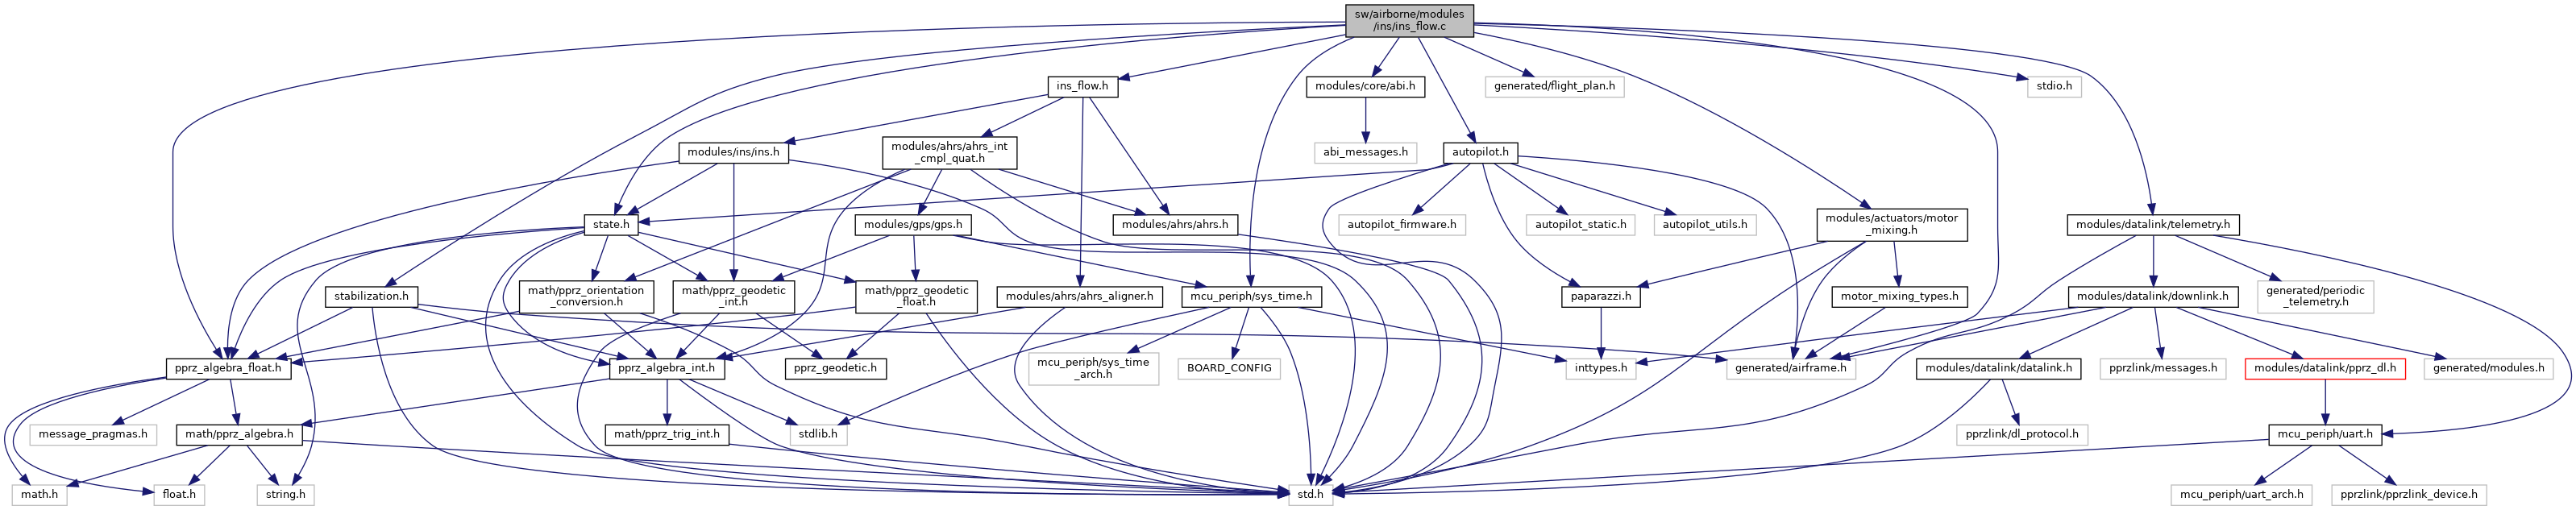
#include "ins_flow.h"#include "modules/core/abi.h"#include "generated/airframe.h"#include "mcu_periph/sys_time.h"#include "autopilot.h"#include "math/pprz_algebra_float.h"#include "generated/flight_plan.h"#include "modules/actuators/motor_mixing.h"#include "stabilization.h"#include <stdio.h>#include "modules/datalink/telemetry.h"#include "state.h"Go to the source code of this file.
Data Structures | |
| struct | InsFlow |
Macros | |
| #define | DEBUG_INS_FLOW 0 |
| #define | DEBUG_PRINT(...) |
| #define | DEBUG_MAT_PRINT(...) |
| #define | AHRS_ICQ_OUTPUT_ENABLED TRUE |
| #define | INS_FLOW_GYRO_ID ABI_BROADCAST |
| #define | INS_FLOW_ACCEL_ID ABI_BROADCAST |
| #define | INS_FLOW_IMU_ID ABI_BROADCAST |
| #define | INS_FLOW_GPS_ID GPS_MULTI_ID |
| #define | INS_OPTICAL_FLOW_ID ABI_BROADCAST |
| #define | INS_RPM_ID ABI_BROADCAST |
| #define | MOMENT_DELAY 20 |
| #define | OF_N_ROTORS 4 |
| #define | USE_STANDARD_PARAMS 0 |
| #define | PAR_IX 0 |
| #define | PAR_MASS 1 |
| #define | PAR_BASE 2 |
| #define | PAR_K0 3 |
| #define | PAR_K1 4 |
| #define | PAR_K2 5 |
| #define | PAR_K3 6 |
| #define | PAR_R0 7 |
| #define | PAR_R1 8 |
| #define | PAR_Q0 9 |
| #define | PAR_Q1 10 |
| #define | PAR_Q2 11 |
| #define | PAR_Q3 12 |
| #define | PAR_Q4 13 |
| #define | PAR_P0 14 |
| #define | PAR_P1 15 |
| #define | PAR_P2 16 |
| #define | PAR_P3 17 |
| #define | PAR_P4 18 |
| #define | PAR_KD 19 |
| #define | PAR_Q_TB 20 |
| #define | PAR_P_TB 21 |
| #define | PAR_PRED_ROLL_1 22 |
| #define | PAR_PRED_ROLL_2 23 |
| #define | PAR_PRED_ROLL_3 24 |
Functions | |
| static void | gyro_cb (uint8_t sender_id, uint32_t stamp, struct Int32Rates *gyro) |
| static void | accel_cb (uint8_t sender_id, uint32_t stamp, struct Int32Vect3 *accel) |
| static void | gps_cb (uint8_t sender_id, uint32_t stamp, struct GpsState *gps_s) |
| void | ins_optical_flow_cb (uint8_t sender_id, uint32_t stamp, int32_t flow_x, int32_t flow_y, int32_t flow_der_x, int32_t flow_der_y, float quality, float size_divergence) |
| static void | ins_act_feedback_cb (uint8_t sender_id, struct act_feedback_t *feedback, uint8_t num_act) |
| static void | aligner_cb (uint8_t sender_id, uint32_t stamp, struct Int32Rates *lp_gyro, struct Int32Vect3 *lp_accel, struct Int32Vect3 *lp_mag) |
| static void | reset_cb (uint8_t sender_id UNUSED, uint8_t flag) |
| static void | print_ins_flow_state (void) |
| static void | print_true_state (void) |
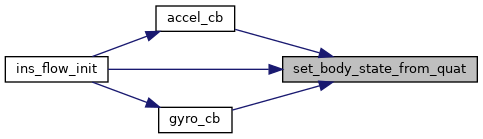
| static void | set_body_state_from_quat (void) |
| Rotate angles and rates from imu to body frame and set state. | |
| static void | ins_reset_filter (void) |
| static void | send_quat (struct transport_tx *trans, struct link_device *dev) |
| static void | send_euler (struct transport_tx *trans, struct link_device *dev) |
| static void | send_bias (struct transport_tx *trans, struct link_device *dev) |
| static void | send_geo_mag (struct transport_tx *trans, struct link_device *dev) |
| static void | send_filter_status (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ins (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ins_ref (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ins_flow (struct transport_tx *trans, struct link_device *dev) |
| void | ins_flow_init (void) |
| void | ins_flow_update (void) |
Variables | |
| static abi_event | gyro_ev |
| static abi_event | accel_ev |
| static abi_event | gps_ev |
| static abi_event | ins_optical_flow_ev |
| static abi_event | ins_act_feedback_ev |
| static abi_event | aligner_ev |
| static abi_event | reset_ev |
| static uint32_t | ahrs_icq_last_stamp |
| static uint8_t | ahrs_flow_id = AHRS_COMP_ID_FLOW |
| Component ID for FLOW. | |
| struct InsFlow | ins_flow |
| float | moments [MOMENT_DELAY] = {0.} |
| int | moment_ind |
| float | OF_X [N_STATES_OF_KF] = {0.} |
| float | OF_Q [N_STATES_OF_KF][N_STATES_OF_KF] = {{0.}} |
| float | OF_P [N_STATES_OF_KF][N_STATES_OF_KF] = {{0.}} |
| float | OF_R [N_MEAS_OF_KF][N_MEAS_OF_KF] = {{0.}} |
| float | RPM_FACTORS [OF_N_ROTORS] |
| float | of_time |
| float | of_prev_time |
| float | lp_factor |
| float | lp_factor_strong |
| bool | reset_filter |
| int | use_filter |
| bool | run_filter |
| uint32_t | counter |
| float | thrust_factor |
| float | GT_phi |
| float | GT_theta |
| float | parameters [22] = {0.219033, 0.376572, 0.184002, 0.096388, 0.240843, 0.172390, 0.133111, 0.495885, 0.357086, 0.233624, 0.125611, 1.661682, 0.136735, 2.812652, 0.715887, 0.166932, 0.371409, 1.043920, 0.840683, 0.567703, 0.192238, 0.301966} |
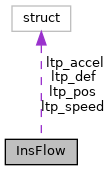
| struct InsFlow |
Definition at line 133 of file ins_flow.c.
| Data Fields | ||
|---|---|---|
| float | divergence | |
| float | lp_gyro_bias_pitch | |
| float | lp_gyro_bias_roll | |
| float | lp_gyro_pitch | |
| float | lp_gyro_roll | |
| float | lp_roll_command | |
| float | lp_thrust | |
| struct NedCoor_i | ltp_accel | |
| struct LtpDef_i | ltp_def | |
| bool | ltp_initialized | |
| struct NedCoor_i | ltp_pos | |
| struct NedCoor_i | ltp_speed | |
| bool | new_flow_measurement | |
| float | optical_flow_x | |
| float | optical_flow_y | |
| uint16_t | RPM[8] | |
| uint8_t | RPM_num_act | |
| float | thrust_factor | |
| float | vision_time | |
| #define AHRS_ICQ_OUTPUT_ENABLED TRUE |
Definition at line 62 of file ins_flow.c.
| #define DEBUG_INS_FLOW 0 |
Definition at line 49 of file ins_flow.c.
Referenced by ins_flow_update().
| #define DEBUG_MAT_PRINT | ( | ... | ) |
Definition at line 58 of file ins_flow.c.
Referenced by ins_flow_update().
| #define DEBUG_PRINT | ( | ... | ) |
Definition at line 57 of file ins_flow.c.
Referenced by ins_flow_update().
| #define INS_FLOW_ACCEL_ID ABI_BROADCAST |
Definition at line 74 of file ins_flow.c.
Referenced by ins_flow_init().
| #define INS_FLOW_GPS_ID GPS_MULTI_ID |
Definition at line 87 of file ins_flow.c.
Referenced by ins_flow_init().
| #define INS_FLOW_GYRO_ID ABI_BROADCAST |
Definition at line 68 of file ins_flow.c.
Referenced by ins_flow_init().
| #define INS_FLOW_IMU_ID ABI_BROADCAST |
Definition at line 80 of file ins_flow.c.
Referenced by ins_flow_init().
| #define INS_OPTICAL_FLOW_ID ABI_BROADCAST |
Definition at line 93 of file ins_flow.c.
Referenced by ins_flow_init().
| #define INS_RPM_ID ABI_BROADCAST |
Definition at line 99 of file ins_flow.c.
Referenced by ins_flow_init().
| #define MOMENT_DELAY 20 |
Definition at line 168 of file ins_flow.c.
| #define OF_N_ROTORS 4 |
Definition at line 177 of file ins_flow.c.
Referenced by ins_flow_update(), and send_ins_flow().
| #define PAR_BASE 2 |
Definition at line 257 of file ins_flow.c.
| #define PAR_IX 0 |
Definition at line 255 of file ins_flow.c.
Referenced by ins_flow_update().
| #define PAR_K0 3 |
Definition at line 258 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_K1 4 |
Definition at line 259 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_K2 5 |
Definition at line 260 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_K3 6 |
Definition at line 261 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_KD 19 |
Definition at line 274 of file ins_flow.c.
Referenced by ins_flow_update().
| #define PAR_MASS 1 |
Definition at line 256 of file ins_flow.c.
Referenced by ins_flow_update(), and send_ins_flow().
| #define PAR_P0 14 |
Definition at line 269 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_P1 15 |
Definition at line 270 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_P2 16 |
Definition at line 271 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_P3 17 |
Definition at line 272 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_P4 18 |
Definition at line 273 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_P_TB 21 |
Definition at line 276 of file ins_flow.c.
Referenced by ins_reset_filter().
| #define PAR_PRED_ROLL_1 22 |
Definition at line 277 of file ins_flow.c.
| #define PAR_PRED_ROLL_2 23 |
Definition at line 278 of file ins_flow.c.
| #define PAR_PRED_ROLL_3 24 |
Definition at line 279 of file ins_flow.c.
Referenced by ins_flow_update().
| #define PAR_Q0 9 |
Definition at line 264 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_Q1 10 |
Definition at line 265 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_Q2 11 |
Definition at line 266 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_Q3 12 |
Definition at line 267 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_Q4 13 |
Definition at line 268 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_Q_TB 20 |
Definition at line 275 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_R0 7 |
Definition at line 262 of file ins_flow.c.
Referenced by ins_flow_init().
| #define PAR_R1 8 |
Definition at line 263 of file ins_flow.c.
Referenced by ins_flow_init().
| #define USE_STANDARD_PARAMS 0 |
Definition at line 194 of file ins_flow.c.
|
static |
Definition at line 1373 of file ins_flow.c.
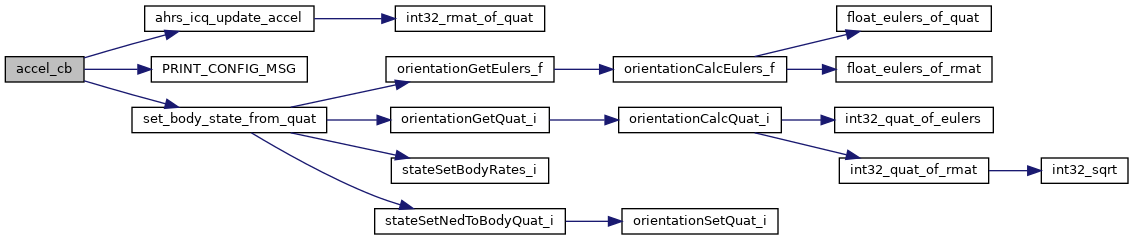
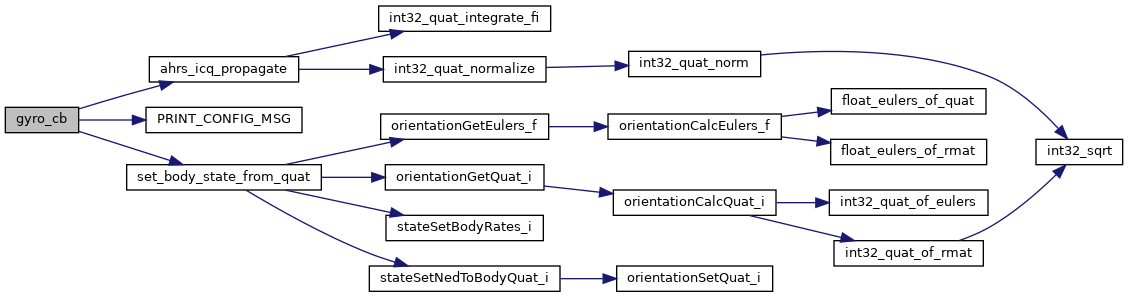
References ahrs_icq, ahrs_icq_update_accel(), PRINT_CONFIG_MSG(), PRINT_CONFIG_VAR(), and set_body_state_from_quat().
|
static |
Definition at line 1530 of file ins_flow.c.
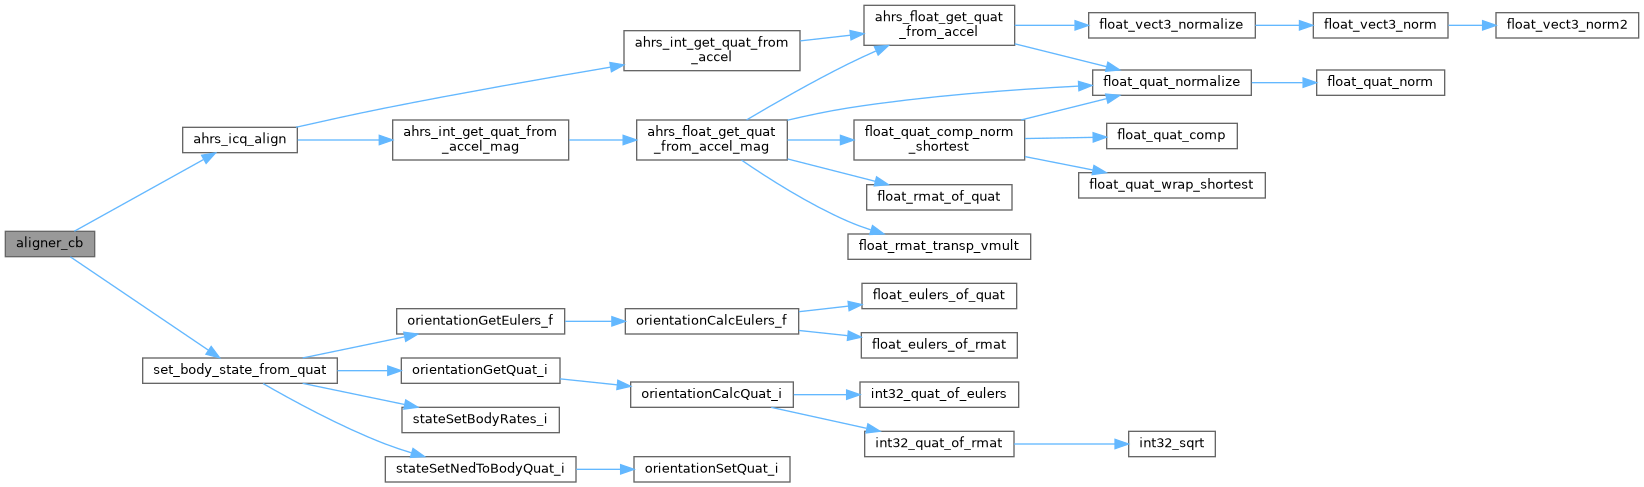
References ahrs_icq, ahrs_icq_align(), and set_body_state_from_quat().
Definition at line 1456 of file ins_flow.c.
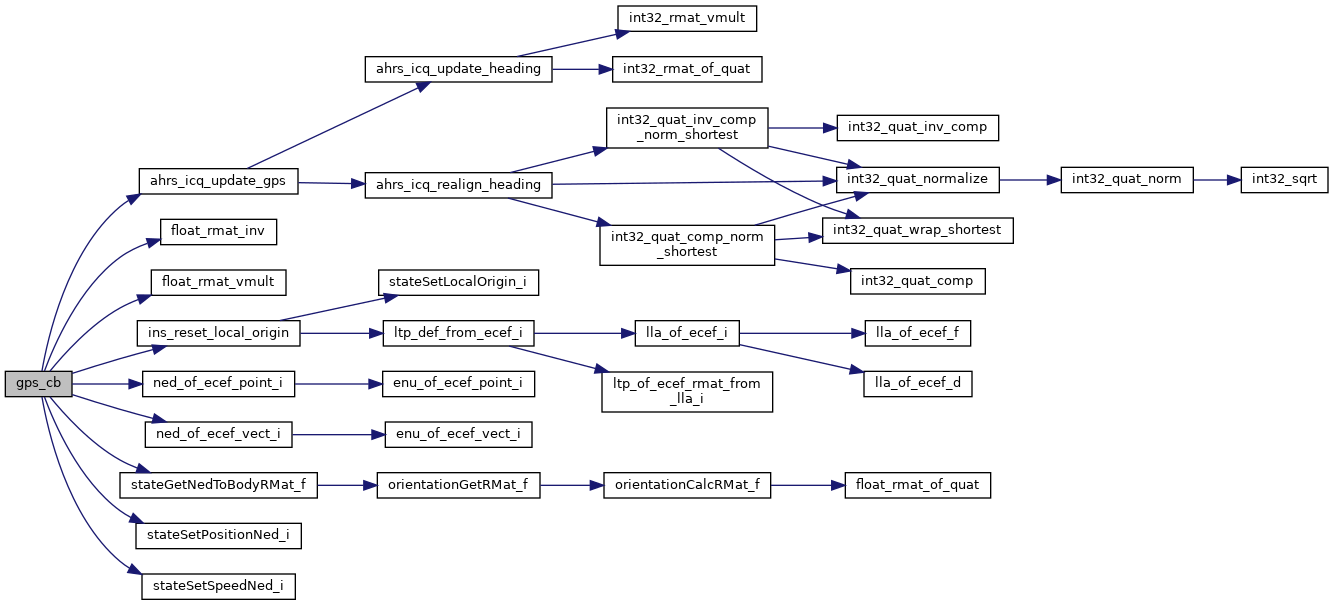
References ahrs_icq_update_gps(), CONSTANT_ALT_FILTER, ecef_int_from_gps(), ecef_vel_int_from_gps(), GpsState::fix, float_rmat_inv(), float_rmat_vmult(), GPS_FIX_3D, ins_flow, INS_RESET_REF, INT32_POS_OF_CM_DEN, INT32_POS_OF_CM_NUM, INT32_SPEED_OF_CM_S_DEN, INT32_SPEED_OF_CM_S_NUM, INT32_VECT3_SCALE_2, ned_of_ecef_point_i(), ned_of_ecef_vect_i(), OF_V_IND, OF_X, OF_Z_IND, reset_cb(), stateGetNedToBodyRMat_f(), stateSetPositionNed_i(), stateSetSpeedNed_i(), UNUSED, use_filter, USE_HEIGHT, USE_VELOCITY, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
|
static |
Definition at line 1340 of file ins_flow.c.
References ahrs_icq, ahrs_icq_last_stamp, ahrs_icq_propagate(), AHRS_ICQ_RUNNING, AHRS_PROPAGATE_FREQUENCY, ins_flow, lp_factor, Int32Rates::p, PRINT_CONFIG_MSG(), PRINT_CONFIG_VAR(), Int32Rates::q, and set_body_state_from_quat().
|
static |
Definition at line 1444 of file ins_flow.c.
References ins_flow, act_feedback_t::rpm, and UNUSED.
Referenced by ins_flow_init().
| void ins_flow_init | ( | void | ) |
Definition at line 532 of file ins_flow.c.
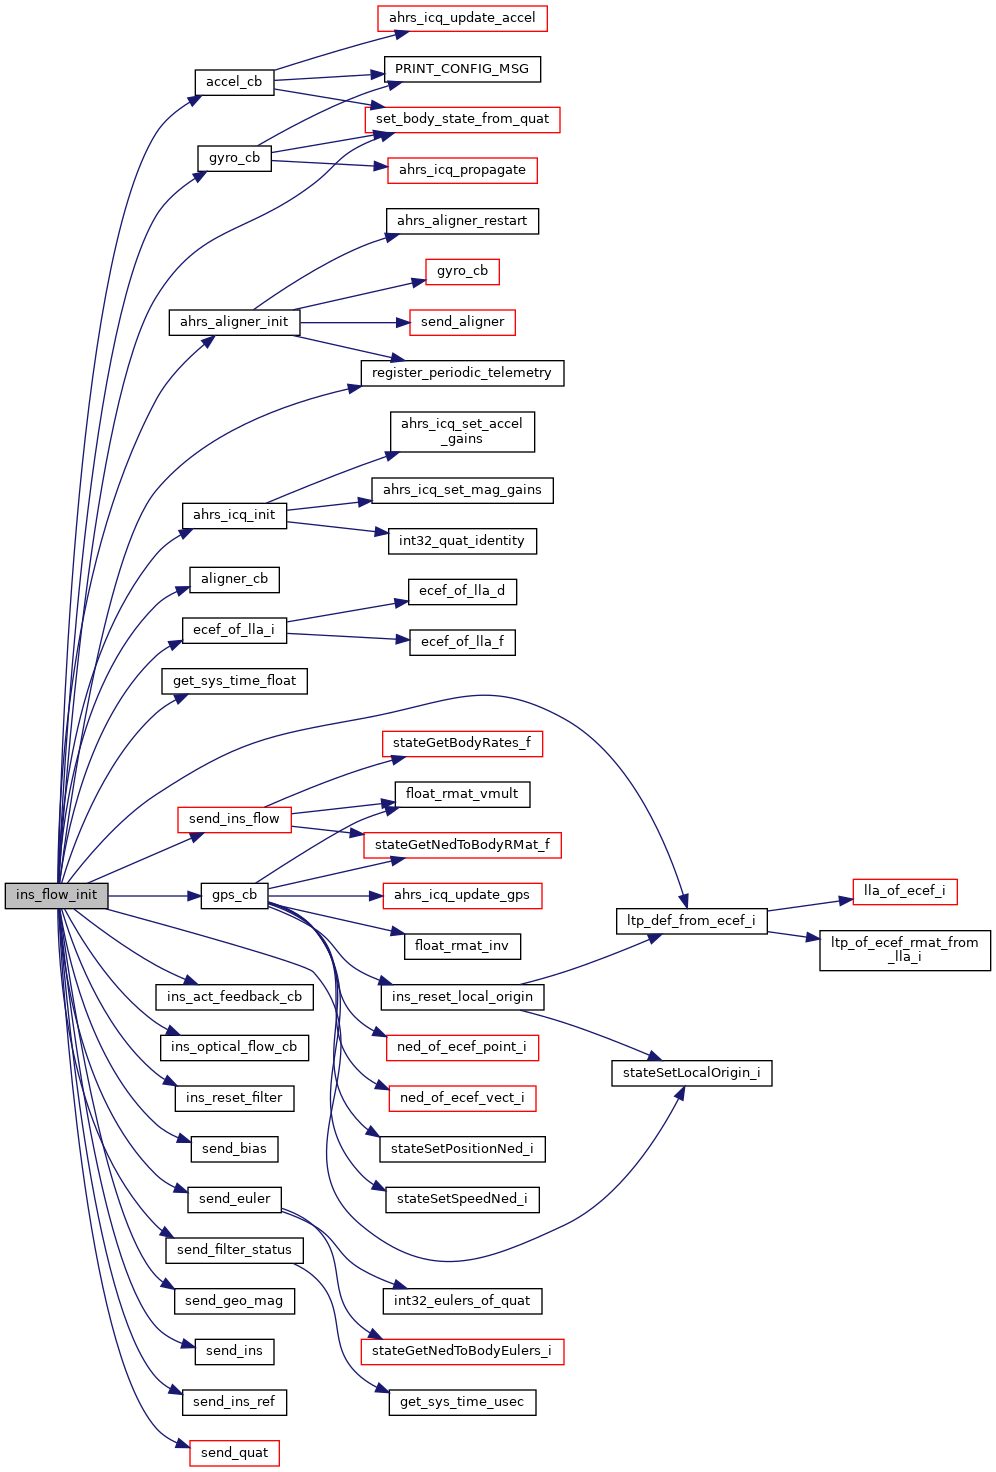
References ABI_BROADCAST, accel_cb(), accel_ev, ahrs_aligner_init(), ahrs_icq_init(), aligner_cb(), aligner_ev, LlaCoor_i::alt, CONSTANT_ALT_FILTER, DefaultPeriodic, E, ecef_of_lla_i(), get_sys_time_float(), gps_cb(), gps_ev, GT_phi, GT_theta, gyro_cb(), gyro_ev, ins_act_feedback_cb(), ins_act_feedback_ev, ins_flow, INS_FLOW_ACCEL_ID, INS_FLOW_GPS_ID, INS_FLOW_GYRO_ID, INS_FLOW_IMU_ID, ins_optical_flow_cb(), ins_optical_flow_ev, INS_OPTICAL_FLOW_ID, ins_reset_filter(), INS_RPM_ID, LlaCoor_i::lat, LlaCoor_i::lon, lp_factor, lp_factor_strong, ltp_def, ltp_def_from_ecef_i(), moment_ind, N_MEAS_OF_KF, OF_ANGLE_DOT_IND, OF_ANGLE_IND, OF_DIV_FLOW_IND, OF_LAT_FLOW_IND, OF_LAT_FLOW_X_IND, of_prev_time, OF_Q, OF_R, OF_RATE_IND, OF_THETA_IND, OF_THRUST_BIAS, OF_THRUST_BIAS_IND, of_time, OF_TWO_DIM, OF_V_IND, OF_VX_IND, OF_Z_DOT_IND, OF_Z_IND, PAR_K0, PAR_K1, PAR_K2, PAR_K3, PAR_Q0, PAR_Q1, PAR_Q2, PAR_Q3, PAR_Q4, PAR_Q_TB, PAR_R0, PAR_R1, parameters, register_periodic_telemetry(), reset_cb(), reset_ev, reset_filter, RPM_FACTORS, run_filter, send_bias(), send_euler(), send_filter_status(), send_geo_mag(), send_ins(), send_ins_flow(), send_ins_ref(), send_quat(), set_body_state_from_quat(), stateSetLocalOrigin_i(), and use_filter.
| void ins_flow_update | ( | void | ) |
Definition at line 726 of file ins_flow.c.
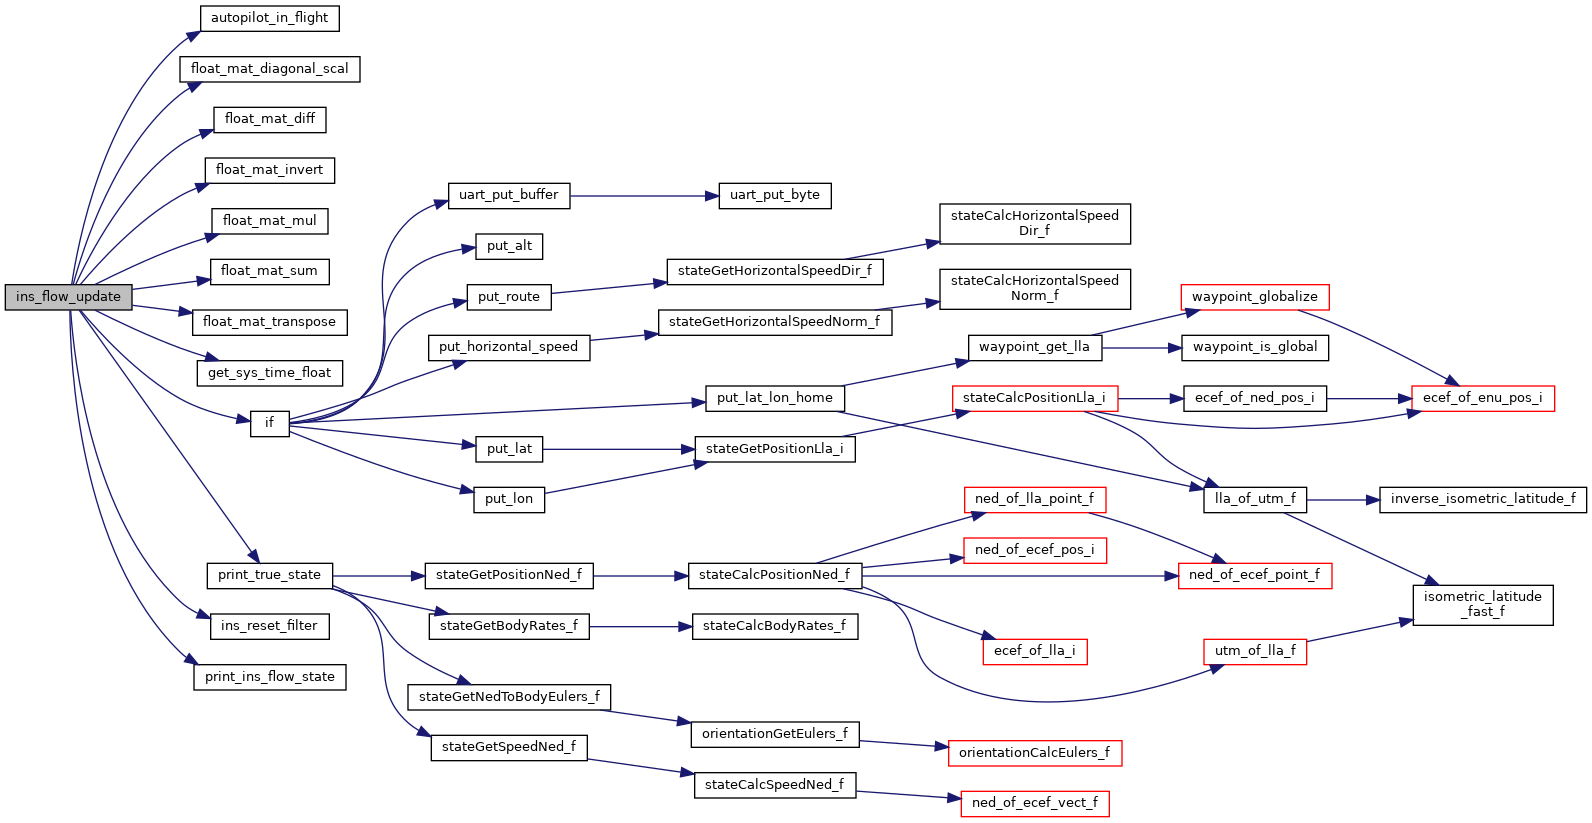
References autopilot_in_flight(), COMMAND_ROLL, CONSTANT_ALT_FILTER, DEBUG_INS_FLOW, DEBUG_MAT_PRINT, DEBUG_PRINT, E, float_mat_diagonal_scal(), float_mat_diff(), float_mat_invert(), float_mat_mul(), float_mat_sum(), float_mat_transpose(), g, get_sys_time_float(), H, ins_flow, ins_reset_filter(), K, lp_factor_strong, MAKE_MATRIX_PTR, N_MEAS_OF_KF, N_STATES_OF_KF, OF_ANGLE_DOT_IND, OF_ANGLE_IND, OF_DIV_FLOW_IND, OF_DRAG, OF_LAT_FLOW_IND, OF_LAT_FLOW_X_IND, OF_N_ROTORS, OF_P, of_prev_time, OF_Q, OF_R, OF_RATE_IND, OF_THETA_IND, OF_THRUST_BIAS, OF_THRUST_BIAS_IND, of_time, OF_TWO_DIM, OF_USE_GYROS, OF_V_IND, OF_VX_IND, OF_X, OF_Z_DOT_IND, OF_Z_IND, P, PAR_IX, PAR_KD, PAR_MASS, PAR_PRED_ROLL_3, parameters, PREDICT_GYROS, print_ins_flow_state(), print_true_state(), reset_filter, RPM_FACTORS, run_filter, stabilization, and thrust_factor.
| void ins_optical_flow_cb | ( | uint8_t sender_id | UNUSED, |
| uint32_t | stamp, | ||
| int32_t flow_x | UNUSED, | ||
| int32_t flow_y | UNUSED, | ||
| int32_t flow_der_x | UNUSED, | ||
| int32_t flow_der_y | UNUSED, | ||
| float quality | UNUSED, | ||
| float | size_divergence ) |
Definition at line 669 of file ins_flow.c.
References ins_flow, and UNUSED.
Referenced by ins_flow_init().
|
static |
Definition at line 489 of file ins_flow.c.
References CONSTANT_ALT_FILTER, counter, N_STATES_OF_KF, OF_ANGLE_DOT_IND, OF_ANGLE_IND, OF_P, OF_THETA_IND, OF_THRUST_BIAS, OF_THRUST_BIAS_IND, OF_TWO_DIM, OF_V_IND, OF_VX_IND, OF_X, OF_Z_DOT_IND, OF_Z_IND, PAR_P0, PAR_P1, PAR_P2, PAR_P3, PAR_P4, PAR_P_TB, and parameters.
Referenced by ins_flow_init(), and ins_flow_update().
|
static |
Definition at line 688 of file ins_flow.c.
References CONSTANT_ALT_FILTER, OF_ANGLE_DOT_IND, OF_ANGLE_IND, OF_THETA_IND, OF_THRUST_BIAS, OF_THRUST_BIAS_IND, OF_TWO_DIM, OF_V_IND, OF_VX_IND, OF_X, OF_Z_DOT_IND, and OF_Z_IND.
Referenced by ins_flow_update().
|
static |
Definition at line 713 of file ins_flow.c.
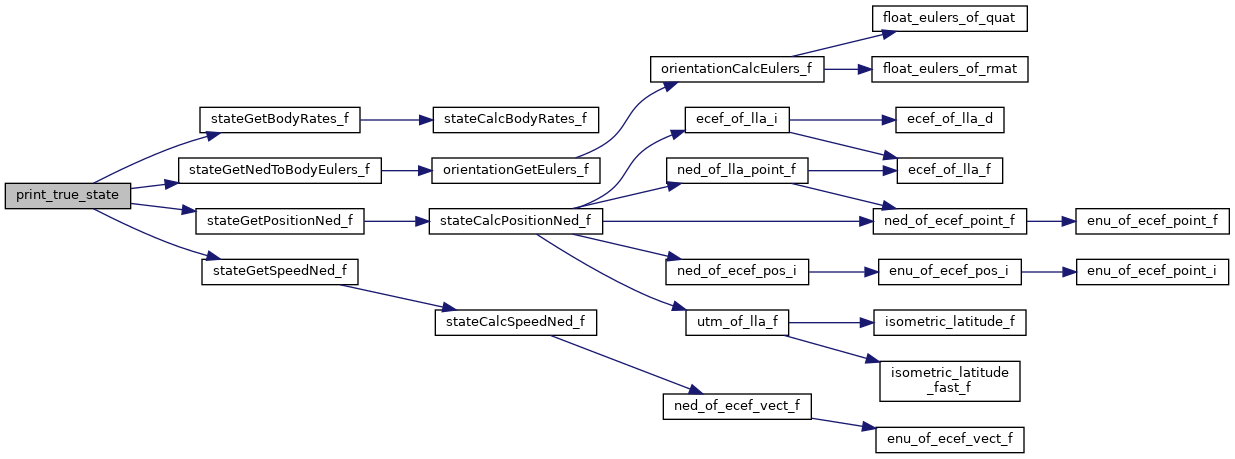
References FloatRates::p, FloatEulers::phi, stateGetBodyRates_f(), stateGetNedToBodyEulers_f(), stateGetPositionNed_f(), stateGetSpeedNed_f(), NedCoor_f::y, and NedCoor_f::z.
Referenced by ins_flow_update().
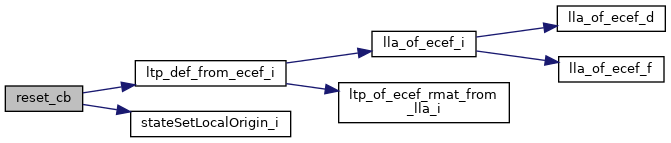
Definition at line 657 of file ins_flow.c.
References ecef_int_from_gps(), gps, ins_flow, INS_RESET_REF, ltp_def_from_ecef_i(), stateSetLocalOrigin_i(), and UNUSED.
Referenced by gps_cb().
|
static |
Definition at line 331 of file ins_flow.c.
References ahrs_flow_id, ahrs_icq, and dev.
|
static |
Definition at line 315 of file ins_flow.c.
References ahrs_flow_id, ahrs_icq, dev, int32_eulers_of_quat(), Int32Eulers::phi, Int32Eulers::psi, stateGetNedToBodyEulers_i(), and Int32Eulers::theta.
|
static |
Definition at line 348 of file ins_flow.c.
References ahrs_flow_id, ahrs_icq, ahrs_icq_last_stamp, dev, get_sys_time_usec(), and val.
|
static |
Definition at line 338 of file ins_flow.c.
References ahrs_flow_id, ahrs_icq, dev, MAG_FLOAT_OF_BFP, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
|
static |
Definition at line 360 of file ins_flow.c.
|
static |
Definition at line 390 of file ins_flow.c.
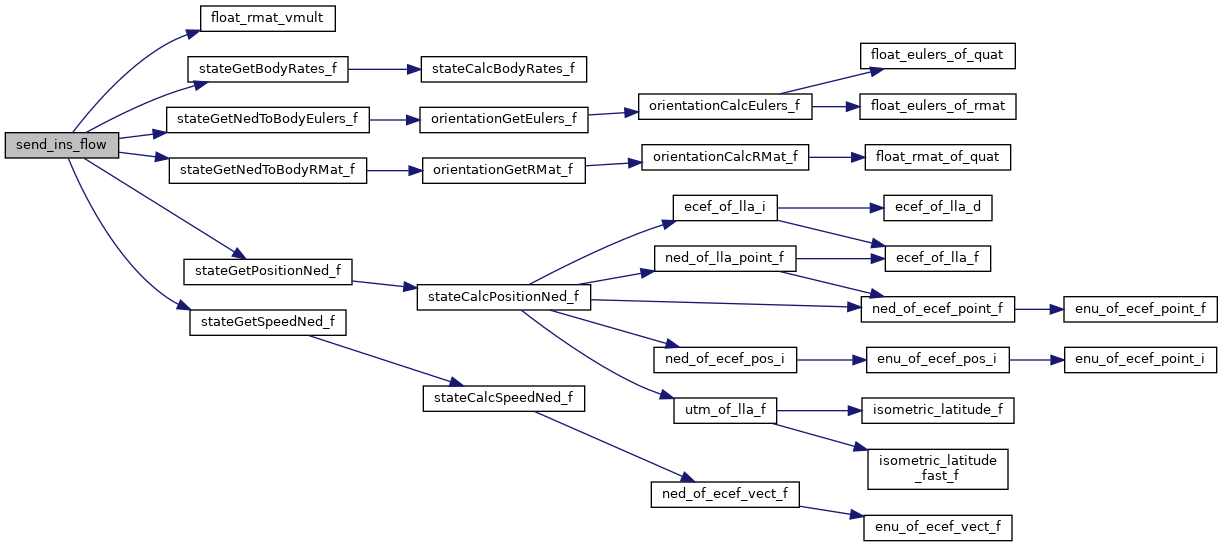
References CONSTANT_ALT_FILTER, dev, float_rmat_vmult(), g, GT_phi, GT_theta, ins_flow, OF_ANGLE_DOT_IND, OF_ANGLE_IND, OF_N_ROTORS, OF_THETA_IND, OF_THRUST_BIAS, OF_THRUST_BIAS_IND, OF_TWO_DIM, OF_V_IND, OF_VX_IND, OF_X, OF_Z_DOT_IND, OF_Z_IND, FloatRates::p, p, PAR_MASS, parameters, FloatEulers::phi, FloatRates::q, RPM_FACTORS, stateGetBodyRates_f(), stateGetNedToBodyEulers_f(), stateGetNedToBodyRMat_f(), stateGetPositionNed_f(), stateGetSpeedNed_f(), FloatEulers::theta, thrust_factor, USE_ANGLE, use_filter, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
Referenced by ins_flow_init().
|
static |
Definition at line 376 of file ins_flow.c.
|
static |
Definition at line 299 of file ins_flow.c.
References ahrs_flow_id, ahrs_icq, dev, Int32Quat::qi, Int32Quat::qx, Int32Quat::qy, Int32Quat::qz, and stateGetNedToBodyQuat_i().
|
static |
Rotate angles and rates from imu to body frame and set state.
Definition at line 1399 of file ins_flow.c.
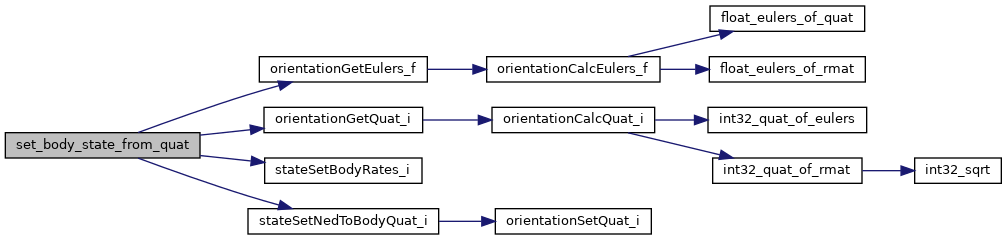
References ahrs_icq, OrientationReps::eulers_f, GT_phi, GT_theta, OF_ANGLE_IND, OF_THETA_IND, OF_TWO_DIM, OF_X, orientationGetEulers_f(), orientationGetQuat_i(), ORREP_EULER_F, ORREP_QUAT_I, FloatEulers::phi, OrientationReps::quat_i, stateSetBodyRates_i(), stateSetNedToBodyQuat_i(), OrientationReps::status, FloatEulers::theta, USE_ANGLE, and use_filter.
Referenced by accel_cb(), aligner_cb(), gyro_cb(), and ins_flow_init().
|
static |
Definition at line 105 of file ins_flow.c.
|
static |
Component ID for FLOW.
Definition at line 129 of file ins_flow.c.
Referenced by send_bias(), send_euler(), send_filter_status(), send_geo_mag(), and send_quat().
|
static |
Definition at line 128 of file ins_flow.c.
|
static |
Definition at line 109 of file ins_flow.c.
| uint32_t counter |
Definition at line 187 of file ins_flow.c.
Referenced by airspeed_otf_parse(), airspeed_uadc_parse(), airspeed_uADC_periodic(), gec_decrypt_message(), gec_encrypt_message(), ground_detect_periodic(), ins_mekf_wind_wrapper_init(), ins_reset_filter(), logger_file_start(), motor_mixing_run_spinup(), nav_fish_velocity_run(), open_log(), periodic_light(), run_avoid_navigation_onvision(), stereo_avoid_run(), and wind_estimator_init().
|
static |
Definition at line 106 of file ins_flow.c.
| float GT_phi |
Definition at line 190 of file ins_flow.c.
Referenced by ins_flow_init(), send_ins_flow(), and set_body_state_from_quat().
| float GT_theta |
Definition at line 191 of file ins_flow.c.
Referenced by ins_flow_init(), send_ins_flow(), and set_body_state_from_quat().
|
static |
Definition at line 104 of file ins_flow.c.
|
static |
Definition at line 108 of file ins_flow.c.
Referenced by ins_flow_init().
| struct InsFlow ins_flow |
Definition at line 164 of file ins_flow.c.
Referenced by gps_cb(), gyro_cb(), ins_act_feedback_cb(), ins_flow_init(), ins_flow_update(), ins_optical_flow_cb(), reset_cb(), send_ins(), send_ins_flow(), and send_ins_ref().
|
static |
Definition at line 107 of file ins_flow.c.
Referenced by ins_flow_init().
| float lp_factor |
Definition at line 182 of file ins_flow.c.
Referenced by gyro_cb(), horizontal_ctrl_module_run(), ins_flow_init(), PID_divergence_control(), PID_flow_control(), update_errors(), vertical_ctrl_module_run(), and vertical_ctrl_module_run().
| float lp_factor_strong |
Definition at line 183 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| int moment_ind |
Definition at line 170 of file ins_flow.c.
Referenced by ins_flow_init().
| float moments[MOMENT_DELAY] = {0.} |
Definition at line 169 of file ins_flow.c.
Referenced by evaluate_obm_moments(), and find_contour().
| float OF_P[N_STATES_OF_KF][N_STATES_OF_KF] = {{0.}} |
Definition at line 174 of file ins_flow.c.
Referenced by ins_flow_update(), and ins_reset_filter().
| float of_prev_time |
Definition at line 181 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float OF_Q[N_STATES_OF_KF][N_STATES_OF_KF] = {{0.}} |
Definition at line 173 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float OF_R[N_MEAS_OF_KF][N_MEAS_OF_KF] = {{0.}} |
Definition at line 175 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float of_time |
Definition at line 180 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float OF_X[N_STATES_OF_KF] = {0.} |
Definition at line 172 of file ins_flow.c.
Referenced by gps_cb(), ins_flow_update(), ins_reset_filter(), print_ins_flow_state(), send_ins_flow(), and set_body_state_from_quat().
| float parameters[22] = {0.219033, 0.376572, 0.184002, 0.096388, 0.240843, 0.172390, 0.133111, 0.495885, 0.357086, 0.233624, 0.125611, 1.661682, 0.136735, 2.812652, 0.715887, 0.166932, 0.371409, 1.043920, 0.840683, 0.567703, 0.192238, 0.301966} |
Definition at line 249 of file ins_flow.c.
Referenced by fit_linear_model(), fit_linear_model_OF(), fit_linear_model_prior(), ins_flow_init(), ins_flow_update(), ins_reset_filter(), and send_ins_flow().
|
static |
Definition at line 110 of file ins_flow.c.
| bool reset_filter |
Definition at line 184 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float RPM_FACTORS[OF_N_ROTORS] |
Definition at line 178 of file ins_flow.c.
Referenced by ins_flow_init(), ins_flow_update(), and send_ins_flow().
| bool run_filter |
Definition at line 186 of file ins_flow.c.
Referenced by ins_flow_init(), and ins_flow_update().
| float thrust_factor |
Definition at line 188 of file ins_flow.c.
Referenced by ins_flow_update(), and send_ins_flow().
| int use_filter |
Definition at line 185 of file ins_flow.c.
Referenced by gps_cb(), ins_flow_init(), send_ins_flow(), and set_body_state_from_quat().
 1.15.0