|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
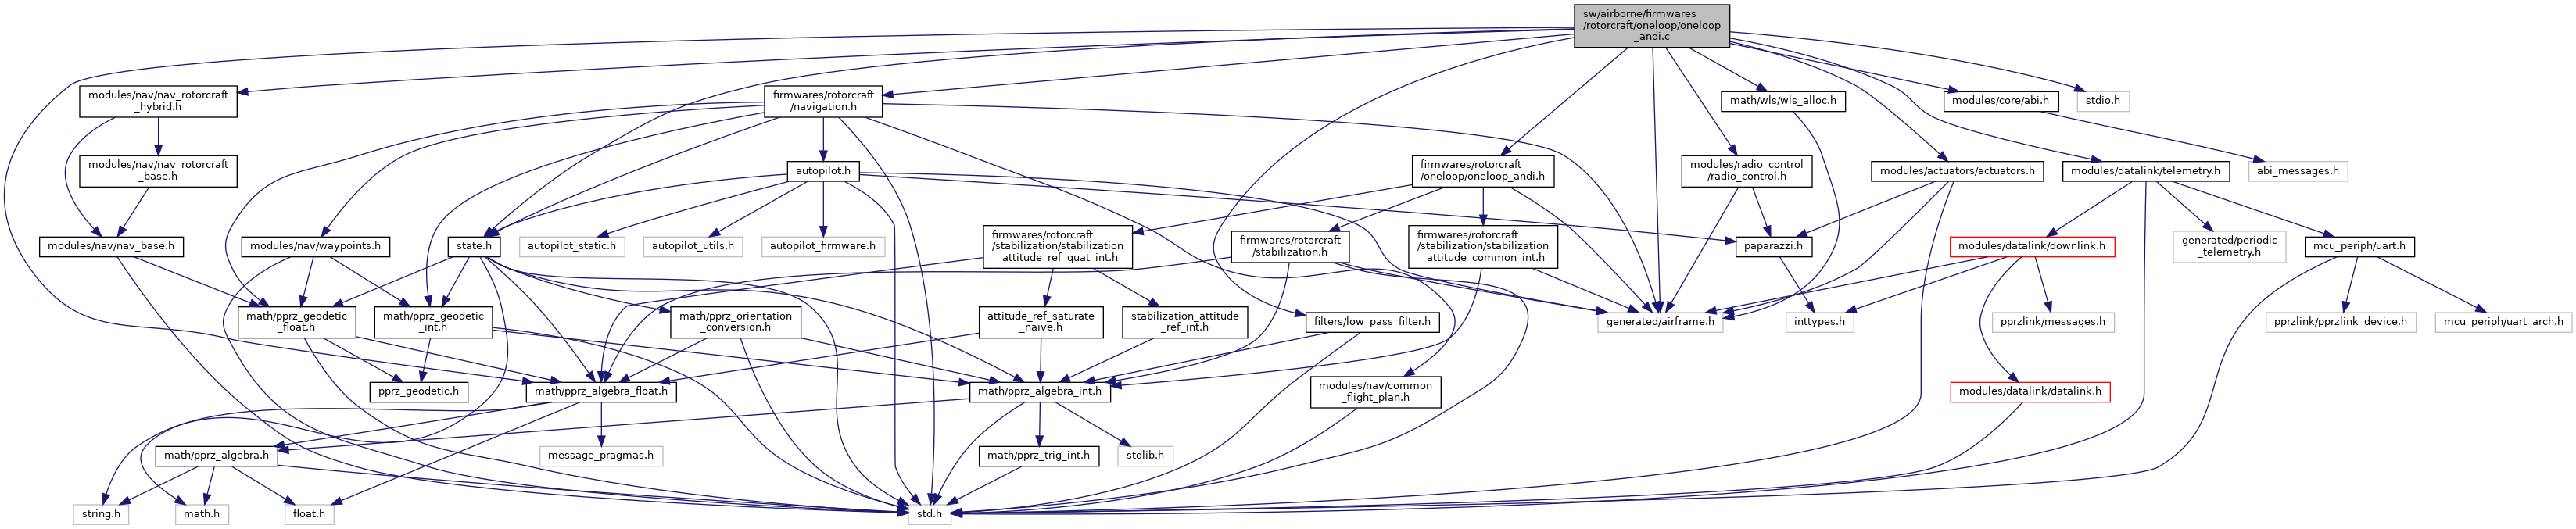
#include "firmwares/rotorcraft/oneloop/oneloop_andi.h"#include "math/pprz_algebra_float.h"#include "state.h"#include "generated/airframe.h"#include "modules/radio_control/radio_control.h"#include "modules/actuators/actuators.h"#include "modules/core/abi.h"#include "filters/low_pass_filter.h"#include "filters/notch_filter_float.h"#include "math/wls/wls_alloc.h"#include "modules/nav/nav_rotorcraft_hybrid.h"#include "firmwares/rotorcraft/navigation.h"#include "modules/rotwing_drone/rotwing_state.h"#include "modules/core/commands.h"#include "generated/modules.h"#include <stdio.h>#include "modules/datalink/telemetry.h"Go to the source code of this file.
Macros | |
| #define | ONELOOP_ANDI_DEBUG_MODE FALSE |
| #define | USE_BW2 |
| #define | USE_PID_NUMDIFF_DERIVATIVE |
| #define | ONELOOP_ANDI_MAX_BANK act_max[COMMAND_ROLL] |
| #define | ONELOOP_ANDI_MAX_PHI act_max[COMMAND_ROLL] |
| #define | ONELOOP_ANDI_MAX_THETA act_max[COMMAND_PITCH] |
| #define | ONELOOP_ANDI_AIRSPEED_SWITCH_THRESHOLD 10.0 |
| #define | USE_ND_VELOCITIES |
| #define | USE_PID_OUTERLOOP |
Functions | |
| PRINT_CONFIG_VAR (ONELOOP_ANDI_FILT_CUTOFF) | |
| PRINT_CONFIG_VAR (ONELOOP_ANDI_FILT_CUTOFF_Q) | |
| PRINT_CONFIG_VAR (ONELOOP_ANDI_FILT_CUTOFF_P) | |
| PRINT_CONFIG_VAR (ONELOOP_ANDI_FILT_CUTOFF_R) | |
| void | init_poles (void) |
| Initialize Position of Poles. | |
| void | calc_normalization (void) |
| Calculate Normalization of actuators and discrete actuator dynamics. | |
| void | normalize_nu (void) |
| Function to normalize the pseudo control vector. | |
| void | G1G2_oneloop (int ctrl_type) |
| Function that samples and scales the effectiveness matrix FIXME: make this function into a for loop to make it more adaptable to different configurations. | |
| void | get_act_state_oneloop (void) |
| Function to reconstruct actuator state using first order dynamics. | |
| void | oneloop_andi_propagate_filters (void) |
| Propagate the filters. | |
| void | init_filter (void) |
| Initialize the filters. | |
| void | init_controller_gains (void) |
| Initialize Controller Gains FIXME: Calculate the gains dynamically for transition. | |
| void | reinit_controller (void) |
| Re-Init function of controller variables. | |
| void | float_rates_of_euler_dot_vec (float r[3], float e[3], float edot[3]) |
| Attitude Rates to Euler Conversion Function ZYX. | |
| void | float_euler_dot_of_rates_vec (float r[3], float e[3], float edot[3]) |
| Attitude Euler to Rates Conversion Function ZYX. | |
| void | err_nd (float err[], float a[], float b[], float k[], int n) |
| Calculate Scaled Error between two 3D arrays. | |
| void | err_sum_nd (float err[], float a[], float b[], float k[], float c[], int n) |
| Calculate Scaled Error between two 3D arrays. | |
| void | float_vect_diff_euler (float err[3], float a[3], float b[3]) |
| Calculate Error between two 3D euler arrays with the psi normalized. | |
| void | integrate_nd (float dt, float a[], float a_dot[], int n) |
| Integrate in time 3D array. | |
| void | vect_bound_nd (float vect[], float bound, int n) |
| Scale a 3D array to within a 3D bound. | |
| void | acc_body_bound (struct FloatVect2 *vect, float bound) |
| Scale a 3D array to within a 3D bound. | |
| float | bound_v_from_a_vect (float e_x[], float v_bound, float a_bound, int n) |
| Calculate velocity limit based on acceleration limit for a vector From SUVAT we have that v^2 = u^2 + 2*a*s. | |
| float | bound_v_from_a (float e_x, float v_bound, float a_bound) |
| Calculate velocity limit based on acceleration limit for a float From SUVAT we have that v^2 = u^2 + 2*a*s. | |
| void | rm_3rd_attitude (float dt, float x_ref[3], float x_d_ref[3], float x_2d_ref[3], float x_3d_ref[3], float x_des[3], bool ow_psi, float psi_overwrite[4], float k1_rm[3], float k2_rm[3], float k3_rm[3], struct OneloopStabilizationRef bounds) |
| Reference Model Definition for 3rd order system with attitude conversion functions. | |
| void | rm_3rd_pos (float dt, float x_ref[], float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x_des[], float k1_rm[], float k2_rm[], float k3_rm[], float x_d_bound, float x_2d_bound, float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | rm_2nd_pos (float dt, float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x_d_des[], float k2_rm[], float k3_rm[], float x_2d_bound, float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | rm_1st_pos (float dt, float x_2d_ref[], float x_3d_ref[], float x_2d_des[], float k3_rm[], float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | ec_3rd_att (float y_4d[3], float x_des[3], float x_ref[3], float x_d_ref[3], float x_2d_ref[3], float x_3d_ref[3], float x[3], float x_d[3], float x_2d[3], float k1_e[3], float k2_e[3], float k3_e[3], struct OneloopStabilizationRef bounds, float fb[3]) |
| Error Controller Definition for 3rd order system specific to attitude. | |
| void | ec_3rd_pos (float y_4d[], float x_des[], float x_ref[], float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x[], float x_d[], float x_2d[], float k1_e[], float k2_e[], float k3_e[], float x_d_bound, float x_2d_bound, float fb[], int n) |
| Error Controller Definition for 3rd order system. | |
| float | oneloop_andi_sideslip (void) |
| Function to calculate corrections for sideslip. | |
| void | reshape_wind (void) |
| void | chirp_pos (float time_elapsed, float f0, float f1, float t_chirp, float A, int8_t n, float psi, float p_ref[], float v_ref[], float a_ref[], float j_ref[], float p_ref_0[]) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | chirp_call (bool *chirp_on, bool *chirp_first_call, float *t_0_chirp, float *time_elapsed, float f0, float f1, float t_chirp, float A, int8_t n, float psi, float p_ref[], float v_ref[], float a_ref[], float j_ref[], float p_ref_0[]) |
| void | oneloop_axis_effectiveness_calc (void) |
| void | oneloop_andi_bound_disturbance (void) |
| void | oneloop_calc_model_disturbance (bool in_flight) |
| Function that calculates the model disturbance (Control Effort) The control effort is equalt to : EFF_MAT*u_filt where EFF_MAT is what is inverted and u_filt is the filtered actuator state. | |
| void | dynFilter_init (struct Oneloop_DynFilt_t *mu, float varepsilon, float sigma) |
| void | dynFilter_run (struct Oneloop_DynFilt_t *mu, float u_c, float sigma) |
| static void | send_wls_v_oneloop (struct transport_tx *trans, struct link_device *dev) |
| static void | send_wls_u_oneloop (struct transport_tx *trans, struct link_device *dev) |
| static void | send_eff_mat_stab_oneloop_andi (struct transport_tx *trans, struct link_device *dev) |
| static void | send_eff_mat_guid_oneloop_andi (struct transport_tx *trans, struct link_device *dev) |
| static void | send_oneloop_andi (struct transport_tx *trans, struct link_device *dev) |
| static void | send_guidance_oneloop_andi (struct transport_tx *trans, struct link_device *dev) |
| static void | debug_vect (struct transport_tx *trans, struct link_device *dev, char *name, float *data, int datasize) |
| static void | send_oneloop_debug (struct transport_tx *trans, struct link_device *dev) |
| static float | positive_non_zero (float input) |
| Function to make sure that inputs are positive non zero vaues. | |
| static float | k_rm_1_3_f (float omega_n, float zeta, float p1) |
| Reference Model Gain Design. | |
| static float | k_rm_2_3_f (float omega_n, float zeta, float p1) |
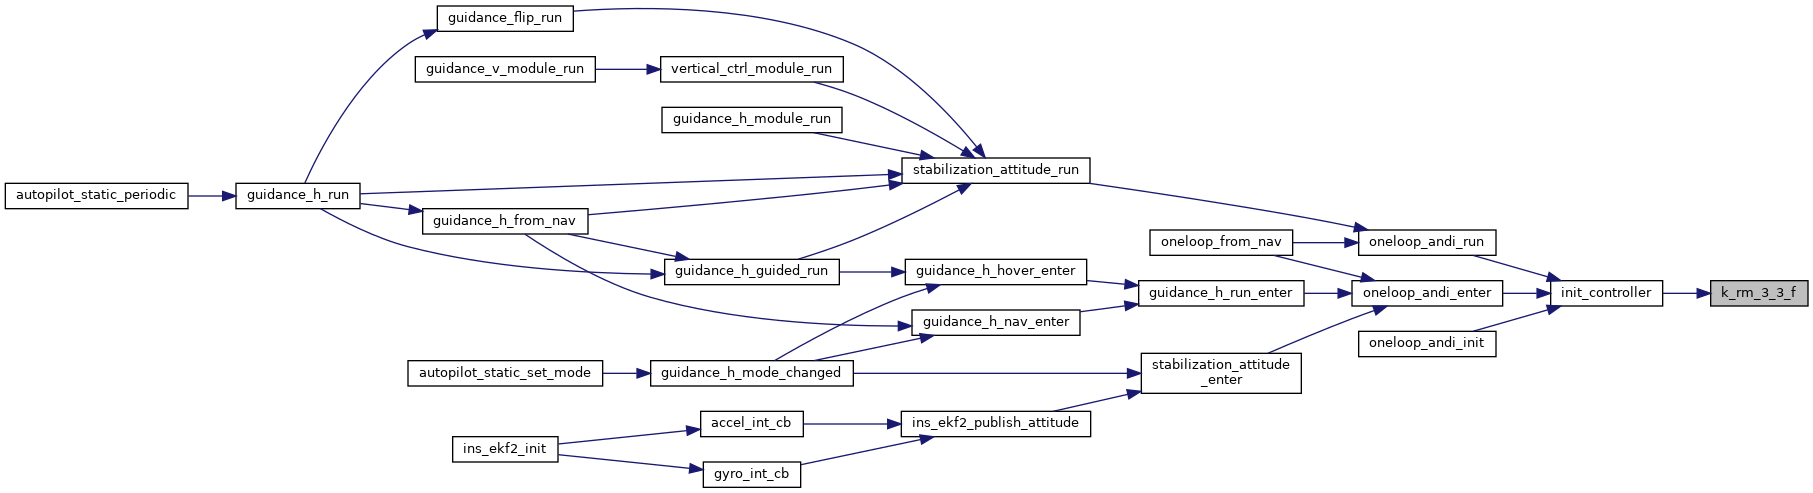
| static float | k_rm_3_3_f (float omega_n, float zeta, float p1) |
| static void | Pos_PID (float x_des[3], float x[3], float x_dot[3], float k_P, float k_I, float k_D, float a[3]) |
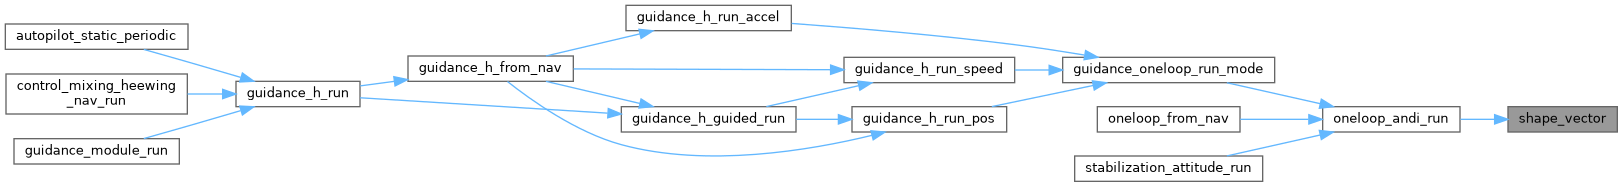
| static void | shape_vector (float a[3]) |
| static void | eul_of_acc (float a[3], float psi) |
| static float | w_approx (float p1, float p2, float p3, float rm_k) |
| Third Order to First Order Dynamics Approximation. | |
| static void | init_filter_on_type (struct LP_t *filter, float x0) |
| Initialize a filter based on its type. | |
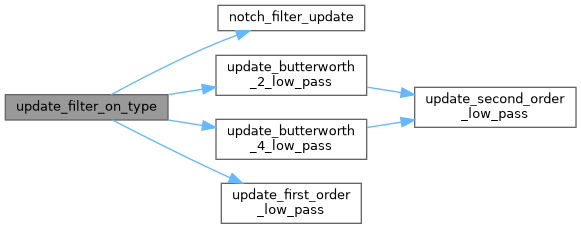
| static void | update_filter_on_type (struct LP_t *filter, float input) |
| Update a filter based on its type. | |
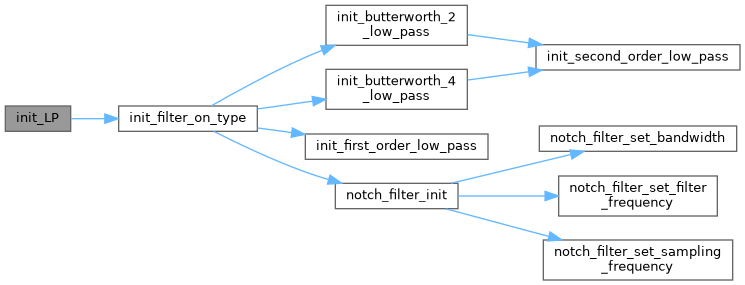
| static void | init_LP (struct LP_t *LP, float fc) |
| Initialize the Low Pass Filter Struct. | |
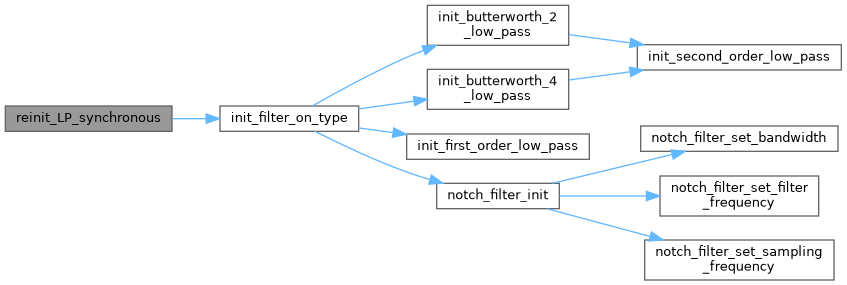
| static void | reinit_LP_synchronous (struct LP_t *LP, struct LP_t *f, bool reinit) |
| Reinitialize Low Pass filter if new frequency setting or if forced. | |
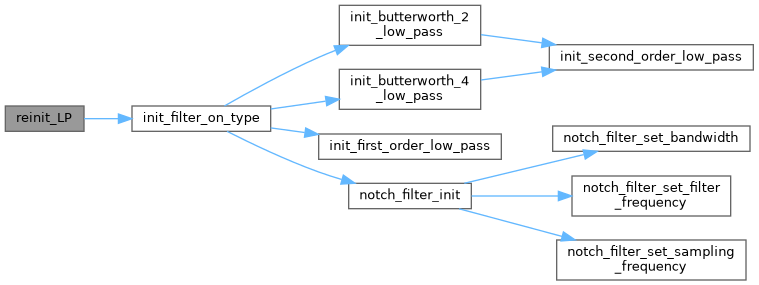
| static void | reinit_LP (struct LP_t *LP, bool reinit) |
| static void | init_all_LP (void) |
| Initialize all Low Pass Filters. | |
| static void | reinit_all_LP (bool reinit) |
| Reinitialize all the Low Pass Filters. | |
| void | oneloop_andi_init (void) |
| Init function of Oneloop ANDI controller. | |
| void | oneloop_andi_enter (bool half_loop_sp, int ctrl_type) |
| Function that resets important values upon engaging Oneloop ANDI. | |
| void | oneloop_andi_RM (bool half_loop, struct FloatVect3 PSA_des, int rm_order_h, int rm_order_v, bool in_flight_oneloop) |
| Function to generate the reference signals for the oneloop controller. | |
| void | oneloop_andi_run (bool in_flight, bool half_loop, struct FloatVect3 PSA_des, int rm_order_h, int rm_order_v) |
| Main function that runs the controller and performs control allocation. | |
| void | oneloop_from_nav (bool in_flight) |
| Function that maps navigation inputs to the oneloop controller for the generated autopilot. | |
| static float | chirp_pos_p_ref (float delta_t, float f0, float k, float A) |
| Function to calculate the position reference during the chirp. | |
| static float | chirp_pos_v_ref (float delta_t, float f0, float k, float A) |
| Function to calculate the velocity reference during the chirp. | |
| static float | chirp_pos_a_ref (float delta_t, float f0, float k, float A) |
| Function to calculate the acceleration reference during the chirp. | |
| static float | chirp_pos_j_ref (float delta_t, float f0, float k, float A) |
| Function to calculate the jerk reference during the chirp. | |
| bool | autopilot_in_flight_end_detection (bool motors_on UNUSED) |
| Quadplanes can still be in-flight with COMMAND_THRUST==0 and can even soar not descending in updrafts with all thrust off. | |
| void | guidance_set_min_max_airspeed (float min_airspeed, float max_airspeed) |
| void | guidance_set_max_bank_angle (float max_bank) |
| Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid). | |
| void | guidance_set_max_climb_speed (float max_climb_speed_quad, float max_climb_speed_fwd) |
| void | guidance_set_max_descend_speed (float max_descend_speed_quad, float max_descend_speed_fwd) |
| #define ONELOOP_ANDI_AIRSPEED_SWITCH_THRESHOLD 10.0 |
Definition at line 372 of file oneloop_andi.c.
Referenced by reshape_wind().
| #define ONELOOP_ANDI_DEBUG_MODE FALSE |
Definition at line 129 of file oneloop_andi.c.
Referenced by oneloop_andi_run().
| #define ONELOOP_ANDI_MAX_BANK act_max[COMMAND_ROLL] |
Definition at line 265 of file oneloop_andi.c.
Referenced by init_controller_gains(), and oneloop_andi_sideslip().
| #define ONELOOP_ANDI_MAX_PHI act_max[COMMAND_ROLL] |
Definition at line 266 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and oneloop_andi_run().
| #define ONELOOP_ANDI_MAX_THETA act_max[COMMAND_PITCH] |
Definition at line 267 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and oneloop_andi_run().
| #define USE_BW2 |
Definition at line 138 of file oneloop_andi.c.
| #define USE_ND_VELOCITIES |
Definition at line 405 of file oneloop_andi.c.
| #define USE_PID_NUMDIFF_DERIVATIVE |
Definition at line 198 of file oneloop_andi.c.
| #define USE_PID_OUTERLOOP |
| void acc_body_bound | ( | struct FloatVect2 * | vect, |
| float | bound ) |
Scale a 3D array to within a 3D bound.
Definition at line 886 of file oneloop_andi.c.
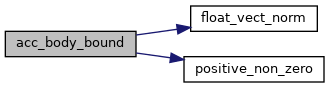
References float_vect_norm(), Min, positive_non_zero(), FloatVect2::x, and FloatVect2::y.
Referenced by reshape_wind().
| bool autopilot_in_flight_end_detection | ( | bool motors_on | UNUSED | ) |
Quadplanes can still be in-flight with COMMAND_THRUST==0 and can even soar not descending in updrafts with all thrust off.
Definition at line 2852 of file oneloop_andi.c.
References UNUSED.
| float bound_v_from_a | ( | float | e_x, |
| float | v_bound, | ||
| float | a_bound ) |
Calculate velocity limit based on acceleration limit for a float From SUVAT we have that v^2 = u^2 + 2*a*s.
Assuming a is constant we can calculate the velocity bound given the position error and the acceleration limit. This bounding also assumes that we want to arrive at the waypoint with zero velocity which might be untrue.
| e_x | Error in Position (always wrt the Desired) |
| v_bound | Safety bound on velocity |
| a_bound | Acceleration limit |
| n | Size of vector |
Definition at line 931 of file oneloop_andi.c.
References xdot_lim_sf.
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| float bound_v_from_a_vect | ( | float | e_x[], |
| float | v_bound, | ||
| float | a_bound, | ||
| int | n ) |
Calculate velocity limit based on acceleration limit for a vector From SUVAT we have that v^2 = u^2 + 2*a*s.
Assuming a is constant we can calculate the velocity bound given the position error and the acceleration limit. This bounding also assumes that we want to arrive at the waypoint with zero velocity which might be untrue.
| e_x | Error in Position (always wrt the Desired) |
| v_bound | Safety bound on velocity |
| a_bound | Acceleration limit |
| n | Size of vector |
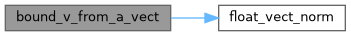
Definition at line 915 of file oneloop_andi.c.
References float_vect_norm(), and xdot_lim_sf.
Referenced by ec_3rd_pos(), and rm_3rd_pos().
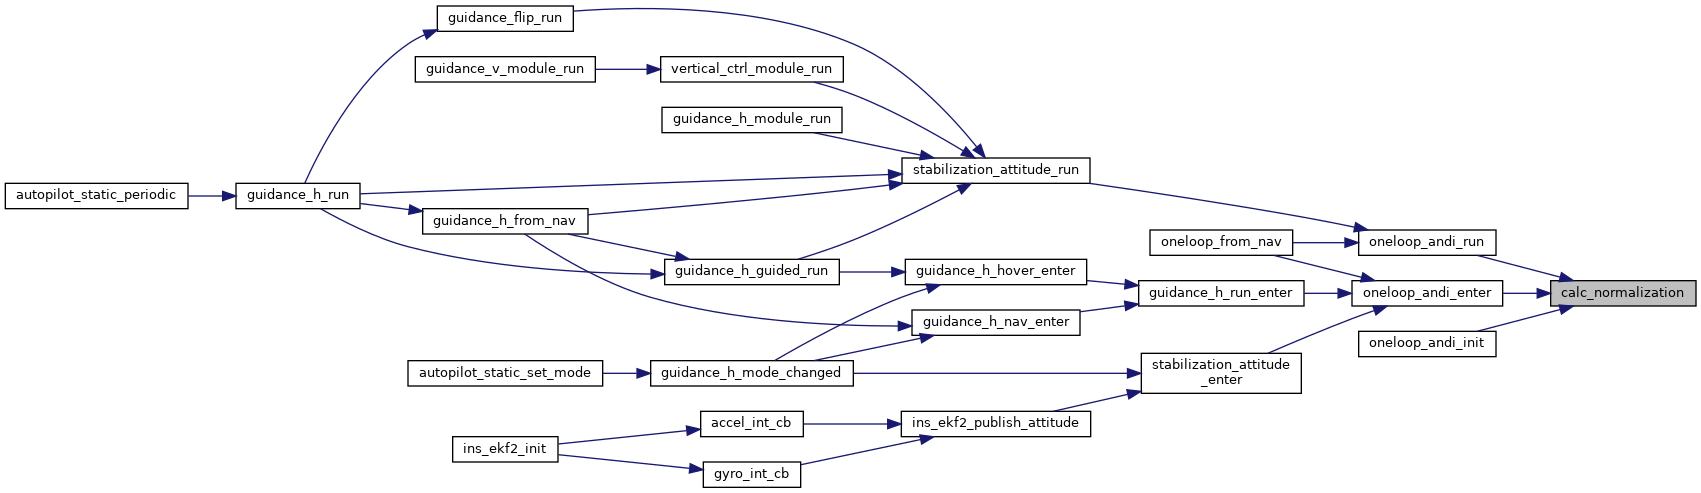
| void calc_normalization | ( | void | ) |
Calculate Normalization of actuators and discrete actuator dynamics.
Definition at line 2509 of file oneloop_andi.c.
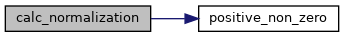
References act_dynamics, act_dynamics_d, act_max, act_max_norm, act_min, act_min_norm, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, dt_1l, max_j_lin, MAX_PPRZ, nu_norm_max, positive_non_zero(), ratio_u_un, ratio_vn_v, RW_aD, RW_aE, RW_aN, RW_ap, RW_aq, RW_ar, and sta_bounds.
Referenced by oneloop_andi_enter(), oneloop_andi_init(), and oneloop_andi_run().
| void chirp_call | ( | bool * | chirp_on, |
| bool * | chirp_first_call, | ||
| float * | t_0_chirp, | ||
| float * | time_elapsed, | ||
| float | f0, | ||
| float | f1, | ||
| float | t_chirp, | ||
| float | A, | ||
| int8_t | n, | ||
| float | psi, | ||
| float | p_ref[], | ||
| float | v_ref[], | ||
| float | a_ref[], | ||
| float | j_ref[], | ||
| float | p_ref_0[] ) |
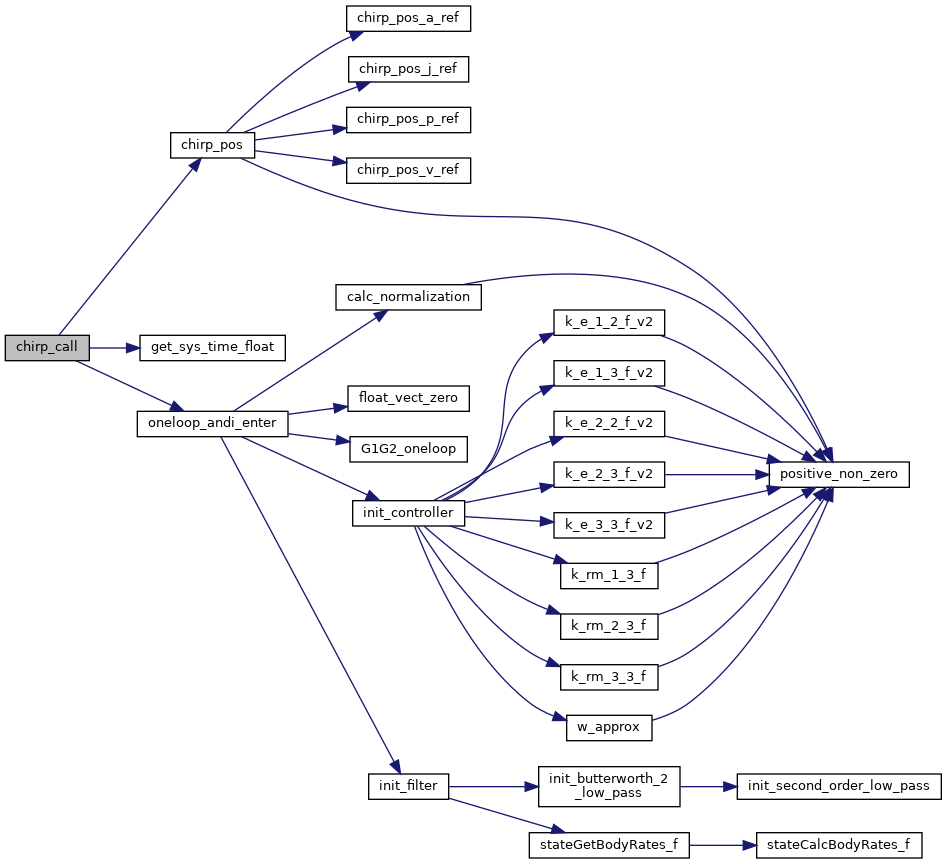
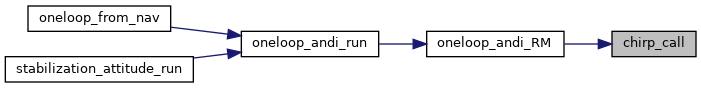
Definition at line 2810 of file oneloop_andi.c.
References A, chirp_first_call, chirp_on, chirp_pos(), drop_aD, drop_aE, drop_aN, drop_pitch, drop_roll, drop_yaw, float_vect_zero(), get_sys_time_float(), p_ref_0, and t_chirp.
Referenced by oneloop_andi_RM().
| void chirp_pos | ( | float | time_elapsed, |
| float | f0, | ||
| float | f1, | ||
| float | t_chirp, | ||
| float | A, | ||
| int8_t | n, | ||
| float | psi, | ||
| float | p_ref[], | ||
| float | v_ref[], | ||
| float | a_ref[], | ||
| float | j_ref[], | ||
| float | p_ref_0[] ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | [s] time passed since start of the chirp |
| f0 | [Hz] initial frequency of the chirp |
| f1 | [Hz] final frequency of the chirp |
| t_chirp | [s] duration of the chirp |
| p_ref | [m] position reference |
| v_ref | [m/s] velocity reference |
| a_ref | [m/s2] acceleration reference |
| j_ref | [m/s3] jerk reference |
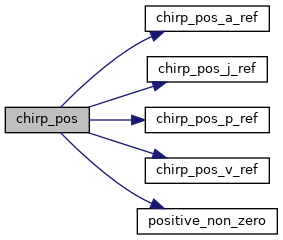
Definition at line 2676 of file oneloop_andi.c.
References A, chirp_pos_a_ref(), chirp_pos_j_ref(), chirp_pos_p_ref(), chirp_pos_v_ref(), drop_aE, drop_aN, oneloop_andi, oneloop_andi_sigma, oneloop_andi_sigma_max, oneloop_andi_sigma_min, p_ref_0, pitch_pref, positive_non_zero(), psi_des_rad, t_chirp, and theta_pref_max.
Referenced by chirp_call().
|
static |
Function to calculate the acceleration reference during the chirp.
Definition at line 2653 of file oneloop_andi.c.
References A.
Referenced by chirp_pos().
|
static |
Function to calculate the jerk reference during the chirp.
Definition at line 2659 of file oneloop_andi.c.
References A.
Referenced by chirp_pos().
|
static |
Function to calculate the position reference during the chirp.
Definition at line 2641 of file oneloop_andi.c.
References A.
Referenced by chirp_pos().
|
static |
Function to calculate the velocity reference during the chirp.
Definition at line 2647 of file oneloop_andi.c.
References A.
Referenced by chirp_pos().
|
static |
Definition at line 656 of file oneloop_andi.c.
References dev.
Referenced by send_oneloop_debug().
| void dynFilter_init | ( | struct Oneloop_DynFilt_t * | mu, |
| float | varepsilon, | ||
| float | sigma ) |
Definition at line 3093 of file oneloop_andi.c.
References Oneloop_DynFilt_t::fs, Oneloop_DynFilt_t::mu_c, Oneloop_DynFilt_t::mu_c_0, Oneloop_DynFilt_t::sigma, Oneloop_DynFilt_t::u_c, Oneloop_DynFilt_t::u_c_0, and Oneloop_DynFilt_t::varepsilon.
Referenced by oneloop_andi_init().
| void dynFilter_run | ( | struct Oneloop_DynFilt_t * | mu, |
| float | u_c, | ||
| float | sigma ) |
Definition at line 3077 of file oneloop_andi.c.
References Oneloop_DynFilt_t::fs, Oneloop_DynFilt_t::mu_c, Oneloop_DynFilt_t::mu_c_0, Oneloop_DynFilt_t::sigma, Oneloop_DynFilt_t::u_c, Oneloop_DynFilt_t::u_c_0, and Oneloop_DynFilt_t::varepsilon.
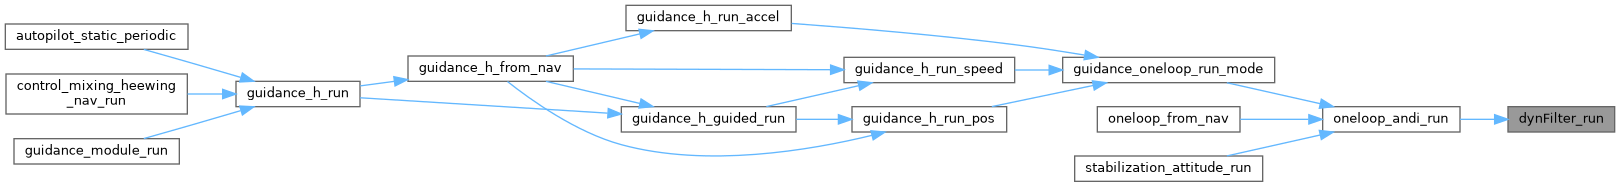
Referenced by oneloop_andi_run().
| void ec_3rd_att | ( | float | y_4d[3], |
| float | x_des[3], | ||
| float | x_ref[3], | ||
| float | x_d_ref[3], | ||
| float | x_2d_ref[3], | ||
| float | x_3d_ref[3], | ||
| float | x[3], | ||
| float | x_d[3], | ||
| float | x_2d[3], | ||
| float | k1_e[3], | ||
| float | k2_e[3], | ||
| float | k3_e[3], | ||
| struct OneloopStabilizationRef | bounds, | ||
| float | fb[3] ) |
Error Controller Definition for 3rd order system specific to attitude.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| x | Current 1st order signal |
| x_d | Current 2nd order signal |
| x_2d | Current 3rd order signal |
| k1_e | Error Controller Gain 1st order signal |
| k2_e | Error Controller Gain 2nd order signal |
| k3_e | Error Controller Gain 3rd order signal |
Definition at line 1131 of file oneloop_andi.c.
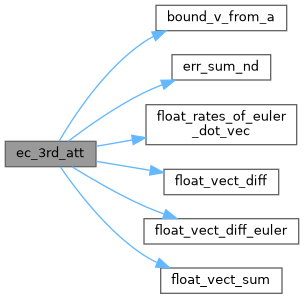
References OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_d, bound_v_from_a(), ec_headroom, err_sum_nd(), float_rates_of_euler_dot_vec(), float_vect_diff(), float_vect_diff_euler(), and float_vect_sum().
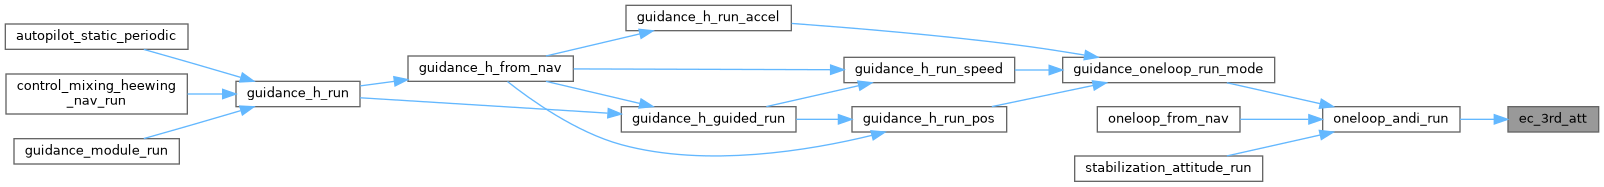
Referenced by oneloop_andi_run().
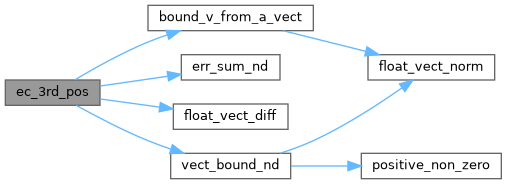
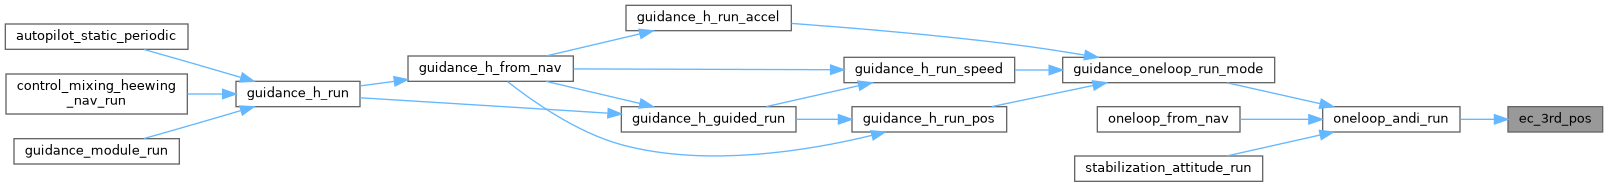
| void ec_3rd_pos | ( | float | y_4d[], |
| float | x_des[], | ||
| float | x_ref[], | ||
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x[], | ||
| float | x_d[], | ||
| float | x_2d[], | ||
| float | k1_e[], | ||
| float | k2_e[], | ||
| float | k3_e[], | ||
| float | x_d_bound, | ||
| float | x_2d_bound, | ||
| float | fb[], | ||
| int | n ) |
Error Controller Definition for 3rd order system.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| x | Current 1st order signal |
| x_d | Current 2nd order signal |
| x_2d | Current 3rd order signal |
| k1_e | Error Controller Gain 1st order signal |
| k2_e | Error Controller Gain 2nd order signal |
| k3_e | Error Controller Gain 3rd order signal |
Definition at line 1099 of file oneloop_andi.c.
References bound_v_from_a_vect(), ec_headroom, err_sum_nd(), float_vect_diff(), and vect_bound_nd().
Referenced by oneloop_andi_run().
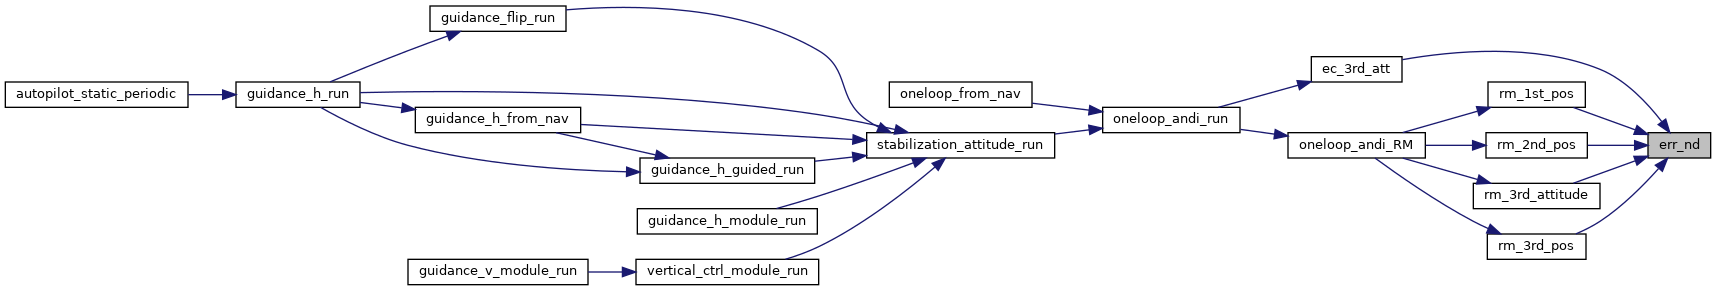
| void err_nd | ( | float | err[], |
| float | a[], | ||
| float | b[], | ||
| float | k[], | ||
| int | n ) |
Calculate Scaled Error between two 3D arrays.
Definition at line 697 of file oneloop_andi.c.
References b.
Referenced by rm_1st_pos(), rm_2nd_pos(), rm_3rd_attitude(), and rm_3rd_pos().
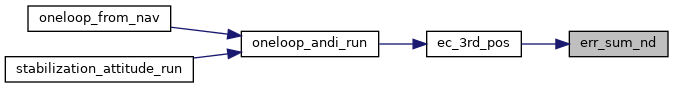
| void err_sum_nd | ( | float | err[], |
| float | a[], | ||
| float | b[], | ||
| float | k[], | ||
| float | c[], | ||
| int | n ) |
Calculate Scaled Error between two 3D arrays.
Definition at line 705 of file oneloop_andi.c.
References b.
Referenced by ec_3rd_att(), and ec_3rd_pos().
|
static |
Definition at line 803 of file oneloop_andi.c.
References eulers_zxy_des.
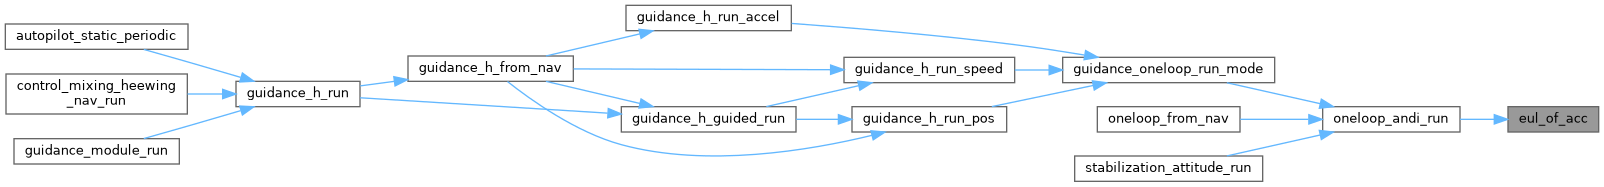
Referenced by oneloop_andi_run().
| void float_euler_dot_of_rates_vec | ( | float | r[3], |
| float | e[3], | ||
| float | edot[3] ) |
Attitude Euler to Rates Conversion Function ZYX.
Attitude Euler to Rates Conversion Function ZXY
Definition at line 866 of file oneloop_andi.c.
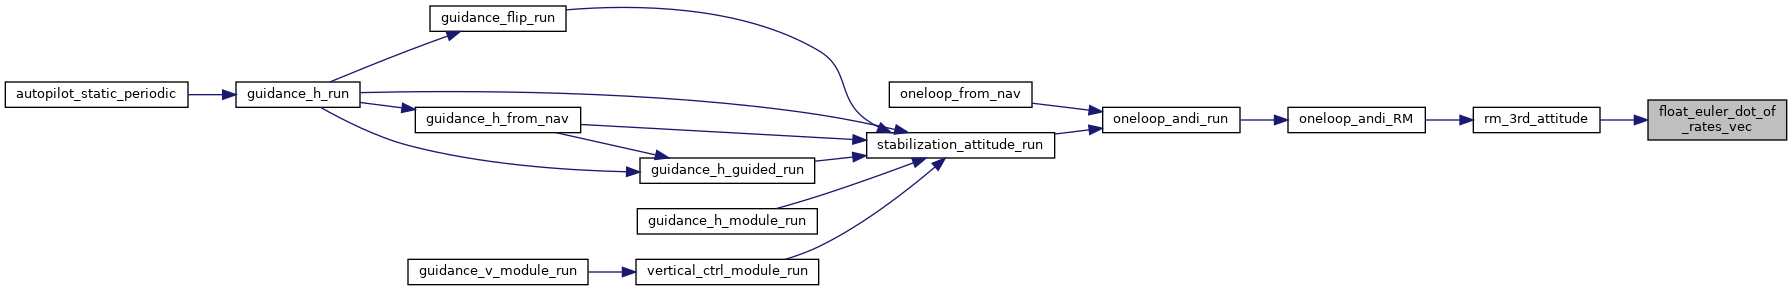
Referenced by rm_3rd_attitude().
| void float_rates_of_euler_dot_vec | ( | float | r[3], |
| float | e[3], | ||
| float | edot[3] ) |
Attitude Rates to Euler Conversion Function ZYX.
Attitude Rates to Euler Conversion Function ZXY
Definition at line 838 of file oneloop_andi.c.
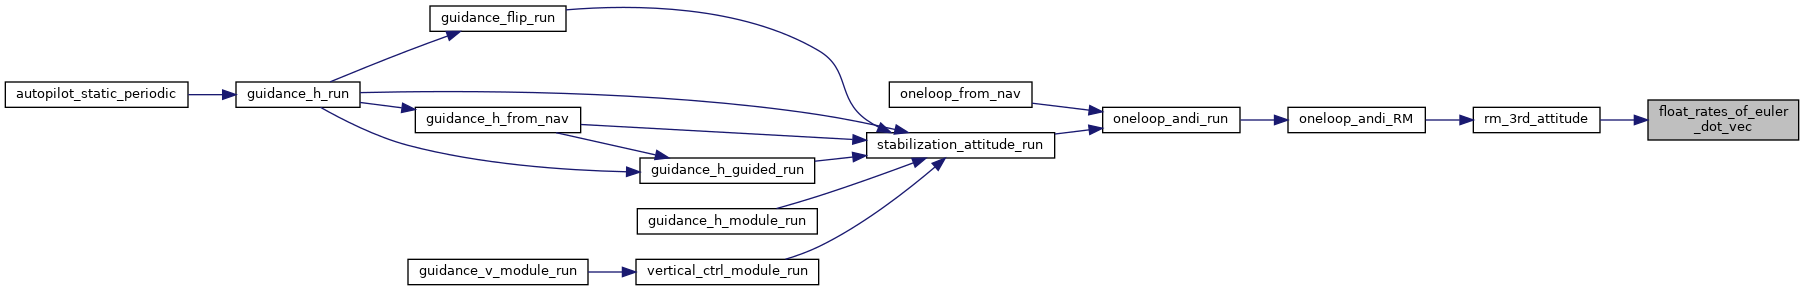
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| void float_vect_diff_euler | ( | float | err[3], |
| float | a[3], | ||
| float | b[3] ) |
Calculate Error between two 3D euler arrays with the psi normalized.
Definition at line 714 of file oneloop_andi.c.
References b.
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| void G1G2_oneloop | ( | int | ctrl_type | ) |
Function that samples and scales the effectiveness matrix FIXME: make this function into a for loop to make it more adaptable to different configurations.
Definition at line 2419 of file oneloop_andi.c.
References act_dyn_ctrl, airspeed_filt, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, COMMAND_PITCH, COMMAND_ROLL, CTRL_ANDI, CTRL_INDI, ctrl_off, drop_yaw, EFF_MAT_G, EFF_MAT_RW, ELE_MIN_AS, oneloop_axis_effectiveness_calc(), ratio_u_un, ratio_vn_v, rotwing_state, ROTWING_STATE_FORCE_HOVER, and rotwing_state_hover_motors_running().
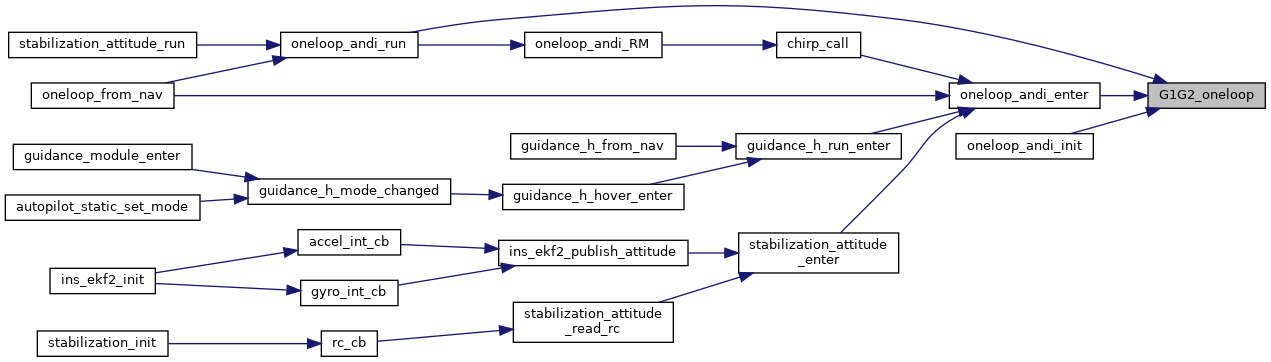
Referenced by oneloop_andi_enter(), oneloop_andi_init(), and oneloop_andi_run().
| void get_act_state_oneloop | ( | void | ) |
Function to reconstruct actuator state using first order dynamics.
Definition at line 2348 of file oneloop_andi.c.
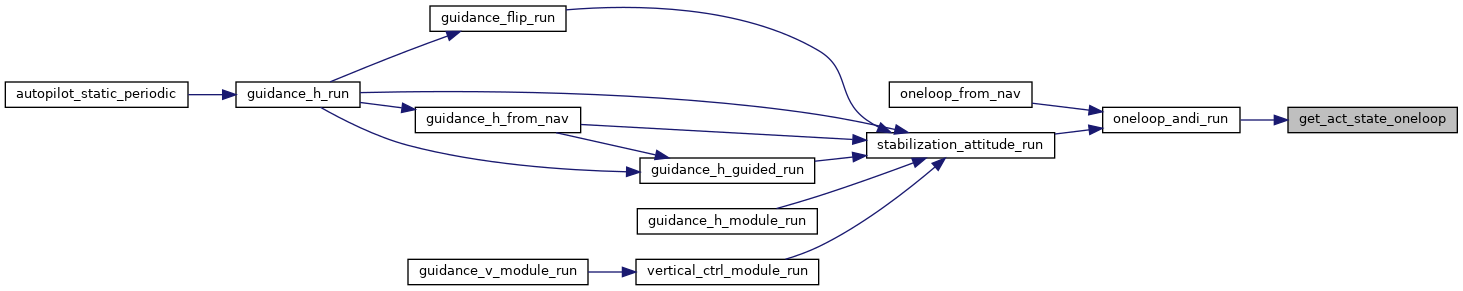
References act_dynamics_d, act_max, act_min, actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, andi_u, autopilot_get_motors_on(), and oneloop_andi.
Referenced by oneloop_andi_run().
| void guidance_set_max_bank_angle | ( | float | max_bank | ) |
Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid).
The one loop controller uses its own limits, so these are no-ops here.
Definition at line 3108 of file oneloop_andi.c.
References max_bank.
| void guidance_set_max_climb_speed | ( | float | max_climb_speed_quad, |
| float | max_climb_speed_fwd ) |
Definition at line 3113 of file oneloop_andi.c.
| void guidance_set_max_descend_speed | ( | float | max_descend_speed_quad, |
| float | max_descend_speed_fwd ) |
Definition at line 3119 of file oneloop_andi.c.
| void guidance_set_min_max_airspeed | ( | float | min_airspeed, |
| float | max_airspeed ) |
Definition at line 2925 of file oneloop_andi.c.
References max_airspeed, max_as, and min_as.
|
inlinestatic |
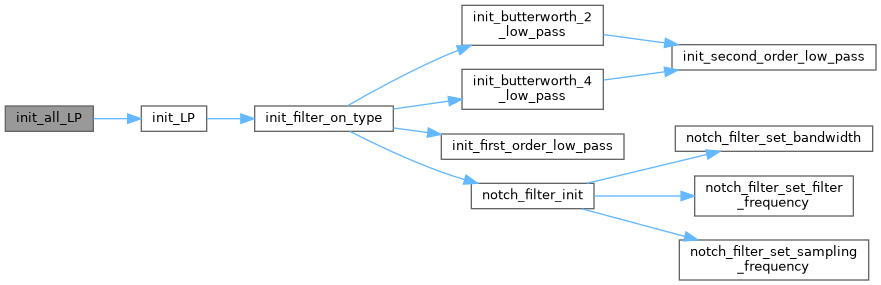
Initialize all Low Pass Filters.
Definition at line 1480 of file oneloop_andi.c.
References init_LP(), LP, and oneloop_andi_model_filt.
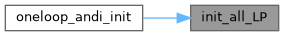
Referenced by oneloop_andi_init().
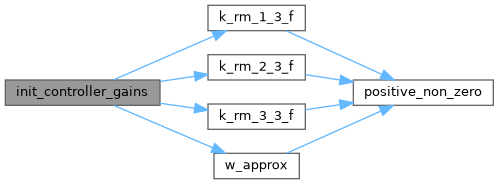
| void init_controller_gains | ( | void | ) |
Initialize Controller Gains FIXME: Calculate the gains dynamically for transition.
Definition at line 1244 of file oneloop_andi.c.
References act_dynamics, COMMAND_PITCH, COMMAND_ROLL, k1_NE_tune, k2_NE_tune, k_att_e, k_att_e_indi, k_att_rm, k_pos_e, k_pos_e_indi, k_pos_rm, k_rm_1_3_f(), k_rm_2_3_f(), k_rm_3_3_f(), max_a_nav, max_v_nav, nav_hybrid_max_bank, nav_hybrid_pos_gain, nav_max_acceleration_sp, nav_max_speed, ONELOOP_ANDI_MAX_BANK, p_alt_e, p_alt_rm, p_att_e, p_att_rm, p_head_e, p_head_rm, p_pos_e, p_pos_rm, p_roll_e, and w_approx().
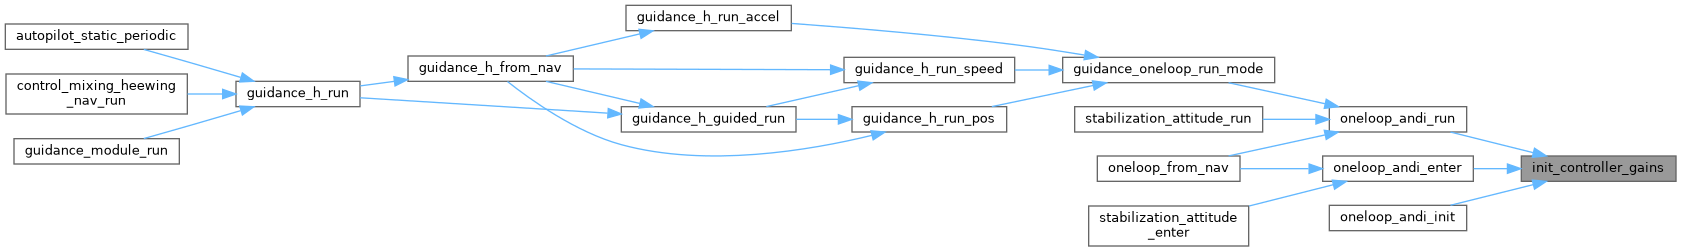
Referenced by oneloop_andi_enter(), oneloop_andi_init(), and oneloop_andi_run().
| void init_filter | ( | void | ) |
Initialize the filters.
Definition at line 1516 of file oneloop_andi.c.
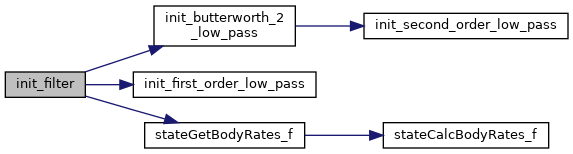
References accely_filt, airspeed_filt, ANDI_NUM_ACT_TOT, filt_veloc, init_butterworth_2_low_pass(), oneloop_andi_filt_cutoff, oneloop_andi_filt_cutoff_v, and u_filt.
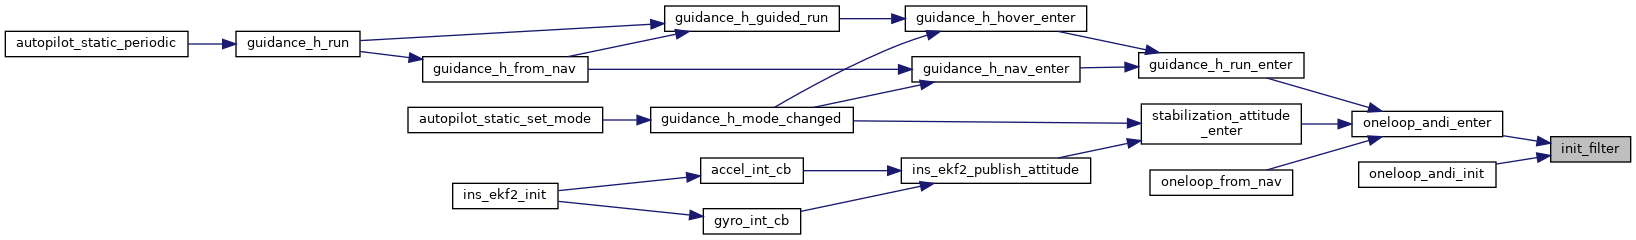
Referenced by oneloop_andi_init().
|
inlinestatic |
Initialize a filter based on its type.
Definition at line 1388 of file oneloop_andi.c.
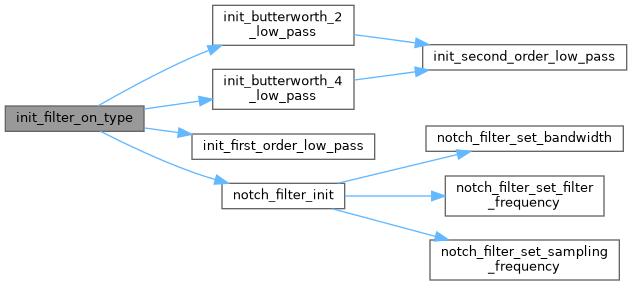
References LP_t::bandwidth, BUTTERWORTH_2, BUTTERWORTH_4, LP_t::filter_type, LP_t::freq, init_butterworth_2_low_pass(), init_butterworth_4_low_pass(), init_first_order_low_pass(), LOWPASS_1, LP_t::meas_filt, NOTCH, notch_filter_init(), and LP_t::tau.
Referenced by init_LP(), reinit_LP(), and reinit_LP_synchronous().
|
inlinestatic |
Initialize the Low Pass Filter Struct.
Definition at line 1440 of file oneloop_andi.c.
References BUTTERWORTH_2, BUTTERWORTH_4, init_filter_on_type(), LOWPASS_1, and LP.
Referenced by init_all_LP().
| void init_poles | ( | void | ) |
Initialize Position of Poles.
Definition at line 1191 of file oneloop_andi.c.
References act_dynamics, COMMAND_PITCH, COMMAND_ROLL, p_alt_e, p_alt_rm, p_att_e, p_att_rm, p_head_e, p_head_rm, p_pos_e, p_pos_rm, p_roll_e, slow_pole, and w_approx().
Referenced by oneloop_andi_init().
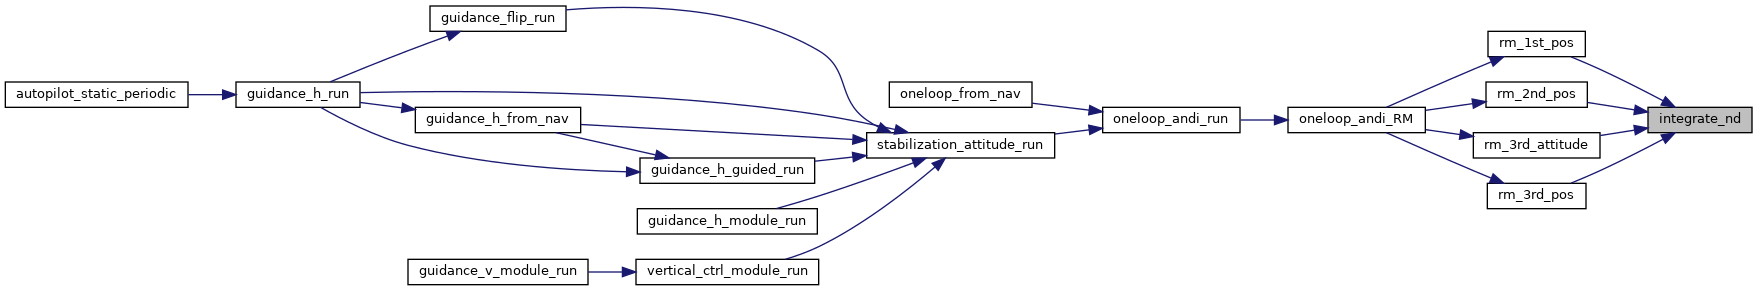
| void integrate_nd | ( | float | dt, |
| float | a[], | ||
| float | a_dot[], | ||
| int | n ) |
Integrate in time 3D array.
Definition at line 722 of file oneloop_andi.c.
Referenced by rm_1st_pos(), rm_2nd_pos(), rm_3rd_attitude(), and rm_3rd_pos().
|
static |
Reference Model Gain Design.
Definition at line 744 of file oneloop_andi.c.
References positive_non_zero().
Referenced by init_controller_gains().
|
static |
Definition at line 750 of file oneloop_andi.c.
References positive_non_zero().
Referenced by init_controller_gains().
|
static |
Definition at line 756 of file oneloop_andi.c.
References positive_non_zero().
Referenced by init_controller_gains().
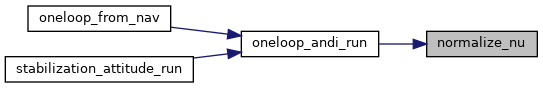
| void normalize_nu | ( | void | ) |
Function to normalize the pseudo control vector.
Definition at line 2555 of file oneloop_andi.c.
References ANDI_OUTPUTS, nu, nu_n, ratio_vn_v, and WLS_one_p.
Referenced by oneloop_andi_run().
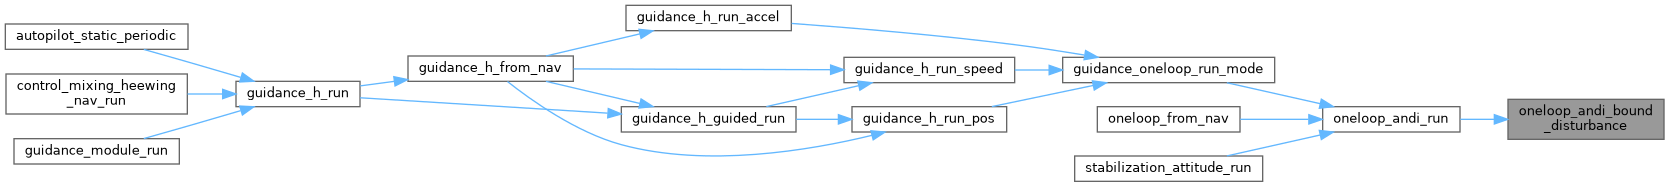
| void oneloop_andi_bound_disturbance | ( | void | ) |
Definition at line 3049 of file oneloop_andi.c.
References oneloop_andi, oneloop_andi_dist_bound, oneloop_andi_model, RW_aD, RW_aE, RW_aN, RW_ap, RW_aq, and RW_ar.
Referenced by oneloop_andi_run().
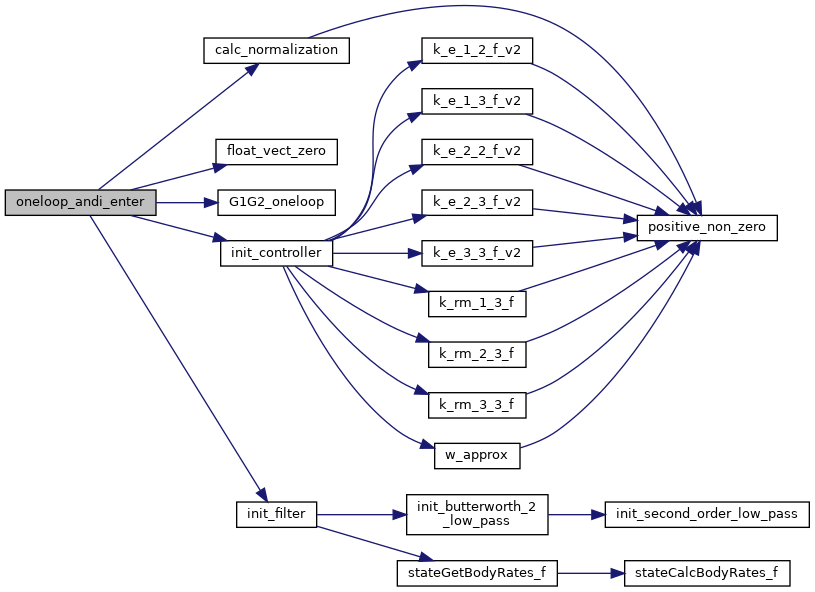
| void oneloop_andi_enter | ( | bool | half_loop_sp, |
| int | ctrl_type ) |
Function that resets important values upon engaging Oneloop ANDI.
FIXME: Ideally we should distinguish between the "stabilization" and "guidance" needs because it is unlikely to switch stabilization in flight, and there are multiple modes that use (the same) stabilization. Resetting the controller is not so nice when you are flying.
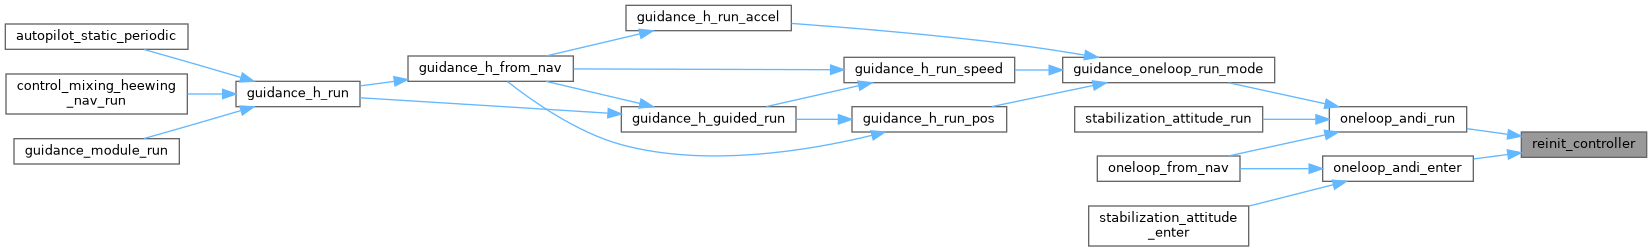
Definition at line 1680 of file oneloop_andi.c.
References ANDI_OUTPUTS, bwls_1l, calc_normalization(), EFF_MAT_G, ele_min, eulers_zxy, G1G2_oneloop(), init_controller_gains(), multiple_chirp_run, oneloop_andi, psi_des_deg, psi_des_rad, and reinit_controller().
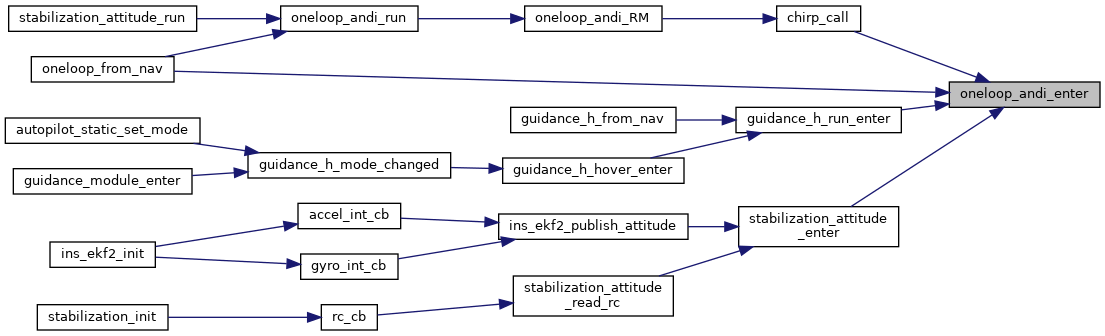
Referenced by oneloop_from_nav(), and stabilization_attitude_enter().
| void oneloop_andi_init | ( | void | ) |
Init function of Oneloop ANDI controller.
Definition at line 1621 of file oneloop_andi.c.
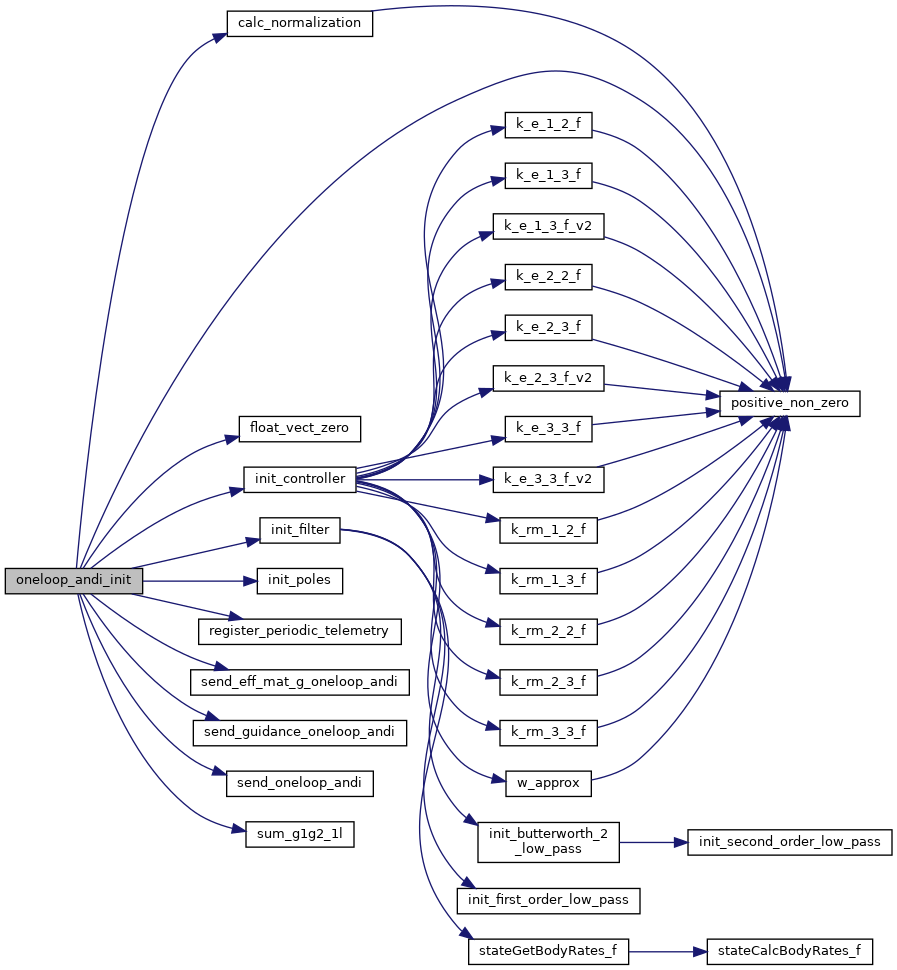
References act_dynamics, actuator_state_1l, andi_du, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, andi_u, andi_u_n, bwls_1l, calc_normalization(), CTRL_ANDI, DefaultPeriodic, dynFilter_init(), EFF_MAT_G, eulers_zxy_des, float_vect_zero(), G1G2_oneloop(), init_all_LP(), init_controller_gains(), init_filter(), init_poles(), mu_mL, mu_mR, nav_target, nav_target_new, nu, nu_n, oneloop_andi, positive_non_zero(), register_periodic_telemetry(), send_eff_mat_guid_oneloop_andi(), send_eff_mat_stab_oneloop_andi(), send_guidance_oneloop_andi(), send_oneloop_andi(), send_oneloop_debug(), send_wls_u_oneloop(), and send_wls_v_oneloop().
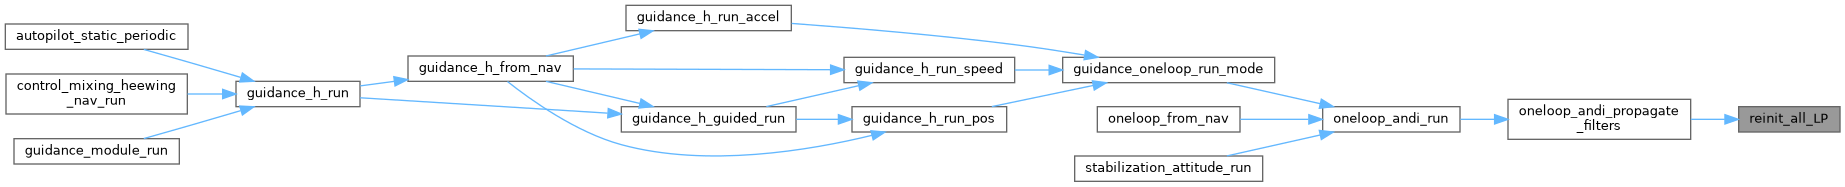
| void oneloop_andi_propagate_filters | ( | void | ) |
Propagate the filters.
Definition at line 1538 of file oneloop_andi.c.
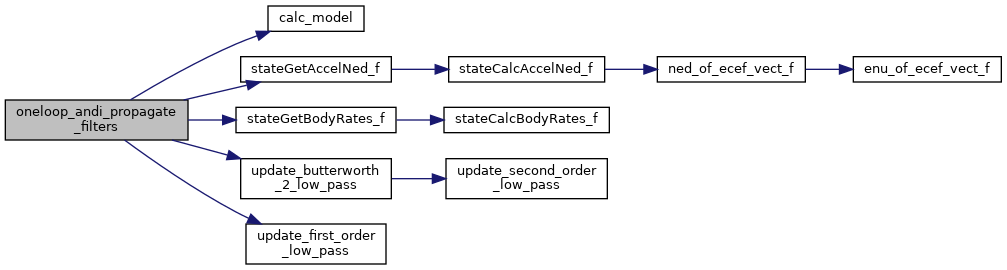
References ACCEL_FLOAT_OF_BFP, accely_filt, airspeed_filt, LP, FloatRates::p, FloatRates::q, FloatRates::r, reinit_all_LP(), stateGetAccelBody_i(), stateGetAccelNed_f(), stateGetAirspeed_f(), stateGetBodyRates_f(), stateGetSpeedNed_f(), update_butterworth_2_low_pass(), update_filter_on_type(), NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
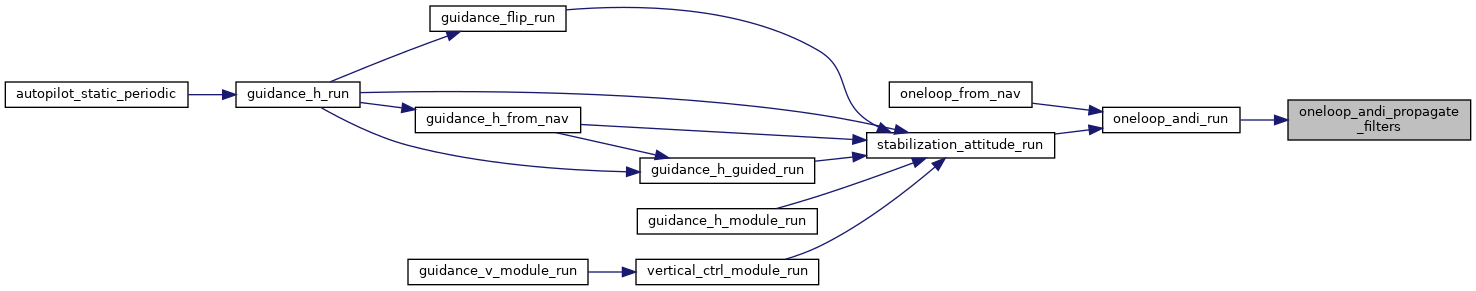
Referenced by oneloop_andi_run().
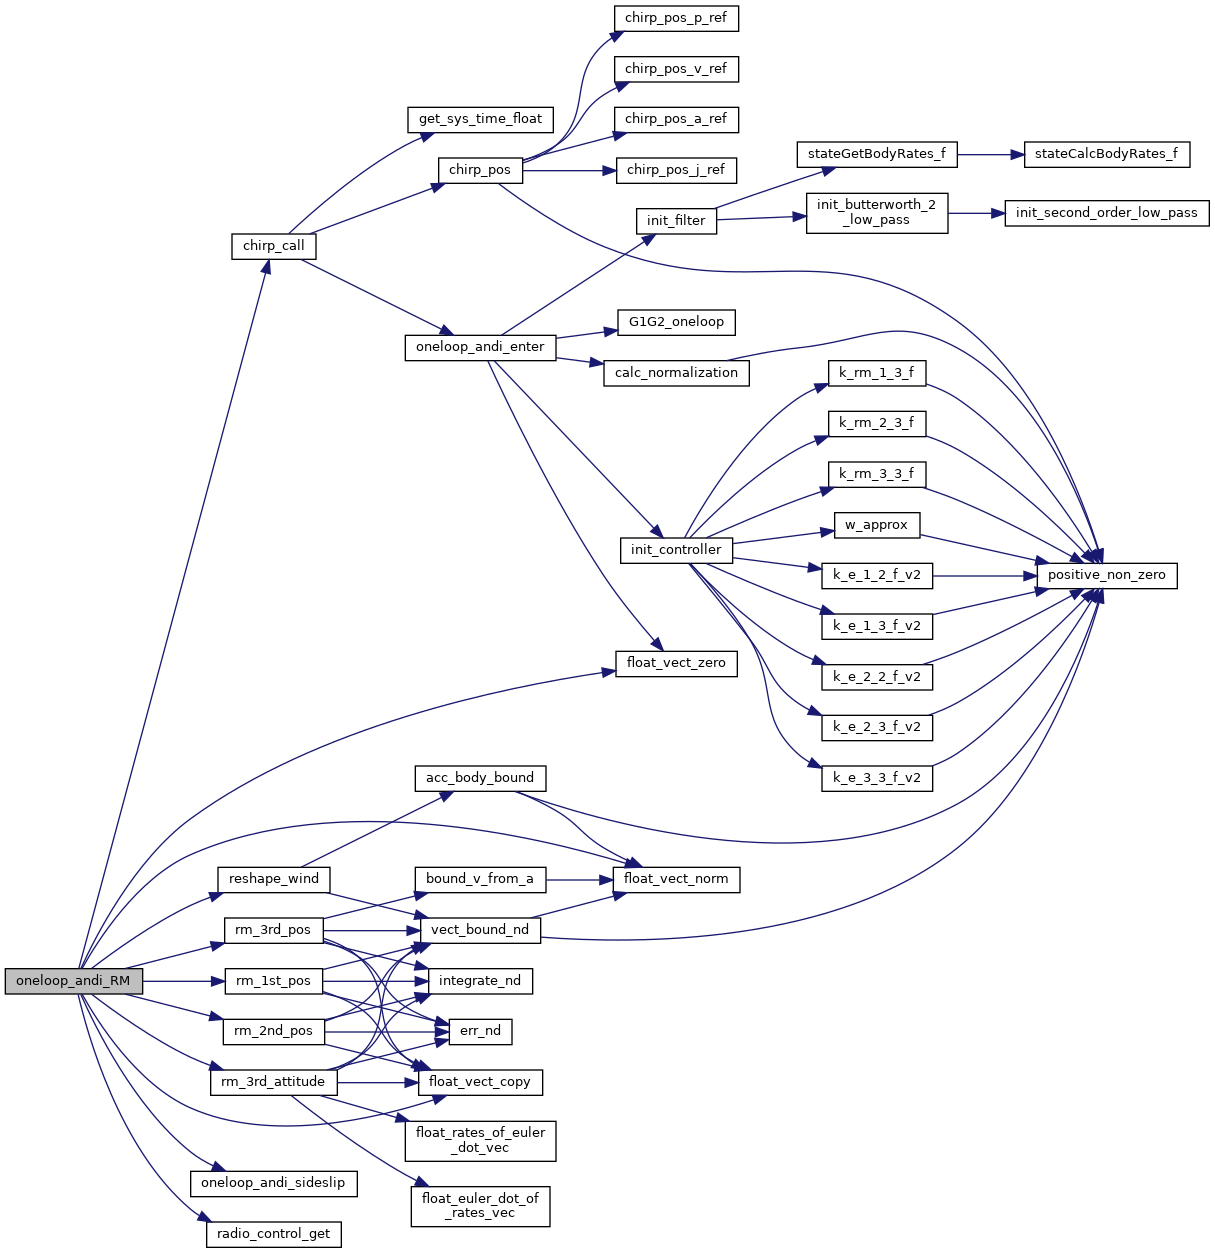
| void oneloop_andi_RM | ( | bool | half_loop, |
| struct FloatVect3 | PSA_des, | ||
| int | rm_order_h, | ||
| int | rm_order_v, | ||
| bool | in_flight_oneloop ) |
Function to generate the reference signals for the oneloop controller.
| half_loop | In half-loop mode the controller is used for stabilization only |
| PSA_des | Desired position/speed/acceleration |
| rm_order_h | Order of the reference model for horizontal guidance |
| rm_order_v | Order of the reference model for vertical guidance |
Definition at line 1724 of file oneloop_andi.c.
References A_chirp, a_thrust, act_dyn_ctrl, ANDI_NUM_ACT, chirp_axis, chirp_call(), chirp_first_call, chirp_n_counter, chirp_n_repeat, chirp_on, CTRL_ANDI, delay_counter, drop_yaw, dt_1l, EFF_MAT_RW, eulers_zxy, eulers_zxy_des, f0_chirp, f1_chirp, firing_counter, float_vect_copy(), float_vect_zero(), heading_manual, k_att_rm, k_pos_rm, max_a_nav, max_j_lin, MAX_PPRZ, max_r, max_v_nav, max_v_nav_v, multiple_chirp_run, nav_target, nav_target_new, oneloop_andi, ONELOOP_ANDI_MAX_PHI, ONELOOP_ANDI_MAX_THETA, oneloop_andi_model, oneloop_andi_sideslip(), p_ref_0, phi_vec, psi_des_deg, psi_des_rad, psi_vec, radio_control_get(), RADIO_PITCH, RADIO_ROLL, RADIO_THROTTLE, RADIO_YAW, reshape_wind(), rm_1st_pos(), rm_2nd_pos(), rm_3rd_attitude(), rm_3rd_pos(), RW_aD, sta_bounds, t_0_chirp, t_chirp, time_elapsed_chirp, WLS_one_p, Wv_backup, FloatVect3::x, FloatVect3::y, yaw_stick_in_auto, and FloatVect3::z.
Referenced by oneloop_andi_run().
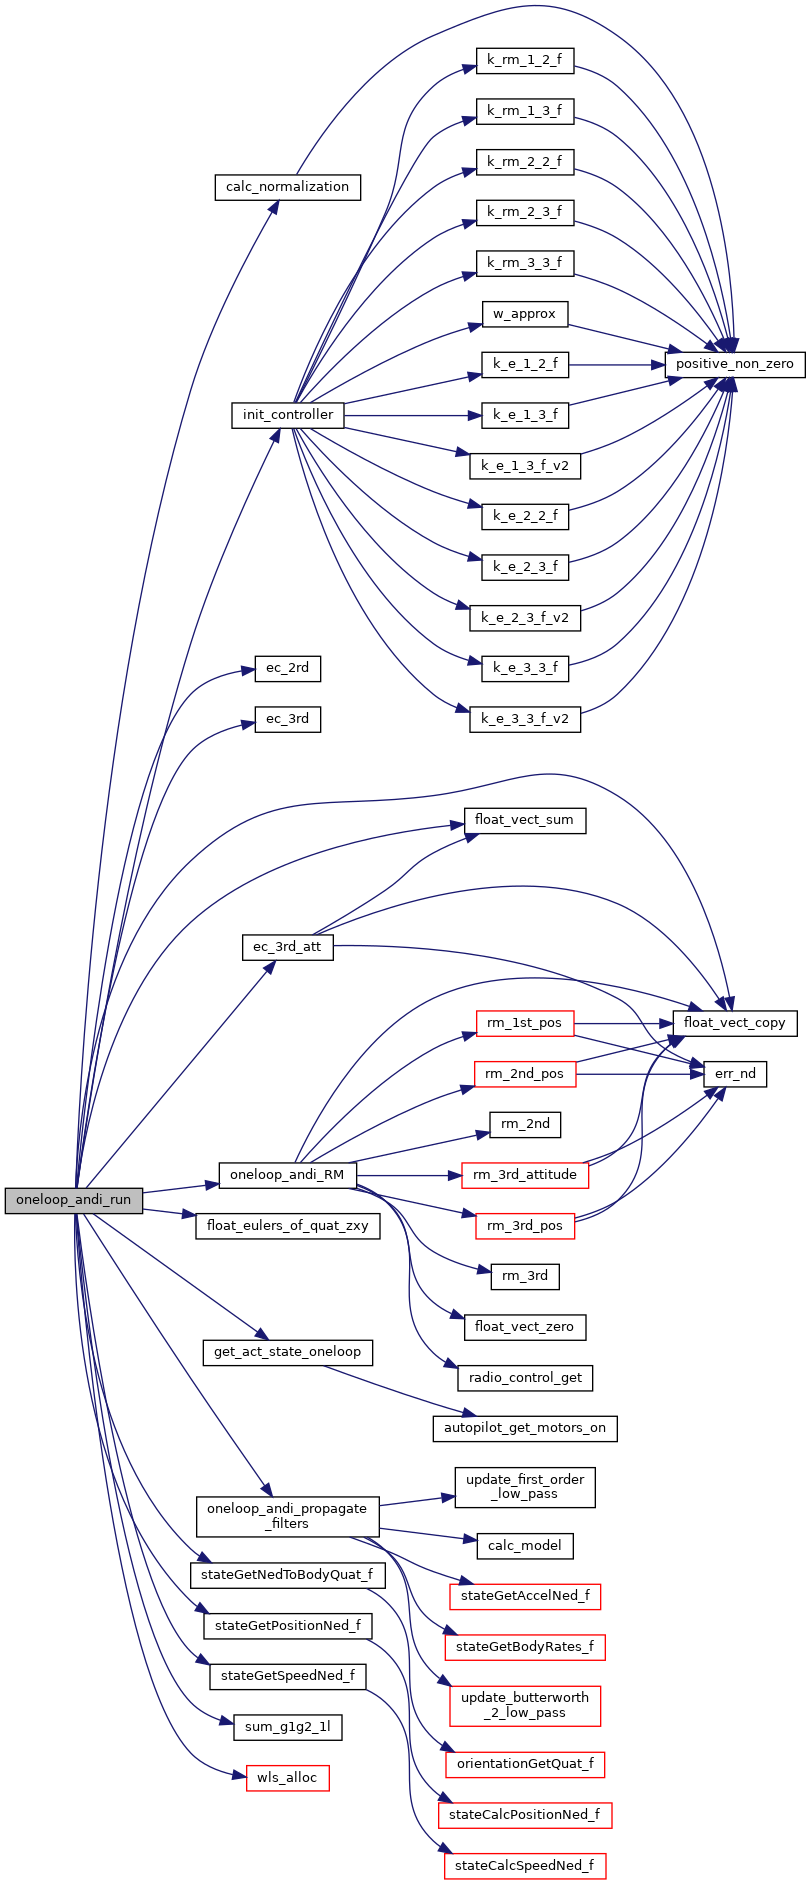
| void oneloop_andi_run | ( | bool | in_flight, |
| bool | half_loop, | ||
| struct FloatVect3 | PSA_des, | ||
| int | rm_order_h, | ||
| int | rm_order_v ) |
Main function that runs the controller and performs control allocation.
| half_loop | In half-loop mode the controller is used for stabilization only |
| in_flight | The drone is in flight |
| PSA_des | Desired position/speed/acceleration |
| rm_order_h | Order of the reference model for horizontal guidance |
| rm_order_v | Order of the reference model for vertical guidance |
Definition at line 1963 of file oneloop_andi.c.
References a_thrust, act_dyn_ctrl, act_dynamics, act_max, act_min, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, andi_u, andi_u_n, autopilot, bwls_1l, calc_normalization(), chirp_on, COMMAND_PITCH, COMMAND_ROLL, commands, CTRL_ANDI, CTRL_INDI, ctrl_off, drop_aD, drop_aE, drop_aN, drop_pitch, drop_roll, drop_yaw, dynFilter_run(), ec_3rd_att(), ec_3rd_pos(), EFF_MAT_G, eul_of_acc(), eulers_zxy, eulers_zxy_des, G1G2_oneloop(), g2_ff, G2_RW, get_act_state_oneloop(), heading_manual, init_controller_gains(), k_att_e, k_att_e_indi, k_D, k_I, k_P, k_pos_e, k_pos_e_indi, LP, max_a_nav, MAX_PPRZ, max_v_nav, mu_mL, mu_mR, nav, normalize_nu(), nu, num_thrusters_oneloop, oneloop_andi, oneloop_andi_bound_disturbance(), ONELOOP_ANDI_DEBUG_MODE, ONELOOP_ANDI_MAX_PHI, ONELOOP_ANDI_MAX_THETA, oneloop_andi_model, oneloop_andi_model_filt, oneloop_andi_propagate_filters(), oneloop_andi_RM(), oneloop_andi_sigma, oneloop_calc_model_disturbance(), pitch_pref, POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, Pos_PID(), psi_des_deg, psi_des_rad, RADIO_AUX4, RADIO_AUX5, radio_control, radio_control_get(), RADIO_THROTTLE, ratio_u_un, reinit_controller(), rotwing_state, RW, RW_aD, RW_aE, RW_aN, RW_ap, RW_aq, RW_ar, shape_vector(), sta_bounds, stabilization, stateGetNedToBodyEulersZxy_f(), stateGetPositionNed_f(), stateGetSpeedNed_f(), sys_id_doublet_running(), theta_pref_max, u_filt, u_pref, use_dyn_filter, wls_alloc(), WLS_one_p, Wu_backup, Wu_quad_motors_fwd, NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
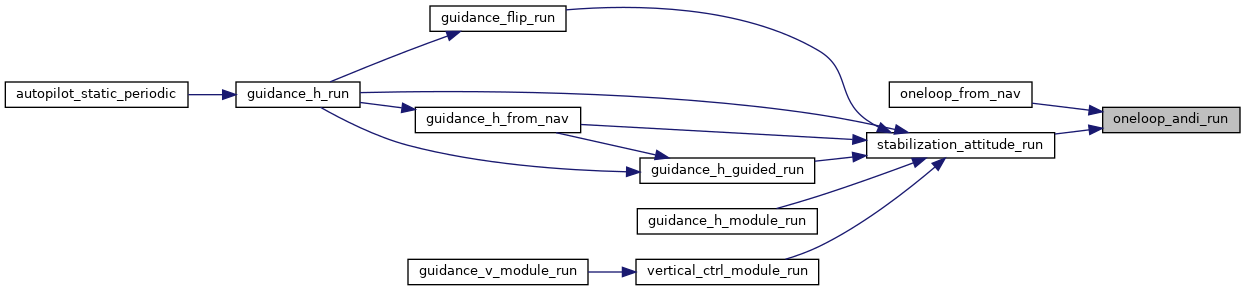
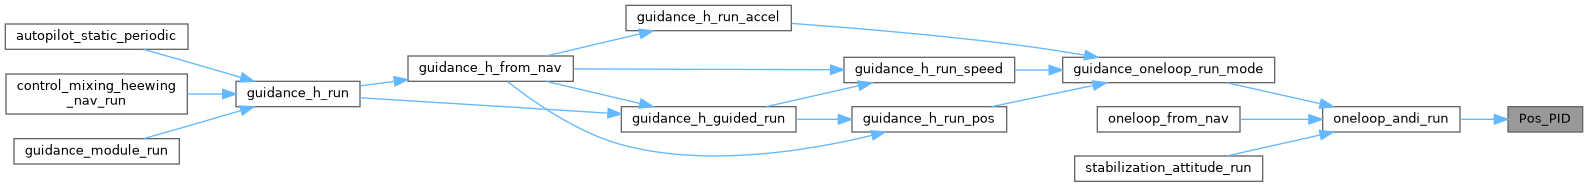
Referenced by guidance_oneloop_run_mode(), oneloop_from_nav(), and stabilization_attitude_run().
| float oneloop_andi_sideslip | ( | void | ) |
Function to calculate corrections for sideslip.
Definition at line 2609 of file oneloop_andi.c.
References accely_filt, airspeed_filt, eulers_zxy, fwd_sideslip_gain, g, max_phi, and ONELOOP_ANDI_MAX_BANK.
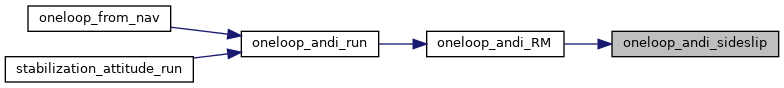
Referenced by oneloop_andi_RM().
| void oneloop_axis_effectiveness_calc | ( | void | ) |
Definition at line 2931 of file oneloop_andi.c.
References ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, COMMAND_PITCH, COMMAND_ROLL, coupling_factor, EFF_MAT_G, m_array, MAX_PPRZ, n_array, positive_non_zero(), ratio_u_un, ratio_vn_v, and RW.
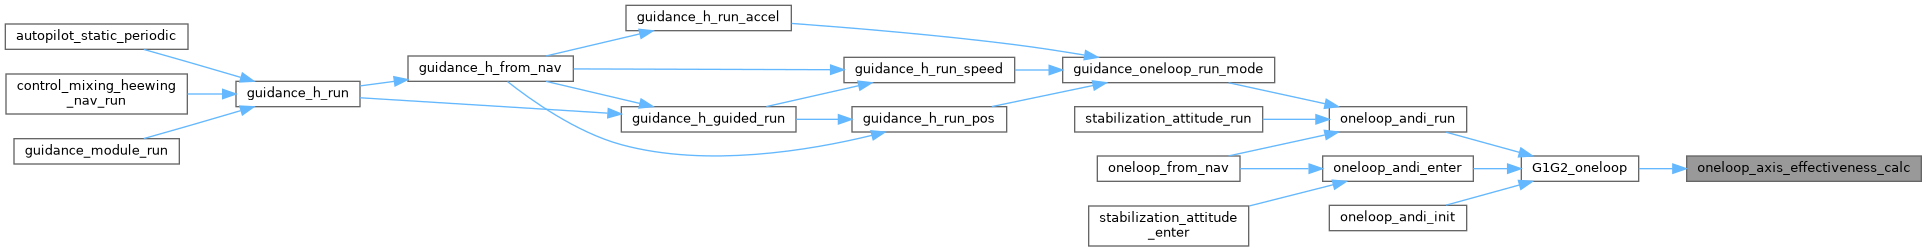
Referenced by G1G2_oneloop().
| void oneloop_calc_model_disturbance | ( | bool | in_flight | ) |
Function that calculates the model disturbance (Control Effort) The control effort is equalt to : EFF_MAT*u_filt where EFF_MAT is what is inverted and u_filt is the filtered actuator state.
Definition at line 2981 of file oneloop_andi.c.
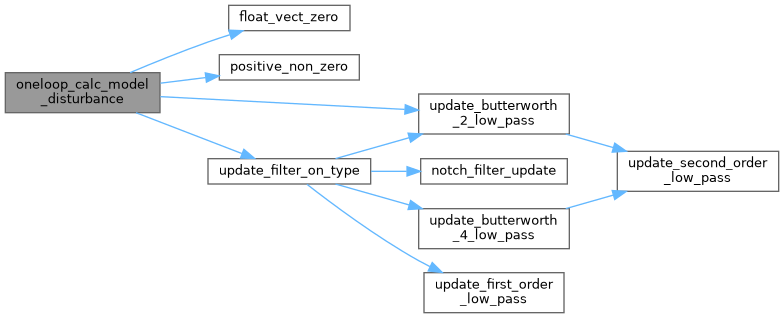
References actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, EFF_MAT_G, float_vect_zero(), k_att_e, oneloop_andi, oneloop_andi_model, oneloop_andi_model_filt, positive_non_zero(), ratio_u_un, ratio_vn_v, RW_aD, RW_aE, RW_aN, RW_ap, RW_aq, RW_ar, u_filt, update_butterworth_2_low_pass(), and update_filter_on_type().
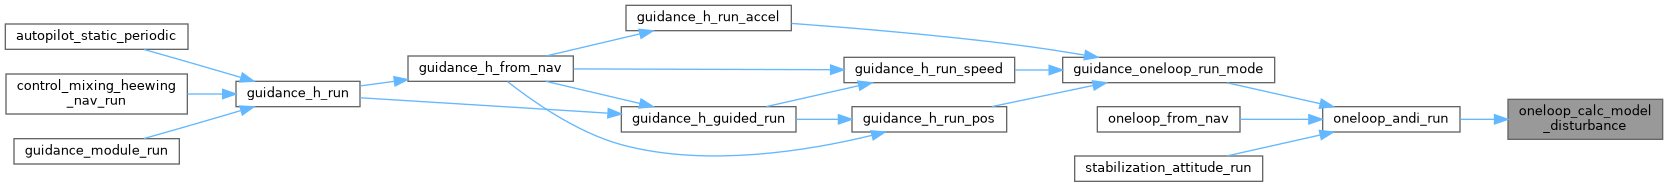
Referenced by oneloop_andi_run().
| void oneloop_from_nav | ( | bool | in_flight | ) |
Function that maps navigation inputs to the oneloop controller for the generated autopilot.
Definition at line 2568 of file oneloop_andi.c.
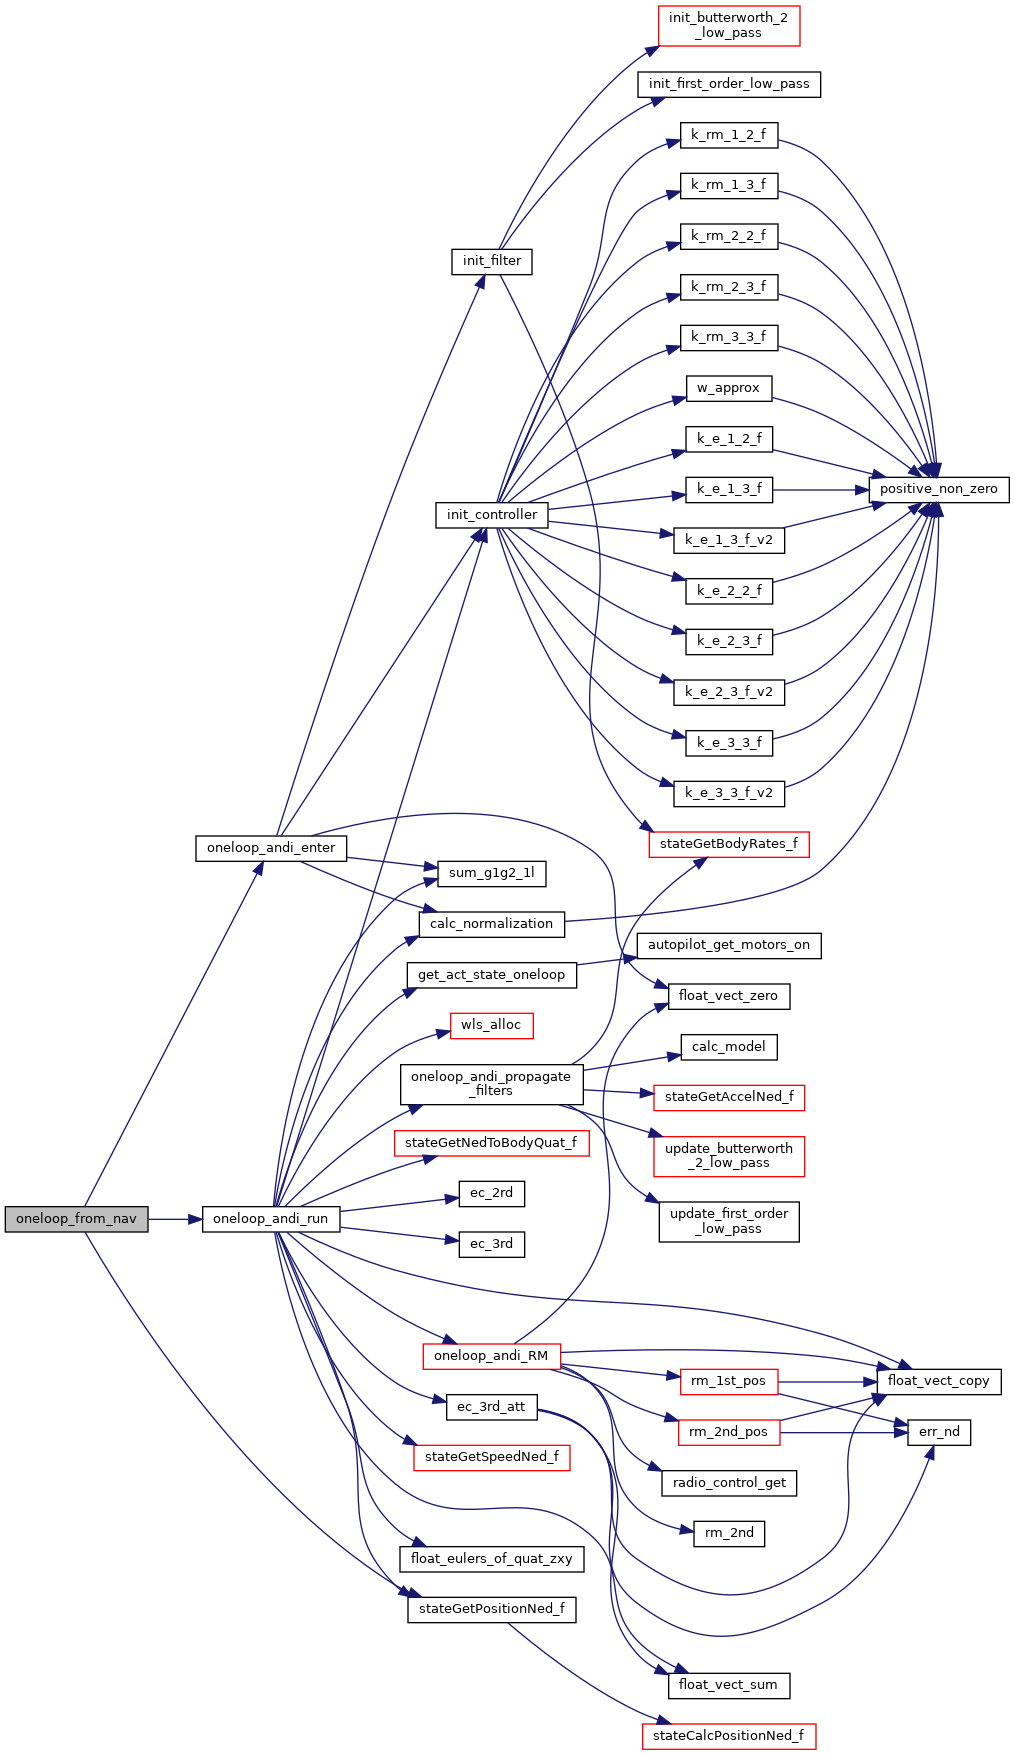
References nav, NAV_SETPOINT_MODE_POS, NAV_SETPOINT_MODE_SPEED, NAV_VERTICAL_MODE_ALT, NAV_VERTICAL_MODE_CLIMB, oneloop_andi, oneloop_andi_enter(), oneloop_andi_run(), POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, SPEED_BFP_OF_REAL, SPEED_FLOAT_OF_BFP, stateGetPositionNed_f(), FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
|
static |
Definition at line 765 of file oneloop_andi.c.
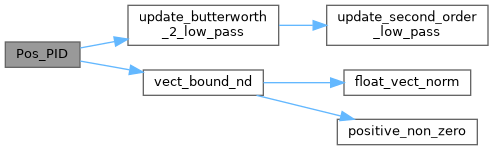
References dt_1l, filt_veloc, k_D, k_I, k_P, temp_D_error, temp_I_error, temp_P_error, update_butterworth_2_low_pass(), and vect_bound_nd().
Referenced by oneloop_andi_run().
|
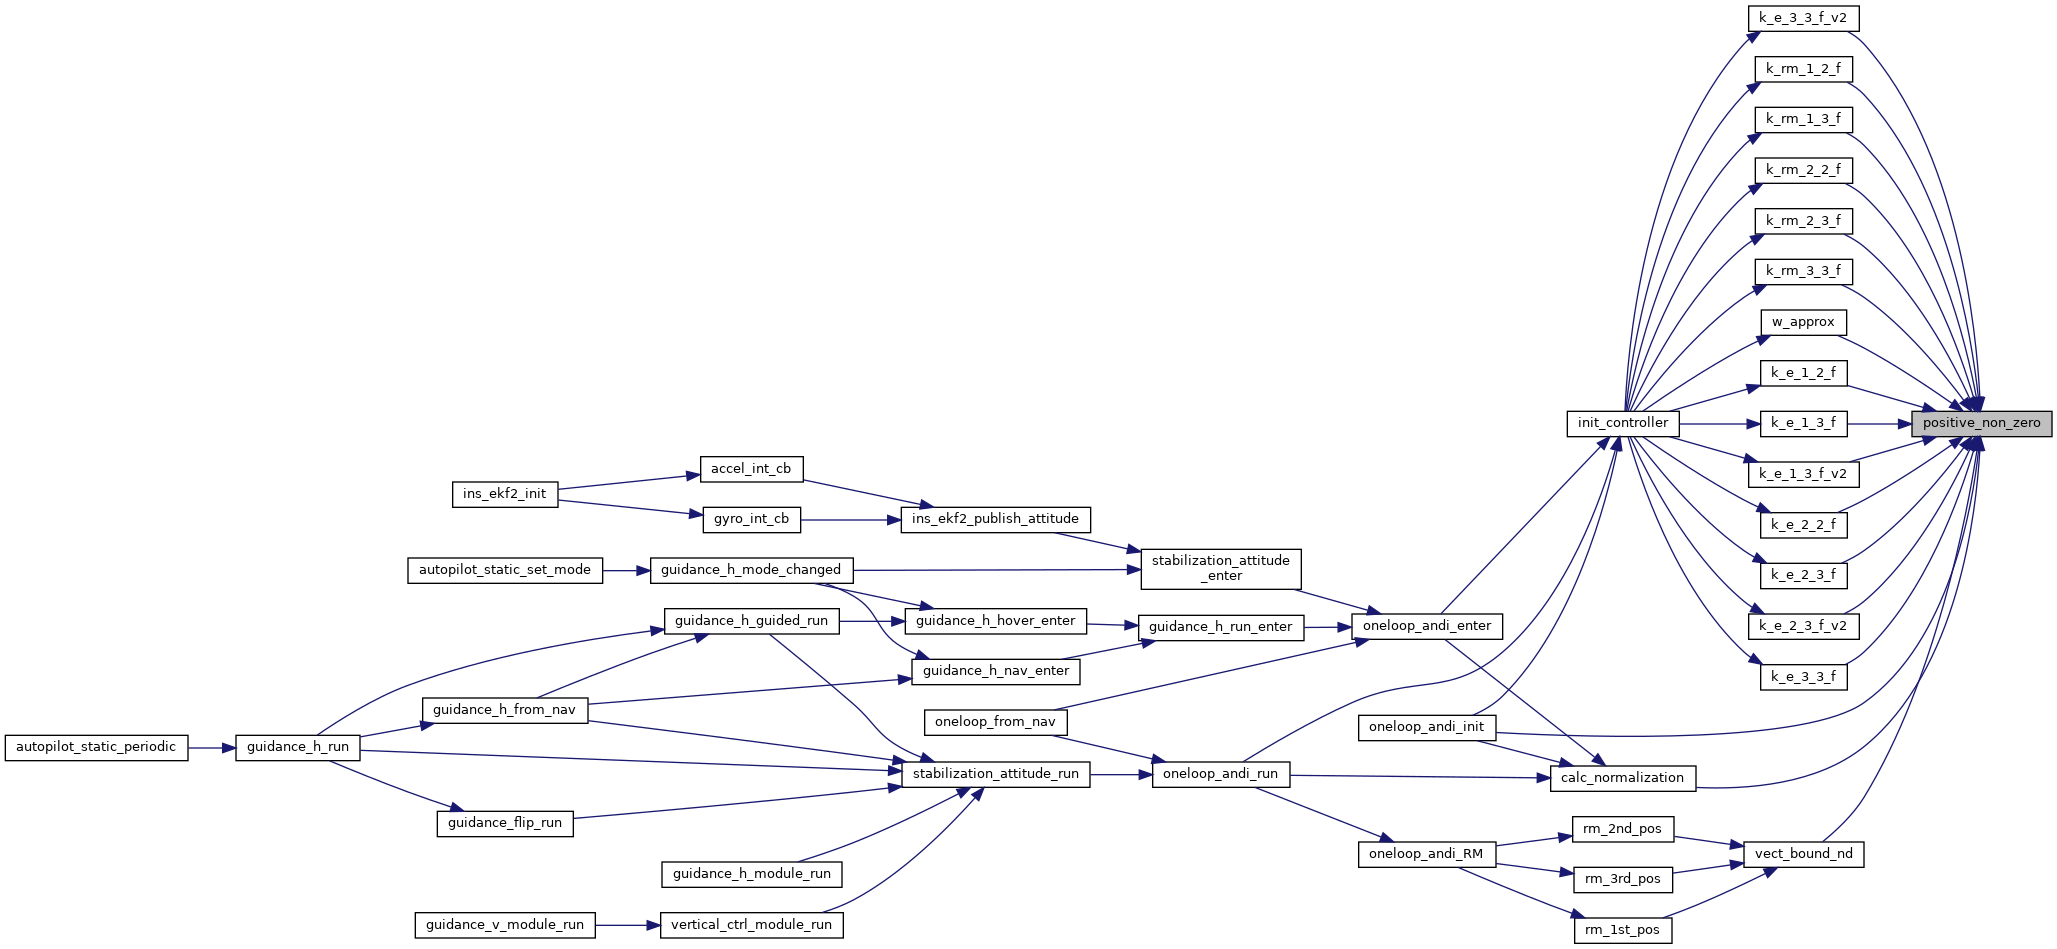
static |
Function to make sure that inputs are positive non zero vaues.
Definition at line 688 of file oneloop_andi.c.
Referenced by acc_body_bound(), calc_normalization(), chirp_pos(), k_rm_1_3_f(), k_rm_2_3_f(), k_rm_3_3_f(), oneloop_andi_init(), oneloop_axis_effectiveness_calc(), oneloop_calc_model_disturbance(), vect_bound_nd(), and w_approx().
| PRINT_CONFIG_VAR | ( | ONELOOP_ANDI_FILT_CUTOFF | ) |
References PRINT_CONFIG_VAR().
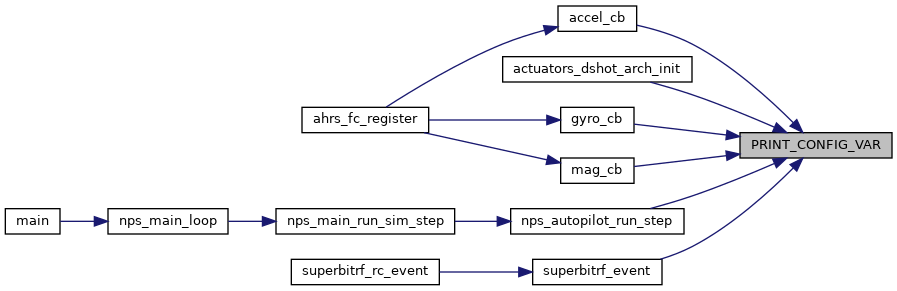
Referenced by accel_cb(), accel_cb(), accel_cb(), actuators_dshot_arch_init(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), gyro_cb(), mag_cb(), mag_cb(), nps_autopilot_run_step(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), PRINT_CONFIG_VAR(), and superbitrf_event().
| PRINT_CONFIG_VAR | ( | ONELOOP_ANDI_FILT_CUTOFF_P | ) |
| PRINT_CONFIG_VAR | ( | ONELOOP_ANDI_FILT_CUTOFF_Q | ) |
| PRINT_CONFIG_VAR | ( | ONELOOP_ANDI_FILT_CUTOFF_R | ) |
|
inlinestatic |
Reinitialize all the Low Pass Filters.
Definition at line 1501 of file oneloop_andi.c.
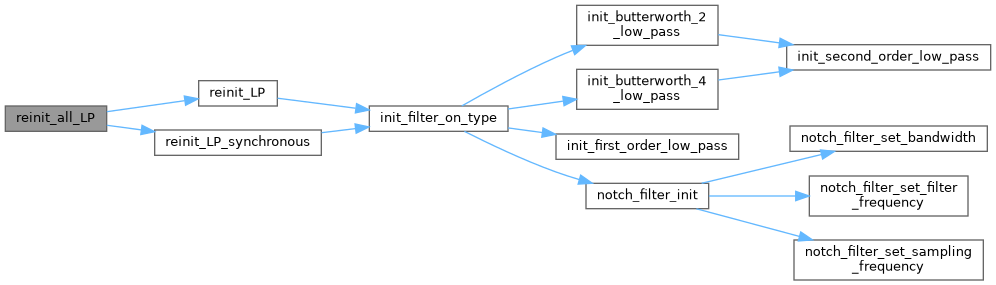
References LP, oneloop_andi_model_filt, reinit_LP(), and reinit_LP_synchronous().
Referenced by oneloop_andi_propagate_filters().
| void reinit_controller | ( | void | ) |
Re-Init function of controller variables.
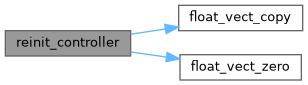
Definition at line 1585 of file oneloop_andi.c.
References andi_u, COMMAND_PITCH, COMMAND_ROLL, eulers_zxy_des, float_vect_copy(), float_vect_zero(), and oneloop_andi.
Referenced by oneloop_andi_enter(), and oneloop_andi_run().
|
inlinestatic |
Definition at line 1469 of file oneloop_andi.c.
References init_filter_on_type(), and LP.
Referenced by reinit_all_LP().
Reinitialize Low Pass filter if new frequency setting or if forced.
Definition at line 1459 of file oneloop_andi.c.
References f, init_filter_on_type(), and LP.
Referenced by reinit_all_LP().
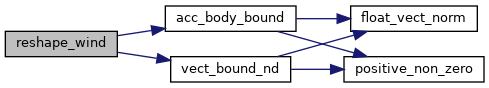
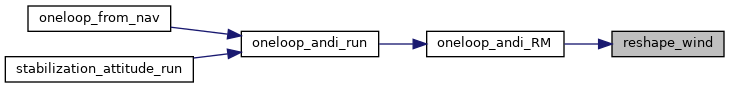
| void reshape_wind | ( | void | ) |
Definition at line 2857 of file oneloop_andi.c.
References acc_body_bound(), airspeed_filt, eulers_zxy, FLOAT_ANGLE_NORMALIZE, FLOAT_VECT2_NORM, force_forward, gi_unbounded_airspeed_sp, k_pos_rm, max_a_nav, max_as, min_as, nav_target, nav_target_new, oneloop_andi, ONELOOP_ANDI_AIRSPEED_SWITCH_THRESHOLD, VECT2_DIFF, vect_bound_nd(), FloatVect2::x, and FloatVect2::y.
Referenced by oneloop_andi_RM().
| void rm_1st_pos | ( | float | dt, |
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_2d_des[], | ||
| float | k3_rm[], | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_2d_des | Desired 3rd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
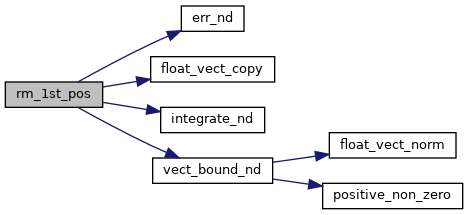
Definition at line 1074 of file oneloop_andi.c.
References err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
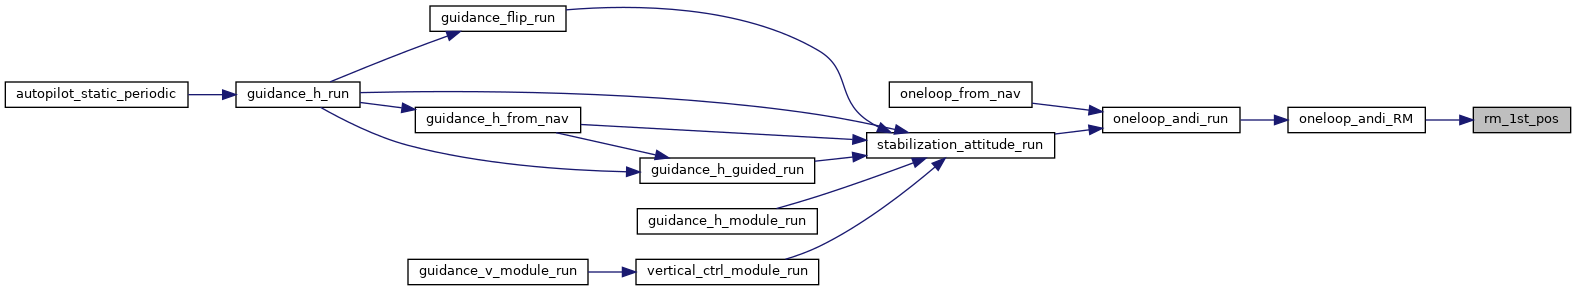
Referenced by oneloop_andi_RM().
| void rm_2nd_pos | ( | float | dt, |
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_d_des[], | ||
| float | k2_rm[], | ||
| float | k3_rm[], | ||
| float | x_2d_bound, | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_d_des | Desired 2nd order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_2d_bound | Bound for the 3rd order reference signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
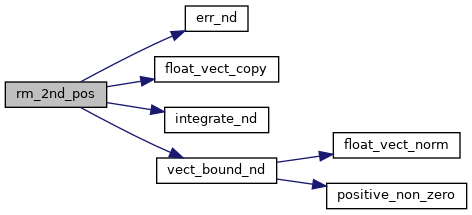
Definition at line 1051 of file oneloop_andi.c.
References err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
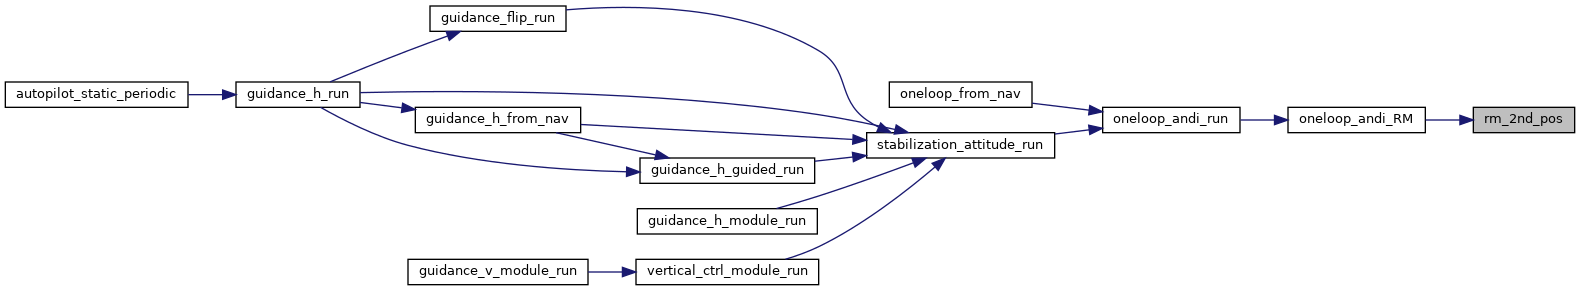
Referenced by oneloop_andi_RM().
| void rm_3rd_attitude | ( | float | dt, |
| float | x_ref[3], | ||
| float | x_d_ref[3], | ||
| float | x_2d_ref[3], | ||
| float | x_3d_ref[3], | ||
| float | x_des[3], | ||
| bool | ow_psi, | ||
| float | psi_overwrite[4], | ||
| float | k1_rm[3], | ||
| float | k2_rm[3], | ||
| float | k3_rm[3], | ||
| struct OneloopStabilizationRef | bounds ) |
Reference Model Definition for 3rd order system with attitude conversion functions.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order (Attitude) |
| x_d_ref | Reference signal 2nd order (Angular Rate) |
| x_2d_ref | Reference signal 3rd order (Angular Acceleration) |
| x_3d_ref | Reference signal 4th order (Angular Jerk) |
| x_des | Desired 1st order signal (Desired Attitude) |
| ow_psi | Overwrite psi (for navigation functions) [bool] |
| psi_overwrite | Overwrite psi (for navigation functions) [values] |
| k1_rm | Reference Model Gain 1st order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| bounds | Bounds for the Reference Model |
Definition at line 956 of file oneloop_andi.c.
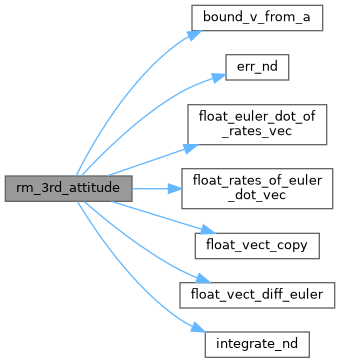
References OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_3d, OneloopStabilizationRef::att_d, bound_v_from_a(), err_nd(), float_euler_dot_of_rates_vec(), float_rates_of_euler_dot_vec(), float_vect_copy(), float_vect_diff_euler(), and integrate_nd().
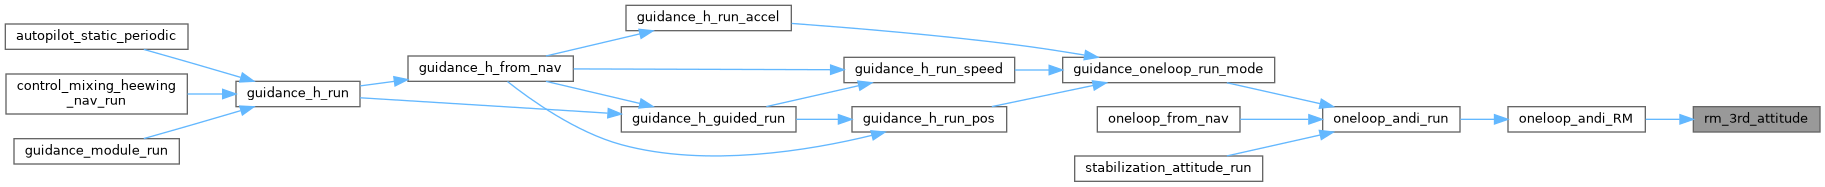
Referenced by oneloop_andi_RM().
| void rm_3rd_pos | ( | float | dt, |
| float | x_ref[], | ||
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_des[], | ||
| float | k1_rm[], | ||
| float | k2_rm[], | ||
| float | k3_rm[], | ||
| float | x_d_bound, | ||
| float | x_2d_bound, | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| k1_rm | Reference Model Gain 1st order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_d_bound | Bound for the 2nd order reference signal |
| x_2d_bound | Bound for the 3rd order reference signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
Definition at line 1020 of file oneloop_andi.c.
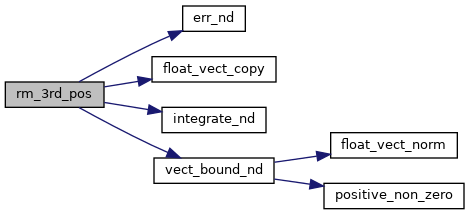
References bound_v_from_a_vect(), err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
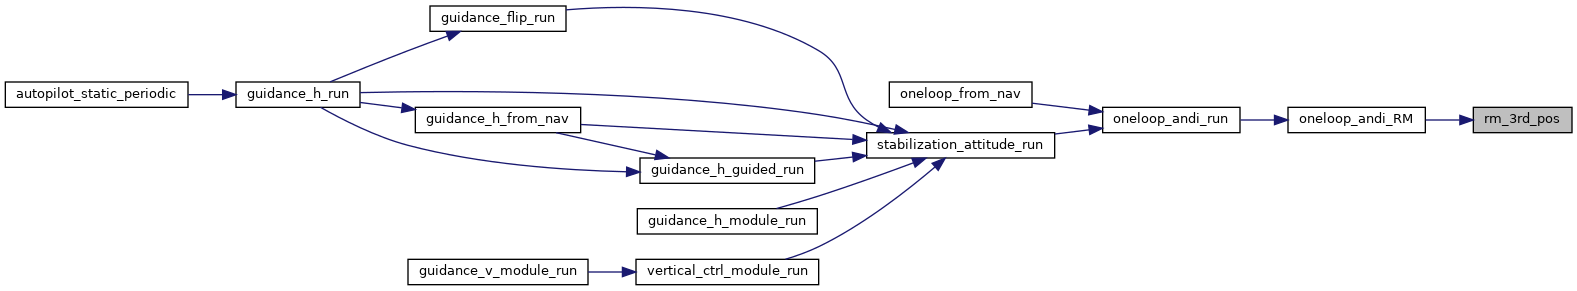
Referenced by oneloop_andi_RM().
|
static |
Definition at line 610 of file oneloop_andi.c.
References ANDI_NUM_ACT_TOT, dev, and EFF_MAT_RW.
Referenced by oneloop_andi_init().
|
static |
Definition at line 602 of file oneloop_andi.c.
References ANDI_NUM_ACT, dev, EFF_MAT_RW, and G2_RW.
Referenced by oneloop_andi_init().
|
static |
Definition at line 631 of file oneloop_andi.c.
References dev, and oneloop_andi.
Referenced by oneloop_andi_init().
|
static |
Definition at line 617 of file oneloop_andi.c.
References actuator_state_1l, ANDI_NUM_ACT, dev, eulers_zxy_des, and oneloop_andi.
Referenced by oneloop_andi_init().
|
static |
Definition at line 662 of file oneloop_andi.c.
References debug_vect(), dev, temp_D_error, temp_I_error, and temp_P_error.
Referenced by oneloop_andi_init(), and oneloop_nB_init().
|
static |
Definition at line 598 of file oneloop_andi.c.
References dev, send_wls_u(), and WLS_one_p.
Referenced by oneloop_andi_init(), and oneloop_nB_init().
|
static |
Definition at line 594 of file oneloop_andi.c.
References dev, send_wls_v(), and WLS_one_p.
Referenced by oneloop_andi_init(), and oneloop_nB_init().
|
static |
Definition at line 799 of file oneloop_andi.c.
References vect_bound_nd().
Referenced by oneloop_andi_run().
|
inlinestatic |
Update a filter based on its type.
Definition at line 1410 of file oneloop_andi.c.
References BUTTERWORTH_2, BUTTERWORTH_4, LP_t::filter_type, LOWPASS_1, LP_t::meas_filt, NOTCH, notch_filter_update(), LP_t::out, update_butterworth_2_low_pass(), update_butterworth_4_low_pass(), and update_first_order_low_pass().
Referenced by oneloop_andi_propagate_filters(), and oneloop_calc_model_disturbance().
| void vect_bound_nd | ( | float | vect[], |
| float | bound, | ||
| int | n ) |
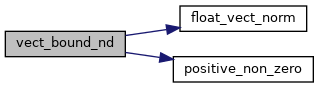
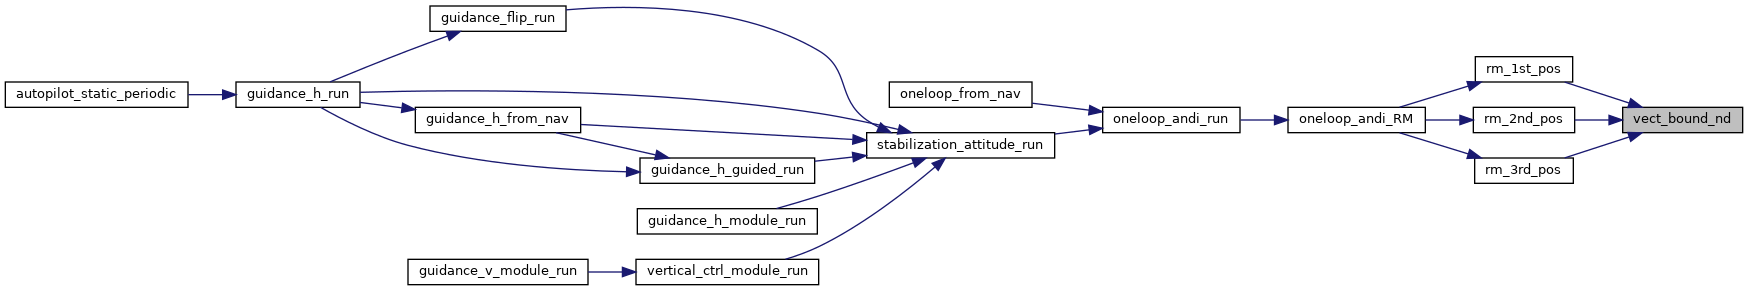
Scale a 3D array to within a 3D bound.
Definition at line 730 of file oneloop_andi.c.
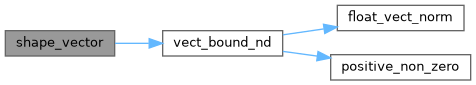
References float_vect_norm(), positive_non_zero(), and scale.
Referenced by ec_3rd_pos(), Pos_PID(), reshape_wind(), rm_1st_pos(), rm_2nd_pos(), rm_3rd_pos(), and shape_vector().
|
static |
Third Order to First Order Dynamics Approximation.
| p1 | Pole 1 |
| p2 | Pole 2 |
| p3 | Pole 3 |
| rm_k | Reference Model Gain |
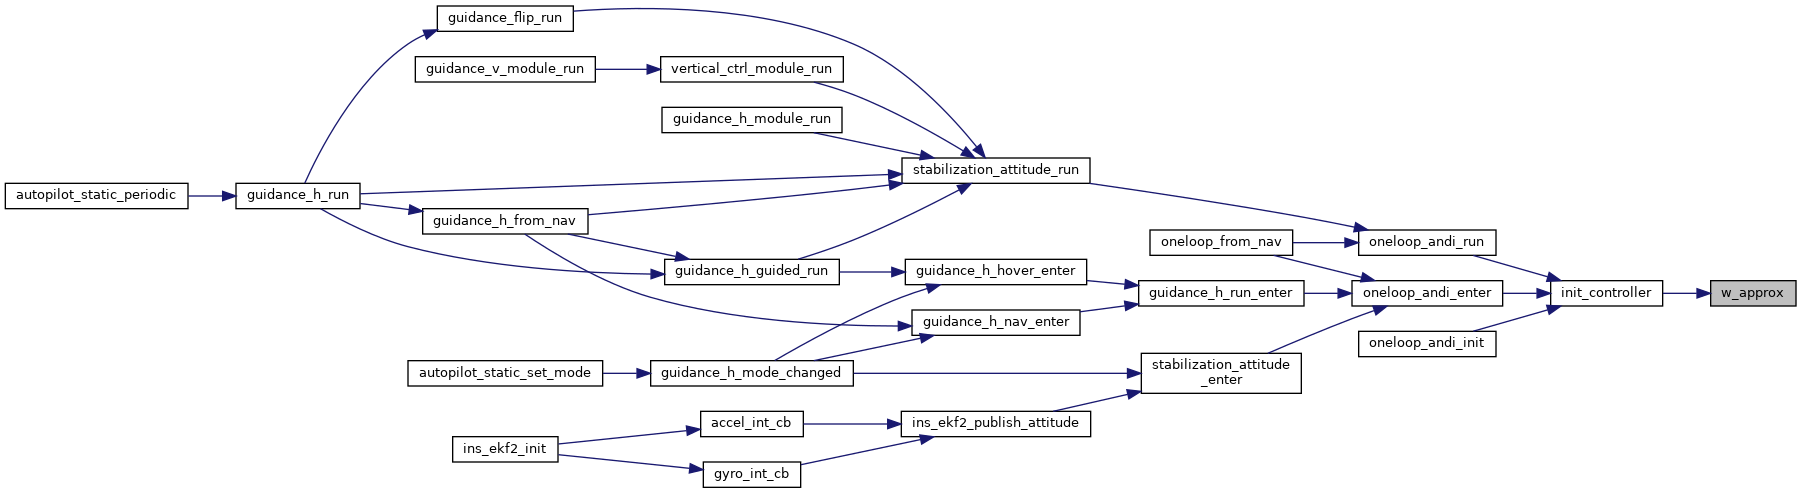
Definition at line 1176 of file oneloop_andi.c.
References positive_non_zero().
Referenced by init_controller_gains(), and init_poles().
| float A_chirp = 250.0 |
Definition at line 524 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
|
static |
Definition at line 458 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), oneloop_andi_run(), and oneloop_nB_RM().
|
static |
Definition at line 202 of file oneloop_andi.c.
| float act_dyn_ctrl[ANDI_NUM_ACT_TOT] = = {1} |
Definition at line 226 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), oneloop_andi_RM(), oneloop_andi_run(), and oneloop_nB_run().
| float act_dynamics[ANDI_NUM_ACT_TOT] = = {1} |
Definition at line 225 of file oneloop_andi.c.
Referenced by calc_normalization(), G1G2_oneloop(), init_controller_gains(), init_poles(), oneloop_andi_init(), oneloop_andi_run(), and oneloop_nB_init().
|
static |
Definition at line 289 of file oneloop_andi.c.
Referenced by calc_normalization(), and get_act_state_oneloop().
| float act_max[ANDI_NUM_ACT_TOT] = = {MAX_PPRZ} |
Definition at line 232 of file oneloop_andi.c.
Referenced by calc_normalization(), compute_wls_u_scaler(), compute_wls_upper_bounds(), get_act_state_oneloop(), oneloop_andi_run(), oneloop_nB_run(), and set_WLS_settings().
| float act_max_norm[ANDI_NUM_ACT_TOT] = = {1.0} |
Definition at line 244 of file oneloop_andi.c.
Referenced by calc_normalization().
| float act_min[ANDI_NUM_ACT_TOT] = = {0.0} |
Definition at line 238 of file oneloop_andi.c.
Referenced by calc_normalization(), compute_wls_lower_bounds(), compute_wls_u_scaler(), get_act_state_oneloop(), oneloop_andi_run(), oneloop_nB_run(), and set_WLS_settings().
| float act_min_norm[ANDI_NUM_ACT_TOT] = = {0.0} |
Definition at line 250 of file oneloop_andi.c.
Referenced by calc_normalization().
| bool actuator_is_servo[ANDI_NUM_ACT_TOT] = {0} |
Definition at line 217 of file oneloop_andi.c.
| float actuator_state_1l[ANDI_NUM_ACT_TOT] |
Definition at line 290 of file oneloop_andi.c.
Referenced by calc_all_thrust_curve(), calc_G1_G2_RW(), get_act_state_oneloop(), oneloop_andi_init(), oneloop_calc_model_disturbance(), oneloop_nB_init(), oneloop_nB_run(), send_oneloop_andi(), and send_oneloop_nB().
|
static |
Definition at line 203 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), init_filter(), oneloop_andi_propagate_filters(), oneloop_andi_sideslip(), oneloop_nB_propagate_filters(), oneloop_nB_sideslip(), and reshape_wind().
| float andi_du[ANDI_NUM_ACT_TOT] |
Definition at line 285 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), and oneloop_nB_init().
| float andi_u[ANDI_NUM_ACT_TOT] |
Definition at line 284 of file oneloop_andi.c.
Referenced by get_act_state_oneloop(), oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_run(), reinit_controller(), and send_oneloop_debug().
|
static |
Definition at line 286 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_init(), and oneloop_nB_run().
| float* bwls_1l[ANDI_OUTPUTS] |
Definition at line 463 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), oneloop_andi_enter(), oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_run(), send_eff_mat_stab_oneloop_nB(), and send_eff_mat_stab_thrust_oneloop_nB().
| int8_t chirp_axis = 6 |
Definition at line 525 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), send_chirp(), set_current_chirp_values(), and sys_id_chirp_axis_handler().
| bool chirp_first_call = true |
Definition at line 518 of file oneloop_andi.c.
Referenced by chirp_call(), and oneloop_andi_RM().
| int16_t chirp_n_counter = 0 |
Definition at line 528 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| int16_t chirp_n_repeat = 10 |
Definition at line 527 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| bool chirp_on = false |
Definition at line 517 of file oneloop_andi.c.
Referenced by chirp_call(), oneloop_andi_RM(), and oneloop_andi_run().
| float coupling_factor[ANDI_OUTPUTS] |
Definition at line 467 of file oneloop_andi.c.
Referenced by oneloop_axis_effectiveness_calc().
| bool ctrl_off = false |
Definition at line 460 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), oneloop_andi_run(), and oneloop_nB_RM().
| int16_t delay_counter = 0 |
Definition at line 530 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| bool drop_aD = false |
Definition at line 480 of file oneloop_andi.c.
Referenced by chirp_call(), drop_axis(), oneloop_andi_run(), and set_WLS_settings().
| bool drop_aE = false |
Definition at line 479 of file oneloop_andi.c.
Referenced by chirp_call(), chirp_pos(), and oneloop_andi_run().
| bool drop_aN = false |
Definition at line 478 of file oneloop_andi.c.
Referenced by chirp_call(), chirp_pos(), and oneloop_andi_run().
| bool drop_pitch = false |
Definition at line 477 of file oneloop_andi.c.
Referenced by chirp_call(), drop_axis(), oneloop_andi_run(), and set_WLS_settings().
| bool drop_roll = false |
Definition at line 476 of file oneloop_andi.c.
Referenced by chirp_call(), drop_axis(), oneloop_andi_run(), and set_WLS_settings().
| bool drop_yaw = false |
Definition at line 475 of file oneloop_andi.c.
Referenced by chirp_call(), drop_axis(), G1G2_oneloop(), oneloop_andi_RM(), oneloop_andi_run(), and set_WLS_settings().
|
static |
Definition at line 133 of file oneloop_andi.c.
Referenced by calc_normalization(), oneloop_andi_RM(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), spin_man_ramp_ref(), spin_man_update(), and Vel_PID_ARW().
| float ec_headroom = 1.5 |
Definition at line 410 of file oneloop_andi.c.
Referenced by ec_3rd_att(), and ec_3rd_pos().
| float EFF_MAT_G[ANDI_OUTPUTS][ANDI_NUM_ACT_TOT] |
Definition at line 464 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), oneloop_andi_enter(), oneloop_andi_init(), oneloop_andi_run(), oneloop_axis_effectiveness_calc(), oneloop_calc_model_disturbance(), and oneloop_nB_RM().
| struct FloatEulers eulers_zxy |
Definition at line 363 of file oneloop_andi.c.
| struct FloatEulers eulers_zxy_des |
Definition at line 362 of file oneloop_andi.c.
Referenced by eul_of_acc(), eul_of_acc(), oneloop_andi_init(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), reinit_controller(), send_oneloop_andi(), and send_oneloop_nB().
| float f0_chirp = 0.2 |
Definition at line 521 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| float f1_chirp = 0.2 |
Definition at line 522 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
|
static |
Definition at line 200 of file oneloop_andi.c.
Referenced by init_filter(), and Pos_PID().
| int16_t firing_counter = 0 |
Definition at line 529 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| float fwd_sideslip_gain = 0.2 |
Definition at line 376 of file oneloop_andi.c.
Referenced by oneloop_andi_sideslip(), and oneloop_nB_sideslip().
|
static |
Definition at line 134 of file oneloop_andi.c.
Referenced by ballistic_touchdown_run(), image_calculate_g(), ins_flow_update(), light_scheduler_set(), light_ws2812_arch_set(), oneloop_andi_sideslip(), oneloop_nB_sideslip(), pprz_circfit_wei_float(), send_ins_flow(), snake_gate_detection(), xgeqrf(), and xgeqrf_f().
|
static |
Definition at line 459 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), and oneloop_nB_run().
| float gi_unbounded_airspeed_sp = 0.0 |
Definition at line 413 of file oneloop_andi.c.
| bool heading_manual = false |
Definition at line 309 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_RM(), and oneloop_nB_run().
| float k1_NE_tune = 0.6 |
Definition at line 505 of file oneloop_andi.c.
Referenced by init_controller_gains().
| float k2_NE_tune = 1.85 |
Definition at line 506 of file oneloop_andi.c.
Referenced by init_controller_gains().
| struct Gains3rdOrder k_att_e |
Definition at line 498 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_run(), oneloop_calc_model_disturbance(), oneloop_nB_run(), and SpinQuad_overwrite().
| struct Gains3rdOrder k_att_e_indi |
Definition at line 503 of file oneloop_andi.c.
Referenced by init_controller_gains(), and oneloop_andi_run().
| struct Gains3rdOrder k_att_rm |
Definition at line 499 of file oneloop_andi.c.
Referenced by generate_reference_attitude(), init_controller_gains(), oneloop_andi_RM(), and oneloop_nB_RM().
| float k_D = 1.2 |
Definition at line 509 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
| float k_I = 9.0e-4 |
Definition at line 510 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
| float k_P = 0.6 |
Definition at line 508 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
| struct Gains3rdOrder k_pos_e |
Definition at line 500 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_run(), and oneloop_nB_RM().
| struct Gains3rdOrder k_pos_e_indi |
Definition at line 504 of file oneloop_andi.c.
Referenced by init_controller_gains(), and oneloop_andi_run().
| struct Gains3rdOrder k_pos_rm |
Definition at line 501 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_RM(), and reshape_wind().
| struct Oneloop_LP_t LP |
Definition at line 189 of file oneloop_andi.c.
Referenced by init_all_LP(), init_all_LP(), init_LP(), init_LP(), oneloop_andi_propagate_filters(), oneloop_andi_run(), oneloop_nB_calc_nB_states(), oneloop_nB_propagate_filters(), oneloop_nB_run(), reinit_all_LP(), reinit_all_LP(), reinit_LP(), reinit_LP(), reinit_LP_synchronous(), reinit_LP_synchronous(), and send_oneloop_debug().
| float m_array[ANDI_NUM_ACT_TOT] |
Definition at line 466 of file oneloop_andi.c.
Referenced by oneloop_axis_effectiveness_calc().
| float max_a_nav = 4.0 |
Definition at line 384 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_RM(), oneloop_andi_run(), and reshape_wind().
| float max_as = 19.0f |
Definition at line 407 of file oneloop_andi.c.
Referenced by guidance_set_min_max_airspeed(), and reshape_wind().
| float max_j_lin = 500.0 |
Definition at line 390 of file oneloop_andi.c.
Referenced by calc_normalization(), and oneloop_andi_RM().
| float max_r = RadOfDeg(120.0) |
Definition at line 295 of file oneloop_andi.c.
Referenced by attitude_ref_quat_int_set_max_r(), oneloop_andi_RM(), and oneloop_nB_RM().
| float max_v_nav = 5.0 |
Definition at line 396 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_RM(), and oneloop_andi_run().
| float max_v_nav_v = 1.5 |
Definition at line 402 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| float min_as = 0.0f |
Definition at line 408 of file oneloop_andi.c.
Referenced by guidance_set_min_max_airspeed(), and reshape_wind().
| struct Oneloop_DynFilt_t mu_mL |
Definition at line 191 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), and oneloop_andi_run().
| struct Oneloop_DynFilt_t mu_mR |
Definition at line 192 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), and oneloop_andi_run().
| bool multiple_chirp_run = false |
Definition at line 531 of file oneloop_andi.c.
Referenced by oneloop_andi_enter(), and oneloop_andi_RM().
| float n_array[ANDI_OUTPUTS] |
Definition at line 465 of file oneloop_andi.c.
Referenced by oneloop_axis_effectiveness_calc().
|
static |
Definition at line 411 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), oneloop_andi_RM(), oneloop_nB_init(), oneloop_nB_RM(), and reshape_wind().
|
static |
Definition at line 412 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), oneloop_andi_RM(), oneloop_nB_init(), and reshape_wind().
| float nu[ANDI_OUTPUTS] |
Definition at line 287 of file oneloop_andi.c.
Referenced by control_error_attitude(), control_error_rate(), control_error_thrust(), drop_axis(), normalize_nu(), oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_state_compensation(), and send_oneloop_debug().
| float nu_n[ANDI_OUTPUTS] |
Definition at line 288 of file oneloop_andi.c.
Referenced by normalize_nu(), oneloop_andi_init(), and oneloop_nB_init().
| float nu_norm_max = 1.0 |
Definition at line 256 of file oneloop_andi.c.
Referenced by calc_normalization().
| float num_thrusters_oneloop = 4.0 |
Definition at line 209 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), and oneloop_nB_run().
| struct OneloopGeneral oneloop_andi |
Definition at line 132 of file oneloop_andi.c.
Referenced by chirp_pos(), get_act_state_oneloop(), guidance_oneloop_run_mode(), oneloop_andi_bound_disturbance(), oneloop_andi_enter(), oneloop_andi_init(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_calc_model_disturbance(), oneloop_from_nav(), reinit_controller(), reshape_wind(), send_guidance_oneloop_andi(), send_oneloop_andi(), and stabilization_attitude_run().
| float oneloop_andi_dist_bound[ANDI_OUTPUTS] |
Definition at line 469 of file oneloop_andi.c.
Referenced by oneloop_andi_bound_disturbance().
| float oneloop_andi_filt_cutoff = 2.0 |
Definition at line 143 of file oneloop_andi.c.
Referenced by init_filter().
| float oneloop_andi_filt_cutoff_a = 2.0 |
Definition at line 149 of file oneloop_andi.c.
| float oneloop_andi_filt_cutoff_p = 20.0 |
Definition at line 162 of file oneloop_andi.c.
| float oneloop_andi_filt_cutoff_q = 20.0 |
Definition at line 169 of file oneloop_andi.c.
| float oneloop_andi_filt_cutoff_r = 20.0 |
Definition at line 176 of file oneloop_andi.c.
| float oneloop_andi_filt_cutoff_v = 30.0 |
Definition at line 155 of file oneloop_andi.c.
Referenced by init_filter().
| float oneloop_andi_model[ANDI_OUTPUTS] |
Definition at line 468 of file oneloop_andi.c.
Referenced by oneloop_andi_bound_disturbance(), oneloop_andi_RM(), oneloop_andi_run(), and oneloop_calc_model_disturbance().
| struct Oneloop_LP_t oneloop_andi_model_filt |
Definition at line 190 of file oneloop_andi.c.
Referenced by init_all_LP(), oneloop_andi_run(), oneloop_calc_model_disturbance(), and reinit_all_LP().
| float oneloop_andi_sigma = 29.0 |
Definition at line 194 of file oneloop_andi.c.
Referenced by chirp_pos(), and oneloop_andi_run().
| float oneloop_andi_sigma_max = 29.0 |
Definition at line 195 of file oneloop_andi.c.
Referenced by chirp_pos().
| float oneloop_andi_sigma_min = 8.0 |
Definition at line 196 of file oneloop_andi.c.
Referenced by chirp_pos().
| float oneloop_andi_yaw_dist_limit = 99999.f |
Definition at line 303 of file oneloop_andi.c.
| struct PolePlacement p_alt_e |
Definition at line 492 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
| struct PolePlacement p_alt_rm |
Definition at line 493 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
| struct PolePlacement p_att_e |
Definition at line 485 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
| struct PolePlacement p_att_rm |
Definition at line 487 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
| struct PolePlacement p_head_e |
Definition at line 495 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
| struct PolePlacement p_head_rm |
Definition at line 496 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
| struct PolePlacement p_pos_e |
Definition at line 489 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
| struct PolePlacement p_pos_rm |
Definition at line 490 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
| float p_ref_0[3] = {0.0, 0.0, 0.0} |
Definition at line 526 of file oneloop_andi.c.
Referenced by chirp_call(), chirp_pos(), and oneloop_andi_RM().
| struct PolePlacement p_roll_e |
Definition at line 486 of file oneloop_andi.c.
Referenced by init_controller_gains(), and init_poles().
|
static |
Definition at line 367 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
|
static |
Definition at line 461 of file oneloop_andi.c.
Referenced by chirp_pos(), and oneloop_andi_run().
| float psi_des_deg = 0.0 |
Definition at line 365 of file oneloop_andi.c.
Referenced by oneloop_andi_enter(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_enter(), oneloop_nB_RM(), and oneloop_nB_run().
| float psi_des_rad = 0.0 |
Definition at line 364 of file oneloop_andi.c.
Referenced by chirp_pos(), oneloop_andi_enter(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_enter(), oneloop_nB_RM(), oneloop_nB_run(), and send_oneloop_debug().
|
static |
Definition at line 366 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and oneloop_nB_RM().
| float ratio_u_un[ANDI_NUM_ACT_TOT] |
Definition at line 470 of file oneloop_andi.c.
Referenced by calc_normalization(), G1G2_oneloop(), oneloop_andi_run(), oneloop_axis_effectiveness_calc(), oneloop_calc_model_disturbance(), oneloop_nB_RM(), oneloop_nB_run(), and set_WLS_settings().
| float ratio_vn_v[ANDI_OUTPUTS] |
Definition at line 471 of file oneloop_andi.c.
Referenced by calc_normalization(), G1G2_oneloop(), normalize_nu(), oneloop_axis_effectiveness_calc(), oneloop_calc_model_disturbance(), and oneloop_nB_RM().
| struct OneloopStabilizationRef sta_bounds |
Definition at line 318 of file oneloop_andi.c.
Referenced by calc_normalization(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_RM(), oneloop_nB_run(), and SpinQuad_overwrite().
| float t_0_chirp = 0.0 |
Definition at line 520 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
| float t_chirp = 0.65 |
Definition at line 523 of file oneloop_andi.c.
Referenced by chirp_call(), chirp_pos(), and oneloop_andi_RM().
| float temp_D_error[3] |
Definition at line 512 of file oneloop_andi.c.
Referenced by Pos_PID(), and send_oneloop_debug().
| float temp_I_error[3] |
Definition at line 513 of file oneloop_andi.c.
Referenced by Pos_PID(), and send_oneloop_debug().
| float temp_P_error[3] |
Definition at line 511 of file oneloop_andi.c.
Referenced by Pos_PID(), and send_oneloop_debug().
| float theta_pref_max = RadOfDeg(20.0) |
Definition at line 270 of file oneloop_andi.c.
Referenced by chirp_pos(), and oneloop_andi_run().
| float time_elapsed_chirp = 0.0 |
Definition at line 519 of file oneloop_andi.c.
Referenced by oneloop_andi_RM().
|
static |
Definition at line 204 of file oneloop_andi.c.
Referenced by init_filter(), oneloop_andi_run(), oneloop_calc_model_disturbance(), oneloop_nB_run(), and reinit_all_LP().
|
static |
Definition at line 262 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), and set_WLS_settings().
| bool use_dyn_filter = false |
Definition at line 193 of file oneloop_andi.c.
Referenced by oneloop_andi_run().
| struct WLS_t WLS_one_p |
Definition at line 423 of file oneloop_andi.c.
Referenced by normalize_nu(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_run(), send_wls_u_oneloop(), send_wls_u_oneloop(), send_wls_v_oneloop(), send_wls_v_oneloop(), and set_WLS_settings().
|
static |
Definition at line 455 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), and set_WLS_settings().
| float Wu_quad_motors_fwd = 6.0 |
Definition at line 418 of file oneloop_andi.c.
Referenced by oneloop_andi_run().
|
static |
Definition at line 449 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and set_WLS_settings().
| float xdot_lim_sf = 0.8 |
Definition at line 409 of file oneloop_andi.c.
Referenced by bound_v_from_a(), and bound_v_from_a_vect().
| bool yaw_stick_in_auto = false |
Definition at line 315 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and oneloop_nB_RM().
 1.15.0