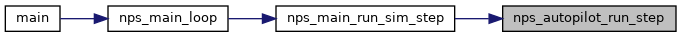|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
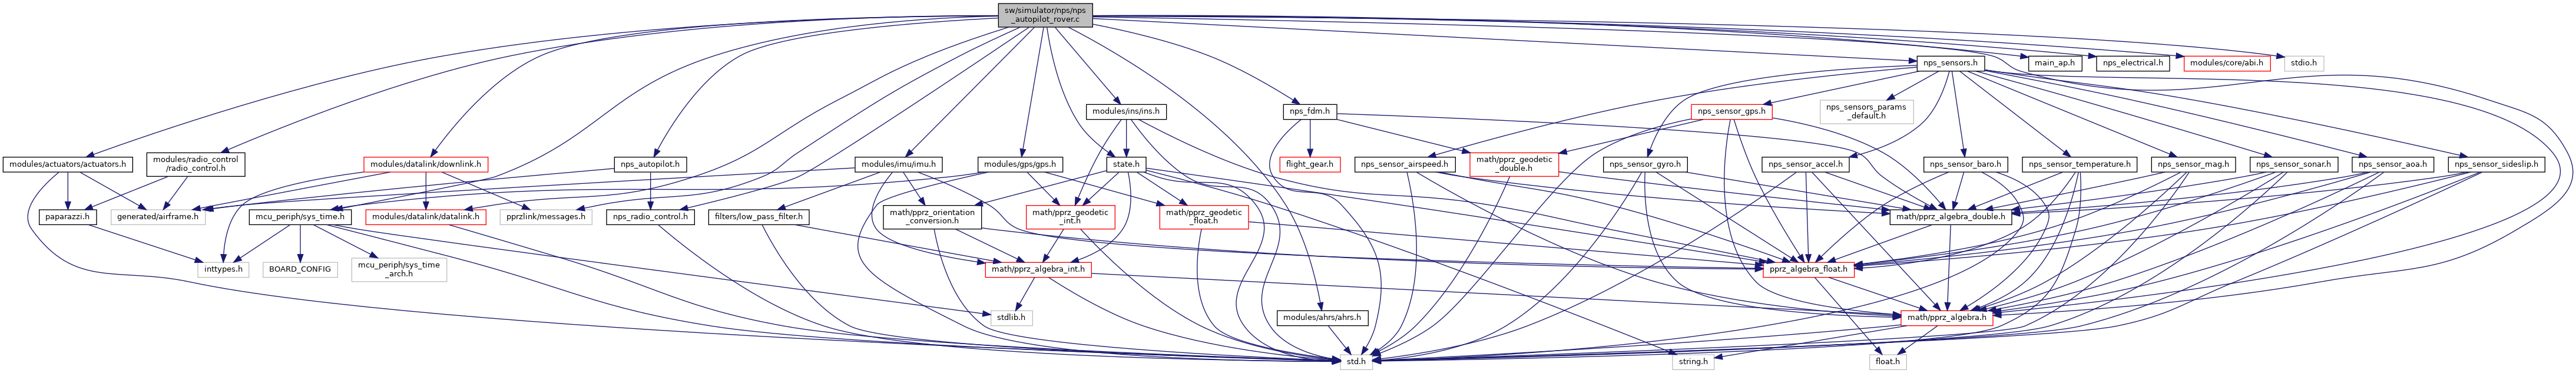
#include "nps_autopilot.h"#include "main_ap.h"#include "nps_sensors.h"#include "nps_radio_control.h"#include "nps_electrical.h"#include "nps_fdm.h"#include "modules/radio_control/radio_control.h"#include "modules/imu/imu.h"#include "mcu_periph/sys_time.h"#include "state.h"#include "modules/ahrs/ahrs.h"#include "modules/ins/ins.h"#include "math/pprz_algebra.h"#include "modules/core/abi.h"#include "pprzlink/messages.h"#include "modules/datalink/downlink.h"#include "modules/datalink/datalink.h"#include "modules/actuators/actuators.h"#include <stdio.h>#include "modules/gps/gps.h"Go to the source code of this file.
Macros | |
| #define | NPS_BYPASS_AHRS FALSE |
| #define | NPS_BYPASS_INS FALSE |
Functions | |
| void | sys_tick_handler (void) |
| void | nps_autopilot_init (enum NpsRadioControlType type_rc, int num_rc_script, char *rc_dev) |
| void | nps_autopilot_run_systime_step (void) |
| void | nps_autopilot_run_step (double time) |
| void | sim_overwrite_ahrs (void) |
| void | sim_overwrite_ins (void) |
Variables | |
| struct NpsAutopilot | nps_autopilot |
| #ifndef NPS_NO_MOTOR_MIXING #include "modules/actuators/motor_mixing.h" | |
| bool | nps_bypass_ahrs |
| bool | nps_bypass_ins |
| #define NPS_BYPASS_AHRS FALSE |
Definition at line 61 of file nps_autopilot_rover.c.
| #define NPS_BYPASS_INS FALSE |
Definition at line 65 of file nps_autopilot_rover.c.
| void nps_autopilot_init | ( | enum NpsRadioControlType | type_rc, |
| int | num_rc_script, | ||
| char * | rc_dev ) |
Definition at line 74 of file nps_autopilot_rover.c.
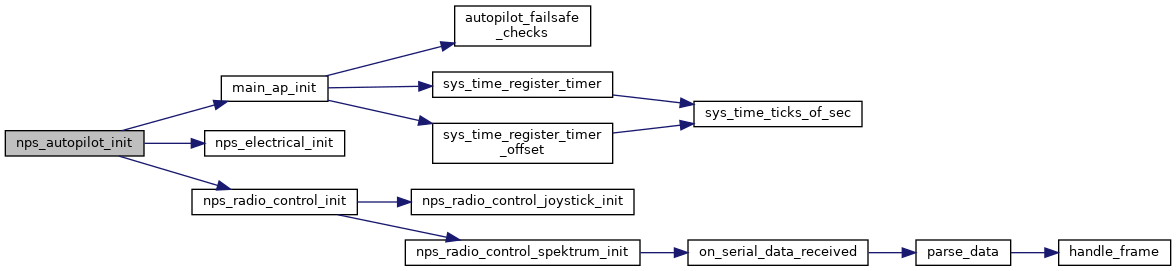
References FALSE, main_ap_init(), nps_autopilot, NPS_BYPASS_AHRS, nps_bypass_ahrs, NPS_BYPASS_INS, nps_bypass_ins, nps_electrical_init(), nps_radio_control_init(), and TRUE.
Referenced by nps_radio_and_autopilot_init().
| void nps_autopilot_run_step | ( | double | time | ) |
Definition at line 97 of file nps_autopilot_rover.c.
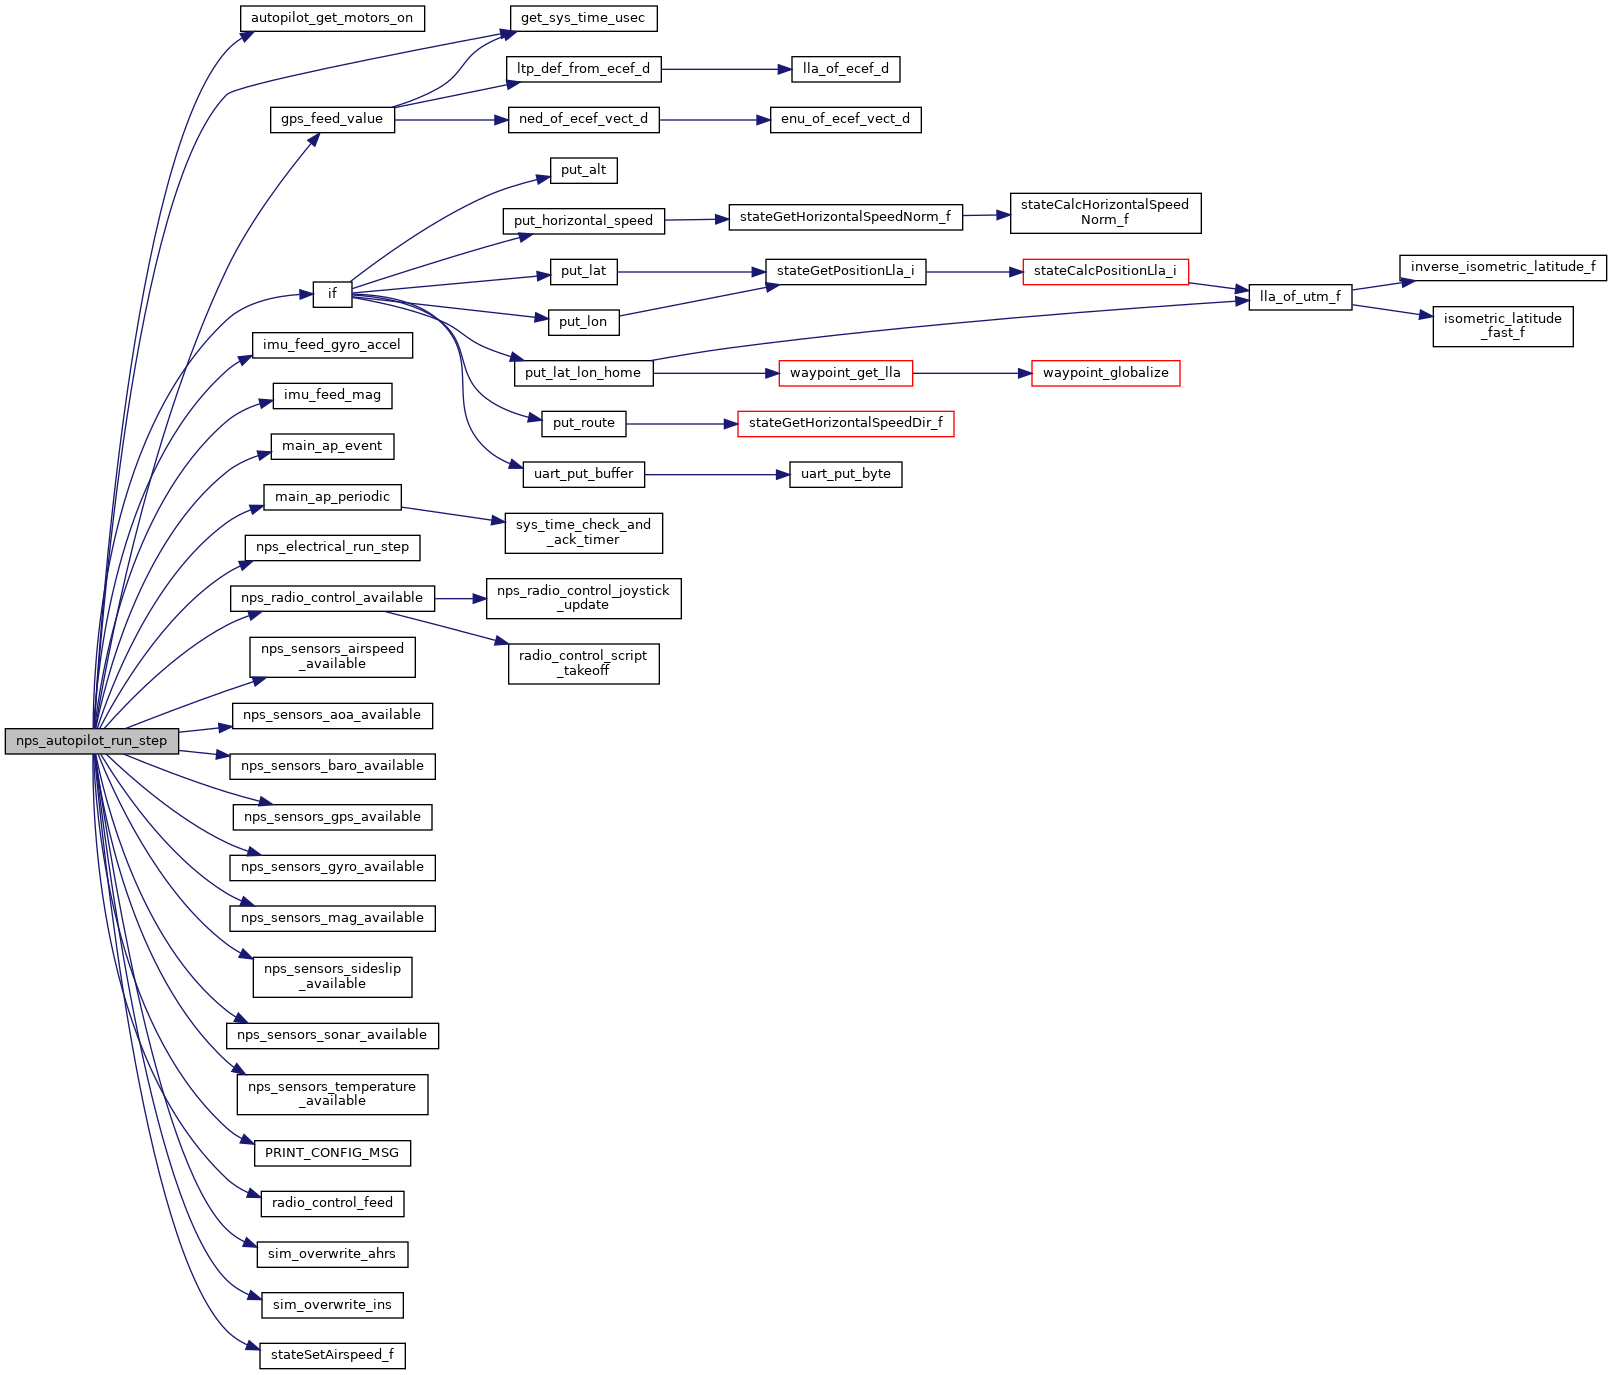
References AGL_SONAR_NPS_ID, AIRSPEED_NPS_ID, autopilot, autopilot_get_motors_on(), BARO_SIM_SENDER_ID, COMMAND_PITCH, COMMAND_ROLL, commands, DefaultChannel, DefaultDevice, foo, get_sys_time_usec(), gps_feed_value(), imu_feed_gyro_accel(), imu_feed_mag(), INCIDENCE_NPS_ID, main_ap_event(), main_ap_periodic(), MAX_PPRZ, nps_autopilot, nps_bypass_ahrs, nps_bypass_ins, NPS_COMMANDS_NB, nps_electrical_run_step(), nps_radio_control_available(), nps_sensors_airspeed_available(), nps_sensors_aoa_available(), nps_sensors_baro_available(), nps_sensors_gps_available(), nps_sensors_gyro_available(), nps_sensors_mag_available(), nps_sensors_sideslip_available(), nps_sensors_sonar_available(), nps_sensors_temperature_available(), PRINT_CONFIG_MSG(), PRINT_CONFIG_VAR(), radio_control_feed(), sensors, sim_overwrite_ahrs(), sim_overwrite_ins(), stateSetAirspeed_f(), and TEMPERATURE_TYPE_AIR.
Referenced by nps_main_run_sim_step().
| void nps_autopilot_run_systime_step | ( | void | ) |
Definition at line 89 of file nps_autopilot_rover.c.
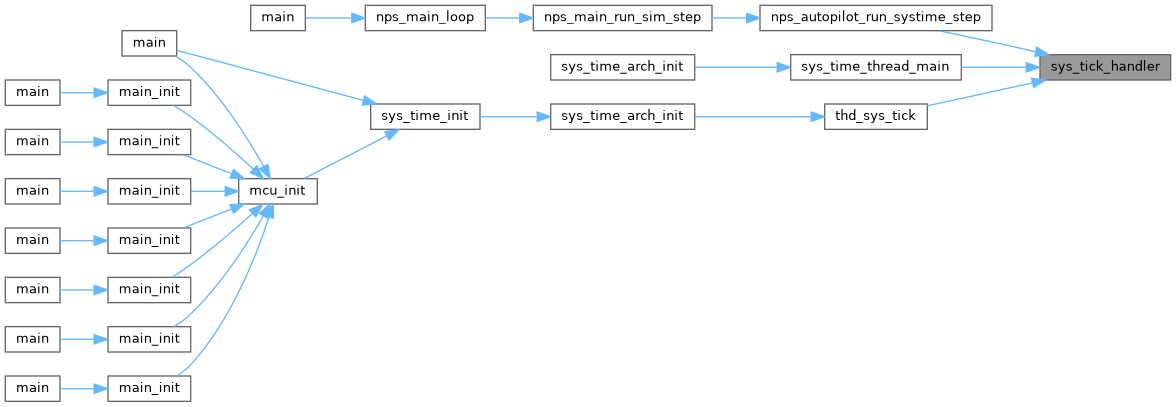
References sys_tick_handler().
Referenced by nps_main_run_sim_step().
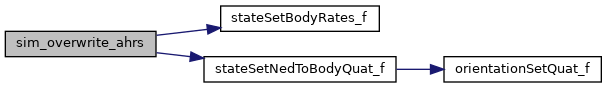
| void sim_overwrite_ahrs | ( | void | ) |
Definition at line 185 of file nps_autopilot_rover.c.
References fdm, QUAT_COPY, RATES_COPY, STATE_INPUT_ATTITUDE, stateSetBodyRates_f(), stateSetInputFilter(), and stateSetNedToBodyQuat_f().
Referenced by nps_autopilot_run_step().
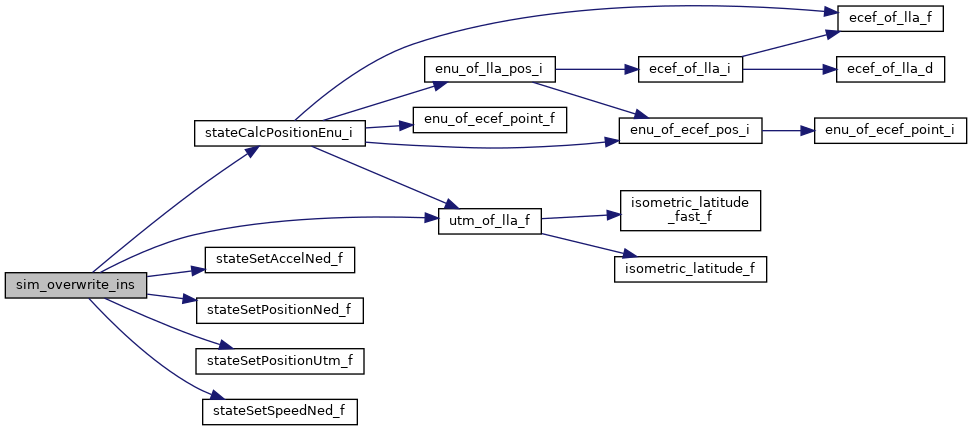
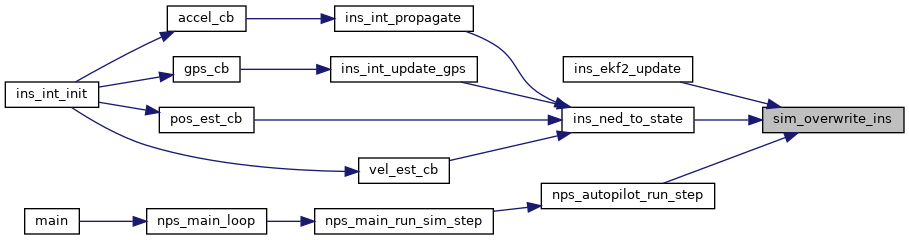
| void sim_overwrite_ins | ( | void | ) |
Definition at line 199 of file nps_autopilot_rover.c.
References fdm, LLA_COPY, state, stateCalcPositionEnu_i(), stateSetAccelNed_f(), stateSetPositionLla_f(), stateSetPositionNed_f(), stateSetSpeedNed_f(), and VECT3_COPY.
Referenced by ins_ekf2_update(), ins_ned_to_state(), ins_ned_to_state(), and nps_autopilot_run_step().
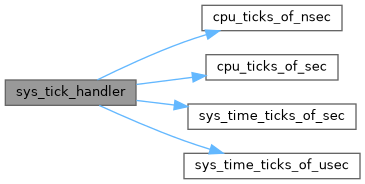
| void sys_tick_handler | ( | void | ) |
Definition at line 155 of file sys_time_arch.c.
References sys_time_timer::cb, CH_CFG_ST_FREQUENCY, cpu_counter, cpu_ticks, cpu_ticks_of_nsec(), cpu_ticks_of_sec(), sys_time::cpu_ticks_per_sec, sys_time_timer::duration, sys_time_timer::elapsed, sys_time_timer::end_time, sys_time_timer::in_use, LED_TOGGLE, sys_time::nb_sec, sys_time::nb_sec_rem, sys_time::nb_tick, sys_time::resolution_cpu_ticks, startup_time, SYS_TIME_NB_TIMER, sys_time_ticks_of_sec(), sys_time_ticks_of_usec(), sys_time::timer, and TRUE.
Referenced by nps_autopilot_run_systime_step(), sys_time_thread_main(), and thd_sys_tick().
| struct NpsAutopilot nps_autopilot |
#ifndef NPS_NO_MOTOR_MIXING #include "modules/actuators/motor_mixing.h"
if NPS_COMMANDS_NB != MOTOR_MIXING_NB_MOTOR #warning "NPS_COMMANDS_NB does not match MOTOR_MIXING_NB_MOTOR!" #endif #endif
Definition at line 56 of file nps_autopilot_rover.c.
| bool nps_bypass_ahrs |
Definition at line 57 of file nps_autopilot_rover.c.
Referenced by nps_autopilot_init(), nps_autopilot_init(), and nps_autopilot_run_step().
| bool nps_bypass_ins |
Definition at line 58 of file nps_autopilot_rover.c.
Referenced by ins_ekf2_update(), ins_ned_to_state(), ins_ned_to_state(), nps_autopilot_init(), nps_autopilot_init(), and nps_autopilot_run_step().
 1.15.0