|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
UAVCan actuators using RAWCOMMAND message and ESC_STATUS telemetry. More...
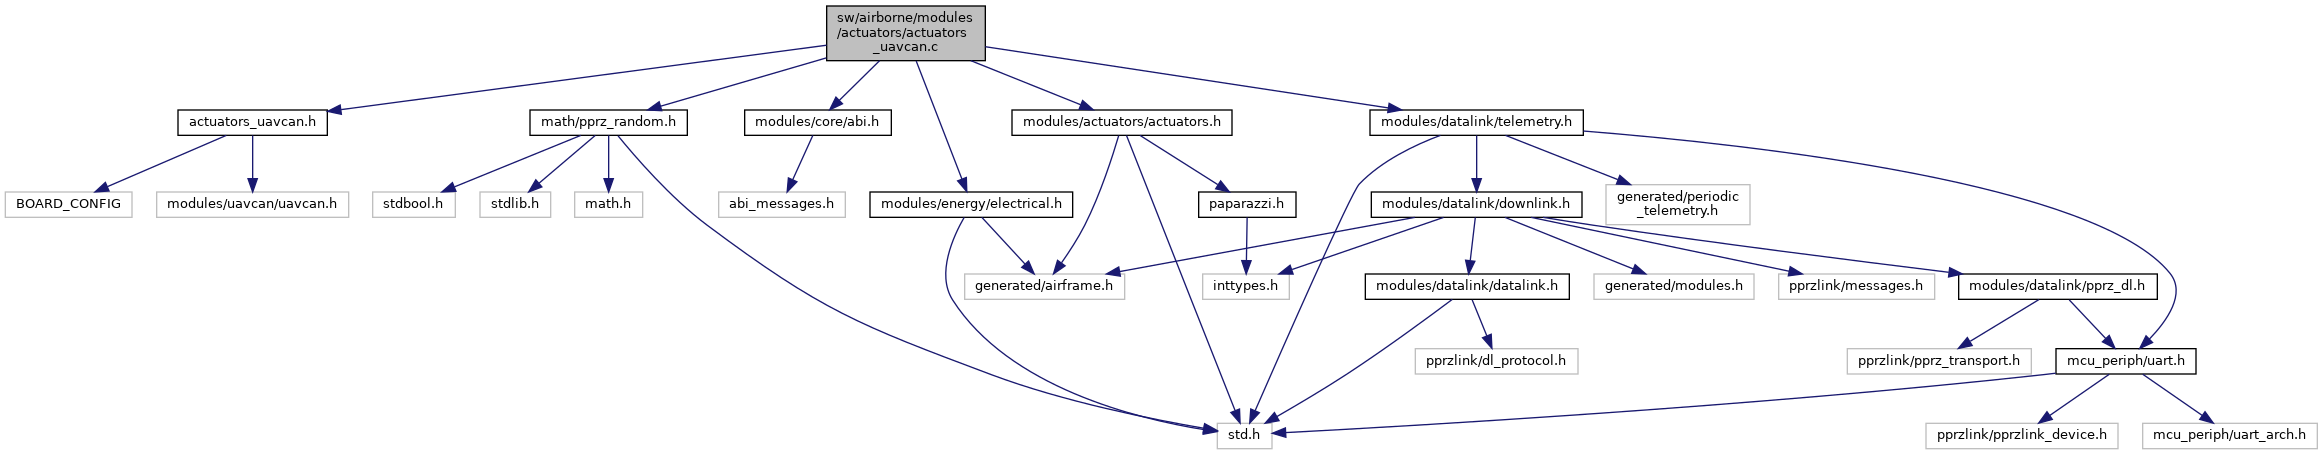
#include "actuators_uavcan.h"#include "modules/energy/electrical.h"#include "math/pprz_random.h"#include "modules/core/abi.h"#include "modules/actuators/actuators.h"#include <math.h>#include "uavcan.equipment.esc.Status.h"#include "uavcan.equipment.esc.RawCommand.h"#include "uavcan.equipment.actuator.Status.h"#include "uavcan.equipment.actuator.ArrayCommand.h"#include "uavcan.equipment.device.Temperature.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Data Structures | |
| struct | actuators_uavcan_telem_t |
Macros | |
| #define | UAVCAN_ACTUATORS_USE_CURRENT TRUE |
| #define | UNITLESS UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_UNITLESS |
| #define | POSITION UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_POSITION |
| #define | FORCE UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_FORCE |
| #define | SPEED UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_SPEED |
| #define | PWM UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_PWM |
| #define | UAVCAN_CMD_UNUSED (MIN_PPRZ-1) |
Functions | |
| static struct actuators_uavcan_telem_t * | actuators_uavcan_next_telem (void) |
| static void | actuators_uavcan_send_esc (struct transport_tx *trans, struct link_device *dev) |
| static struct actuators_uavcan_telem_t * | get_actuator_telem (struct uavcan_iface_t *iface, uint8_t idx) |
| static uint8_t | get_actuator_idx (struct uavcan_iface_t *iface, uint8_t idx) |
| static void | actuators_uavcan_esc_status_cb (struct uavcan_iface_t *iface, CanardRxTransfer *transfer) |
| Whevener an ESC_STATUS message from the EQUIPMENT group is received. | |
| static void | actuators_uavcan_actuator_status_cb (struct uavcan_iface_t *iface, CanardRxTransfer *transfer) |
| Whevener an ACTUATOR_STATUS message from the EQUIPMENT group is received. | |
| static void | actuators_uavcan_device_temperature_cb (struct uavcan_iface_t *iface, CanardRxTransfer *transfer) |
| Whevener an DEVICE_TEMPERATURE message from the EQUIPMENT group is received. | |
| void | actuators_uavcan_init (struct uavcan_iface_t *iface) |
| Initialize an uavcan interface. | |
| void | actuators_uavcan_commit (struct uavcan_iface_t *iface, int16_t *values, uint8_t nb) |
| Commit actuator values to the uavcan interface (EQUIPMENT_ESC_RAWCOMMAND). | |
| void | actuators_uavcan_cmd_commit (struct uavcan_iface_t *iface, int16_t *values, uint8_t nb) |
| Commit actuator values to the uavcan interface (EQUIPMENT_ACTUATOR_ARRAYCOMMAND). | |
Variables | |
| static bool | actuators_uavcan_initialized = false |
| static uavcan_event | esc_status_ev |
| static uavcan_event | actuator_status_ev |
| static uavcan_event | device_temperature_ev |
| static uint8_t | old_idx = 0 |
| static uint8_t | esc_idx = 0 |
UAVCan actuators using RAWCOMMAND message and ESC_STATUS telemetry.
Definition in file actuators_uavcan.c.
| struct actuators_uavcan_telem_t |
Definition at line 53 of file actuators_uavcan.c.
| Data Fields | ||
|---|---|---|
| float | current | |
| uint32_t | energy | |
| uint8_t | node_id | |
| float | position | |
| int32_t | rpm | |
| bool | set | |
| float | temperature | |
| float | temperature_dev | |
| float | timestamp | |
| float | voltage | |
| #define FORCE UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_FORCE |
Definition at line 48 of file actuators_uavcan.c.
| #define POSITION UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_POSITION |
Definition at line 47 of file actuators_uavcan.c.
| #define PWM UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_PWM |
Definition at line 50 of file actuators_uavcan.c.
| #define SPEED UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_SPEED |
Definition at line 49 of file actuators_uavcan.c.
| #define UAVCAN_ACTUATORS_USE_CURRENT TRUE |
Definition at line 43 of file actuators_uavcan.c.
| #define UAVCAN_CMD_UNUSED (MIN_PPRZ-1) |
Definition at line 144 of file actuators_uavcan.c.
Referenced by actuators_uavcan_cmd_commit(), and actuators_uavcan_init().
| #define UNITLESS UAVCAN_EQUIPMENT_ACTUATOR_COMMAND_COMMAND_TYPE_UNITLESS |
Definition at line 46 of file actuators_uavcan.c.
|
static |
Whevener an ACTUATOR_STATUS message from the EQUIPMENT group is received.
Definition at line 370 of file actuators_uavcan.c.
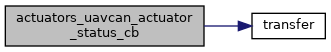
References ACT_FEEDBACK_UAVCAN_ID, act_feedback_t::act_feedback_set_t::force, act_feedback_t::force, get_actuator_idx(), get_actuator_telem(), act_feedback_t::idx, act_feedback_t::act_feedback_set_t::position, act_feedback_t::position, actuators_uavcan_telem_t::position, act_feedback_t::act_feedback_set_t::power, act_feedback_t::power_pct, act_feedback_t::set, act_feedback_t::act_feedback_set_t::speed, act_feedback_t::speed, and transfer().
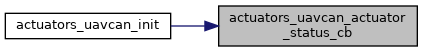
Referenced by actuators_uavcan_init().
| void actuators_uavcan_cmd_commit | ( | struct uavcan_iface_t * | iface, |
| int16_t * | values, | ||
| uint8_t | nb ) |
Commit actuator values to the uavcan interface (EQUIPMENT_ACTUATOR_ARRAYCOMMAND).
Definition at line 492 of file actuators_uavcan.c.
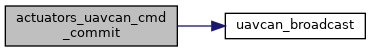
References MAX_PPRZ, MIN_PPRZ, uavcan_broadcast(), and UAVCAN_CMD_UNUSED.
| void actuators_uavcan_commit | ( | struct uavcan_iface_t * | iface, |
| int16_t * | values, | ||
| uint8_t | nb ) |
Commit actuator values to the uavcan interface (EQUIPMENT_ESC_RAWCOMMAND).
Definition at line 471 of file actuators_uavcan.c.
References uavcan_broadcast().
|
static |
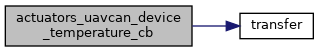
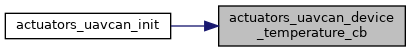
Whevener an DEVICE_TEMPERATURE message from the EQUIPMENT group is received.
Definition at line 409 of file actuators_uavcan.c.
References get_actuator_telem(), actuators_uavcan_telem_t::set, actuators_uavcan_telem_t::temperature_dev, and transfer().
Referenced by actuators_uavcan_init().
|
static |
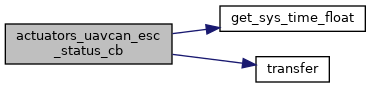
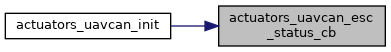
Whevener an ESC_STATUS message from the EQUIPMENT group is received.
Definition at line 313 of file actuators_uavcan.c.
References ACT_FEEDBACK_UAVCAN_ID, actuators_uavcan_telem_t::current, electrical, actuators_uavcan_telem_t::energy, get_actuator_idx(), get_actuator_telem(), get_sys_time_float(), act_feedback_t::idx, actuators_uavcan_telem_t::node_id, act_feedback_t::act_feedback_set_t::rpm, act_feedback_t::rpm, actuators_uavcan_telem_t::rpm, act_feedback_t::set, actuators_uavcan_telem_t::set, actuators_uavcan_telem_t::temperature, actuators_uavcan_telem_t::timestamp, transfer(), and actuators_uavcan_telem_t::voltage.
Referenced by actuators_uavcan_init().
| void actuators_uavcan_init | ( | struct uavcan_iface_t * | iface | ) |
Initialize an uavcan interface.
Definition at line 431 of file actuators_uavcan.c.
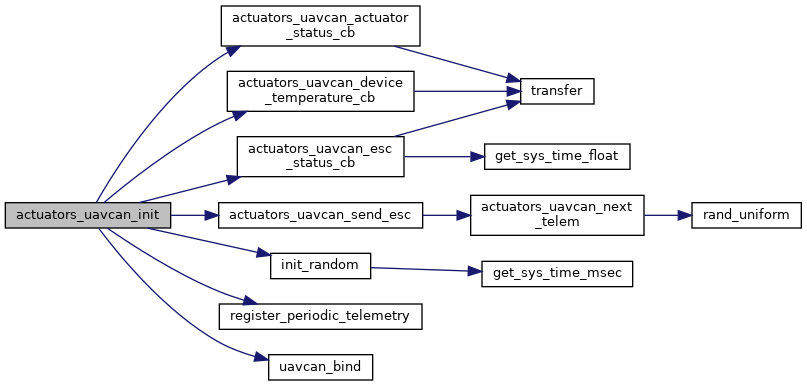
References actuator_status_ev, actuators_uavcan1cmd_values, actuators_uavcan2cmd_values, actuators_uavcan_actuator_status_cb(), actuators_uavcan_device_temperature_cb(), actuators_uavcan_esc_status_cb(), actuators_uavcan_initialized, actuators_uavcan_send_esc(), DefaultPeriodic, device_temperature_ev, esc_status_ev, init_random(), register_periodic_telemetry(), uavcan_bind(), and UAVCAN_CMD_UNUSED.
|
static |
Definition at line 157 of file actuators_uavcan.c.
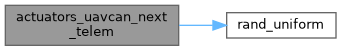
References esc_idx, idx, offset, old_idx, rand_uniform(), and actuators_uavcan_telem_t::set.
Referenced by actuators_uavcan_send_esc().
|
static |
Definition at line 231 of file actuators_uavcan.c.
References actuators_uavcan_next_telem(), actuators_uavcan_telem_t::current, dev, electrical, actuators_uavcan_telem_t::energy, actuators_uavcan_telem_t::node_id, old_idx, actuators_uavcan_telem_t::rpm, rpm, actuators_uavcan_telem_t::temperature, actuators_uavcan_telem_t::temperature_dev, and actuators_uavcan_telem_t::voltage.
Referenced by actuators_uavcan_init().
|
static |
Definition at line 269 of file actuators_uavcan.c.
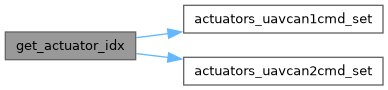
References actuators_uavcan1cmd_set(), actuators_uavcan2cmd_set(), idx, and actuators_uavcan_telem_t::set.
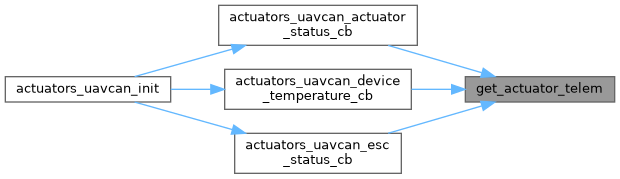
Referenced by actuators_uavcan_actuator_status_cb(), and actuators_uavcan_esc_status_cb().
|
static |
Definition at line 252 of file actuators_uavcan.c.
References idx.
Referenced by actuators_uavcan_actuator_status_cb(), actuators_uavcan_device_temperature_cb(), and actuators_uavcan_esc_status_cb().
|
static |
Definition at line 149 of file actuators_uavcan.c.
Referenced by actuators_uavcan_init().
|
static |
Definition at line 147 of file actuators_uavcan.c.
Referenced by actuators_uavcan_init().
|
static |
Definition at line 150 of file actuators_uavcan.c.
Referenced by actuators_uavcan_init().
|
static |
Definition at line 156 of file actuators_uavcan.c.
Referenced by actuators_uavcan_next_telem().
|
static |
Definition at line 148 of file actuators_uavcan.c.
Referenced by actuators_uavcan_init().
|
static |
Definition at line 155 of file actuators_uavcan.c.
Referenced by actuators_uavcan_next_telem(), and actuators_uavcan_send_esc().
 1.15.0