|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "actuators_uavcan.h"Go to the source code of this file.
Macros | |
| #define | ActuatorUavcan1CmdSet actuators_uavcan1cmd_set |
| #define | ActuatorsUavcan1CmdInit() |
| #define | ActuatorsUavcan1CmdCommit() |
Functions | |
| void | actuators_uavcan1cmd_set (uint8_t idx, int16_t value) |
Variables | |
| int16_t | actuators_uavcan1cmd_values [SERVOS_UAVCAN1CMD_NB] |
| Stub file needed per uavcan interface because of generator. | |
| #define ActuatorsUavcan1CmdCommit | ( | ) |
Definition at line 39 of file actuators_uavcan1cmd.h.
| #define ActuatorsUavcan1CmdInit | ( | ) |
Definition at line 38 of file actuators_uavcan1cmd.h.
| #define ActuatorUavcan1CmdSet actuators_uavcan1cmd_set |
Definition at line 37 of file actuators_uavcan1cmd.h.
|
extern |
Stub file needed per uavcan interface because of generator.
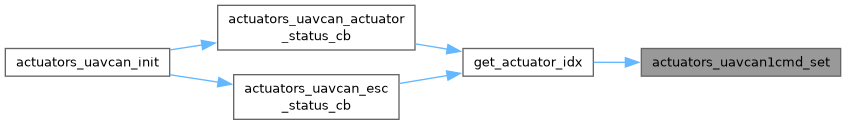
Referenced by actuators_uavcan_init().
 1.15.0