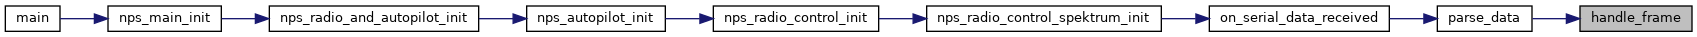|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
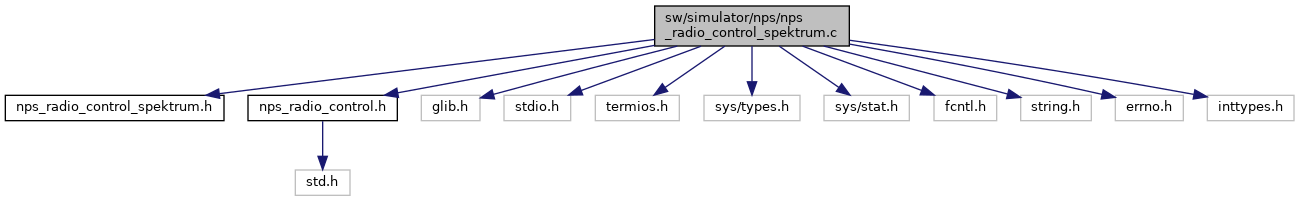
#include "nps_radio_control_spektrum.h"#include "nps_radio_control.h"#include <glib.h>#include <stdio.h>#include <termios.h>#include <sys/types.h>#include <sys/stat.h>#include <fcntl.h>#include <string.h>#include <errno.h>#include <inttypes.h>Go to the source code of this file.
Macros | |
| #define | IUCLC 0 |
| #define | CHANNEL_OF_FRAME(i) |
| #define | SYNC_1 0x03 |
| #define | SYNC_2 0x12 |
| #define | STA_UNINIT 0 |
| #define | STA_GOT_SYNC_1 1 |
| #define | STA_GOT_SYNC_2 2 |
| #define | FRAME_LEN 14 |
Functions | |
| static gboolean | on_serial_data_received (GIOChannel *source, GIOCondition condition, gpointer data) |
| static void | parse_data (char *buf, int len) |
| static void | handle_frame (void) |
| int | nps_radio_control_spektrum_init (const char *device) |
Variables | |
| static int | sp_fd |
| uint8_t | status = STA_UNINIT |
| static uint8_t | frame_buf [FRAME_LEN] |
| static uint32_t | idx = 0 |
| #define CHANNEL_OF_FRAME | ( | i | ) |
| #define FRAME_LEN 14 |
Definition at line 103 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
| #define IUCLC 0 |
Definition at line 17 of file nps_radio_control_spektrum.c.
| #define STA_GOT_SYNC_1 1 |
Definition at line 98 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
| #define STA_GOT_SYNC_2 2 |
Definition at line 99 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
| #define STA_UNINIT 0 |
Definition at line 97 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
| #define SYNC_1 0x03 |
Definition at line 94 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
| #define SYNC_2 0x12 |
Definition at line 95 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
|
static |
Definition at line 141 of file nps_radio_control_spektrum.c.
References CHANNEL_OF_FRAME, and nps_radio_control.
Referenced by parse_data().
| int nps_radio_control_spektrum_init | ( | const char * | device | ) |
Definition at line 31 of file nps_radio_control_spektrum.c.
References B115200, IUCLC, on_serial_data_received(), and sp_fd.
Referenced by nps_radio_control_init().
|
static |
Definition at line 74 of file nps_radio_control_spektrum.c.
References parse_data(), and TRUE.
Referenced by nps_radio_control_spektrum_init().
|
static |
Definition at line 107 of file nps_radio_control_spektrum.c.
References frame_buf, FRAME_LEN, handle_frame(), idx, STA_GOT_SYNC_1, STA_GOT_SYNC_2, STA_UNINIT, status, SYNC_1, and SYNC_2.
Referenced by on_serial_data_received().
Definition at line 104 of file nps_radio_control_spektrum.c.
Referenced by parse_data().
|
static |
Definition at line 105 of file nps_radio_control_spektrum.c.
Referenced by act_feedback_cb(), actuators_asctec_v2_set(), actuators_bebop_set(), actuators_disco_set(), actuators_dshot_set(), actuators_dualpwm_set(), actuators_faulhaber_set(), actuators_md25_set(), actuators_ostrich_set(), actuators_pwm_set(), actuators_sbus_set(), actuators_spektrum_set(), actuators_sts3032_set(), actuators_t4_set(), actuators_uavcan1_set(), actuators_uavcan1cmd_set(), actuators_uavcan2_set(), actuators_uavcan2cmd_set(), actuators_uavcan_next_telem(), air_data_next(), attitude_ref_quat_float_idx_set_omega_p(), attitude_ref_quat_float_idx_set_omega_q(), attitude_ref_quat_float_idx_set_omega_r(), attitude_ref_quat_float_schedule(), baro_cb(), calculate_edge_histogram(), cloud_sensor_callback(), dshotTlmRec(), esc32_get_float(), find_launch_index(), get_actuator_idx(), get_actuator_telem(), image_gradient_pixel(), image_show_points_color(), jpeg_huffman(), mavlink_common_message_handler(), mtostk_populate_float_array_from_buffer(), mtostk_populate_uuid_from_buffer(), osd_put_s(), parse_data(), pfc_act_feedback_cb(), pfc_actuators_value(), power_uavcan_send_power_device(), px4flow_i2c_periodic(), radio_control_get(), radio_control_set(), range_msg_callback(), rm3100_get_raw_from_buf(), rotwing_state_feedback_cb(), rpm_cb(), send_airspeed_raw(), send_baro_raw(), send_gps_relpos(), settings_send_dl_value(), slcan_can_rx_cb(), spi_submit(), stabilization_attitude_gain_schedule(), superbitrf_gen_dsmx_channels(), and vn200_read_message().
|
static |
Definition at line 22 of file nps_radio_control_spektrum.c.
Referenced by nps_radio_control_spektrum_init().
| uint8_t status = STA_UNINIT |
Definition at line 101 of file nps_radio_control_spektrum.c.
 1.15.0