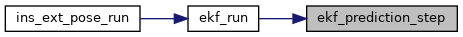|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Integrated Navigation System interface. More...
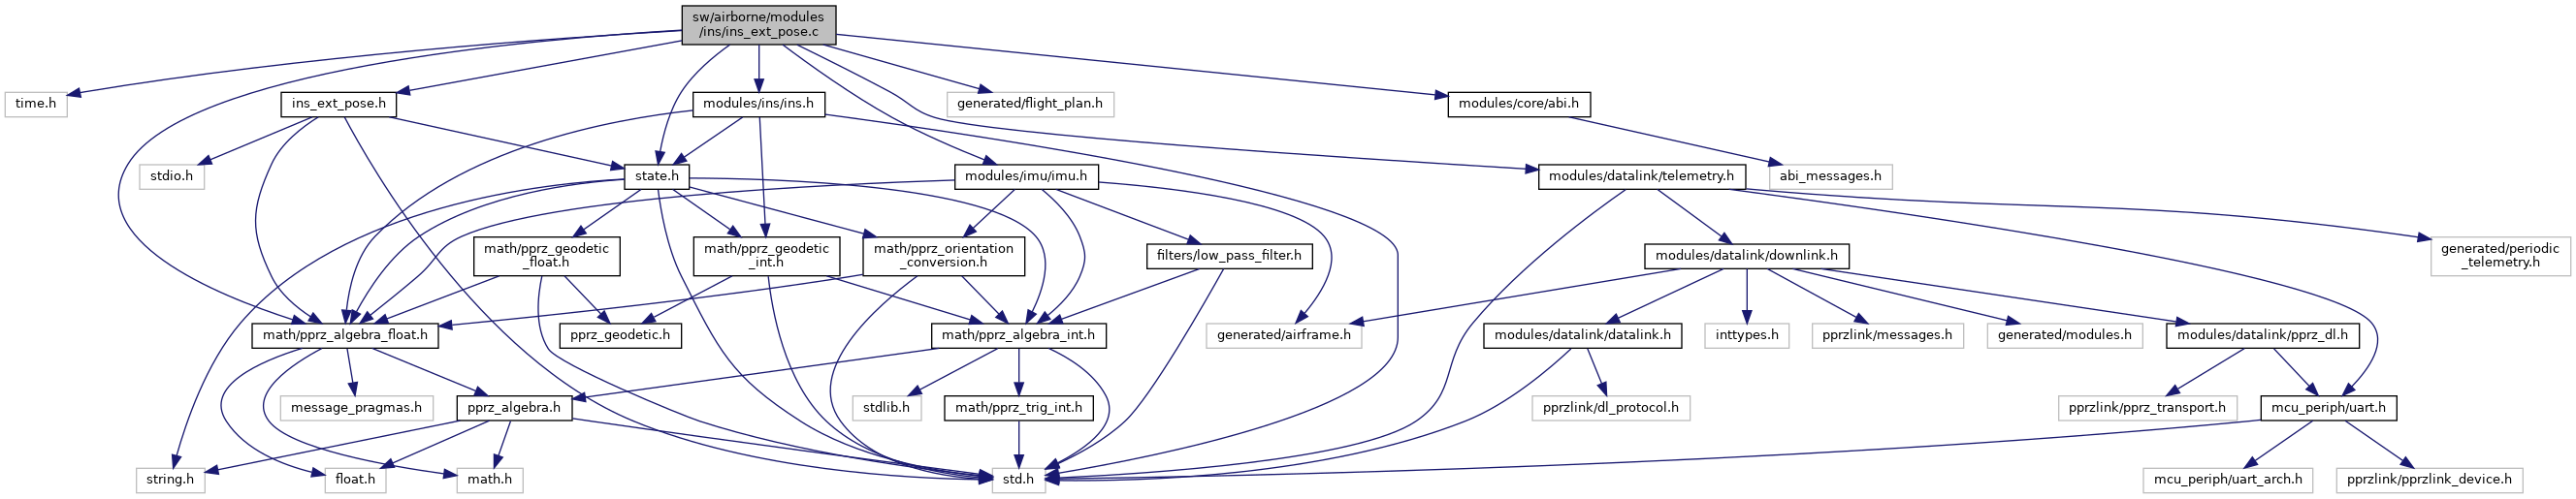
#include <time.h>#include "ins_ext_pose.h"#include "state.h"#include "math/pprz_algebra.h"#include "math/pprz_algebra_float.h"#include "modules/imu/imu.h"#include "modules/ahrs/ahrs.h"#include "modules/ins/ins.h"#include "generated/flight_plan.h"#include "modules/core/abi.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Data Structures | |
| struct | InsExtPose |
| Data for telemetry and LTP origin. More... | |
Macros | |
| #define | INS_EXT_POSE_P0 {1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1.} |
| #define | INS_EXT_POSE_Q_NOISE {1.0, 1.0, 1.0, 0.0173, 4.878e-4, 3.547e-4} |
| #define | INS_EXT_POSE_R_NOISE {8.372e-6, 3.832e-6, 4.761e-6, 2.830e-4, 8.684e-6, 7.013e-6} |
| #define | INS_EXT_POSE_MAX_AGE 30.f |
| Maximum age of an external pose [ms], 0 to disable the check. | |
| #define | INS_EXT_POSE_AGE_DRIFT 0.01f |
| Rate at which the lowest delay may rise [ms per received pose], to follow clock drift. | |
| #define | INS_EXT_POSE_AGE_RESYNC 1000 |
| Delay jump above which the sender clock is considered restarted [ms]. | |
| #define | INS_EXT_POSE_AGE_RESET_TIME 300 |
| Time with all poses too old after which the lowest delay is reset [ms]. | |
| #define | INS_EXT_POSE_GATE_PSI RadOfDeg(40.f) |
| Innovation gates [rad], 0 to disable. | |
| #define | INS_EXT_POSE_GATE_TILT RadOfDeg(15.f) |
| #define | INS_EXT_POSE_GATE_RESET_NB 10 |
| Number of consecutive gated poses after which the filter is reset on the pose. | |
| #define | INS_EXT_POSE_TIMEOUT 0.5f |
| Time without fused pose after which the filter status is reported as lost [s]. | |
| #define | DEBUG_PRINT(...) |
| #define | INS_EXT_POSE_IMU_ID ABI_BROADCAST |
| Import Gyro and Acc from ABI. | |
Functions | |
| static void | ins_ext_pose_init_from_flightplan (void) |
| static void | send_ins (struct transport_tx *trans, struct link_device *dev) |
| Provide telemetry. | |
| static void | send_ins_z (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ins_ref (struct transport_tx *trans, struct link_device *dev) |
| static void | send_filter_status (struct transport_tx *trans, struct link_device *dev) |
| static void | send_external_pose_down (struct transport_tx *trans, struct link_device *dev) |
| static void | send_ahrs_bias (struct transport_tx *trans, struct link_device *dev) |
| static void | accel_cb (uint8_t sender_id, uint32_t stamp, struct Int32Vect3 *accel) |
| static void | gyro_cb (uint8_t sender_id, uint32_t stamp, struct Int32Rates *gyro) |
| static bool | ins_ext_pose_check_age (uint32_t ts) |
| Import External Pose Message. | |
| void | ins_ext_pose_msg_update (uint8_t *buf) |
| static void | ekf_init (void) |
| EKF protos. | |
| static void | ekf_run (void) |
| void | ins_ext_pose_init (void) |
| Module. | |
| void | ins_ext_pose_run (void) |
| static void | ekf_f (const float X[EKF_NUM_STATES], const float U[EKF_NUM_INPUTS], float out[EKF_NUM_STATES]) |
| static void | ekf_F (const float X[EKF_NUM_STATES], const float U[EKF_NUM_INPUTS], float out[EKF_NUM_STATES][EKF_NUM_STATES]) |
| static void | ekf_L (const float X[EKF_NUM_STATES], const float U[EKF_NUM_INPUTS], float out[EKF_NUM_STATES][EKF_NUM_INPUTS]) |
| static void | ekf_prediction_step (const float U[EKF_NUM_INPUTS], const float dt) |
| static void | ekf_measurement_step (const float Z[EKF_NUM_OUTPUTS]) |
| static void | ekf_set_diag (float **a, float *b, int n) |
| static float | ekf_psi_meas (void) |
| Heading measurement close to the (unwrapped) heading state. | |
| static void | ekf_reset_on_pose (void) |
| Set position and attitude to the external pose and restore the initial covariance. | |
| void | ins_ext_pose_log_header (FILE *file) |
| Logging. | |
| void | ins_ext_pose_log_data (FILE *file) |
Variables | |
| float | ins_ext_pose_max_age = INS_EXT_POSE_MAX_AGE |
| float | ins_ext_pose_gate_psi = INS_EXT_POSE_GATE_PSI |
| float | ins_ext_pose_gate_tilt = INS_EXT_POSE_GATE_TILT |
| struct InsExtPose | ins_ext_pose |
| static abi_event | accel_ev |
| static abi_event | gyro_ev |
| float | ekf_X [EKF_NUM_STATES] |
| static float | ekf_U [EKF_NUM_INPUTS] |
| static float | ekf_Z [EKF_NUM_OUTPUTS] |
| static float | ekf_P [EKF_NUM_STATES][EKF_NUM_STATES] |
| static float | ekf_Q [EKF_NUM_INPUTS][EKF_NUM_INPUTS] |
| static float | ekf_R [EKF_NUM_OUTPUTS][EKF_NUM_OUTPUTS] |
| static float | ekf_H [EKF_NUM_OUTPUTS][EKF_NUM_STATES] |
| static float | t0 |
| static float | t1 |
Integrated Navigation System interface.
Definition in file ins_ext_pose.c.
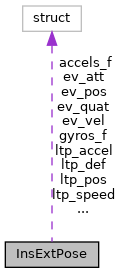
| struct InsExtPose |
Data for telemetry and LTP origin.
Definition at line 116 of file ins_ext_pose.c.
| Data Fields | ||
|---|---|---|
| struct FloatVect3 | accels_f | |
| uint32_t | age_ok_time | receive time of the last pose with a valid age [ms] |
| float | delay_min | lowest recent receive delay, relative to delay_ref [ms] |
| uint32_t | delay_ref | receive delay reference (includes clock offset) [ms] |
| float | ev_age | age of the last pose [ms] |
| struct FloatEulers | ev_att | |
| struct FloatVect3 | ev_pos | |
| struct FloatQuat | ev_quat | |
| float | ev_time | |
| struct FloatVect3 | ev_vel | |
| uint8_t | gate_cnt | consecutive gated poses |
| struct FloatRates | gyros_f | |
| bool | has_new_acc | |
| bool | has_new_ext_pose | |
| bool | has_new_gyro | |
| float | last_fused | time of the last fused pose [s] |
| struct NedCoor_i | ltp_accel | |
| struct LtpDef_i | ltp_def | |
| struct NedCoor_i | ltp_pos | |
| struct NedCoor_i | ltp_speed | |
| uint16_t | nb_gated | poses dropped by the innovation gates |
| uint16_t | nb_reset | filter resets after repeated gating |
| uint16_t | nb_stale | poses dropped for age or order |
| bool | started | |
| uint32_t | ts_last | last accepted capture time [ms] |
| bool | ts_valid | capture time reference initialized |
| #define DEBUG_PRINT | ( | ... | ) |
Definition at line 107 of file ins_ext_pose.c.
Referenced by ekf_init(), ekf_run(), and ins_ext_pose_msg_update().
| #define INS_EXT_POSE_AGE_DRIFT 0.01f |
Rate at which the lowest delay may rise [ms per received pose], to follow clock drift.
Definition at line 63 of file ins_ext_pose.c.
Referenced by ins_ext_pose_check_age().
| #define INS_EXT_POSE_AGE_RESET_TIME 300 |
Time with all poses too old after which the lowest delay is reset [ms].
Follows a lasting increase of the link delay; the innovation gates still apply.
Definition at line 75 of file ins_ext_pose.c.
Referenced by ins_ext_pose_check_age().
| #define INS_EXT_POSE_AGE_RESYNC 1000 |
Delay jump above which the sender clock is considered restarted [ms].
Definition at line 68 of file ins_ext_pose.c.
Referenced by ins_ext_pose_check_age().
| #define INS_EXT_POSE_GATE_PSI RadOfDeg(40.f) |
Innovation gates [rad], 0 to disable.
A pose whose heading or roll/pitch differs more than this from the prediction is not fused.
Definition at line 82 of file ins_ext_pose.c.
| #define INS_EXT_POSE_GATE_RESET_NB 10 |
Number of consecutive gated poses after which the filter is reset on the pose.
Definition at line 91 of file ins_ext_pose.c.
Referenced by ekf_run().
| #define INS_EXT_POSE_GATE_TILT RadOfDeg(15.f) |
Definition at line 86 of file ins_ext_pose.c.
| #define INS_EXT_POSE_IMU_ID ABI_BROADCAST |
Import Gyro and Acc from ABI.
Definition at line 262 of file ins_ext_pose.c.
Referenced by ins_ext_pose_init().
| #define INS_EXT_POSE_MAX_AGE 30.f |
Maximum age of an external pose [ms], 0 to disable the check.
The age is the receive delay above the lowest delay seen recently, computed from the capture time in the timestamp field of EXTERNAL_POSE (ms, sender clock). Not used when the sender leaves the timestamp at 0.
Definition at line 58 of file ins_ext_pose.c.
| #define INS_EXT_POSE_P0 {1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1., 1.} |
Definition at line 41 of file ins_ext_pose.c.
Referenced by ekf_init(), and ekf_reset_on_pose().
| #define INS_EXT_POSE_Q_NOISE {1.0, 1.0, 1.0, 0.0173, 4.878e-4, 3.547e-4} |
Definition at line 45 of file ins_ext_pose.c.
Referenced by ekf_init().
| #define INS_EXT_POSE_R_NOISE {8.372e-6, 3.832e-6, 4.761e-6, 2.830e-4, 8.684e-6, 7.013e-6} |
Definition at line 49 of file ins_ext_pose.c.
Referenced by ekf_init().
| #define INS_EXT_POSE_TIMEOUT 0.5f |
Time without fused pose after which the filter status is reported as lost [s].
Definition at line 96 of file ins_ext_pose.c.
Referenced by send_filter_status().
|
static |
Definition at line 281 of file ins_ext_pose.c.
References ACCELS_FLOAT_OF_BFP, and ins_ext_pose.
|
static |
Definition at line 567 of file ins_ext_pose.c.
References EKF_NUM_INPUTS, EKF_NUM_STATES, EKF_U_ACC_X, EKF_U_ACC_Y, EKF_U_ACC_Z, EKF_U_GYRO_Q, EKF_U_GYRO_R, EKF_X_A_BIAS_X, EKF_X_A_BIAS_Y, EKF_X_A_BIAS_Z, EKF_X_G_BIAS_P, EKF_X_G_BIAS_Q, EKF_X_G_BIAS_R, EKF_X_PHI, EKF_X_POS_X, EKF_X_POS_Y, EKF_X_POS_Z, EKF_X_PSI, EKF_X_THETA, EKF_X_VEL_X, EKF_X_VEL_Y, EKF_X_VEL_Z, and x12.
Referenced by ekf_prediction_step().
|
static |
Definition at line 528 of file ins_ext_pose.c.
References EKF_NUM_INPUTS, EKF_NUM_STATES, EKF_U_ACC_X, EKF_U_ACC_Y, EKF_U_ACC_Z, EKF_U_GYRO_P, EKF_U_GYRO_Q, EKF_U_GYRO_R, EKF_X_A_BIAS_X, EKF_X_A_BIAS_Y, EKF_X_A_BIAS_Z, EKF_X_G_BIAS_P, EKF_X_G_BIAS_Q, EKF_X_G_BIAS_R, EKF_X_PHI, EKF_X_POS_X, EKF_X_POS_Y, EKF_X_POS_Z, EKF_X_PSI, EKF_X_THETA, EKF_X_VEL_X, EKF_X_VEL_Y, EKF_X_VEL_Z, and x12.
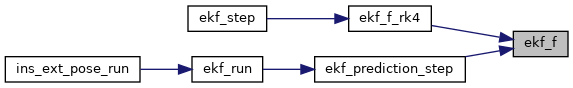
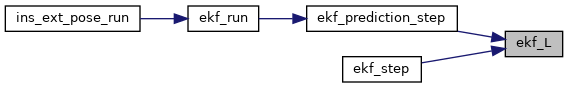
Referenced by ekf_prediction_step().
|
static |
EKF protos.
Definition at line 504 of file ins_ext_pose.c.
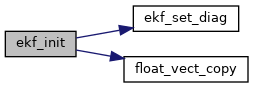
References DEBUG_PRINT, EKF_NUM_INPUTS, EKF_NUM_OUTPUTS, EKF_NUM_STATES, ekf_P, ekf_Q, ekf_R, ekf_set_diag(), ekf_U, ekf_X, ekf_Z, float_vect_copy(), INS_EXT_POSE_P0, INS_EXT_POSE_Q_NOISE, INS_EXT_POSE_R_NOISE, and MAKE_MATRIX_PTR.
Referenced by ins_ext_pose_init().
|
static |
Definition at line 645 of file ins_ext_pose.c.
References EKF_NUM_INPUTS, EKF_NUM_STATES, EKF_X_PHI, EKF_X_PSI, EKF_X_THETA, EKF_X_VEL_X, EKF_X_VEL_Y, EKF_X_VEL_Z, EKF_Z_PHI, EKF_Z_POS_X, EKF_Z_POS_Y, EKF_Z_POS_Z, EKF_Z_PSI, and EKF_Z_THETA.
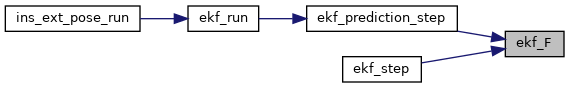
Referenced by ekf_prediction_step().
|
static |
Definition at line 860 of file ins_ext_pose.c.
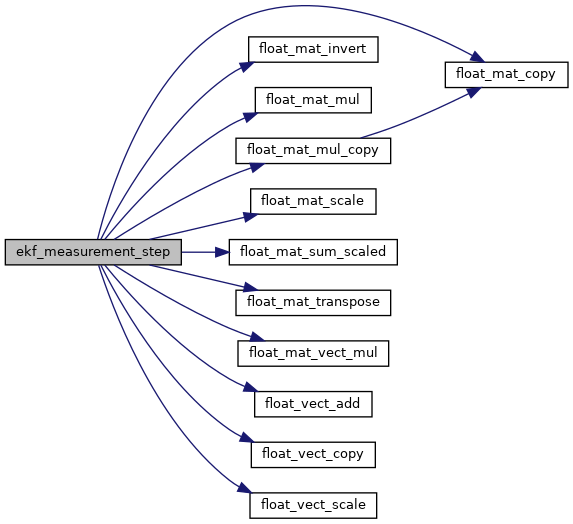
References ekf_H, EKF_NUM_OUTPUTS, EKF_NUM_STATES, ekf_P, ekf_R, ekf_X, float_mat_copy(), float_mat_invert(), float_mat_mul(), float_mat_mul_copy(), float_mat_scale(), float_mat_sum_scaled(), float_mat_transpose(), float_mat_vect_mul(), float_vect_add(), float_vect_copy(), float_vect_scale(), K, and MAKE_MATRIX_PTR.
Referenced by ekf_run().
|
static |
Definition at line 733 of file ins_ext_pose.c.
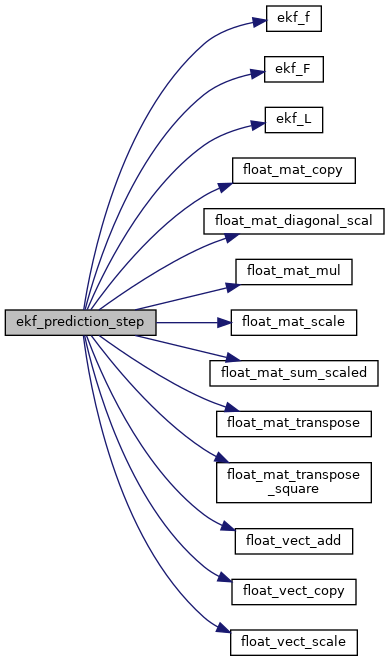
References ekf_F(), ekf_f(), ekf_L(), EKF_NUM_INPUTS, EKF_NUM_STATES, ekf_P, ekf_Q, ekf_X, float_mat_copy(), float_mat_diagonal_scal(), float_mat_mul(), float_mat_scale(), float_mat_sum_scaled(), float_mat_transpose(), float_mat_transpose_square(), float_vect_add(), float_vect_copy(), float_vect_scale(), and MAKE_MATRIX_PTR.
Referenced by ekf_run().
|
static |
Heading measurement close to the (unwrapped) heading state.
Definition at line 946 of file ins_ext_pose.c.
References ekf_X, EKF_X_PSI, FLOAT_ANGLE_NORMALIZE, and ins_ext_pose.
Referenced by ekf_reset_on_pose(), and ekf_run().
|
static |
Set position and attitude to the external pose and restore the initial covariance.
Definition at line 954 of file ins_ext_pose.c.
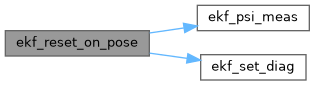
References EKF_NUM_STATES, ekf_P, ekf_psi_meas(), ekf_set_diag(), ekf_X, EKF_X_PHI, EKF_X_POS_X, EKF_X_POS_Y, EKF_X_POS_Z, EKF_X_PSI, EKF_X_THETA, ins_ext_pose, INS_EXT_POSE_P0, and MAKE_MATRIX_PTR.
Referenced by ekf_run().
|
static |
Definition at line 968 of file ins_ext_pose.c.
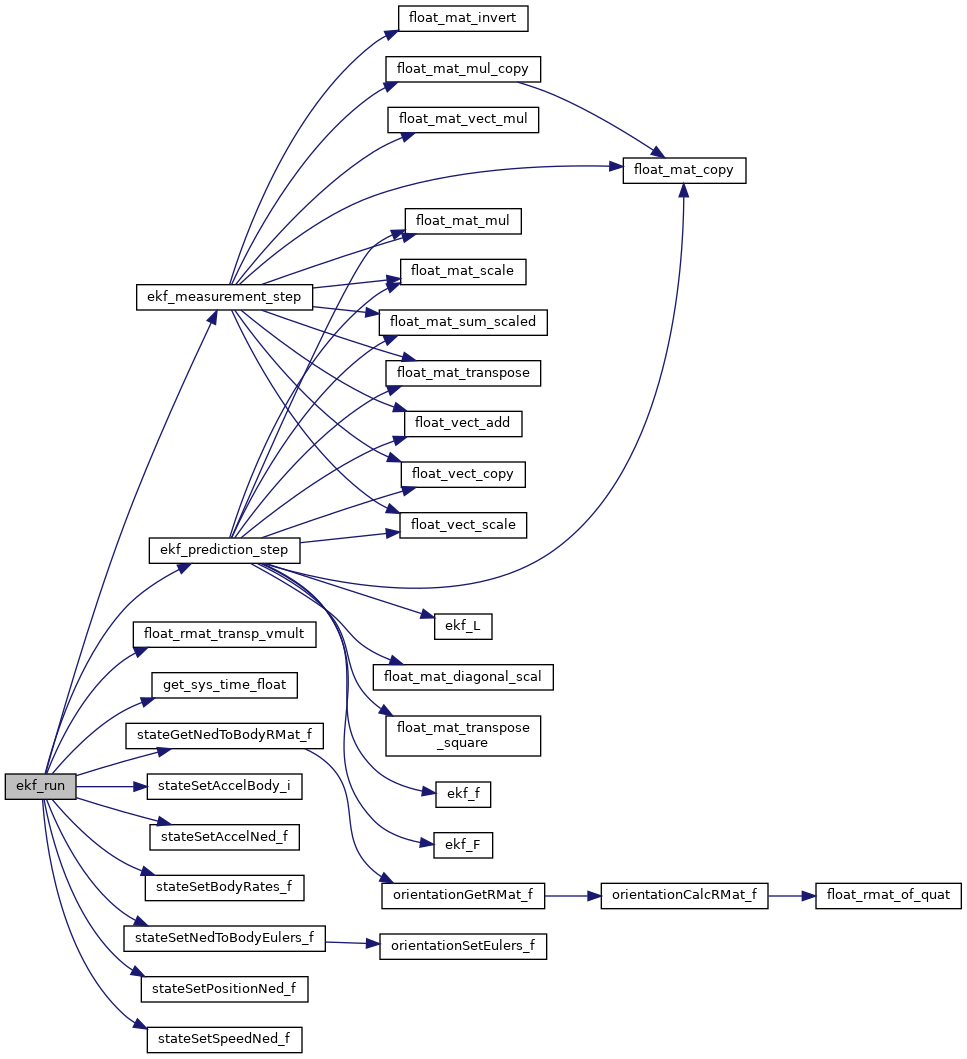
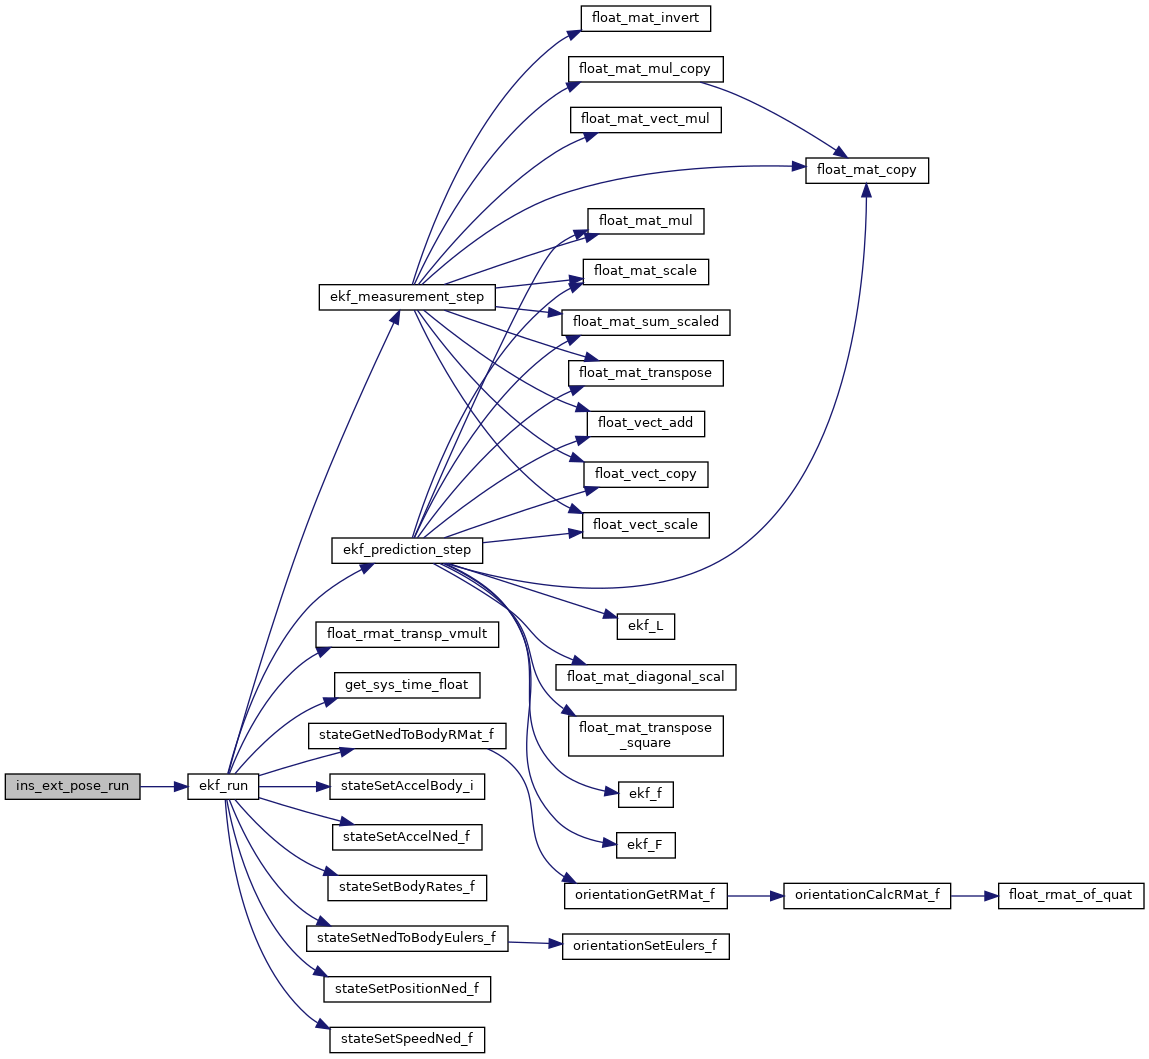
References ACCELS_BFP_OF_REAL, DEBUG_PRINT, ekf_measurement_step(), ekf_prediction_step(), ekf_psi_meas(), ekf_reset_on_pose(), ekf_U, EKF_U_ACC_X, EKF_U_ACC_Y, EKF_U_ACC_Z, EKF_U_GYRO_P, EKF_U_GYRO_Q, EKF_U_GYRO_R, ekf_X, EKF_X_A_BIAS_X, EKF_X_A_BIAS_Y, EKF_X_A_BIAS_Z, EKF_X_G_BIAS_P, EKF_X_G_BIAS_Q, EKF_X_G_BIAS_R, EKF_X_PHI, EKF_X_POS_X, EKF_X_POS_Y, EKF_X_POS_Z, EKF_X_PSI, EKF_X_THETA, EKF_X_VEL_X, EKF_X_VEL_Y, EKF_X_VEL_Z, ekf_Z, EKF_Z_PHI, EKF_Z_POS_X, EKF_Z_POS_Y, EKF_Z_POS_Z, EKF_Z_PSI, EKF_Z_THETA, FLOAT_ANGLE_NORMALIZE, float_rmat_of_eulers, float_rmat_transp_vmult(), get_sys_time_float(), ins_ext_pose, ins_ext_pose_gate_psi, INS_EXT_POSE_GATE_RESET_NB, ins_ext_pose_gate_tilt, FloatRates::p, FloatEulers::phi, POSITIONS_BFP_OF_REAL, FloatEulers::psi, FloatRates::q, FloatRates::r, SPEEDS_BFP_OF_REAL, stateSetAccelBody_i(), stateSetAccelNed_f(), stateSetBodyRates_f(), stateSetNedToBodyEulers_f(), stateSetPositionNed_f(), stateSetSpeedNed_f(), t0, t1, FloatEulers::theta, VECT3_COPY, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
Referenced by ins_ext_pose_run().
|
static |
Definition at line 488 of file ins_ext_pose.c.
References b.
Referenced by ekf_init(), and ekf_reset_on_pose().
|
static |
Definition at line 273 of file ins_ext_pose.c.
References gyro_cb(), ins_ext_pose, and RATES_FLOAT_OF_BFP.
|
static |
Import External Pose Message.
Check the age of a pose from its capture time. The receive delay (receive time - capture time) includes an unknown clock offset, so the age is taken as the delay above the lowest delay seen recently.
| ts | capture time [ms], 0 if not provided |
Definition at line 300 of file ins_ext_pose.c.
References delay, get_sys_time_msec(), ins_ext_pose, INS_EXT_POSE_AGE_DRIFT, INS_EXT_POSE_AGE_RESET_TIME, INS_EXT_POSE_AGE_RESYNC, ins_ext_pose_max_age, and Min.
Referenced by ins_ext_pose_msg_update().
| void ins_ext_pose_init | ( | void | ) |
Module.
Definition at line 405 of file ins_ext_pose.c.
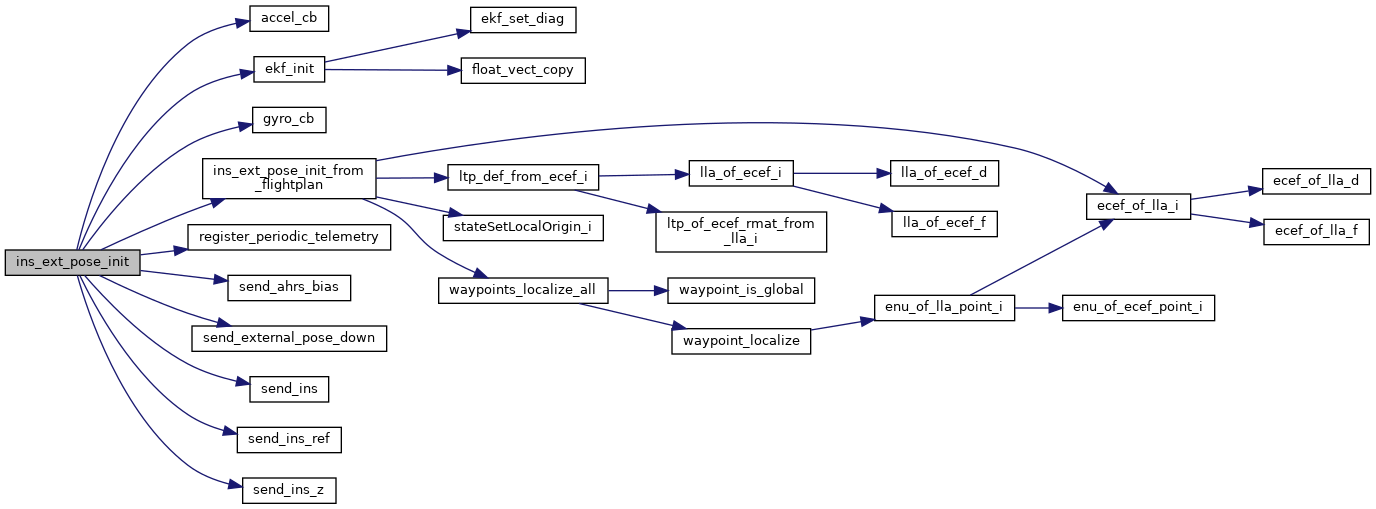
References accel_cb(), accel_ev, DefaultPeriodic, ekf_init(), gyro_cb(), gyro_ev, ins_ext_pose, INS_EXT_POSE_IMU_ID, ins_ext_pose_init_from_flightplan(), register_periodic_telemetry(), send_ahrs_bias(), send_external_pose_down(), send_filter_status(), send_ins(), send_ins_ref(), and send_ins_z().
|
static |
Definition at line 158 of file ins_ext_pose.c.
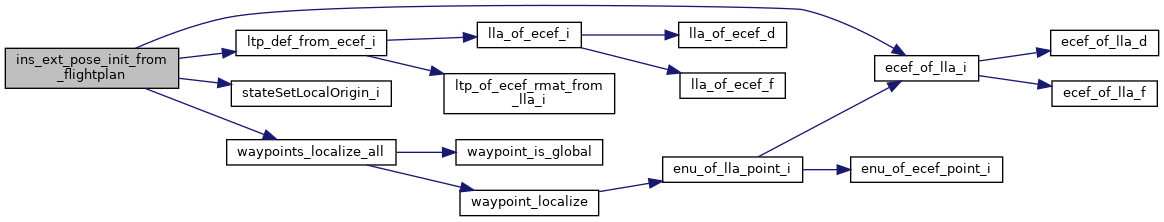
References LlaCoor_i::alt, ecef_of_lla_i(), ins_ext_pose, LlaCoor_i::lat, LlaCoor_i::lon, ltp_def_from_ecef_i(), stateSetLocalOrigin_i(), and waypoints_localize_all().
Referenced by ins_ext_pose_init().
| void ins_ext_pose_log_data | ( | FILE * | file | ) |
Definition at line 1123 of file ins_ext_pose.c.
References ekf_U, ekf_X, and ekf_Z.
Referenced by logger_file_write_row().
| void ins_ext_pose_log_header | ( | FILE * | file | ) |
Logging.
Definition at line 1115 of file ins_ext_pose.c.
Referenced by logger_file_write_header().
| void ins_ext_pose_msg_update | ( | uint8_t * | buf | ) |
Definition at line 343 of file ins_ext_pose.c.
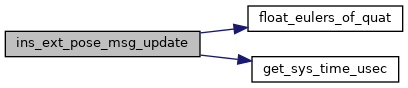
References DEBUG_PRINT, ENU_OF_TO_NED, EULERS_COPY, float_eulers_of_quat(), float_quat_comp(), get_sys_time_usec(), ins_ext_pose, ins_ext_pose_check_age(), FloatQuat::qi, QUAT_COPY, FloatQuat::qx, FloatQuat::qy, FloatQuat::qz, EnuCoor_f::x, EnuCoor_f::y, and EnuCoor_f::z.
| void ins_ext_pose_run | ( | void | ) |
Definition at line 443 of file ins_ext_pose.c.
References ekf_run().
|
static |
Definition at line 240 of file ins_ext_pose.c.
|
static |
Definition at line 224 of file ins_ext_pose.c.
References dev, and ins_ext_pose.
|
static |
Definition at line 208 of file ins_ext_pose.c.
References AHRS_COMP_ID_GENERIC, dev, get_sys_time_float(), ins_ext_pose, and INS_EXT_POSE_TIMEOUT.
|
static |
|
static |
Definition at line 199 of file ins_ext_pose.c.
References dev, and ins_ext_pose.
|
static |
Definition at line 191 of file ins_ext_pose.c.
References dev, and ins_ext_pose.
|
static |
Definition at line 266 of file ins_ext_pose.c.
|
static |
Definition at line 476 of file ins_ext_pose.c.
Referenced by ekf_measurement_step().
|
static |
Definition at line 472 of file ins_ext_pose.c.
Referenced by ekf_init(), ekf_measurement_step(), ekf_prediction_step(), and ekf_reset_on_pose().
|
static |
Definition at line 473 of file ins_ext_pose.c.
Referenced by ekf_init(), and ekf_prediction_step().
|
static |
Definition at line 474 of file ins_ext_pose.c.
Referenced by ekf_init(), and ekf_measurement_step().
|
static |
Definition at line 470 of file ins_ext_pose.c.
Referenced by ekf_init(), ekf_run(), and ins_ext_pose_log_data().
| float ekf_X[EKF_NUM_STATES] |
Definition at line 469 of file ins_ext_pose.c.
Referenced by ekf_init(), ekf_measurement_step(), ekf_prediction_step(), ekf_psi_meas(), ekf_reset_on_pose(), ekf_run(), ins_ext_pose_log_data(), and send_ahrs_bias().
|
static |
Definition at line 471 of file ins_ext_pose.c.
Referenced by ekf_init(), ekf_run(), and ins_ext_pose_log_data().
|
static |
Definition at line 267 of file ins_ext_pose.c.
| struct InsExtPose ins_ext_pose |
Definition at line 155 of file ins_ext_pose.c.
Referenced by accel_cb(), ekf_psi_meas(), ekf_reset_on_pose(), ekf_run(), gyro_cb(), ins_ext_pose_check_age(), ins_ext_pose_init(), ins_ext_pose_init_from_flightplan(), ins_ext_pose_msg_update(), send_external_pose_down(), send_filter_status(), send_ins(), send_ins_ref(), and send_ins_z().
| float ins_ext_pose_gate_psi = INS_EXT_POSE_GATE_PSI |
Definition at line 100 of file ins_ext_pose.c.
Referenced by ekf_run().
| float ins_ext_pose_gate_tilt = INS_EXT_POSE_GATE_TILT |
Definition at line 101 of file ins_ext_pose.c.
Referenced by ekf_run().
| float ins_ext_pose_max_age = INS_EXT_POSE_MAX_AGE |
Definition at line 99 of file ins_ext_pose.c.
Referenced by ins_ext_pose_check_age().
|
static |
Definition at line 485 of file ins_ext_pose.c.
Referenced by amt22_read(), and ekf_run().
|
static |
Definition at line 486 of file ins_ext_pose.c.
Referenced by amt22_read(), distributed_circular(), ekf_run(), mtostk_apply_polynomial_temp(), nps_main_loop(), and oneloop_nB_calc_nB_states().
 1.15.0