|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
A guidance mode based on Incremental Nonlinear Dynamic Inversion. More...
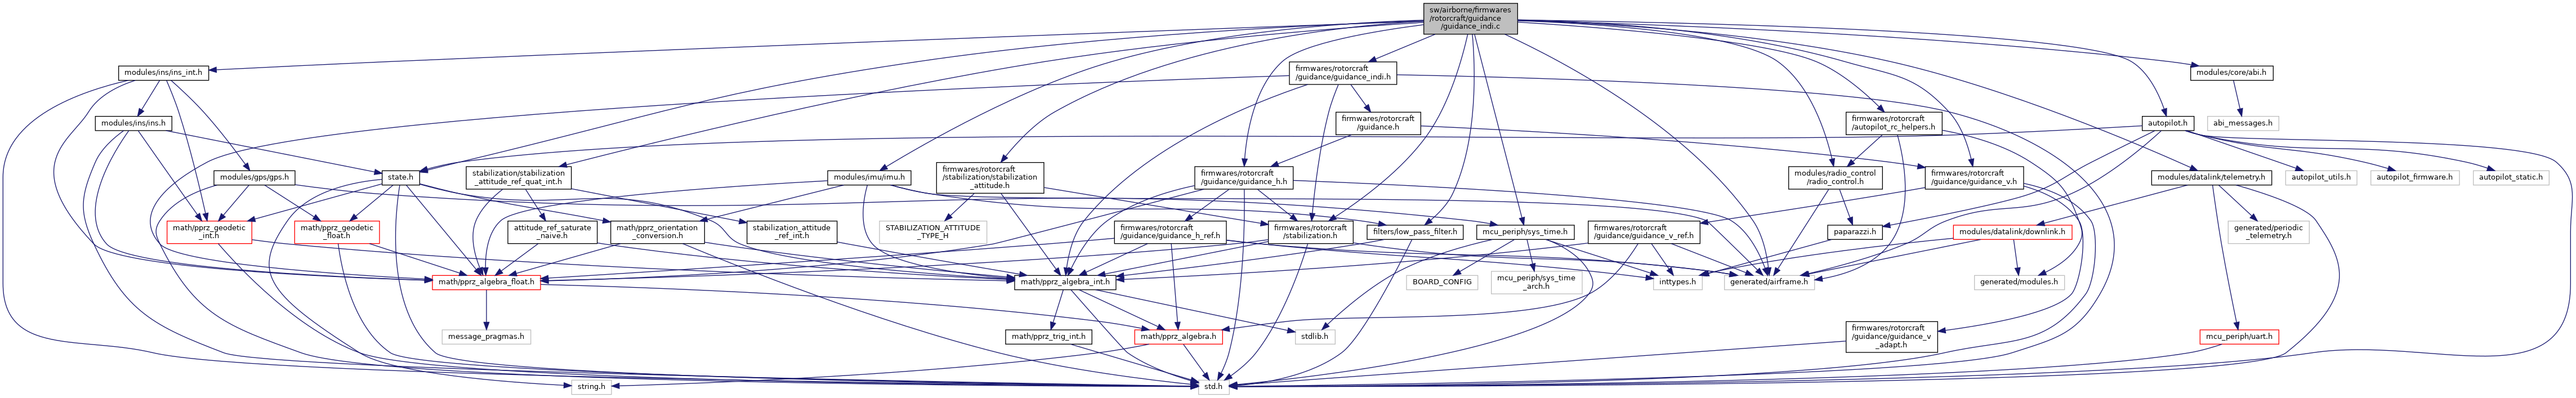
#include "generated/airframe.h"#include "firmwares/rotorcraft/guidance/guidance_indi.h"#include "modules/radio_control/radio_control.h"#include "firmwares/rotorcraft/stabilization.h"#include "firmwares/rotorcraft/guidance/guidance_h.h"#include "firmwares/rotorcraft/guidance/guidance_v.h"#include "firmwares/rotorcraft/autopilot_rc_helpers.h"#include "mcu_periph/sys_time.h"#include "state.h"#include "autopilot.h"#include "filters/low_pass_filter.h"#include "filters/quaternion_filter.h"#include "modules/core/abi.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Macros | |
| #define | GUIDANCE_INDI_ACCEL_SP_ID ABI_BROADCAST |
| #define | GUIDANCE_INDI_FILTER_CUTOFF 3.0 |
Functions | |
| static void | accel_sp_cb (uint8_t sender_id, uint8_t flag, struct FloatVect3 *accel_sp) |
| ABI callback that obtains the acceleration setpoint from telemetry flag: 0 -> 2D, 1 -> 3D. | |
| static void | guidance_indi_propagate_filters (void) |
| Low pass the accelerometer measurements to remove noise from vibrations. | |
| static void | send_indi_guidance (struct transport_tx *trans, struct link_device *dev) |
| void | guidance_indi_init (void) |
| Init function. | |
| void | guidance_indi_enter (void) |
| Call upon entering indi guidance. | |
| struct StabilizationSetpoint | guidance_indi_run (struct FloatVect3 *accel_sp, float heading_sp) |
| struct FloatVect3 WEAK | guidance_indi_controller (bool in_flight UNUSED, struct HorizontalGuidance *gh, struct VerticalGuidance *gv, enum GuidanceIndi_HMode h_mode, enum GuidanceIndi_VMode v_mode) |
| struct StabilizationSetpoint | guidance_indi_run_mode (bool in_flight, struct HorizontalGuidance *gh, struct VerticalGuidance *gv, enum GuidanceIndi_HMode h_mode, enum GuidanceIndi_VMode v_mode) |
Variables | |
| float | guidance_indi_pos_gain = 0.5 |
| float | guidance_indi_speed_gain = 1.8 |
| abi_event | accel_sp_ev |
| struct FloatVect3 | indi_accel_sp = {0.0f, 0.0f, 0.0f} |
| bool | indi_accel_sp_set_2d = false |
| bool | indi_accel_sp_set_3d = false |
| struct FloatVect3 | speed_sp = {0.0f, 0.0f, 0.0f} |
| struct FloatVect3 | sp_accel = {0.0f, 0.0f, 0.0f} |
| float | thrust_dyn = 0.f |
| float | thrust_act = 0.f |
| Butterworth2LowPass | filt_accel_ned [3] |
| Butterworth2LowPass | thrust_filt |
| QuatButterworthLowPass | quat_filt |
| static float | Gmat [GUIDANCE_INDI_NV][GUIDANCE_INDI_NU] |
| struct FloatMat33 | Ga |
| struct FloatMat33 | Ga_inv |
| struct FloatVect3 | control_increment |
| float | filter_cutoff = GUIDANCE_INDI_FILTER_CUTOFF |
| float | guidance_indi_max_bank = GUIDANCE_H_MAX_BANK |
| float | time_of_accel_sp_2d = 0.0 |
| float | time_of_accel_sp_3d = 0.0 |
| struct FloatEulers | guidance_euler_cmd |
| struct ThrustSetpoint | thrust_sp |
| float | thrust_in |
| float | thrust_vect [3] |
A guidance mode based on Incremental Nonlinear Dynamic Inversion.
Based on the papers: Cascaded Incremental Nonlinear Dynamic Inversion Control for MAV Disturbance Rejection https://www.researchgate.net/publication/312907985_Cascaded_Incremental_Nonlinear_Dynamic_Inversion_Control_for_MAV_Disturbance_Rejection
Gust Disturbance Alleviation with Incremental Nonlinear Dynamic Inversion https://www.researchgate.net/publication/309212603_Gust_Disturbance_Alleviation_with_Incremental_Nonlinear_Dynamic_Inversion
Definition in file guidance_indi.c.
| #define GUIDANCE_INDI_ACCEL_SP_ID ABI_BROADCAST |
Definition at line 64 of file guidance_indi.c.
Referenced by guidance_indi_init().
| #define GUIDANCE_INDI_FILTER_CUTOFF 3.0 |
Definition at line 94 of file guidance_indi.c.
|
static |
ABI callback that obtains the acceleration setpoint from telemetry flag: 0 -> 2D, 1 -> 3D.
Definition at line 458 of file guidance_indi.c.
References get_sys_time_float(), indi_accel_sp, indi_accel_sp_set_2d, indi_accel_sp_set_3d, time_of_accel_sp_2d, time_of_accel_sp_3d, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by guidance_indi_init().
| struct FloatVect3 WEAK guidance_indi_controller | ( | bool in_flight | UNUSED, |
| struct HorizontalGuidance * | gh, | ||
| struct VerticalGuidance * | gv, | ||
| enum GuidanceIndi_HMode | h_mode, | ||
| enum GuidanceIndi_VMode | v_mode ) |
Definition at line 341 of file guidance_indi.c.
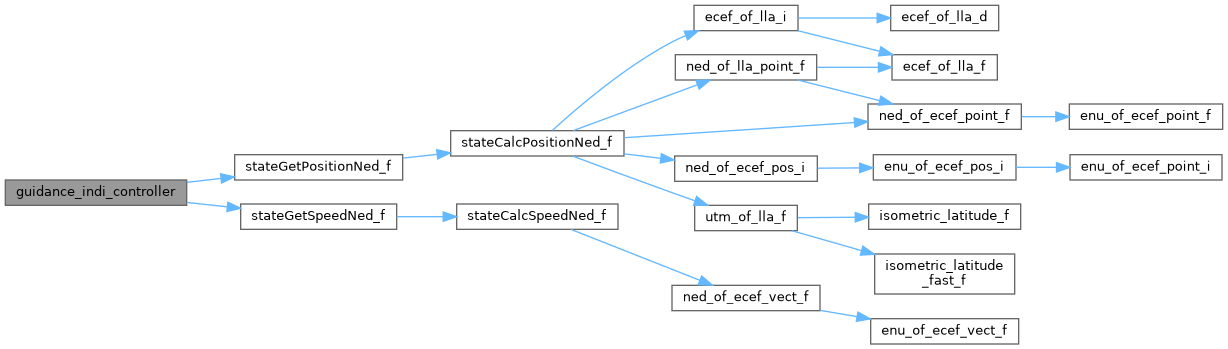
References ACCEL_FLOAT_OF_BFP, guidance_indi_controller(), GUIDANCE_INDI_H_ACCEL, GUIDANCE_INDI_H_SPEED, guidance_indi_pos_gain, guidance_indi_speed_gain, GUIDANCE_INDI_V_ACCEL, GUIDANCE_INDI_V_SPEED, POS_FLOAT_OF_BFP, SPEED_FLOAT_OF_BFP, speed_sp, stateGetPositionNed_f(), stateGetSpeedNed_f(), UNUSED, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, NedCoor_f::z, VerticalGuidance::z_ref, VerticalGuidance::zd_ref, and VerticalGuidance::zdd_ref.
Referenced by guidance_indi_controller(), guidance_indi_controller(), guidance_indi_controller(), and guidance_indi_run_mode().
| void guidance_indi_enter | ( | void | ) |
Call upon entering indi guidance.
Definition at line 207 of file guidance_indi.c.
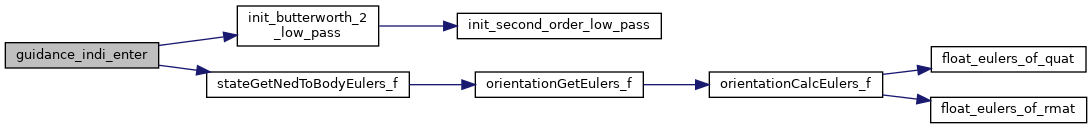
References filt_accel_ned, filter_cutoff, init_butterworth_2_low_pass(), init_quat_butterworth_low_pass(), nav, FloatEulers::psi, quat_filt, stabilization, stateGetNedToBodyEulers_f(), stateGetNedToBodyQuat_f(), thrust_act, thrust_dyn, thrust_filt, and thrust_in.
| void guidance_indi_init | ( | void | ) |
Init function.
Definition at line 192 of file guidance_indi.c.
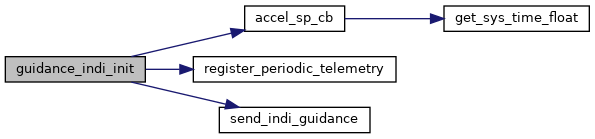
References accel_sp_cb(), accel_sp_ev, DefaultPeriodic, FLOAT_EULERS_ZERO, guidance_euler_cmd, GUIDANCE_INDI_ACCEL_SP_ID, register_periodic_telemetry(), send_indi_guidance(), thrust_sp, and THRUST_SP_SET_ZERO.
|
static |
Low pass the accelerometer measurements to remove noise from vibrations.
The roll and pitch also need to be filtered to synchronize them with the acceleration
Definition at line 445 of file guidance_indi.c.
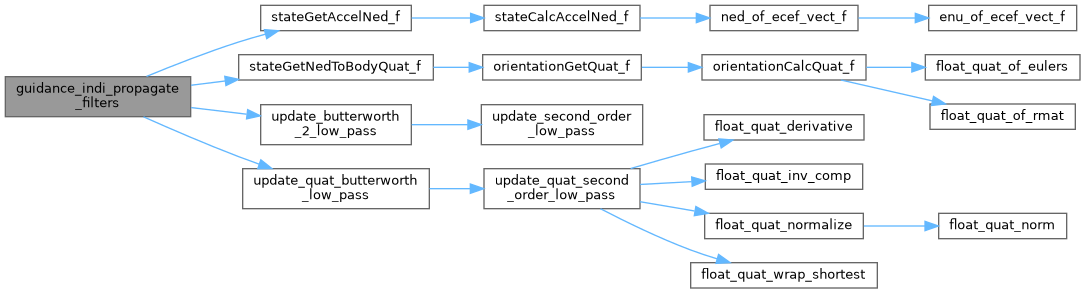
References filt_accel_ned, quat_filt, stateGetAccelNed_f(), stateGetNedToBodyQuat_f(), update_butterworth_2_low_pass(), update_quat_butterworth_low_pass(), NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
Referenced by guidance_indi_run().
| struct StabilizationSetpoint guidance_indi_run | ( | struct FloatVect3 * | accel_sp, |
| float | heading_sp ) |
| accel_sp | accel setpoint in NED frame [m/s^2] |
| heading_sp | the desired heading [rad] |
main indi guidance function
Definition at line 235 of file guidance_indi.c.
References control_increment, filt_accel_ned, float_eulers_of_quat_yxz(), float_quat_of_eulers_yxz(), Ga, Ga_inv, Gmat, guidance_euler_cmd, guidance_indi_calcG(), guidance_indi_max_bank, GUIDANCE_INDI_NU, GUIDANCE_INDI_NV, guidance_indi_propagate_filters(), guidance_indi_run(), guidance_indi_set_wls_settings(), guidance_indi_specific_force_gain, MAT33_INV, MAT33_VECT3_MUL, MAX_PPRZ, FloatEulers::phi, FloatEulers::psi, quat_filt, RMAT_ELMT, sp_accel, stab_sp_from_quat_f(), th_sp_from_incr_vect_f(), th_sp_from_thrust_i(), FloatEulers::theta, THRUST_AXIS_Z, thrust_filt, thrust_in, thrust_sp, thrust_vect, WLS_t::u, WLS_t::v, wls_alloc(), FloatVect3::x, FloatVect3::y, and FloatVect3::z.
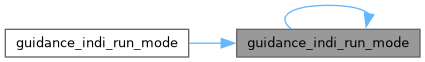
Referenced by guidance_indi_run(), and guidance_indi_run_mode().
| struct StabilizationSetpoint guidance_indi_run_mode | ( | bool in_flight in_flight | , |
| struct HorizontalGuidance * | gh, | ||
| struct VerticalGuidance * | gv, | ||
| enum GuidanceIndi_HMode | h_mode, | ||
| enum GuidanceIndi_VMode | v_mode ) |
Definition at line 392 of file guidance_indi.c.
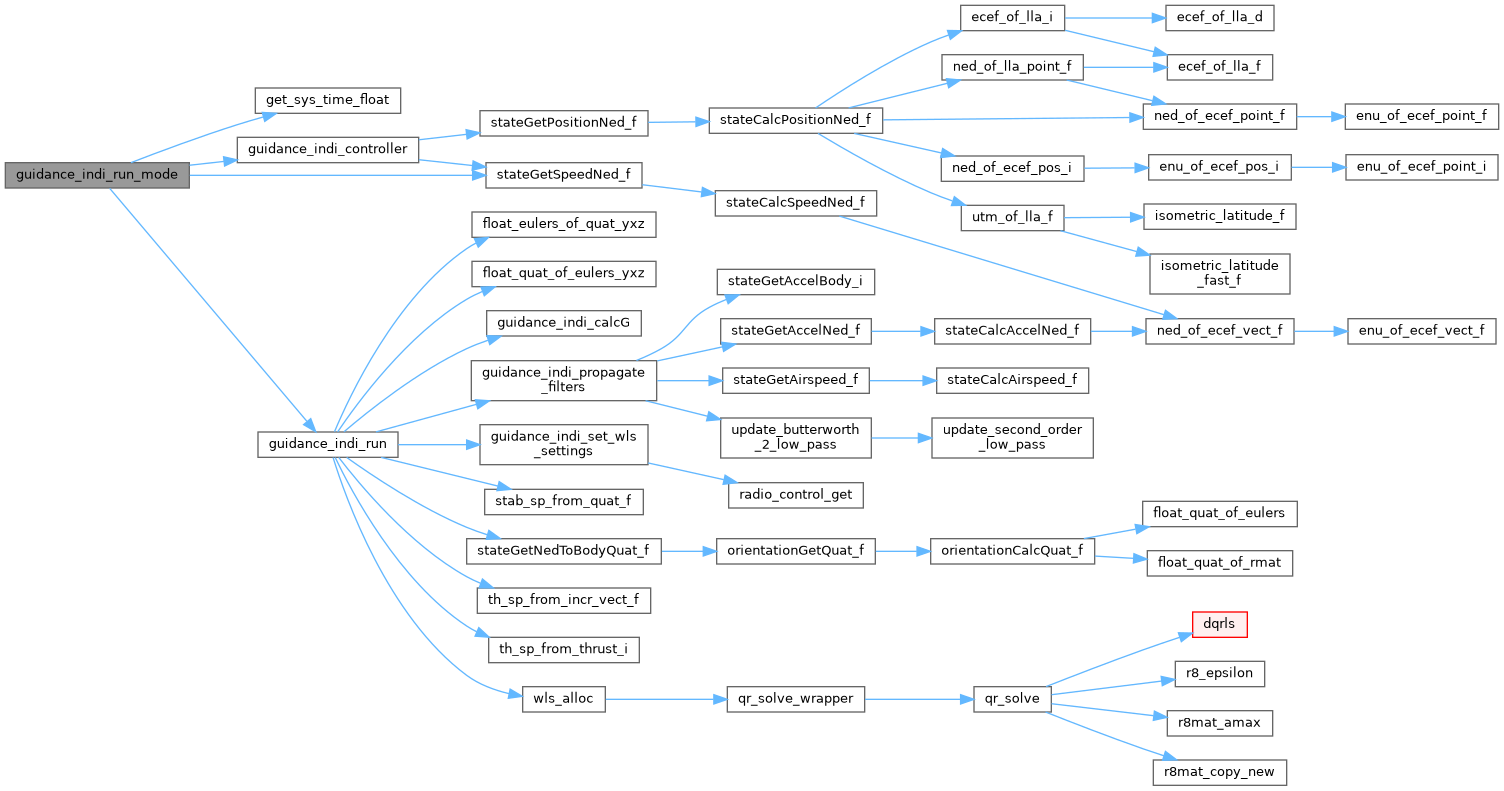
References get_sys_time_float(), guidance_indi_controller(), guidance_indi_run(), guidance_indi_run_mode(), guidance_indi_speed_gain, indi_accel_sp, indi_accel_sp_set_2d, indi_accel_sp_set_3d, speed_sp, stateGetSpeedNed_f(), time_of_accel_sp_2d, time_of_accel_sp_3d, FloatVect3::x, FloatVect3::y, FloatVect3::z, and NedCoor_f::z.
Referenced by guidance_indi_run_mode(), and guidance_indi_run_mode().
|
static |
Definition at line 165 of file guidance_indi.c.
References control_increment, dev, filt_accel_ned, sp_accel, and speed_sp.
Referenced by guidance_indi_init().
| abi_event accel_sp_ev |
Definition at line 66 of file guidance_indi.c.
Referenced by guidance_indi_init().
| struct FloatVect3 control_increment |
Definition at line 144 of file guidance_indi.c.
Referenced by guidance_indi_run(), and send_indi_guidance().
| Butterworth2LowPass filt_accel_ned[3] |
Definition at line 100 of file guidance_indi.c.
Referenced by guidance_indi_enter(), guidance_indi_init_filters(), guidance_indi_propagate_filters(), guidance_indi_propagate_filters(), guidance_indi_run(), send_guidance_indi_hybrid(), and send_indi_guidance().
| float filter_cutoff = GUIDANCE_INDI_FILTER_CUTOFF |
Definition at line 148 of file guidance_indi.c.
Referenced by guidance_indi_enter(), and guidance_indi_init_filters().
| struct FloatMat33 Ga |
Definition at line 142 of file guidance_indi.c.
Referenced by guidance_indi_init(), guidance_indi_run(), and send_eff_mat_guid_indi_hybrid().
| struct FloatMat33 Ga_inv |
Definition at line 143 of file guidance_indi.c.
Referenced by guidance_indi_run().
|
static |
Definition at line 104 of file guidance_indi.c.
Referenced by guidance_indi_calcG(), guidance_indi_calcG(), guidance_indi_calcG(), guidance_indi_calcg_wing(), guidance_indi_calcg_wing(), guidance_indi_calcG_yxz(), guidance_indi_calcG_zyx(), and guidance_indi_run().
| struct FloatEulers guidance_euler_cmd |
Definition at line 154 of file guidance_indi.c.
Referenced by guidance_indi_init(), and guidance_indi_run().
| float guidance_indi_max_bank = GUIDANCE_H_MAX_BANK |
Definition at line 149 of file guidance_indi.c.
Referenced by guidance_indi_calcG(), guidance_indi_hybrid_set_wls_settings(), guidance_indi_run(), guidance_indi_set_wls_settings(), and guidance_set_max_bank_angle().
| float guidance_indi_pos_gain = 0.5 |
Definition at line 54 of file guidance_indi.c.
Referenced by guidance_indi_calcG(), and guidance_indi_controller().
| float guidance_indi_speed_gain = 1.8 |
Definition at line 60 of file guidance_indi.c.
Referenced by guidance_indi_calcG(), guidance_indi_controller(), and guidance_indi_run_mode().
| struct FloatVect3 indi_accel_sp = {0.0f, 0.0f, 0.0f} |
Definition at line 68 of file guidance_indi.c.
Referenced by accel_sp_cb(), and guidance_indi_run_mode().
| bool indi_accel_sp_set_2d = false |
Definition at line 69 of file guidance_indi.c.
Referenced by accel_sp_cb(), and guidance_indi_run_mode().
| bool indi_accel_sp_set_3d = false |
Definition at line 70 of file guidance_indi.c.
Referenced by accel_sp_cb(), and guidance_indi_run_mode().
| QuatButterworthLowPass quat_filt |
Definition at line 102 of file guidance_indi.c.
Referenced by guidance_indi_calcg_wing(), guidance_indi_calcg_wing(), guidance_indi_enter(), guidance_indi_init_filters(), guidance_indi_propagate_filters(), guidance_indi_propagate_filters(), and guidance_indi_run().
| struct FloatVect3 sp_accel = {0.0f, 0.0f, 0.0f} |
Definition at line 74 of file guidance_indi.c.
Referenced by guidance_h_update_reference(), guidance_indi_run(), send_guidance_indi_hybrid(), and send_indi_guidance().
| struct FloatVect3 speed_sp = {0.0f, 0.0f, 0.0f} |
Definition at line 73 of file guidance_indi.c.
Referenced by compute_accel_from_speed_sp(), gh_saturate_speed(), gh_update_ref_from_speed_sp(), guidance_indi_controller(), guidance_indi_controller(), guidance_indi_run_mode(), nav_hybrid_goto(), nps_fdm_run_step(), orange_avoider_guided_periodic(), read_rc_setpoint_speed_i(), rotwing_state_periodic(), and send_indi_guidance().
| float thrust_act = 0.f |
Definition at line 99 of file guidance_indi.c.
Referenced by guidance_indi_enter(), and guidance_indi_init_filters().
| float thrust_dyn = 0.f |
Definition at line 98 of file guidance_indi.c.
Referenced by guidance_indi_enter(), and guidance_indi_init().
| Butterworth2LowPass thrust_filt |
Definition at line 101 of file guidance_indi.c.
Referenced by guidance_indi_enter(), guidance_indi_init_filters(), and guidance_indi_run().
| float thrust_in |
Definition at line 156 of file guidance_indi.c.
Referenced by guidance_indi_enter(), guidance_indi_init_filters(), and guidance_indi_run().
| struct ThrustSetpoint thrust_sp |
Definition at line 155 of file guidance_indi.c.
Referenced by autopilot_static_periodic(), guidance_indi_init(), guidance_indi_run(), guidance_v_run_accel(), guidance_v_run_pos(), and guidance_v_run_speed().
| float thrust_vect[3] |
Definition at line 157 of file guidance_indi.c.
Referenced by guidance_indi_run(), and quat_from_earth_cmd_f().
| float time_of_accel_sp_2d = 0.0 |
Definition at line 151 of file guidance_indi.c.
Referenced by accel_sp_cb(), and guidance_indi_run_mode().
| float time_of_accel_sp_3d = 0.0 |
Definition at line 152 of file guidance_indi.c.
Referenced by accel_sp_cb(), and guidance_indi_run_mode().
 1.15.0