|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Horizontal guidance for rotorcrafts. More...
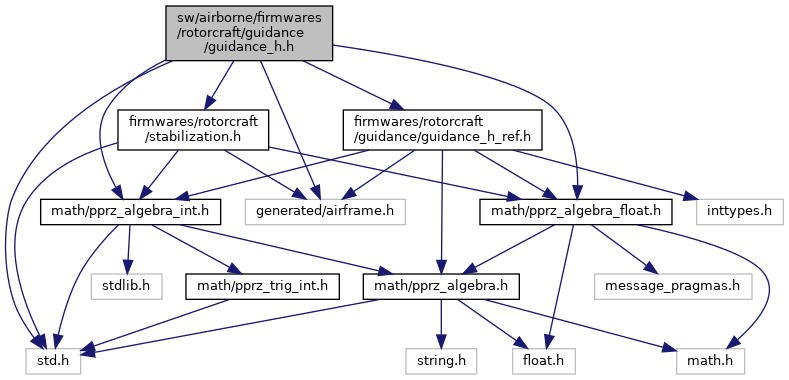
#include "math/pprz_algebra_int.h"#include "math/pprz_algebra_float.h"#include "firmwares/rotorcraft/guidance/guidance_h_ref.h"#include "firmwares/rotorcraft/stabilization.h"#include "generated/airframe.h"#include "std.h"Go to the source code of this file.
Data Structures | |
| struct | HorizontalGuidanceSetpoint |
| struct | HorizontalGuidanceReference |
| struct | HorizontalGuidanceRCInput |
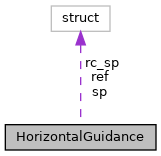
| struct | HorizontalGuidance |
Macros | |
| #define | GUIDANCE_H_USE_REF TRUE |
| Use horizontal guidance reference trajectory. | |
| #define | GUIDANCE_H_USE_SPEED_REF TRUE |
| Use horizontal guidance speed reference. | |
| #define | GUIDANCE_H_MODE_NONE 0 |
| #define | GUIDANCE_H_MODE_HOVER 1 |
| #define | GUIDANCE_H_MODE_NAV 2 |
| #define | GUIDANCE_H_MODE_GUIDED 3 |
| #define | GUIDANCE_H_MAX_BANK RadOfDeg(20) |
| Max bank controlled by guidance. | |
| #define | guidance_h_SetUseRef(_val) |
Functions | |
| void | guidance_h_init (void) |
| void | guidance_h_mode_changed (uint8_t new_mode) |
| void | guidance_h_run_enter (void) |
| struct StabilizationSetpoint | guidance_h_run (bool in_flight) |
| struct StabilizationSetpoint | guidance_h_run_pos (bool in_flight, struct HorizontalGuidance *gh) |
| struct StabilizationSetpoint | guidance_h_run_speed (bool in_flight, struct HorizontalGuidance *gh) |
| struct StabilizationSetpoint | guidance_h_run_accel (bool in_flight, struct HorizontalGuidance *gh) |
| void | guidance_h_hover_enter (void) |
| void | guidance_h_nav_enter (void) |
| struct StabilizationSetpoint | guidance_h_from_nav (bool in_flight) |
| Set horizontal guidance from NAV and run control loop. | |
| struct StabilizationSetpoint | guidance_h_guided_run (bool in_flight) |
| Run GUIDED mode control. | |
| void | guidance_h_set_pos (float x, float y) |
| Set horizontal position setpoint. | |
| void | guidance_h_set_heading (float heading) |
| Set heading setpoint. | |
| void | guidance_h_set_body_vel (float vx, float vy) |
| Set body relative horizontal velocity setpoint. | |
| void | guidance_h_set_vel (float vx, float vy) |
| Set horizontal velocity setpoint. | |
| void | guidance_h_set_body_acc (float ax, float ay) |
| Set body relative horizontal acceleration setpoint. | |
| void | guidance_h_set_acc (float ax, float ay) |
| Set horizontal acceleration setpoint. | |
| void | guidance_h_set_heading_rate (float rate) |
| Set heading rate setpoint. | |
| void | guidance_h_set_all (float x, float y, float vx, float vy, float ax, float ay) |
| Set position speed and acceleration (NED frame). | |
| static void | guidance_h_SetMaxSpeed (float speed) |
| static void | guidance_h_SetOmega (float omega) |
| static void | guidance_h_SetZeta (float zeta) |
| static void | guidance_h_SetTau (float tau) |
Variables | |
| struct HorizontalGuidance | guidance_h |
Horizontal guidance for rotorcrafts.
Definition in file guidance_h.h.
| struct HorizontalGuidanceReference |
Definition at line 92 of file guidance_h.h.
| Data Fields | ||
|---|---|---|
| struct Int32Vect2 | accel | with INT32_ACCEL_FRAC |
| struct Int32Vect2 | pos | with INT32_POS_FRAC |
| struct Int32Vect2 | speed | with INT32_SPEED_FRAC |
| struct HorizontalGuidanceRCInput |
Definition at line 98 of file guidance_h.h.
| Data Fields | ||
|---|---|---|
| float | heading | |
| float | last_ts | |
| struct Int32Vect2 | vect | |
| struct HorizontalGuidance |
Definition at line 104 of file guidance_h.h.
| Data Fields | ||
|---|---|---|
| uint8_t | mode | |
| struct HorizontalGuidanceRCInput | rc_sp | remote control setpoint |
| struct HorizontalGuidanceReference | ref | reference calculated from setpoints |
| struct HorizontalGuidanceSetpoint | sp | setpoints |
| bool | use_ref | |
| #define GUIDANCE_H_MAX_BANK RadOfDeg(20) |
Max bank controlled by guidance.
Definition at line 64 of file guidance_h.h.
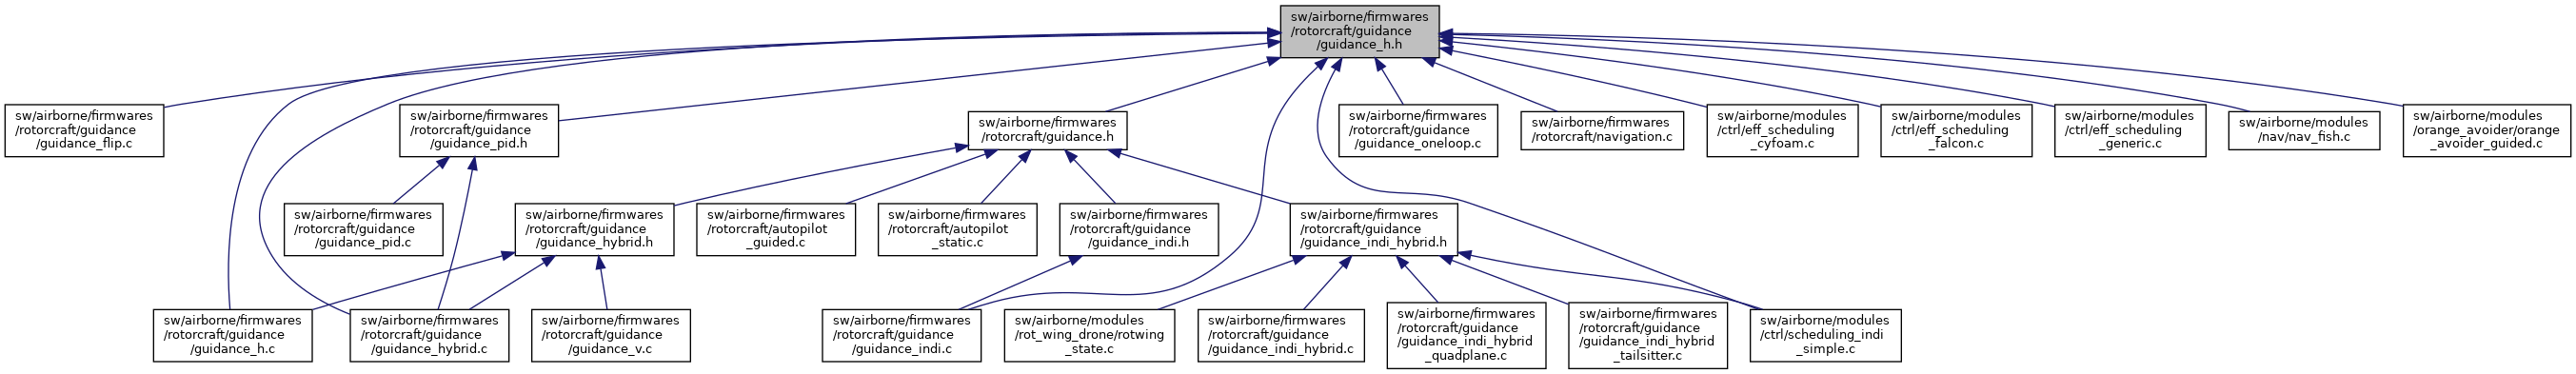
Referenced by computeOptiTrack(), guidance_pid_h_run(), and rotwing_state_periodic().
| #define GUIDANCE_H_MODE_GUIDED 3 |
Definition at line 59 of file guidance_h.h.
Referenced by autopilot_static_set_mode(), guidance_h_mode_changed(), guidance_h_run(), and orange_avoider_guided_periodic().
| #define GUIDANCE_H_MODE_HOVER 1 |
Definition at line 57 of file guidance_h.h.
Referenced by autopilot_static_set_mode(), guidance_h_mode_changed(), guidance_h_run(), guidance_h_update_reference(), guidance_module_enter(), rc_cb(), and stabilization_indi_set_wls_settings().
| #define GUIDANCE_H_MODE_NAV 2 |
Definition at line 58 of file guidance_h.h.
Referenced by autopilot_static_set_mode(), control_mixing_heewing_nav_enter(), guidance_h_mode_changed(), guidance_h_run(), guidance_h_update_reference(), rc_cb(), and stabilization_indi_set_wls_settings().
| #define GUIDANCE_H_MODE_NONE 0 |
Definition at line 56 of file guidance_h.h.
Referenced by autopilot_static_periodic(), autopilot_static_set_mode(), control_mixing_heewing_attitude_direct_enter(), control_mixing_heewing_attitude_plane_enter(), guidance_h_init(), and rotwing_state_periodic().
| #define guidance_h_SetUseRef | ( | _val | ) |
Definition at line 188 of file guidance_h.h.
| #define GUIDANCE_H_USE_REF TRUE |
Use horizontal guidance reference trajectory.
Default is TRUE, define to FALSE to always disable it.
Definition at line 45 of file guidance_h.h.
Referenced by guidance_h_init().
| #define GUIDANCE_H_USE_SPEED_REF TRUE |
Use horizontal guidance speed reference.
This also allows to give velocity commands via RC in GUIDANCE_H_MODE_HOVER. Default is TRUE, define to FALSE to always disable it.
Definition at line 53 of file guidance_h.h.
|
extern |
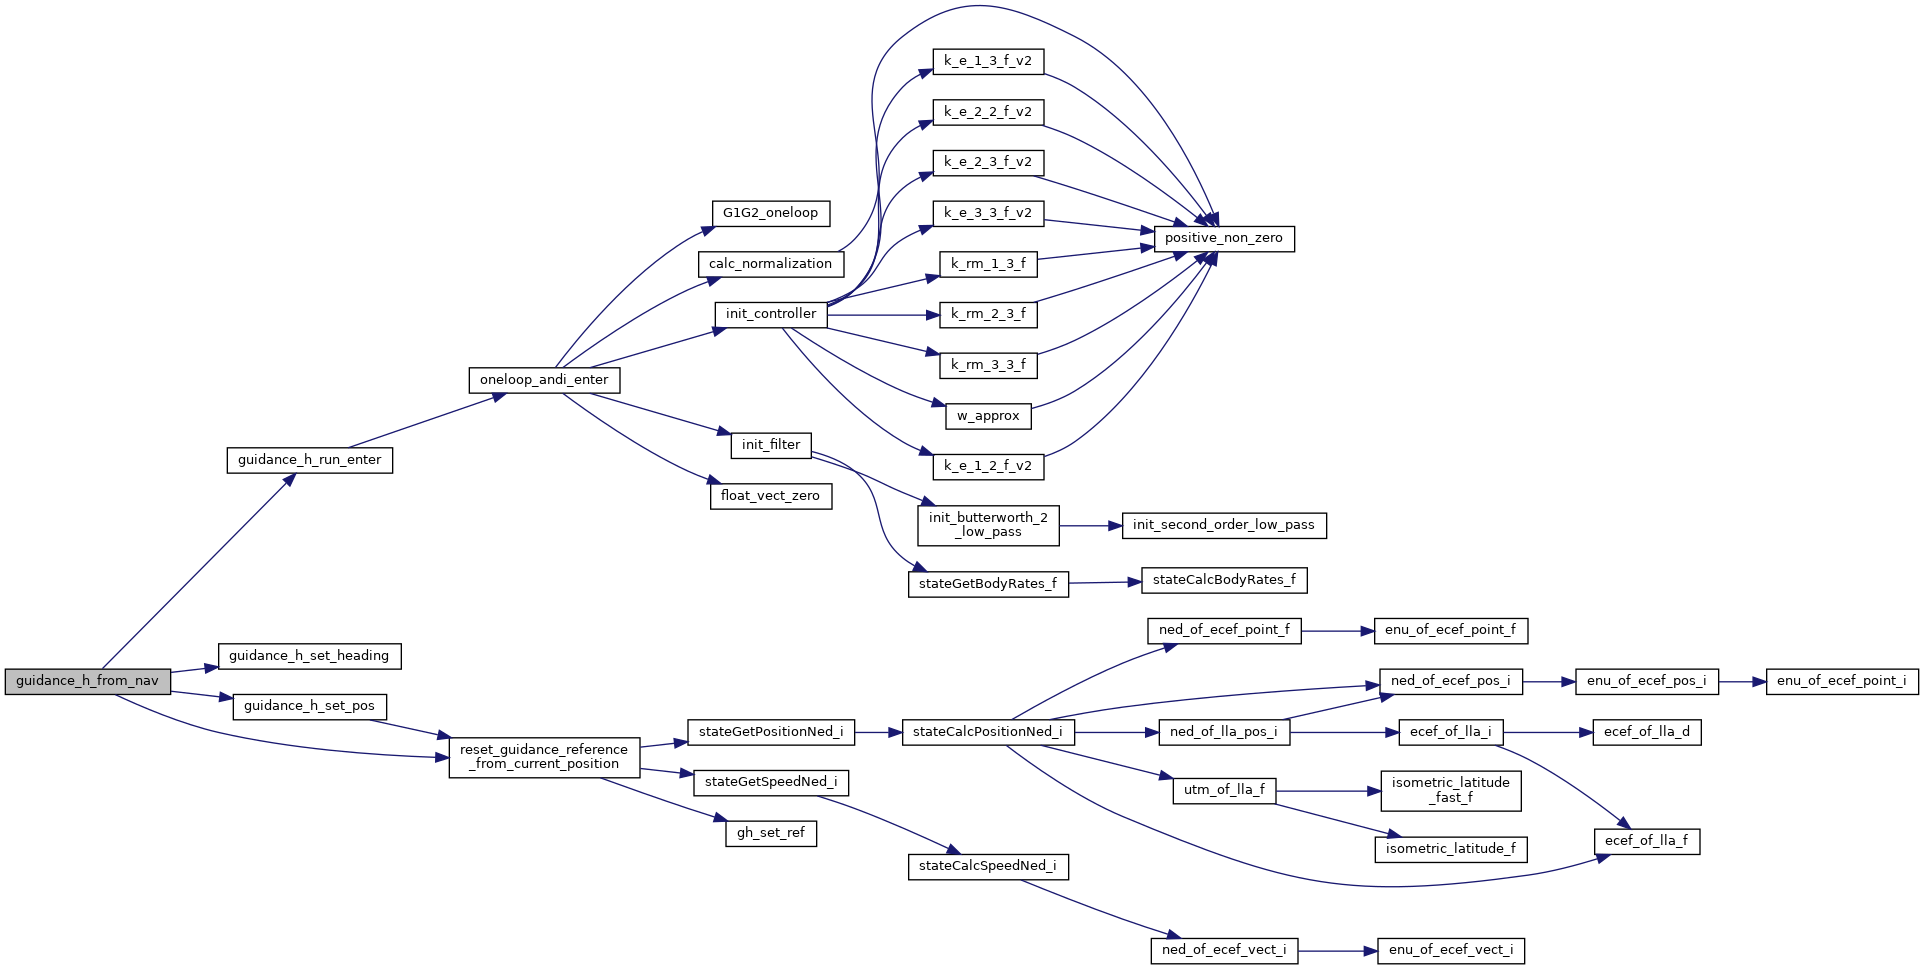
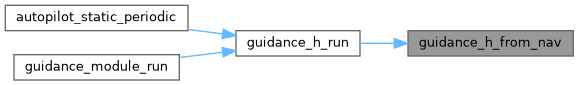
Set horizontal guidance from NAV and run control loop.
Definition at line 391 of file guidance_h.c.
References guidance_h_from_nav(), guidance_h_nav_enter(), if(), nav, NAV_HORIZONTAL_MODE_ATTITUDE, NAV_HORIZONTAL_MODE_NONE, and stab_sp_from_eulers_f().
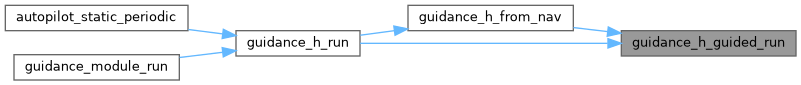
Referenced by guidance_h_from_nav(), and guidance_h_run().
|
extern |
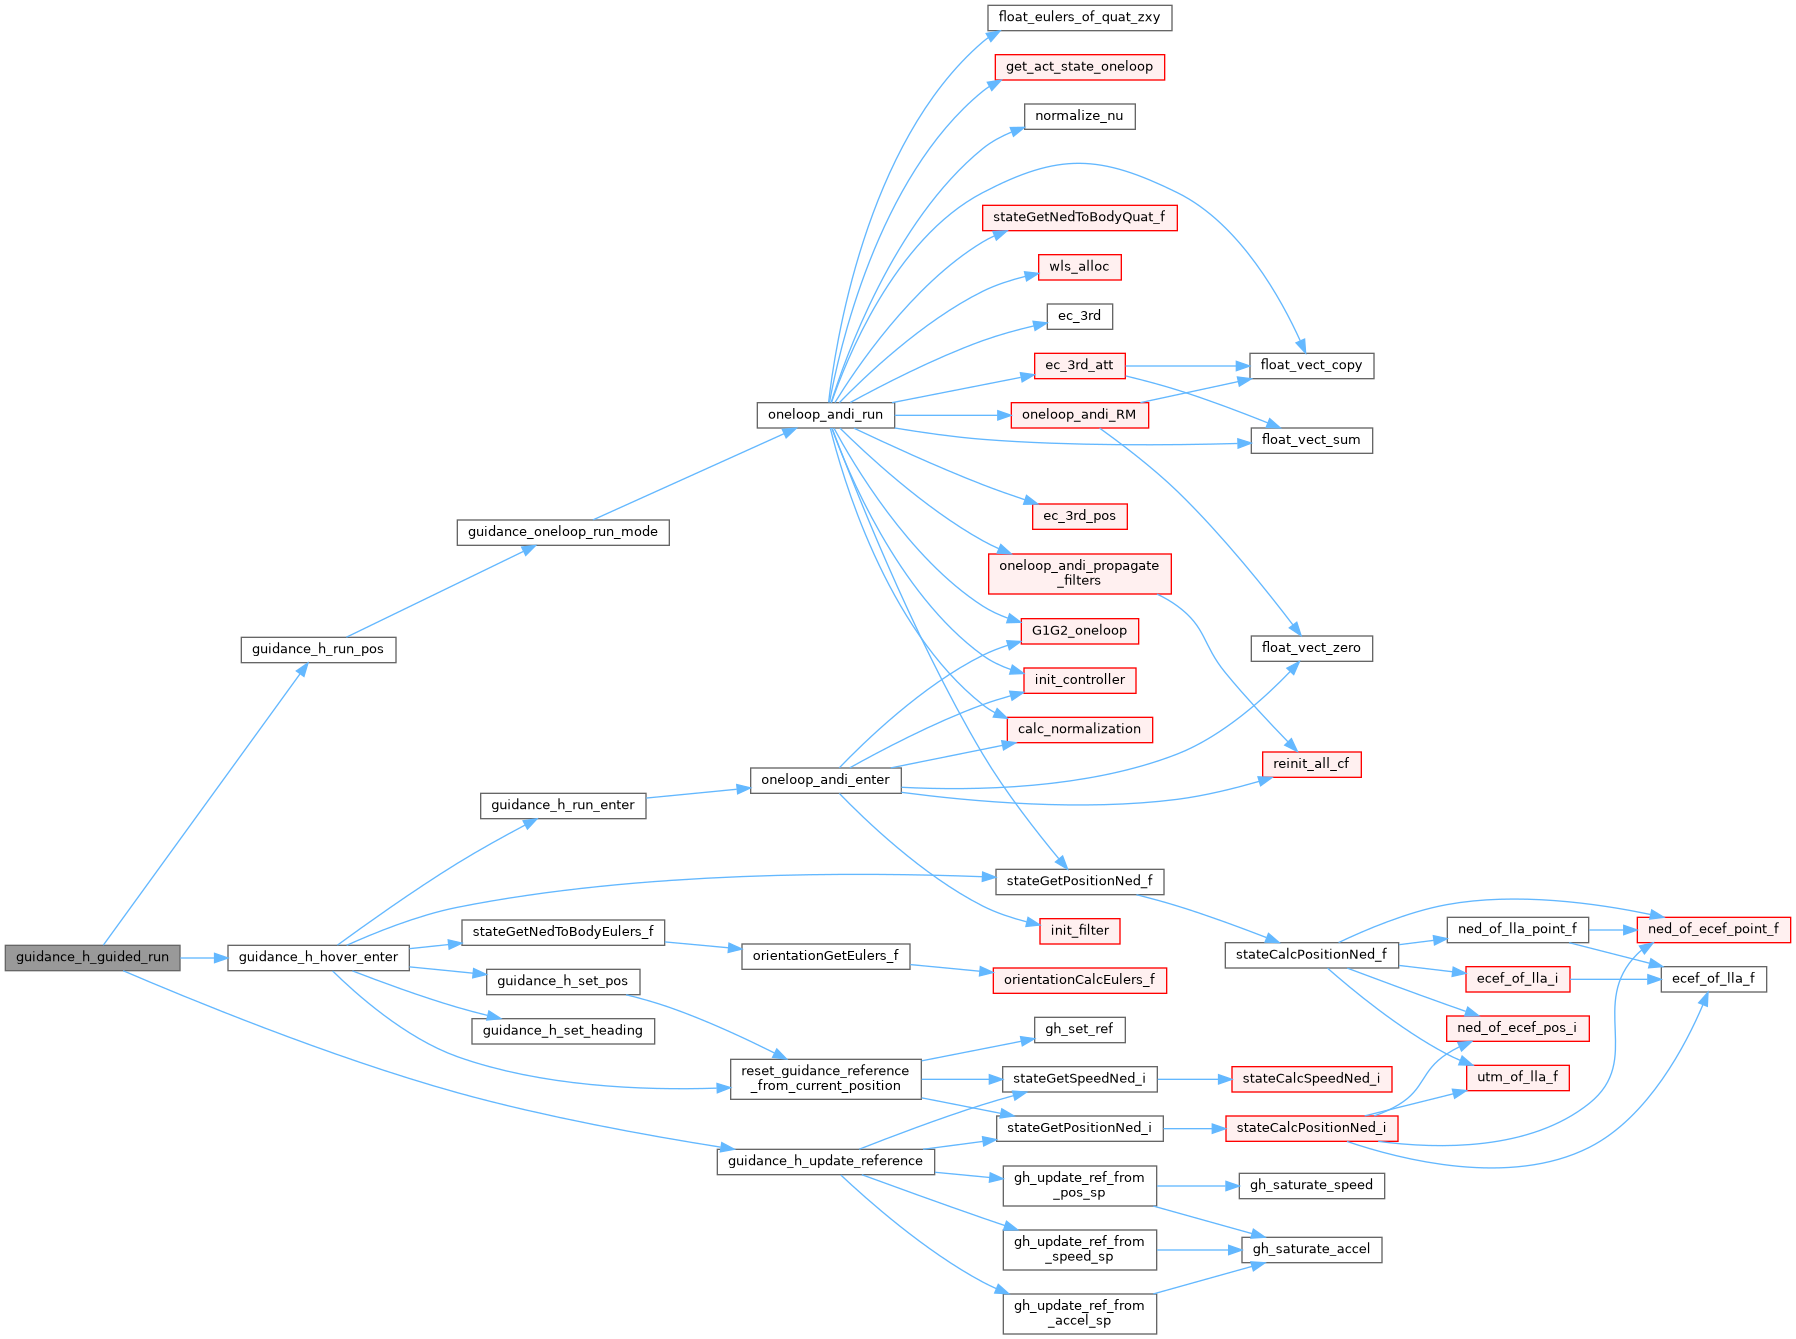
Run GUIDED mode control.
Definition at line 457 of file guidance_h.c.
References guidance_h, guidance_h_cmd, guidance_h_guided_run(), guidance_h_hover_enter(), guidance_h_run_pos(), guidance_h_run_speed(), and guidance_h_update_reference().
Referenced by guidance_h_guided_run(), and guidance_h_run().
|
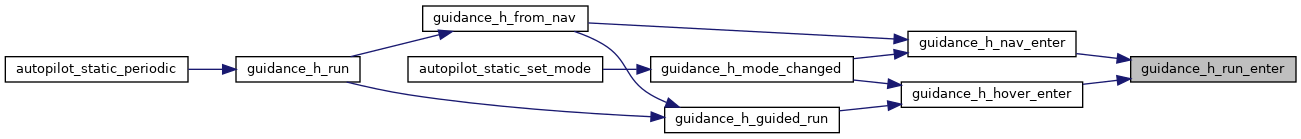
extern |
Definition at line 359 of file guidance_h.c.
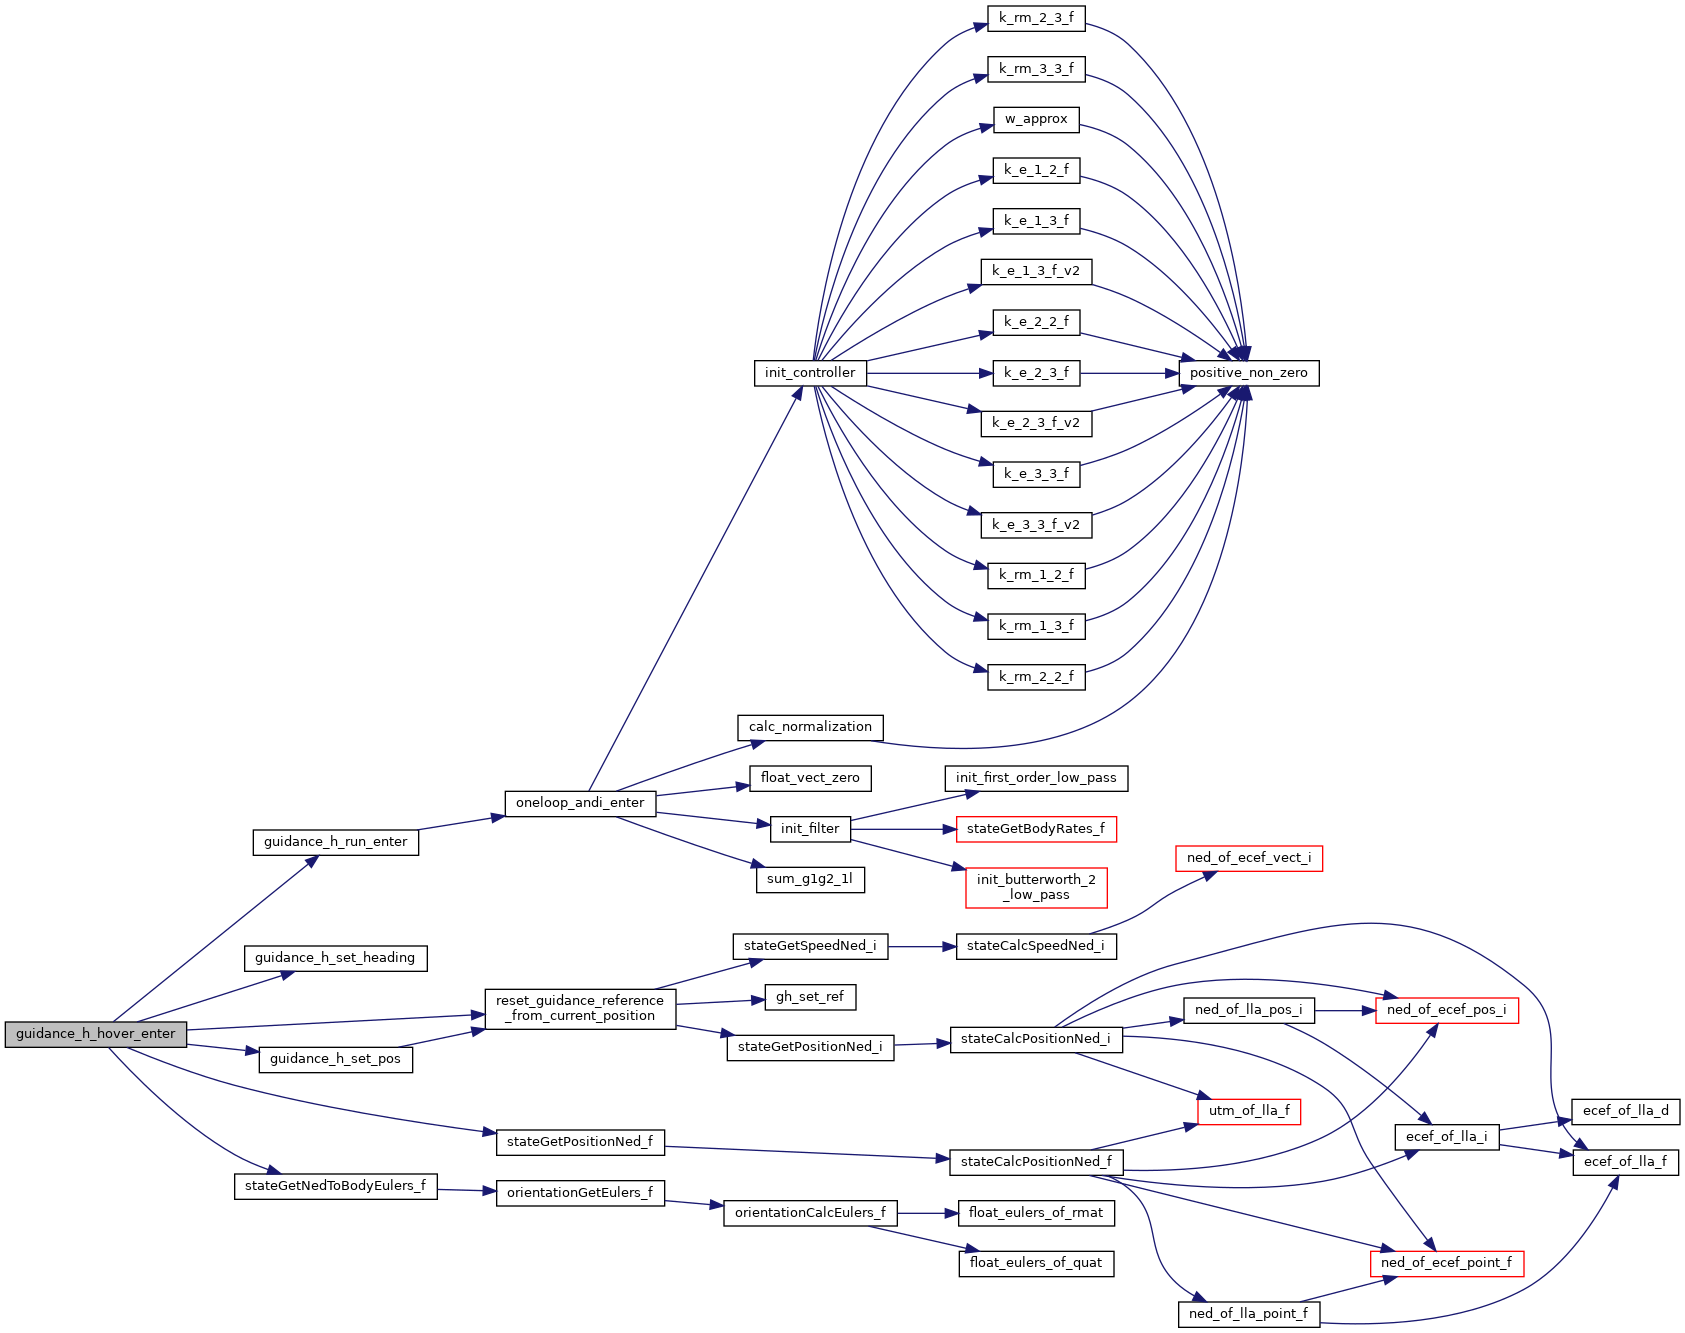
References guidance_h, guidance_h_run_enter(), guidance_h_set_heading(), guidance_h_set_pos(), FloatEulers::psi, reset_guidance_reference_from_current_position(), stateGetNedToBodyEulers_f(), stateGetPositionNed_f(), FloatVect2::x, and FloatVect2::y.
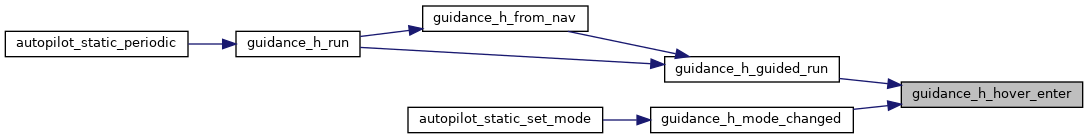
Referenced by guidance_h_guided_run(), guidance_h_mode_changed(), and wedgebug_periodic().
|
extern |
Definition at line 86 of file guidance_h.c.
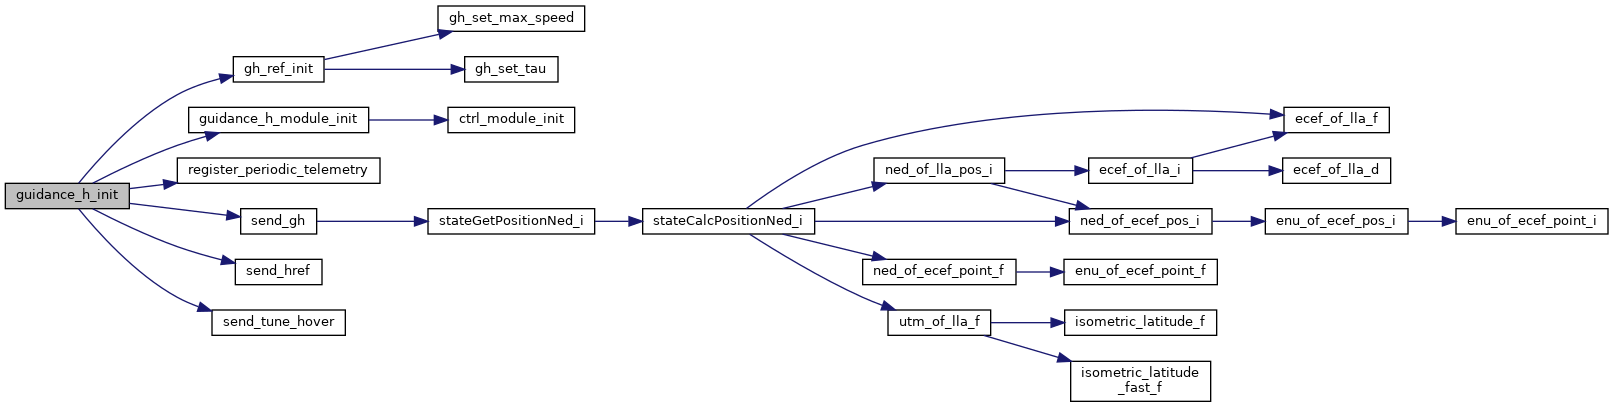
References DefaultPeriodic, gh_ref_init(), guidance_h, GUIDANCE_H_MODE_NONE, GUIDANCE_H_RC_ID, GUIDANCE_H_USE_REF, INT_VECT2_ZERO, rc_cb(), rc_ev, register_periodic_telemetry(), send_gh(), and send_href().
|
extern |
Definition at line 128 of file guidance_h.c.
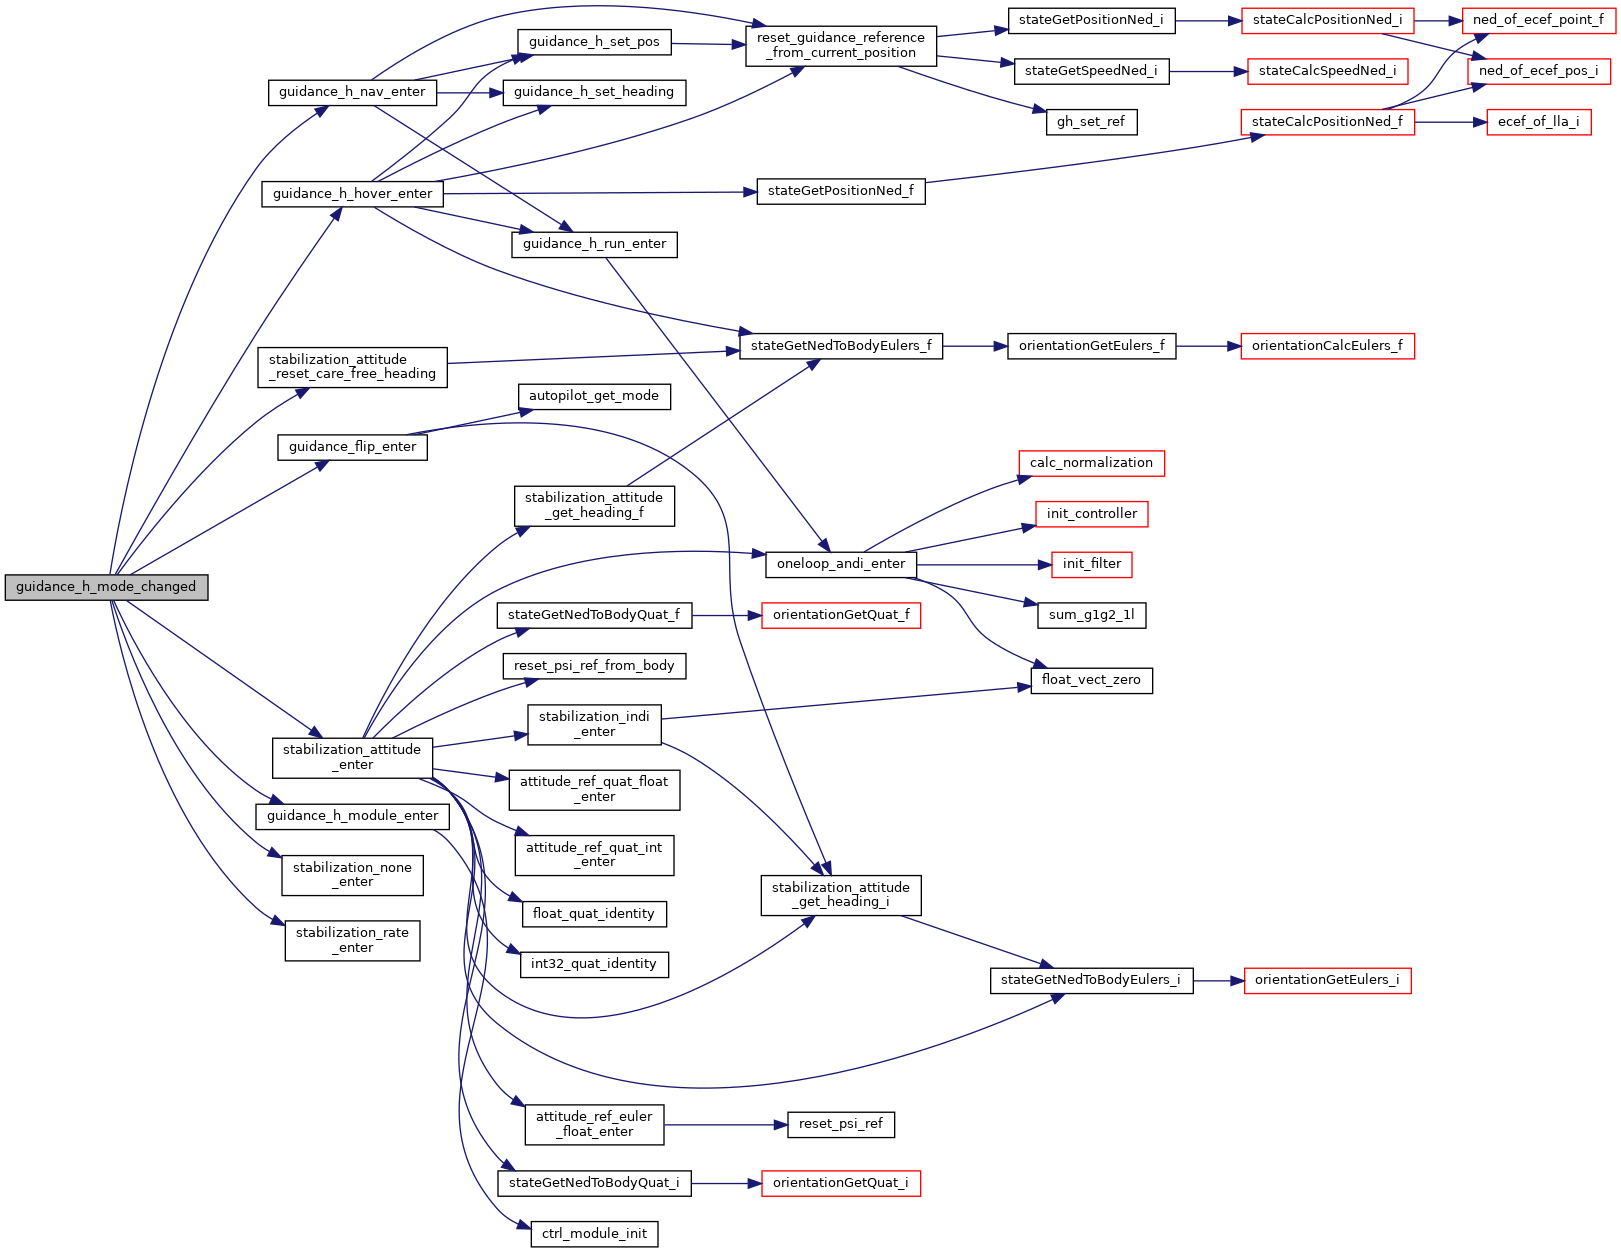
References guidance_h, guidance_h_hover_enter(), GUIDANCE_H_MODE_GUIDED, GUIDANCE_H_MODE_HOVER, GUIDANCE_H_MODE_NAV, and guidance_h_nav_enter().
Referenced by autopilot_static_set_mode(), control_mixing_heewing_attitude_direct_enter(), control_mixing_heewing_attitude_plane_enter(), control_mixing_heewing_nav_enter(), and guidance_module_enter().
|
extern |
Definition at line 380 of file guidance_h.c.
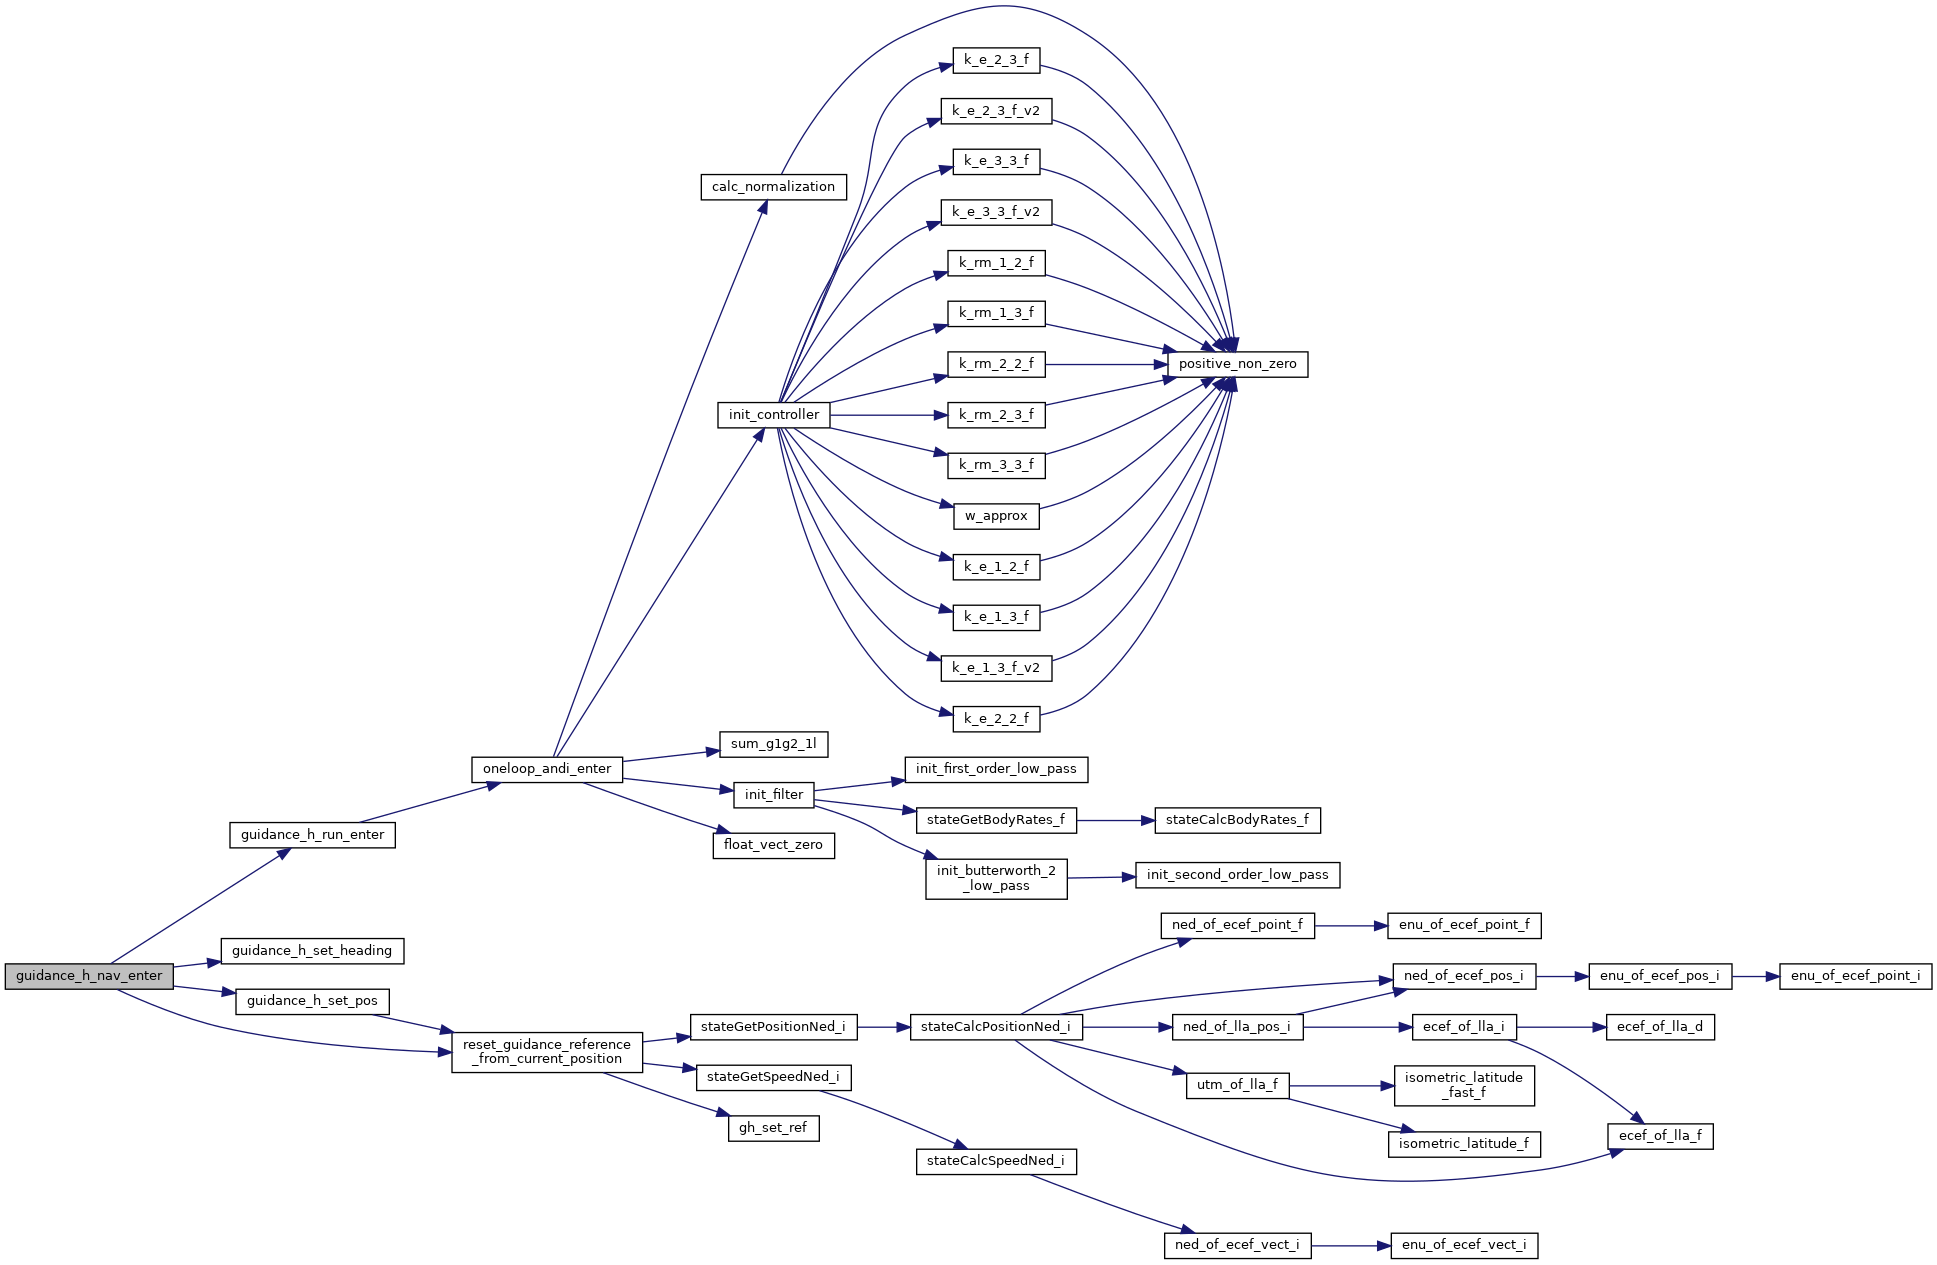
References guidance_h_run_enter(), guidance_h_set_heading(), guidance_h_set_pos(), nav, and reset_guidance_reference_from_current_position().
Referenced by guidance_h_from_nav(), and guidance_h_mode_changed().
|
extern |
Definition at line 244 of file guidance_h.c.
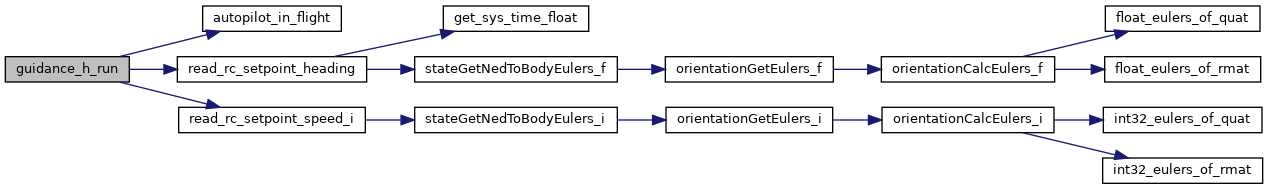
References guidance_h, guidance_h_from_nav(), guidance_h_guided_run(), GUIDANCE_H_MODE_GUIDED, GUIDANCE_H_MODE_HOVER, GUIDANCE_H_MODE_NAV, guidance_h_run(), StabilizationSetpoint::sp, and STAB_SP_SET_EULERS_ZERO.
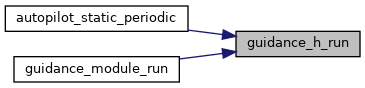
Referenced by autopilot_static_periodic(), control_mixing_heewing_nav_run(), guidance_h_run(), and guidance_module_run().
|
extern |
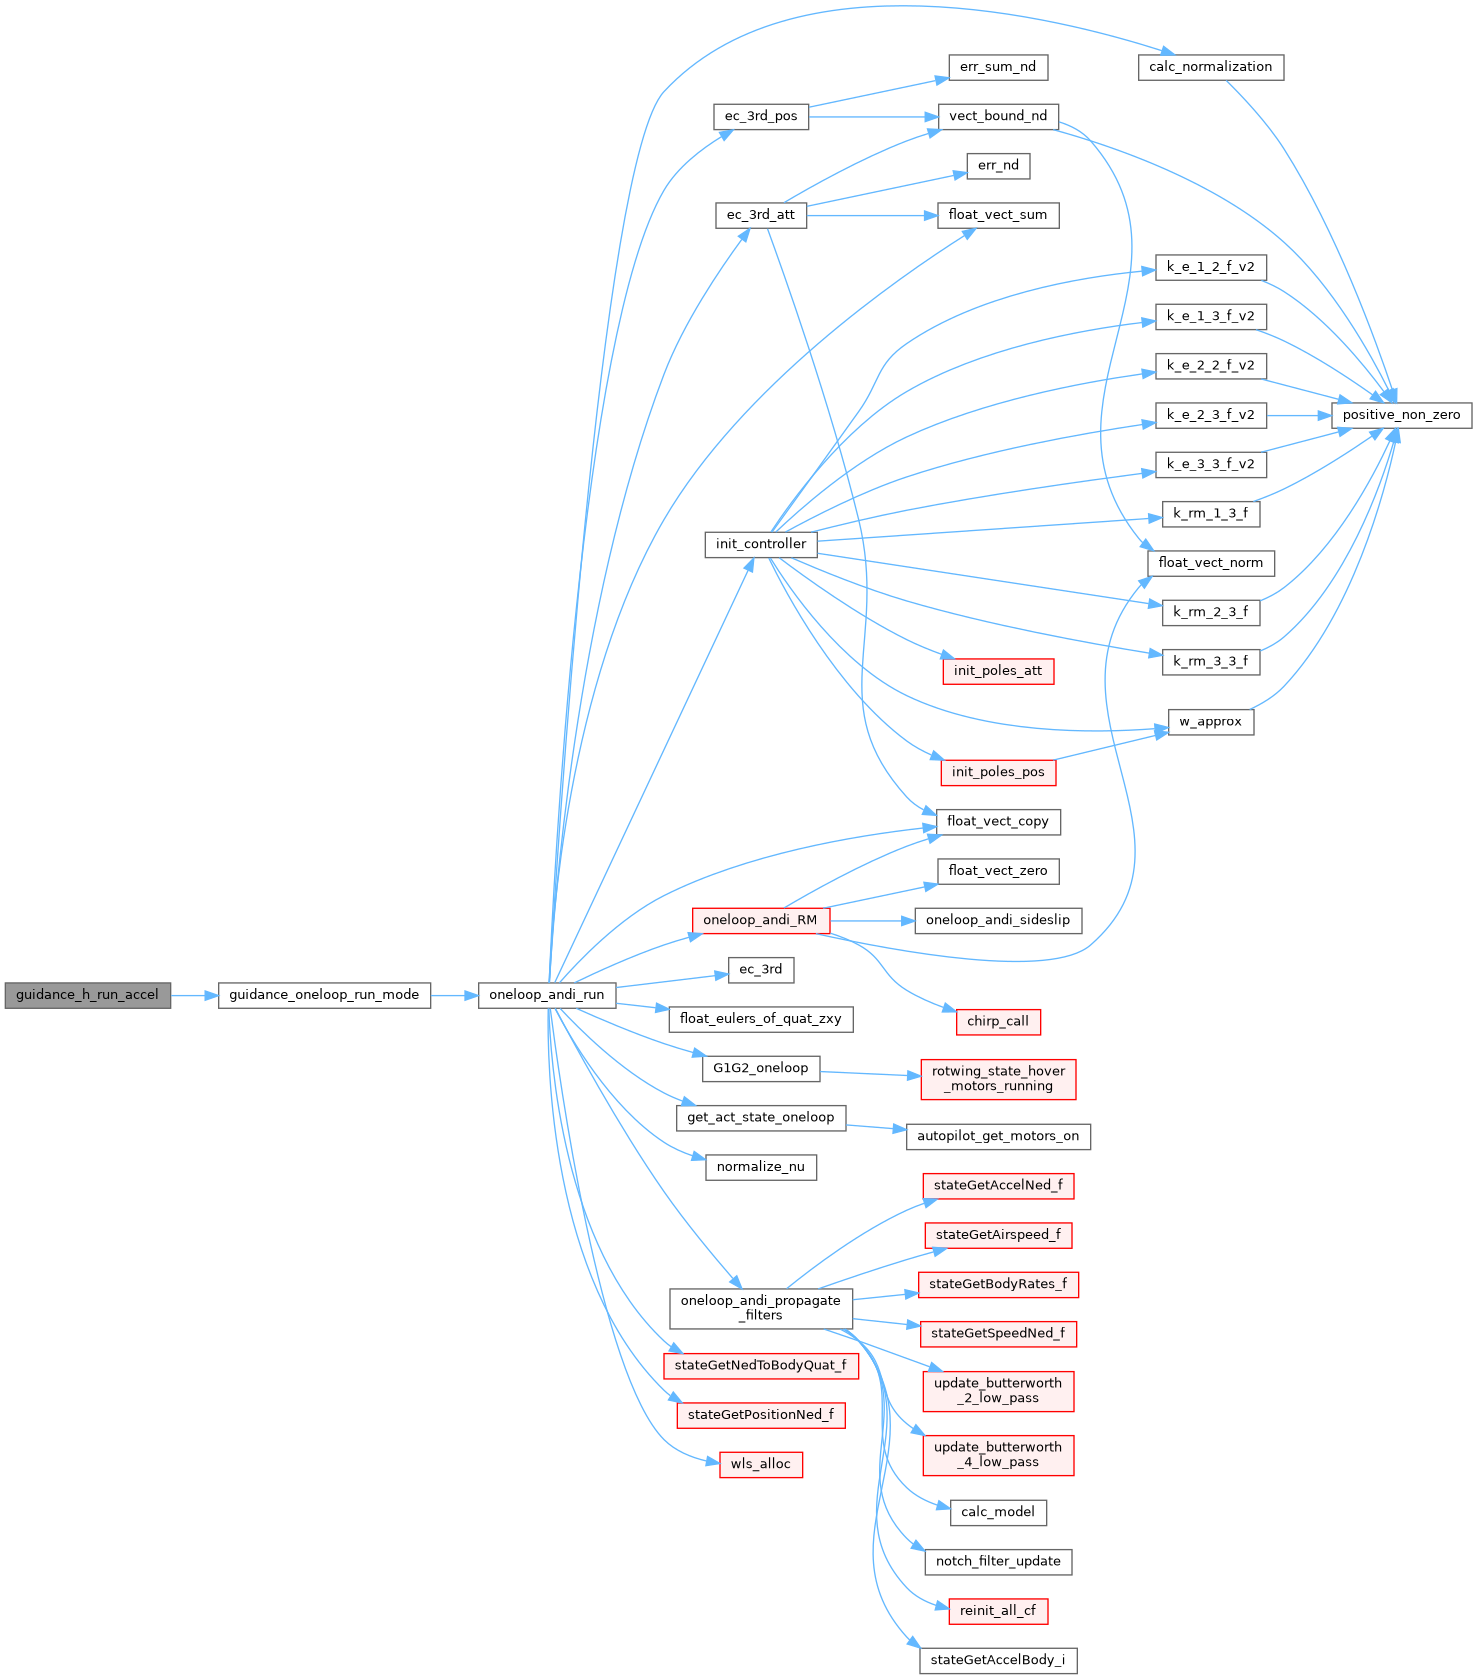
Definition at line 58 of file guidance_oneloop.c.
References _gv, _v_mode, guidance_h_run_accel(), GUIDANCE_ONELOOP_H_ACCEL, GUIDANCE_ONELOOP_NB_H_ACCEL, guidance_oneloop_nB_run_mode(), and guidance_oneloop_run_mode().
Referenced by guidance_h_run_accel().
|
extern |
Definition at line 35 of file guidance_oneloop.c.
Referenced by guidance_h_hover_enter(), and guidance_h_nav_enter().
|
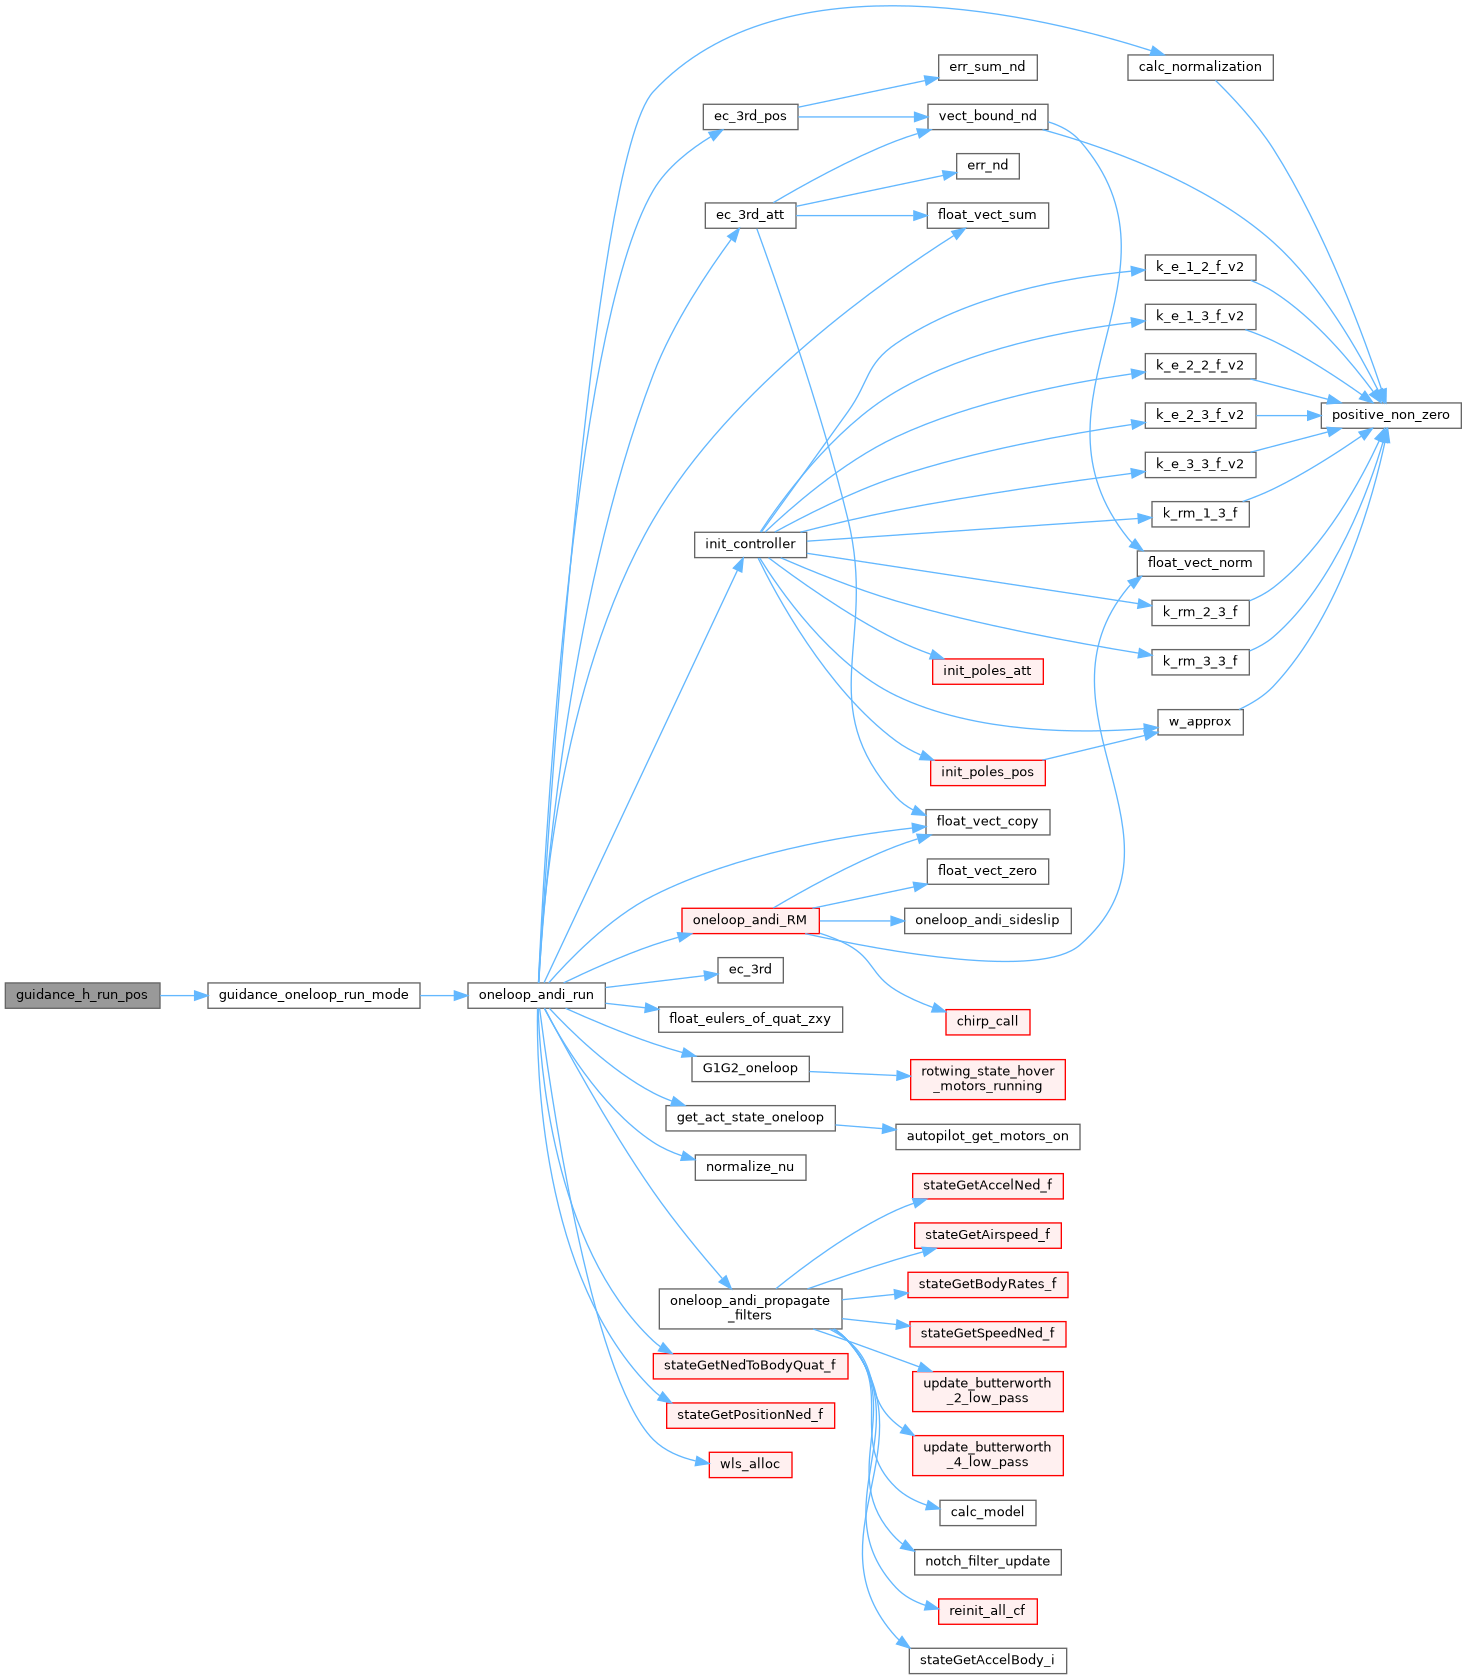
extern |
Definition at line 48 of file guidance_oneloop.c.
References _gv, _v_mode, guidance_h_run_pos(), GUIDANCE_ONELOOP_H_POS, GUIDANCE_ONELOOP_NB_H_POS, guidance_oneloop_nB_run_mode(), and guidance_oneloop_run_mode().
Referenced by guidance_h_guided_run(), and guidance_h_run_pos().
|
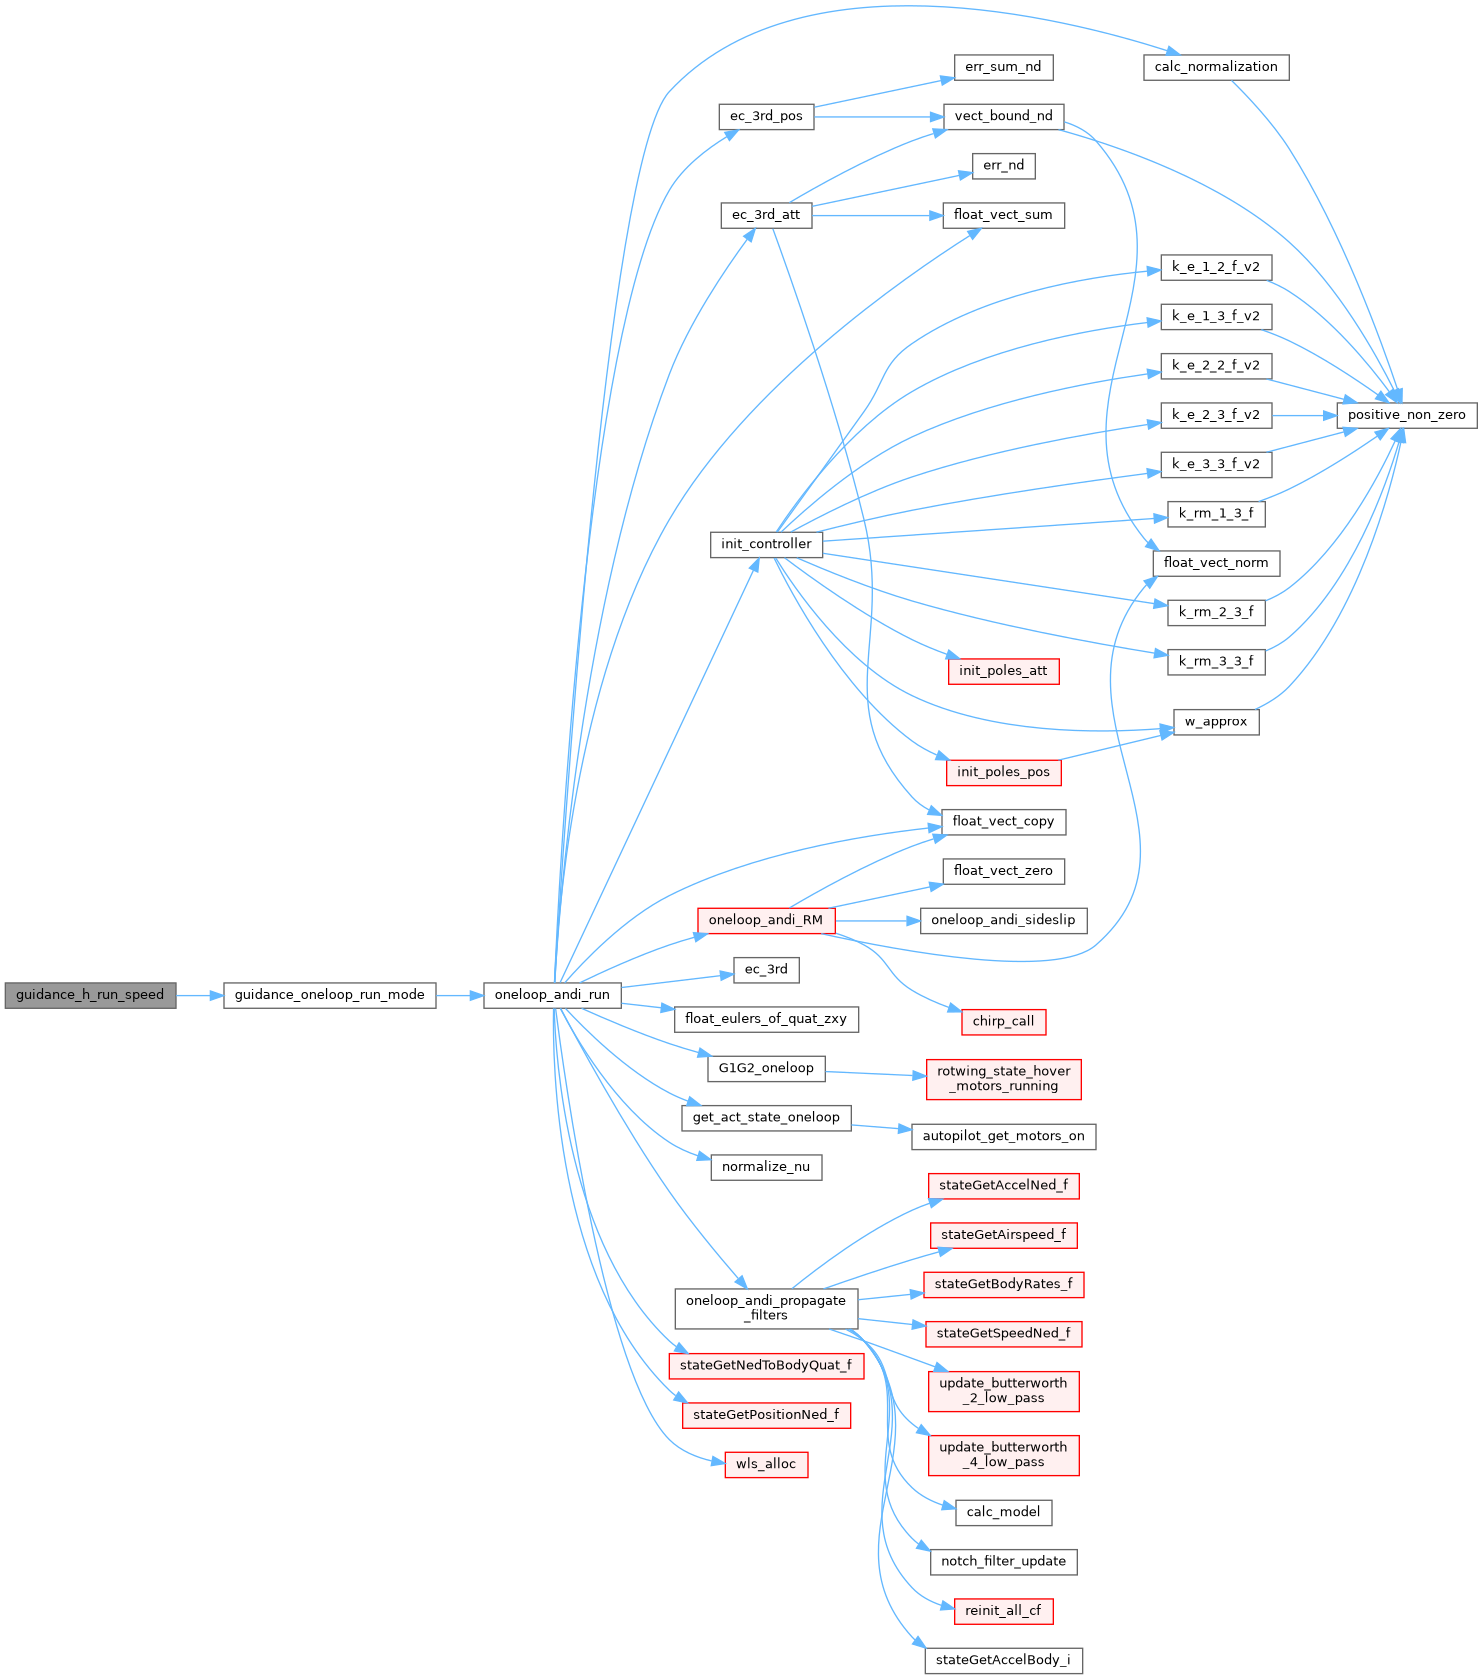
extern |
Definition at line 53 of file guidance_oneloop.c.
References _gv, _v_mode, guidance_h_run_speed(), GUIDANCE_ONELOOP_H_SPEED, GUIDANCE_ONELOOP_NB_H_SPEED, guidance_oneloop_nB_run_mode(), and guidance_oneloop_run_mode().
Referenced by guidance_h_guided_run(), and guidance_h_run_speed().
|
extern |
Set horizontal acceleration setpoint.
| ax | North acceleration (local NED frame) in meters/sec². |
| ay | East acceleration (local NED frame) in meters/sec². |
Definition at line 520 of file guidance_h.c.
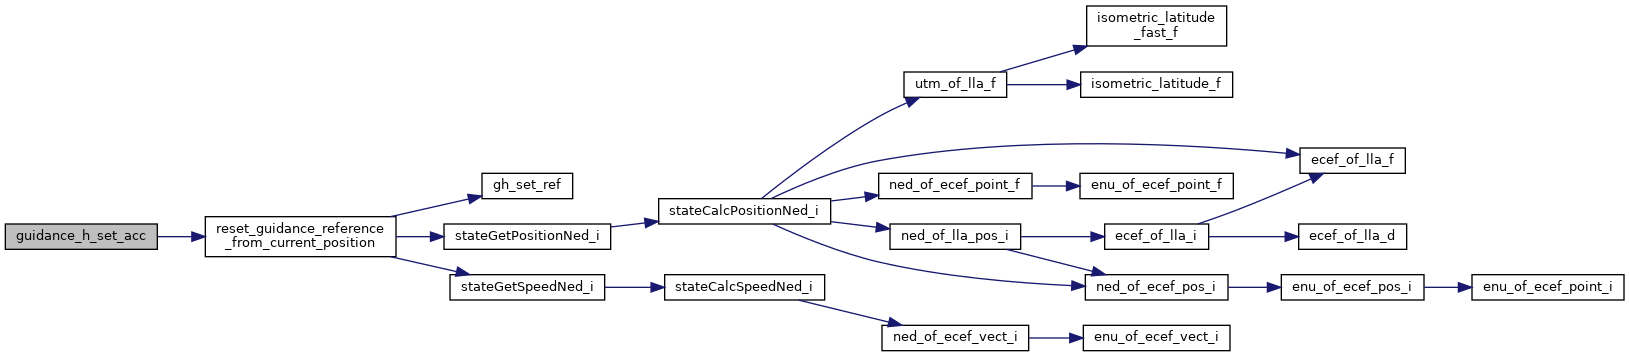
References ACCEL_BFP_OF_REAL, guidance_h, and reset_guidance_reference_from_current_position().
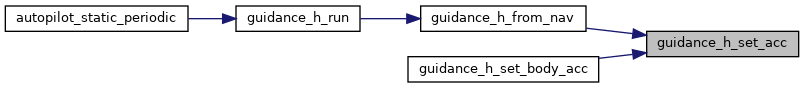
Referenced by guidance_h_set_body_acc().
|
extern |
Set position speed and acceleration (NED frame).
| x | North position (local NED frame) in meters. |
| y | East position (local NED frame) in meters. |
| vx | North velocity (local NED frame) in meters/sec. |
| vy | East velocity (local NED frame) in meters/sec. |
| ax | North acceleration (local NED frame) in meters/sec². |
| ay | East acceleration (local NED frame) in meters/sec². |
Definition at line 536 of file guidance_h.c.
References ACCEL_BFP_OF_REAL, guidance_h, POS_BFP_OF_REAL, and SPEED_BFP_OF_REAL.
|
extern |
Set body relative horizontal acceleration setpoint.
| ax | forward acceleration (body frame) in meters/sec². |
| ay | right acceleration (body frame) in meters/sec². |
Definition at line 512 of file guidance_h.c.
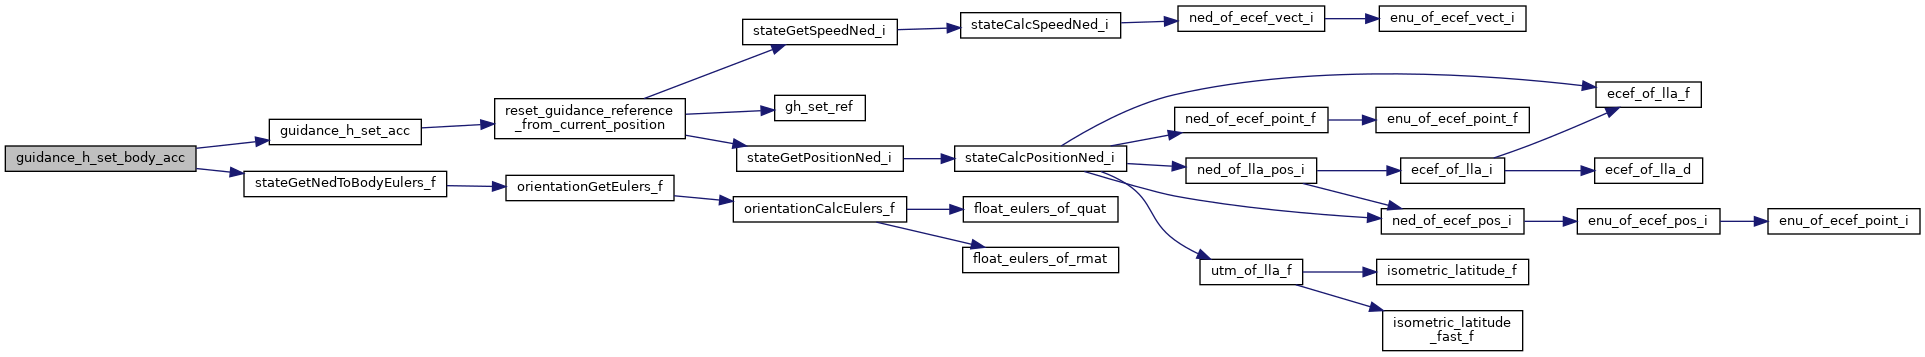
References guidance_h_set_acc(), FloatEulers::psi, and stateGetNedToBodyEulers_f().
|
extern |
Set body relative horizontal velocity setpoint.
| vx | forward velocity (body frame) in meters/sec. |
| vy | right velocity (body frame) in meters/sec. |
Definition at line 494 of file guidance_h.c.
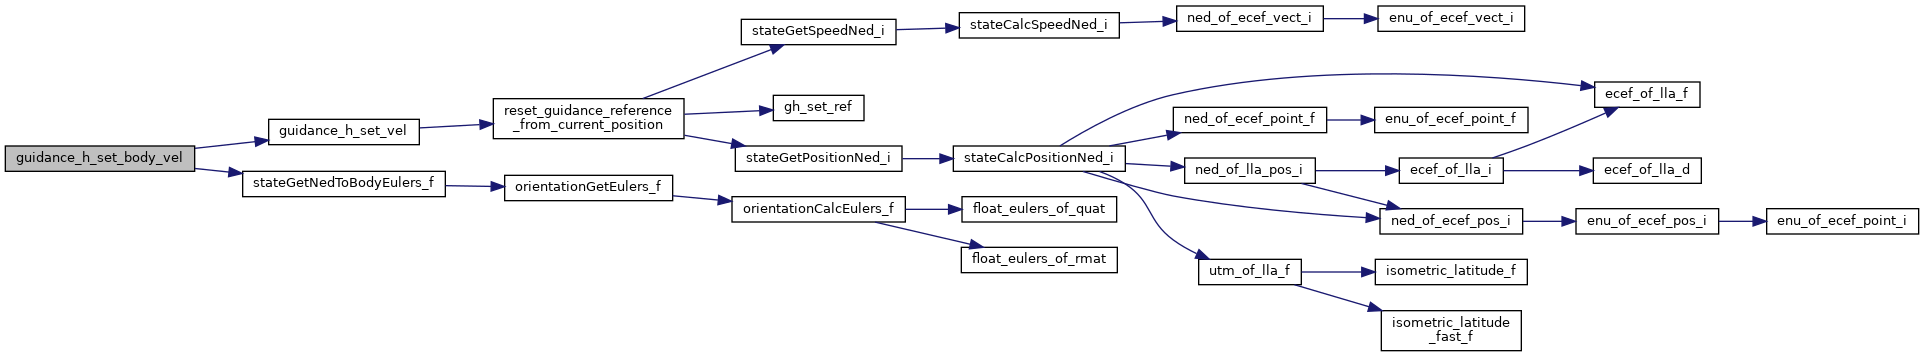
References guidance_h_set_vel(), FloatEulers::psi, and stateGetNedToBodyEulers_f().
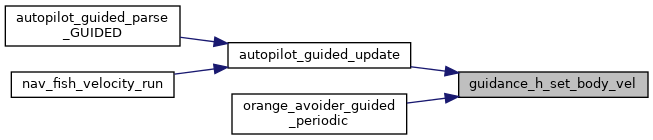
Referenced by orange_avoider_guided_periodic().
|
extern |
Set heading setpoint.
| heading | Setpoint in radians. |
Definition at line 487 of file guidance_h.c.
References FLOAT_ANGLE_NORMALIZE, guidance_h, and heading.
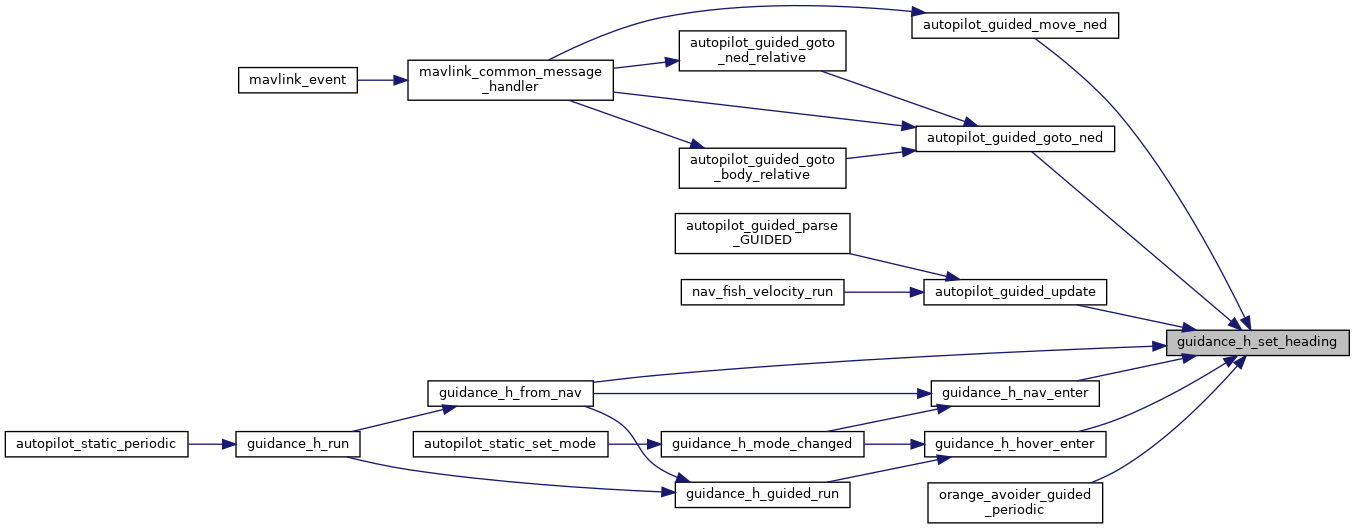
Referenced by guidance_h_hover_enter(), guidance_h_nav_enter(), orange_avoider_guided_periodic(), and wedgebug_periodic().
|
extern |
Set heading rate setpoint.
| rate | Heading rate in radians. |
Definition at line 530 of file guidance_h.c.
References guidance_h.
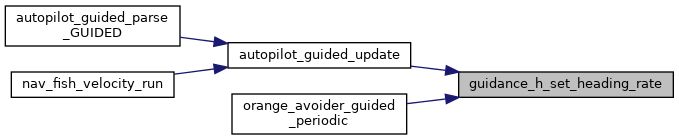
Referenced by orange_avoider_guided_periodic().
|
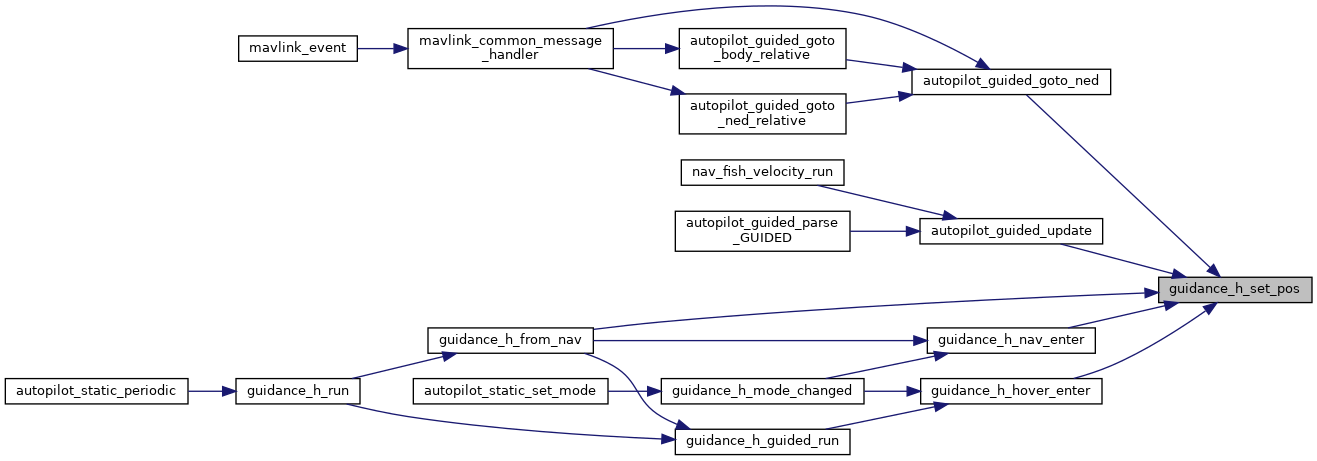
extern |
Set horizontal position setpoint.
| x | North position (local NED frame) in meters. |
| y | East position (local NED frame) in meters. |
Definition at line 477 of file guidance_h.c.
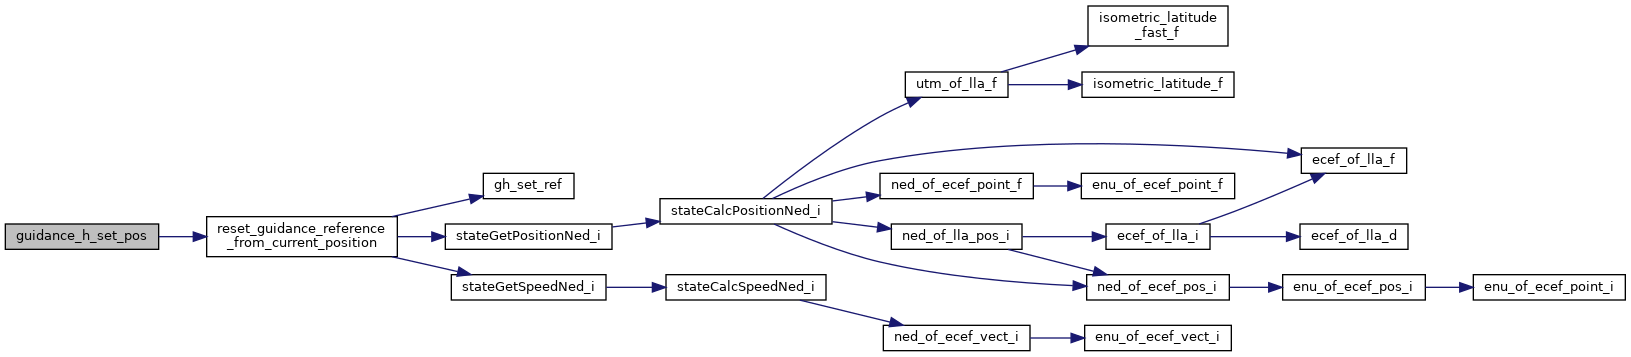
References guidance_h, POS_BFP_OF_REAL, and reset_guidance_reference_from_current_position().
Referenced by guidance_h_hover_enter(), guidance_h_nav_enter(), and wedgebug_periodic().
|
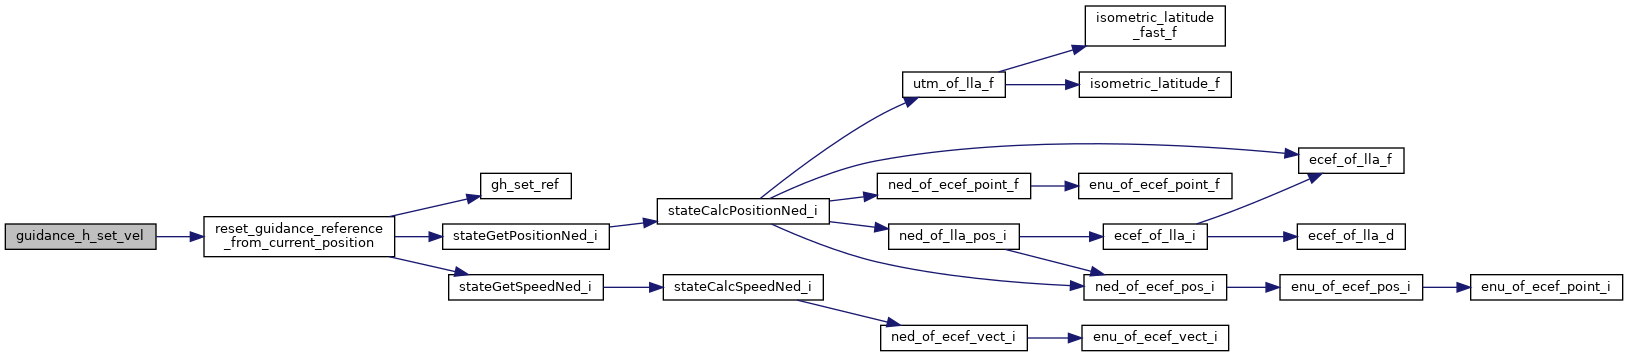
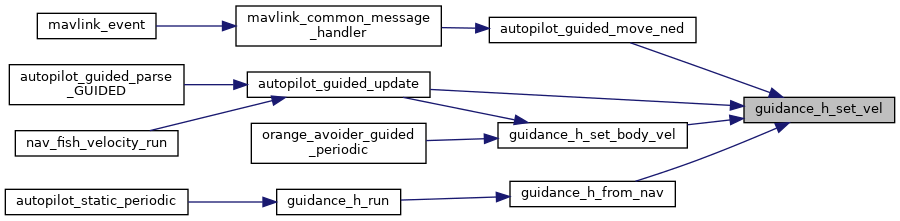
extern |
Set horizontal velocity setpoint.
| vx | North velocity (local NED frame) in meters/sec. |
| vy | East velocity (local NED frame) in meters/sec. |
Definition at line 502 of file guidance_h.c.
References guidance_h, reset_guidance_reference_from_current_position(), and SPEED_BFP_OF_REAL.
Referenced by guidance_h_set_body_vel().
|
inlinestatic |
Definition at line 192 of file guidance_h.h.
References gh_set_max_speed().
|
inlinestatic |
Definition at line 197 of file guidance_h.h.
References gh_set_omega().
|
inlinestatic |
Definition at line 207 of file guidance_h.h.
References gh_set_tau().
|
inlinestatic |
Definition at line 202 of file guidance_h.h.
References gh_set_zeta().
|
extern |
Definition at line 45 of file guidance_h.c.
Referenced by autopilot_static_periodic(), guidance_h_guided_run(), guidance_h_hover_enter(), guidance_h_init(), guidance_h_mode_changed(), guidance_h_run(), guidance_h_set_acc(), guidance_h_set_all(), guidance_h_set_heading(), guidance_h_set_heading_rate(), guidance_h_set_pos(), guidance_h_set_vel(), guidance_h_update_reference(), guidance_pid_h_run(), ins_ekf2_publish_attitude(), orange_avoider_guided_periodic(), rc_cb(), reset_guidance_reference_from_current_position(), rotwing_state_periodic(), send_fp(), send_gh(), send_hover_loop(), send_href(), send_status(), and stabilization_indi_set_wls_settings().
 1.15.0