|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Paparazzi specific wrapper to run simple module based INS. More...
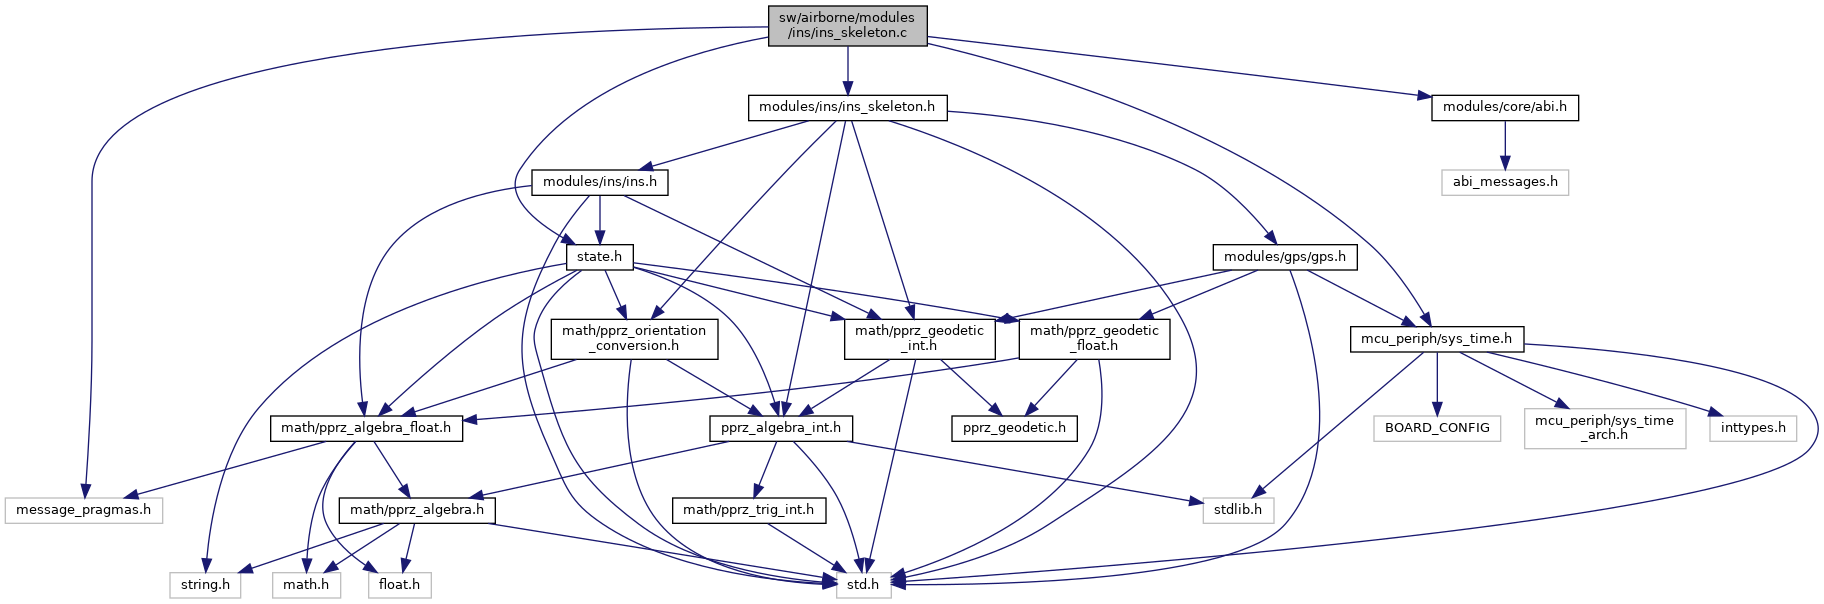
#include "modules/ins/ins_skeleton.h"#include "modules/core/abi.h"#include "mcu_periph/sys_time.h"#include "message_pragmas.h"#include "state.h"Go to the source code of this file.
Macros | |
| #define | USE_INS_NAV_INIT TRUE |
| #define | INS_MODULE_BARO_ID AIR_DATA_SENDER_ID |
| baro | |
| #define | INS_MODULE_IMU_ID ABI_BROADCAST |
| IMU (accel). | |
| #define | INS_MODULE_GPS_ID GPS_MULTI_ID |
| ABI binding for gps data. | |
Functions | |
| void | ins_module_wrapper_init (void) |
| static void | ins_ned_to_state (void) |
| copy position and speed to state interface | |
| static void | reset_cb (uint8_t sender_id UNUSED, uint8_t flag) |
| static void | baro_cb (uint8_t sender_id, uint32_t stamp, float pressure) |
| static void | accel_cb (uint8_t sender_id, uint32_t stamp, struct Int32Vect3 *accel) |
| static void | gps_cb (uint8_t sender_id, uint32_t stamp, struct GpsState *gps_s) |
| void WEAK | ins_module_init (void) |
| void WEAK | ins_module_update_baro (float pressure) |
| void WEAK | ins_module_update_gps (struct GpsState *gps_s, float dt) |
| void WEAK | ins_module_propagate (struct Int32Vect3 *accel, float dt) |
| void WEAK | ins_module_reset_local_origin (void) |
Variables | |
| static abi_event | baro_ev |
| static abi_event | accel_ev |
| static abi_event | gps_ev |
| static abi_event | reset_ev |
| struct InsModuleInt | ins_module |
| global INS state | |
Paparazzi specific wrapper to run simple module based INS.
Definition in file ins_skeleton.c.
| #define INS_MODULE_BARO_ID AIR_DATA_SENDER_ID |
| #define INS_MODULE_GPS_ID GPS_MULTI_ID |
ABI binding for gps data.
Used for GPS ABI messages.
Definition at line 58 of file ins_skeleton.c.
Referenced by ins_module_wrapper_init().
| #define INS_MODULE_IMU_ID ABI_BROADCAST |
| #define USE_INS_NAV_INIT TRUE |
Definition at line 35 of file ins_skeleton.c.
|
static |
Definition at line 114 of file ins_skeleton.c.
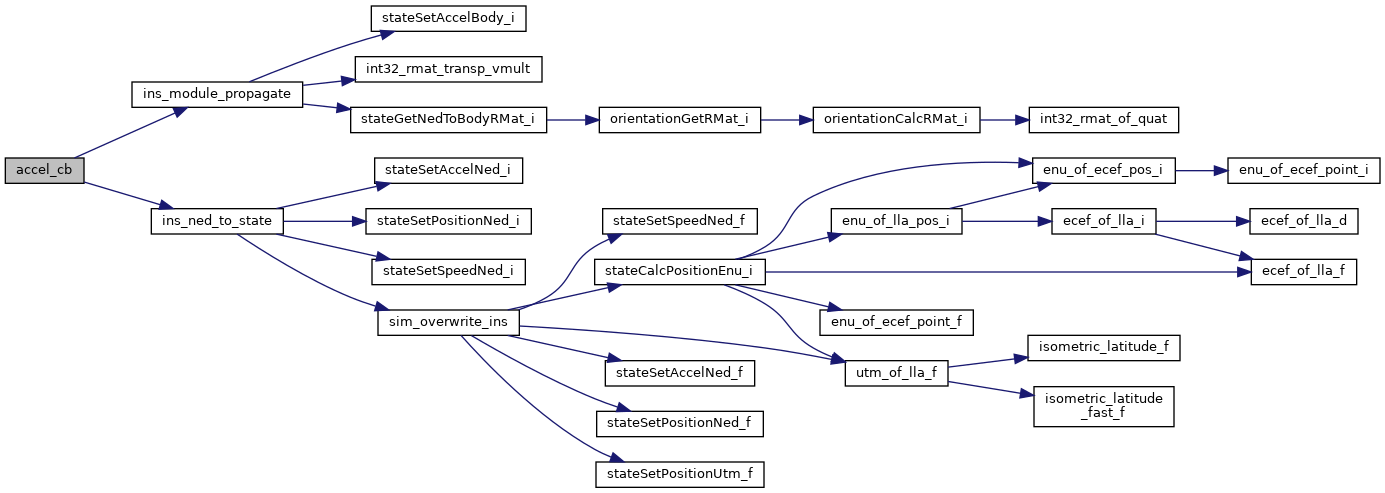
References ins_module_propagate(), and ins_ned_to_state().
Definition at line 107 of file ins_skeleton.c.
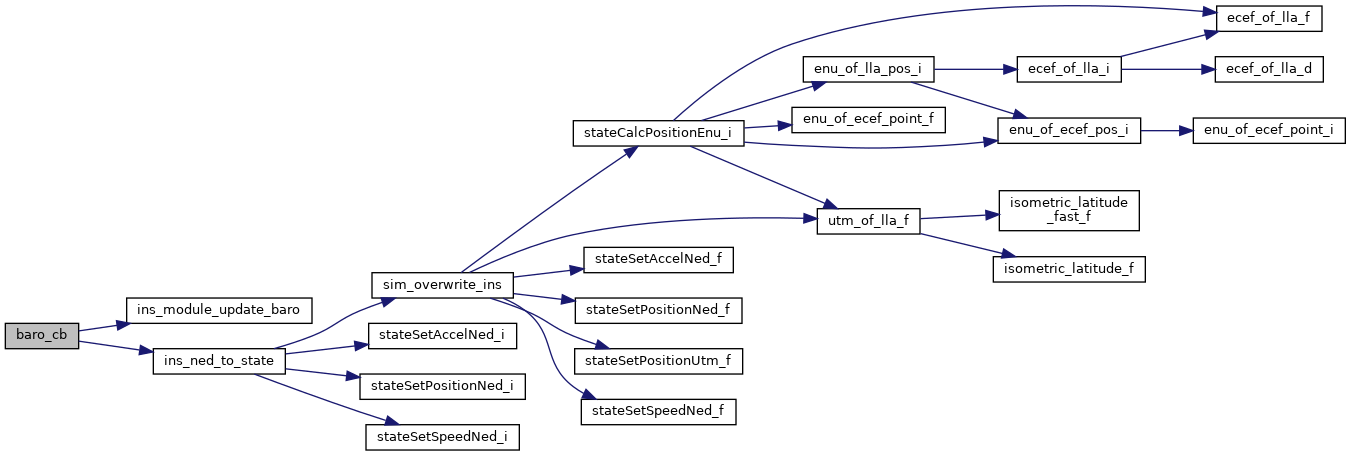
References ins_module_update_baro(), and ins_ned_to_state().
Definition at line 129 of file ins_skeleton.c.
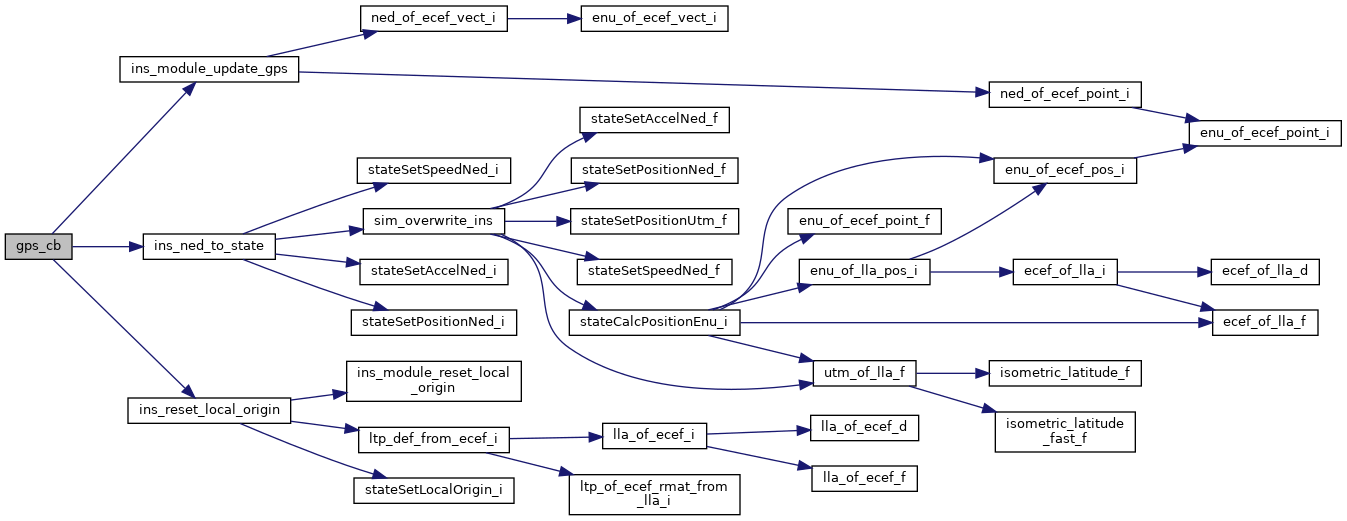
References GpsState::fix, GPS_FIX_3D, ins_module, ins_module_update_gps(), ins_ned_to_state(), INS_RESET_REF, and reset_cb().
| void WEAK ins_module_init | ( | void | ) |
Definition at line 158 of file ins_skeleton.c.
Referenced by ins_module_wrapper_init().
| void WEAK ins_module_propagate | ( | struct Int32Vect3 * | accel, |
| float | dt ) |
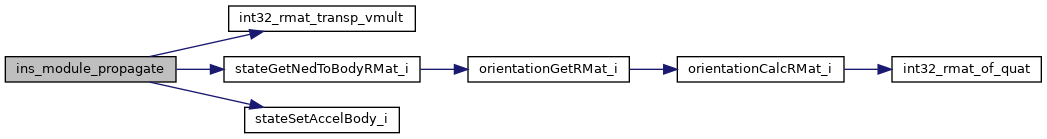
Definition at line 196 of file ins_skeleton.c.
References ins_module, int32_rmat_transp_vmult(), stateGetNedToBodyRMat_i(), stateSetAccelBody_i(), and VECT3_COPY.
Referenced by accel_cb().
| void WEAK ins_module_reset_local_origin | ( | void | ) |
Definition at line 206 of file ins_skeleton.c.
Referenced by reset_cb().
| void WEAK ins_module_update_baro | ( | float | pressure | ) |
Definition at line 162 of file ins_skeleton.c.
Referenced by baro_cb().
| void WEAK ins_module_update_gps | ( | struct GpsState * | gps_s, |
| float | dt ) |
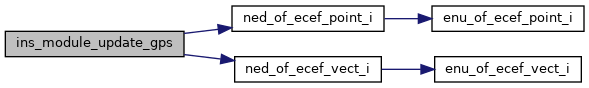
Definition at line 166 of file ins_skeleton.c.
References ecef_int_from_gps(), GpsState::ecef_vel, GPS_VALID_POS_ECEF_BIT, GPS_VALID_POS_LLA_BIT, GPS_VALID_VEL_ECEF_BIT, GPS_VALID_VEL_NED_BIT, ins_module, INT32_POS_OF_CM_DEN, INT32_POS_OF_CM_NUM, INT32_SPEED_OF_CM_S_DEN, INT32_SPEED_OF_CM_S_NUM, INT32_VECT3_SCALE_2, ned_of_ecef_point_i(), ned_of_ecef_vect_i(), GpsState::ned_vel, and GpsState::valid_fields.
Referenced by gps_cb().
| void ins_module_wrapper_init | ( | void | ) |
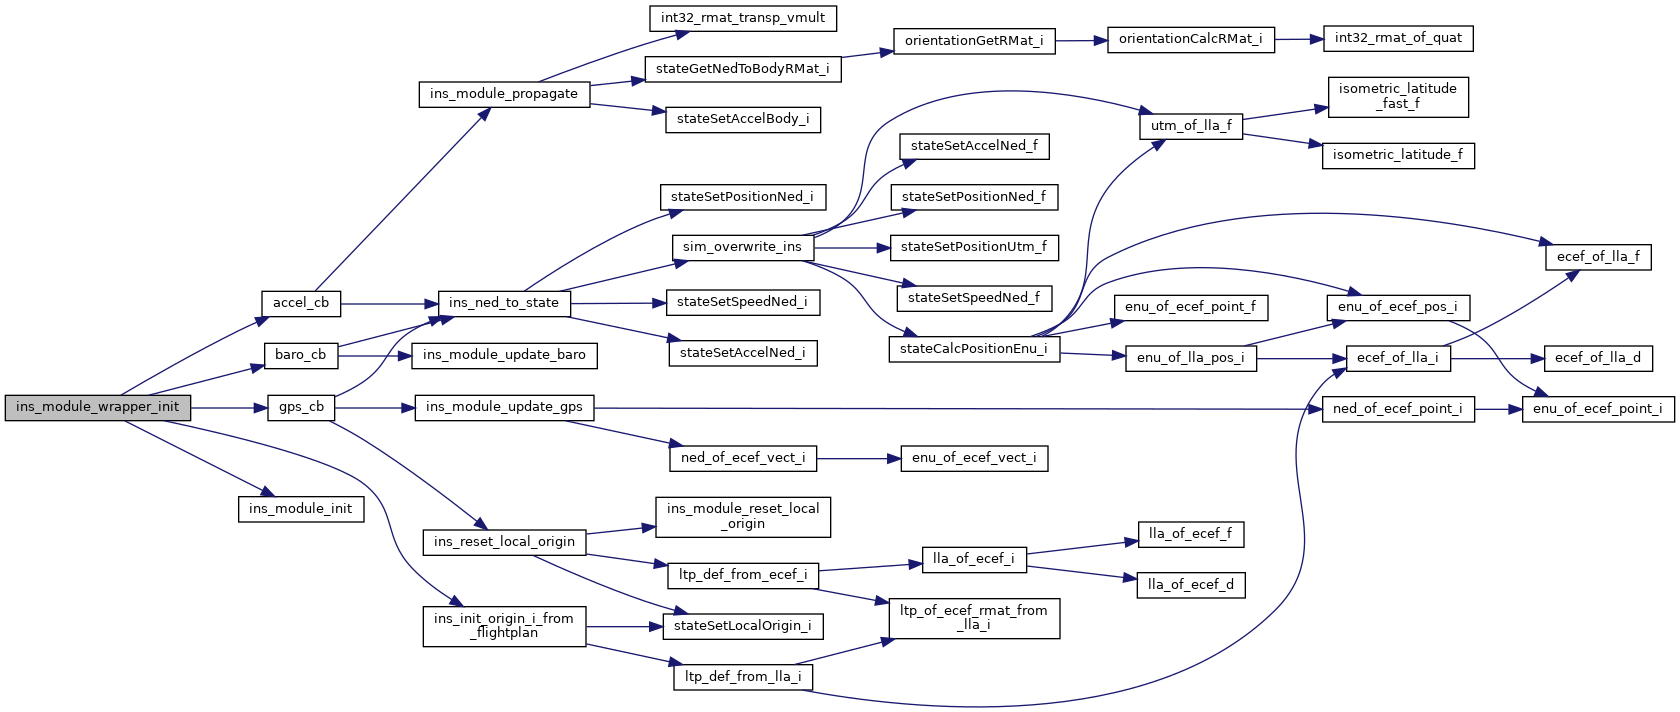
Definition at line 211 of file ins_skeleton.c.
References ABI_BROADCAST, accel_cb(), accel_ev, baro_cb(), baro_ev, gps_cb(), gps_ev, ins_init_origin_i_from_flightplan(), ins_module, INS_MODULE_BARO_ID, INS_MODULE_GPS_ID, INS_MODULE_IMU_ID, ins_module_init(), INT32_VECT3_ZERO, reset_cb(), and reset_ev.
|
static |
copy position and speed to state interface
Definition at line 72 of file ins_skeleton.c.
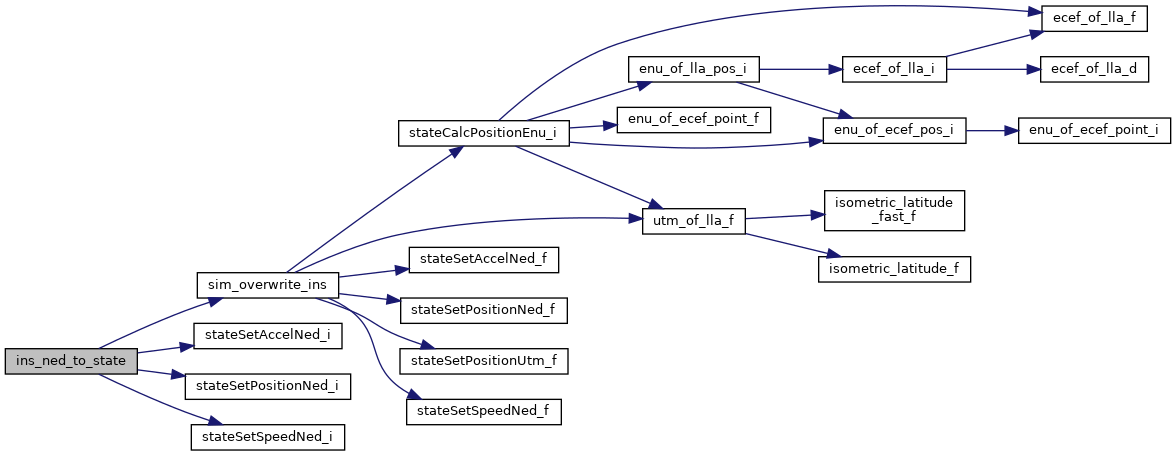
References ins_module, ins_ned_to_state(), nps_bypass_ins, sim_overwrite_ins(), stateSetAccelNed_i(), stateSetPositionNed_i(), and stateSetSpeedNed_i().
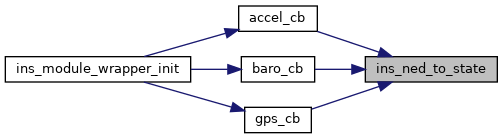
Referenced by accel_cb(), baro_cb(), and gps_cb().
Definition at line 89 of file ins_skeleton.c.
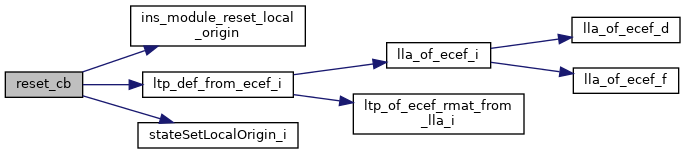
References ecef_int_from_gps(), GPS_FIX_3D, ins_module, ins_module_reset_local_origin(), INS_RESET_REF, ltp_def_from_ecef_i(), stateSetLocalOrigin_i(), and UNUSED.
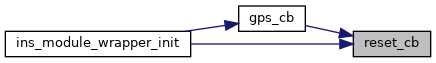
Referenced by gps_cb().
|
static |
Definition at line 63 of file ins_skeleton.c.
|
static |
Definition at line 62 of file ins_skeleton.c.
|
static |
Definition at line 64 of file ins_skeleton.c.
| struct InsModuleInt ins_module |
global INS state
Definition at line 67 of file ins_skeleton.c.
Referenced by gps_cb(), ins_module_propagate(), ins_module_update_gps(), ins_module_wrapper_init(), ins_ned_to_state(), and reset_cb().
|
static |
Definition at line 65 of file ins_skeleton.c.
 1.15.0