|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
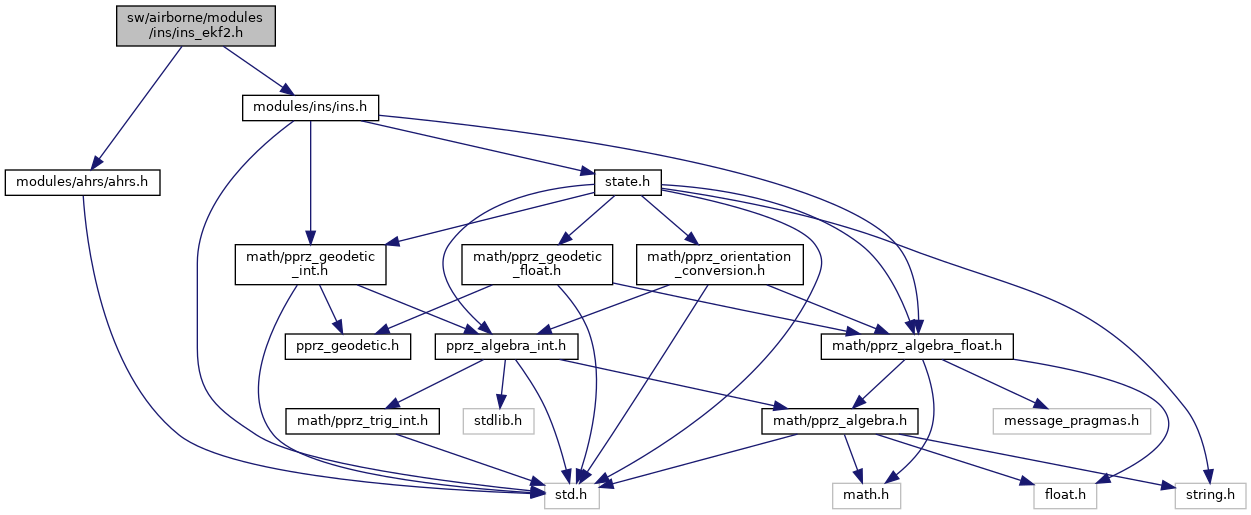
INS based in the EKF2 of PX4. More...
Go to the source code of this file.
Data Structures | |
| struct | ekf2_t |
Functions | |
| void | ins_ekf2_init (void) |
| void | ins_ekf2_update (void) |
| void | ins_ekf2_parse_EXTERNAL_POSE (uint8_t *buf) |
| void | ins_ekf2_parse_EXTERNAL_POSE_SMALL (uint8_t *buf) |
Variables | |
| struct ekf2_t | ekf2 |
| Local EKF2 status structure. | |
| bool | ins_ekf2_events_all |
INS based in the EKF2 of PX4.
Definition in file ins_ekf2.h.
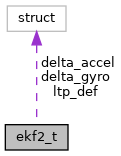
| struct ekf2_t |
Definition at line 40 of file ins_ekf2.h.
| Data Fields | ||
|---|---|---|
| uint32_t | accel_dt | Accelerometer delta timestamp between abi messages (us). |
| struct FloatVect3 | accel_ned | Latest NED acceleration from the EKF (m/s^2). |
| bool | accel_valid | If we received a acceleration measurement. |
| float | air_density | Air density from the barometer (kg/m^3). |
| bool | armed | Armed state last given to the EKF. |
| struct FloatVect3 | delta_accel | Last accelerometer measurements. |
| struct FloatRates | delta_gyro | Last gyroscope measurements. |
| bool | fixed_wing | Fixed wing flight state last given to the EKF. |
| uint32_t | flow_stamp | Optic flow last abi message timestamp. |
| bool | got_imu_data | If we received valid IMU data (any sensor). |
| uint32_t | gyro_dt | Gyroscope delta timestamp between abi messages (us). |
| bool | gyro_valid | If we received a gyroscope measurement. |
| bool | in_air | In-air state last given to the EKF. |
| struct LtpDef_i | ltp_def | Latest LTP definition from the quat_reset_counter EKF2. |
| uint64_t | ltp_stamp | Last LTP change timestamp from the EKF2. |
| float | mag_scale | Field strength the normalized magnetometer is scaled to without calibration strength (gauss). |
| uint8_t | quat_reset_counter | Amount of quaternion resets from the EKF2. |
| uint64_t | system_flags_time | Last time the system flags were given to the EKF (us). |
| float | temp | Latest temperature measurement in degrees celcius. |
|
extern |
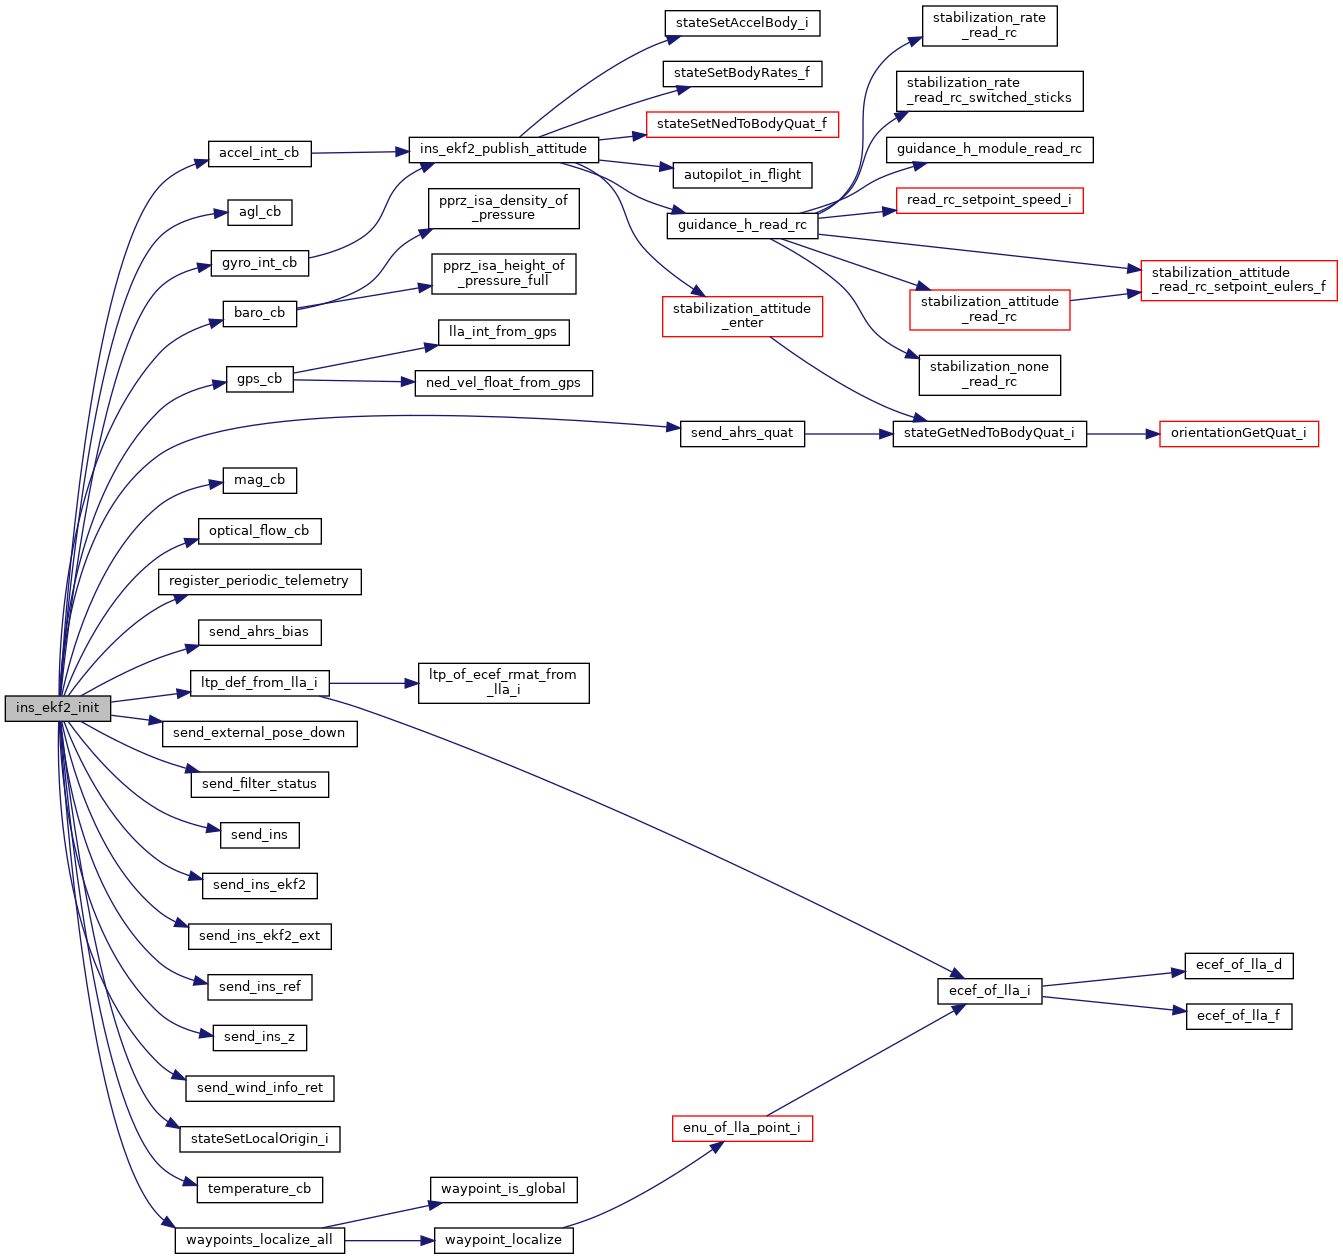
Definition at line 1127 of file ins_ekf2.cpp.
References ABI_BROADCAST, accel_int_cb(), accel_int_ev, agl_cb(), agl_ev, airspeed_cb(), airspeed_ev, LlaCoor_i::alt, baro_cb(), baro_ev, DefaultPeriodic, ekf, ekf2, ekf2_log_origin_set, ekf2_time_us(), ekf_params, FLOAT_VECT3_ZERO, get_sys_time_usec(), gnss_checks, gps_cb(), gps_ev, gyro_int_cb(), gyro_int_ev, INS_EKF2_ACCEL_ID, INS_EKF2_AGL_ID, INS_EKF2_AIRSPEED_ID, INS_EKF2_BARO_ID, INS_EKF2_GNSS_CHECK, INS_EKF2_GNSS_REQ_EPH, INS_EKF2_GNSS_REQ_SACC, INS_EKF2_GPS_DELAY, INS_EKF2_GPS_ID, INS_EKF2_GYRO_ID, INS_EKF2_MAG_ID, INS_EKF2_OF_ID, INS_EKF2_OF_MAX_RATE, INS_EKF2_RELPOS_ID, INS_EKF2_RNG_MAX_DIST, INS_EKF2_RNG_MIN_DIST, INS_EKF2_TEMPERATURE_ID, LlaCoor_i::lat, LlaCoor_i::lon, ltp_def_from_lla_i(), mag_cb(), mag_ev, optical_flow_cb(), optical_flow_ev, PPRZ_ISA_AIR_DENSITY, preflight_check_register(), register_periodic_telemetry(), relpos_cb(), relpos_ev, reset_cb(), reset_ev, sample_ev, send_ahrs_bias(), send_ahrs_quat(), send_external_pose_down(), send_filter_status(), send_ins(), send_ins_ekf2(), send_ins_ekf2_ext(), send_ins_ref(), send_ins_z(), send_wind_info_ret(), stateSetLocalOrigin_i(), temperature_cb(), temperature_ev, and waypoints_localize_all().
|
extern |
Definition at line 1543 of file ins_ekf2.cpp.
References ekf, EKF2_IN_EV, ekf2_input_enabled(), ekf2_log, ekf2_time_us(), float_quat_comp(), get_sys_time_usec(), FloatQuat::qi, FloatQuat::qx, FloatQuat::qy, FloatQuat::qz, and sample_ev.
|
extern |
Definition at line 1593 of file ins_ekf2.cpp.
|
extern |
Definition at line 1436 of file ins_ekf2.cpp.
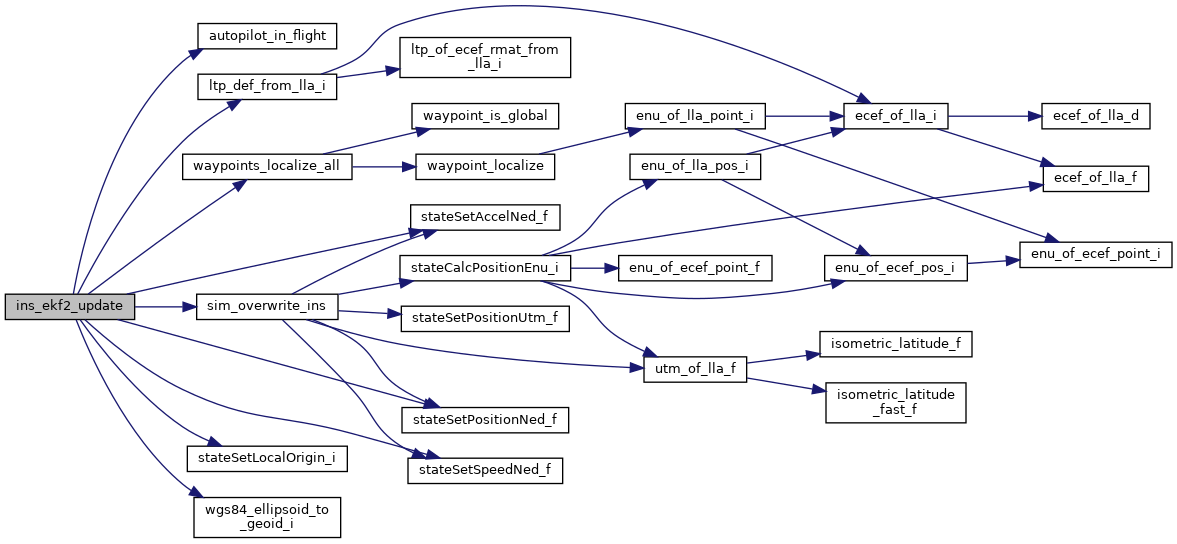
References LlaCoor_i::alt, ekf, ekf2, EKF2_IN_UPDATE, ekf2_input_enabled(), ekf2_log, ekf2_log_check_start, ekf2_log_origin_set, ekf2_log_output, ekf2_time_us(), get_sys_time_usec(), ins_ekf2_airspeed_update(), ins_ekf2_check_events, ins_ekf2_preflight_filter, ins_ekf2_update_system_flags(), LlaCoor_i::lat, LlaCoor_i::lon, ltp_def_from_lla_i(), nps_bypass_ins, sim_overwrite_ins(), stateSetAccelNed_f(), stateSetLocalOrigin_i(), stateSetPositionNed_f(), stateSetSpeedNed_f(), waypoints_localize_all(), wgs84_ellipsoid_to_geoid_i(), NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
|
extern |
Local EKF2 status structure.
Definition at line 379 of file ins_ekf2.cpp.
Referenced by accel_int_cb(), baro_cb(), gps_cb(), gyro_int_cb(), ins_ekf2_airspeed_update(), ins_ekf2_init(), ins_ekf2_publish_attitude(), ins_ekf2_update(), ins_ekf2_update_system_flags(), mag_cb(), optical_flow_cb(), reset_ref(), reset_vertical_ref(), send_ins(), send_ins_ref(), send_ins_z(), and temperature_cb().
|
extern |
Definition at line 823 of file ins_ekf2.cpp.
 1.15.0