|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "uavcan.h"#include "mcu_periph/can.h"#include "modules/core/threads.h"#include "uavcan.protocol.NodeStatus.h"#include "uavcan_reporting.h"#include "mcu_periph/sys_time.h"#include "modules/uavcan/uavcan_allocator.h"Go to the source code of this file.
Macros | |
| #define | UAVCAN_NODE_ID 100 |
| #define | UAVCAN_BAUDRATE 1000000 |
Functions | |
| static void | can_frame_cb (struct pprzcan_frame *rx_msg, UNUSED struct pprzaddr_can *src_addr, void *user_data) |
| Called in the CAN receive thread: only queue the frame. | |
| static void | uavcan_handle_rx (struct uavcan_iface_t *iface) |
| Let canard handle the queued frames of an interface, in the main thread. | |
| static void | uavcan_tx (void *p) |
| static void | onTransferReceived (CanardInstance *ins, CanardRxTransfer *transfer) |
| Whenever a valid and 'accepted' transfer is received. | |
| static bool | shouldAcceptTransfer (const CanardInstance *ins, uint64_t *out_data_type_signature, uint16_t data_type_id, CanardTransferType transfer_type, uint8_t source_node_id) |
| If we should accept this transfer. | |
| static void | uavcanInitIface (struct uavcan_iface_t *iface) |
| Initialize uavcan interface. | |
| void | uavcan_rx_event (void) |
| Handle the received frames of all interfaces (main thread). | |
| void | uavcan_init (void) |
| Initialize all uavcan interfaces. | |
| void | uavcan_bind (uint16_t data_type_id, uint64_t data_type_signature, uavcan_event *ev, uavcan_callback cb) |
| Bind to a receiving message from uavcan. | |
| static uint8_t * | get_transfer_id (struct uavcan_iface_t *iface, uint8_t destination_node_id, CanardTxTransfer *transfer) |
| void | uavcan_transfer (struct uavcan_iface_t *iface, CanardTxTransfer *transfer) |
| void | uavcan_request (struct uavcan_iface_t *iface, uint8_t destination_node_id, CanardTxTransfer *transfer) |
| void | uavcan_broadcast (struct uavcan_iface_t *iface, uint64_t data_type_signature, uint16_t data_type_id, uint8_t priority, const void *payload, uint16_t payload_len) |
| Legacy function Broadcast an uavcan message to a specific interface. | |
| void | uavcan_response (struct uavcan_iface_t *iface, uint8_t destination_node_id, CanardTxTransfer *transfer) |
Variables | |
| static uavcan_event * | uavcan_event_hd = NULL |
|
static |
Called in the CAN receive thread: only queue the frame.
The transfers and the callbacks of the modules (which send ABI messages) are handled in the main thread by uavcan_rx_event().
Definition at line 85 of file uavcan.c.
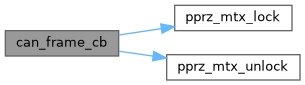
References CAN_EID_MASK, CAN_FRAME_EFF, pprzcan_frame::can_id, CAN_SID_MASK, pprzcan_frame::data, uavcan_rx_frame::frame, framed_ring_buffer_put(), pprzcan_frame::len, uavcan_iface_t::rx_overflows, uavcan_iface_t::rx_queue, pprzcan_frame::timestamp, uavcan_rx_frame::timestamp, and UNUSED.
Referenced by uavcanInitIface().
|
static |
Definition at line 284 of file uavcan.c.
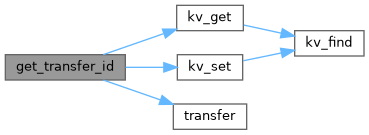
References kv_get(), kv_set(), uavcan_iface_t::node_id, transfer(), and uavcan_iface_t::transfer_ids_store.
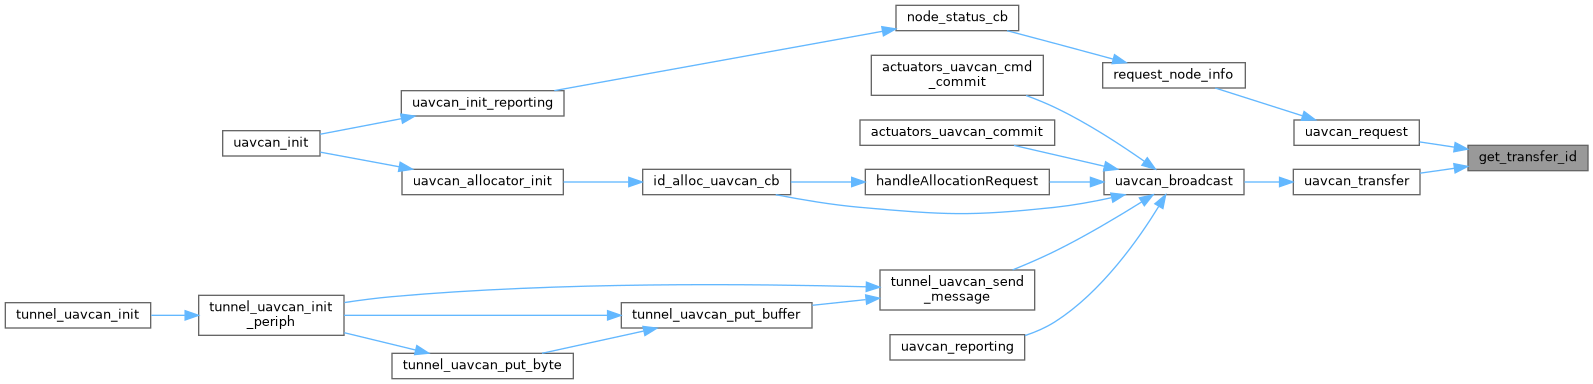
Referenced by uavcan_request(), and uavcan_transfer().
|
static |
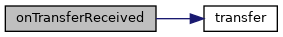
Whenever a valid and 'accepted' transfer is received.
Definition at line 159 of file uavcan.c.
References ev, transfer(), and uavcan_event_hd.
Referenced by uavcanInitIface().
|
static |
If we should accept this transfer.
Definition at line 173 of file uavcan.c.
References ev, and uavcan_event_hd.
Referenced by uavcanInitIface().
| void uavcan_bind | ( | uint16_t | data_type_id, |
| uint64_t | data_type_signature, | ||
| uavcan_event * | ev, | ||
| uavcan_callback | cb ) |
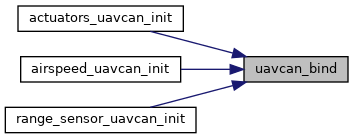
Bind to a receiving message from uavcan.
Definition at line 272 of file uavcan.c.
References ev, and uavcan_event_hd.
Referenced by actuators_uavcan_init(), airspeed_uavcan_init(), can_fuelcell_init(), gps_uavcan_init(), mag_uavcan_init(), power_uavcan_init(), range_sensor_uavcan_init(), rc_uavcan_init(), scout_detector_init(), tunnel_uavcan_init_periph(), uavcan_allocator_init(), and uavcan_init_reporting().
| void uavcan_broadcast | ( | struct uavcan_iface_t * | iface, |
| uint64_t | data_type_signature, | ||
| uint16_t | data_type_id, | ||
| uint8_t | priority, | ||
| const void * | payload, | ||
| uint16_t | payload_len ) |
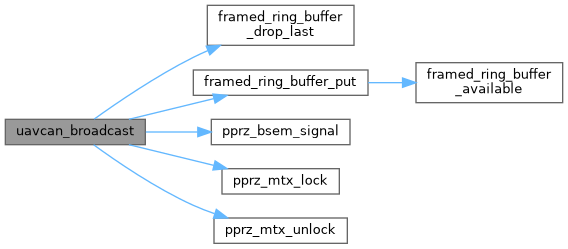
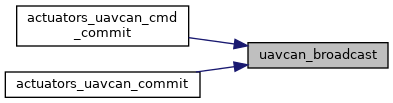
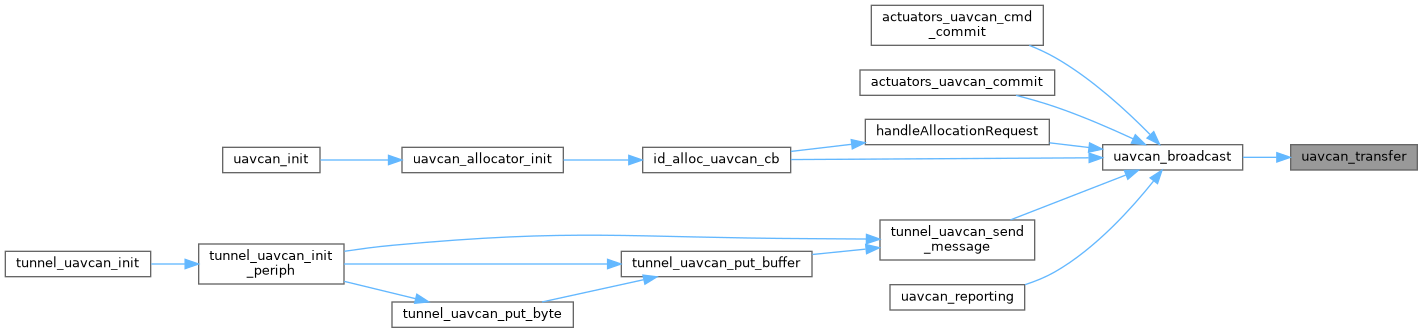
Legacy function Broadcast an uavcan message to a specific interface.
Definition at line 345 of file uavcan.c.
References transfer(), and uavcan_transfer().
Referenced by actuators_uavcan_cmd_commit(), actuators_uavcan_commit(), handleAllocationRequest(), id_alloc_uavcan_cb(), tunnel_uavcan_send_message(), and uavcan_reporting().
|
static |
Let canard handle the queued frames of an interface, in the main thread.
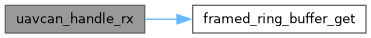
Definition at line 104 of file uavcan.c.
References uavcan_iface_t::canard, uavcan_rx_frame::frame, framed_ring_buffer_get(), uavcan_iface_t::initialized, uavcan_iface_t::rx_queue, and uavcan_rx_frame::timestamp.
Referenced by uavcan_rx_event().
| void uavcan_init | ( | void | ) |
Initialize all uavcan interfaces.
uavcan interfaces
Definition at line 257 of file uavcan.c.
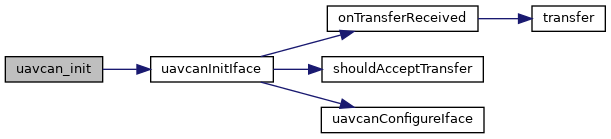
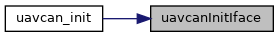
References uavcan_allocator_init(), uavcan_init_reporting(), and uavcanInitIface().
| void uavcan_request | ( | struct uavcan_iface_t * | iface, |
| uint8_t | destination_node_id, | ||
| CanardTxTransfer * | transfer ) |
| transfer | should be initialized with canardInitTxTransfer. |
Definition at line 321 of file uavcan.c.
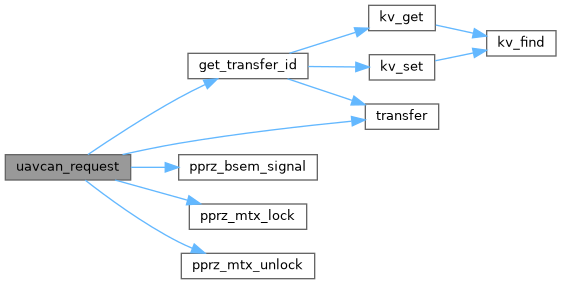
References uavcan_iface_t::bsem, uavcan_iface_t::canard, get_transfer_id(), uavcan_iface_t::initialized, uavcan_iface_t::nb_errors, pprz_bsem_signal(), pprz_mtx_lock(), pprz_mtx_unlock(), transfer(), and uavcan_iface_t::tx_mutex.
Referenced by request_node_info().
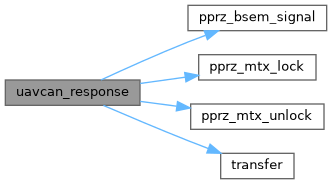
| void uavcan_response | ( | struct uavcan_iface_t * | iface, |
| uint8_t | destination_node_id, | ||
| CanardTxTransfer * | transfer ) |
| inout_transfer_id | should be set to the request transfer id before calling this function |
Definition at line 364 of file uavcan.c.
References uavcan_iface_t::bsem, uavcan_iface_t::canard, uavcan_iface_t::initialized, pprz_bsem_signal(), pprz_mtx_lock(), pprz_mtx_unlock(), transfer(), and uavcan_iface_t::tx_mutex.
Referenced by node_info_cb().
| void uavcan_rx_event | ( | void | ) |
Handle the received frames of all interfaces (main thread).
Definition at line 244 of file uavcan.c.
References uavcan_handle_rx().
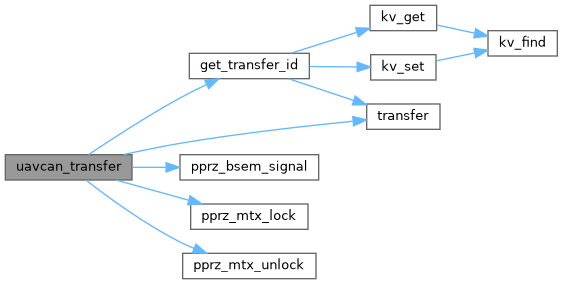
| void uavcan_transfer | ( | struct uavcan_iface_t * | iface, |
| CanardTxTransfer * | transfer ) |
| transfer | should be initialized with canardInitTxTransfer. |
Definition at line 300 of file uavcan.c.
References uavcan_iface_t::bsem, uavcan_iface_t::canard, get_transfer_id(), uavcan_iface_t::initialized, uavcan_iface_t::nb_errors, pprz_bsem_signal(), pprz_mtx_lock(), pprz_mtx_unlock(), transfer(), and uavcan_iface_t::tx_mutex.
Referenced by uavcan_broadcast().
|
static |
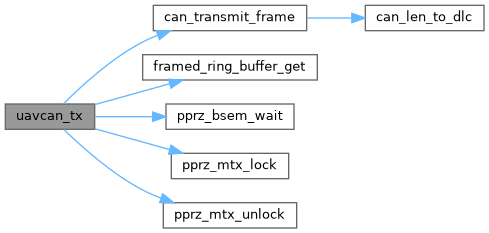
Definition at line 118 of file uavcan.c.
References uavcan_iface_t::bsem, CAN_FRAME_EFF, pprzcan_frame::can_id, uavcan_iface_t::can_net, can_transmit_frame(), uavcan_iface_t::canard, pprzcan_frame::data, pprzcan_frame::len, p, pprz_bsem_wait(), pprz_mtx_lock(), pprz_mtx_unlock(), sys_time_msleep(), and uavcan_iface_t::tx_mutex.
Referenced by uavcanInitIface().
|
static |
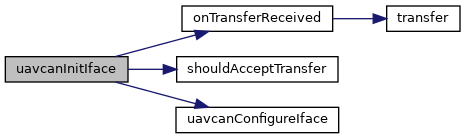
Initialize uavcan interface.
Definition at line 210 of file uavcan.c.
References uavcan_iface_t::bsem, can_frame_cb(), uavcan_iface_t::can_net, can_register_callback(), uavcan_iface_t::canard, uavcan_iface_t::canard_memory_pool, framed_ring_buffer_init(), uavcan_iface_t::initialized, kv_init(), uavcan_iface_t::node_id, onTransferReceived(), pprz_bsem_init(), pprz_mtx_init(), PPRZ_NORMAL_PRIO, pprz_thread_create(), uavcan_iface_t::rx_queue, uavcan_iface_t::rx_queue_buf, shouldAcceptTransfer(), uavcan_iface_t::thread_tx, uavcan_iface_t::transfer_ids_keys, uavcan_iface_t::transfer_ids_store, uavcan_iface_t::transfer_ids_used, uavcan_iface_t::transfer_ids_values, uavcan_iface_t::tx_mutex, UAVCAN_TID_STORE_CAPACITY, and uavcan_tx().
Referenced by uavcan_init().
|
static |
Definition at line 43 of file uavcan.c.
Referenced by onTransferReceived(), shouldAcceptTransfer(), and uavcan_bind().
 1.15.0