|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Xsens as a full INS solution. More...
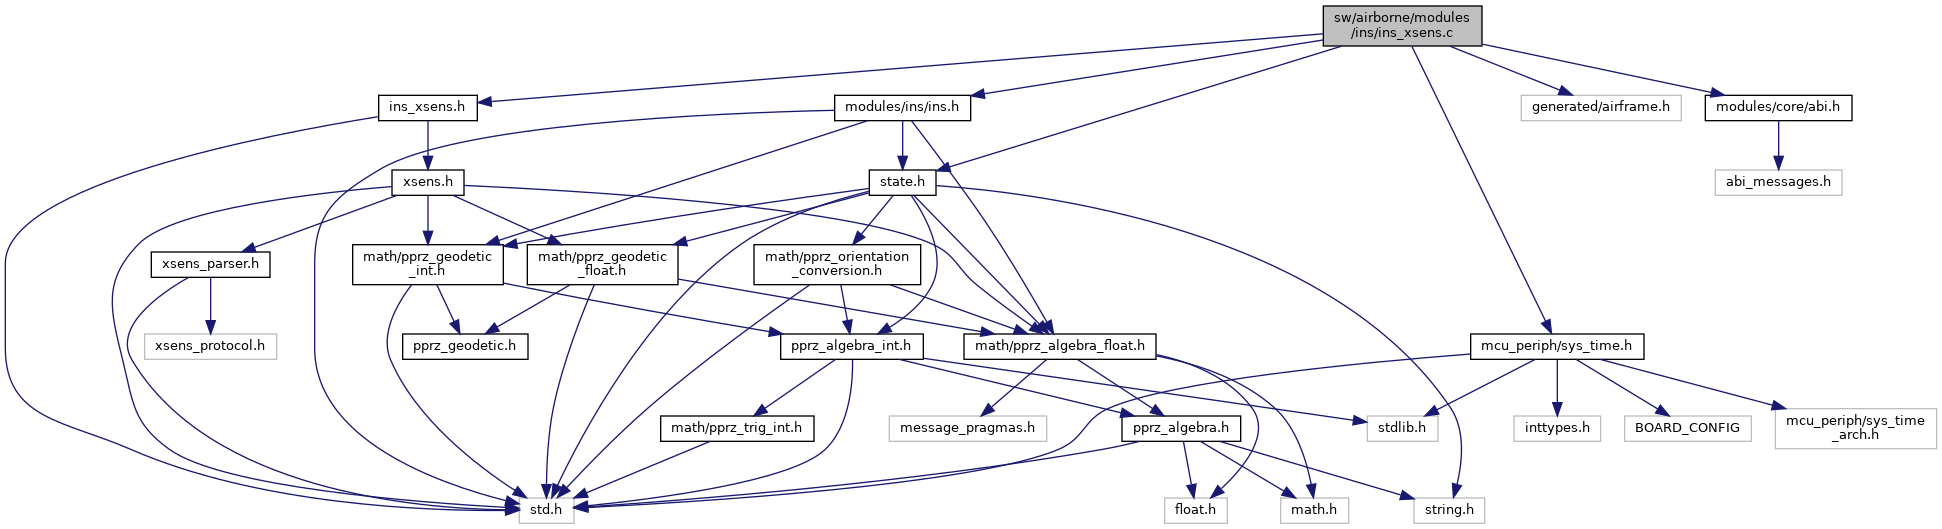
#include "ins_xsens.h"#include "modules/ins/ins.h"#include "generated/airframe.h"#include "generated/modules.h"#include "mcu_periph/sys_time.h"#include "modules/core/abi.h"#include "state.h"Go to the source code of this file.
Macros | |
| #define | INS_XSENS_GPS_ID GPS_MULTI_ID |
| ABI binding for gps data. | |
Functions | |
| static void | handle_ins_msg (void) |
| static void | update_state_interface (void) |
| static void | gps_cb (uint8_t sender_id, uint32_t stamp, struct GpsState *gps_s) |
| void | ins_xsens_init (void) |
| void | ins_xsens_event (void) |
Variables | |
| static abi_event | gps_ev |
| float | ins_pitch_neutral |
| float | ins_roll_neutral |
Xsens as a full INS solution.
Definition in file ins_xsens.c.
| #define INS_XSENS_GPS_ID GPS_MULTI_ID |
ABI binding for gps data.
Used for GPS ABI messages.
Definition at line 50 of file ins_xsens.c.
Referenced by ins_xsens_init().
Definition at line 88 of file ins_xsens.c.
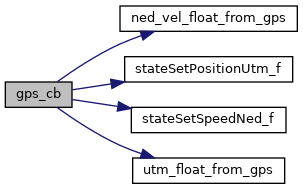
References UtmCoor_f::alt, GpsState::hmsl, nav_utm_zone0, ned_vel_float_from_gps(), stateSetPositionUtm_f(), stateSetSpeedNed_f(), and utm_float_from_gps().
|
static |
Definition at line 151 of file ins_xsens.c.
Referenced by ins_xsens_event().
| void ins_xsens_event | ( | void | ) |
Definition at line 78 of file ins_xsens.c.
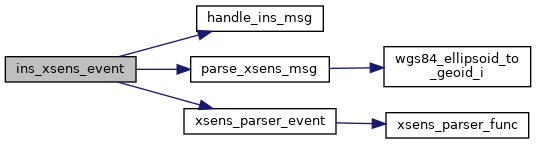
References FALSE, handle_ins_msg(), parse_xsens_msg(), xsens, and xsens_parser_event().
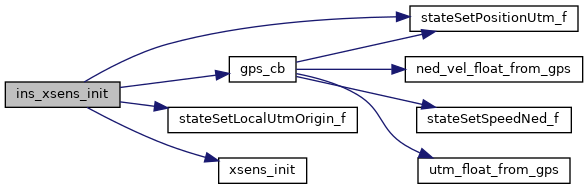
| void ins_xsens_init | ( | void | ) |
Definition at line 64 of file ins_xsens.c.
References gps_cb(), gps_ev, ins_pitch_neutral, INS_PITCH_NEUTRAL_DEFAULT, ins_roll_neutral, INS_ROLL_NEUTRAL_DEFAULT, INS_XSENS_GPS_ID, ins_xsens_init(), nav_utm_east0, nav_utm_north0, nav_utm_zone0, stateSetLocalUtmOrigin_f(), stateSetPositionUtm_f(), and xsens_init().
Referenced by ins_xsens_init().
|
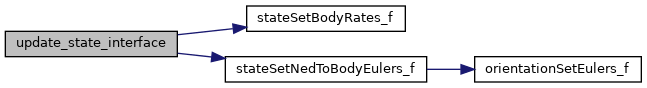
static |
Definition at line 124 of file ins_xsens.c.
References ins_pitch_neutral, ins_roll_neutral, stateSetBodyRates_f(), stateSetNedToBodyEulers_f(), and xsens.
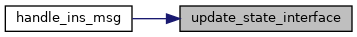
Referenced by handle_ins_msg().
|
static |
Definition at line 53 of file ins_xsens.c.
| float ins_pitch_neutral |
Definition at line 55 of file ins_xsens.c.
| float ins_roll_neutral |
Definition at line 56 of file ins_xsens.c.
 1.15.0