|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Calculate velocity from optic flow. More...
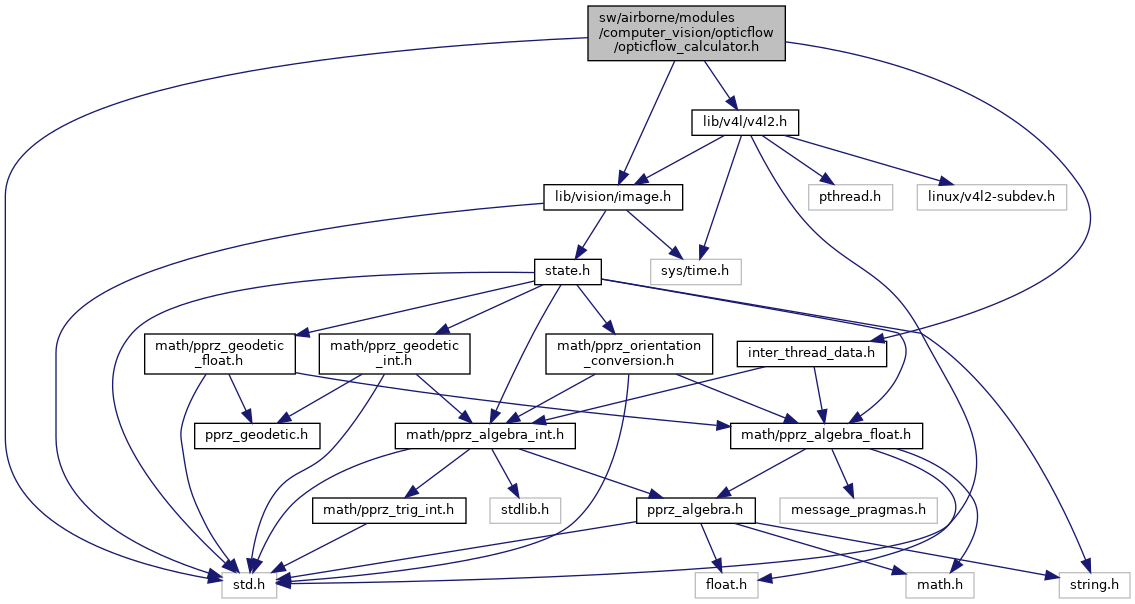
#include "std.h"#include "inter_thread_data.h"#include "lib/vision/image.h"#include "lib/v4l/v4l2.h"Go to the source code of this file.
Data Structures | |
| struct | opticflow_t |
Macros | |
| #define | FAST9_MAX_CORNERS 512 |
Functions | |
| void | opticflow_calc_init (struct opticflow_t opticflow[]) |
| Initialize the opticflow calculator. | |
| bool | opticflow_calc_frame (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow on a new image frame. | |
| bool | calc_fast9_lukas_kanade (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow with fast9 and lukaskanade on a new image frame. | |
| bool | calc_edgeflow_tot (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow with EDGEFLOW on a new image frame. | |
| void | kalman_filter_opticflow_velocity (float *velocity_x, float *velocity_y, float *acceleration_measurement, float fps, float *measurement_noise, float process_noise, bool reinitialize_kalman) |
Calculate velocity from optic flow.
Using images from a vertical camera and IMU sensor data.
Definition in file opticflow_calculator.h.
| struct opticflow_t |
Definition at line 40 of file opticflow_calculator.h.
| Data Fields | ||
|---|---|---|
| int | actfast_gradient_method | Whether to use a simple or Sobel filter. |
| float | actfast_long_step | Step size to take when there is no texture. |
| int | actfast_min_gradient | Threshold that decides when there is sufficient texture for edge following. |
| float | actfast_short_step | Step size to take when there is an edge to be followed. |
| const struct video_config_t * | camera | |
| uint8_t | corner_method | Method to use for determining where the corners are. |
| bool | derotation | Derotation switched on or off (depended on the quality of the gyroscope measurement). |
| float | derotation_correction_factor_x | Correction factor for derotation in x axis, determined from a fit from the gyros and flow rotation. (wrong FOV, camera not in center). |
| float | derotation_correction_factor_y | Correction factor for derotation in Y axis, determined from a fit from the gyros and flow rotation. (wrong FOV, camera not in center). |
| bool | fast9_adaptive | Whether the FAST9 threshold should be adaptive. |
| uint16_t | fast9_min_distance | Minimum distance in pixels between corners. |
| uint8_t | fast9_num_regions | The number of regions of interest the image is split into. |
| uint16_t | fast9_padding | Padding used in FAST9 detector. |
| bool | fast9_region_detect | Decides whether to detect fast9 corners in specific regions of interest or the whole image (only for feature management). |
| struct point_t * | fast9_ret_corners | Corners. |
| uint16_t | fast9_rsize | Amount of corners allocated. |
| uint8_t | fast9_threshold | FAST9 corner detection threshold. |
| bool | feature_management | Decides whether to keep track corners in memory for the next frame instead of re-detecting every time. |
| uint16_t | fps | |
| bool | got_first_img | If we got a image to work with. |
| uint8_t | id | |
| struct image_t | img_gray | Current gray image frame. |
| bool | just_switched_method | Boolean to check if methods has been switched (for reinitialization). |
| uint8_t | max_iterations | The maximum amount of iterations the Lucas Kanade algorithm should do. |
| uint16_t | max_track_corners | Maximum amount of corners Lucas Kanade should track. |
| bool | median_filter | Decides to use a median filter on the velocity. |
| uint8_t | method | Method to use to calculate the optical flow. |
| struct image_t | prev_img_gray | Previous gray image frame. |
| uint8_t | pyramid_level | Number of pyramid levels used in Lucas Kanade algorithm (0 == no pyramids used). |
| uint16_t | resolution_factor | The resolution in EdgeFlow to determine the Divergence. |
| uint16_t | search_distance | Search distance for blockmatching alg. |
| bool | show_flow | Whether to draw the flow vectors on the image. Watch out! This changes the image as will be received by subsequent processing steps. |
| uint16_t | subpixel_factor | The amount of subpixels per pixel. |
| uint8_t | threshold_vec | The threshold in x, y subpixels which the algorithm should stop. |
| bool | track_back | Whether to track flow vectors back to the previous image, in order to check if the back-tracked flow leads to the original corner position. |
| uint16_t | window_size | Window size for the blockmatching algorithm (general value for all methods). |
| #define FAST9_MAX_CORNERS 512 |
Definition at line 88 of file opticflow_calculator.h.
Referenced by opticflow_calc_init().
|
extern |
Run the optical flow with EDGEFLOW on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
| computation | successful |
Definition at line 1017 of file opticflow_calculator.c.
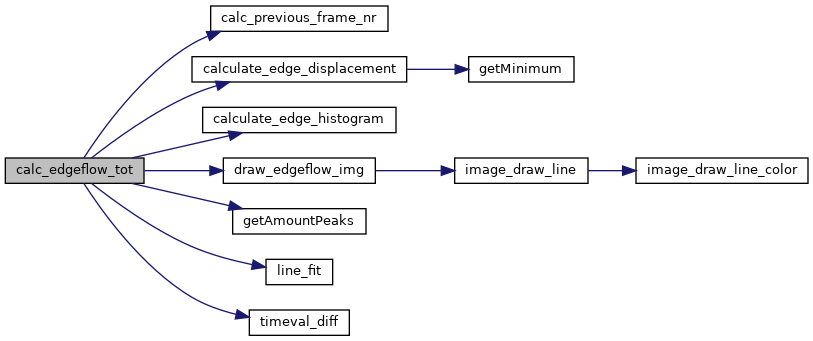
References agl_dist_value_filtered, calc_previous_frame_nr(), calculate_edge_displacement(), calculate_edge_histogram(), opticflow_result_t::camera_id, opticflow_result_t::corner_cnt, DISP_RANGE_MAX, opticflow_result_t::div_size, edge_flow_t::div_x, edge_flow_t::div_y, opticflow_result_t::divergence, draw_edgeflow_img(), edge_hist_t::eulers, image_t::eulers, FLOAT_EULERS_ZERO, opticflow_result_t::flow_der_x, opticflow_result_t::flow_der_y, edge_flow_t::flow_x, opticflow_result_t::flow_x, edge_flow_t::flow_y, opticflow_result_t::flow_y, opticflow_result_t::fps, edge_hist_t::frame_time, getAmountPeaks(), image_t::h, line_fit(), MAX_HORIZON, MAX_WINDOW_SIZE, opticflow_result_t::noise_measurement, opticflow, FloatEulers::phi, RES, opticflow_result_t::surface_roughness, FloatEulers::theta, timeval_diff(), opticflow_result_t::tracked_cnt, image_t::ts, UpdateMedianFilterVect3Float, opticflow_result_t::vel_cam, vel_filt, image_t::w, edge_hist_t::x, edgeflow_displacement_t::x, FloatVect3::x, edge_hist_t::y, edgeflow_displacement_t::y, FloatVect3::y, and FloatVect3::z.
Referenced by opticflow_calc_frame().
|
extern |
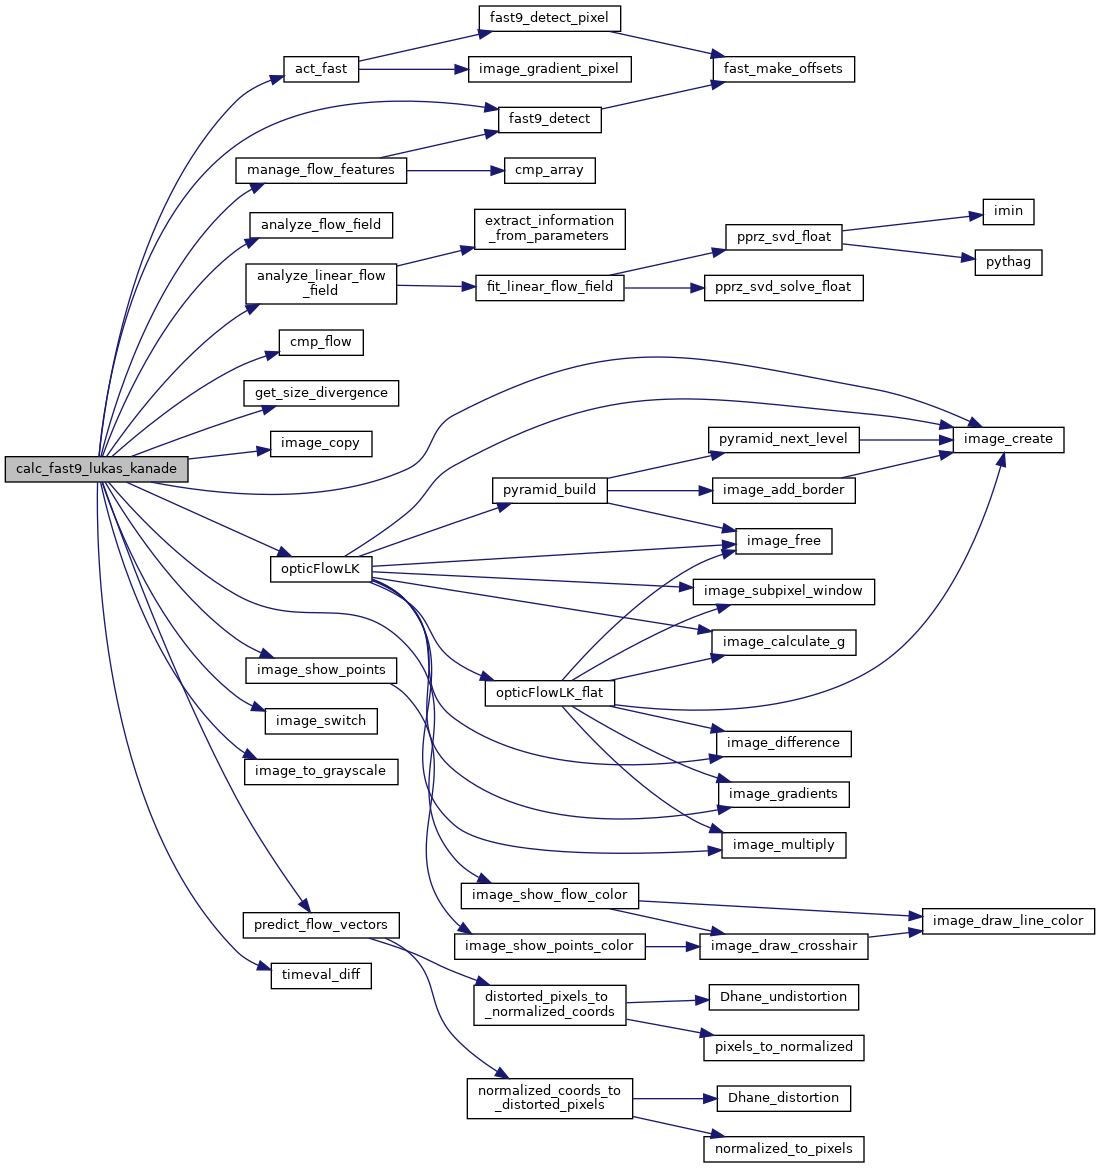
Run the optical flow with fast9 and lukaskanade on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
Definition at line 494 of file opticflow_calculator.c.
References ACT_FAST, act_fast(), agl_dist_value_filtered, analyze_flow_field(), analyze_linear_flow_field(), bottom_camera, opticflow_result_t::camera_id, cmp_flow(), opticflow_result_t::corner_cnt, point_t::count, opticflow_result_t::div_size, linear_flow_fit_info::divergence, opticflow_result_t::divergence, flow_t::error, EXHAUSTIVE_FAST, fast9_detect(), FAST9_HIGH_THRESHOLD, FAST9_LOW_THRESHOLD, opticflow_result_t::flow_der_x, opticflow_result_t::flow_der_y, flow_t::flow_x, opticflow_result_t::flow_x, flow_t::flow_y, opticflow_result_t::flow_y, opticflow_result_t::fps, get_size_divergence(), image_t::h, image_copy(), image_create(), IMAGE_GRAYSCALE, image_show_flow_color(), image_show_points(), image_switch(), image_to_grayscale(), InitMedianFilterVect3Float, LARGE_FLOW_ERROR, LINEAR_FIT, manage_flow_features(), MEDIAN_DEFAULT_SIZE, n_agents, n_samples, n_time_steps, opticflow_result_t::noise_measurement, opticflow, opticFlowLK(), flow_t::pos, predict_flow_vectors(), SIZE_DIV, linear_flow_fit_info::surface_roughness, opticflow_result_t::surface_roughness, timeval_diff(), opticflow_result_t::tracked_cnt, image_t::ts, UpdateMedianFilterVect3Float, VECT3_ASSIGN, opticflow_result_t::vel_body, opticflow_result_t::vel_cam, vel_filt, image_t::w, FloatVect3::x, point_t::x, FloatVect3::y, point_t::y, and FloatVect3::z.
Referenced by opticflow_calc_frame().
|
extern |
|
extern |
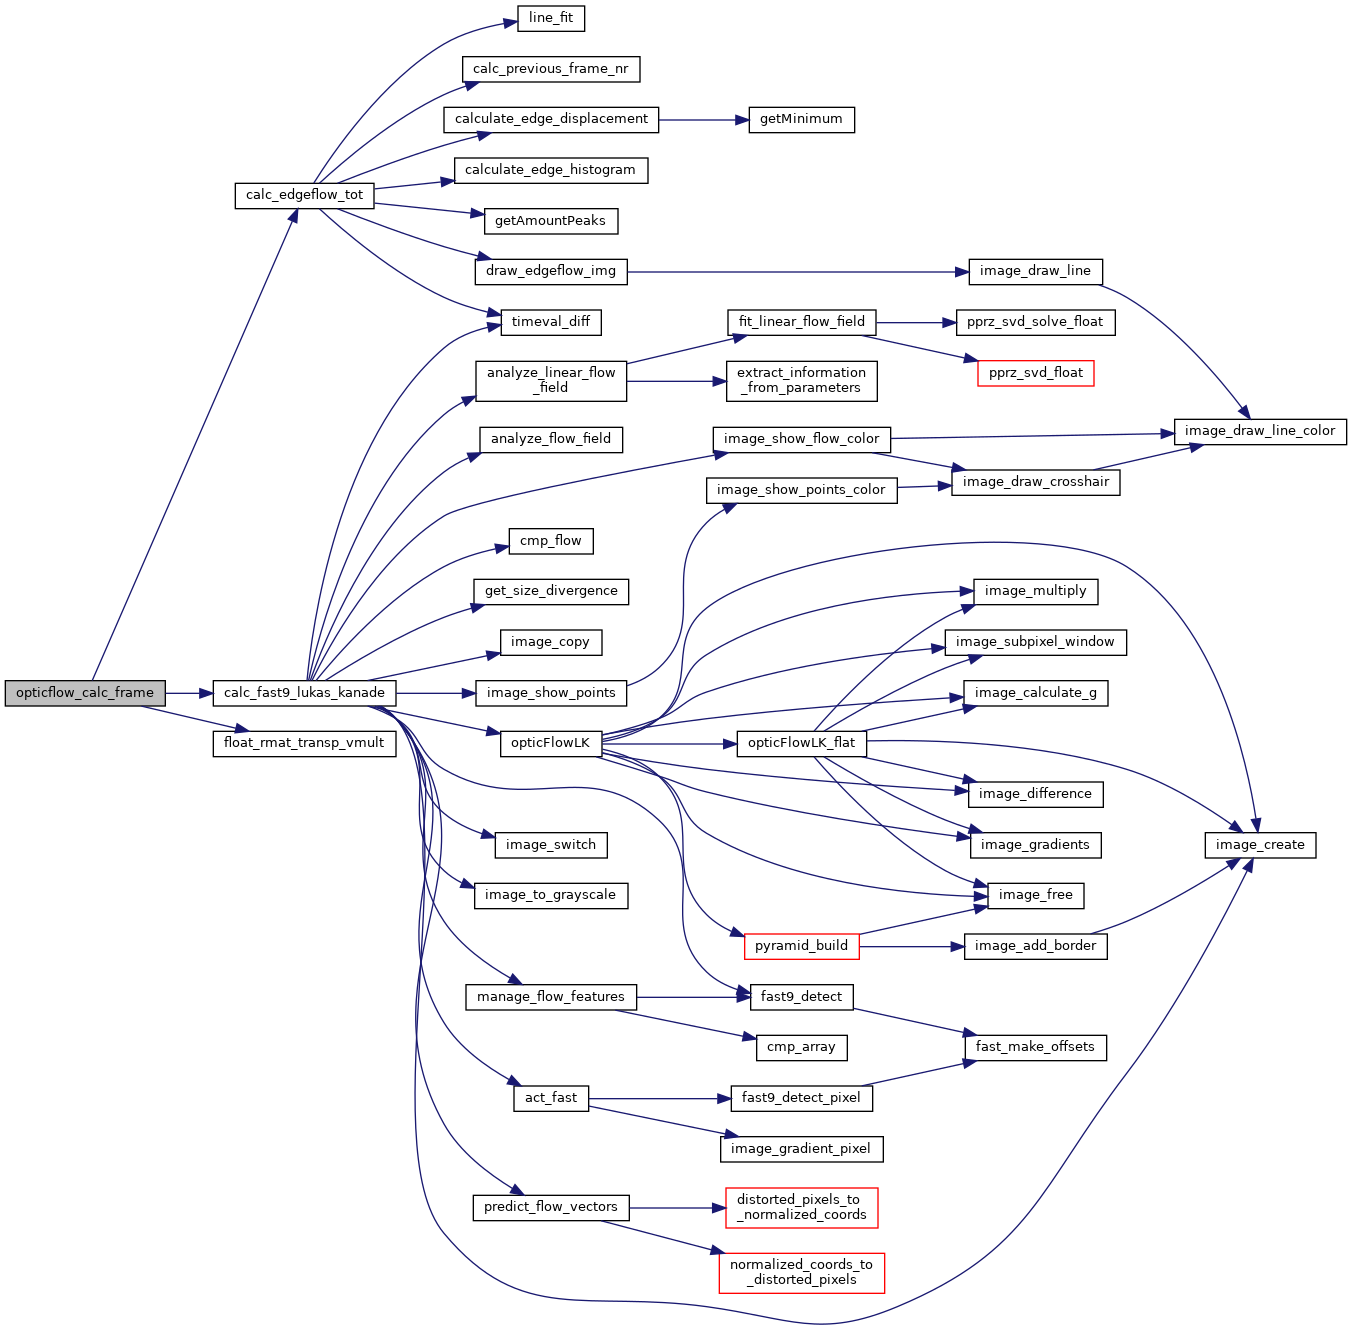
Run the optical flow on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
Definition at line 1181 of file opticflow_calculator.c.
References body_to_cam, calc_edgeflow_tot(), calc_fast9_lukas_kanade(), float_rmat_transp_vmult(), opticflow, opticflow_result_t::vel_body, and opticflow_result_t::vel_cam.
Referenced by opticflow_module_calc().
|
extern |
Initialize the opticflow calculator.
| [out] | *opticflow | The new optical flow calculator |
Definition at line 397 of file opticflow_calculator.c.
References body_to_cam, FAST9_MAX_CORNERS, float_rmat_of_eulers, opticflow, OPTICFLOW_ACTFAST_GRADIENT_METHOD, OPTICFLOW_ACTFAST_GRADIENT_METHOD_CAMERA2, OPTICFLOW_ACTFAST_LONG_STEP, OPTICFLOW_ACTFAST_LONG_STEP_CAMERA2, OPTICFLOW_ACTFAST_MIN_GRADIENT, OPTICFLOW_ACTFAST_MIN_GRADIENT_CAMERA2, OPTICFLOW_ACTFAST_SHORT_STEP, OPTICFLOW_ACTFAST_SHORT_STEP_CAMERA2, OPTICFLOW_BODY_TO_CAM_PHI, OPTICFLOW_BODY_TO_CAM_PHI_CAMERA2, OPTICFLOW_BODY_TO_CAM_PSI, OPTICFLOW_BODY_TO_CAM_PSI_CAMERA2, OPTICFLOW_BODY_TO_CAM_THETA, OPTICFLOW_BODY_TO_CAM_THETA_CAMERA2, OPTICFLOW_CORNER_METHOD, OPTICFLOW_CORNER_METHOD_CAMERA2, OPTICFLOW_DEROTATION, OPTICFLOW_DEROTATION_CAMERA2, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X_CAMERA2, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y_CAMERA2, OPTICFLOW_FAST9_ADAPTIVE, OPTICFLOW_FAST9_ADAPTIVE_CAMERA2, OPTICFLOW_FAST9_MIN_DISTANCE, OPTICFLOW_FAST9_MIN_DISTANCE_CAMERA2, OPTICFLOW_FAST9_NUM_REGIONS, OPTICFLOW_FAST9_NUM_REGIONS_CAMERA2, OPTICFLOW_FAST9_PADDING, OPTICFLOW_FAST9_PADDING_CAMERA2, OPTICFLOW_FAST9_REGION_DETECT, OPTICFLOW_FAST9_REGION_DETECT_CAMERA2, OPTICFLOW_FAST9_THRESHOLD, OPTICFLOW_FAST9_THRESHOLD_CAMERA2, OPTICFLOW_FEATURE_MANAGEMENT, OPTICFLOW_FEATURE_MANAGEMENT_CAMERA2, OPTICFLOW_MAX_ITERATIONS, OPTICFLOW_MAX_ITERATIONS_CAMERA2, OPTICFLOW_MAX_TRACK_CORNERS, OPTICFLOW_MAX_TRACK_CORNERS_CAMERA2, OPTICFLOW_MEDIAN_FILTER, OPTICFLOW_MEDIAN_FILTER_CAMERA2, OPTICFLOW_METHOD, OPTICFLOW_METHOD_CAMERA2, OPTICFLOW_PYRAMID_LEVEL, OPTICFLOW_PYRAMID_LEVEL_CAMERA2, OPTICFLOW_RESOLUTION_FACTOR, OPTICFLOW_RESOLUTION_FACTOR_CAMERA2, OPTICFLOW_SEARCH_DISTANCE, OPTICFLOW_SEARCH_DISTANCE_CAMERA2, OPTICFLOW_SHOW_FLOW, OPTICFLOW_SHOW_FLOW_CAMERA2, OPTICFLOW_SUBPIXEL_FACTOR, OPTICFLOW_SUBPIXEL_FACTOR_CAMERA2, OPTICFLOW_THRESHOLD_VEC, OPTICFLOW_THRESHOLD_VEC_CAMERA2, OPTICFLOW_TRACK_BACK, OPTICFLOW_TRACK_BACK_CAMERA2, OPTICFLOW_WINDOW_SIZE, and OPTICFLOW_WINDOW_SIZE_CAMERA2.
Referenced by opticflow_module_init().
 1.15.0