|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Inertial Measurement Unit interface. More...
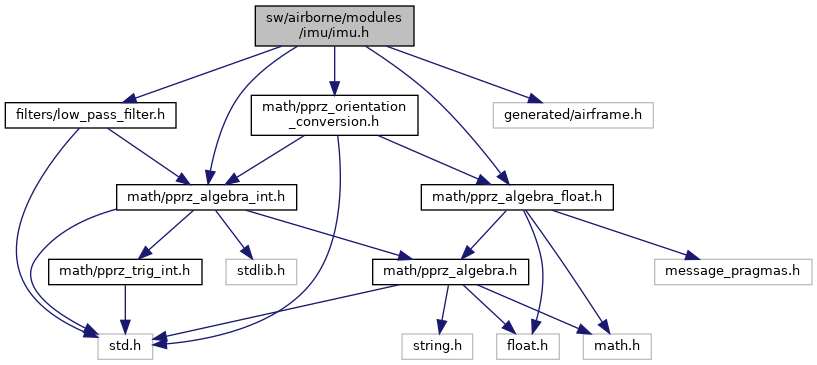
#include "math/pprz_algebra_int.h"#include "math/pprz_algebra_float.h"#include "math/pprz_orientation_conversion.h"#include "filters/low_pass_filter.h"#include "generated/airframe.h"Go to the source code of this file.
Data Structures | |
| struct | imu_calib_t |
| struct | imu_rate_est_t |
| Measured sample rate of a sensor, counted against the timestamps. More... | |
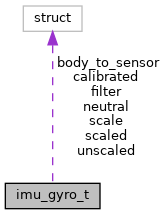
| struct | imu_gyro_t |
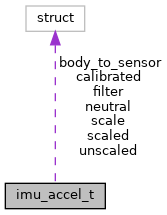
| struct | imu_accel_t |
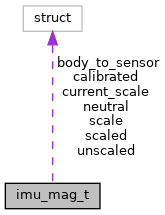
| struct | imu_mag_t |
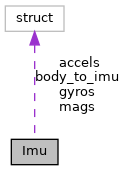
| struct | Imu |
| abstract IMU interface providing fixed point interface More... | |
Macros | |
| #define | IMU_MAX_SENSORS 4 |
Functions | |
| void | imu_init (void) |
| External functions. | |
| void | imu_set_defaults_gyro (uint8_t abi_id, const struct Int32RMat *imu_to_sensor, const struct Int32Rates *neutral, const struct FloatRates *scale_f) |
| Set the defaults for a gyro sensor WARNING: Should be called before sensor is publishing messages to ensure correct values. | |
| void | imu_set_defaults_accel (uint8_t abi_id, const struct Int32RMat *imu_to_sensor, const struct Int32Vect3 *neutral, const struct FloatVect3 *scale_f) |
| Set the defaults for a accel sensor WARNING: Should be called before sensor is publishing messages to ensure correct values. | |
| void | imu_set_defaults_mag (uint8_t abi_id, const struct Int32RMat *imu_to_sensor, const struct Int32Vect3 *neutral, const struct FloatVect3 *scale_f) |
| Set the defaults for a mag sensor WARNING: Should be called before sensor is publishing messages to ensure correct values. | |
| struct imu_gyro_t * | imu_get_gyro (uint8_t sender_id, bool create) |
| Find or create the gyro in the imu structure. | |
| struct imu_accel_t * | imu_get_accel (uint8_t sender_id, bool create) |
| Find or create the accel in the imu structure. | |
| struct imu_mag_t * | imu_get_mag (uint8_t sender_id, bool create) |
| Find or create the mag in the imu structure. | |
| void | imu_SetBodyToImuPhi (float phi) |
| void | imu_SetBodyToImuTheta (float theta) |
| void | imu_SetBodyToImuPsi (float psi) |
| void | imu_SetBodyToImuCurrent (bool set) |
| void | imu_ResetBodyToImu (float reset) |
Variables | |
| struct Imu | imu |
| global IMU state | |
Inertial Measurement Unit interface.
Definition in file imu.h.
| struct imu_calib_t |
| struct imu_rate_est_t |
Measured sample rate of a sensor, counted against the timestamps.
| Data Fields | ||
|---|---|---|
| float | rate | Filtered measured sample rate (Hz), 0 until the first window. |
| bool | rejected | A window was rejected (out of bounds), only warned once. |
| uint32_t | samples | Samples received since the window start. |
| uint32_t | start | Timestamp of the current window start (us). |
| uint16_t | windows | Accepted windows, up to IMU_RATE_EST_REPORT when the rate is reported. |
| struct imu_gyro_t |
| Data Fields | ||
|---|---|---|
| uint8_t | abi_id | ABI sensor ID. |
| struct Int32RMat | body_to_sensor | Rotation from body to sensor frame, set as imu to sensor in the airframe calibration and combined with body_to_imu at init. |
| struct FloatEulers | body_to_sensor_f | Rotation from imu to sensor frame in eulers (airframe calibration, only used at init). |
| struct imu_calib_t | calibrated | Calibration bitmask. |
| Butterworth2LowPass | filter[3] | Lowpass filter optional. |
| float | filter_freq | Lowpass filter cutoff frequency (Hz). |
| struct FloatVect3 | last_delta_alpha | Last integrated sample delta angle in sensor frame for the coning correction (IMU_INTEGRATION). |
| struct FloatVect3 | last_sample | Last scaled sample in sensor frame for the integration (IMU_INTEGRATION). |
| uint32_t | last_stamp | Last measurement timestamp for integration. |
| struct Int32Rates | neutral | Neutral values, compensation on unscaled->scaled. |
| struct imu_rate_est_t | rate_est | Measured sample rate for the integration (IMU_INTEGRATION). |
| float | sample_freq | Calibrated sample frequency (Hz) for the filter, and reference of the measured integration rate (the driver rate if not set). |
| struct Int32Rates | scale[2] | Scaling, first is numerator and second denominator. |
| struct FloatRates | scale_f | Scaling. |
| struct Int32Rates | scaled | Last scaled values in body frame. |
| float | temperature | Temperature in degrees celcius. |
| struct Int32Rates | unscaled | Last unscaled values in sensor frame. |
| struct imu_accel_t |
| Data Fields | ||
|---|---|---|
| uint8_t | abi_id | ABI sensor ID. |
| struct Int32RMat | body_to_sensor | Rotation from body to sensor frame, set as imu to sensor in the airframe calibration and combined with body_to_imu at init. |
| struct FloatEulers | body_to_sensor_f | Rotation from imu to sensor frame in eulers (airframe calibration, only used at init). |
| struct imu_calib_t | calibrated | Calibration bitmask. |
| Butterworth2LowPass | filter[3] | Lowpass filter optional. |
| float | filter_freq | Lowpass filter cutoff frequency (Hz). |
| struct FloatVect3 | last_sample | Last scaled sample in sensor frame for the integration (IMU_INTEGRATION). |
| uint32_t | last_stamp | Last measurement timestamp for integration. |
| struct Int32Vect3 | neutral | Neutral values, compensation on unscaled->scaled. |
| struct imu_rate_est_t | rate_est | Measured sample rate for the integration (IMU_INTEGRATION). |
| float | sample_freq | Calibrated sample frequency (Hz) for the filter, and reference of the measured integration rate (the driver rate if not set). |
| struct Int32Vect3 | scale[2] | Scaling, first is numerator and second denominator. |
| struct FloatVect3 | scale_f | Scaling. |
| struct Int32Vect3 | scaled | Last scaled values in body frame. |
| float | temperature | Temperature in degrees celcius. |
| struct Int32Vect3 | unscaled | Last unscaled values in sensor frame. |
| struct imu_mag_t |
| Data Fields | ||
|---|---|---|
| uint8_t | abi_id | ABI sensor ID. |
| struct Int32RMat | body_to_sensor | Rotation from body to sensor frame, set as imu to sensor in the airframe calibration and combined with body_to_imu at init. |
| struct FloatEulers | body_to_sensor_f | Rotation from imu to sensor frame in eulers (airframe calibration, only used at init). |
| struct imu_calib_t | calibrated | Calibration bitmask. |
| struct FloatVect3 | current_scale | Current scaling multiplying. |
| struct Int32Vect3 | neutral | Neutral values, compensation on unscaled->scaled. |
| struct Int32Vect3 | scale[2] | Scaling, first is numerator and second denominator. |
| struct FloatVect3 | scale_f | Scaling. |
| struct Int32Vect3 | scaled | Last scaled values in body frame. |
| float | strength | Earth field strength where it was calibrated (gauss), the scaled values are 1 there; 0 if unknown. |
| struct Int32Vect3 | unscaled | Last unscaled values in sensor frame. |
| struct Imu |
| Data Fields | ||
|---|---|---|
| uint8_t | accel_abi_send_id | Filter out and send only a specific ABI id in telemetry for the accelerometer. |
| struct imu_accel_t | accels[IMU_MAX_SENSORS] | The accelerometer sensors. |
| bool | b2i_set_current |
flag for adjusting body_to_imu via settings. if FALSE, reset to airframe values, if TRUE set current roll/pitch |
| struct OrientationReps | body_to_imu | Rotation from body to imu (all sensors) frame. |
| uint8_t | gyro_abi_send_id | Filter out and send only a specific ABI id in telemetry for the gyro. |
| struct imu_gyro_t | gyros[IMU_MAX_SENSORS] | The gyro sensors. |
| bool | initialized | Check if the IMU is initialized. |
| uint8_t | mag_abi_send_id | Filter out and send only a specific ABI id in telemetry for the magnetometer. |
| struct imu_mag_t | mags[IMU_MAX_SENSORS] | The magnetometer sensors. |
| #define IMU_MAX_SENSORS 4 |
Definition at line 42 of file imu.h.
Referenced by imu_get_accel(), imu_get_gyro(), imu_get_mag(), imu_init(), imu_set_body_to_imu_eulers(), send_accel(), send_accel_raw(), send_accel_scaled(), send_gyro(), send_gyro_raw(), send_gyro_scaled(), send_mag(), send_mag_current(), send_mag_raw(), and send_mag_scaled().
|
extern |
Find or create the accel in the imu structure.
| sender_id | The ABI sender id to search for |
| create | Create a new index if not found |
Definition at line 1193 of file imu.c.
References ABI_BROADCAST, ABI_DISABLE, imu_accel_t::abi_id, imu, and IMU_MAX_SENSORS.
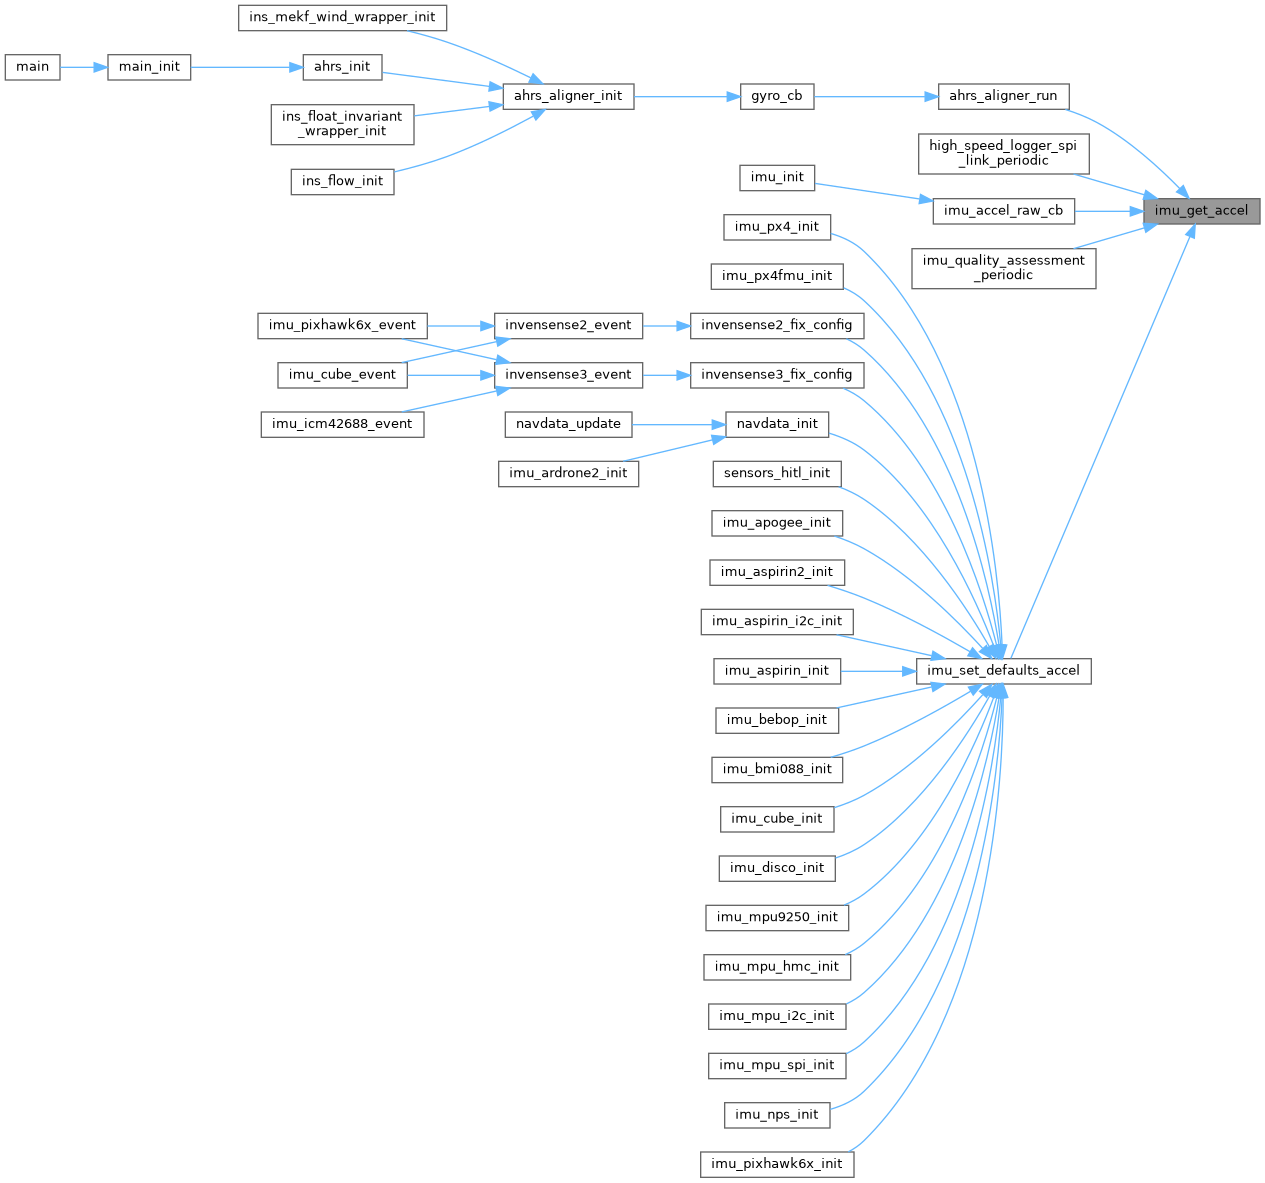
Referenced by ahrs_aligner_run(), imu_accel_raw_cb(), imu_quality_assessment_periodic(), and imu_set_defaults_accel().
|
extern |
Find or create the gyro in the imu structure.
| sender_id | The ABI sender id to search for |
| create | Create a new index if not found |
Definition at line 1170 of file imu.c.
References ABI_BROADCAST, ABI_DISABLE, imu_gyro_t::abi_id, imu, and IMU_MAX_SENSORS.
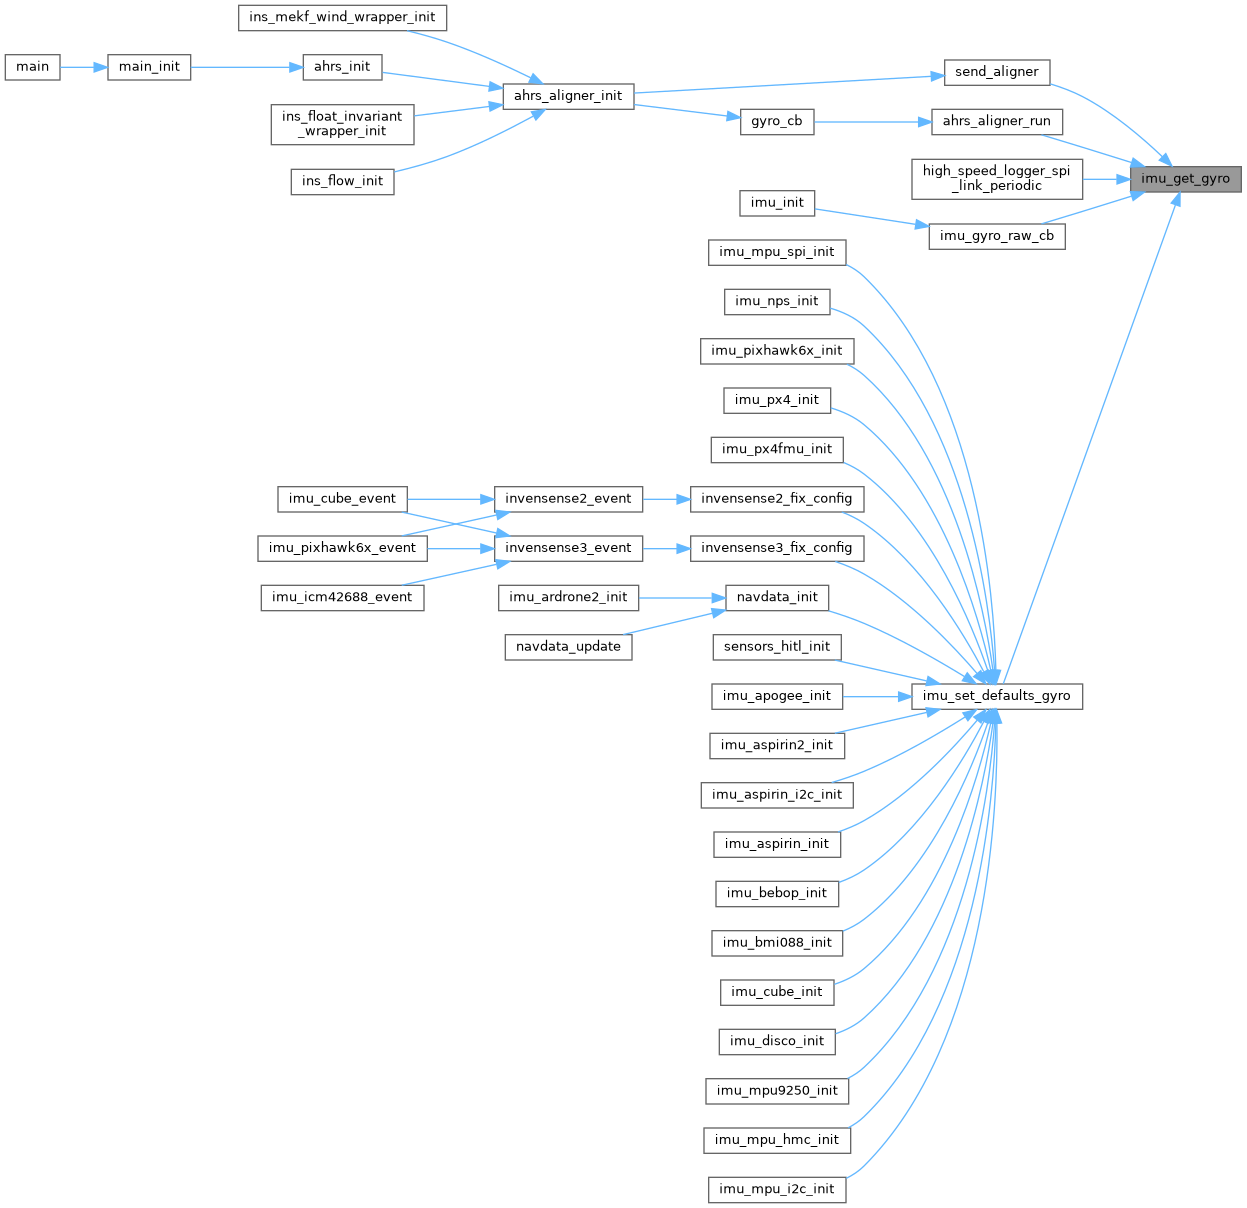
Referenced by ahrs_aligner_run(), imu_gyro_raw_cb(), imu_set_defaults_gyro(), and send_aligner().
Find or create the mag in the imu structure.
| sender_id | The ABI sender id to search for |
| create | Create a new index if not found |
Definition at line 1217 of file imu.c.
References ABI_BROADCAST, ABI_DISABLE, imu_mag_t::abi_id, imu, and IMU_MAX_SENSORS.
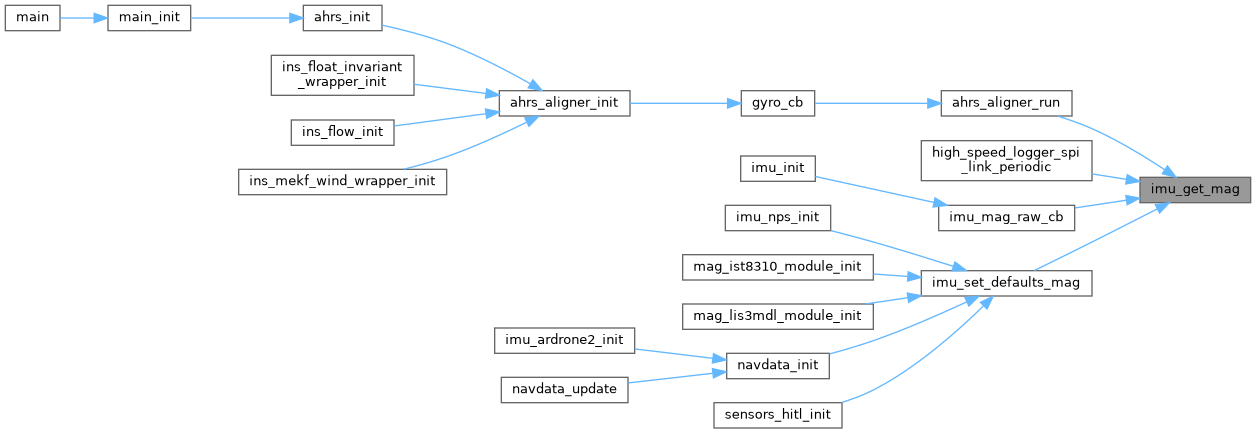
Referenced by ahrs_aligner_run(), imu_mag_raw_cb(), imu_set_defaults_mag(), and mag_cb().
|
extern |
External functions.
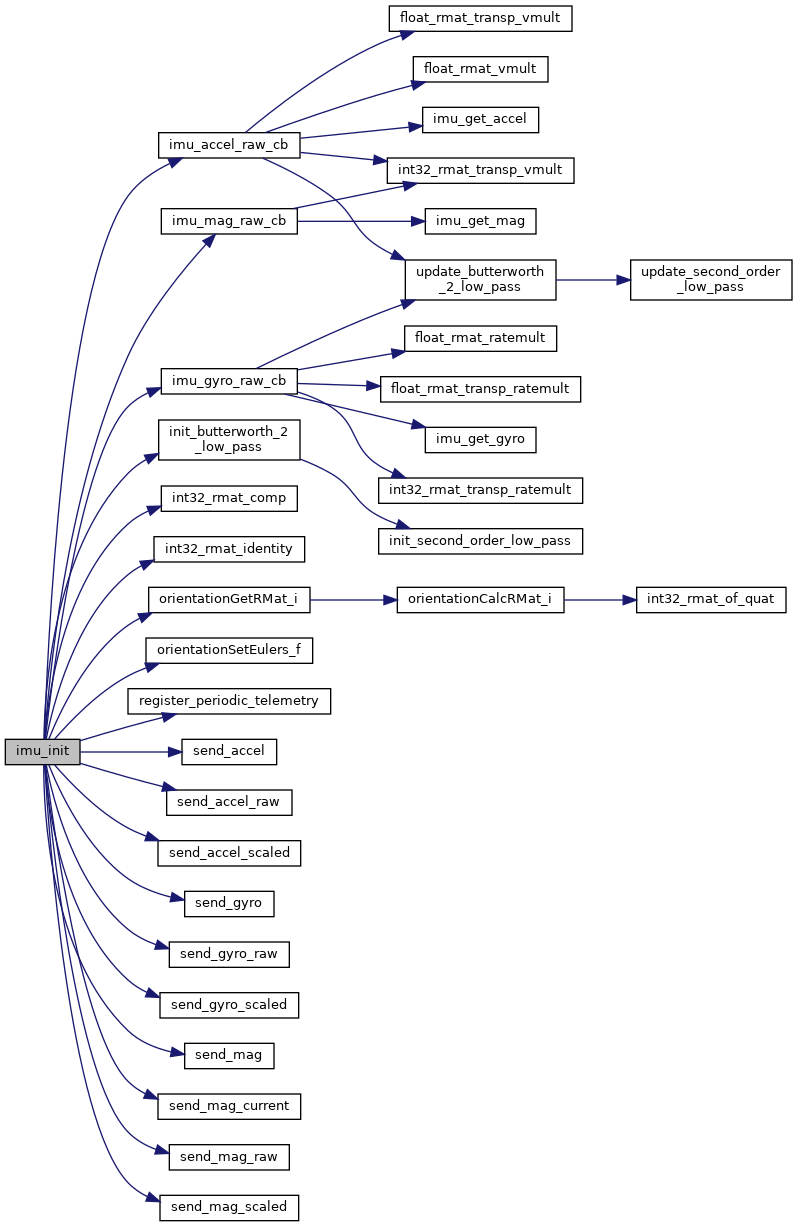
Definition at line 645 of file imu.c.
References ABI_BROADCAST, ABI_DISABLE, DefaultPeriodic, EULERS_BFP_OF_REAL, FLOAT_VECT3_ZERO, imu, IMU_ACCEL_ABI_SEND_ID, IMU_ACCEL_CALIB, imu_accel_raw_cb(), imu_accel_raw_ev, IMU_ACCEL_X_SIGN, IMU_ACCEL_Y_SIGN, IMU_ACCEL_Z_SIGN, IMU_BODY_TO_IMU_PHI, IMU_BODY_TO_IMU_PSI, IMU_BODY_TO_IMU_THETA, IMU_GYRO_ABI_SEND_ID, IMU_GYRO_CALIB, IMU_GYRO_P_SIGN, IMU_GYRO_Q_SIGN, IMU_GYRO_R_SIGN, imu_gyro_raw_cb(), imu_gyro_raw_ev, IMU_MAG_ABI_SEND_ID, IMU_MAG_CALIB, imu_mag_raw_cb(), imu_mag_raw_ev, IMU_MAG_X_SIGN, IMU_MAG_Y_SIGN, IMU_MAG_Z_SIGN, IMU_MAX_SENSORS, int32_rmat_comp(), int32_rmat_identity(), int32_rmat_of_eulers, INT_RATES_ZERO, INT_VECT3_ZERO, mag_calib, orientationGetRMat_i(), orientationSetEulers_f(), preflight_check_register(), RATES_ASSIGN, register_periodic_telemetry(), RMAT_COPY, send_accel(), send_accel_raw(), send_accel_scaled(), send_gyro(), send_gyro_raw(), send_gyro_scaled(), send_mag(), send_mag_current(), send_mag_raw(), send_mag_scaled(), shell_add_entry(), and VECT3_ASSIGN.
|
extern |
References reset.
|
extern |
Set the defaults for a accel sensor WARNING: Should be called before sensor is publishing messages to ensure correct values.
| abi_id | The ABI sender id to set the defaults for |
| imu_to_sensor | Imu to sensor rotation matrix |
| neutral | Neutral values |
| scale_f | Scale values |
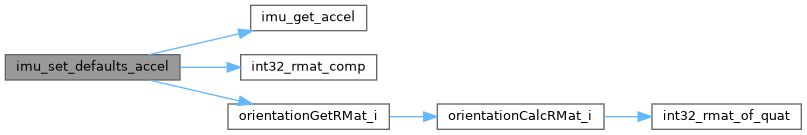
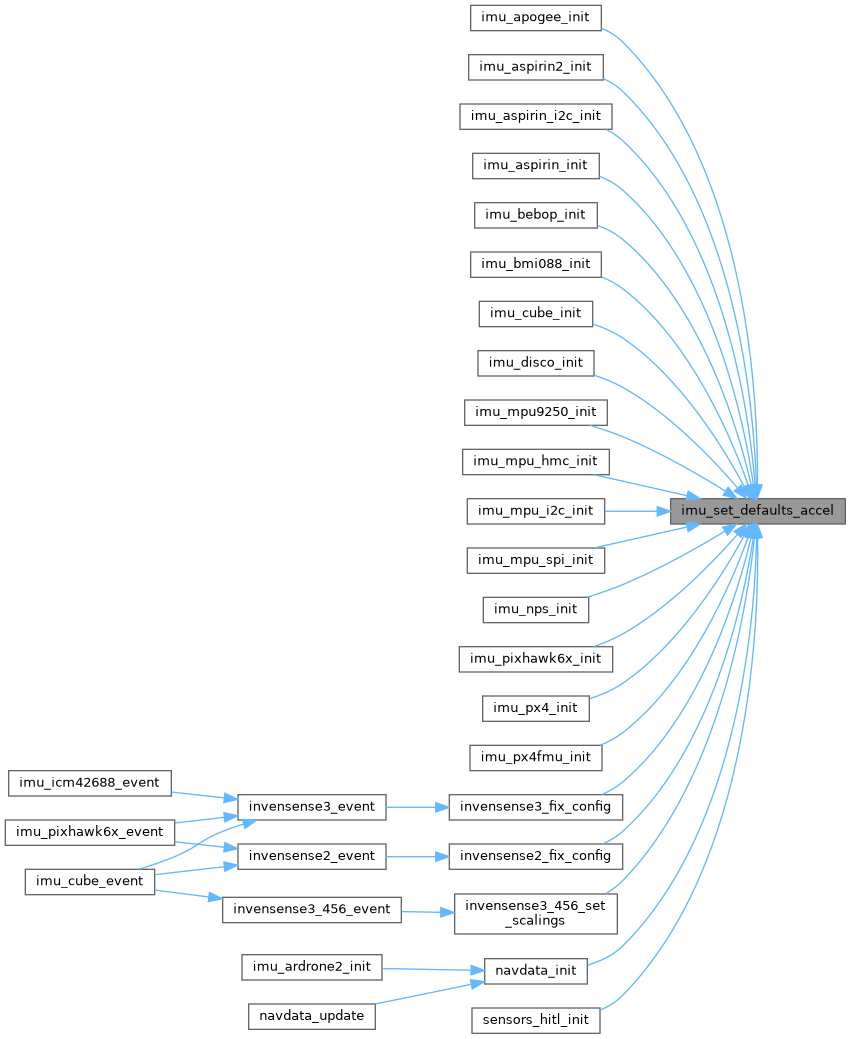
Definition at line 871 of file imu.c.
References imu_accel_t::abi_id, imu_accel_t::body_to_sensor, imu_accel_t::calibrated, imu, IMU_ACCEL_X_SIGN, IMU_ACCEL_Y_SIGN, IMU_ACCEL_Z_SIGN, imu_get_accel(), int32_rmat_comp(), imu_accel_t::neutral, imu_calib_t::neutral, orientationGetRMat_i(), RMAT_COPY, imu_calib_t::rotation, imu_accel_t::scale_f, imu_calib_t::scale_f, VECT3_ASSIGN, VECT3_COPY, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by imu_apogee_init(), imu_aspirin2_init(), imu_aspirin_i2c_init(), imu_aspirin_init(), imu_bebop_init(), imu_bmi088_init(), imu_cube_init(), imu_disco_init(), imu_mpu9250_init(), imu_mpu_hmc_init(), imu_mpu_i2c_init(), imu_mpu_spi_init(), imu_nps_init(), imu_pixhawk6x_init(), imu_px4_init(), imu_px4fmu_init(), invensense2_fix_config(), invensense3_456_set_scalings(), invensense3_fix_config(), and sensors_hitl_init().
|
extern |
Set the defaults for a gyro sensor WARNING: Should be called before sensor is publishing messages to ensure correct values.
| abi_id | The ABI sender id to set the defaults for |
| imu_to_sensor | Imu to sensor rotation matrix |
| neutral | Neutral values |
| scale_f | Scale values |
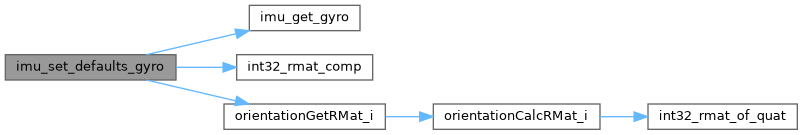
Definition at line 842 of file imu.c.
References imu_gyro_t::abi_id, imu_gyro_t::body_to_sensor, imu_gyro_t::calibrated, imu, imu_get_gyro(), IMU_GYRO_P_SIGN, IMU_GYRO_Q_SIGN, IMU_GYRO_R_SIGN, int32_rmat_comp(), imu_calib_t::neutral, imu_gyro_t::neutral, orientationGetRMat_i(), FloatRates::p, FloatRates::q, FloatRates::r, RATES_ASSIGN, RATES_COPY, RMAT_COPY, imu_calib_t::rotation, imu_calib_t::scale_f, and imu_gyro_t::scale_f.
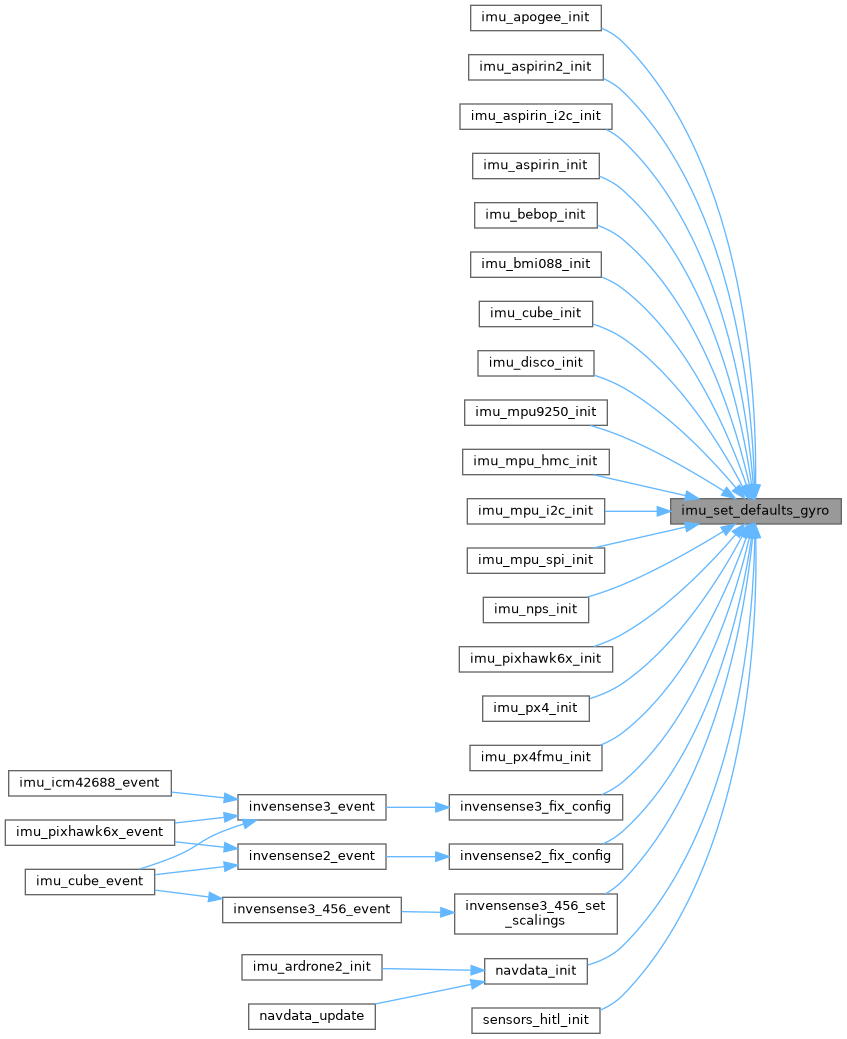
Referenced by imu_apogee_init(), imu_aspirin2_init(), imu_aspirin_i2c_init(), imu_aspirin_init(), imu_bebop_init(), imu_bmi088_init(), imu_cube_init(), imu_disco_init(), imu_mpu9250_init(), imu_mpu_hmc_init(), imu_mpu_i2c_init(), imu_mpu_spi_init(), imu_nps_init(), imu_pixhawk6x_init(), imu_px4_init(), imu_px4fmu_init(), invensense2_fix_config(), invensense3_456_set_scalings(), invensense3_fix_config(), and sensors_hitl_init().
|
extern |
Set the defaults for a mag sensor WARNING: Should be called before sensor is publishing messages to ensure correct values.
| abi_id | The ABI sender id to set the defaults for |
| imu_to_sensor | Imu to sensor rotation matrix |
| neutral | Neutral values |
| scale_f | Scale values |
Definition at line 900 of file imu.c.
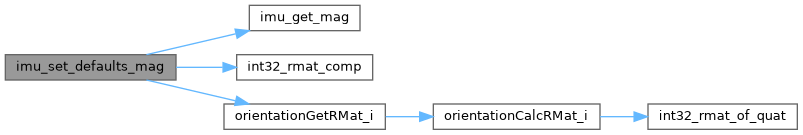
References imu_mag_t::abi_id, imu_mag_t::body_to_sensor, imu_mag_t::calibrated, imu, imu_get_mag(), IMU_MAG_X_SIGN, IMU_MAG_Y_SIGN, IMU_MAG_Z_SIGN, int32_rmat_comp(), imu_calib_t::neutral, imu_mag_t::neutral, orientationGetRMat_i(), RMAT_COPY, imu_calib_t::rotation, imu_calib_t::scale_f, imu_mag_t::scale_f, VECT3_ASSIGN, VECT3_COPY, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
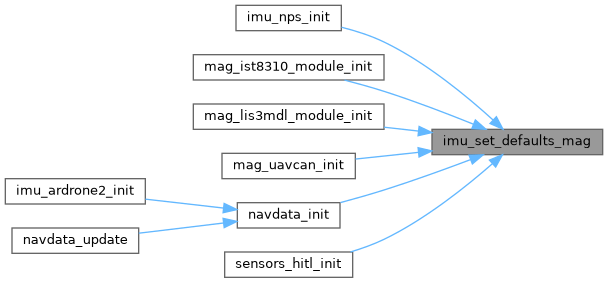
Referenced by imu_nps_init(), mag_ist8310_module_init(), mag_lis3mdl_module_init(), mag_uavcan_init(), and sensors_hitl_init().
|
extern |
Definition at line 1292 of file imu.c.
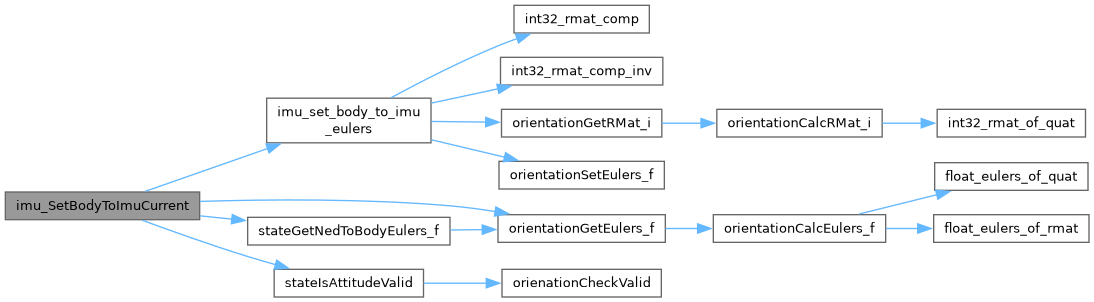
References imu, IMU_BODY_TO_IMU_PHI, IMU_BODY_TO_IMU_PSI, IMU_BODY_TO_IMU_THETA, imu_set_body_to_imu_eulers(), orientationGetEulers_f(), FloatEulers::phi, stateGetNedToBodyEulers_f(), stateIsAttitudeValid(), and FloatEulers::theta.
|
extern |
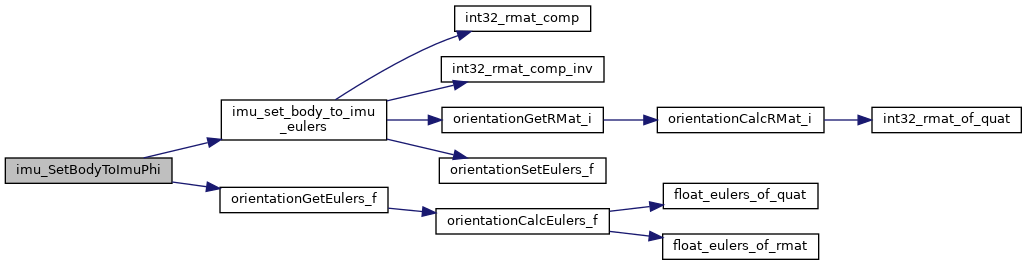
Definition at line 1268 of file imu.c.
References imu, imu_set_body_to_imu_eulers(), orientationGetEulers_f(), and FloatEulers::phi.
|
extern |
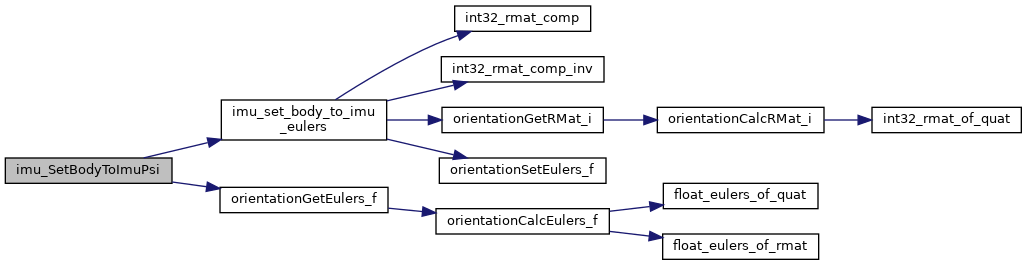
Definition at line 1284 of file imu.c.
References imu, imu_set_body_to_imu_eulers(), orientationGetEulers_f(), and FloatEulers::psi.
|
extern |
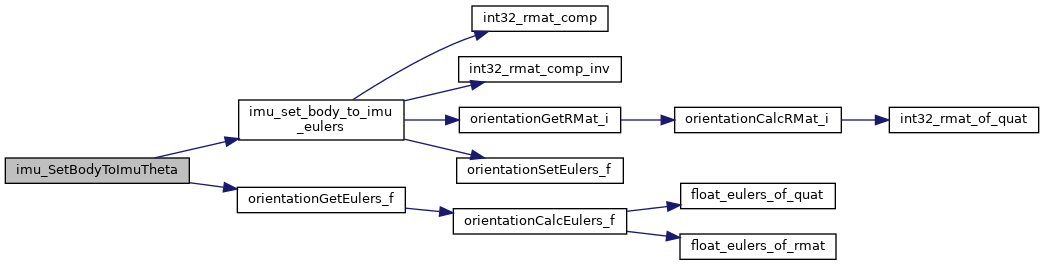
Definition at line 1276 of file imu.c.
References imu, imu_set_body_to_imu_eulers(), orientationGetEulers_f(), and FloatEulers::theta.
|
extern |
global IMU state
Definition at line 465 of file imu.c.
Referenced by imu_get_accel(), imu_get_gyro(), imu_get_mag(), imu_init(), imu_set_body_to_imu_eulers(), imu_set_defaults_accel(), imu_set_defaults_gyro(), imu_set_defaults_mag(), imu_SetBodyToImuCurrent(), imu_SetBodyToImuPhi(), imu_SetBodyToImuPsi(), imu_SetBodyToImuTheta(), ins_ekf2_at_rest_update(), jevois_mavlink_filter_init(), jevois_mavlink_filter_periodic(), mag_calib_ukf_run(), send_accel(), send_accel_raw(), send_accel_scaled(), send_gyro(), send_gyro_raw(), send_gyro_scaled(), send_mag(), send_mag_current(), send_mag_raw(), and send_mag_scaled().
 1.15.0