|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
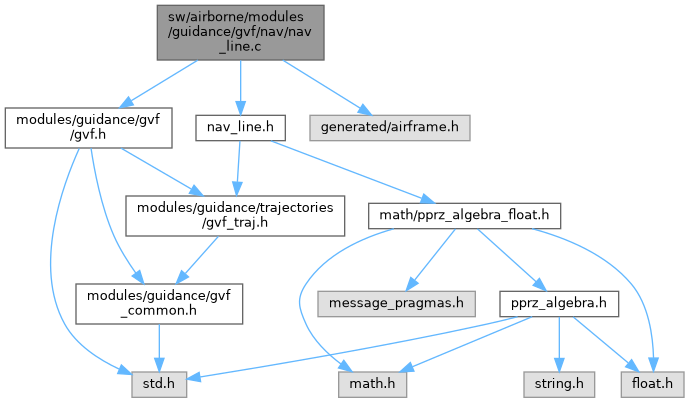
Go to the source code of this file.
Macros | |
| #define | GVF_LINE_KE 1 |
| #define | GVF_LINE_KN 1 |
| #define | GVF_LINE_HEADING 0 |
| #define | GVF_SEGMENT_D1 0 |
| #define | GVF_SEGMENT_D2 0 |
Functions | |
| static void | gvf_line (float a, float b, float heading) |
| static int | out_of_segment_area (float x1, float y1, float x2, float y2, float d1, float d2) |
| bool | nav_gvf_line_XY_heading (float a, float b, float heading) |
| bool | nav_gvf_line_wp_heading (uint8_t wp, float heading) |
| bool | nav_gvf_line_XY1_XY2 (float x1, float y1, float x2, float y2) |
| bool | nav_gvf_line_wp1_wp2 (uint8_t wp1, uint8_t wp2) |
| bool | nav_gvf_segment_loop_XY1_XY2 (float x1, float y1, float x2, float y2, float d1, float d2) |
| bool | nav_gvf_segment_loop_wp1_wp2 (uint8_t wp1, uint8_t wp2, float d1, float d2) |
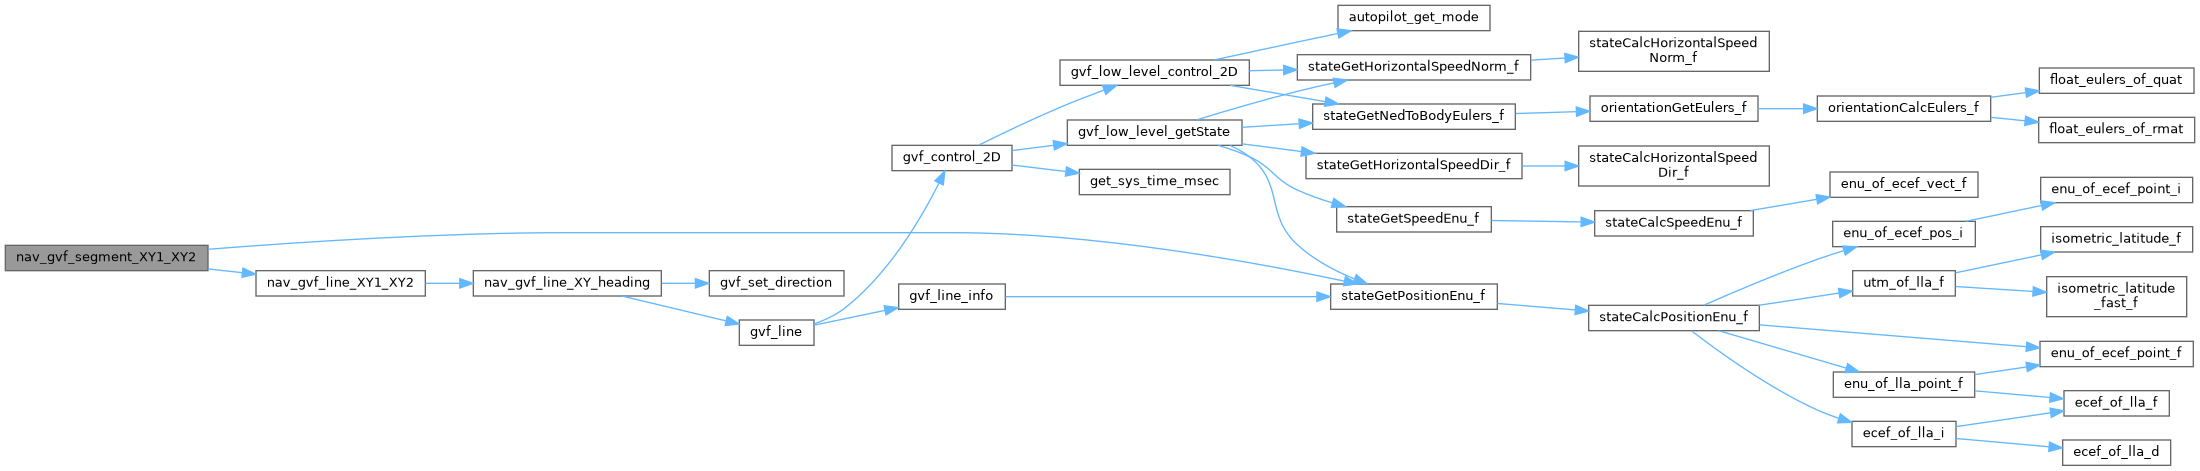
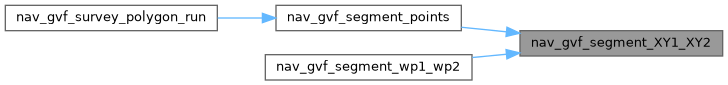
| bool | nav_gvf_segment_XY1_XY2 (float x1, float y1, float x2, float y2) |
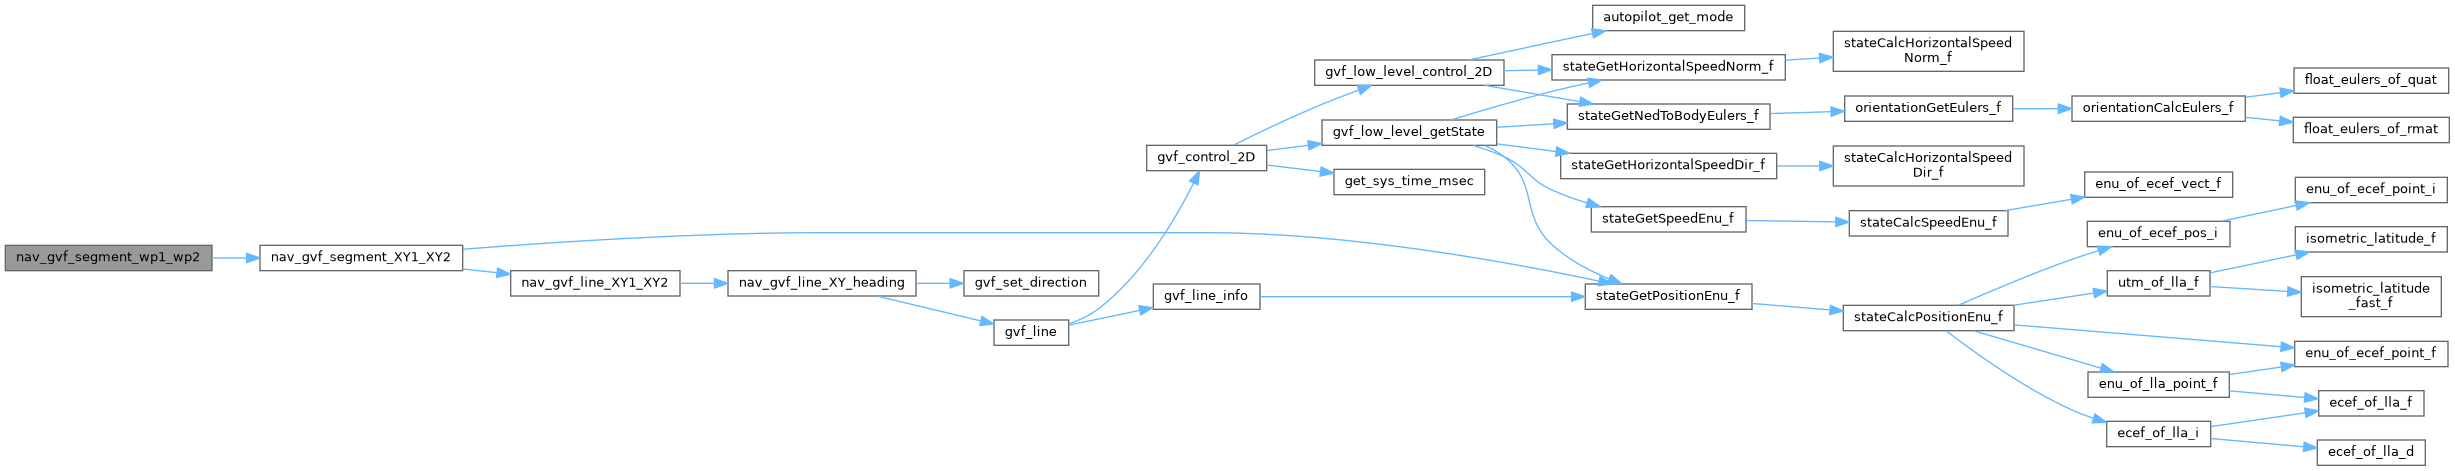
| bool | nav_gvf_segment_wp1_wp2 (uint8_t wp1, uint8_t wp2) |
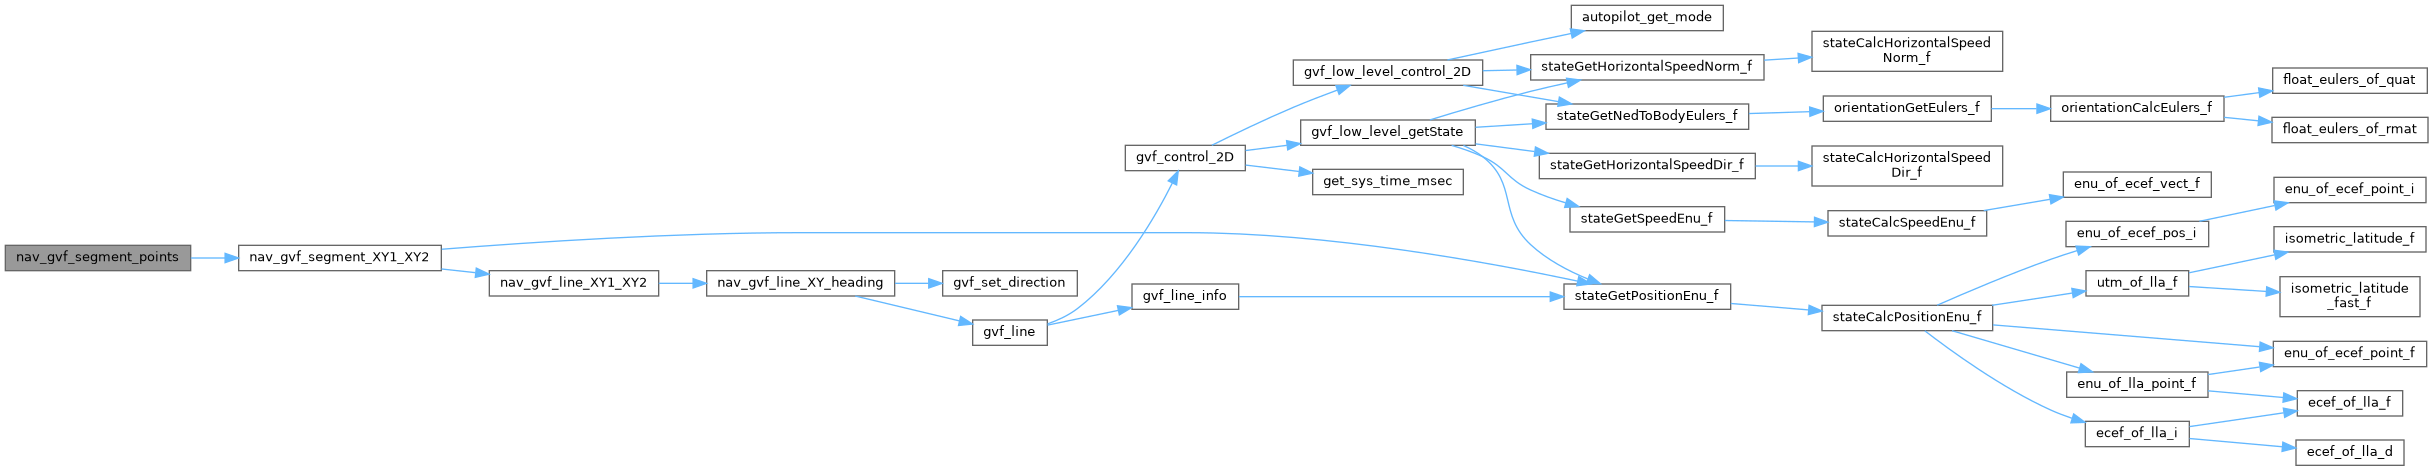
| bool | nav_gvf_segment_points (struct FloatVect2 start, struct FloatVect2 end) |
Variables | |
| gvf_li_par | gvf_line_par = {GVF_LINE_KE, GVF_LINE_KN, GVF_LINE_HEADING} |
| gvf_seg_par | gvf_segment_par = {GVF_SEGMENT_D1, GVF_SEGMENT_D2} |
| static int | gvf_p_len_wps = 0 |
| #define GVF_LINE_HEADING 0 |
Default heading in degrees for a trajectory called from gvf_line_**_HEADING
Definition at line 40 of file nav_line.c.
| #define GVF_LINE_KE 1 |
Gain ke for the line trajectory
Definition at line 30 of file nav_line.c.
| #define GVF_LINE_KN 1 |
Gain kn for the line trajectory
Definition at line 35 of file nav_line.c.
| #define GVF_SEGMENT_D1 0 |
In case of tracking a segment, how much distance in meters will go the vehicle beyond the point x1,y1 before turning back
Definition at line 45 of file nav_line.c.
| #define GVF_SEGMENT_D2 0 |
In case of tracking a segment, how much distance in meters will go the vehicle beyond the point x2,y2 before turning back
Definition at line 50 of file nav_line.c.
|
static |
Definition at line 61 of file nav_line.c.
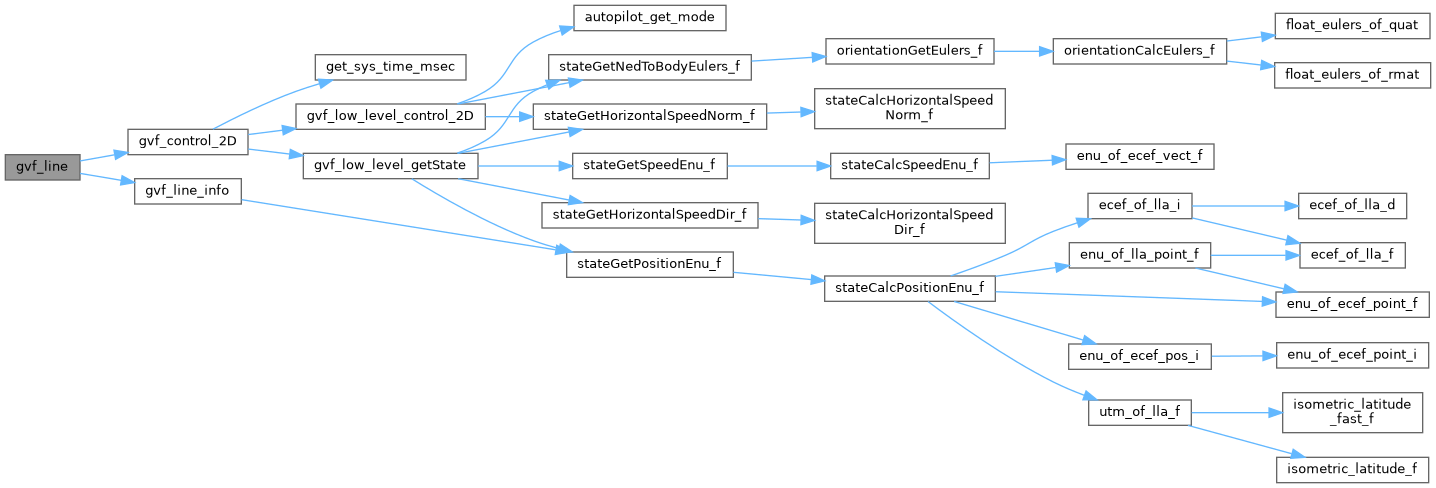
References b, gvf_control, gvf_control_2D(), gvf_line_info(), gvf_line_par, gvf_p_len_wps, gvf_segment, gvf_trajectory, and heading.
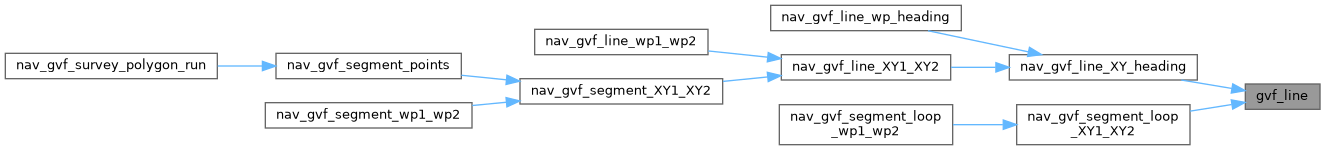
Referenced by nav_gvf_line_XY_heading(), and nav_gvf_segment_loop_XY1_XY2().
Definition at line 161 of file nav_line.c.
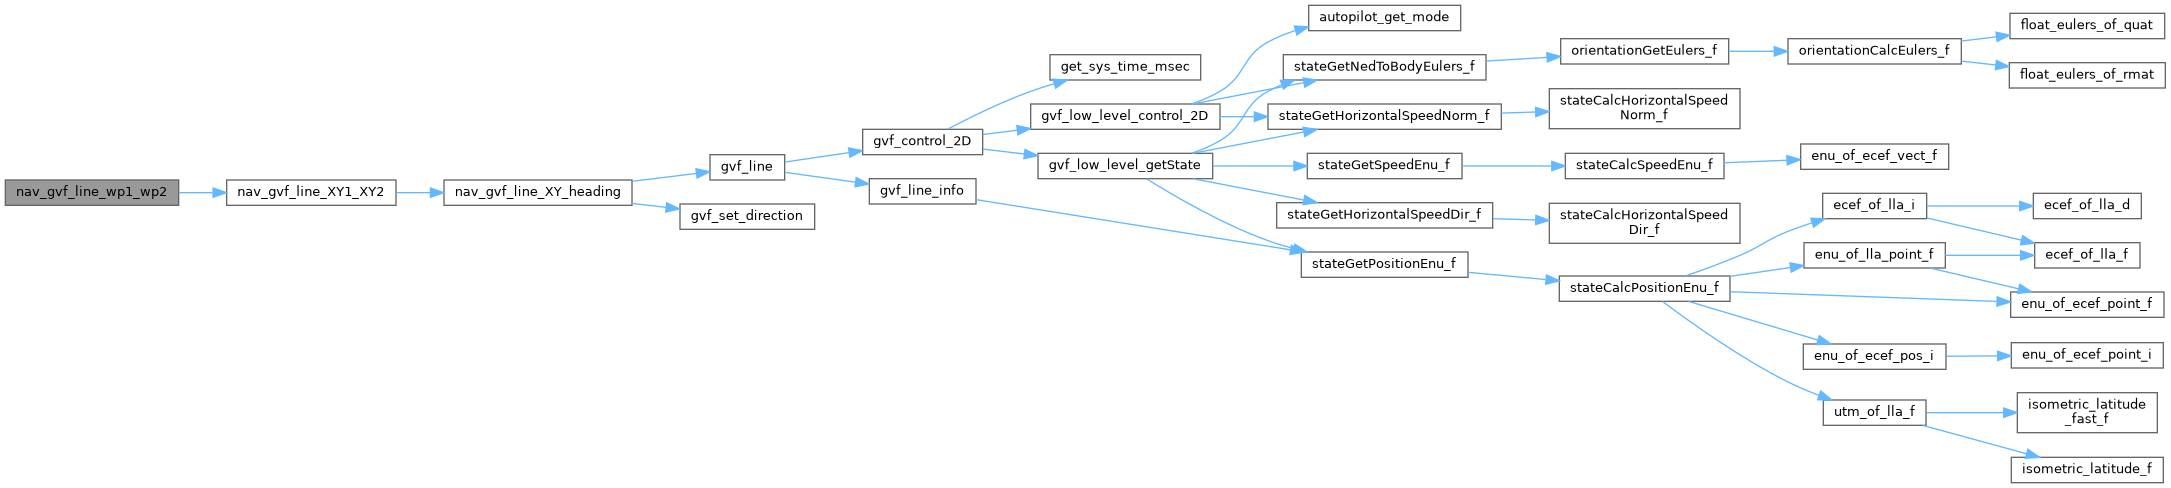
References gvf_p_len_wps, gvf_trajectory, nav_gvf_line_XY1_XY2(), WaypointX, and WaypointY.
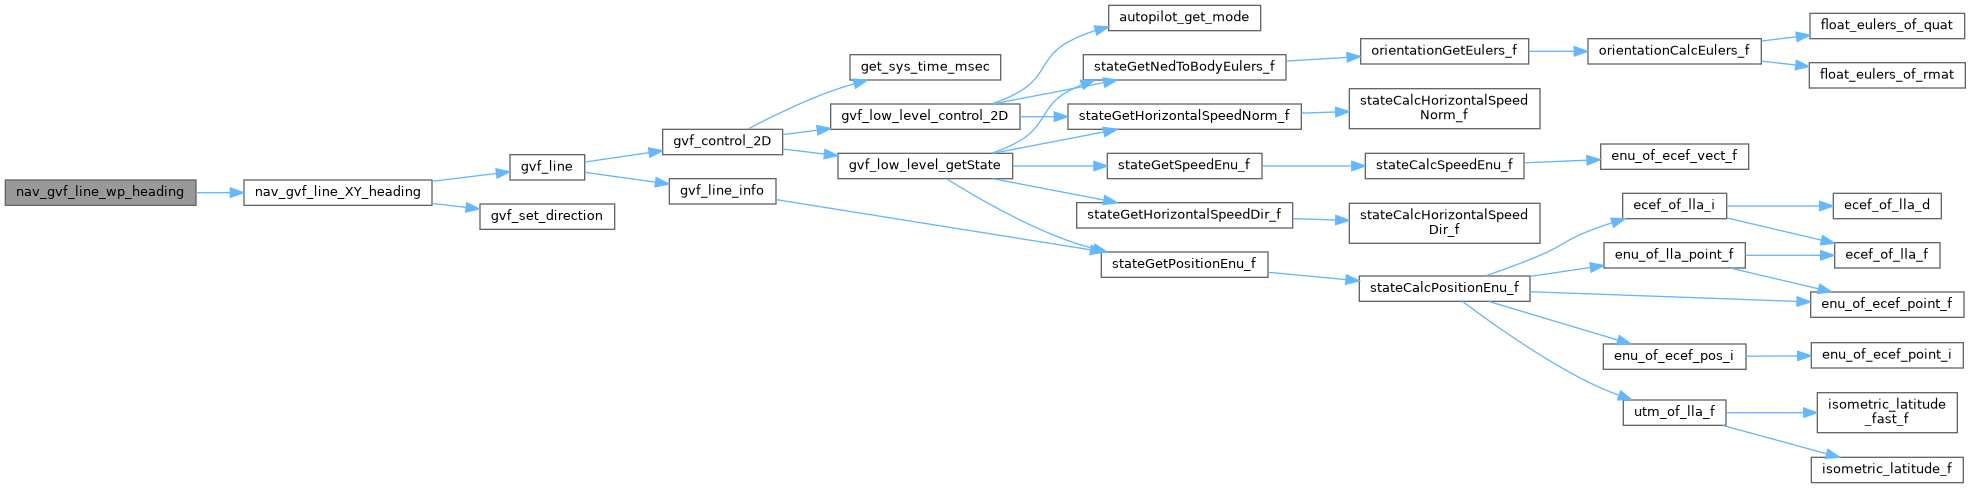
| bool nav_gvf_line_wp_heading | ( | uint8_t | wp, |
| float | heading ) |
Definition at line 127 of file nav_line.c.
References b, heading, nav_gvf_line_XY_heading(), WaypointX, and WaypointY.
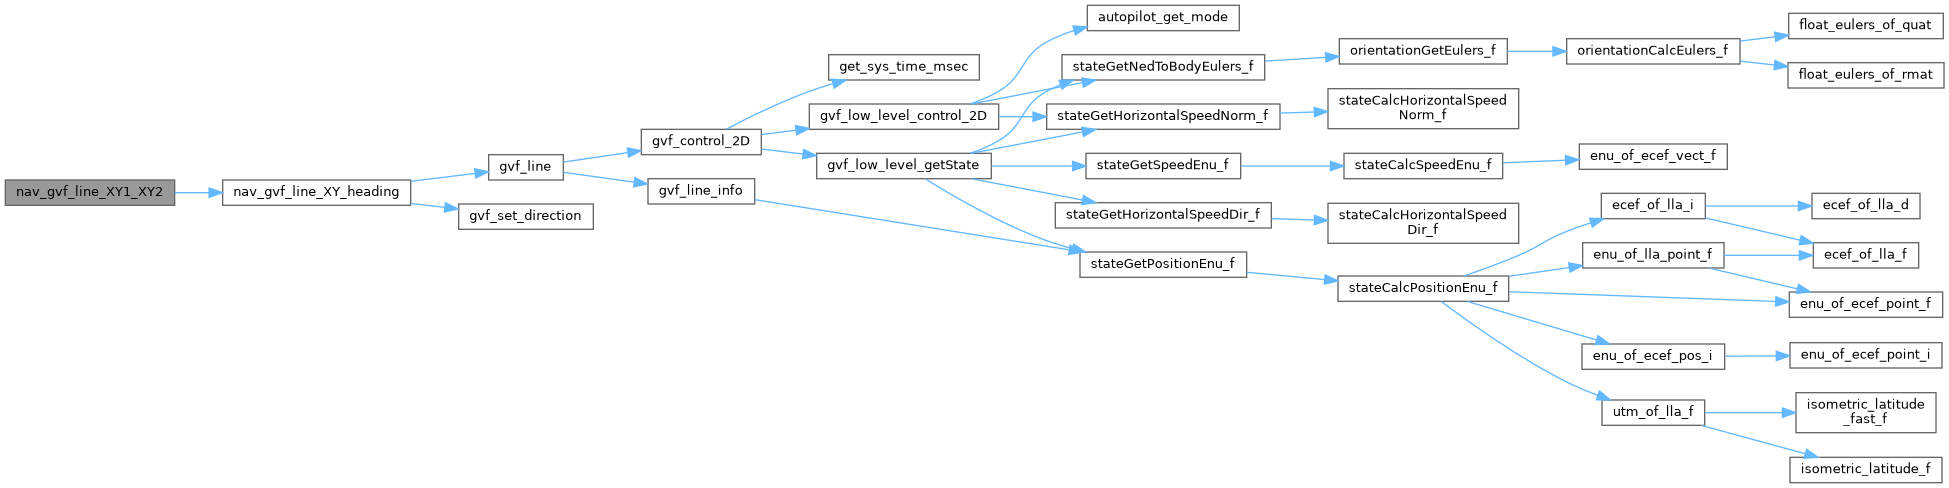
| bool nav_gvf_line_XY1_XY2 | ( | float | x1, |
| float | y1, | ||
| float | x2, | ||
| float | y2 ) |
Definition at line 137 of file nav_line.c.
References gvf_p_len_wps, gvf_segment, gvf_trajectory, and nav_gvf_line_XY_heading().
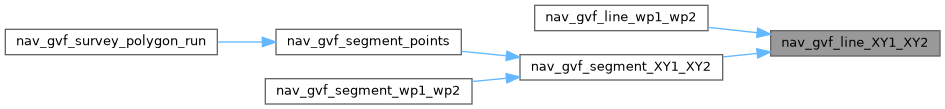
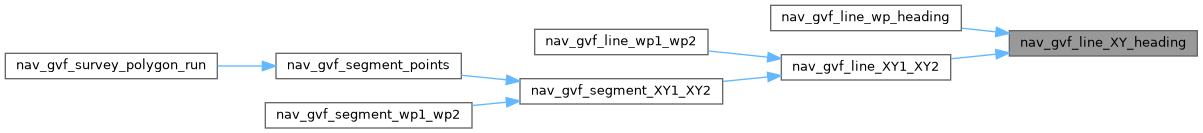
Referenced by nav_gvf_line_wp1_wp2(), and nav_gvf_segment_XY1_XY2().
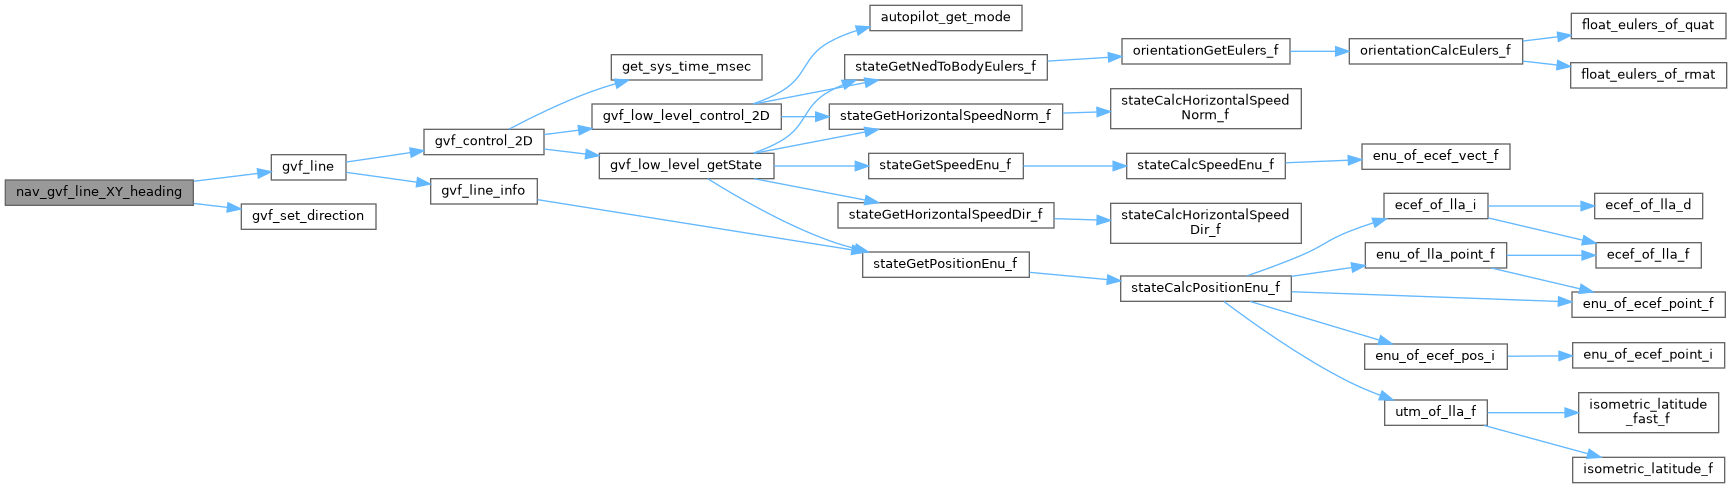
| bool nav_gvf_line_XY_heading | ( | float | a, |
| float | b, | ||
| float | heading ) |
Definition at line 120 of file nav_line.c.
References b, gvf_line(), gvf_set_direction(), and heading.
Referenced by nav_gvf_line_wp_heading(), and nav_gvf_line_XY1_XY2().
Definition at line 201 of file nav_line.c.
References d1, d2, gvf_p_len_wps, gvf_trajectory, nav_gvf_segment_loop_XY1_XY2(), WaypointX, and WaypointY.
| bool nav_gvf_segment_loop_XY1_XY2 | ( | float | x1, |
| float | y1, | ||
| float | x2, | ||
| float | y2, | ||
| float | d1, | ||
| float | d2 ) |
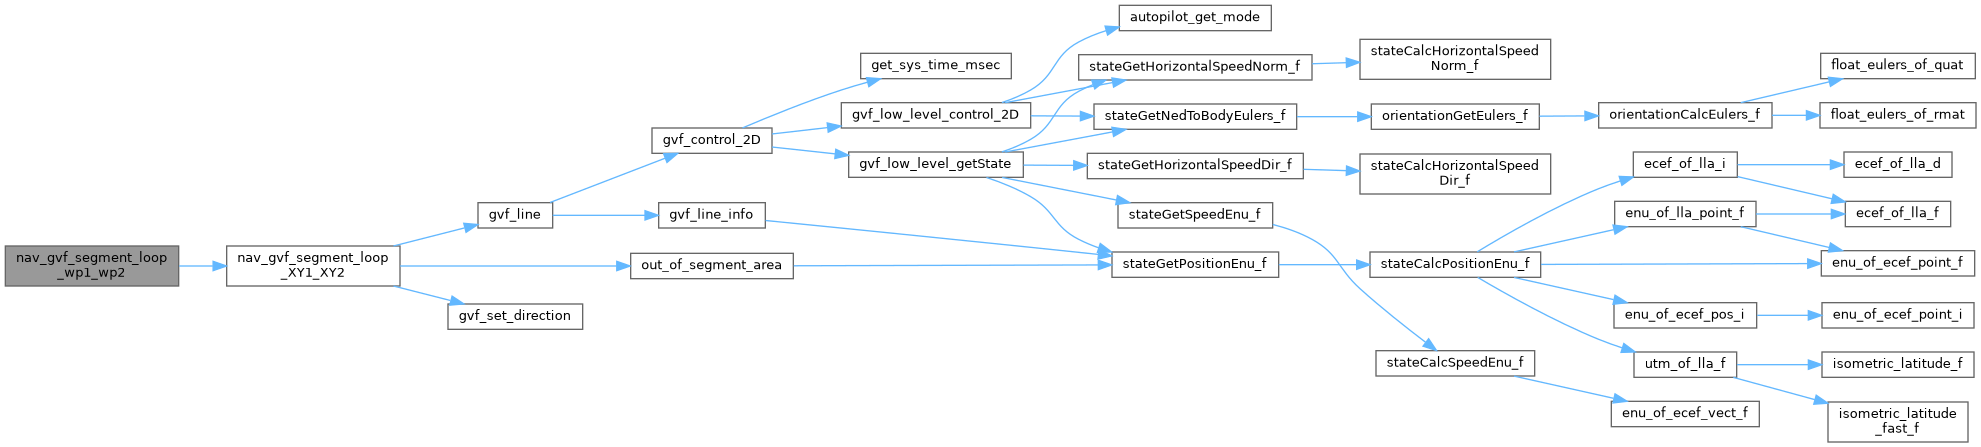
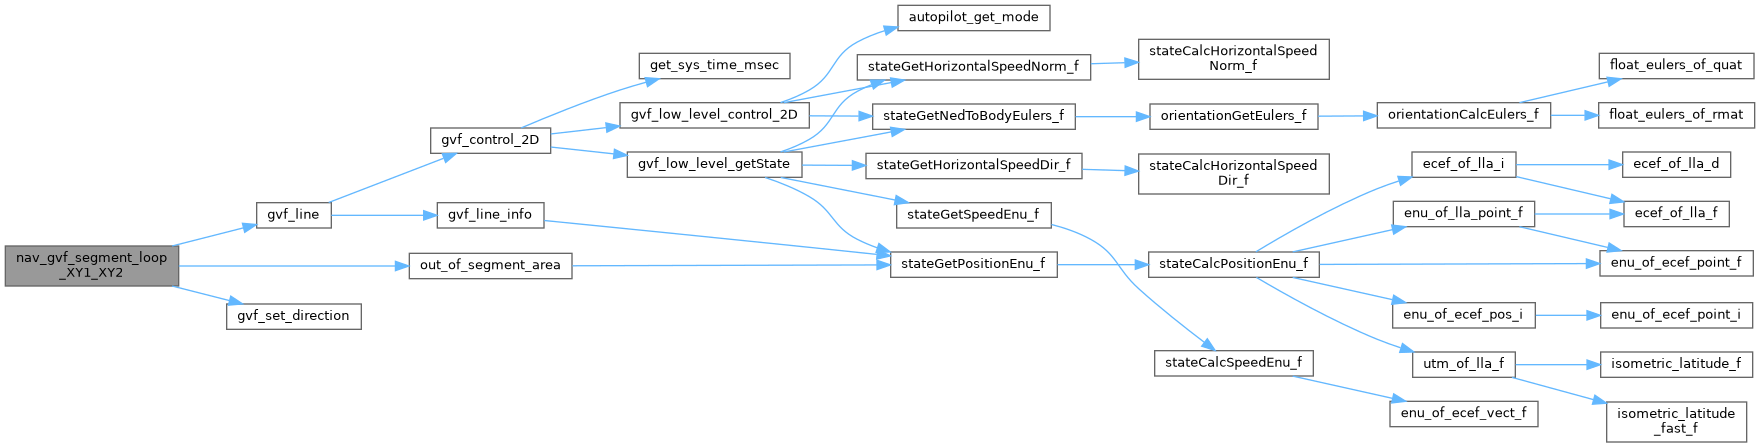
Definition at line 177 of file nav_line.c.
References alpha, d1, d2, gvf_line(), gvf_segment, gvf_set_direction(), out_of_segment_area(), and s.
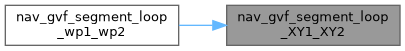
Referenced by nav_gvf_segment_loop_wp1_wp2().
| bool nav_gvf_segment_points | ( | struct FloatVect2 | start, |
| struct FloatVect2 | end ) |
Definition at line 253 of file nav_line.c.
References nav_gvf_segment_XY1_XY2(), FloatVect2::x, and FloatVect2::y.
Referenced by nav_gvf_survey_polygon_run().
Definition at line 239 of file nav_line.c.
References gvf_p_len_wps, gvf_trajectory, nav_gvf_segment_XY1_XY2(), WaypointX, and WaypointY.
| bool nav_gvf_segment_XY1_XY2 | ( | float | x1, |
| float | y1, | ||
| float | x2, | ||
| float | y2 ) |
Definition at line 217 of file nav_line.c.
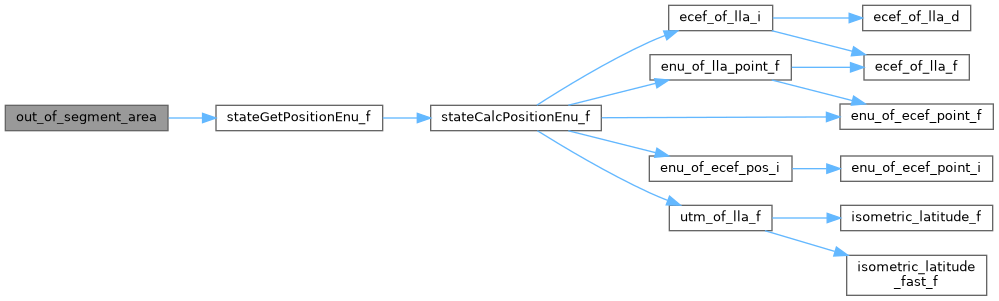
References nav_gvf_line_XY1_XY2(), p, and stateGetPositionEnu_f().
Referenced by nav_gvf_segment_points(), and nav_gvf_segment_wp1_wp2().
|
static |
Definition at line 85 of file nav_line.c.
References alpha, d1, d2, p, s, and stateGetPositionEnu_f().
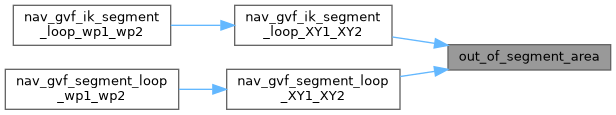
Referenced by nav_gvf_ik_segment_loop_XY1_XY2(), and nav_gvf_segment_loop_XY1_XY2().
| gvf_li_par gvf_line_par = {GVF_LINE_KE, GVF_LINE_KN, GVF_LINE_HEADING} |
|
static |
Definition at line 57 of file nav_line.c.
| gvf_seg_par gvf_segment_par = {GVF_SEGMENT_D1, GVF_SEGMENT_D2} |
Definition at line 54 of file nav_line.c.
 1.15.0