|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "std.h"Go to the source code of this file.
Macros | |
| #define | PRIMARY_GPS GPS_SIM |
Functions | |
| void | sensors_hitl_init (void) |
| void | sensors_hitl_periodic (void) |
| void | sensors_hitl_event (void) |
| void | sensors_hitl_parse_HITL_IMU (uint8_t *buf) |
| void | sensors_hitl_parse_HITL_GPS (uint8_t *buf) |
| void | sensors_hitl_parse_HITL_AIR_DATA (uint8_t *buf) |
| void | imu_feed_gyro_accel (void) |
| void | imu_feed_mag (void) |
| void | gps_feed_value (void) |
Variables | |
| bool | gps_has_fix |
| #define PRIMARY_GPS GPS_SIM |
Definition at line 27 of file sensors_hitl.h.
|
extern |
Definition at line 58 of file gps_sim_nps.c.
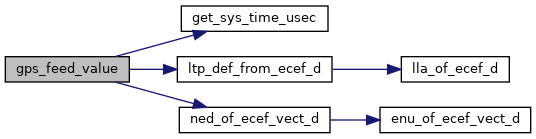
References fdm, get_sys_time_usec(), GPS_FIX_3D, GPS_FIX_NONE, gps_has_fix, gps_nps, GPS_NPS_HACC, GPS_NPS_PACC, GPS_NPS_PDOP, GPS_NPS_SACC, GPS_NPS_VACC, GPS_SIM_ID, GPS_VALID_COURSE_BIT, GPS_VALID_HMSL_BIT, GPS_VALID_POS_ECEF_BIT, GPS_VALID_POS_LLA_BIT, GPS_VALID_VEL_ECEF_BIT, GPS_VALID_VEL_NED_BIT, ltp_def_from_ecef_d(), sys_time::nb_sec, sys_time::nb_sec_rem, ned_of_ecef_vect_d(), sensors, SYS_TIME_GPS_LEAP_SECONDS, SYS_TIME_MSEC_PER_WEEK, SYS_TIME_UNIX_GPS_EPOCH_MS, NedCoor_d::x, NedCoor_d::y, and NedCoor_d::z.
Referenced by nps_autopilot_run_step().
|
extern |
Definition at line 50 of file imu_nps.c.
References imu_nps, RATES_ASSIGN, sensors, and VECT3_COPY.
Referenced by nps_autopilot_run_step().
|
extern |
Definition at line 61 of file imu_nps.c.
References imu_nps, sensors, and VECT3_COPY.
Referenced by nps_autopilot_run_step().
|
extern |
Definition at line 201 of file sensors_hitl.c.
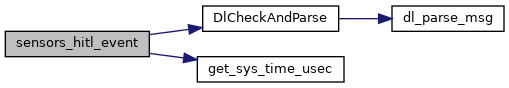
References DlCheckAndParse(), get_sys_time_usec(), imu_hitl, IMU_NPS_ID, sensors_hitl_dl_buffer, sensors_hitl_msg_available, and sensors_hitl_tp.
|
extern |
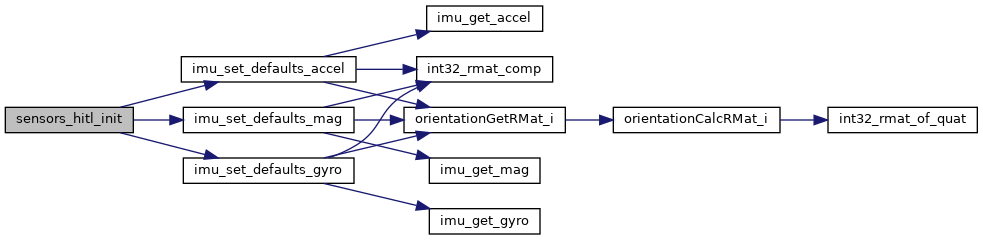
Definition at line 53 of file sensors_hitl.c.
References ACCEL_FLOAT_OF_BFP, gps_has_fix, imu_hitl, IMU_NPS_ID, imu_set_defaults_accel(), imu_set_defaults_gyro(), imu_set_defaults_mag(), MAG_FLOAT_OF_BFP, RATE_FLOAT_OF_BFP, and sensors_hitl_tp.
|
extern |
Definition at line 178 of file sensors_hitl.c.
References AIRSPEED_NPS_ID, BARO_SIM_SENDER_ID, get_sys_time_usec(), and INCIDENCE_NPS_ID.
|
extern |
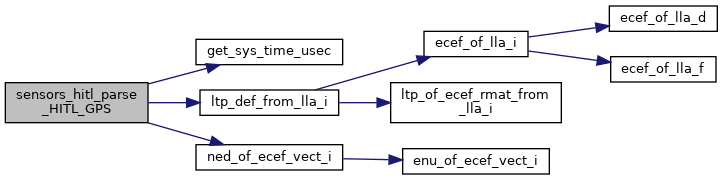
Definition at line 111 of file sensors_hitl.c.
References get_sys_time_usec(), GPS_FIX_3D, GPS_FIX_NONE, gps_has_fix, gps_hitl, GPS_SIM_ID, GPS_VALID_COURSE_BIT, GPS_VALID_HMSL_BIT, GPS_VALID_POS_LLA_BIT, GPS_VALID_VEL_ECEF_BIT, GPS_VALID_VEL_NED_BIT, ltp_def_from_lla_i(), sys_time::nb_sec, sys_time::nb_sec_rem, ned_of_ecef_vect_i(), VECT3_FLOAT_OF_CM, NedCoor_f::x, NedCoor_i::x, NedCoor_f::y, NedCoor_i::y, NedCoor_f::z, and NedCoor_i::z.
|
extern |
Definition at line 87 of file sensors_hitl.c.
References imu_hitl, RATES_ASSIGN, and VECT3_ASSIGN.
|
extern |
Definition at line 76 of file sensors_hitl.c.
References electrical.
|
extern |
Definition at line 31 of file gps_sim_nps.c.
Referenced by gps_feed_value(), gps_nps_init(), on_WORLD_ENV(), sensors_hitl_init(), and sensors_hitl_parse_HITL_GPS().
 1.15.0