|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
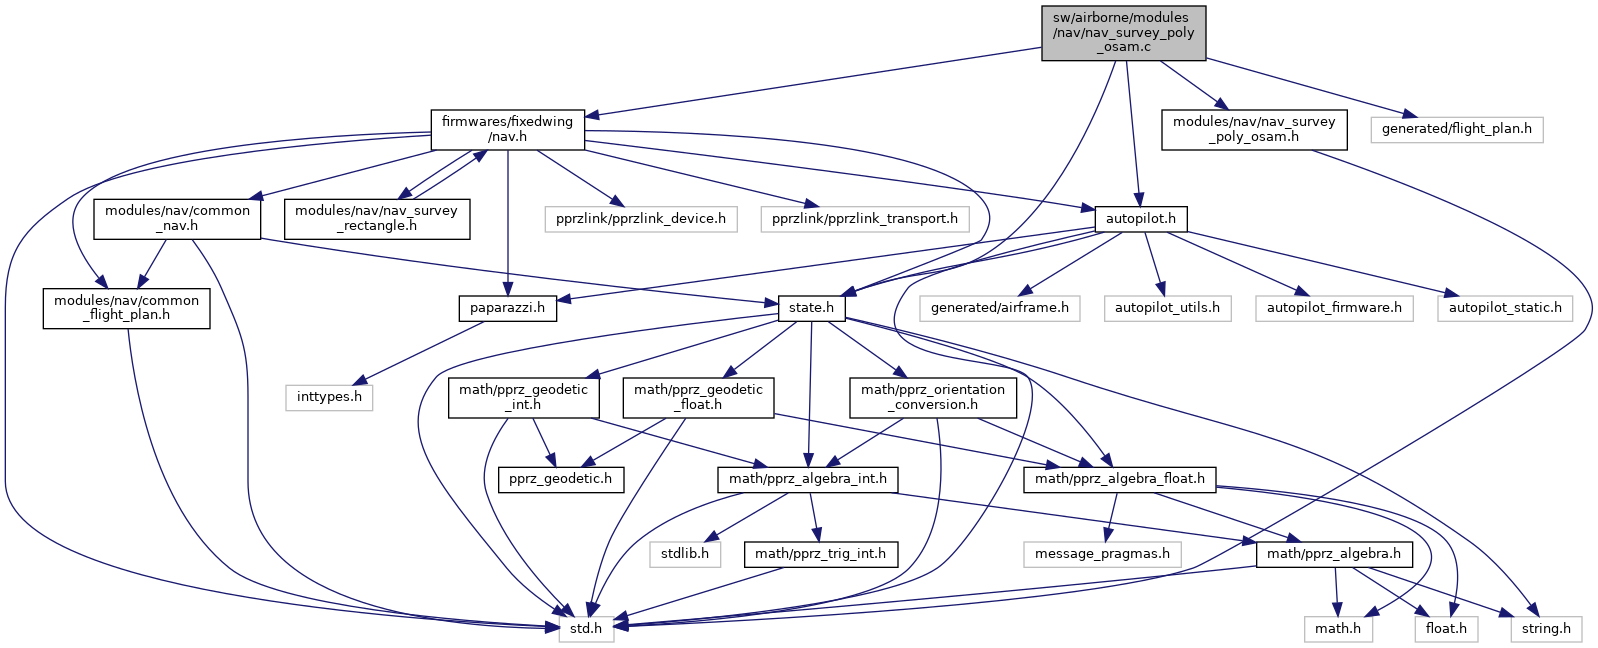
#include "modules/nav/nav_survey_poly_osam.h"#include "firmwares/fixedwing/nav.h"#include "state.h"#include "autopilot.h"#include "generated/flight_plan.h"Go to the source code of this file.
Data Structures | |
| struct | Point2D |
| struct | Line |
Macros | |
| #define | POLY_OSAM_DEFAULT_SIZE 5 |
| #define | POLY_OSAM_DEFAULT_SWEEP 100 |
| #define | POLY_OSAM_ENTRY_RADIUS 0 |
| Default entry radius, if 0 default to half sweep. | |
| #define | POLY_OSAM_MIN_RADIUS 30 |
| if 0 never check for min radius | |
| #define | POLY_OSAM_FIRST_SWEEP_DISTANCE 0 |
| if 0 default to half sweep | |
| #define | POLY_OSAM_POLYGONSIZE 10 |
| maximum number of polygon corners | |
| #define | POLY_OSAM_USE_FULL_CIRCLE TRUE |
| #define | POLY_OSAM_HALF_SWEEP_ENABLED TRUE |
| #define | PolygonSize POLY_OSAM_POLYGONSIZE |
| #define | MaxFloat 1000000000 |
| #define | MinFloat -1000000000 |
| #define | LINE_START_FUNCTION {} |
| #define | LINE_STOP_FUNCTION {} |
Enumerations | |
| enum | SurveyStatus { Init , Entry , Sweep , SweepCircle } |
| This routine will cover the enitre area of any Polygon defined in the flightplan which is a convex polygon. More... | |
Functions | |
| void | nav_survey_poly_osam_setup_towards (uint8_t FirstWP, uint8_t Size, float Sweep, int SecondWP) |
| Setup "dynamic" polygon survey with sweep orientation towards a waypoint. | |
| static void | TranslateAndRotateFromWorld (struct Point2D *p, float Zrot, float transX, float transY) |
| static void | RotateAndTranslateToWorld (struct Point2D *p, float Zrot, float transX, float transY) |
| Rotates point round z by -Zrot then translates so (0,0) becomes (transX,transY). | |
| static void | FindInterceptOfTwoLines (float *x, float *y, struct Line L1, struct Line L2) |
| static float | EvaluateLineForX (float y, struct Line L) |
| void | nav_survey_poly_osam_ResetSweepNumber (bool rst) |
| Reset sweep number. | |
| void | nav_survey_poly_osam_setup (uint8_t EntryWP, uint8_t Size, float sw, float Orientation) |
| Setup polygon survey. | |
| bool | nav_survey_poly_osam_run (void) |
| Run polygon survey. | |
Variables | |
| uint8_t | Poly_Size = POLY_OSAM_DEFAULT_SIZE |
| float | Poly_Sweep = POLY_OSAM_DEFAULT_SWEEP |
| bool | use_full_circle = POLY_OSAM_USE_FULL_CIRCLE |
| bool | Half_Sweep_Enabled = POLY_OSAM_HALF_SWEEP_ENABLED |
| bool | Reset_Sweep = FALSE |
| static enum SurveyStatus | CSurveyStatus |
| static struct Point2D | SmallestCorner |
| static struct Line | Edges [PolygonSize] |
| static float | EdgeMaxY [PolygonSize] |
| static float | EdgeMinY [PolygonSize] |
| static float | SurveyTheta |
| static float | dSweep |
| static float | SurveyRadius |
| static struct Point2D | SurveyToWP |
| static struct Point2D | SurveyFromWP |
| static struct Point2D | SurveyCircle |
| static uint8_t | SurveyEntryWP |
| static uint8_t | SurveySize |
| static float | SurveyCircleQdr |
| static float | MaxY |
| uint16_t | PolySurveySweepNum |
| uint16_t | PolySurveySweepBackNum |
| float | EntryRadius |
| struct Point2D |
Definition at line 90 of file nav_launcher.c.
| Data Fields | ||
|---|---|---|
| float | x | |
| float | y | |
| struct Line |
Definition at line 77 of file nav_survey_hybrid.c.
| Data Fields | ||
|---|---|---|
| float | b | |
| float | m | |
| float | x | |
| #define LINE_START_FUNCTION {} |
Definition at line 114 of file nav_survey_poly_osam.c.
| #define LINE_STOP_FUNCTION {} |
Definition at line 117 of file nav_survey_poly_osam.c.
| #define MaxFloat 1000000000 |
Definition at line 110 of file nav_survey_poly_osam.c.
| #define MinFloat -1000000000 |
Definition at line 111 of file nav_survey_poly_osam.c.
| #define POLY_OSAM_DEFAULT_SIZE 5 |
Definition at line 39 of file nav_survey_poly_osam.c.
| #define POLY_OSAM_DEFAULT_SWEEP 100 |
Definition at line 43 of file nav_survey_poly_osam.c.
| #define POLY_OSAM_ENTRY_RADIUS 0 |
Default entry radius, if 0 default to half sweep.
Definition at line 48 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_setup().
| #define POLY_OSAM_FIRST_SWEEP_DISTANCE 0 |
if 0 default to half sweep
Definition at line 58 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_setup().
| #define POLY_OSAM_HALF_SWEEP_ENABLED TRUE |
Definition at line 72 of file nav_survey_poly_osam.c.
| #define POLY_OSAM_MIN_RADIUS 30 |
if 0 never check for min radius
Definition at line 53 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run().
| #define POLY_OSAM_POLYGONSIZE 10 |
maximum number of polygon corners
Definition at line 63 of file nav_survey_poly_osam.c.
| #define POLY_OSAM_USE_FULL_CIRCLE TRUE |
Definition at line 67 of file nav_survey_poly_osam.c.
| #define PolygonSize POLY_OSAM_POLYGONSIZE |
Definition at line 109 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_setup().
| enum SurveyStatus |
This routine will cover the enitre area of any Polygon defined in the flightplan which is a convex polygon.
| Enumerator | |
|---|---|
| Init | |
| Entry | |
| Sweep | |
| SweepCircle | |
Definition at line 125 of file nav_survey_poly_osam.c.
|
static |
Definition at line 615 of file nav_survey_poly_osam.c.
References Line::b, Line::m, and Point2D::y.
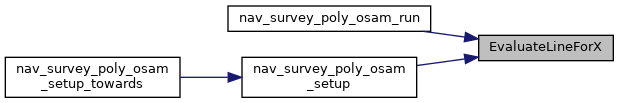
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_osam_setup().
Definition at line 608 of file nav_survey_poly_osam.c.
References Line::b, Line::m, Point2D::x, and Point2D::y.
Referenced by nav_survey_poly_osam_setup().
| void nav_survey_poly_osam_ResetSweepNumber | ( | bool | rst | ) |
Reset sweep number.
Definition at line 101 of file nav_survey_poly_osam.c.
References FALSE, PolySurveySweepBackNum, and Reset_Sweep.
| bool nav_survey_poly_osam_run | ( | void | ) |
Run polygon survey.
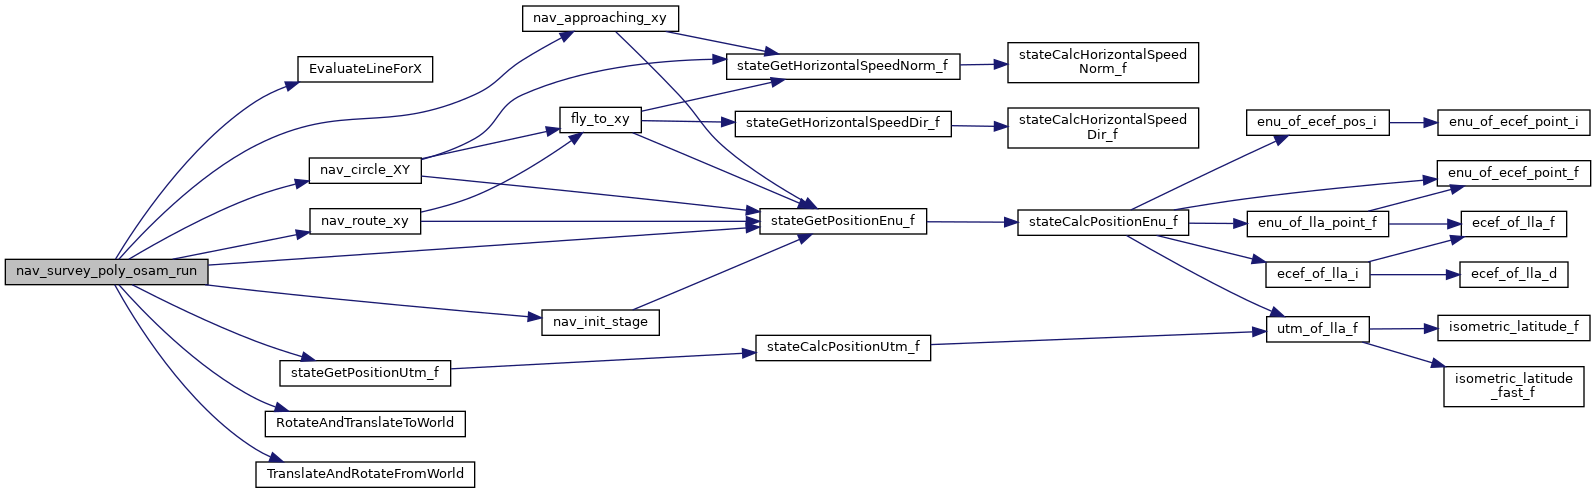
Definition at line 349 of file nav_survey_poly_osam.c.
References CSurveyStatus, dc_autoshoot, DC_AUTOSHOOT_STOP, dSweep, EdgeMaxY, EdgeMinY, Edges, Entry, EvaluateLineForX(), Half_Sweep_Enabled, Init, LINE_START_FUNCTION, LINE_STOP_FUNCTION, MaxY, nav_approaching_xy(), nav_circle_XY(), nav_init_stage(), nav_route_xy(), nav_survey_shift, NavCircleCount, NavCircleCountNoRewind, NavQdrCloseTo, NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, POLY_OSAM_MIN_RADIUS, Poly_Sweep, PolySurveySweepBackNum, PolySurveySweepNum, RotateAndTranslateToWorld(), SmallestCorner, stateGetPositionEnu_f(), stateGetPositionUtm_f(), SurveyCircle, SurveyCircleQdr, SurveyEntryWP, SurveyFromWP, SurveyRadius, SurveySize, SurveyTheta, SurveyToWP, Sweep, SweepCircle, TranslateAndRotateFromWorld(), use_full_circle, waypoints, EnuCoor_f::x, Point2D::x, EnuCoor_f::y, and Point2D::y.
Setup polygon survey.
| FirstWP | first waypoint/corner of the polygon |
| Size | number of waypoints/corners used to define the polygon |
| Sweep | distance between scan lines |
| Orientation | angle of scan lines in degrees (CCW, east) |
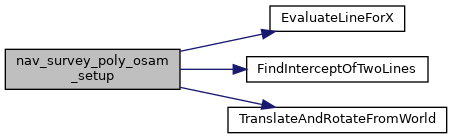
Definition at line 146 of file nav_survey_poly_osam.c.
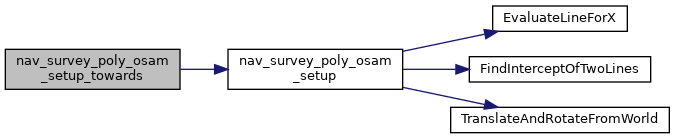
References CSurveyStatus, dSweep, EdgeMaxY, EdgeMinY, Edges, Entry, EntryRadius, EvaluateLineForX(), FindInterceptOfTwoLines(), Init, LINE_STOP_FUNCTION, MaxFloat, MaxY, POLY_OSAM_ENTRY_RADIUS, POLY_OSAM_FIRST_SWEEP_DISTANCE, Poly_Sweep, PolygonSize, PolySurveySweepBackNum, PolySurveySweepNum, SmallestCorner, SurveyCircle, SurveyCircleQdr, SurveyEntryWP, SurveyFromWP, SurveyRadius, SurveySize, SurveyTheta, SurveyToWP, TranslateAndRotateFromWorld(), waypoints, Point2D::x, and Point2D::y.
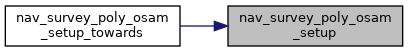
Referenced by nav_survey_poly_osam_setup_towards().
| void nav_survey_poly_osam_setup_towards | ( | uint8_t | FirstWP, |
| uint8_t | Size, | ||
| float | Sweep, | ||
| int | SecondWP ) |
Setup "dynamic" polygon survey with sweep orientation towards a waypoint.
Computes the sweep orientation angle from the line FirstWP-SecondWP. If you pass zero for Size and/or Sweep it will use the global Poly_Size and Poly_Sweep variables respectively (which can be changed via telemetry/settings).
| FirstWP | first waypoint/corner of the polygon |
| Size | number of waypoints/corners used to define the polygon, if zero uses Poly_Size |
| Sweep | distance between scan lines, if zero uses Poly_Sweep |
| SecondWP | second waypoint towards which the sweep orientation is computed |
Definition at line 81 of file nav_survey_poly_osam.c.
References nav_survey_poly_osam_setup(), Poly_Size, Poly_Sweep, Sweep, and waypoints.
|
static |
Rotates point round z by -Zrot then translates so (0,0) becomes (transX,transY).
Definition at line 597 of file nav_survey_poly_osam.c.
References p.
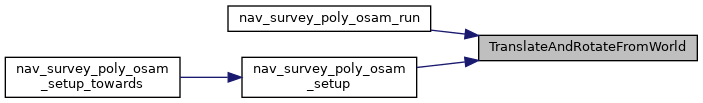
Referenced by nav_survey_poly_osam_run().
|
static |
Definition at line 584 of file nav_survey_poly_osam.c.
References p.
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_osam_setup().
|
static |
Definition at line 126 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 132 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 129 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 130 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 128 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
| float EntryRadius |
Definition at line 143 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_setup().
| bool Half_Sweep_Enabled = POLY_OSAM_HALF_SWEEP_ENABLED |
Definition at line 78 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_run().
|
static |
Definition at line 140 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
| uint8_t Poly_Size = POLY_OSAM_DEFAULT_SIZE |
Definition at line 75 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_setup_towards(), and nav_survey_poly_setup_towards().
| float Poly_Sweep = POLY_OSAM_DEFAULT_SWEEP |
Definition at line 76 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), and nav_survey_poly_osam_setup_towards().
| uint16_t PolySurveySweepBackNum |
Definition at line 142 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_ResetSweepNumber(), nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
| uint16_t PolySurveySweepNum |
Definition at line 141 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
| bool Reset_Sweep = FALSE |
Definition at line 79 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_ResetSweepNumber().
|
static |
Definition at line 127 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 136 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_osam_setup().
|
static |
Definition at line 139 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_osam_setup().
|
static |
Definition at line 137 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 135 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 133 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), and nav_survey_poly_osam_setup().
|
static |
Definition at line 138 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 131 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
|
static |
Definition at line 134 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run(), nav_survey_poly_osam_setup(), nav_survey_poly_run(), and nav_survey_poly_setup().
| bool use_full_circle = POLY_OSAM_USE_FULL_CIRCLE |
Definition at line 77 of file nav_survey_poly_osam.c.
Referenced by nav_survey_poly_osam_run().
 1.15.0