|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
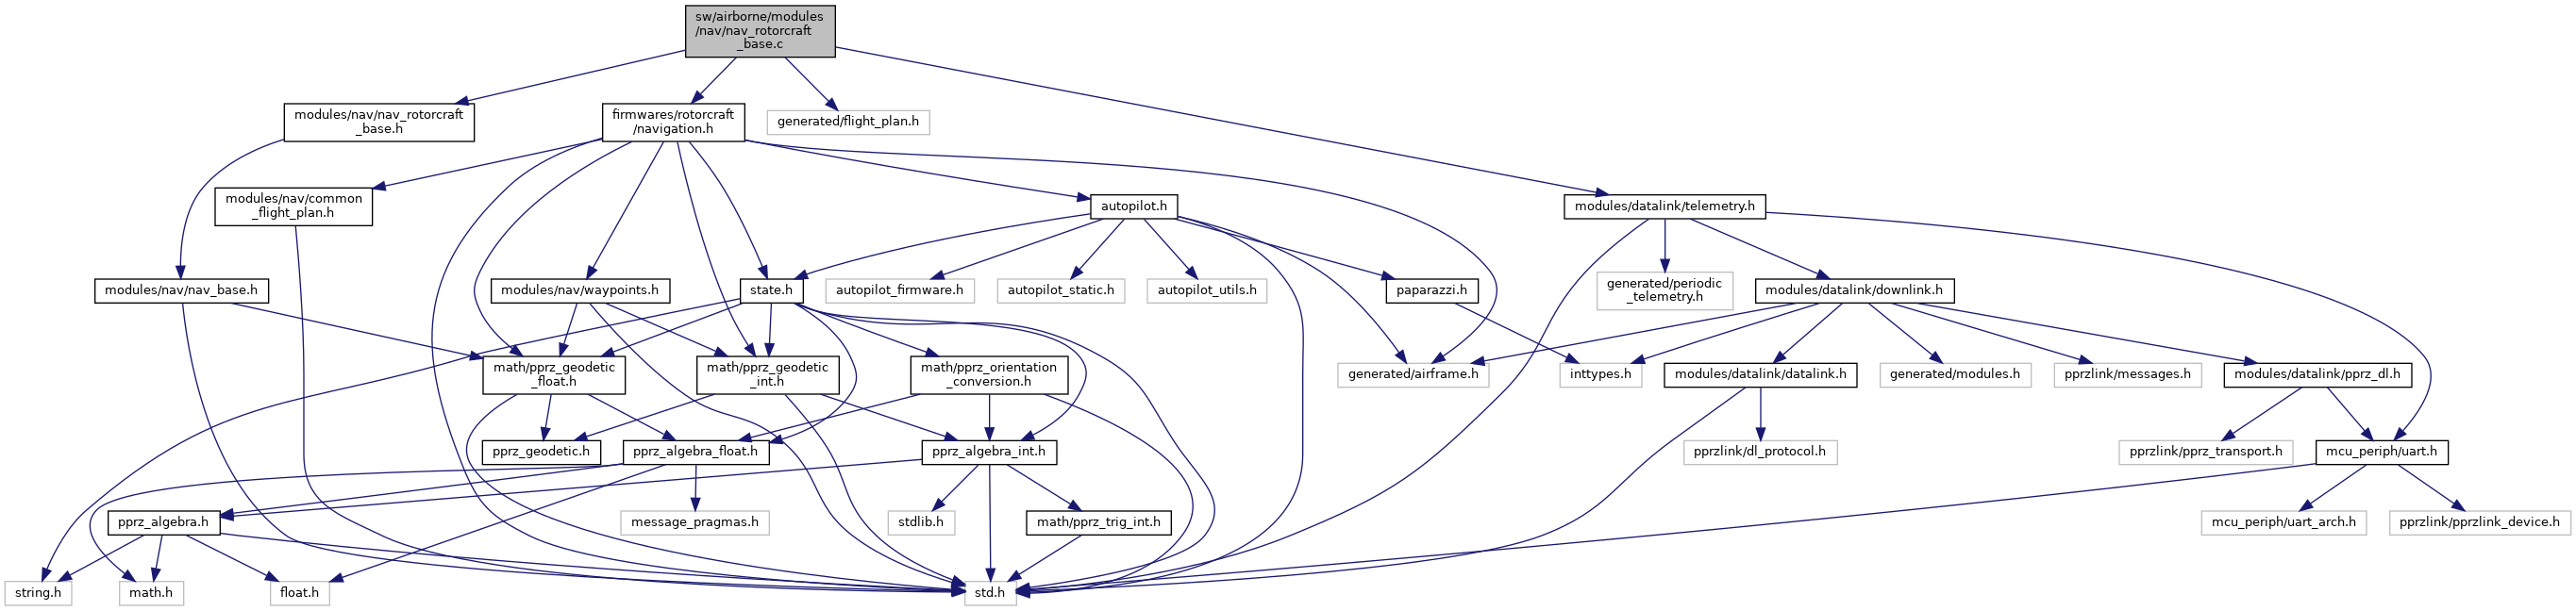
#include "modules/nav/nav_rotorcraft_base.h"#include "firmwares/rotorcraft/navigation.h"#include "generated/flight_plan.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Macros | |
| #define | LINE_START_FUNCTION {} |
| Navigation along a figure O. | |
| #define | LINE_STOP_FUNCTION {} |
Functions | |
| static void | nav_stage_init (void) |
| Implement basic nav function. | |
| static void | nav_goto (struct EnuCoor_f *wp) |
| static void | nav_route (struct EnuCoor_f *wp_start, struct EnuCoor_f *wp_end) |
| static bool | nav_approaching (struct EnuCoor_f *wp, struct EnuCoor_f *from, float approaching_time) |
| static void | nav_circle (struct EnuCoor_f *wp_center, float radius) |
| static void | _nav_oval_init (void) |
| static void | nav_oval (struct EnuCoor_f *wp1, struct EnuCoor_f *wp2, float radius) |
| static void | send_nav_status (struct transport_tx *trans, struct link_device *dev) |
| void | nav_rotorcraft_init (void) |
| Init and register nav functions. | |
Variables | |
| struct NavBase_t | nav_rotorcraft_base |
| Basic Nav struct. | |
Definition in file nav_rotorcraft_base.c.
| #define LINE_START_FUNCTION {} |
Navigation along a figure O.
One side leg is defined by waypoints [p1] and [p2]. The navigation goes through 4 states: OC1 (half circle next to [p1]), OR21 (route [p2] to [p1], OC2 (half circle next to [p2]) and OR12 (opposite leg). Initial state is the route along the desired segment (OC2).
Definition at line 164 of file nav_rotorcraft_base.c.
| #define LINE_STOP_FUNCTION {} |
Definition at line 167 of file nav_rotorcraft_base.c.
|
static |
Definition at line 170 of file nav_rotorcraft_base.c.
References nav_rotorcraft_base, and OC2.
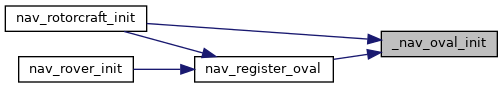
Referenced by nav_register_oval(), nav_rotorcraft_init(), and nav_rover_init().
|
static |
Definition at line 73 of file nav_rotorcraft_base.c.
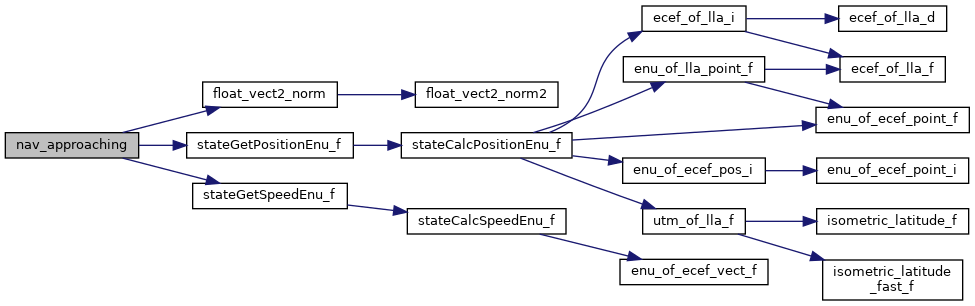
References ARRIVED_AT_WAYPOINT, float_vect2_norm(), stateGetPositionEnu_f(), stateGetSpeedEnu_f(), VECT2_DIFF, VECT2_SMUL, VECT2_SUM, FloatVect2::x, and FloatVect2::y.
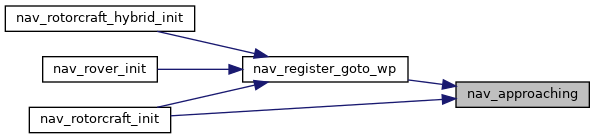
Referenced by nav_register_goto_wp(), nav_register_goto_wp(), nav_rotorcraft_init(), and nav_rover_init().
|
static |
Definition at line 114 of file nav_rotorcraft_base.c.
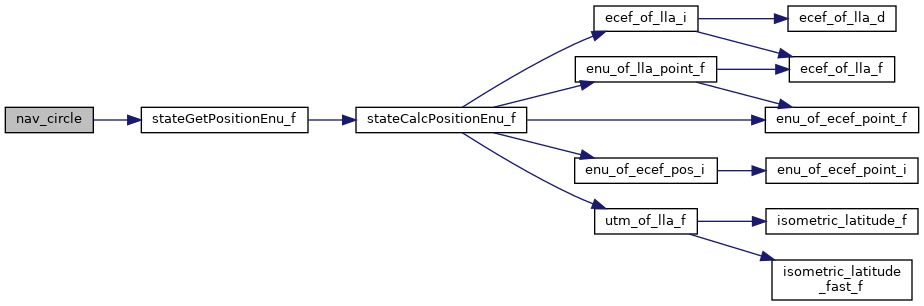
References Min, nav, NAV_CARROT_DIST, NAV_HORIZONTAL_MODE_CIRCLE, nav_rotorcraft_base, NAV_SETPOINT_MODE_POS, pos_diff, stateGetPositionEnu_f(), VECT2_ASSIGN, VECT2_COPY, VECT2_DIFF, and VECT2_SUM.
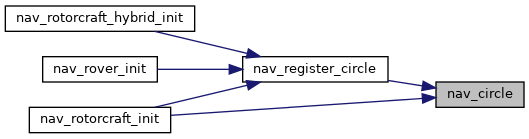
Referenced by nav_register_circle(), nav_register_circle(), nav_rotorcraft_init(), and nav_rover_init().
|
static |
Definition at line 41 of file nav_rotorcraft_base.c.
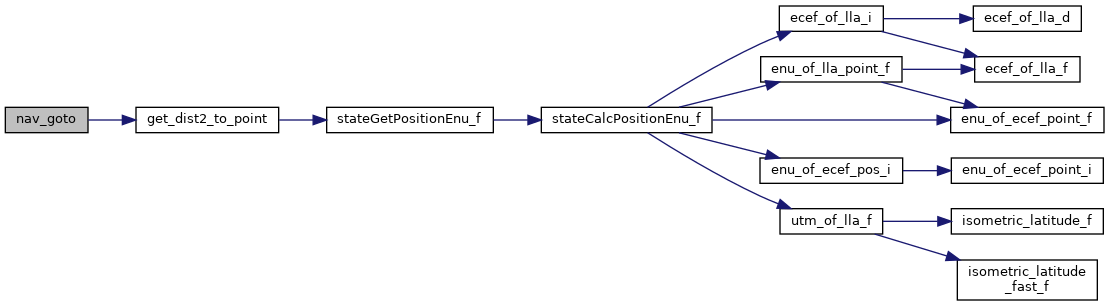
References get_dist2_to_point(), nav, NAV_HORIZONTAL_MODE_WAYPOINT, nav_rotorcraft_base, NAV_SETPOINT_MODE_POS, and VECT2_COPY.
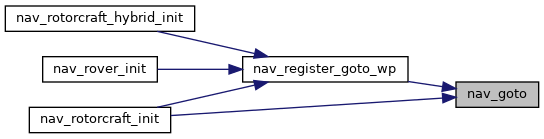
Referenced by nav_register_goto_wp(), nav_register_goto_wp(), nav_rotorcraft_init(), and nav_rover_init().
Definition at line 176 of file nav_rotorcraft_base.c.
References CARROT, dir, float_vect2_normalize(), InitStage, LINE_START_FUNCTION, LINE_STOP_FUNCTION, nav, nav_rotorcraft_base, NavQdrCloseTo, OC1, OC2, OR12, OR21, VECT2_DIFF, EnuCoor_f::x, EnuCoor_f::y, and EnuCoor_f::z.
| void nav_rotorcraft_init | ( | void | ) |
Init and register nav functions.
Definition at line 302 of file nav_rotorcraft_base.c.
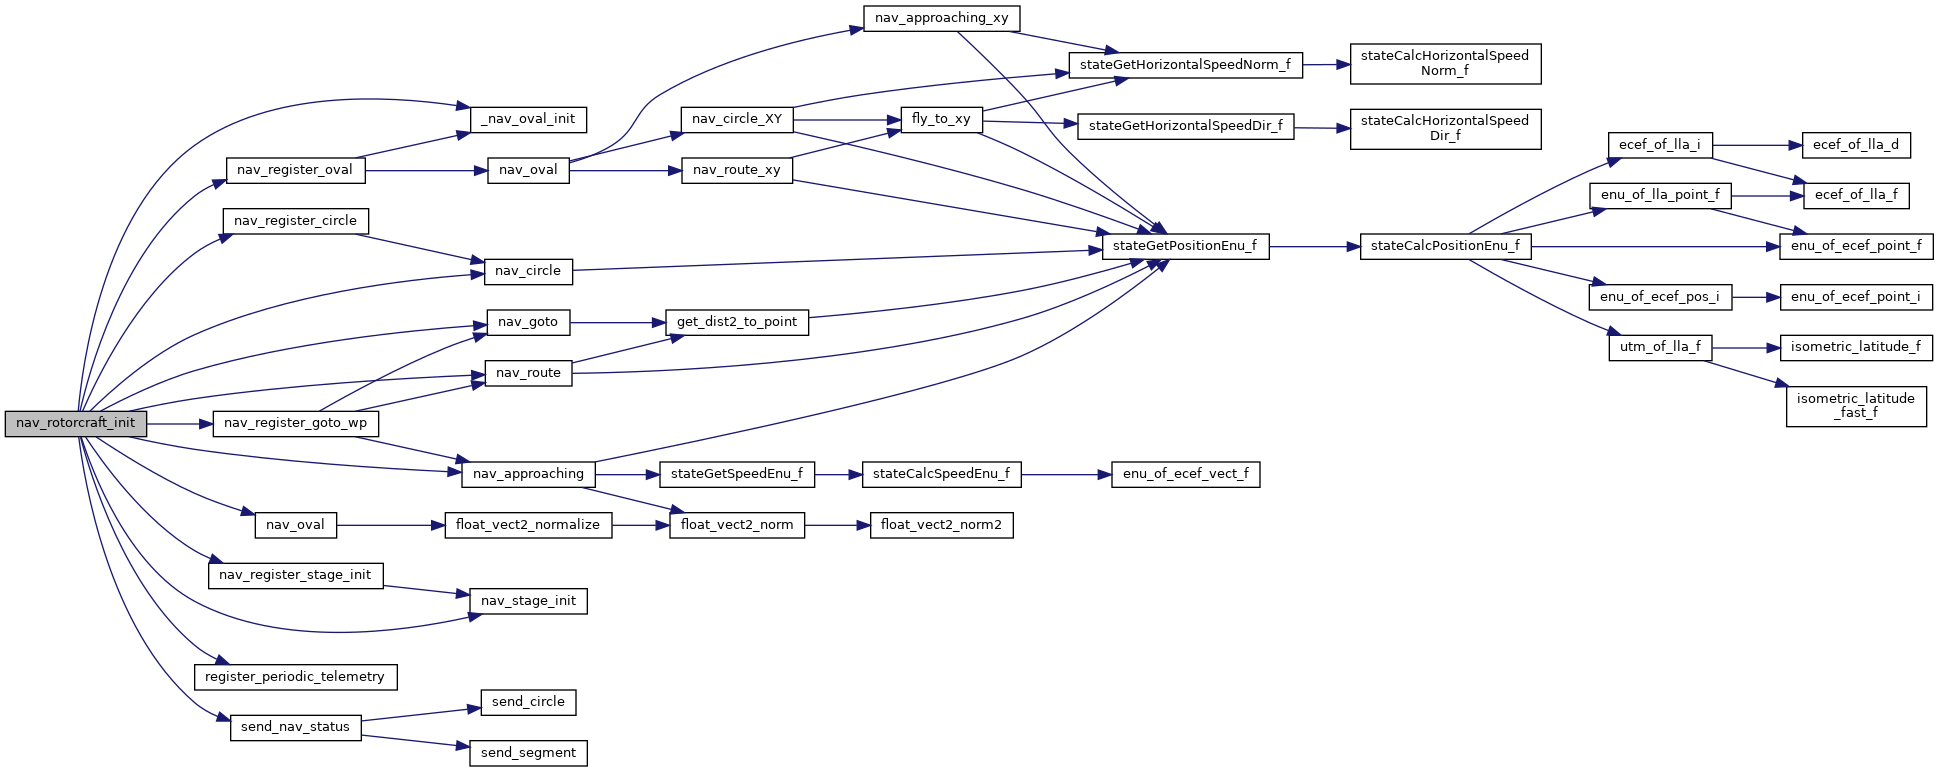
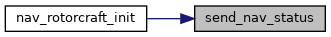
References _nav_oval_init(), DEFAULT_CIRCLE_RADIUS, DefaultPeriodic, nav_approaching(), nav_circle(), nav_goto(), nav_oval(), nav_register_circle(), nav_register_goto_wp(), nav_register_oval(), nav_register_stage_init(), nav_rotorcraft_base, nav_route(), nav_stage_init(), register_periodic_telemetry(), and send_nav_status().
Definition at line 50 of file nav_rotorcraft_base.c.
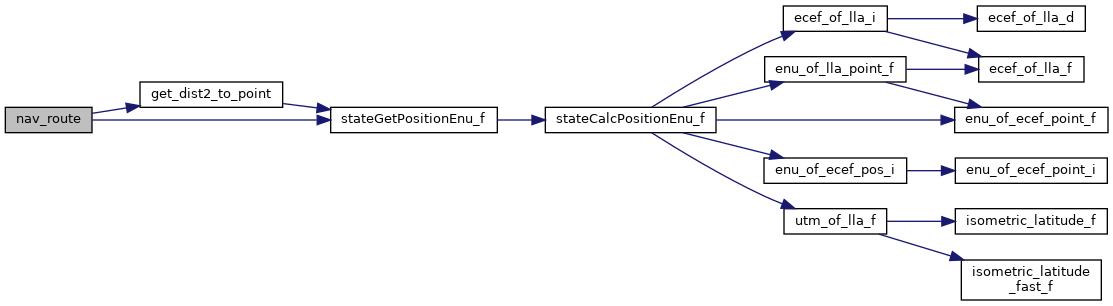
References get_dist2_to_point(), nav, NAV_CARROT_DIST, NAV_HORIZONTAL_MODE_ROUTE, nav_rotorcraft_base, NAV_SETPOINT_MODE_POS, pos_diff, stateGetPositionEnu_f(), VECT2_DIFF, VECT2_SMUL, VECT2_SUM, FloatVect2::x, and FloatVect2::y.
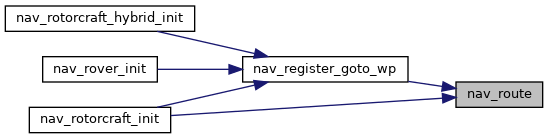
Referenced by nav_register_goto_wp(), nav_register_goto_wp(), nav_rotorcraft_init(), and nav_rover_init().
|
static |
Implement basic nav function.
Definition at line 35 of file nav_rotorcraft_base.c.
References nav_rotorcraft_base.
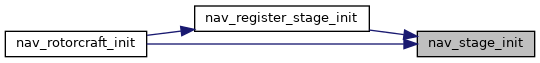
Referenced by nav_register_stage_init(), nav_register_stage_init(), nav_rotorcraft_init(), and nav_rover_init().
|
static |
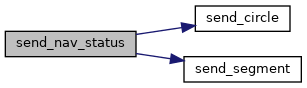
Definition at line 281 of file nav_rotorcraft_base.c.
References block_time, dev, nav, nav_block, NAV_HORIZONTAL_MODE_CIRCLE, NAV_HORIZONTAL_MODE_ROUTE, nav_rotorcraft_base, nav_stage, send_circle(), send_segment(), and stage_time.
Referenced by nav_rotorcraft_init(), and nav_rover_init().
| struct NavBase_t nav_rotorcraft_base |
Basic Nav struct.
Definition at line 31 of file nav_rotorcraft_base.c.
Referenced by _nav_oval_init(), airspeed_consistency_periodic(), nav_circle(), nav_goto(), nav_hybrid_circle(), nav_hybrid_goto(), nav_hybrid_route(), nav_oval(), nav_rotorcraft_hybrid_init(), nav_rotorcraft_init(), nav_route(), nav_stage_init(), and send_nav_status().
 1.15.0