|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
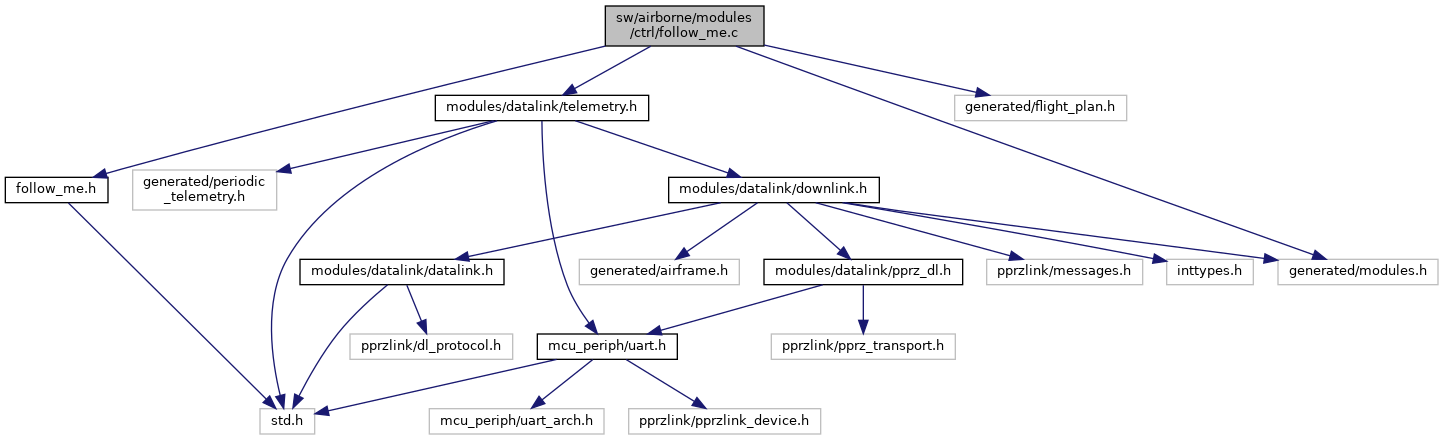
#include "follow_me.h"#include "modules/datalink/telemetry.h"#include "generated/modules.h"#include "generated/flight_plan.h"Go to the source code of this file.
Macros | |
| #define | FOLLOW_ME_DISTANCE 45 |
| #define | FOLLOW_ME_HEIGHT 60 |
| #define | FOLLOW_ME_GPS_TIMEOUT 5000 |
| #define | FOLLOW_ME_GROUND_TIMEOUT 5000 |
| #define | FOLLOW_ME_FILT 0.9 |
| #define | FOLLOW_ME_MOVING_WPS |
Functions | |
| void | follow_me_init (void) |
| init function | |
| void | follow_me_periodic (void) |
| periodic function | |
| void | follow_me_parse_target_pos (uint8_t *buf) |
| on receiving a TARGET_POS message | |
| void | follow_me_set_wp (uint8_t wp_id, float speed) |
| run function | |
Variables | |
| float | follow_me_distance = FOLLOW_ME_DISTANCE |
| distance from the ground gps | |
| float | follow_me_height = FOLLOW_ME_HEIGHT |
| height from the ground gps | |
| float | follow_me_heading = 180. |
| heading direction in which to hover from (automatically set if ground is exceeding speed) | |
| float | follow_me_filt = FOLLOW_ME_FILT |
| Follow me course sin/cos filter value (higher is harder filter). | |
| float | follow_me_diag_speed = 1.0 |
| Diagonal speed for follow me. | |
| float | follow_me_gps_delay = 200 |
| Follow me GPS delay from the relative positionb packet (in ms). | |
| float | follow_me_datalink_delay = 600 |
| Follow me datalink delay from the ground GPS packet (in ms). | |
| float | follow_me_advance_ms = 800 |
| Follow me waypoint advance time in ms (multiplied by the ground speed). | |
| float | follow_me_min_dist = 1 |
| Follow me minimum distance in meters when trying to approach with a certain speed. | |
| float | follow_me_min_height = 30 |
| Follow me minimum height in meters when approaching with a speed. | |
| static uint32_t | ground_time_msec = 0 |
| static bool | ground_set = false |
| static struct LlaCoor_i | ground_lla |
| static float | ground_speed |
| static float | ground_climb |
| static float | ground_course |
| static float | ground_heading |
| static uint8_t | moving_wps [] = {FOLLOW_ME_MOVING_WPS} |
| static uint8_t | moving_wps_cnt = 0 |
| static struct EnuCoor_f | last_targetpos |
| static float | last_targetpos_heading |
| static bool | last_targetpos_valid = false |
Definition in file follow_me.c.
| #define FOLLOW_ME_DISTANCE 45 |
Definition at line 34 of file follow_me.c.
Referenced by follow_me_set_wp().
| #define FOLLOW_ME_FILT 0.9 |
Definition at line 54 of file follow_me.c.
| #define FOLLOW_ME_GPS_TIMEOUT 5000 |
Definition at line 44 of file follow_me.c.
| #define FOLLOW_ME_GROUND_TIMEOUT 5000 |
Definition at line 49 of file follow_me.c.
Referenced by follow_me_set_wp().
| #define FOLLOW_ME_HEIGHT 60 |
Definition at line 39 of file follow_me.c.
Referenced by follow_me_set_wp().
| #define FOLLOW_ME_MOVING_WPS |
Definition at line 59 of file follow_me.c.
| void follow_me_init | ( | void | ) |
init function
Definition at line 87 of file follow_me.c.
References ground_set, ground_time_msec, last_targetpos_valid, moving_wps, and moving_wps_cnt.
| void follow_me_parse_target_pos | ( | uint8_t * | buf | ) |
on receiving a TARGET_POS message
Definition at line 147 of file follow_me.c.
References get_sys_time_msec(), ground_climb, ground_course, ground_heading, ground_lla, ground_set, ground_speed, and ground_time_msec.
| void follow_me_periodic | ( | void | ) |
periodic function
Definition at line 95 of file follow_me.c.
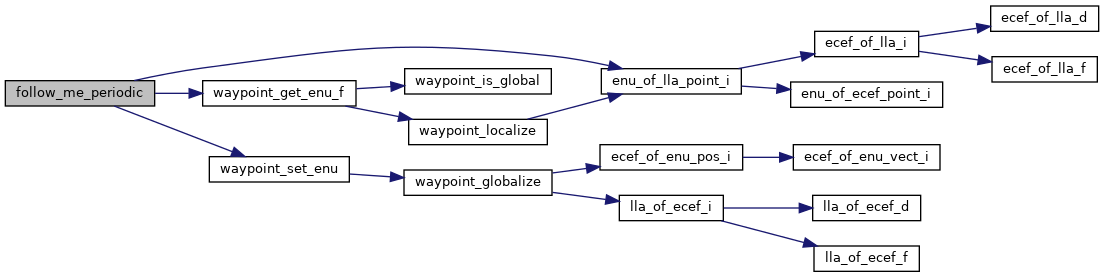
References DefaultChannel, DefaultDevice, enu_of_lla_point_i(), ground_heading, ground_lla, ground_set, last_targetpos, last_targetpos_heading, last_targetpos_valid, moving_wps, moving_wps_cnt, stateGetNedOrigin_i(), VECT3_COPY, VECT3_DIFF, VECT3_FLOAT_OF_CM, waypoint_get_enu_f(), waypoint_set_enu(), waypoints, EnuCoor_f::x, EnuCoor_f::y, and EnuCoor_f::z.
| void follow_me_set_wp | ( | uint8_t | wp_id, |
| float | speed ) |
run function
should be called in a flight plan stay block using pre_call will only set the x and y position and not the height
ex: <block name="Track Object"> <stay wp="STDBY" pre_call="object_tracking_run(WP_STDBY)"> </block>
Definition at line 170 of file follow_me.c.
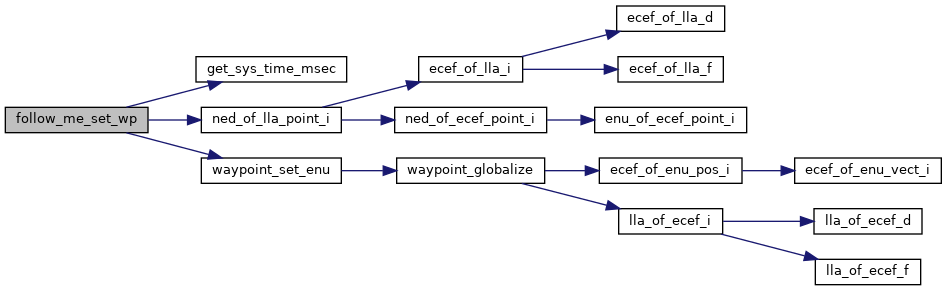
References DefaultChannel, DefaultDevice, ENU_OF_TO_NED, follow_me_advance_ms, follow_me_datalink_delay, FOLLOW_ME_DISTANCE, follow_me_distance, follow_me_filt, FOLLOW_ME_GROUND_TIMEOUT, follow_me_heading, FOLLOW_ME_HEIGHT, follow_me_height, follow_me_min_dist, follow_me_min_height, get_sys_time_msec(), ground_course, ground_heading, ground_lla, ground_set, ground_speed, ground_time_msec, ned_of_lla_point_i(), state, stateGetNedOrigin_i(), waypoint_set_enu(), waypoints, NedCoor_f::x, NedCoor_i::x, NedCoor_f::y, NedCoor_i::y, NedCoor_f::z, and NedCoor_i::z.
| float follow_me_advance_ms = 800 |
Follow me waypoint advance time in ms (multiplied by the ground speed).
Definition at line 69 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_datalink_delay = 600 |
Follow me datalink delay from the ground GPS packet (in ms).
Definition at line 68 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_diag_speed = 1.0 |
Diagonal speed for follow me.
Definition at line 66 of file follow_me.c.
| float follow_me_distance = FOLLOW_ME_DISTANCE |
distance from the ground gps
Definition at line 62 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_filt = FOLLOW_ME_FILT |
Follow me course sin/cos filter value (higher is harder filter).
Definition at line 65 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_gps_delay = 200 |
Follow me GPS delay from the relative positionb packet (in ms).
Definition at line 67 of file follow_me.c.
| float follow_me_heading = 180. |
heading direction in which to hover from (automatically set if ground is exceeding speed)
Definition at line 64 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_height = FOLLOW_ME_HEIGHT |
height from the ground gps
Definition at line 63 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_min_dist = 1 |
Follow me minimum distance in meters when trying to approach with a certain speed.
Definition at line 70 of file follow_me.c.
Referenced by follow_me_set_wp().
| float follow_me_min_height = 30 |
Follow me minimum height in meters when approaching with a speed.
Definition at line 71 of file follow_me.c.
Referenced by follow_me_set_wp().
|
static |
Definition at line 77 of file follow_me.c.
Referenced by follow_me_parse_target_pos().
|
static |
Definition at line 78 of file follow_me.c.
Referenced by follow_me_parse_target_pos(), and follow_me_set_wp().
|
static |
Definition at line 79 of file follow_me.c.
Referenced by follow_me_parse_target_pos(), follow_me_periodic(), and follow_me_set_wp().
|
static |
Definition at line 75 of file follow_me.c.
Referenced by follow_me_parse_target_pos(), follow_me_periodic(), and follow_me_set_wp().
|
static |
Definition at line 74 of file follow_me.c.
Referenced by follow_me_init(), follow_me_parse_target_pos(), follow_me_periodic(), and follow_me_set_wp().
|
static |
Definition at line 76 of file follow_me.c.
Referenced by follow_me_parse_target_pos(), follow_me_set_wp(), gvf_low_level_control_2D(), gvf_low_level_control_3D(), gvf_low_level_getState(), gvf_parametric_control_2D(), and snav_on_time().
|
static |
Definition at line 73 of file follow_me.c.
Referenced by follow_me_init(), follow_me_parse_target_pos(), and follow_me_set_wp().
|
static |
Definition at line 83 of file follow_me.c.
Referenced by follow_me_periodic().
|
static |
Definition at line 84 of file follow_me.c.
Referenced by follow_me_periodic().
|
static |
Definition at line 85 of file follow_me.c.
Referenced by follow_me_init(), and follow_me_periodic().
|
static |
Definition at line 81 of file follow_me.c.
Referenced by follow_me_init(), and follow_me_periodic().
|
static |
Definition at line 82 of file follow_me.c.
Referenced by follow_me_init(), and follow_me_periodic().
 1.15.0