|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
MAVLab Delft University of Technology This control algorithm is Incremental Nonlinear Dynamic Inversion (INDI). More...
Go to the source code of this file.
Functions | |
| void | stabilization_attitude_enter (void) |
| Attitude control enter function. | |
| void | stabilization_attitude_run (bool in_flight, struct StabilizationSetpoint *sp, struct ThrustSetpoint *thrust, int32_t *cmd) |
| Attitude control run function. | |
MAVLab Delft University of Technology This control algorithm is Incremental Nonlinear Dynamic Inversion (INDI).
This is an implementation of the publication in the journal of Control Guidance and Dynamics: Adaptive Incremental Nonlinear Dynamic Inversion for Attitude Control of Micro Aerial Vehicles
This is an implementation of the publication in the journal of Control Guidance and Dynamics: Adaptive Incremental Nonlinear Dynamic Inversion for Attitude Control of Micro Aerial Vehicles http://arc.aiaa.org/doi/pdf/10.2514/1.G001490
Definition in file stabilization_attitude_quat_indi.c.
| void stabilization_attitude_enter | ( | void | ) |
Attitude control enter function.
Definition at line 35 of file stabilization_attitude_quat_indi.c.
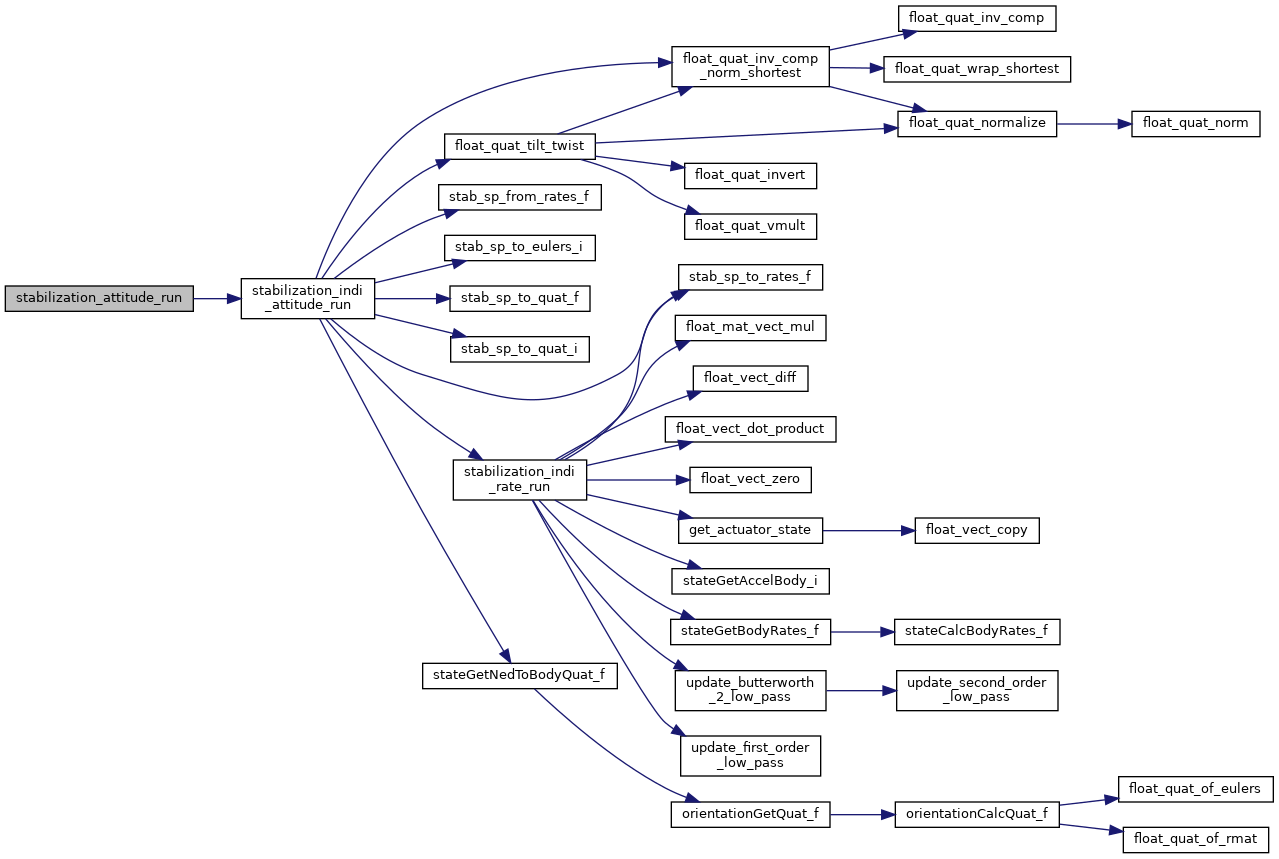
References stabilization_indi_enter().
| void stabilization_attitude_run | ( | bool | in_flight, |
| struct StabilizationSetpoint * | sp, | ||
| struct ThrustSetpoint * | thrust, | ||
| int32_t * | cmd ) |
Attitude control run function.
| [in] | in_flight | true if in flight |
| [in] | sp | pointer to the stabilization setpoint structure |
| [in] | thrust | pointer to the thrust setoint structure |
| [out] | cmd | pointer to the output command vector |
Definition at line 40 of file stabilization_attitude_quat_indi.c.
References stabilization_indi_attitude_run().
 1.15.0