|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
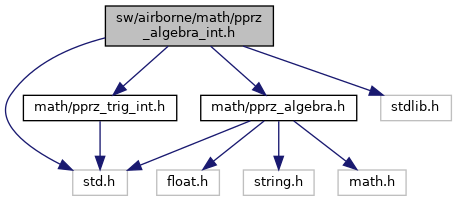
Paparazzi fixed point algebra. More...
Go to the source code of this file.
Data Structures | |
| struct | Uint8Vect3 |
| struct | Int8Vect3 |
| struct | Uint16Vect3 |
| struct | Int16Vect3 |
| struct | Int32Vect2 |
| struct | Int32Vect3 |
| struct | Int32Quat |
| Rotation quaternion. More... | |
| struct | Int64Quat |
| struct | Int16Eulers |
| struct | Int32Eulers |
| euler angles More... | |
| struct | Int32RMat |
| rotation matrix More... | |
| struct | Int32Mat33 |
| struct | Int16Rates |
| struct | Int32Rates |
| angular rates More... | |
| struct | Int64Rates |
| struct | Int64Vect2 |
| struct | Int64Vect3 |
Macros | |
| #define | INT32_POS_FRAC 8 |
| #define | INT32_POS_OF_CM 2.56 |
| #define | INT32_POS_OF_CM_NUM 64 |
| #define | INT32_POS_OF_CM_DEN 25 |
| #define | INT32_SPEED_FRAC 19 |
| #define | INT32_SPEED_OF_CM_S 5242.88 |
| #define | INT32_SPEED_OF_CM_S_NUM 41943 |
| #define | INT32_SPEED_OF_CM_S_DEN 8 |
| #define | INT32_ACCEL_FRAC 10 |
| #define | INT32_MAG_FRAC 11 |
| #define | INT32_PERCENTAGE_FRAC 10 |
| #define | INT32_QUAT_FRAC 15 |
| #define | INT32_ANGLE_FRAC 12 |
| #define | INT32_RATE_FRAC 12 |
| #define | INT32_ANGLE_PI_4 (int32_t)ANGLE_BFP_OF_REAL( 0.7853981633974483096156608458198757) |
| #define | INT32_ANGLE_PI_2 (int32_t)ANGLE_BFP_OF_REAL( 1.5707963267948966192313216916397514) |
| #define | INT32_ANGLE_PI (int32_t)ANGLE_BFP_OF_REAL( 3.1415926535897932384626433832795029) |
| #define | INT32_ANGLE_2_PI (int32_t)ANGLE_BFP_OF_REAL(2.*3.1415926535897932384626433832795029) |
| #define | INT32_RAD_OF_DEG(_deg) |
| #define | INT32_DEG_OF_RAD(_rad) |
| #define | INT32_ANGLE_NORMALIZE(_a) |
| #define | INT32_COURSE_NORMALIZE(_a) |
| #define | INT32_TRIG_FRAC 14 |
| #define | LBFP_OF_REAL(_vr, _frac) |
| #define | BFP_OF_REAL(_vr, _frac) |
| #define | FLOAT_OF_BFP(_vbfp, _frac) |
| #define | DOUBLE_OF_BFP(_vbfp, _frac) |
| #define | RATE_BFP_OF_REAL(_af) |
| #define | RATE_FLOAT_OF_BFP(_ai) |
| #define | ANGLE_BFP_OF_REAL(_af) |
| #define | ANGLE_FLOAT_OF_BFP(_ai) |
| #define | QUAT1_BFP_OF_REAL(_qf) |
| #define | QUAT1_FLOAT_OF_BFP(_qi) |
| #define | TRIG_BFP_OF_REAL(_tf) |
| #define | TRIG_FLOAT_OF_BFP(_ti) |
| #define | POS_BFP_OF_REAL(_af) |
| #define | POS_FLOAT_OF_BFP(_ai) |
| #define | SPEED_BFP_OF_REAL(_af) |
| #define | SPEED_FLOAT_OF_BFP(_ai) |
| #define | ACCEL_BFP_OF_REAL(_af) |
| #define | ACCEL_FLOAT_OF_BFP(_ai) |
| #define | MAG_BFP_OF_REAL(_af) |
| #define | MAG_FLOAT_OF_BFP(_ai) |
| #define | INT_MULT_RSHIFT(_a, _b, _r) |
| #define | INT32_SQRT(_out, _in) |
| #define | INT_VECT2_ZERO(_v) |
| #define | INT32_VECT2_NORM(_v) |
| #define | INT32_VECT2_NORMALIZE(_v, _frac) |
| #define | INT32_VECT2_RSHIFT(_o, _i, _r) |
| #define | INT32_VECT2_LSHIFT(_o, _i, _l) |
| #define | INT32_VECT2_SCALE_2(_a, _b, _num, _den) |
| #define | INT_VECT3_ZERO(_v) |
| #define | INT32_VECT3_ZERO(_v) |
| #define | INT32_VECT3_SCALE_2(_a, _b, _num, _den) |
| #define | INT32_VECT3_NORM(_v) |
| #define | INT32_VECT3_RSHIFT(_o, _i, _r) |
| #define | INT32_VECT3_LSHIFT(_o, _i, _l) |
| #define | INT32_MAT33_ZERO(_m) |
| #define | INT32_MAT33_DIAG(_m, _d00, _d11, _d22) |
| #define | int32_rmat_of_eulers int32_rmat_of_eulers_321 |
| Rotation matrix from Euler angles. | |
| #define | INT32_RMAT_COMP(_m_a2c, _m_a2b, _m_b2c) |
| #define | INT32_RMAT_COMP_INV(_m_a2b, _m_a2c, _m_b2c) |
| #define | INT32_RMAT_VMULT(_vb, _m_a2b, _va) |
| #define | INT32_RMAT_TRANSP_VMULT(_vb, _m_b2a, _va) |
| #define | INT32_RMAT_RATEMULT(_rb, _m_a2b, _ra) |
| #define | INT32_RMAT_TRANSP_RATEMULT(_rb, _m_b2a, _ra) |
| #define | INT32_RMAT_OF_QUAT(_rm, _q) |
| #define | INT32_RMAT_OF_EULERS(_rm, _e) |
| #define | INT32_RMAT_OF_EULERS_321(_rm, _e) |
| #define | INT32_RMAT_OF_EULERS_312(_rm, _e) |
| #define | INT32_QUAT_ZERO(_q) |
| #define | INT32_QUAT_NORM(n, q) |
| #define | INT32_QUAT_WRAP_SHORTEST(q) |
| #define | INT32_QUAT_NORMALIZE(q) |
| #define | INT32_QUAT_COMP(_a2c, _a2b, _b2c) |
| #define | INT32_QUAT_COMP_INV(_a2b, _a2c, _b2c) |
| #define | INT32_QUAT_INV_COMP(_b2c, _a2b, _a2c) |
| #define | INT32_QUAT_COMP_NORM_SHORTEST(_a2c, _a2b, _b2c) |
| #define | INT32_QUAT_INV_COMP_NORM_SHORTEST(_b2c, _a2b, _a2c) |
| #define | INT32_QUAT_DERIVATIVE(_qd, _r, _q) |
| #define | INT32_QUAT_INTEGRATE_FI(_q, _hr, _omega, _f) |
| #define | INT32_QUAT_VMULT(v_out, q, v_in) |
| #define | INT32_QUAT_OF_EULERS(_q, _e) |
| #define | INT32_QUAT_OF_AXIS_ANGLE(_q, _uv, _an) |
| #define | INT32_QUAT_OF_RMAT(_q, _r) |
| #define | INT_EULERS_ZERO(_e) |
| #define | INT32_EULERS_OF_RMAT(_e, _rm) |
| #define | INT32_EULERS_OF_QUAT(_e, _q) |
| #define | INT32_EULERS_LSHIFT(_o, _i, _r) |
| #define | INT32_EULERS_RSHIFT(_o, _i, _r) |
| #define | INT_RATES_ZERO(_e) |
| #define | INT_RATES_RSHIFT(_o, _i, _r) |
| #define | INT_RATES_LSHIFT(_o, _i, _r) |
| #define | int32_eulers_dot_of_rates int32_eulers_dot_321_of_rates |
| #define | INT32_RATES_OF_EULERS_DOT_321(_r, _e, _ed) |
| #define | INT32_RATES_OF_EULERS_DOT(_r, _e, _ed) |
| #define | INT32_EULERS_DOT_321_OF_RATES(_ed, _e, _r) |
| #define | INT32_EULERS_DOT_OF_RATES(_ed, _e, _r) |
Functions | |
| uint32_t | int32_sqrt (uint32_t in) |
| uint32_t | int32_gcd (uint32_t a, uint32_t b) |
| static uint32_t | int32_vect2_norm2 (struct Int32Vect2 *v) |
| return squared norm of 2D vector | |
| static uint32_t | int32_vect2_norm (struct Int32Vect2 *v) |
| return norm of 2D vector | |
| static void | int32_vect2_normalize (struct Int32Vect2 *v, uint8_t frac) |
| normalize 2D vector inplace | |
| static void | int32_rmat_identity (struct Int32RMat *rm) |
| initialises a rotation matrix to identity | |
| void | int32_rmat_comp (struct Int32RMat *m_a2c, const struct Int32RMat *m_a2b, const struct Int32RMat *m_b2c) |
| Composition (multiplication) of two rotation matrices. | |
| void | int32_rmat_comp_inv (struct Int32RMat *m_a2b, const struct Int32RMat *m_a2c, const struct Int32RMat *m_b2c) |
| Composition (multiplication) of two rotation matrices. | |
| void | int32_rmat_vmult (struct Int32Vect3 *vb, struct Int32RMat *m_a2b, struct Int32Vect3 *va) |
| rotate 3D vector by rotation matrix. | |
| void | int32_rmat_transp_vmult (struct Int32Vect3 *vb, struct Int32RMat *m_b2a, struct Int32Vect3 *va) |
| rotate 3D vector by transposed rotation matrix. | |
| void | int32_rmat_ratemult (struct Int32Rates *rb, struct Int32RMat *m_a2b, struct Int32Rates *ra) |
| rotate anglular rates by rotation matrix. | |
| void | int32_rmat_transp_ratemult (struct Int32Rates *rb, struct Int32RMat *m_b2a, struct Int32Rates *ra) |
| rotate anglular rates by transposed rotation matrix. | |
| void | int32_rmat_of_quat (struct Int32RMat *rm, struct Int32Quat *q) |
| Convert unit quaternion to rotation matrix. | |
| void | int32_rmat_of_eulers_321 (struct Int32RMat *rm, struct Int32Eulers *e) |
| Rotation matrix from 321 Euler angles (int). | |
| void | int32_rmat_of_eulers_312 (struct Int32RMat *rm, struct Int32Eulers *e) |
| Rotation matrix from 312 Euler angles. | |
| static void | int32_quat_identity (struct Int32Quat *q) |
| initialises a quaternion to identity | |
| static uint32_t | int32_quat_norm (struct Int32Quat *q) |
| Norm of a quaternion. | |
| static void | int32_quat_wrap_shortest (struct Int32Quat *q) |
| static void | int32_quat_normalize (struct Int32Quat *q) |
| normalize a quaternion inplace | |
| void | int32_quat_comp (struct Int32Quat *a2c, struct Int32Quat *a2b, struct Int32Quat *b2c) |
| Composition (multiplication) of two quaternions. | |
| void | int32_quat_comp_inv (struct Int32Quat *a2b, struct Int32Quat *a2c, struct Int32Quat *b2c) |
| Composition (multiplication) of two quaternions. | |
| void | int32_quat_inv_comp (struct Int32Quat *b2c, struct Int32Quat *a2b, struct Int32Quat *a2c) |
| Composition (multiplication) of two quaternions. | |
| void | int32_quat_comp_norm_shortest (struct Int32Quat *a2c, struct Int32Quat *a2b, struct Int32Quat *b2c) |
| Composition (multiplication) of two quaternions with normalization. | |
| void | int32_quat_comp_inv_norm_shortest (struct Int32Quat *a2b, struct Int32Quat *a2c, struct Int32Quat *b2c) |
| Composition (multiplication) of two quaternions with normalization. | |
| void | int32_quat_inv_comp_norm_shortest (struct Int32Quat *b2c, struct Int32Quat *a2b, struct Int32Quat *a2c) |
| Composition (multiplication) of two quaternions with normalization. | |
| void | int32_quat_derivative (struct Int32Quat *qd, const struct Int32Rates *r, struct Int32Quat *q) |
| Quaternion derivative from rotational velocity. | |
| void | int32_quat_integrate_fi (struct Int32Quat *q, struct Int64Quat *hr, struct Int32Rates *omega, int freq) |
| in place quaternion first order integration with constant rotational velocity. | |
| void | int32_quat_vmult (struct Int32Vect3 *v_out, struct Int32Quat *q, struct Int32Vect3 *v_in) |
| rotate 3D vector by quaternion. | |
| void | int32_quat_of_eulers (struct Int32Quat *q, struct Int32Eulers *e) |
| Quaternion from Euler angles. | |
| void | int32_quat_of_axis_angle (struct Int32Quat *q, struct Int32Vect3 *uv, int32_t angle) |
| Quaternion from unit vector and angle. | |
| void | int32_quat_of_rmat (struct Int32Quat *q, struct Int32RMat *r) |
| Quaternion from rotation matrix. | |
| void | int32_eulers_of_rmat (struct Int32Eulers *e, struct Int32RMat *rm) |
| void | int32_eulers_of_quat (struct Int32Eulers *e, struct Int32Quat *q) |
| void | int32_rates_of_eulers_dot_321 (struct Int32Rates *r, struct Int32Eulers *e, struct Int32Eulers *ed) |
| void | int32_eulers_dot_321_of_rates (struct Int32Eulers *ed, struct Int32Eulers *e, struct Int32Rates *r) |
| static void | int32_vect_zero (int32_t *a, const int n) |
| a = 0 | |
| static void | int16_vect_zero (int16_t *a, const int n) |
| a = 0 | |
| static void | int32_vect_set_value (int32_t *a, const int32_t v, const int n) |
| a = v * ones(n,1) | |
| static void | int32_vect_copy (int32_t *a, const int32_t *b, const int n) |
| a = b | |
| static void | int32_vect_sum (int32_t *o, const int32_t *a, const int32_t *b, const int n) |
| o = a + b | |
| static void | int32_vect_diff (int32_t *o, const int32_t *a, const int32_t *b, const int n) |
| o = a - b | |
| static void | int32_vect_mul (int32_t *o, const int32_t *a, const int32_t *b, const int n) |
| o = a * b (element wise) | |
| static void | int32_vect_add (int32_t *a, const int32_t *b, const int n) |
| a += b | |
| static void | int32_vect_sub (int32_t *a, const int32_t *b, const int n) |
| a -= b | |
| static void | int32_vect_smul (int32_t *o, const int32_t *a, const int32_t s, const int n) |
| o = a * s | |
| static bool | int32_vect_find (const int32_t *a, const int32_t s, int *loc, const int n) |
| Find value s in array a. | |
| static void | int32_mat_mul (int32_t **o, int32_t **a, int32_t **b, int m, int n, int l) |
| o = a * b | |
Paparazzi fixed point algebra.
Definition in file pprz_algebra_int.h.
 1.15.0