|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Smooth navigation to wp_a along an arc (around wp_cd), a segment (from wp_rd to wp_ta) and a second arc (around wp_ca). More...
#include "std.h"Go to the source code of this file.
Functions | |
| bool | snav_init (uint8_t wp_a, float desired_course_rad, float radius) |
| bool | snav_circle1 (void) |
| bool | snav_route (void) |
| bool | snav_circle2 (void) |
| bool | snav_on_time (float radius) |
Variables | |
| float | snav_desired_tow |
Smooth navigation to wp_a along an arc (around wp_cd), a segment (from wp_rd to wp_ta) and a second arc (around wp_ca).
Definition in file nav_smooth.h.
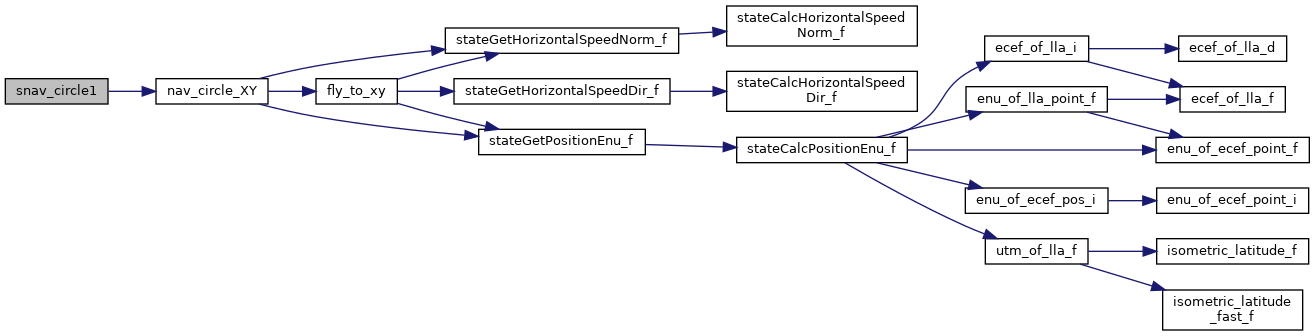
| bool snav_circle1 | ( | void | ) |
Definition at line 121 of file nav_smooth.c.
References d_radius, nav_circle_XY(), NavQdrCloseTo, NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, and qdr_td.
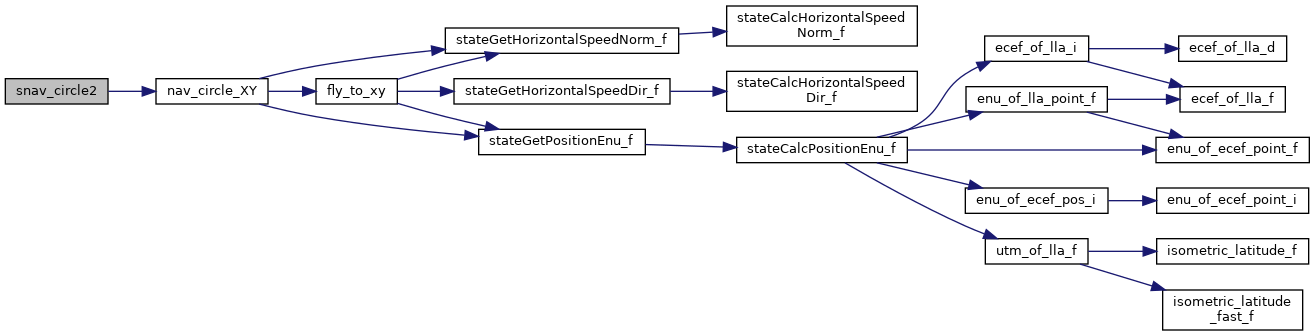
| bool snav_circle2 | ( | void | ) |
Definition at line 140 of file nav_smooth.c.
References a_radius, nav_circle_XY(), NavQdrCloseTo, NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, and qdr_a.
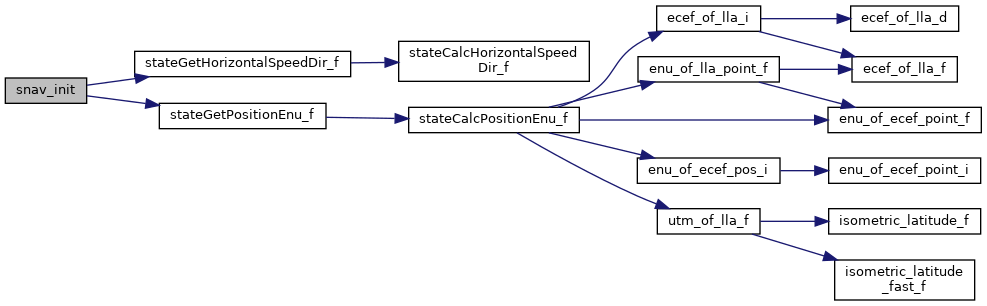
| bool snav_init | ( | uint8_t | wp_a, |
| float | desired_course_rad, | ||
| float | radius ) |
Definition at line 49 of file nav_smooth.c.
References point::a, a_radius, alpha, d_radius, ground_speed_timer, qdr_a, qdr_td, Sign, stateGetHorizontalSpeedDir_f(), stateGetPositionEnu_f(), u_a_ca_x, u_a_ca_y, WaypointAlt, WaypointX, WaypointY, wp_a, wp_ta, EnuCoor_f::x, and EnuCoor_f::y.
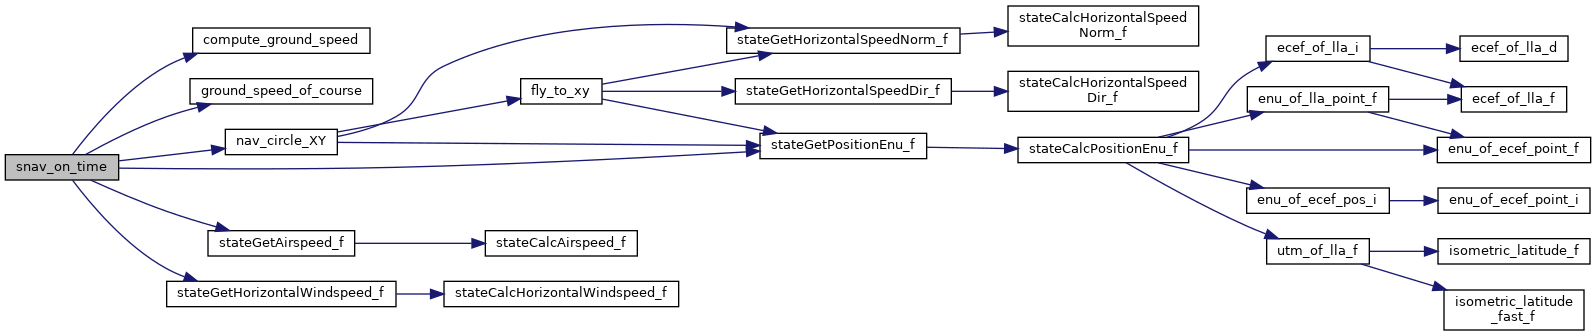
| bool snav_on_time | ( | float | radius | ) |
Definition at line 183 of file nav_smooth.c.
References point::a, a_radius, ANGLE_STEP, compute_ground_speed(), gps, ground_speed, ground_speed_of_course(), ground_speed_timer, nav_circle_XY(), NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, Norm2Pi, qdr_a, Sign, snav_desired_tow, stateGetAirspeed_f(), stateGetHorizontalWindspeed_f(), stateGetPositionEnu_f(), u_a_ca_x, u_a_ca_y, WaypointX, WaypointY, wp_a, point::x, EnuCoor_f::y, and point::y.
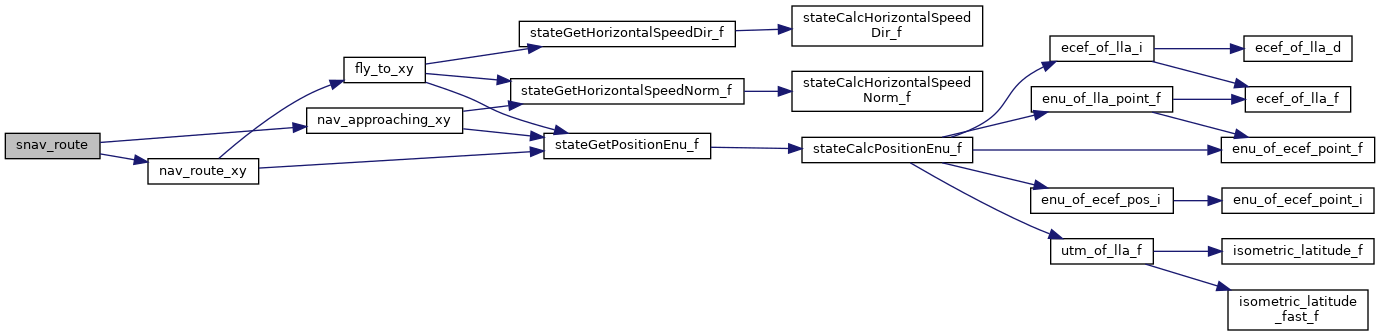
| bool snav_route | ( | void | ) |
Definition at line 130 of file nav_smooth.c.
References CARROT, nav_approaching_xy(), nav_route_xy(), NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, and wp_ta.
|
extern |
Definition at line 44 of file nav_smooth.c.
Referenced by snav_on_time().
 1.15.0