|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Adaptive flower pattern for cloud exploration Can be used in mission mode with custom pattern and ID "RSTT". More...
Go to the source code of this file.
Functions | |
| void | nav_rosette_init (void) |
| Init function called by modules init. | |
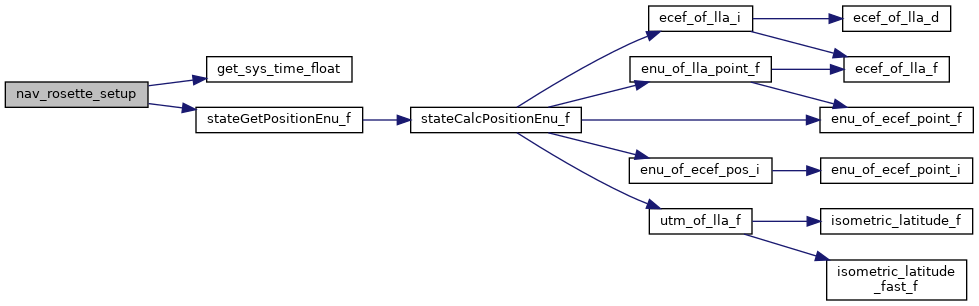
| void | nav_rosette_setup (float init_x, float init_y, float init_z, int turn, float desired_radius, float vx, float vy, float vz) |
| Initialized the exploration with a first target point inside the cloud Called from flight plan or with mission parameters. | |
| bool | nav_rosette_run (void) |
| Navigation function Called by flight plan or mission run function. | |
Adaptive flower pattern for cloud exploration Can be used in mission mode with custom pattern and ID "RSTT".
See: Titouan Verdu, Gautier Hattenberger, Simon Lacroix. Flight patterns for clouds exploration with a fleet of UAVs. 2019 International Conference on Unmanned Aircraft Systems (ICUAS 2019), Jul 2019, Atlanta, United States. https://hal-enac.archives-ouvertes.fr/hal-02137839
Definition in file nav_rosette.h.
|
extern |
Init function called by modules init.
Definition at line 191 of file nav_rosette.c.
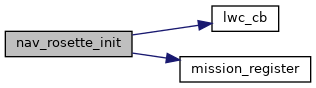
References DEFAULT_CIRCLE_RADIUS, lwc_cb(), lwc_ev, mission_register(), nav_rosette, NAV_ROSETTE_LWC_ID, and RSTT_ENTER.
|
extern |
Navigation function Called by flight plan or mission run function.
Definition at line 233 of file nav_rosette.c.
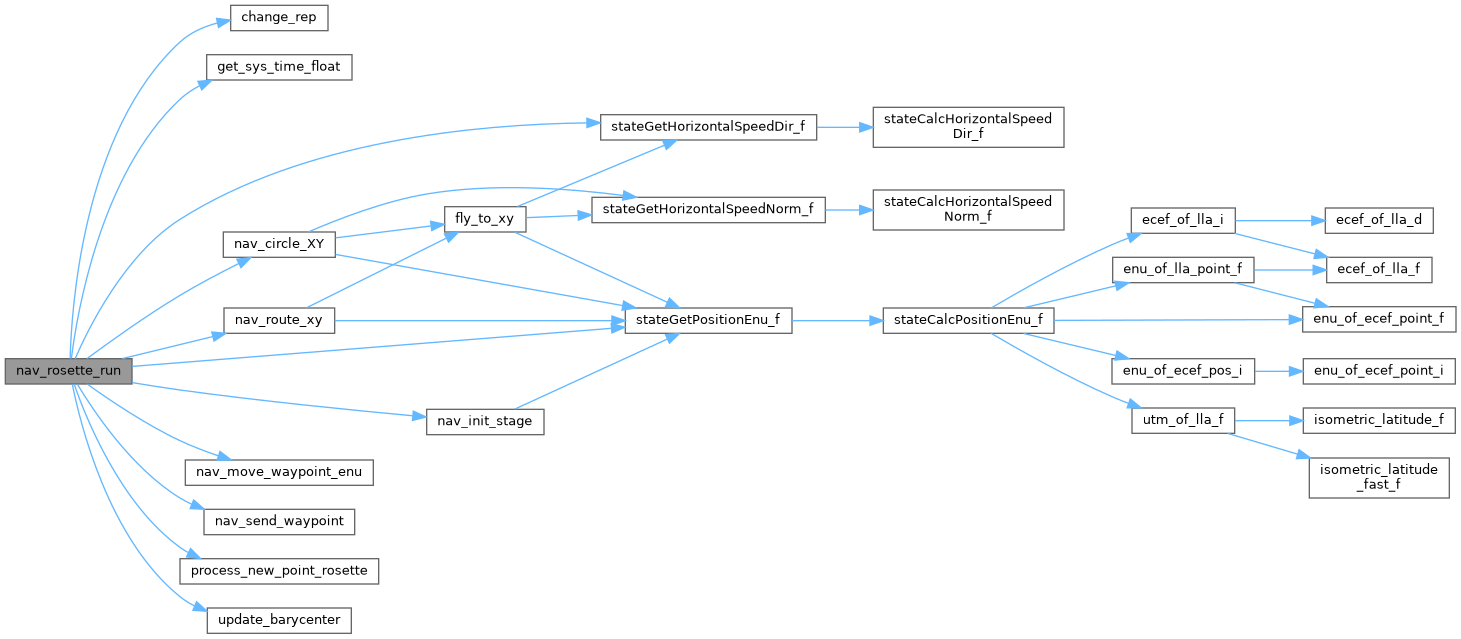
References change_rep(), get_sys_time_float(), ground_alt, nav_circle_XY(), nav_dt, nav_init_stage(), nav_move_waypoint_enu(), nav_rosette, NAV_ROSETTE_BORDER_FILTER, NAV_ROSETTE_RECOVER_MAX_TURN, nav_route_xy(), nav_send_waypoint(), NavCircleCountNoRewind, NavVerticalAltitudeMode, NavVerticalAutoThrottleMode, process_new_point_rosette(), RSTT_CROSSING, RSTT_CROSSING_FIRST, RSTT_CROSSING_START, RSTT_ENTER, RSTT_RECOVER_OUTSIDE, RSTT_RECOVER_START, RSTT_TURNING, RSTT_TURNING_START, stateGetHorizontalSpeedDir_f(), stateGetPositionEnu_f(), update_barycenter(), and VECT3_ADD.
|
extern |
Initialized the exploration with a first target point inside the cloud Called from flight plan or with mission parameters.
Definition at line 207 of file nav_rosette.c.
References get_sys_time_float(), nav_dt, nav_rosette, RSTT_ENTER, RSTT_LEFT, RSTT_RIGHT, stateGetPositionEnu_f(), and VECT3_ASSIGN.
 1.15.0