|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
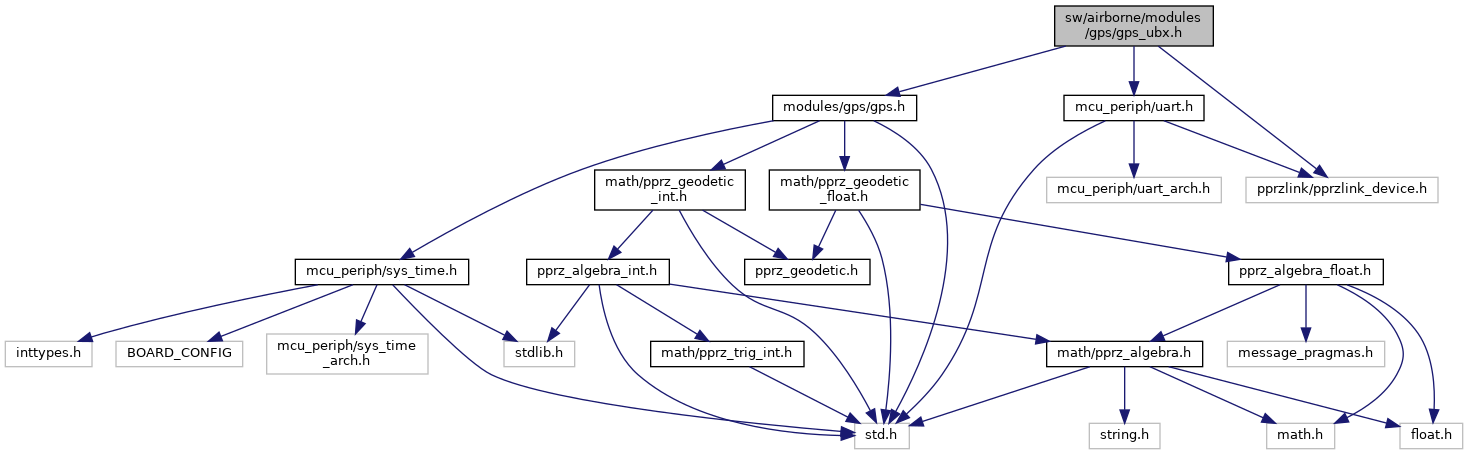
UBX protocol specific code. More...
Go to the source code of this file.
Data Structures | |
| struct | GpsUbx |
Macros | |
| #define | GPS_UBX_NB 1 |
| #define | PRIMARY_GPS GPS_UBX |
| #define | GPS_UBX_NB_CHANNELS 40 |
| #define | GPS_UBX_MAX_PAYLOAD 1024 |
| e.g. UBX-NAV-SAT is 8 + 12 * numSvs bytes | |
Functions | |
| void | gps_ubx_init (void) |
| void | gps_ubx_event (void) |
| void | gps_ubx_parse_HITL_UBX (uint8_t *buf) |
| void | ubx_header (struct link_device *dev, uint8_t nav_id, uint8_t msg_id, uint16_t len) |
| void | ubx_trailer (struct link_device *dev) |
| void | ubx_send_bytes (struct link_device *dev, uint8_t len, uint8_t *bytes) |
| void | ubx_send_cfg_rst (struct link_device *dev, uint16_t bbr, uint8_t reset_mode) |
| void | gps_ubx_periodic_check (void) |
Variables | |
| struct GpsUbx | gps_ubx [GPS_UBX_NB] |
| uint8_t | gps_ubx_reset |
UBX protocol specific code.
Definition in file gps_ubx.h.
| struct GpsUbx |
| Data Fields | ||
|---|---|---|
| uint8_t | ck_a | |
| uint8_t | ck_b | |
| struct link_device * | dev | |
| uint8_t | error_cnt | |
| uint8_t | error_last | |
| uint8_t | gnss_in_use | Satellite systems used in the solution (UBX-NAV-SAT): 1 GPS, 2 GLONASS, 4 BeiDou, 8 Galileo. |
| uint16_t | len | |
| bool | msg_available | |
| uint8_t | msg_buf[GPS_UBX_MAX_PAYLOAD] | |
| uint8_t | msg_class | |
| uint8_t | msg_id | |
| uint16_t | msg_idx | |
| bool | pacc_valid | |
| uint8_t | send_ck_a | |
| uint8_t | send_ck_b | |
| uint8_t | sol_flags | |
| struct GpsState | state | |
| uint8_t | status | |
| uint8_t | status_flags | |
| #define GPS_UBX_MAX_PAYLOAD 1024 |
e.g. UBX-NAV-SAT is 8 + 12 * numSvs bytes
Definition at line 52 of file gps_ubx.h.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_NB 1 |
Definition at line 39 of file gps_ubx.h.
Referenced by gps_ubx_event(), gps_ubx_init(), gps_ubx_periodic_check(), ubx_header(), ubx_send_1byte(), and ubx_trailer().
|
extern |
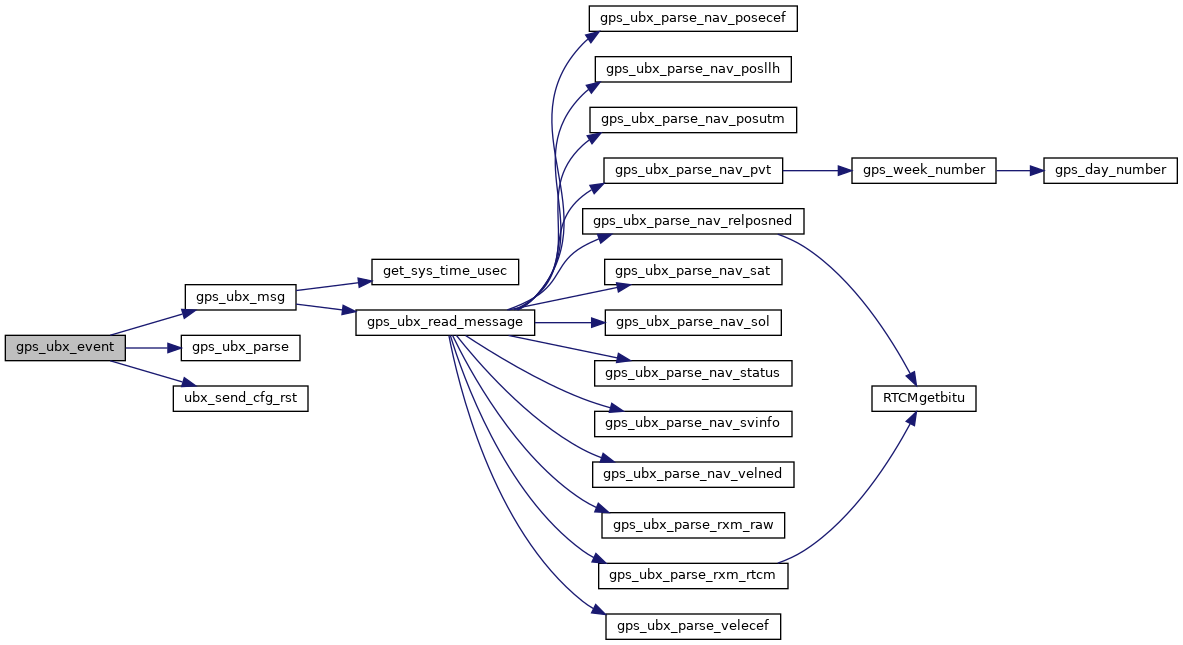
Definition at line 158 of file gps_ubx.c.
References CFG_RST_BBR_Coldstart, CFG_RST_BBR_Hotstart, CFG_RST_BBR_Warmstart, CFG_RST_Reset_Controlled, DEBUG_PRINT, dev, gps_ubx, gps_ubx_msg(), GPS_UBX_NB, gps_ubx_parse(), gps_ubx_reset, and ubx_send_cfg_rst().
|
extern |
Definition at line 136 of file gps_ubx.c.
References gps_ubx, GPS_UBX2_ID, GPS_UBX_BOOTRESET, GPS_UBX_ERR_NONE, GPS_UBX_ID, GPS_UBX_NB, gps_ubx_reset, and UNINIT.
|
extern |
This code simulates gps_ubx.c:parse_ubx()
Definition at line 185 of file gps_ubx.c.
References gps_ubx, and GPS_UBX_ERR_OVERRUN.
|
extern |
Definition at line 797 of file gps_ubx.c.
References gps_periodic_check(), gps_ubx, GPS_UBX_NB, and state.
Definition at line 717 of file gps_ubx.c.
References dev, gps_ubx, GPS_UBX_NB, and ubx_send_1byte().
Definition at line 746 of file gps_ubx.c.
References dev, and ubx_send_1byte().
References dev.
|
extern |
Definition at line 734 of file gps_ubx.c.
References dev, gps_ubx, and GPS_UBX_NB.
|
extern |
Definition at line 97 of file gps_ubx.c.
Referenced by ArduIMU_periodicGPS(), gps_ubx_event(), gps_ubx_init(), gps_ubx_parse_HITL_UBX(), gps_ubx_periodic_check(), gps_ubx_ucenter_event(), gps_ubx_ucenter_gnss(), ubx_header(), ubx_send_1byte(), and ubx_trailer().
|
extern |
Definition at line 98 of file gps_ubx.c.
Referenced by gps_ubx_event(), and gps_ubx_init().
 1.15.0