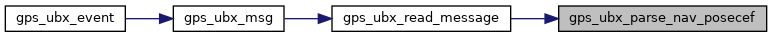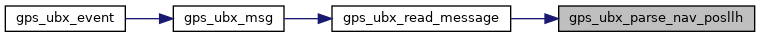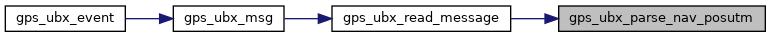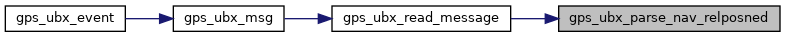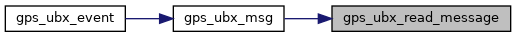|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
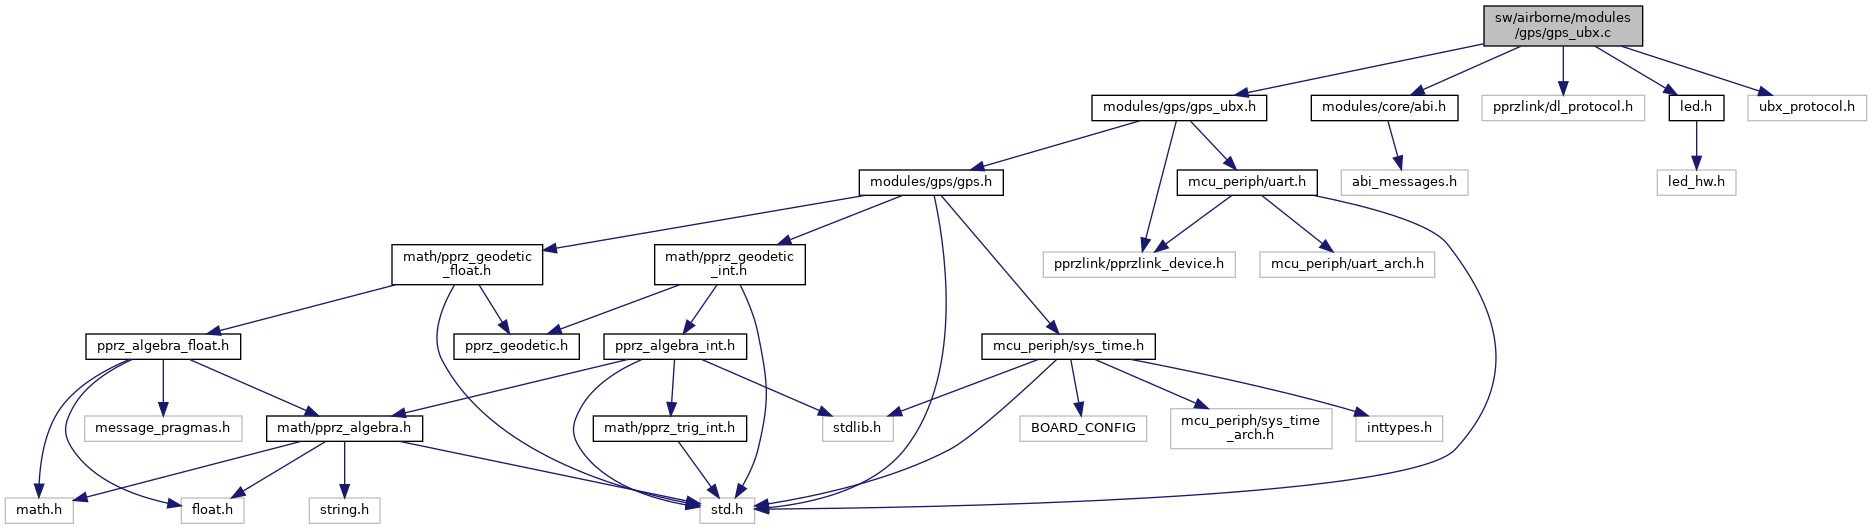
#include "modules/gps/gps_ubx.h"#include "modules/core/abi.h"#include "pprzlink/dl_protocol.h"#include "led.h"#include <math.h>#include "ubx_protocol.h"Go to the source code of this file.
Macros | |
| #define | USE_GPS_UBX_RTCM 0 |
| #define | DEBUG_PRINT(...) |
| #define | UNINIT 0 |
| Includes macros generated from ubx.xml. | |
| #define | GOT_SYNC1 1 |
| #define | GOT_SYNC2 2 |
| #define | GOT_CLASS 3 |
| #define | GOT_ID 4 |
| #define | GOT_LEN1 5 |
| #define | GOT_LEN2 6 |
| #define | GOT_PAYLOAD 7 |
| #define | GOT_CHECKSUM1 8 |
| #define | RXM_RTCM_VERSION 0x02 |
| #define | NAV_RELPOSNED_VERSION 0x01 |
| #define | NAV_DAHEADING_VERSION 0x02 |
| #define | NAV_DAHEADING_REF_ID 0xFFFF |
| RELPOS reference id used for the dual-antenna heading. | |
| #define | GPS_UBX_HEADING_BASELINE 0. |
| Distance between the two antennas of a heading receiver [m] (dual-antenna or moving base), 0 to not check it. | |
| #define | GPS_UBX_HEADING_BASELINE_TOL 0.4 |
| Largest difference between the measured and the configured antenna distance [m]. | |
| #define | GPS_UBX_HEADING_BASELINE_MAX 10. |
| Longest antenna distance for which a heading is used when GPS_UBX_HEADING_BASELINE is not set [m] (as PX4). | |
| #define | GPS_UBX_ERR_NONE 0 |
| #define | GPS_UBX_ERR_OVERRUN 1 |
| #define | GPS_UBX_ERR_MSG_TOO_LONG 2 |
| #define | GPS_UBX_ERR_CHECKSUM 3 |
| #define | GPS_UBX_ERR_UNEXPECTED 4 |
| #define | GPS_UBX_ERR_OUT_OF_SYNC 5 |
| #define | UTM_HEM_NORTH 0 |
| #define | UTM_HEM_SOUTH 1 |
| #define | GPS_UBX_BOOTRESET 0 |
| #define | CFG_RST_Reset_Hardware 0x00 |
| #define | CFG_RST_Reset_Controlled 0x01 |
| #define | CFG_RST_Reset_Controlled_GPS_only 0x02 |
| #define | CFG_RST_Reset_Controlled_GPS_stop 0x08 |
| #define | CFG_RST_Reset_Controlled_GPS_start 0x09 |
| #define | CFG_RST_BBR_Hotstart 0x0000 |
| #define | CFG_RST_BBR_Warmstart 0x0001 |
| #define | CFG_RST_BBR_Coldstart 0xffff |
| #define | gps_ubx_ucenter_event() |
Functions | |
| void | gps_ubx_parse (struct GpsUbx *gubx, uint8_t c) |
| void | gps_ubx_msg (struct GpsUbx *gubx) |
| void | gps_ubx_init (void) |
| void | gps_ubx_event (void) |
| void | gps_ubx_parse_HITL_UBX (uint8_t *buf) |
| static void | gps_ubx_parse_nav_pvt (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_sol (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_posecef (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_posllh (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_posutm (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_velecef (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_velned (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_svinfo (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_sat (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_status (struct GpsUbx *gubx) |
| static bool | gps_ubx_heading_baseline_ok (double distance) |
| A receiver can report a fixed and valid heading on a wrong carrier phase solution (seen indoors with the antennas tens of meters apart). | |
| static void | gps_ubx_parse_nav_relposned (struct GpsUbx *gubx) |
| static void | gps_ubx_parse_nav_daheading (struct GpsUbx *gubx) |
| void | gps_ubx_read_message (struct GpsUbx *gubx) |
| static void | ubx_send_1byte (struct link_device *dev, uint8_t byte) |
| void | ubx_header (struct link_device *dev, uint8_t nav_id, uint8_t msg_id, uint16_t len) |
| void | ubx_trailer (struct link_device *dev) |
| void | ubx_send_bytes (struct link_device *dev, uint8_t len, uint8_t *bytes) |
| void | ubx_send_cfg_rst (struct link_device *dev, uint16_t bbr, UNUSED uint8_t reset_mode) |
| void | gps_ubx_periodic_check (void) |
| void | gps_ublox_write (struct link_device *dev, uint8_t *buff, uint32_t n) |
Variables | |
| struct GpsUbx | gps_ubx [GPS_UBX_NB] = {0} |
| uint8_t | gps_ubx_reset = 0 |
| #define CFG_RST_BBR_Coldstart 0xffff |
Definition at line 134 of file gps_ubx.c.
Referenced by gps_ubx_event().
| #define CFG_RST_BBR_Hotstart 0x0000 |
Definition at line 132 of file gps_ubx.c.
Referenced by gps_ubx_event().
| #define CFG_RST_BBR_Warmstart 0x0001 |
Definition at line 133 of file gps_ubx.c.
Referenced by gps_ubx_event().
| #define CFG_RST_Reset_Controlled 0x01 |
Definition at line 127 of file gps_ubx.c.
Referenced by gps_ubx_event().
| #define DEBUG_PRINT | ( | ... | ) |
| #define GOT_CLASS 3 |
Definition at line 60 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_BOOTRESET 0 |
Definition at line 123 of file gps_ubx.c.
Referenced by gps_ubx_init().
| #define GPS_UBX_ERR_CHECKSUM 3 |
Definition at line 90 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_ERR_MSG_TOO_LONG 2 |
Definition at line 89 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_ERR_NONE 0 |
Definition at line 87 of file gps_ubx.c.
Referenced by gps_ubx_init().
| #define GPS_UBX_ERR_OUT_OF_SYNC 5 |
Definition at line 92 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_ERR_OVERRUN 1 |
Definition at line 88 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and gps_ubx_parse_HITL_UBX().
| #define GPS_UBX_ERR_UNEXPECTED 4 |
Definition at line 91 of file gps_ubx.c.
Referenced by gps_ubx_parse(), and ubx_process().
| #define GPS_UBX_HEADING_BASELINE 0. |
Distance between the two antennas of a heading receiver [m] (dual-antenna or moving base), 0 to not check it.
Definition at line 74 of file gps_ubx.c.
Referenced by gps_ubx_heading_baseline_ok().
| #define GPS_UBX_HEADING_BASELINE_MAX 10. |
Longest antenna distance for which a heading is used when GPS_UBX_HEADING_BASELINE is not set [m] (as PX4).
Definition at line 84 of file gps_ubx.c.
Referenced by gps_ubx_heading_baseline_ok().
| #define GPS_UBX_HEADING_BASELINE_TOL 0.4 |
Largest difference between the measured and the configured antenna distance [m].
Definition at line 79 of file gps_ubx.c.
Referenced by gps_ubx_heading_baseline_ok().
| #define gps_ubx_ucenter_event | ( | void | ) |
| #define NAV_DAHEADING_REF_ID 0xFFFF |
RELPOS reference id used for the dual-antenna heading.
Definition at line 70 of file gps_ubx.c.
Referenced by gps_ubx_parse_nav_daheading().
| #define NAV_DAHEADING_VERSION 0x02 |
Definition at line 69 of file gps_ubx.c.
Referenced by gps_ubx_parse_nav_daheading().
| #define NAV_RELPOSNED_VERSION 0x01 |
Definition at line 68 of file gps_ubx.c.
Referenced by gps_ubx_parse_nav_relposned().
| #define UTM_HEM_SOUTH 1 |
Definition at line 95 of file gps_ubx.c.
Referenced by gps_ubx_parse_nav_posutm().
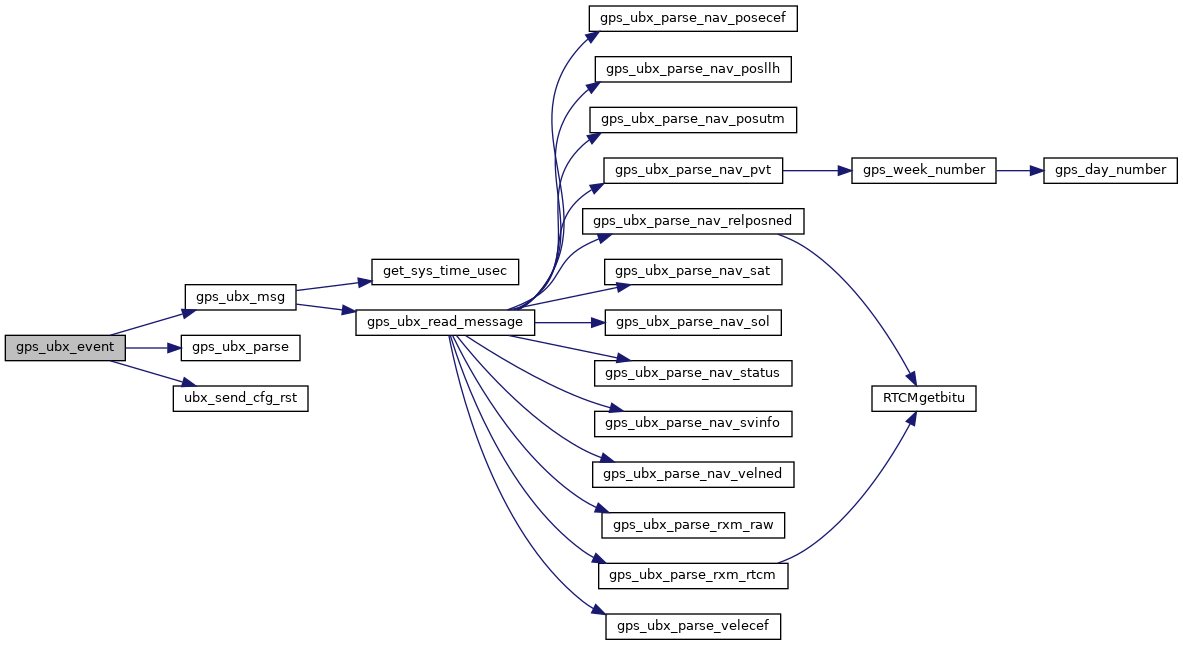
| void gps_ubx_event | ( | void | ) |
Definition at line 158 of file gps_ubx.c.
References CFG_RST_BBR_Coldstart, CFG_RST_BBR_Hotstart, CFG_RST_BBR_Warmstart, CFG_RST_Reset_Controlled, DEBUG_PRINT, dev, gps_ubx, gps_ubx_msg(), GPS_UBX_NB, gps_ubx_parse(), gps_ubx_reset, and ubx_send_cfg_rst().
|
static |
A receiver can report a fixed and valid heading on a wrong carrier phase solution (seen indoors with the antennas tens of meters apart).
The measured antenna distance shows it, while the INS can't tell.
Definition at line 454 of file gps_ubx.c.
References GPS_UBX_HEADING_BASELINE, GPS_UBX_HEADING_BASELINE_MAX, and GPS_UBX_HEADING_BASELINE_TOL.
Referenced by gps_ubx_parse_nav_daheading(), and gps_ubx_parse_nav_relposned().
| void gps_ubx_init | ( | void | ) |
Definition at line 136 of file gps_ubx.c.
References gps_ubx, GPS_UBX2_ID, GPS_UBX_BOOTRESET, GPS_UBX_ERR_NONE, GPS_UBX_ID, GPS_UBX_NB, gps_ubx_reset, and UNINIT.
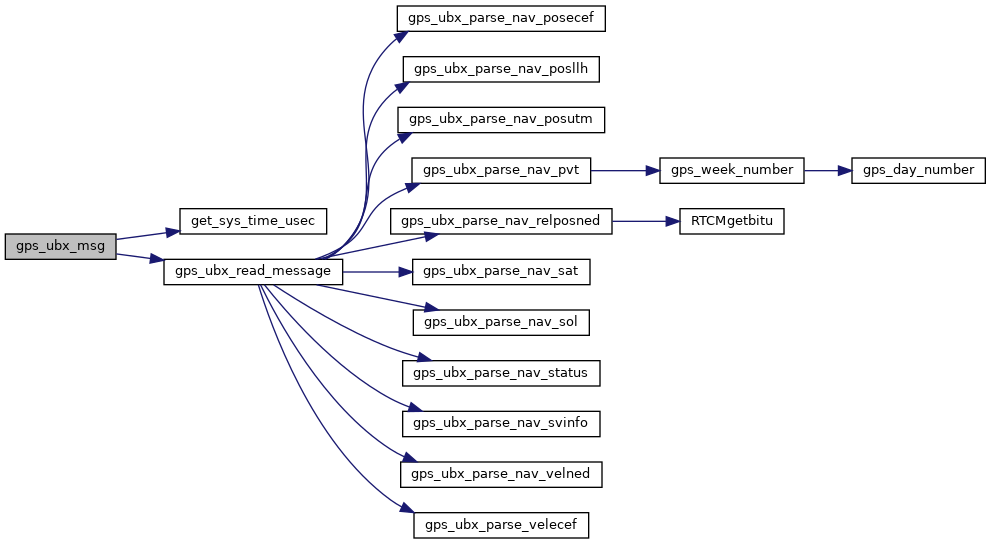
| void gps_ubx_msg | ( | struct GpsUbx * | gubx | ) |
Definition at line 767 of file gps_ubx.c.
References GpsState::comp_id, GpsState::fix, get_sys_time_usec(), GPS_FIX_3D, gps_ubx_read_message(), gps_ubx_ucenter_event, GPS_VALID_VEL_NED_BIT, GpsState::last_3dfix_ticks, GpsState::last_3dfix_time, GpsState::last_msg_ticks, GpsState::last_msg_time, LED_ON, LED_TOGGLE, GpsUbx::msg_class, GpsUbx::msg_id, sys_time::nb_sec, sys_time::nb_sec_rem, GpsUbx::state, and GpsState::valid_fields.
Referenced by gps_ubx_event().
Definition at line 621 of file gps_ubx.c.
References GpsUbx::ck_a, GpsUbx::ck_b, GpsUbx::error_cnt, GpsUbx::error_last, GOT_CHECKSUM1, GOT_CLASS, GOT_ID, GOT_LEN1, GOT_LEN2, GOT_PAYLOAD, GOT_SYNC1, GOT_SYNC2, GPS_UBX_ERR_CHECKSUM, GPS_UBX_ERR_MSG_TOO_LONG, GPS_UBX_ERR_OUT_OF_SYNC, GPS_UBX_ERR_OVERRUN, GPS_UBX_ERR_UNEXPECTED, GPS_UBX_MAX_PAYLOAD, GpsUbx::len, GpsUbx::msg_available, GpsUbx::msg_buf, GpsUbx::msg_class, GpsUbx::msg_id, GpsUbx::msg_idx, pprzLogFile, sdLogWriteByte(), GpsUbx::status, and UNINIT.
Referenced by gps_ubx_event().
| void gps_ubx_parse_HITL_UBX | ( | uint8_t * | buf | ) |
This code simulates gps_ubx.c:parse_ubx()
Definition at line 185 of file gps_ubx.c.
References gps_ubx, and GPS_UBX_ERR_OVERRUN.
|
static |
Definition at line 517 of file gps_ubx.c.
References GpsState::comp_id, RelPosNED::distance, RelPosNED::distance_acc, get_sys_time_usec(), gps_ubx_heading_baseline_ok(), RelPosNED::heading, RelPosNED::heading_acc, GpsUbx::msg_buf, NAV_DAHEADING_REF_ID, NAV_DAHEADING_VERSION, RelPosNED::pos, RelPosNED::pos_acc, RelPosNED::reference_id, GpsUbx::state, RelPosNED::tow, NedCoor_d::x, NedCoor_f::x, NedCoor_d::y, NedCoor_f::y, NedCoor_d::z, and NedCoor_f::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 296 of file gps_ubx.c.
References GpsState::ecef_pos, GPS_VALID_POS_ECEF_BIT, GpsUbx::msg_buf, GpsState::pacc, GpsUbx::pacc_valid, GpsUbx::state, GpsState::tow, GpsState::valid_fields, EcefCoor_i::x, EcefCoor_i::y, and EcefCoor_i::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 311 of file gps_ubx.c.
References LlaCoor_i::alt, GPS_VALID_HMSL_BIT, GPS_VALID_POS_LLA_BIT, GpsState::hacc, GpsState::hmsl, LlaCoor_i::lat, GpsState::lla_pos, LlaCoor_i::lon, GpsUbx::msg_buf, GpsUbx::state, GpsState::vacc, and GpsState::valid_fields.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 328 of file gps_ubx.c.
References UtmCoor_i::alt, UtmCoor_i::east, GPS_VALID_HMSL_BIT, GPS_VALID_POS_UTM_BIT, GpsState::hmsl, GpsUbx::msg_buf, UtmCoor_i::north, GpsUbx::state, UTM_HEM_SOUTH, GpsState::utm_pos, GpsState::valid_fields, and UtmCoor_i::zone.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 201 of file gps_ubx.c.
References LlaCoor_i::alt, GpsState::cacc, GpsState::course, GpsState::fix, GPS_FIX_3D, GPS_FIX_DGPS, GPS_FIX_NONE, GPS_FIX_RTK, GPS_VALID_COURSE_BIT, GPS_VALID_HMSL_BIT, GPS_VALID_POS_LLA_BIT, GPS_VALID_VEL_NED_BIT, gps_week_number(), GpsState::gspeed, GpsState::hacc, GpsState::hmsl, LlaCoor_i::lat, GpsState::lla_pos, LlaCoor_i::lon, GpsUbx::msg_buf, GpsState::ned_vel, GpsState::num_sv, GpsState::pacc, GpsUbx::pacc_valid, GpsState::pdop, GpsState::sacc, GpsUbx::state, GpsState::tow, GpsState::vacc, GpsState::valid_fields, GpsState::week, NedCoor_i::x, NedCoor_i::y, and NedCoor_i::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 462 of file gps_ubx.c.
References GpsState::comp_id, RelPosNED::distance, RelPosNED::distance_acc, GpsState::fix, get_sys_time_usec(), gps_ubx_heading_baseline_ok(), RelPosNED::heading, RelPosNED::heading_acc, GpsUbx::msg_buf, NAV_RELPOSNED_VERSION, RelPosNED::pos, RelPosNED::pos_acc, RelPosNED::reference_id, GpsUbx::state, RelPosNED::tow, NedCoor_d::x, NedCoor_f::x, NedCoor_d::y, NedCoor_f::y, NedCoor_d::z, and NedCoor_f::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 398 of file gps_ubx.c.
References SVinfo::azim, SVinfo::cno, SVinfo::elev, SVinfo::flags, GpsUbx::gnss_in_use, GPS_NB_CHANNELS, GpsUbx::len, Min, GpsUbx::msg_buf, GpsState::nb_channels, SVinfo::qi, GpsUbx::state, SVinfo::svid, GpsState::svinfos, and GpsState::tow.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 264 of file gps_ubx.c.
References GpsState::ecef_pos, GpsState::ecef_vel, GpsState::fix, GPS_FIX_3D, GPS_VALID_POS_ECEF_BIT, GPS_VALID_VEL_ECEF_BIT, GpsUbx::msg_buf, GpsState::num_sv, GpsState::pacc, GpsUbx::pacc_valid, GpsState::pdop, GpsState::sacc, GpsUbx::state, GpsState::tow, GpsState::valid_fields, GpsState::week, EcefCoor_i::x, EcefCoor_i::y, and EcefCoor_i::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 438 of file gps_ubx.c.
References GpsState::fix, GPS_FIX_3D, GpsUbx::msg_buf, GpsUbx::state, GpsUbx::status_flags, and GpsState::tow.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 382 of file gps_ubx.c.
References SVinfo::azim, SVinfo::cno, SVinfo::elev, SVinfo::flags, GPS_NB_CHANNELS, Min, GpsUbx::msg_buf, GpsState::nb_channels, SVinfo::qi, GpsUbx::state, SVinfo::svid, and GpsState::svinfos.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 361 of file gps_ubx.c.
References GpsState::cacc, GpsState::course, GPS_VALID_COURSE_BIT, GPS_VALID_VEL_NED_BIT, GpsState::gspeed, GpsUbx::msg_buf, GpsState::ned_vel, GpsState::speed_3d, GpsUbx::state, GpsState::tow, GpsState::valid_fields, NedCoor_i::x, NedCoor_i::y, and NedCoor_i::z.
Referenced by gps_ubx_read_message().
|
static |
Definition at line 347 of file gps_ubx.c.
References GpsState::ecef_vel, GPS_VALID_VEL_ECEF_BIT, GpsUbx::msg_buf, GpsState::sacc, GpsUbx::state, GpsState::tow, GpsState::valid_fields, EcefCoor_i::x, EcefCoor_i::y, and EcefCoor_i::z.
Referenced by gps_ubx_read_message().
| void gps_ubx_periodic_check | ( | void | ) |
Definition at line 797 of file gps_ubx.c.
References gps_periodic_check(), gps_ubx, GPS_UBX_NB, and state.
| void gps_ubx_read_message | ( | struct GpsUbx * | gubx | ) |
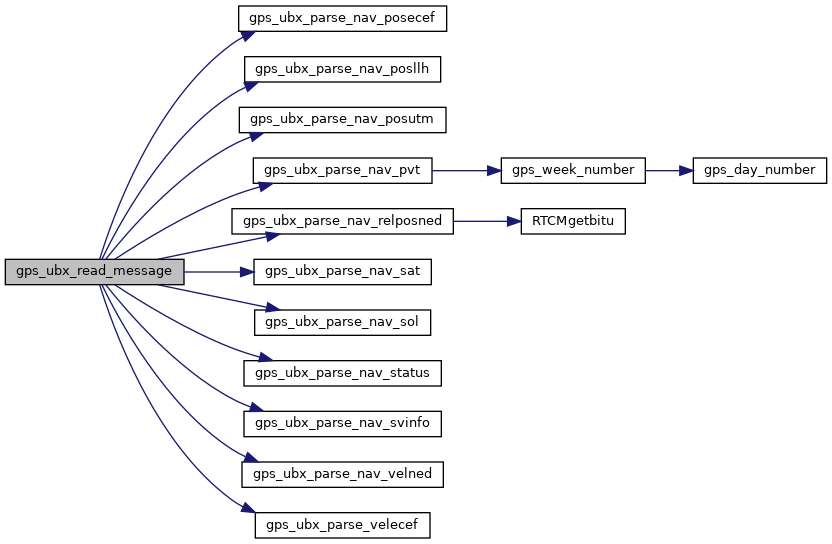
Definition at line 559 of file gps_ubx.c.
References gps_ubx_parse_nav_daheading(), gps_ubx_parse_nav_posecef(), gps_ubx_parse_nav_posllh(), gps_ubx_parse_nav_posutm(), gps_ubx_parse_nav_pvt(), gps_ubx_parse_nav_relposned(), gps_ubx_parse_nav_sat(), gps_ubx_parse_nav_sol(), gps_ubx_parse_nav_status(), gps_ubx_parse_nav_svinfo(), gps_ubx_parse_nav_velned(), gps_ubx_parse_velecef(), GpsUbx::msg_class, and GpsUbx::msg_id.
Referenced by gps_ubx_msg().
Definition at line 717 of file gps_ubx.c.
References dev, gps_ubx, GPS_UBX_NB, and ubx_send_1byte().
|
static |
Definition at line 705 of file gps_ubx.c.
References dev, gps_ubx, and GPS_UBX_NB.
Referenced by ubx_header(), and ubx_send_bytes().
Definition at line 746 of file gps_ubx.c.
References dev, and ubx_send_1byte().
Definition at line 754 of file gps_ubx.c.
Referenced by gps_ubx_event().
| void ubx_trailer | ( | struct link_device * | dev | ) |
Definition at line 734 of file gps_ubx.c.
References dev, gps_ubx, and GPS_UBX_NB.
| struct GpsUbx gps_ubx[GPS_UBX_NB] = {0} |
Definition at line 97 of file gps_ubx.c.
Referenced by ArduIMU_periodicGPS(), gps_ubx_event(), gps_ubx_init(), gps_ubx_parse_HITL_UBX(), gps_ubx_periodic_check(), gps_ubx_ucenter_event(), gps_ubx_ucenter_gnss(), ubx_header(), ubx_send_1byte(), and ubx_trailer().
| uint8_t gps_ubx_reset = 0 |
Definition at line 98 of file gps_ubx.c.
Referenced by gps_ubx_event(), and gps_ubx_init().
 1.15.0