|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
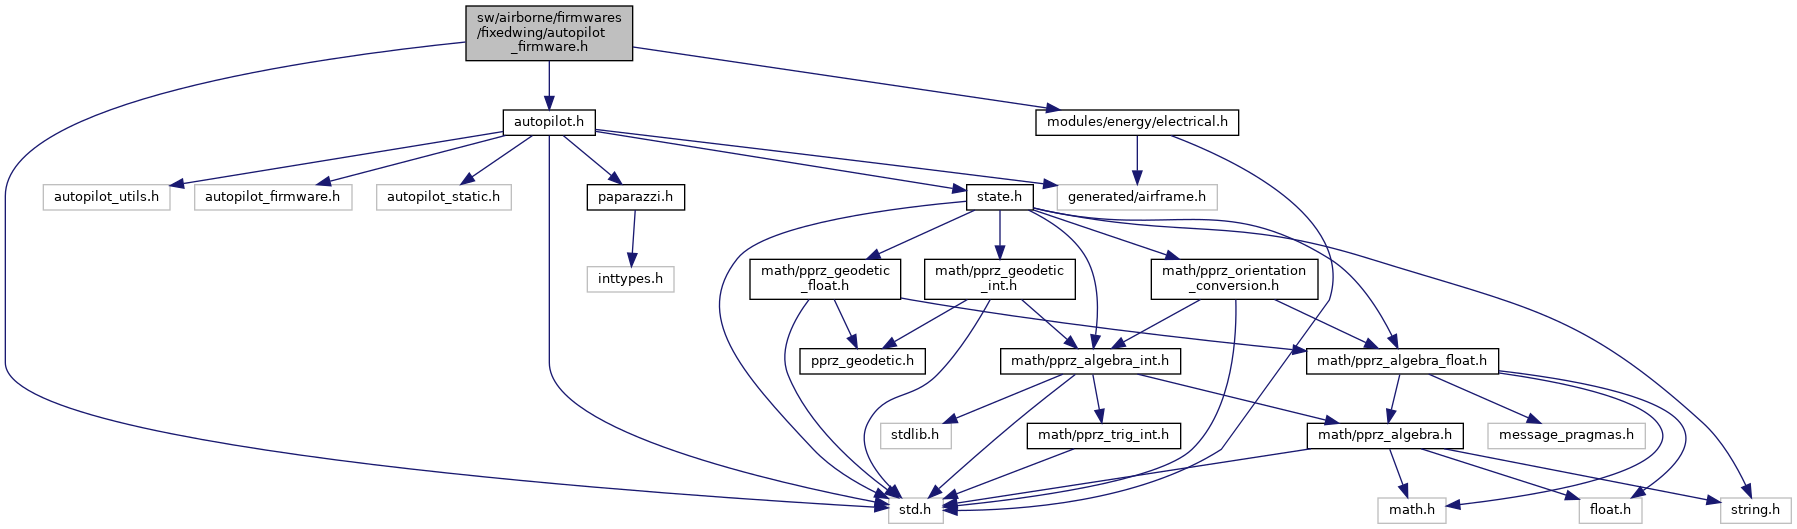
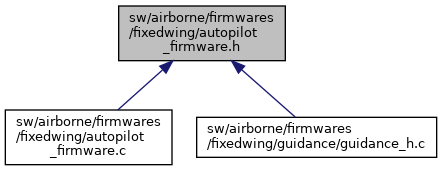
Fixedwing specific autopilot interface and initialization. More...
Go to the source code of this file.
Macros | |
| #define | LATERAL_MODE_MANUAL 0 |
| #define | LATERAL_MODE_ROLL_RATE 1 |
| #define | LATERAL_MODE_ROLL 2 |
| #define | LATERAL_MODE_COURSE 3 |
| #define | LATERAL_MODE_NB 4 |
Functions | |
| void | autopilot_firmware_init (void) |
| Init function. | |
| void | monitor_task (void) |
| monitoring task should be called at 1Hz | |
Variables | |
| uint8_t | lateral_mode |
Fixedwing specific autopilot interface and initialization.
Definition in file autopilot_firmware.h.
| #define LATERAL_MODE_COURSE 3 |
Definition at line 39 of file autopilot_firmware.h.
Referenced by fly_to_xy(), h_ctl_guidance_loop(), and navigation_task().
| #define LATERAL_MODE_MANUAL 0 |
Definition at line 36 of file autopilot_firmware.h.
Referenced by autopilot_static_init().
| #define LATERAL_MODE_NB 4 |
Definition at line 40 of file autopilot_firmware.h.
| #define LATERAL_MODE_ROLL 2 |
Definition at line 38 of file autopilot_firmware.h.
Referenced by collective_tracking_control(), fly_to_xy(), gvf_low_level_control_2D(), gvf_low_level_control_3D(), nav_without_gps(), and v_ctl_landing_loop().
| #define LATERAL_MODE_ROLL_RATE 1 |
Definition at line 37 of file autopilot_firmware.h.
|
extern |
Init function.
Definition at line 157 of file autopilot_firmware.c.
|
extern |
monitoring task should be called at 1Hz
monitoring task should be called at 1Hz
Definition at line 199 of file autopilot_firmware.c.
References autopilot, CATASTROPHIC_BAT_KILL_DELAY, DefaultChannel, DefaultDevice, dist2_to_home, electrical, KILL_MODE_DISTANCE, MIN_SPEED_FOR_TAKEOFF, sys_time::nb_sec, Square, and stateGetHorizontalSpeedNorm_f().
|
extern |
Definition at line 38 of file autopilot_firmware.c.
Referenced by autopilot_static_init(), collective_tracking_control(), fly_to_xy(), gvf_low_level_control_2D(), gvf_low_level_control_3D(), h_ctl_guidance_loop(), nav_without_gps(), navigation_task(), send_mode(), and v_ctl_landing_loop().
 1.15.0