|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
interface to the TU Delft serial stereocam More...
Go to the source code of this file.
Data Structures | |
| struct | stereocam_t |
Functions | |
| void | stereocam_init (void) |
| void | stereocam_event (void) |
| void | state2stereocam (void) |
interface to the TU Delft serial stereocam
Definition in file stereocam.h.
| struct stereocam_t |
Definition at line 34 of file stereocam.h.
| Data Fields | ||
|---|---|---|
| struct FloatRMat | body_to_cam | IMU to stereocam rotation. |
| struct link_device * | device | The device which is uses for communication. |
| bool | msg_available | If we received a message. |
| struct pprz_transport | transport | The transport layer (PPRZ). |
|
extern |
Definition at line 216 of file stereocam.c.
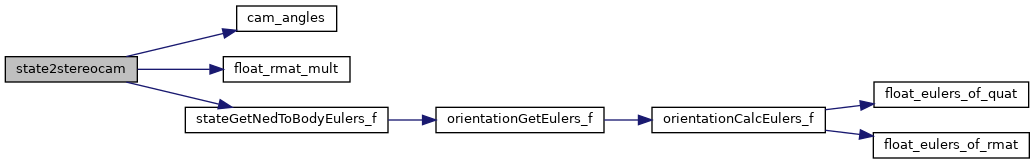
References float_rmat_mult(), FloatEulers::phi, FloatEulers::psi, stateGetNedToBodyEulers_f(), stereocam, and FloatEulers::theta.
|
extern |
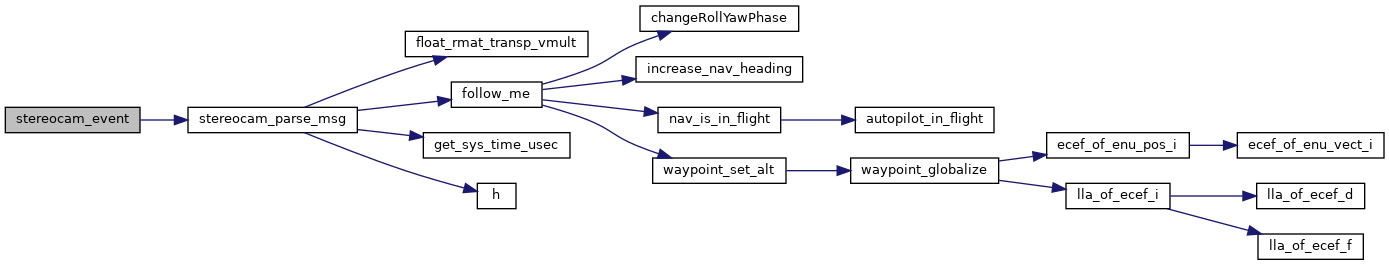
Definition at line 202 of file stereocam.c.
References stereocam, stereocam_msg_buf, and stereocam_parse_msg().
|
extern |
Definition at line 95 of file stereocam.c.
References float_rmat_of_eulers, InitMedianFilterVect3Float, MEDIAN_DEFAULT_SIZE, medianfilter, STEREO_BODY_TO_STEREO_PHI, STEREO_BODY_TO_STEREO_PSI, STEREO_BODY_TO_STEREO_THETA, and stereocam.
 1.15.0