|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
#include "nps_fdm.h"#include <stdlib.h>#include <stdio.h>#include "std.h"#include "math/pprz_geodetic.h"#include "math/pprz_geodetic_double.h"#include "math/pprz_geodetic_float.h"#include "math/pprz_algebra.h"#include "math/pprz_algebra_float.h"#include "math/pprz_isa.h"#include "generated/airframe.h"#include "generated/flight_plan.h"#include "generated/modules.h"#include "state.h"Go to the source code of this file.
Functions | |
| static void | init_ltp (void) |
| void | nps_fdm_init (double dt) |
| NPS FDM rover init. | |
| void | nps_fdm_run_init_step (void) |
| void | nps_fdm_run_step (bool launch, double *commands, int commands_nb) |
| Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target. | |
| void | nps_fdm_set_wind (double speed, double dir) |
| void | nps_fdm_set_wind_ned (double wind_north, double wind_east, double wind_down) |
| void | nps_fdm_set_turbulence (double wind_speed, int turbulence_severity) |
| void | nps_fdm_set_temperature (double temp, double h) |
| Set temperature in degrees Celcius at given height h above MSL. | |
Variables | |
| struct NpsFdm | fdm |
| Holds all necessary NPS FDM state information. | |
| static struct LtpDef_d | ltpdef |
| static struct NedCoor_d | rover_pos |
| Physical model structures. | |
| static struct NedCoor_d | rover_vel |
| static struct NedCoor_d | rover_acc |
|
static |
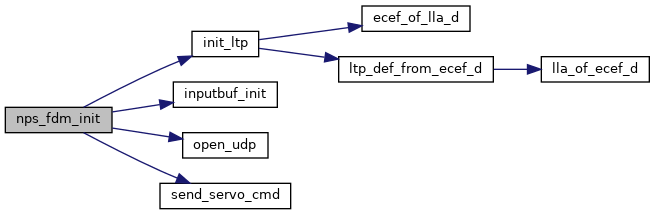
Definition at line 230 of file nps_fdm_rover.c.
References LlaCoor_d::alt, ecef_of_lla_d(), fdm, LlaCoor_d::lat, LlaCoor_d::lon, ltp_def_from_ecef_d(), ltpdef, and PRINT_CONFIG_MSG().
Referenced by nps_fdm_init().
| void nps_fdm_init | ( | double | dt | ) |
NPS FDM rover init.
NPS FDM rover init.
| dt |
Definition at line 110 of file nps_fdm_rover.c.
References EULERS_ASSIGN, fdm, init_first_order_low_pass(), init_ltp(), init_ltp(), PPRZ_ISA_SEA_LEVEL_PRESSURE, sim_state, TRUE, and VECT3_ASSIGN.
Referenced by nps_main_init().
| void nps_fdm_run_init_step | ( | void | ) |
Definition at line 132 of file nps_fdm_rover.c.
Referenced by nps_main_loop().
| void nps_fdm_run_step | ( | bool | launch, |
| double * | commands, | ||
| int | commands_nb ) |
Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target.
Johnson, E.N., Fontaine, S.G., and Kahn, A.D., “Minimum Complexity Uninhabited Air Vehicle Guidance And Flight Control System,” Proceedings of the 20th Digital Avionics Systems Conference, 2001. http://www.ae.gatech.edu/~ejohnson/JohnsonFontaineKahn.pdf
Johnson, E.N. and Fontaine, S.G., “Use Of Flight Simulation To Complement Flight Testing Of Low-Cost UAVs,” Proceedings of the AIAA Modeling and Simulation Technology Conference, 2001. http://www.ae.gatech.edu/~ejohnson/AIAA%202001-4059.pdf
Minimum complexity flight dynamic model In legacy Paparazzi simulator, was implemented in OCaml and correspond to the 'sim' target.
| launch | |
| act_commands | |
| commands_nb |
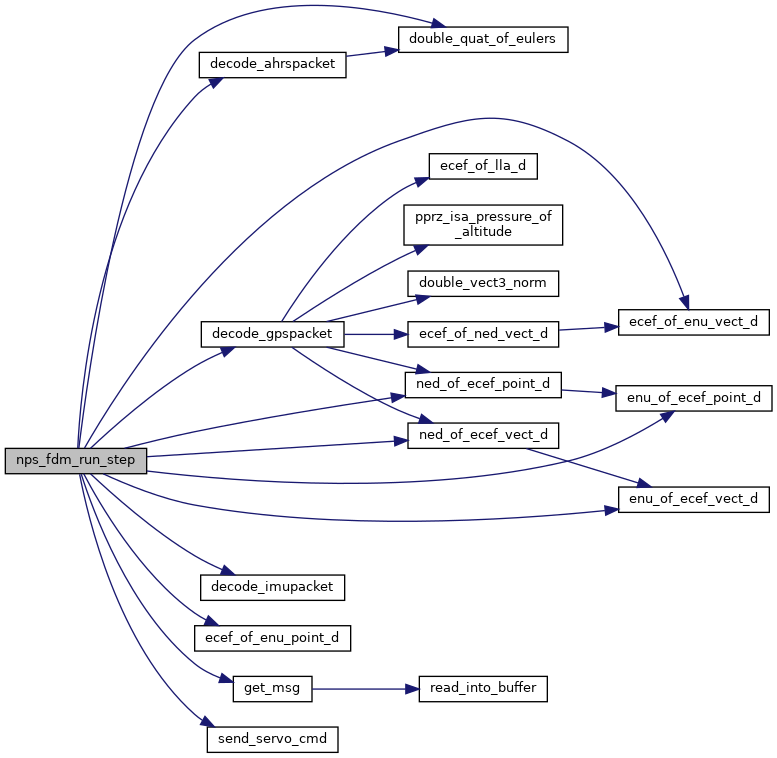
Definition at line 137 of file nps_fdm_rover.c.
References alpha, AUTO_THROTTLE_NOMINAL_CRUISE_THROTTLE, COMMAND_PITCH, COMMAND_ROLL, commands, double_quat_of_eulers(), DRIVE_SHAFT_DISTANCE, ecef_of_enu_point_d(), ecef_of_enu_vect_d(), ecef_of_ned_point_d(), ecef_of_ned_vect_d(), fdm, FLOAT_VECT2_NORM, lla_of_ecef_d(), ltpdef, MAX_DELTA, MAX_PPRZ, MAXIMUM_AIRSPEED, MAXIMUM_POWER, ned_of_ecef_point_d(), ned_of_ecef_vect_d(), PITCH_RESPONSE_FACTOR, PPRZ_ISA_GRAVITY, ROLL_MAX_SETPOINT, ROLL_RATE_MAX_SETPOINT, ROLL_RESPONSE_FACTOR, rover_acc, rover_pos, rover_vel, sim_state, speed_sp, update_first_order_low_pass(), v2, WEIGHT, and YAW_RESPONSE_FACTOR.
Referenced by nps_main_run_sim_step().
| void nps_fdm_set_temperature | ( | double | temp, |
| double | h ) |
Set temperature in degrees Celcius at given height h above MSL.
Definition at line 282 of file nps_fdm_rover.c.
References h().
| void nps_fdm_set_turbulence | ( | double | wind_speed, |
| int | turbulence_severity ) |
Definition at line 277 of file nps_fdm_rover.c.
Referenced by nps_atmosphere_update().
| void nps_fdm_set_wind | ( | double | speed, |
| double | dir ) |
Definition at line 266 of file nps_fdm_rover.c.
| void nps_fdm_set_wind_ned | ( | double | wind_north, |
| double | wind_east, | ||
| double | wind_down ) |
Definition at line 271 of file nps_fdm_rover.c.
References sim_state.
Referenced by nps_atmosphere_update().
| struct NpsFdm fdm |
Holds all necessary NPS FDM state information.
Definition at line 95 of file nps_fdm_rover.c.
Referenced by check_for_nan(), fetch_state(), gazebo_read(), gazebo_read(), get_acc(), get_ang_acc(), get_ang_vel(), get_orient(), get_pos(), get_vel(), gps_feed_value(), init_gazebo(), init_ltp(), init_ltp(), init_ltp(), init_ltp(), net_fdm_dump(), net_fdm_init(), net_fdm_ntoh(), nps_fdm_init(), nps_fdm_run_init_step(), nps_fdm_run_step(), nps_flightgear_send(), nps_flightgear_send_fdm(), nps_ivy_display(), nps_ivy_display_cb(), nps_ivy_send_WORLD_ENV_REQ(), nps_main_loop(), nps_sensor_accel_run_step(), nps_sensor_airspeed_run_step(), nps_sensor_aoa_run_step(), nps_sensor_baro_run_step(), nps_sensor_gps_run_step(), nps_sensor_gyro_run_step(), nps_sensor_mag_run_step(), nps_sensor_sideslip_run_step(), nps_sensor_sonar_run_step(), nps_sensor_temperature_run_step(), sim_overwrite_ahrs(), and sim_overwrite_ins().
|
static |
Definition at line 98 of file nps_fdm_rover.c.
|
static |
Definition at line 106 of file nps_fdm_rover.c.
Referenced by nps_fdm_run_step().
|
static |
Physical model structures.
Definition at line 104 of file nps_fdm_rover.c.
Referenced by fill_bayesian_cell(), fill_free_cells(), and nps_fdm_run_step().
|
static |
Definition at line 105 of file nps_fdm_rover.c.
Referenced by nps_fdm_run_step().
 1.15.0