|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
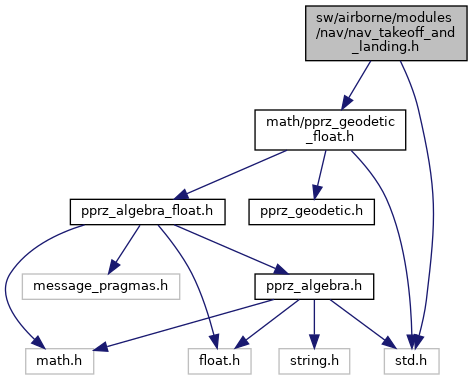
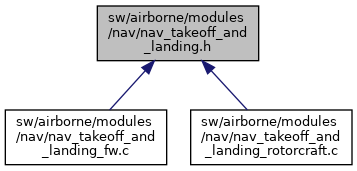
Go to the source code of this file.
Data Structures | |
| struct | nav_takeoff |
| Structure for takeoff. More... | |
| struct | nav_landing |
| Structure for landing. More... | |
Enumerations | |
| enum | nav_takeoff_status { NAV_TAKEOFF_INIT , NAV_TAKEOFF_START_MOTOR , NAV_TAKEOFF_CLIMB , NAV_TAKEOFF_DONE } |
| enum | nav_landing_status { NAV_LANDING_INIT , NAV_LANDING_REACH_AF , NAV_LANDING_DESCENT , NAV_LANDING_FLARE , NAV_LANDING_DONE } |
Functions | |
| void | nav_takeoff_and_landing_init (void) |
| Init function. | |
| void | nav_takeoff_and_landing_periodic (void) |
| Periodic timeout check function. | |
| bool | nav_takeoff_from_wp (uint8_t wp_id, float height) |
| Takeoff from a waypoint. | |
| bool | nav_takeoff_from_loc (float lat, float lon, float height) |
| Takeoff from lat long location. | |
| bool | nav_takeoff_from_here (float height) |
| Takeoff from current location. | |
| bool | nav_land_at_wp (uint8_t td_id, uint8_t af_id, float radius) |
| Land at waypoint location. | |
| bool | nav_land_at_loc (float td_alt, float lat, float lon, float dir, float dist, float radius) |
| Land at lat long location. | |
| bool | nav_land_here (float td_alt, float radius) |
| Land at current location. | |
Variables | |
| float | nav_takeoff_direction |
| Takeoff direction in range [0-360] (deg) set to flight plan QFU by default. | |
Definition in file nav_takeoff_and_landing.h.
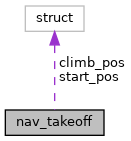
| struct nav_takeoff |
Structure for takeoff.
Definition at line 50 of file nav_takeoff_and_landing.h.
| Data Fields | ||
|---|---|---|
| uint8_t | climb_id | climb waypoint id |
| struct EnuCoor_f | climb_pos | climb point |
| struct EnuCoor_f | start_pos | start position |
| enum nav_takeoff_status | status | current step |
| bool | timeout | true if status should be set to init |
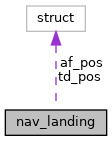
| struct nav_landing |
Structure for landing.
Definition at line 60 of file nav_takeoff_and_landing.h.
| Data Fields | ||
|---|---|---|
| uint8_t | af_id | start of descent wp id |
| struct EnuCoor_f | af_pos | start of descent point |
| float | radius | circle radius for fixedwing landing |
| enum nav_landing_status | status | current step |
| uint8_t | td_id | touch down wp id |
| struct EnuCoor_f | td_pos | touch down point |
| bool | timeout | true if status should be set to init |
| enum nav_landing_status |
| Enumerator | |
|---|---|
| NAV_LANDING_INIT | |
| NAV_LANDING_REACH_AF | |
| NAV_LANDING_DESCENT | |
| NAV_LANDING_FLARE | |
| NAV_LANDING_DONE | |
Definition at line 40 of file nav_takeoff_and_landing.h.
| enum nav_takeoff_status |
| Enumerator | |
|---|---|
| NAV_TAKEOFF_INIT | |
| NAV_TAKEOFF_START_MOTOR | |
| NAV_TAKEOFF_CLIMB | |
| NAV_TAKEOFF_DONE | |
Definition at line 33 of file nav_takeoff_and_landing.h.
|
extern |
Land at lat long location.
| [in] | td_alt | touch down altitude above ground ref (m) |
| [in] | lat | landing latitude (deg) |
| [in] | lon | landing longitude (deg) |
| [in] | dir | direction approach direction ([0-360], deg) |
| [in] | dist | distance to start descent (m) |
| [in] | radius | circle radius for final turn (if positive: turn right, if negative: turn left) (m) |
Definition at line 359 of file nav_takeoff_and_landing_fw.c.
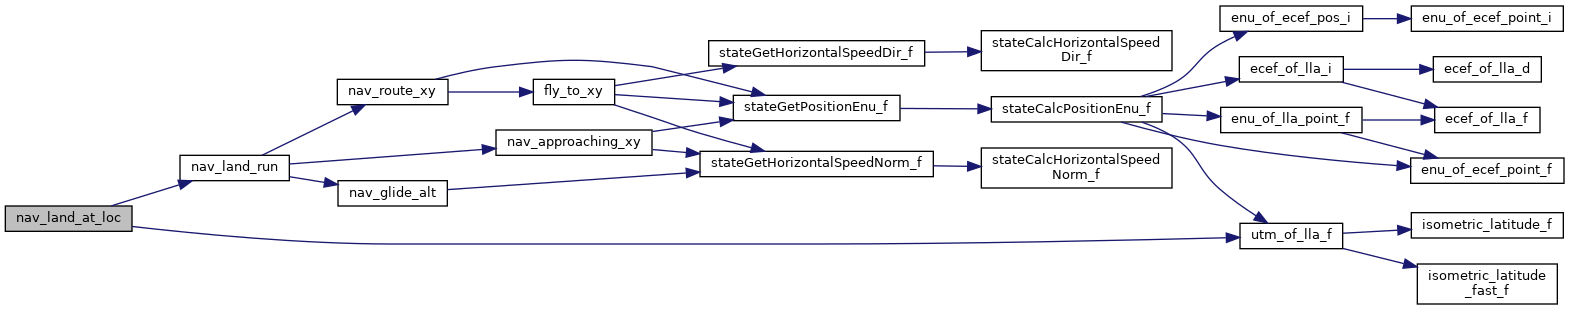
References dir, ENU_OF_UTM_DIFF, GetAltRef, landing, LlaCoor_f::lat, LlaCoor_f::lon, nav_land_run(), NAV_LANDING_AF_HEIGHT, NAV_LANDING_INIT, stateGetUtmOrigin_f(), and utm_of_lla_f().
Land at waypoint location.
set touch down (TD) and start of descent (AF)
| [in] | td_id | waypoint ID for touch down point |
| [in] | af_if | waypoint ID for start of descent |
| [in] | radius | circle radius for final turn (if positive: turn right, if negative: turn left) (m) |
Definition at line 342 of file nav_takeoff_and_landing_fw.c.
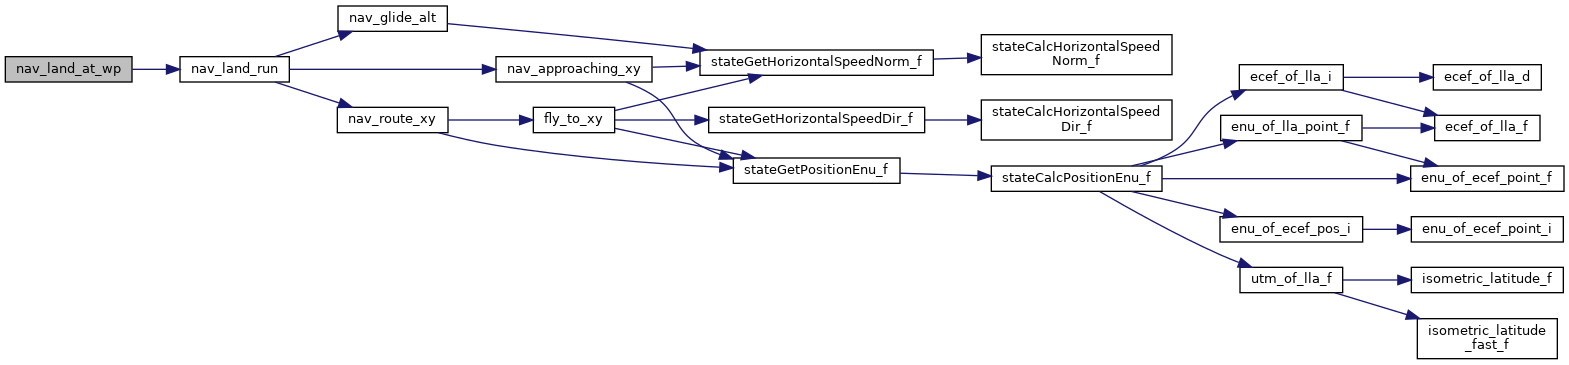
References GetAltRef, landing, nav_land_run(), NAV_LANDING_AF_HEIGHT, NAV_LANDING_INIT, WaypointAlt, WaypointX, and WaypointY.
|
extern |
Land at current location.
emergency landing
| [in] | td_alt | touch down altitude above ground ref (m) |
| [in] | radius | circle radius for final turn (if positive: turn right, if negative: turn left) (m) |
Definition at line 377 of file nav_takeoff_and_landing_fw.c.
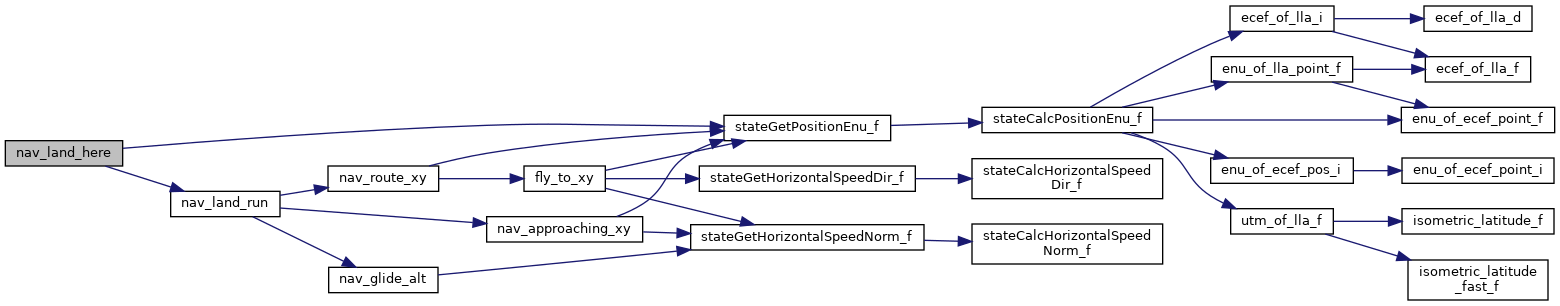
References landing, nav_land_run(), NAV_LANDING_AF_HEIGHT, NAV_LANDING_INIT, and stateGetPositionEnu_f().
|
extern |
Init function.
Definition at line 118 of file nav_takeoff_and_landing_fw.c.
References landing, mission_register(), NAV_LANDING_INIT, nav_takeoff_direction, NAV_TAKEOFF_INIT, and takeoff.
|
extern |
Periodic timeout check function.
Definition at line 136 of file nav_takeoff_and_landing_fw.c.
References landing, NAV_LANDING_INIT, NAV_TAKEOFF_INIT, and takeoff.
|
extern |
Takeoff from current location.
| [in] | height | height in meters for ending takeoff procedure (<0 to use default value) |
Definition at line 227 of file nav_takeoff_and_landing_fw.c.
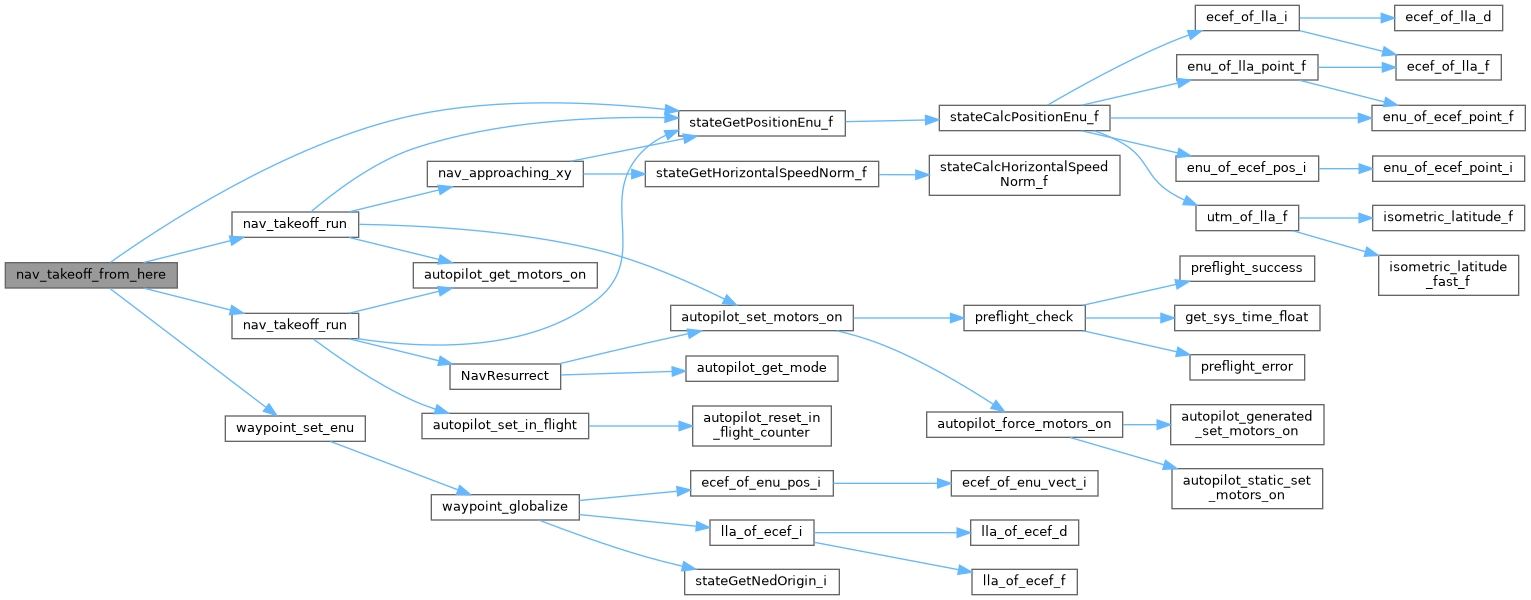
References nav_takeoff_direction, NAV_TAKEOFF_DIST, NAV_TAKEOFF_HEIGHT, NAV_TAKEOFF_INIT, nav_takeoff_run(), nav_takeoff_run(), stateGetPositionEnu_f(), takeoff, and waypoint_set_enu().
Referenced by nav_takeoff_from_loc().
|
extern |
Takeoff from lat long location.
| [in] | lat | takeoff latitude (deg) |
| [in] | lon | takeoff longitude (deg) |
| [in] | height | height in meters for ending takeoff procedure (<0 to use default value) |
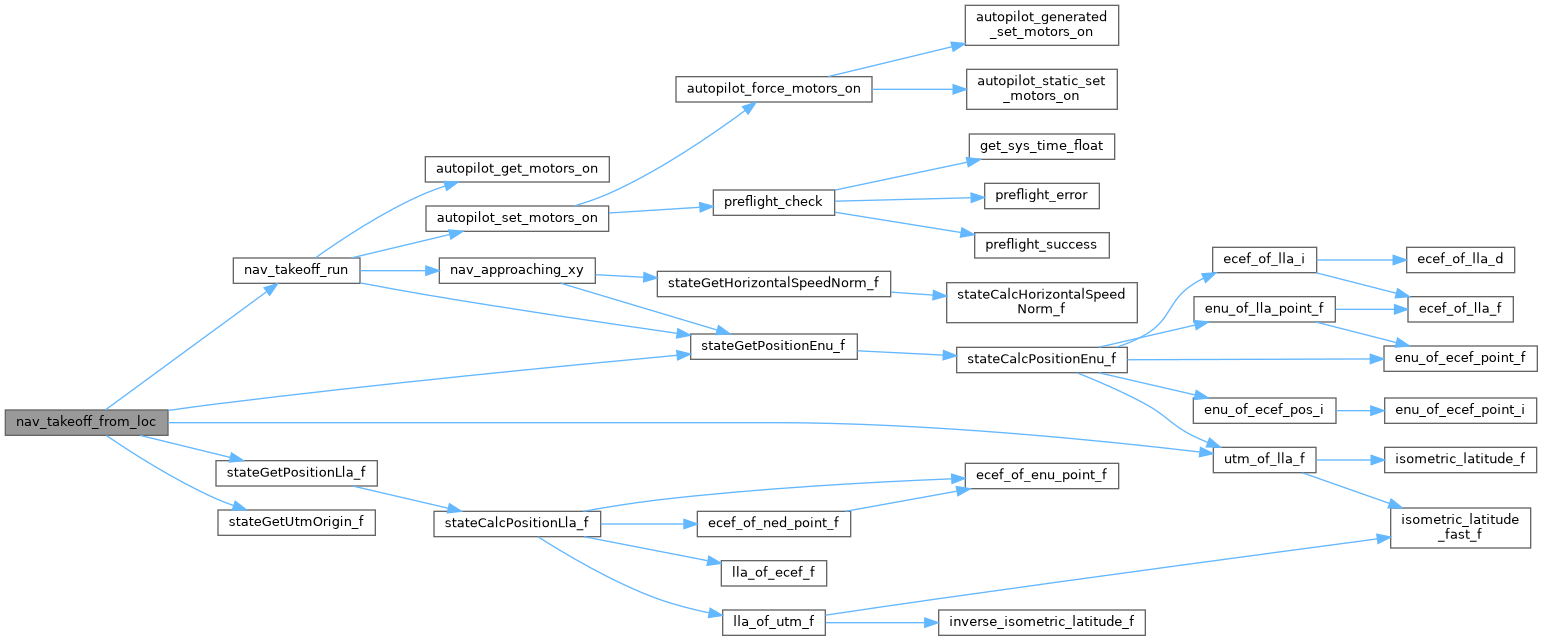
Definition at line 209 of file nav_takeoff_and_landing_fw.c.
References LlaCoor_f::alt, ENU_OF_UTM_DIFF, LlaCoor_f::lat, LlaCoor_f::lon, NAV_TAKEOFF_HEIGHT, NAV_TAKEOFF_INIT, nav_takeoff_run(), stateGetPositionEnu_f(), stateGetPositionLla_f(), stateGetUtmOrigin_f(), takeoff, and utm_of_lla_f().
|
extern |
Takeoff from a waypoint.
| [in] | wp_id | waypoint ID |
| [in] | height | height in meters for ending takeoff procedure (<0 to use default value) |
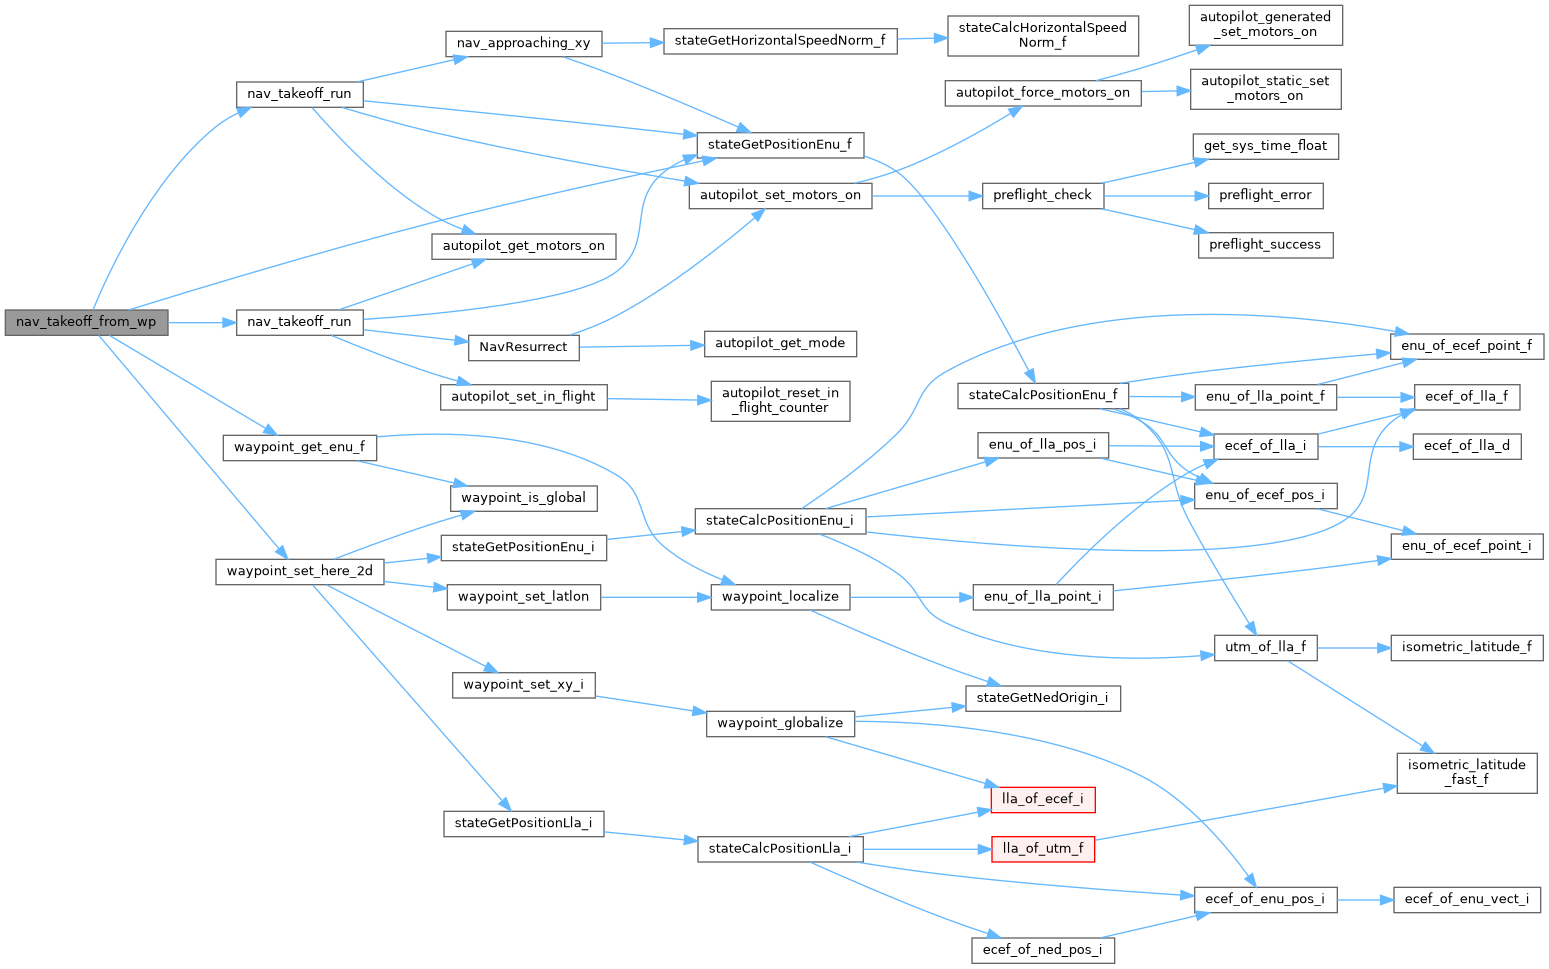
Definition at line 192 of file nav_takeoff_and_landing_fw.c.
References NAV_TAKEOFF_HEIGHT, NAV_TAKEOFF_INIT, nav_takeoff_run(), nav_takeoff_run(), stateGetPositionEnu_f(), takeoff, waypoint_get_enu_f(), waypoint_set_here_2d(), WaypointX, and WaypointY.
|
extern |
Takeoff direction in range [0-360] (deg) set to flight plan QFU by default.
Definition at line 72 of file nav_takeoff_and_landing_fw.c.
Referenced by nav_takeoff_and_landing_init(), and nav_takeoff_from_here().
 1.15.0