|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
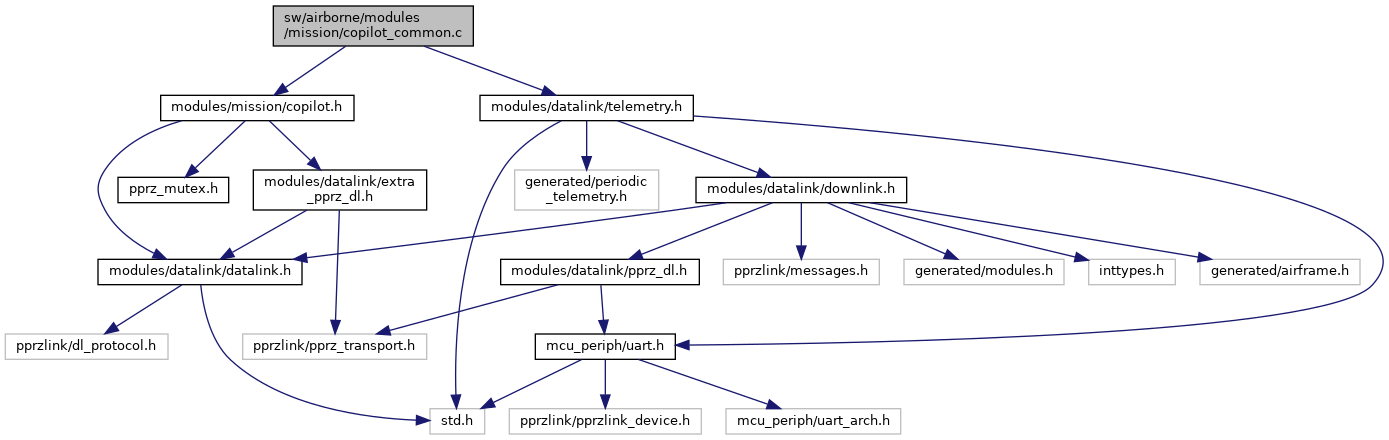
Mission Computer module, interfacing the mission computer (also known as Copilot), based losely on ISaAC: The Intelligent Safety and Airworthiness Co-Pilot module Based on paper "A Payload Verification and Management Framework for Small UAV-based Personal Remote Sensing Systems" by Cal Coopmans and Chris Coffin. More...
Go to the source code of this file.
Functions | |
| void | copilot_init (void) |
| Init function. | |
| void | copilot_periodic (void) |
| Periodic function. | |
| void | copilot_parse_cam_snapshot_dl (uint8_t *buf) |
| copy CAMERA_SNAPSHOT message and mark it to be sent | |
| void | copilot_parse_cam_payload_dl (uint8_t *buf) |
| copy CAMERA_PAYLOAD message and mark it to be sent | |
| void | copilot_parse_copilot_status_dl (uint8_t *buf) |
| copy COPILOT_STATUS message and mark it to be sent | |
| void | copilot_parse_payload_command_dl (uint8_t *buf) |
| Pass through PAYLOAD_COMMAND message and send it as PAYLOAD msg over telemetry. | |
Variables | |
| bool | send_cam_snapshot |
| bool | send_cam_payload |
| bool | send_copilot_status |
| struct CameraPayload | cam_payload |
| struct CameraSnapshot | cam_snapshot |
| struct CopilotStatus | copilot_status |
| pprz_mutex_t | copilot_cam_snapshot_mtx |
| pprz_mutex_t | copilot_cam_payload_mtx |
| pprz_mutex_t | copilot_status_mtx |
Mission Computer module, interfacing the mission computer (also known as Copilot), based losely on ISaAC: The Intelligent Safety and Airworthiness Co-Pilot module Based on paper "A Payload Verification and Management Framework for Small UAV-based Personal Remote Sensing Systems" by Cal Coopmans and Chris Coffin.
Link: http://ieeexplore.ieee.org/abstract/document/6309316/
More info can be found on http://wiki.paparazziuav.org/wiki/Mission_computer
Copilot is intended mainly for mapping applications.
This module processes messages from Copilot, and either forwards them to the GCS (such as CAMERA_SNAPSHOT or CAMERA_PAYLOAD messages), or responds to them as necessary (such as MOVE_WP).
The module assumes the source of the messages is trusted (i.e. not authentication besides AC_ID check is performed).
Definition in file copilot_common.c.
| void copilot_init | ( | void | ) |
Init function.
Definition at line 60 of file copilot_common.c.
References cam_payload, cam_snapshot, copilot_cam_payload_mtx, copilot_cam_snapshot_mtx, copilot_status, copilot_status_mtx, pprz_mtx_init(), send_cam_payload, send_cam_snapshot, and send_copilot_status.
| void copilot_parse_cam_payload_dl | ( | uint8_t * | buf | ) |
copy CAMERA_PAYLOAD message and mark it to be sent
Definition at line 147 of file copilot_common.c.
References cam_payload, copilot_cam_payload_mtx, pprz_mtx_lock(), pprz_mtx_unlock(), and send_cam_payload.
| void copilot_parse_cam_snapshot_dl | ( | uint8_t * | buf | ) |
copy CAMERA_SNAPSHOT message and mark it to be sent
Message processing functions.
In case of multiple cameras, it is up to the payload computer to send CAMERA_SNAPSHOT messages for each camera at proper interval, so the values don't get overwritten.
Definition at line 127 of file copilot_common.c.
References cam_snapshot, copilot_cam_snapshot_mtx, pprz_mtx_lock(), pprz_mtx_unlock(), and send_cam_snapshot.
| void copilot_parse_copilot_status_dl | ( | uint8_t * | buf | ) |
copy COPILOT_STATUS message and mark it to be sent
Definition at line 165 of file copilot_common.c.
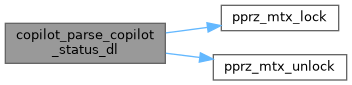
References copilot_status, copilot_status_mtx, pprz_mtx_lock(), pprz_mtx_unlock(), and send_copilot_status.
| void copilot_parse_payload_command_dl | ( | uint8_t * | buf | ) |
Pass through PAYLOAD_COMMAND message and send it as PAYLOAD msg over telemetry.
Definition at line 184 of file copilot_common.c.
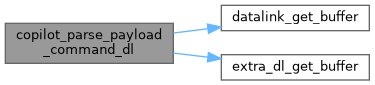
References datalink_get_buffer(), DefaultChannel, DefaultDevice, extra_dl_get_buffer(), and extra_pprz_tp.
| void copilot_periodic | ( | void | ) |
Periodic function.
Definition at line 76 of file copilot_common.c.
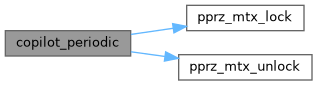
References cam_payload, cam_snapshot, copilot_cam_payload_mtx, copilot_cam_snapshot_mtx, copilot_status, copilot_status_mtx, DefaultChannel, DefaultDevice, pprz_mtx_lock(), pprz_mtx_unlock(), send_cam_payload, send_cam_snapshot, and send_copilot_status.
| struct CameraPayload cam_payload |
Definition at line 51 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_payload_dl(), and copilot_periodic().
| struct CameraSnapshot cam_snapshot |
Definition at line 52 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_snapshot_dl(), and copilot_periodic().
| pprz_mutex_t copilot_cam_payload_mtx |
Definition at line 56 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_payload_dl(), and copilot_periodic().
| pprz_mutex_t copilot_cam_snapshot_mtx |
Definition at line 55 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_snapshot_dl(), and copilot_periodic().
| struct CopilotStatus copilot_status |
Definition at line 53 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_copilot_status_dl(), and copilot_periodic().
| pprz_mutex_t copilot_status_mtx |
Definition at line 57 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_copilot_status_dl(), and copilot_periodic().
| bool send_cam_payload |
Definition at line 48 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_payload_dl(), and copilot_periodic().
| bool send_cam_snapshot |
Definition at line 47 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_cam_snapshot_dl(), and copilot_periodic().
| bool send_copilot_status |
Definition at line 49 of file copilot_common.c.
Referenced by copilot_init(), copilot_parse_copilot_status_dl(), and copilot_periodic().
 1.15.0