|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Dummy plug to set the AHRS from the simple OCaml simulator. More...
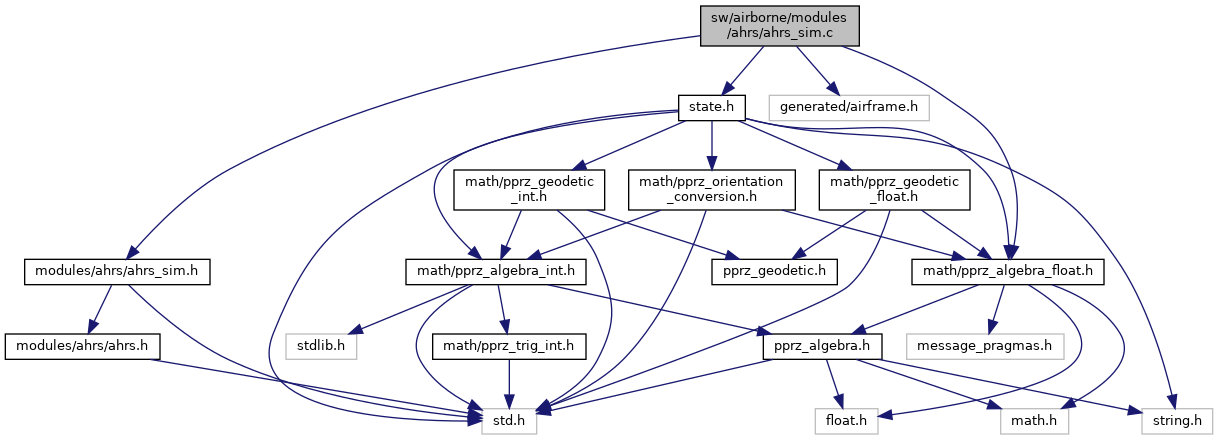
#include "modules/ahrs/ahrs_sim.h"#include "math/pprz_algebra_float.h"#include "generated/airframe.h"#include "state.h"Go to the source code of this file.
Macros | |
| #define | INS_ROLL_NEUTRAL_DEFAULT 0 |
| #define | INS_PITCH_NEUTRAL_DEFAULT 0 |
Functions | |
| void | update_ahrs_from_sim (void) |
Variables | |
| float | sim_phi |
| float | sim_theta |
| float | sim_psi |
| float | sim_p |
| float | sim_q |
| float | sim_r |
| float | ins_roll_neutral = INS_ROLL_NEUTRAL_DEFAULT |
| float | ins_pitch_neutral = INS_PITCH_NEUTRAL_DEFAULT |
Dummy plug to set the AHRS from the simple OCaml simulator.
Definition in file ahrs_sim.c.
| #define INS_PITCH_NEUTRAL_DEFAULT 0 |
Definition at line 46 of file ahrs_sim.c.
Referenced by ArduIMU_init(), ins_xsens700_init(), and ins_xsens_init().
| #define INS_ROLL_NEUTRAL_DEFAULT 0 |
Definition at line 43 of file ahrs_sim.c.
Referenced by ArduIMU_init(), ins_xsens700_init(), and ins_xsens_init().
| void update_ahrs_from_sim | ( | void | ) |
Definition at line 52 of file ahrs_sim.c.
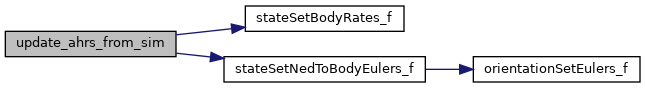
References sim_p, sim_phi, sim_psi, sim_q, sim_r, sim_theta, stateSetBodyRates_f(), and stateSetNedToBodyEulers_f().
| float ins_pitch_neutral = INS_PITCH_NEUTRAL_DEFAULT |
Definition at line 49 of file ahrs_sim.c.
| float ins_roll_neutral = INS_ROLL_NEUTRAL_DEFAULT |
Definition at line 48 of file ahrs_sim.c.
|
extern |
|
extern |
|
extern |
Referenced by update_ahrs_from_sim().
|
extern |
|
extern |
|
extern |
 1.15.0