|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Inter-MCU interface. More...
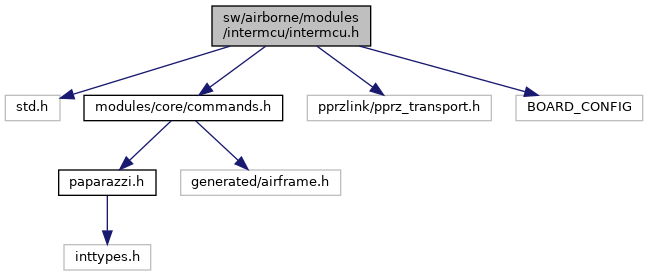
#include "std.h"#include "modules/core/commands.h"#include "pprzlink/pprz_transport.h"#include <BOARD_CONFIG>Go to the source code of this file.
Data Structures | |
| struct | intermcu_t |
Macros | |
| #define | INTERMCU_LOST_CNT 25 /* 50ms with a 512Hz timer TODO fixed value */ |
| #define | INTERMCU_SET_CMD_STATUS(_bit) |
| #define | INTERMCU_CLR_CMD_STATUS(_bit) |
| #define | INTERMCU_GET_CMD_STATUS(_bit) |
Enumerations | |
| enum | intermcu_status { INTERMCU_OK , INTERMCU_LOST } |
| enum | intermcu_cmd_status { INTERMCU_CMD_MOTORS_ON , INTERMCU_CMD_DISARM , INTERMCU_CMD_TIPPROPS , INTERMCU_CMD_FAILSAFE } |
Functions | |
| void | intermcu_init (void) |
| void | intermcu_periodic (void) |
| void | intermcu_event (void) |
Variables | |
| struct intermcu_t | intermcu |
Inter-MCU interface.
Definition in file intermcu.h.
| struct intermcu_t |
Definition at line 60 of file intermcu.h.
| Data Fields | ||
|---|---|---|
| uint8_t | cmd_status | Command status information that is transfered (intermcu_cmd_status). |
| struct link_device * | device | Device used for communication. |
| bool | enabled | If the InterMCU communication is enabled. |
| bool | msg_available | If we have an InterMCU message. |
| enum intermcu_status | status | Status of the INTERMCU. |
| uint8_t | time_since_last_frame | Time since last frame. |
| struct pprz_transport | transport | Transport over communication line (PPRZ). |
| #define INTERMCU_CLR_CMD_STATUS | ( | _bit | ) |
Definition at line 56 of file intermcu.h.
Referenced by intermcu_parse_IMCU_COMMANDS(), and opa_controller_periodic().
| #define INTERMCU_GET_CMD_STATUS | ( | _bit | ) |
Definition at line 57 of file intermcu.h.
Referenced by intermcu_parse_IMCU_COMMANDS(), and opa_controller_periodic().
| #define INTERMCU_LOST_CNT 25 /* 50ms with a 512Hz timer TODO fixed value */ |
Definition at line 35 of file intermcu.h.
Referenced by intermcu_periodic().
| #define INTERMCU_SET_CMD_STATUS | ( | _bit | ) |
Definition at line 55 of file intermcu.h.
Referenced by intermcu_send_commands(), and opa_controller_ap_disarm().
| enum intermcu_cmd_status |
Definition at line 47 of file intermcu.h.
| enum intermcu_status |
| Enumerator | |
|---|---|
| INTERMCU_OK | InterMCU communication is OK. |
| INTERMCU_LOST | No interMCU communication anymore. |
Definition at line 41 of file intermcu.h.
|
extern |
Definition at line 95 of file intermcu_ap.c.
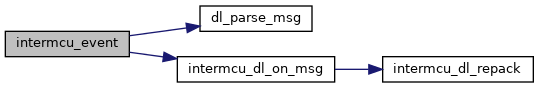
References datalink_nb_msgs, datalink_time, dl_parse_msg(), imcu_msg_buf, intermcu, and intermcu_dl_on_msg().
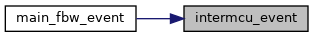
Referenced by main_fbw_event().
|
extern |
Definition at line 69 of file intermcu_ap.c.
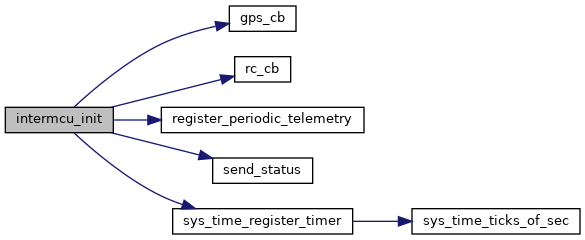
References DefaultPeriodic, gps_cb(), gps_ev, IMCU_GPS_ID, IMCU_RADIO_CONTROL_ID, intermcu, rc_cb(), rc_ev, register_periodic_telemetry(), and send_status().
|
extern |
Definition at line 79 of file intermcu_ap.c.
References DefaultPeriodic, intermcu, INTERMCU_LOST, and INTERMCU_LOST_CNT.
|
extern |
Definition at line 45 of file intermcu_ap.c.
Referenced by fbw_safety_check(), gps_cb(), intermcu_event(), intermcu_forward_uplink(), intermcu_init(), intermcu_parse_IMCU_COMMANDS(), intermcu_periodic(), intermcu_send_commands(), intermcu_send_spektrum_bind(), intermcu_send_status(), intermcu_set_enabled(), opa_controller_periodic(), rc_cb(), and rc_cb().
 1.15.0