|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Guiding vector field algorithm for 2D and 3D complex trajectories. More...
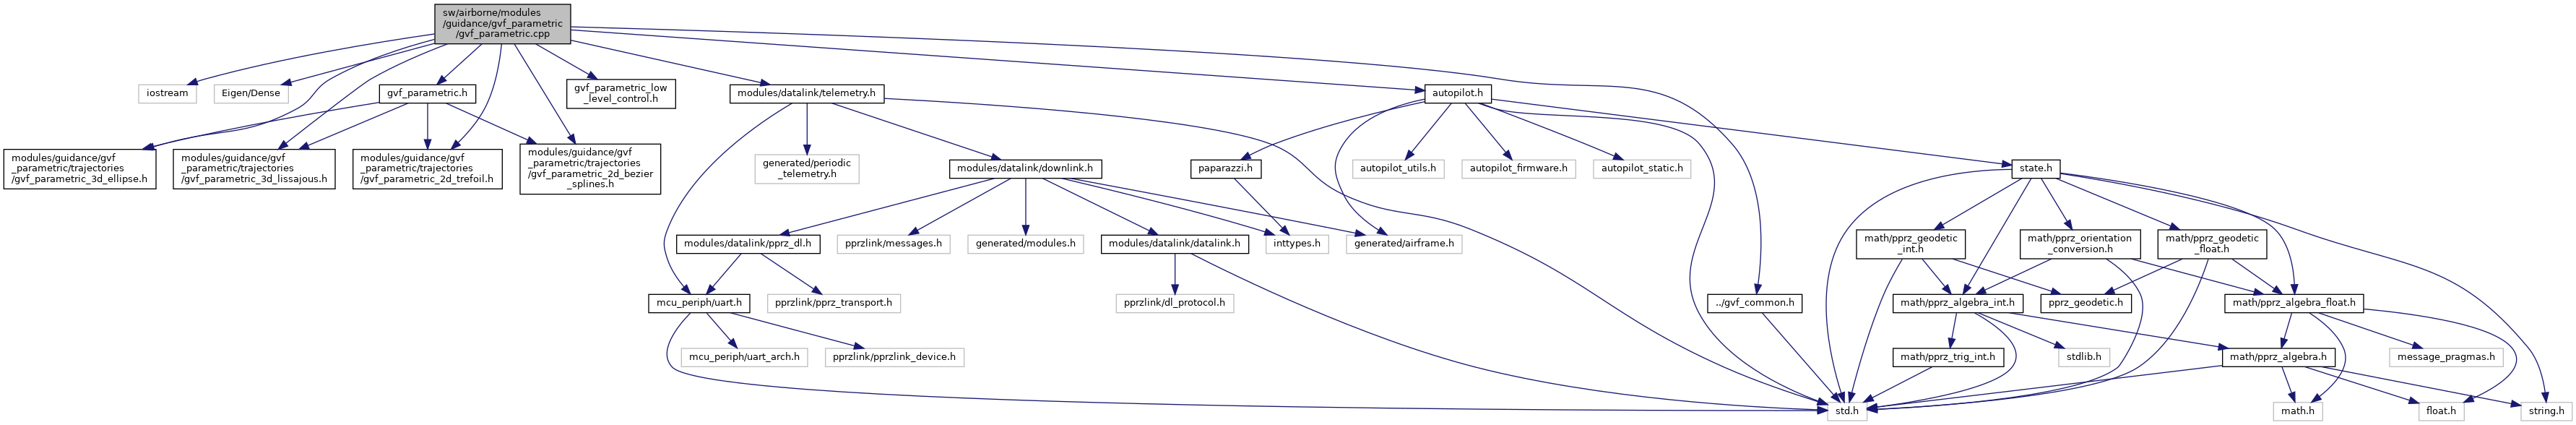
#include <iostream>#include <Eigen/Dense>#include "gvf_parametric.h"#include "autopilot.h"#include "gvf_adapted_step.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Macros | |
| #define | GVF_PARAMETRIC_CONTROL_KROLL 1 |
| #define | GVF_PARAMETRIC_CONTROL_KCLIMB 1 |
| #define | GVF_PARAMETRIC_CONTROL_L 0.1 |
| #define | GVF_PARAMETRIC_CONTROL_BETA 0.01 |
| #define | GVF_PARAMETRIC_CONTROL_KPSI 1 |
Functions | |
| static void | send_gvf_parametric (struct transport_tx *trans, struct link_device *dev) |
| TELEMETRY -----------------------------------------------------------—. | |
| void | gvf_parametric_init (void) |
| void | gvf_parametric_control_2D (float kx, float ky, float f1, float f2, float f1d, float f2d, float f1dd, float f2dd) |
| void | gvf_parametric_set_direction (int8_t s) |
Variables | |
| gvf_parametric_con | gvf_parametric_control |
| gvf_parametric_tel | gvf_parametric_telemetry = {{0}, 1, 0} |
| uint32_t | gvf_parametric_t0 = 0 |
Guiding vector field algorithm for 2D and 3D complex trajectories.
Definition in file gvf_parametric.cpp.
| #define GVF_PARAMETRIC_CONTROL_BETA 0.01 |
Default scale for w
Definition at line 56 of file gvf_parametric.cpp.
Referenced by gvf_parametric_init().
| #define GVF_PARAMETRIC_CONTROL_KCLIMB 1 |
Default gain kclimb for tuning the climbing setting point
Definition at line 39 of file gvf_parametric.cpp.
Referenced by gvf_parametric_init().
| #define GVF_PARAMETRIC_CONTROL_KPSI 1 |
Default gain kpsi for tuning the alignment of the vehicle with the vector field
Definition at line 63 of file gvf_parametric.cpp.
Referenced by gvf_parametric_init().
| #define GVF_PARAMETRIC_CONTROL_KROLL 1 |
Default gain kroll for tuning the "coordinated turn"
Definition at line 34 of file gvf_parametric.cpp.
Referenced by gvf_parametric_init().
| #define GVF_PARAMETRIC_CONTROL_L 0.1 |
Default scale for the error signals
Definition at line 47 of file gvf_parametric.cpp.
Referenced by gvf_parametric_init().
| void gvf_parametric_control_2D | ( | float | kx, |
| float | ky, | ||
| float | f1, | ||
| float | f2, | ||
| float | f1d, | ||
| float | f2d, | ||
| float | f1dd, | ||
| float | f2dd ) |
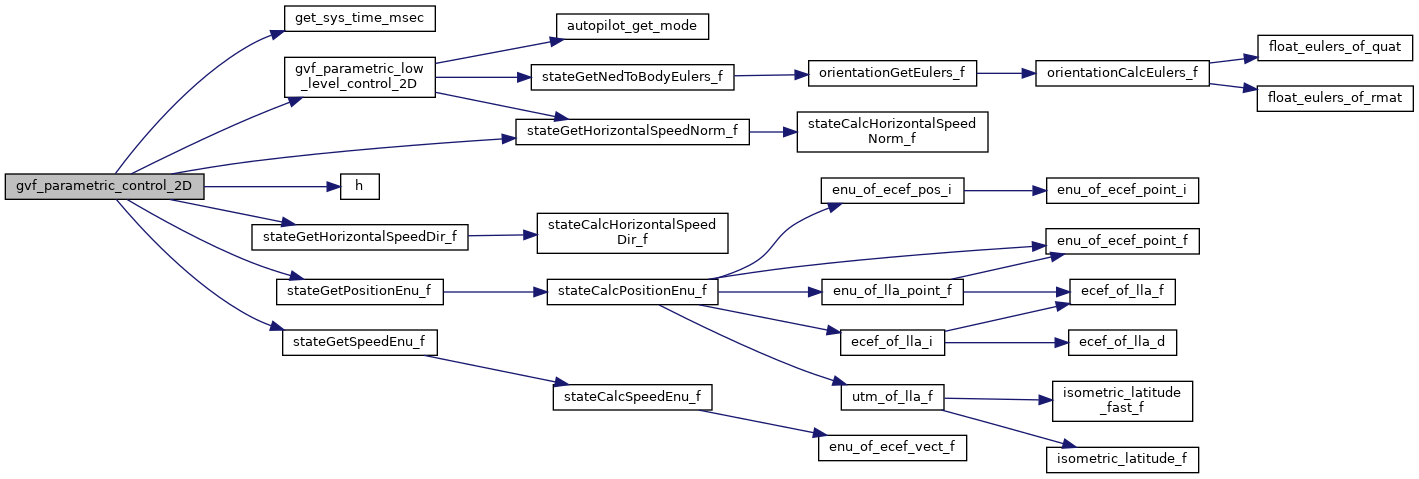
Definition at line 149 of file gvf_parametric.cpp.
References course, desired_x, desired_y, get_sys_time_msec(), ground_speed, gvf_c_ctrl, gvf_c_info, gvf_low_level_control_2D(), gvf_parametric_control, gvf_parametric_t0, gvf_parametric_telemetry, h(), J, stateGetHorizontalSpeedDir_f(), stateGetHorizontalSpeedNorm_f(), stateGetPositionEnu_f(), stateGetSpeedEnu_f(), step_adaptation(), EnuCoor_f::x, and EnuCoor_f::y.
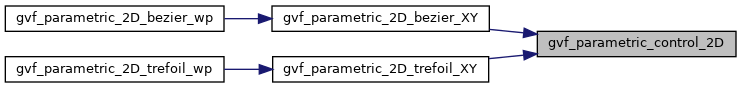
Referenced by nav_gvf_parametric_2D_bezier_run(), and nav_gvf_parametric_2D_trefoil_XY().
| void gvf_parametric_init | ( | void | ) |
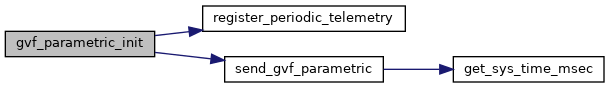
Definition at line 128 of file gvf_parametric.cpp.
References DefaultPeriodic, gvf_c_params, gvf_parametric_control, GVF_PARAMETRIC_CONTROL_BETA, GVF_PARAMETRIC_CONTROL_KCLIMB, GVF_PARAMETRIC_CONTROL_KPSI, GVF_PARAMETRIC_CONTROL_KROLL, GVF_PARAMETRIC_CONTROL_L, GVF_PARAMETRIC_CONTROL_STEP_ADAPTATION, register_periodic_telemetry(), and send_gvf_parametric().
| void gvf_parametric_set_direction | ( | int8_t | s | ) |
Definition at line 437 of file gvf_parametric.cpp.
References gvf_parametric_control, and s.
|
static |
TELEMETRY -----------------------------------------------------------—.
Definition at line 85 of file gvf_parametric.cpp.
References dev, get_sys_time_msec(), gvf_parametric_control, gvf_parametric_t0, gvf_parametric_telemetry, and gvf_parametric_trajectory.
Referenced by gvf_parametric_init().
| gvf_parametric_con gvf_parametric_control |
Definition at line 75 of file gvf_parametric.cpp.
Referenced by gvf_parametric_control_2D(), gvf_parametric_init(), gvf_parametric_set_direction(), nav_gvf_parametric_2D_bezier_run(), nav_gvf_parametric_2D_bezier_wp(), nav_gvf_parametric_2D_trefoil_XY(), and send_gvf_parametric().
| uint32_t gvf_parametric_t0 = 0 |
Definition at line 79 of file gvf_parametric.cpp.
Referenced by gvf_parametric_control_2D(), and send_gvf_parametric().
| gvf_parametric_tel gvf_parametric_telemetry = {{0}, 1, 0} |
Definition at line 76 of file gvf_parametric.cpp.
Referenced by gvf_parametric_control_2D(), nav_gvf_parametric_2D_bezier_wp(), and send_gvf_parametric().
 1.15.0