|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Windtunnel controller. More...
#include <std.h>Go to the source code of this file.
Data Structures | |
| struct | min_max_ctrl_t |
Functions | |
| void | ctrl_windtunnel_init (void) |
| void | guidance_module_enter (void) |
| Entering the module (user switched to module). | |
| void | guidance_module_run (bool in_flight) |
| Main guidance loop. | |
Variables | |
| float | ctrl_windtunnel_steptime |
| struct min_max_ctrl_t | ctrl_windtunnel_throttle |
| struct min_max_ctrl_t | ctrl_windtunnel_flaps |
Windtunnel controller.
Implements a controller for the windtunnel which does some step controls
Definition in file ctrl_windtunnel.h.
| struct min_max_ctrl_t |
Definition at line 33 of file ctrl_windtunnel.h.
| Data Fields | ||
|---|---|---|
| float | current | |
| float | max | |
| float | min | |
| float | step | |
|
extern |
Definition at line 77 of file ctrl_windtunnel.c.
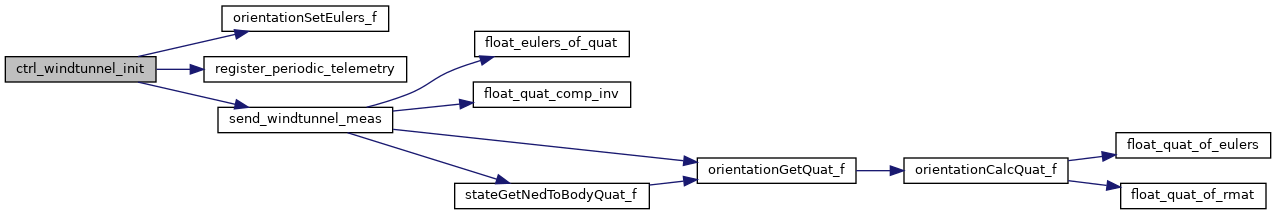
References ctrl_windtunnel, DefaultPeriodic, orientationSetEulers_f(), register_periodic_telemetry(), send_windtunnel_meas(), WINDTUNNEL_TO_BODY_PHI, WINDTUNNEL_TO_BODY_PSI, and WINDTUNNEL_TO_BODY_THETA.
|
extern |
Entering the module (user switched to module).
Entering the module (user switched to module).
Definition at line 77 of file ctrl_module_innerloop_demo.c.
|
extern |
Main guidance loop.
| [in] | in_flight | Whether we are in flight or not |
Definition at line 82 of file ctrl_module_innerloop_demo.c.
|
extern |
Definition at line 55 of file ctrl_windtunnel.c.
Referenced by ctrl_module_run().
|
extern |
Definition at line 53 of file ctrl_windtunnel.c.
Referenced by ctrl_module_run().
|
extern |
Definition at line 54 of file ctrl_windtunnel.c.
Referenced by ctrl_module_run().
 1.15.0