|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
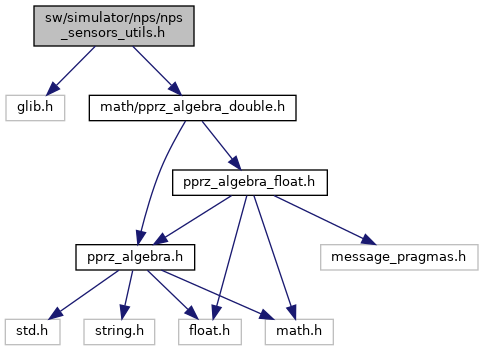
Go to the source code of this file.
Data Structures | |
| struct | BoozDatedSensor |
| struct | BoozDatedSensor_Single |
Functions | |
| void | UpdateSensorLatency (double time, gpointer cur_reading, GSList **history, double latency, gpointer sensor_reading) |
| void | UpdateSensorLatency_Single (double time, gpointer cur_reading, GSList **history, double latency, gpointer sensor_reading) |
| struct BoozDatedSensor |
Definition at line 7 of file nps_sensors_utils.h.
| Data Fields | ||
|---|---|---|
| double | time | |
| struct DoubleVect3 * | value | |
| struct BoozDatedSensor_Single |
Definition at line 12 of file nps_sensors_utils.h.
| Data Fields | ||
|---|---|---|
| double | time | |
| double * | value | |
|
extern |
Definition at line 11 of file nps_sensors_utils.c.
References g_memdup2, BoozDatedSensor::time, BoozDatedSensor::value, and VECT3_COPY.
Referenced by nps_sensor_gps_run_step().
|
extern |
Definition at line 32 of file nps_sensors_utils.c.
References g_memdup2, BoozDatedSensor_Single::time, and BoozDatedSensor_Single::value.
Referenced by nps_sensor_gps_run_step().
 1.15.0