|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Data Structures | |
| struct | DoubleVect2 |
| struct | DoubleVect3 |
| struct | DoubleQuat |
| Roation quaternion. More... | |
| struct | DoubleMat33 |
| struct | DoubleRMat |
| rotation matrix More... | |
| struct | DoubleEulers |
| euler angles More... | |
| struct | DoubleRates |
| angular rates More... | |
Macros | |
| #define | DOUBLE_VECT3_ROUND(_v) |
| #define | DOUBLE_VECT3_RINT(_vout, _vin) |
| #define | DOUBLE_RMAT_OF_EULERS(_rm, _e) |
| #define | DOUBLE_RMAT_OF_EULERS_321(_rm, _e) |
| #define | DOUBLE_QUAT_OF_EULERS(_q, _e) |
| #define | DOUBLE_EULERS_OF_QUAT(_e, _q) |
| #define | DOUBLE_QUAT_VMULT(v_out, q, v_in) |
Functions | |
| static double | double_vect3_norm (struct DoubleVect3 *v) |
| static void | double_vect3_normalize (struct DoubleVect3 *v) |
| normalize 3D vector in place | |
| static void | double_quat_identity (struct DoubleQuat *q) |
| initialises a quaternion to identity | |
| static double | double_quat_norm (struct DoubleQuat *q) |
| static void | double_quat_normalize (struct DoubleQuat *q) |
| void | double_rmat_of_eulers_321 (struct DoubleRMat *rm, struct DoubleEulers *e) |
| Rotation matrix from 321 Euler angles (double). | |
| void | double_quat_of_eulers (struct DoubleQuat *q, struct DoubleEulers *e) |
| void | double_eulers_of_quat (struct DoubleEulers *e, struct DoubleQuat *q) |
| void | double_quat_vmult (struct DoubleVect3 *v_out, struct DoubleQuat *q, struct DoubleVect3 *v_in) |
| void | double_quat_comp (struct DoubleQuat *a2c, struct DoubleQuat *a2b, struct DoubleQuat *b2c) |
| Composition (multiplication) of two quaternions. | |
| static void | double_rmat_identity (struct DoubleRMat *rm) |
| initialises a rotation matrix to identity | |
| void | double_rmat_inv (struct DoubleRMat *m_b2a, struct DoubleRMat *m_a2b) |
| Inverse/transpose of a rotation matrix. | |
| void | double_rmat_comp (struct DoubleRMat *m_a2c, struct DoubleRMat *m_a2b, struct DoubleRMat *m_b2c) |
| Composition (multiplication) of two rotation matrices. | |
| void | double_rmat_vmult (struct DoubleVect3 *vb, struct DoubleRMat *m_a2b, struct DoubleVect3 *va) |
| rotate 3D vector by rotation matrix. | |
| void | double_rmat_transp_vmult (struct DoubleVect3 *vb, struct DoubleRMat *m_b2a, struct DoubleVect3 *va) |
| rotate 3D vector by transposed rotation matrix. | |
| void | double_rmat_of_quat (struct DoubleRMat *rm, struct DoubleQuat *q) |
| static void | double_rmat_of_eulers (struct DoubleRMat *rm, struct DoubleEulers *e) |
| struct DoubleVect2 |
Definition at line 41 of file pprz_algebra_double.h.
| Data Fields | ||
|---|---|---|
| double | x | |
| double | y | |
| struct DoubleVect3 |
Definition at line 46 of file pprz_algebra_double.h.
| Data Fields | ||
|---|---|---|
| double | x | |
| double | y | |
| double | z | |
| struct DoubleQuat |
Roation quaternion.
Definition at line 55 of file pprz_algebra_double.h.
| Data Fields | ||
|---|---|---|
| double | qi | |
| double | qx | |
| double | qy | |
| double | qz | |
| struct DoubleMat33 |
Definition at line 62 of file pprz_algebra_double.h.
| Data Fields | ||
|---|---|---|
| double | m[3 *3] | |
| struct DoubleRMat |
rotation matrix
Definition at line 69 of file pprz_algebra_double.h.
| Data Fields | ||
|---|---|---|
| double | m[3 *3] | |
| #define DOUBLE_EULERS_OF_QUAT | ( | _e, | |
| _q ) |
Definition at line 204 of file pprz_algebra_double.h.
| #define DOUBLE_QUAT_OF_EULERS | ( | _q, | |
| _e ) |
Definition at line 203 of file pprz_algebra_double.h.
| #define DOUBLE_QUAT_VMULT | ( | v_out, | |
| q, | |||
| v_in ) |
Definition at line 205 of file pprz_algebra_double.h.
| #define DOUBLE_RMAT_OF_EULERS | ( | _rm, | |
| _e ) |
Definition at line 201 of file pprz_algebra_double.h.
| #define DOUBLE_RMAT_OF_EULERS_321 | ( | _rm, | |
| _e ) |
Definition at line 202 of file pprz_algebra_double.h.
| #define DOUBLE_VECT3_RINT | ( | _vout, | |
| _vin ) |
Definition at line 94 of file pprz_algebra_double.h.
| #define DOUBLE_VECT3_ROUND | ( | _v | ) |
Definition at line 91 of file pprz_algebra_double.h.
Referenced by nps_sensor_accel_run_step(), nps_sensor_gyro_run_step(), and nps_sensor_mag_run_step().
|
extern |
Definition at line 68 of file pprz_algebra_double.c.
References DoubleEulers::phi, DoubleEulers::psi, DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, DoubleQuat::qz, and DoubleEulers::theta.
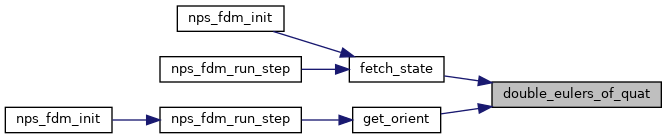
Referenced by fetch_state(), and get_orient().
|
extern |
Composition (multiplication) of two quaternions.
a2c = a2b comp b2c , aka a2c = a2b * b2c
Definition at line 114 of file pprz_algebra_double.c.
References DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, and DoubleQuat::qz.
Referenced by get_orient().
|
inlinestatic |
initialises a quaternion to identity
Definition at line 118 of file pprz_algebra_double.h.
References DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, and DoubleQuat::qz.
|
inlinestatic |
Definition at line 126 of file pprz_algebra_double.h.
References DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, DoubleQuat::qz, and SQUARE.
Referenced by double_quat_normalize().
|
inlinestatic |
Definition at line 132 of file pprz_algebra_double.h.
References double_quat_norm(), DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, and DoubleQuat::qz.
|
extern |
Definition at line 49 of file pprz_algebra_double.c.
References DoubleEulers::phi, DoubleEulers::psi, DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, DoubleQuat::qz, and DoubleEulers::theta.
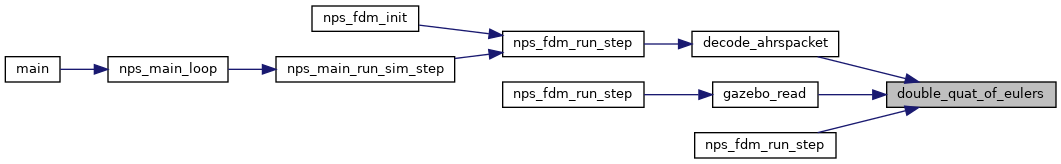
Referenced by gazebo_read(), gazebo_read(), and nps_fdm_run_step().
|
extern |
Definition at line 90 of file pprz_algebra_double.c.
References DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, DoubleQuat::qz, DoubleVect3::x, DoubleVect3::y, and DoubleVect3::z.
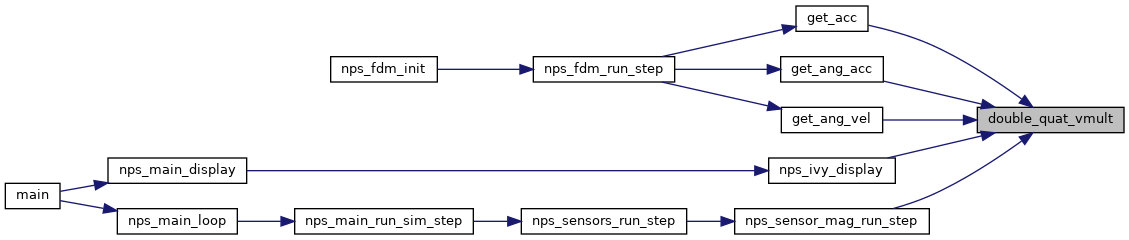
Referenced by get_acc(), nps_ivy_display(), and nps_sensor_mag_run_step().
|
extern |
Composition (multiplication) of two rotation matrices.
m_a2c = m_a2b comp m_b2c , aka m_a2c = m_b2c * m_a2b
Definition at line 139 of file pprz_algebra_double.c.
References DoubleRMat::m.
|
inlinestatic |
initialises a rotation matrix to identity
Definition at line 166 of file pprz_algebra_double.h.
References FLOAT_MAT33_DIAG.
|
extern |
Inverse/transpose of a rotation matrix.
m_b2a = inv(_m_a2b) = transp(_m_a2b)
Definition at line 123 of file pprz_algebra_double.c.
References RMAT_ELMT.
|
inlinestatic |
Definition at line 195 of file pprz_algebra_double.h.
References double_rmat_of_eulers_321().
Referenced by nps_sensor_mag_init(), and nps_sensors_init().
|
extern |
Rotation matrix from 321 Euler angles (double).
The Euler angles are interpreted as zy'x'' (intrinsic) rotation. First rotate around z with psi, then around the new y' with theta, then around new x'' with phi. This is the same as a xyz (extrinsic) rotation, rotating around the fixed x, then y then z axis.
| [out] | rm | pointer to rotation matrix |
| [in] | e | pointer to Euler angles |
Definition at line 29 of file pprz_algebra_double.c.
References DoubleEulers::phi, DoubleEulers::psi, RMAT_ELMT, and DoubleEulers::theta.
Referenced by double_rmat_of_eulers().
|
extern |
Definition at line 173 of file pprz_algebra_double.c.
References M_SQRT2, DoubleQuat::qi, DoubleQuat::qx, DoubleQuat::qy, DoubleQuat::qz, and RMAT_ELMT.
|
extern |
rotate 3D vector by transposed rotation matrix.
vb = m_b2a^T * va
Definition at line 165 of file pprz_algebra_double.c.
References DoubleRMat::m, DoubleVect3::x, DoubleVect3::y, and DoubleVect3::z.
|
extern |
rotate 3D vector by rotation matrix.
vb = m_a2b * va
Definition at line 155 of file pprz_algebra_double.c.
References DoubleRMat::m, DoubleVect3::x, DoubleVect3::y, and DoubleVect3::z.
|
inlinestatic |
Definition at line 100 of file pprz_algebra_double.h.
References VECT3_NORM2.
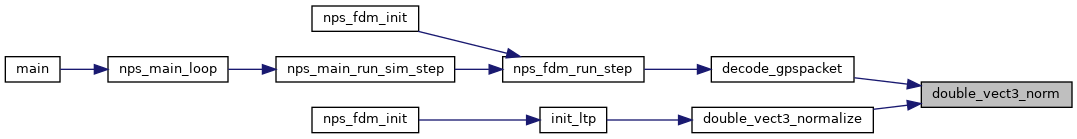
Referenced by double_vect3_normalize().
|
inlinestatic |
normalize 3D vector in place
Definition at line 106 of file pprz_algebra_double.h.
References double_vect3_norm(), DoubleVect3::x, DoubleVect3::y, and DoubleVect3::z.
Referenced by init_ltp().
 1.15.0