|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Macros | |
| #define | RATE_I 0 |
| #define | RATE_F 1 |
Functions | |
| void | stateCalcBodyRates_i (void) |
| void | stateCalcBodyRates_f (void) |
| static bool | stateIsRateValid (void) |
| Test if rates are valid. | |
| static void | stateSetBodyRates_i (uint16_t id, struct Int32Rates *body_rate) |
| Set vehicle body angular rate (int). | |
| static void | stateSetBodyRates_f (uint16_t id, struct FloatRates *body_rate) |
| Set vehicle body angular rate (float). | |
| static struct Int32Rates * | stateGetBodyRates_i (void) |
| Get vehicle body angular rate (int). | |
| static struct FloatRates * | stateGetBodyRates_f (void) |
| Get vehicle body angular rate (float). | |
Variables | |
| uint8_t | State::rate_status |
| Holds the status bits for all angular rate representations. | |
| uint16_t | State::rates_input_filter |
| Holds the input filter id for rates. | |
| struct Int32Rates | State::body_rates_i |
| Angular rates in body frame. | |
| struct FloatRates | State::body_rates_f |
| Angular rates in body frame. | |
| #define RATE_F 1 |
Definition at line 117 of file state.h.
Referenced by stateCalcBodyRates_f(), stateCalcBodyRates_i(), stateGetBodyRates_f(), and stateSetBodyRates_f().
| #define RATE_I 0 |
Definition at line 116 of file state.h.
Referenced by stateCalcBodyRates_f(), stateCalcBodyRates_i(), stateGetBodyRates_i(), and stateSetBodyRates_i().
| void stateCalcBodyRates_f | ( | void | ) |
Definition at line 1377 of file state.c.
References RATE_F, RATE_I, RATES_FLOAT_OF_BFP, and state.
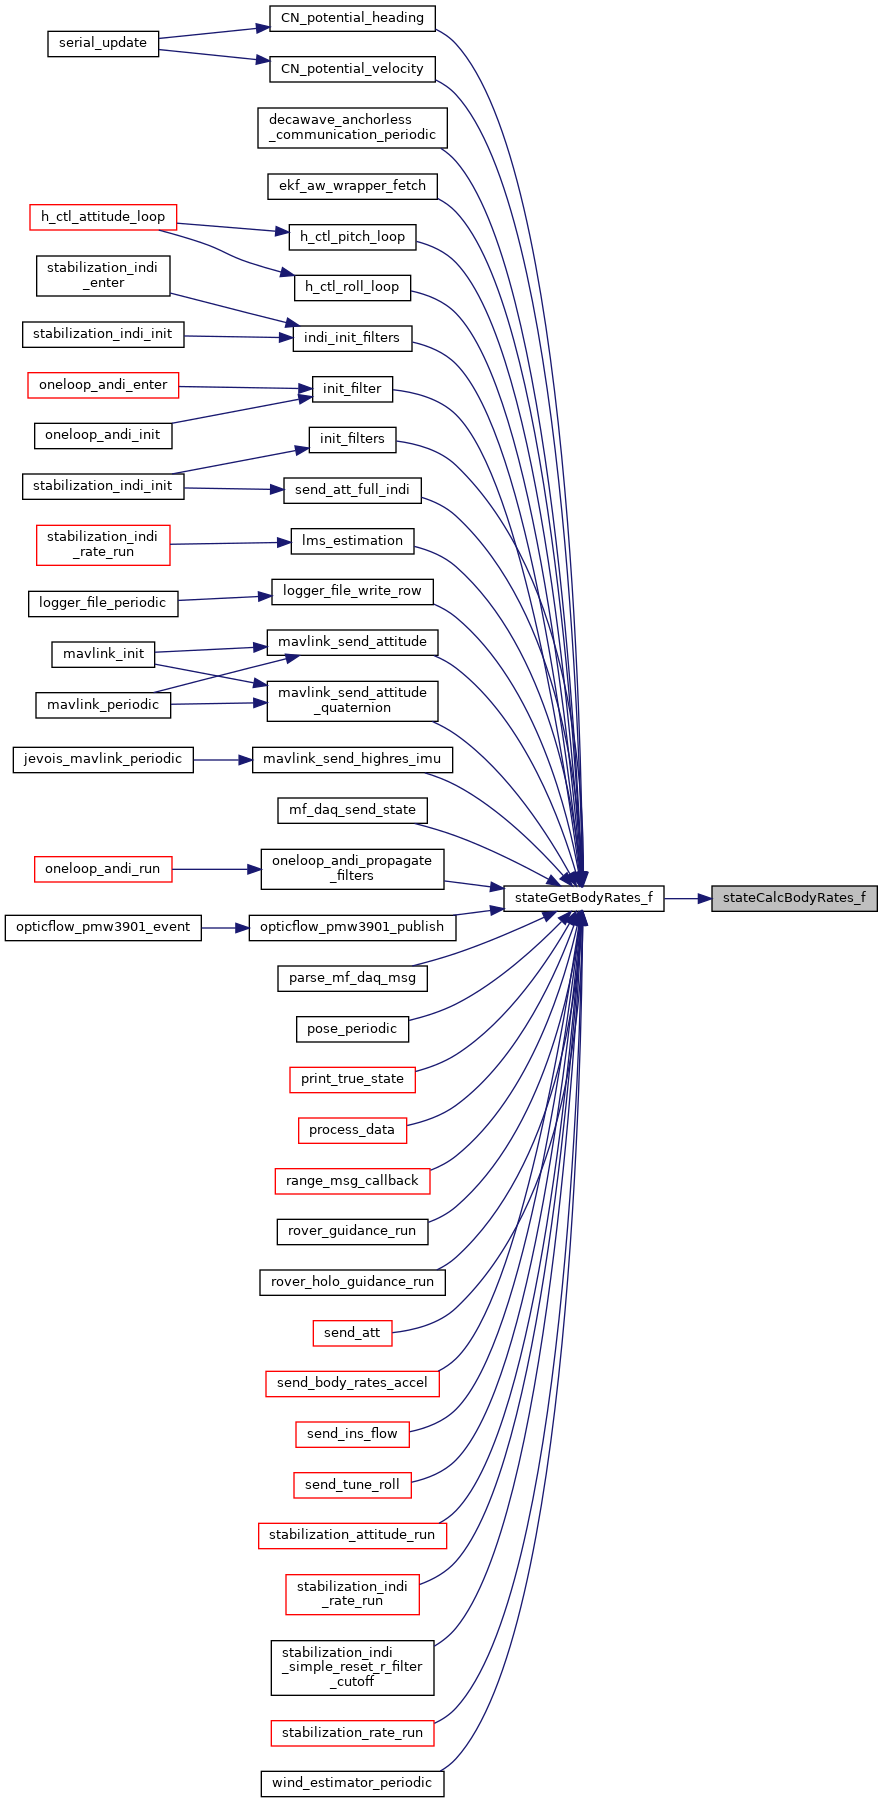
Referenced by stateGetBodyRates_f().
| void stateCalcBodyRates_i | ( | void | ) |
Definition at line 1362 of file state.c.
References RATE_F, RATE_I, RATES_BFP_OF_REAL, and state.
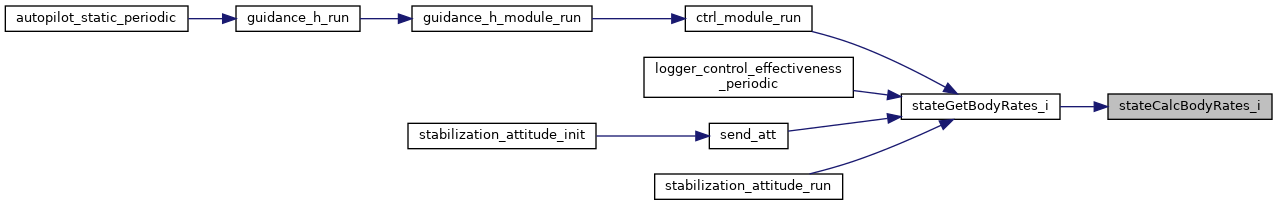
Referenced by stateGetBodyRates_i().
|
inlinestatic |
Get vehicle body angular rate (float).
Definition at line 1392 of file state.h.
References RATE_F, state, and stateCalcBodyRates_f().
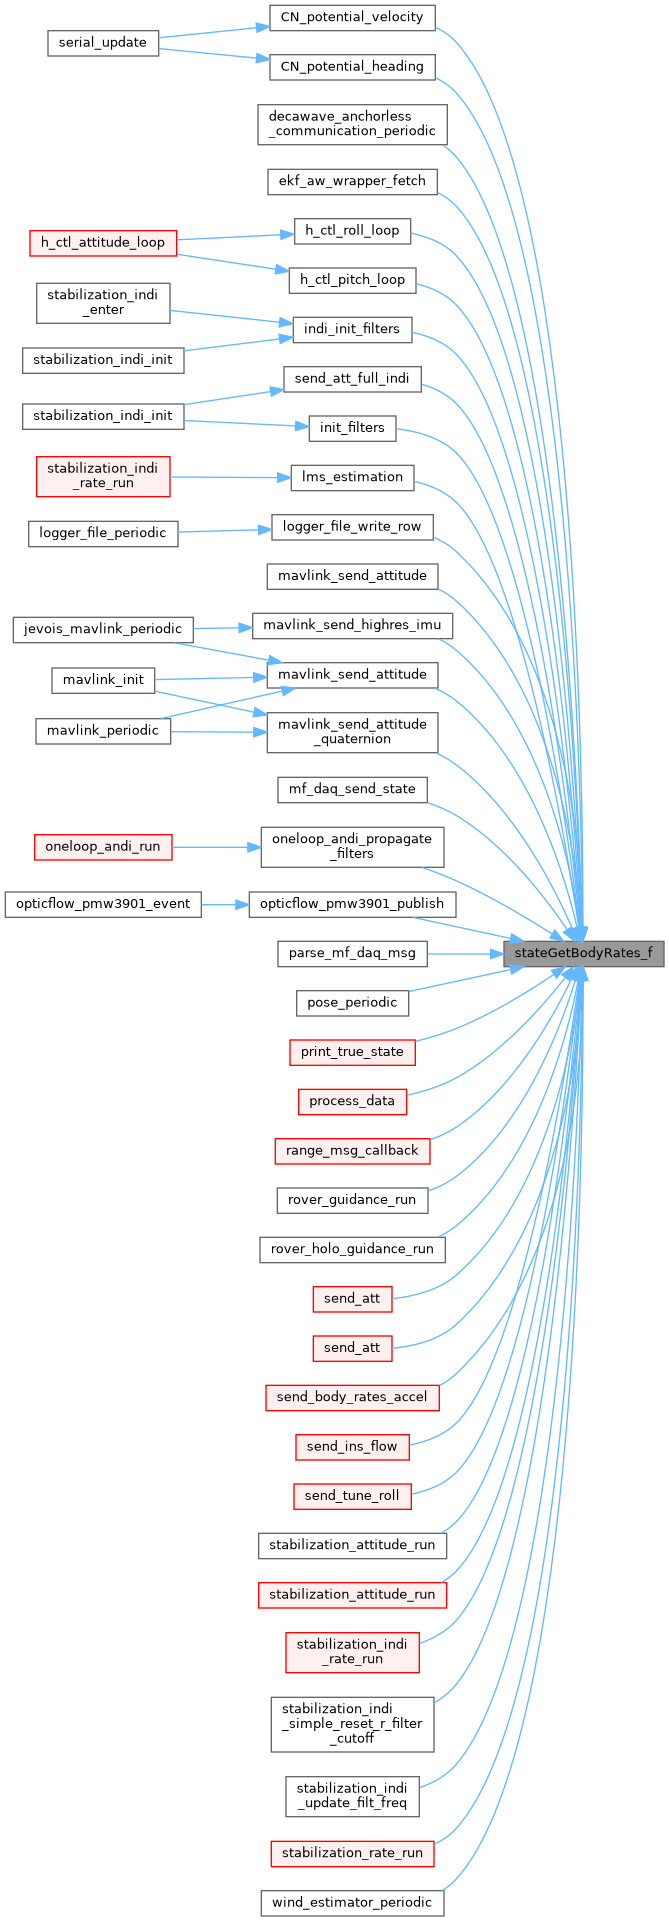
Referenced by CN_potential_heading(), CN_potential_velocity(), decawave_anchorless_communication_periodic(), eff_scheduling_rotwing_update_airspeed(), ekf_aw_wrapper_fetch(), h_ctl_pitch_loop(), h_ctl_roll_loop(), indi_init_filters(), init_filters(), lms_estimation(), logger_file_write_row(), mavlink_send_attitude(), mavlink_send_attitude(), mavlink_send_attitude_quaternion(), mavlink_send_highres_imu(), mf_daq_send_state(), oneloop_andi_propagate_filters(), oneloop_nB_propagate_filters(), opticflow_pmw3901_publish(), parse_mf_daq_msg(), pose_periodic(), print_true_state(), process_data(), range_msg_callback(), rover_guidance_run(), rover_holo_guidance_run(), send_att(), send_att(), send_att(), send_att_full_indi(), send_body_rates_accel(), send_ins_flow(), send_tune_roll(), stabilization_andi_enter(), stabilization_andi_run(), stabilization_attitude_plane_pid_run(), stabilization_attitude_run(), stabilization_attitude_run(), stabilization_indi_rate_run(), stabilization_indi_simple_reset_r_filter_cutoff(), stabilization_indi_update_filt_freq(), stabilization_rate_run(), and wind_estimator_periodic().
|
inlinestatic |
Get vehicle body angular rate (int).
Definition at line 1383 of file state.h.
References RATE_I, state, and stateCalcBodyRates_i().
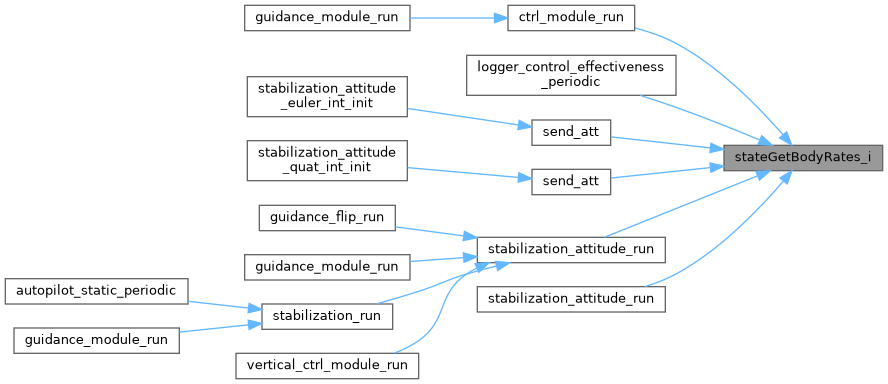
Referenced by ctrl_module_run(), logger_control_effectiveness_periodic(), send_att(), send_att(), stabilization_attitude_run(), and stabilization_attitude_run().
|
inlinestatic |
|
inlinestatic |
Set vehicle body angular rate (float).
Definition at line 1371 of file state.h.
References RATE_F, RATES_COPY, state, and STATE_CHECK_INPUT_AND_RETURN.
Referenced by ahrs_vectornav_propagate(), ArduIMU_event(), ArduIMU_periodic(), compute_body_orientation_and_rates(), compute_body_orientation_and_rates(), compute_body_orientation_and_rates(), ekf_run(), ins_ekf2_publish_attitude(), ins_float_invariant_propagate(), ins_vectornav_propagate(), set_body_orientation_and_rates(), set_body_state_from_quat(), set_state_from_ins(), sim_overwrite_ahrs(), update_ahrs_from_sim(), update_state_interface(), update_state_interface(), and vn100_event_task().
|
inlinestatic |
Set vehicle body angular rate (int).
Definition at line 1361 of file state.h.
References RATE_I, RATES_COPY, state, and STATE_CHECK_INPUT_AND_RETURN.
Referenced by set_body_state_from_quat(), and set_body_state_from_quat().
| struct FloatRates State::body_rates_f |
| struct Int32Rates State::body_rates_i |
Angular rates in body frame.
Units: rad/s in BFP with INT32_RATE_FRAC
| uint8_t State::rate_status |
 1.15.0