|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
A guidance mode based on Incremental Nonlinear Dynamic Inversion Come to IROS2016 to learn more! More...
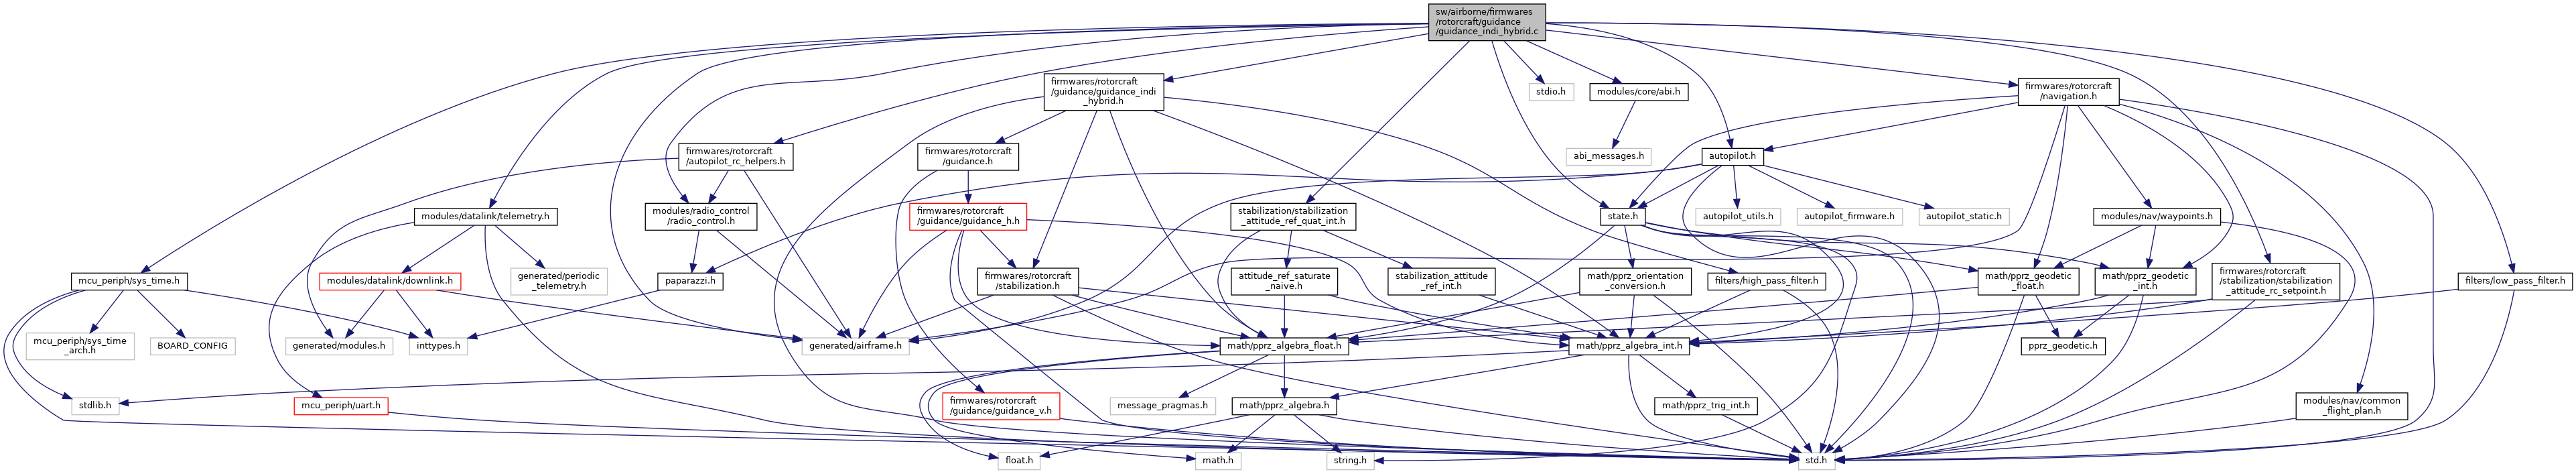
#include "generated/airframe.h"#include "firmwares/rotorcraft/guidance/guidance_indi_hybrid.h"#include "modules/radio_control/radio_control.h"#include "firmwares/rotorcraft/autopilot_rc_helpers.h"#include "state.h"#include "mcu_periph/sys_time.h"#include "autopilot.h"#include "stdio.h"#include "filters/low_pass_filter.h"#include "filters/quaternion_filter.h"#include "filters/low_pass_filter_types.h"#include "modules/core/abi.h"#include "firmwares/rotorcraft/navigation.h"#include "modules/datalink/telemetry.h"Go to the source code of this file.
Functions | |
| static void | vel_sp_cb (uint8_t sender_id, struct FloatVect3 *vel_sp) |
| ABI callback that obtains the velocity setpoint from a module. | |
| static void | guidance_indi_init_filters (struct FloatEulers *eulers) |
| Initialized low pass filters. | |
| static void | guidance_indi_propagate_filters (void) |
| Low pass the accelerometer measurements to remove noise from vibrations. | |
| static void | send_eff_mat_guid_indi_hybrid (struct transport_tx *trans, struct link_device *dev) |
| static void | send_guidance_indi_hybrid (struct transport_tx *trans, struct link_device *dev) |
| void | guidance_indi_init (void) |
| Init function. | |
| void | guidance_indi_enter (void) |
| Call upon entering indi guidance. | |
| void | guidance_set_min_max_airspeed (float min_airspeed, float max_airspeed) |
| void | guidance_set_max_bank_angle (float max_bank) |
| void | guidance_set_max_climb_speed (float max_climb_speed_quad, float max_climb_speed_fwd) |
| void | guidance_set_max_descend_speed (float max_descend_speed_quad, float max_descend_speed_fwd) |
| struct StabilizationSetpoint | guidance_indi_run (struct FloatVect3 *accel_sp, float heading_sp) |
| static struct FloatVect3 | compute_accel_from_speed_sp (struct FloatVect3 *speed_sp) |
| static float | bound_vz_sp (float vz_sp) |
| struct FloatVect3 WEAK | guidance_indi_controller (bool in_flight UNUSED, struct HorizontalGuidance *gh, struct VerticalGuidance *gv, enum GuidanceIndiHybrid_HMode h_mode, enum GuidanceIndiHybrid_VMode v_mode) |
| struct StabilizationSetpoint | guidance_indi_run_mode (bool in_flight UNUSED, struct HorizontalGuidance *gh, struct VerticalGuidance *gv, enum GuidanceIndiHybrid_HMode h_mode, enum GuidanceIndiHybrid_VMode v_mode) |
| float WEAK | guidance_indi_get_liftd (float airspeed, float theta) |
| Get the derivative of lift w.r.t. | |
A guidance mode based on Incremental Nonlinear Dynamic Inversion Come to IROS2016 to learn more!
Definition in file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_AIRSPEED_FILT_CUTOFF 0.5 |
Definition at line 187 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_COORDINATED_TURN_AIRSPEED_MARGIN 0.0 |
Definition at line 203 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_COORDINATED_TURN_MAX_AIRSPEED 30.0 |
Definition at line 199 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_COORDINATED_TURN_MIN_AIRSPEED 10.0 |
Definition at line 195 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_FILTER_CUTOFF 3.0 |
Definition at line 182 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_FWD_CLIMB_SPEED 4.0 |
Climb speed when navigation is making turns instead of direct lines.
Definition at line 88 of file guidance_indi_hybrid.c.
Referenced by rotwing_state_periodic().
| #define GUIDANCE_INDI_FWD_DESCEND_SPEED -4.0 |
Descend speed when navigation is making turns instead of direct lines.
Definition at line 95 of file guidance_indi_hybrid.c.
Referenced by rotwing_state_periodic().
| #define GUIDANCE_INDI_LIFTD_ASQ 0.20 |
Definition at line 60 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_LIFTD_P50 (GUIDANCE_INDI_LIFTD_P80/2) |
Definition at line 73 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_LIFTD_P80 (GUIDANCE_INDI_LIFTD_ASQ*12*12) |
Definition at line 72 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_MAX_LAT_ACCEL 9.81 |
Definition at line 191 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp().
| #define GUIDANCE_INDI_MAX_PUSHER_INCREMENT MAX_PPRZ |
Definition at line 64 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| #define GUIDANCE_INDI_MIN_AIRSPEED -10.f |
Definition at line 81 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_POS_GAIN 0.5 |
Definition at line 55 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_POS_GAINZ 0.5 |
Definition at line 56 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_QUAD_CLIMB_SPEED 2.0 |
Climb speed when navigation is doing direct lines.
Definition at line 102 of file guidance_indi_hybrid.c.
Referenced by rotwing_state_periodic().
| #define GUIDANCE_INDI_QUAD_DESCEND_SPEED -2.0 |
Descend speed when navigation is doing direct lines.
Definition at line 109 of file guidance_indi_hybrid.c.
Referenced by rotwing_state_periodic().
| #define GUIDANCE_INDI_SPEED_GAIN 1.8 |
Definition at line 50 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_SPEED_GAINZ 1.8 |
Definition at line 51 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_VEL_SP_ID ABI_BROADCAST |
Definition at line 288 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_init().
Definition at line 149 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_hybrid_set_wls_settings().
| #define GUIDANCE_INDI_WLS_WU {[0 ... GUIDANCE_INDI_HYBRID_U - 1] = 1.0} |
Definition at line 154 of file guidance_indi_hybrid.c.
| #define GUIDANCE_INDI_ZERO_AIRSPEED FALSE |
Definition at line 160 of file guidance_indi_hybrid.c.
| #define TURN_AIRSPEED_TH 13.0 |
Definition at line 165 of file guidance_indi_hybrid.c.
Referenced by bound_vz_sp(), and compute_accel_from_speed_sp().
|
static |
Definition at line 712 of file guidance_indi_hybrid.c.
References gih_params, stateGetAirspeed_f(), and TURN_AIRSPEED_TH.
Referenced by guidance_indi_controller().
|
static |
Definition at line 586 of file guidance_indi_hybrid.c.
References compute_accel_from_speed_sp(), desired_airspeed, eulers_zxy, FLOAT_ANGLE_NORMALIZE, FLOAT_VECT2_NORM, float_vect3_bound_in_2d(), force_forward, gi_unbounded_airspeed_sp, gih_params, guidance_indi_airspeed_filt, guidance_indi_airspeed_filtering, GUIDANCE_INDI_MAX_LAT_ACCEL, rotwing_state_hover_motors_running(), rotwing_state_pusher_motor_running(), speed_sp, stateGetAirspeed_f(), stateGetNedToBodyEulersZxy_f(), stateGetSpeedNed_f(), TURN_AIRSPEED_TH, VECT2_DIFF, FloatVect2::x, FloatVect3::x, NedCoor_f::x, FloatVect2::y, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
Referenced by compute_accel_from_speed_sp(), guidance_indi_controller(), and guidance_indi_run_mode().
| struct FloatVect3 WEAK guidance_indi_controller | ( | bool in_flight | UNUSED, |
| struct HorizontalGuidance * | gh, | ||
| struct VerticalGuidance * | gv, | ||
| enum GuidanceIndiHybrid_HMode | h_mode, | ||
| enum GuidanceIndiHybrid_VMode | v_mode ) |
Definition at line 723 of file guidance_indi_hybrid.c.
References ACCEL_FLOAT_OF_BFP, bound_vz_sp(), compute_accel_from_speed_sp(), gi_speed_sp, gih_params, guidance_indi_controller(), GUIDANCE_INDI_HYBRID_H_POS, GUIDANCE_INDI_HYBRID_H_SPEED, GUIDANCE_INDI_HYBRID_V_ACCEL, GUIDANCE_INDI_HYBRID_V_POS, GUIDANCE_INDI_HYBRID_V_SPEED, POS_FLOAT_OF_BFP, SPEED_FLOAT_OF_BFP, stateGetPositionNed_f(), stateGetSpeedNed_f(), UNUSED, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, NedCoor_f::z, VerticalGuidance::z_ref, VerticalGuidance::zd_ref, and VerticalGuidance::zdd_ref.
Referenced by guidance_indi_run_mode().
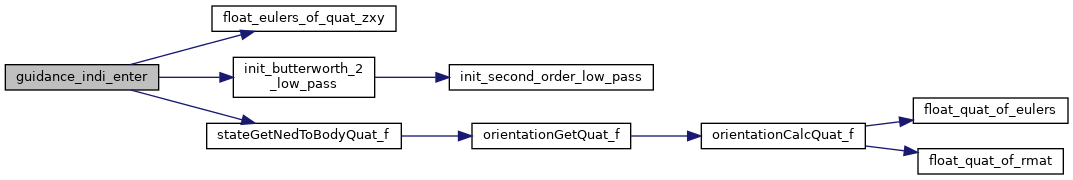
| void guidance_indi_enter | ( | void | ) |
Call upon entering indi guidance.
Definition at line 373 of file guidance_indi_hybrid.c.
References eulers_zxy, guidance_indi_hybrid_heading_sp, guidance_indi_init_filters(), nav, and stateGetNedToBodyEulersZxy_f().
| float WEAK guidance_indi_get_liftd | ( | float | airspeed, |
| float | theta ) |
Get the derivative of lift w.r.t.
pitch.
| airspeed | The airspeed says most about the flight condition |
Definition at line 871 of file guidance_indi_hybrid.c.
References gih_params.
Referenced by guidance_indi_calcg_wing(), and guidance_indi_calcg_wing().
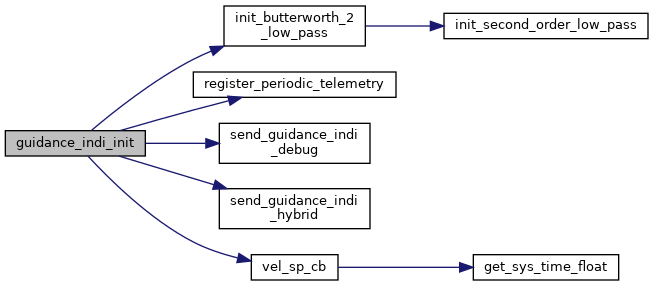
| void guidance_indi_init | ( | void | ) |
Init function.
Definition at line 341 of file guidance_indi_hybrid.c.
References DefaultPeriodic, Ga, guidance_indi_init_filters(), GUIDANCE_INDI_VEL_SP_ID, register_periodic_telemetry(), send_eff_mat_guid_indi_hybrid(), send_guidance_indi_hybrid(), thrust_dyn, vel_sp_cb(), and vel_sp_ev.
|
static |
Initialized low pass filters.
Definition at line 808 of file guidance_indi_hybrid.c.
References accely_filt, filt_accel_ned, filter_cutoff, float_quat_of_eulers_zxy(), guidance_indi_airspeed_filt, guidance_indi_airspeed_filt_cutoff, init_butterworth_2_low_pass(), init_butterworth_2_low_pass_vect3(), init_quat_butterworth_low_pass(), quat_filt, stabilization, thrust_act, thrust_filt, and thrust_in.
Referenced by guidance_indi_enter(), and guidance_indi_init().
|
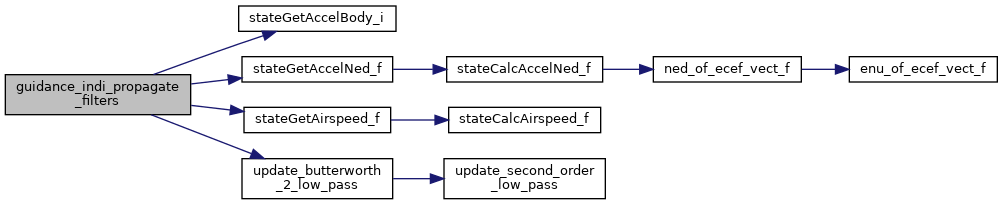
static |
Low pass the accelerometer measurements to remove noise from vibrations.
The orientation needs to be filtered to synchronize with the acceleration. Called as a periodic function with PERIODIC_FREQ
Definition at line 835 of file guidance_indi_hybrid.c.
References ACCEL_FLOAT_OF_BFP, accely_filt, filt_accel_ned, guidance_indi_airspeed_filt, quat_filt, stateGetAccelBody_i(), stateGetAccelNed_f(), stateGetAirspeed_f(), stateGetNedToBodyQuat_f(), update_butterworth_2_low_pass(), update_butterworth_2_low_pass_vect3(), update_quat_butterworth_low_pass(), and FloatVect3::y.
Referenced by guidance_indi_run().
| struct StabilizationSetpoint guidance_indi_run | ( | struct FloatVect3 * | accel_sp, |
| float | heading_sp ) |
| accel_sp | accel setpoint in NED frame [m/s^2] |
| heading_sp | the desired heading [rad] |
main indi guidance function
Definition at line 409 of file guidance_indi_hybrid.c.
References accely_filt, du_gih, euler_cmd, eulers_zxy, filt_accel_ned, FLOAT_ANGLE_NORMALIZE, float_eulers_of_quat_zxy(), float_mat3_mult(), float_mat_inv_3d(), float_quat_normalize(), float_quat_of_eulers_zxy(), g1g2, Ga, Ga_inv, get_butterworth_2_low_pass_vect3(), gih_coordinated_turn_max_airspeed, gih_coordinated_turn_min_airspeed, guidance_euler_cmd, guidance_indi_calcg_wing(), guidance_indi_hybrid_heading_sp, guidance_indi_hybrid_set_wls_settings(), guidance_indi_max_bank, GUIDANCE_INDI_MAX_PITCH, GUIDANCE_INDI_MAX_PUSHER_INCREMENT, guidance_indi_min_pitch, guidance_indi_propagate_filters(), guidance_indi_run(), guidance_indi_specific_force_gain, heading, max_phi, MAX_PPRZ, FloatRates::p, FloatEulers::phi, FloatRates::q, quat_filt, FloatRates::r, sp_accel, stab_sp_from_quat_ff_rates_f(), stabilization, stabilization_attitude_get_heading_f(), stateGetAirspeed_f(), stateGetNedToBodyEulers_f(), stateGetNedToBodyEulersZxy_f(), take_heading_control, th_sp_from_incr_vect_f(), th_sp_from_thrust_i(), FloatEulers::theta, THRUST_AXIS_Z, thrust_filt, thrust_in, thrust_sp, thrust_vect, WLS_t::u, WLS_t::v, v_gih, VECT3_DIFF, wls_alloc(), FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by guidance_indi_run_mode().
| struct StabilizationSetpoint guidance_indi_run_mode | ( | bool in_flight | UNUSED, |
| struct HorizontalGuidance * | gh, | ||
| struct VerticalGuidance * | gv, | ||
| enum GuidanceIndiHybrid_HMode | h_mode, | ||
| enum GuidanceIndiHybrid_VMode | v_mode ) |
Definition at line 785 of file guidance_indi_hybrid.c.
References compute_accel_from_speed_sp(), get_sys_time_float(), gi_speed_sp, guidance_indi_controller(), guidance_indi_run(), guidance_indi_run_mode(), indi_vel_sp, time_of_vel_sp, and UNUSED.
| void guidance_set_max_bank_angle | ( | float | max_bank | ) |
Definition at line 388 of file guidance_indi_hybrid.c.
References guidance_indi_max_bank, and max_bank.
Referenced by rotwing_state_periodic().
| void guidance_set_max_climb_speed | ( | float | max_climb_speed_quad, |
| float | max_climb_speed_fwd ) |
Definition at line 392 of file guidance_indi_hybrid.c.
References gih_params.
Referenced by rotwing_state_periodic().
| void guidance_set_max_descend_speed | ( | float | max_descend_speed_quad, |
| float | max_descend_speed_fwd ) |
Definition at line 397 of file guidance_indi_hybrid.c.
References gih_params.
Referenced by rotwing_state_periodic().
| void guidance_set_min_max_airspeed | ( | float | min_airspeed, |
| float | max_airspeed ) |
Definition at line 383 of file guidance_indi_hybrid.c.
References gih_params, and max_airspeed.
Referenced by rotwing_state_periodic().
|
static |
Definition at line 300 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_init().
|
static |
Definition at line 307 of file guidance_indi_hybrid.c.
References dev, euler_cmd, filt_accel_ned, get_butterworth_2_low_pass_vect3(), gi_speed_sp, sp_accel, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by guidance_indi_init().
|
static |
ABI callback that obtains the velocity setpoint from a module.
Definition at line 903 of file guidance_indi_hybrid.c.
References get_sys_time_float(), indi_vel_sp, time_of_vel_sp, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by guidance_indi_init().
| Butterworth2LowPass accely_filt |
Definition at line 226 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_init_filters(), guidance_indi_propagate_filters(), guidance_indi_run(), init_filter(), oneloop_andi_propagate_filters(), oneloop_andi_sideslip(), oneloop_nB_propagate_filters(), and oneloop_nB_sideslip().
| bool coordinated_turn_use_accel = false |
Definition at line 220 of file guidance_indi_hybrid.c.
| struct FloatVect2 desired_airspeed |
Definition at line 247 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp().
| float du_gih[GUIDANCE_INDI_HYBRID_U] |
Definition at line 253 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| struct FloatVect3 euler_cmd |
Definition at line 251 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run(), and send_guidance_indi_hybrid().
| struct FloatEulers eulers_zxy |
state eulers in zxy order
Definition at line 223 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp(), eff_scheduling_falcon_periodic(), eff_scheduling_periodic_b(), guidance_indi_enter(), guidance_indi_hybrid_set_wls_settings(), guidance_indi_run(), oneloop_andi_enter(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_andi_sideslip(), oneloop_nB_enter(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_sideslip(), reshape_wind(), schdule_control_effectiveness(), send_fp(), and send_oneloop_debug().
| struct Butterworth2LowPassVect3 filt_accel_ned |
Definition at line 225 of file guidance_indi_hybrid.c.
| float filter_cutoff = GUIDANCE_INDI_FILTER_CUTOFF |
Definition at line 277 of file guidance_indi_hybrid.c.
| bool force_forward = false |
forward flight for hybrid nav
Definition at line 171 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp(), nav_hybrid_circle(), nav_hybrid_goto(), nav_hybrid_route(), and reshape_wind().
| float Ga[GUIDANCE_INDI_HYBRID_V][GUIDANCE_INDI_HYBRID_U] |
Definition at line 250 of file guidance_indi_hybrid.c.
| struct FloatVect3 gi_speed_sp = {0.0, 0.0, 0.0} |
Definition at line 285 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_controller(), guidance_indi_run_mode(), and send_guidance_indi_hybrid().
| float gi_unbounded_airspeed_sp = 0.f |
Definition at line 248 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp(), reshape_wind(), rotwing_state_periodic(), and send_rotating_wing_state().
| float gih_coordinated_turn_max_airspeed = GUIDANCE_INDI_COORDINATED_TURN_MAX_AIRSPEED + GUIDANCE_INDI_COORDINATED_TURN_AIRSPEED_MARGIN |
Definition at line 217 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| float gih_coordinated_turn_min_airspeed = GUIDANCE_INDI_COORDINATED_TURN_MIN_AIRSPEED |
Definition at line 216 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| struct guidance_indi_hybrid_params gih_params |
Definition at line 112 of file guidance_indi_hybrid.c.
Referenced by bound_vz_sp(), compute_accel_from_speed_sp(), guidance_indi_controller(), guidance_indi_get_liftd(), guidance_set_max_climb_speed(), guidance_set_max_descend_speed(), and guidance_set_min_max_airspeed().
| struct FloatEulers guidance_euler_cmd |
Definition at line 281 of file guidance_indi_hybrid.c.
| Butterworth2LowPass guidance_indi_airspeed_filt |
Definition at line 227 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp(), guidance_indi_init_filters(), and guidance_indi_propagate_filters().
| float guidance_indi_airspeed_filt_cutoff = GUIDANCE_INDI_AIRSPEED_FILT_CUTOFF |
Definition at line 278 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_init_filters().
| bool guidance_indi_airspeed_filtering = false |
Definition at line 173 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp().
| float guidance_indi_hybrid_heading_sp = 0.f |
Definition at line 280 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_enter(), and guidance_indi_run().
| float guidance_indi_max_bank = GUIDANCE_H_MAX_BANK |
Definition at line 209 of file guidance_indi_hybrid.c.
| float guidance_indi_min_pitch = GUIDANCE_INDI_MIN_PITCH |
Definition at line 210 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| float guidance_indi_pitch_pref_deg = 0 |
Definition at line 133 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_hybrid_set_wls_settings().
| struct FloatVect3 indi_vel_sp = {0.0, 0.0, 0.0} |
Definition at line 292 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run_mode(), and vel_sp_cb().
| float inv_eff[4] |
Definition at line 206 of file guidance_indi_hybrid.c.
| QuatButterworthLowPass quat_filt |
Definition at line 228 of file guidance_indi_hybrid.c.
| struct FloatVect3 sp_accel = {0.0,0.0,0.0} |
Definition at line 176 of file guidance_indi_hybrid.c.
| bool take_heading_control = false |
Definition at line 169 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run().
| float thrust_in |
Definition at line 283 of file guidance_indi_hybrid.c.
| struct ThrustSetpoint thrust_sp |
Definition at line 282 of file guidance_indi_hybrid.c.
| float time_of_vel_sp = 0.0 |
Definition at line 293 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_run_mode(), and vel_sp_cb().
| float v_gih[3] |
Definition at line 274 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_calcg_wing(), and guidance_indi_run().
| abi_event vel_sp_ev |
Definition at line 290 of file guidance_indi_hybrid.c.
Referenced by guidance_indi_init().
 1.15.0