|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Go to the source code of this file.
Macros | |
| #define | GUIDANCE_INDI_MIN_PITCH -20 |
| #define | GUIDANCE_INDI_MAX_PITCH 20 |
Functions | |
| void | guidance_indi_quadplane_init (void) |
| Call upon entering indi guidance. | |
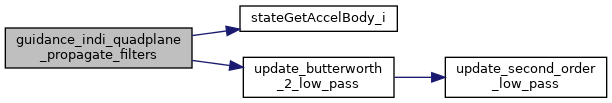
| void | guidance_indi_quadplane_propagate_filters (void) |
| Low pass the accelerometer measurements to remove noise from vibrations. | |
| #define GUIDANCE_INDI_MAX_PITCH 20 |
Definition at line 32 of file guidance_indi_hybrid_quadplane.h.
Referenced by guidance_indi_hybrid_set_wls_settings(), and guidance_indi_run().
| #define GUIDANCE_INDI_MIN_PITCH -20 |
Definition at line 31 of file guidance_indi_hybrid_quadplane.h.
Referenced by guidance_indi_hybrid_set_wls_settings().
|
extern |
Call upon entering indi guidance.
Definition at line 61 of file guidance_indi_hybrid_quadplane.c.
References accel_bodyz_filt, GUIDANCE_INDI_BODYZ_FILTER_CUTOFF, and init_butterworth_2_low_pass().
|
extern |
Low pass the accelerometer measurements to remove noise from vibrations.
The roll and pitch also need to be filtered to synchronize them with the acceleration Called as a periodic function with PERIODIC_FREQ
Definition at line 73 of file guidance_indi_hybrid_quadplane.c.
References accel_bodyz_filt, ACCEL_FLOAT_OF_BFP, stateGetAccelBody_i(), and update_butterworth_2_low_pass().
 1.15.0