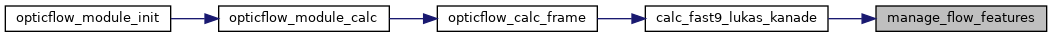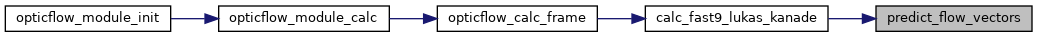|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
Estimate velocity from optic flow. More...
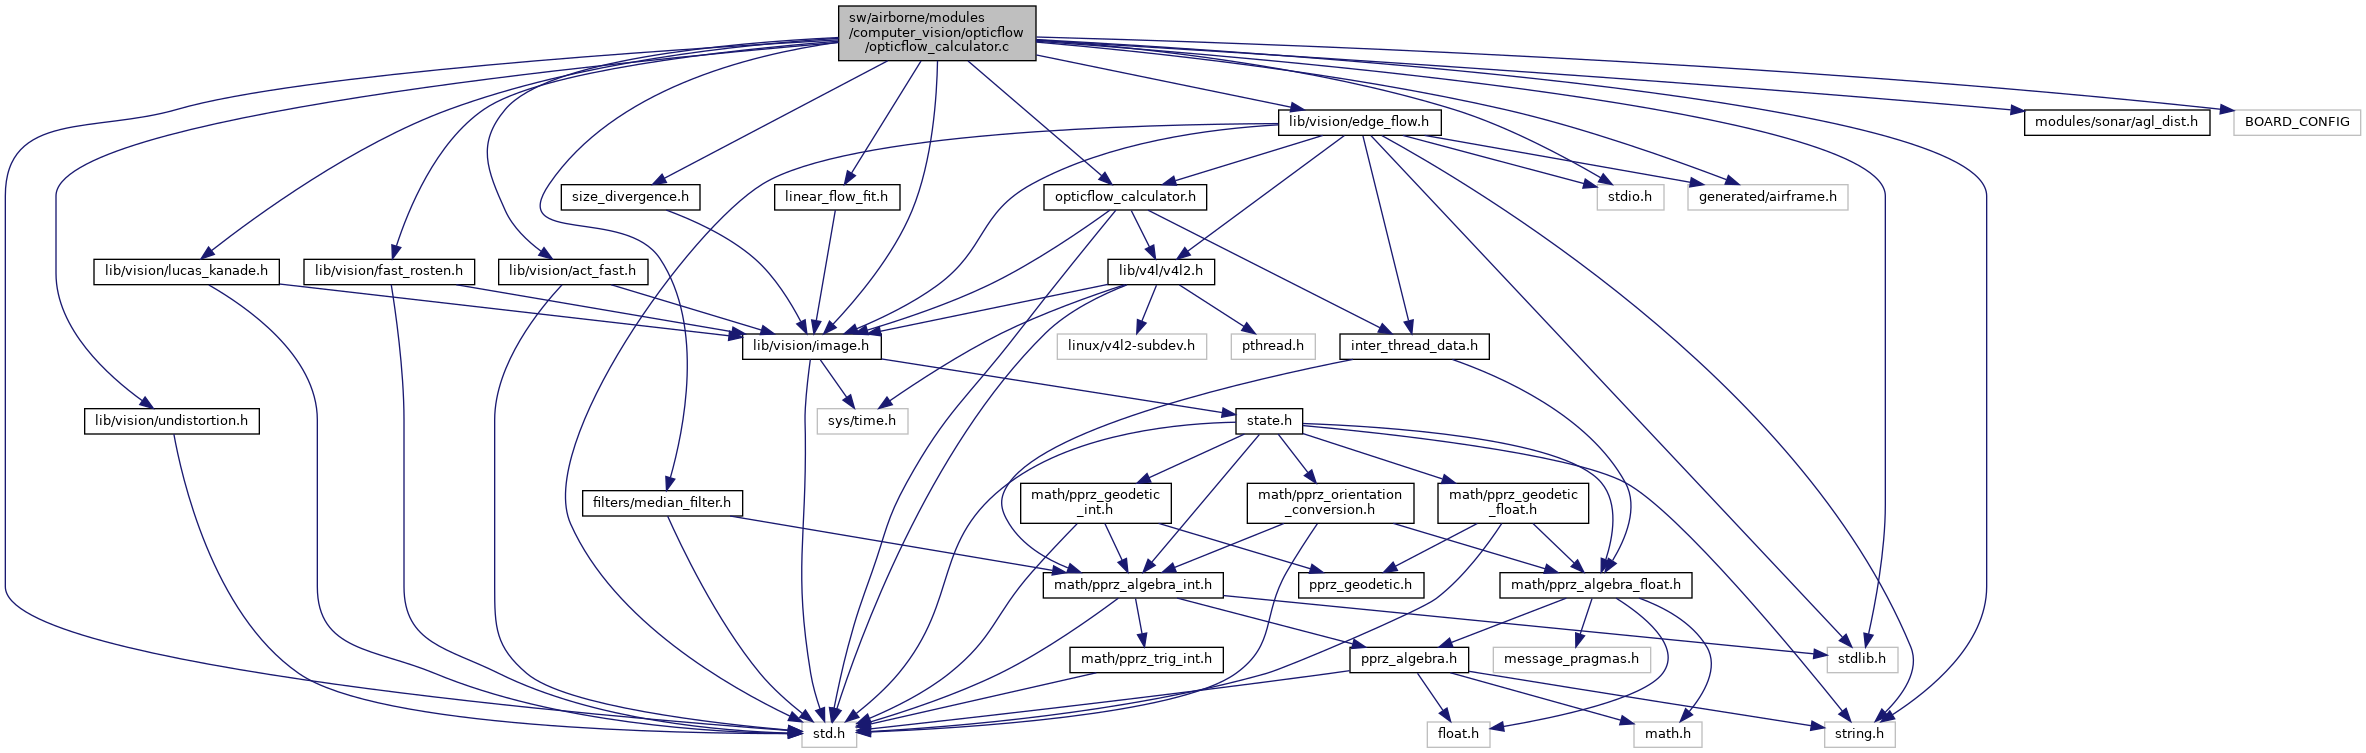
#include "std.h"#include <stdio.h>#include <string.h>#include <stdlib.h>#include "opticflow_calculator.h"#include "lib/vision/image.h"#include "lib/vision/lucas_kanade.h"#include "lib/vision/fast_rosten.h"#include "lib/vision/act_fast.h"#include "lib/vision/edge_flow.h"#include "lib/vision/undistortion.h"#include "size_divergence.h"#include "linear_flow_fit.h"#include "modules/sonar/agl_dist.h"#include "generated/airframe.h"#include <BOARD_CONFIG>#include "filters/median_filter.h"Go to the source code of this file.
Functions | |
| static uint32_t | timeval_diff (struct timeval *starttime, struct timeval *finishtime) |
| Calculate the difference from start till finish. | |
| static int | cmp_flow (const void *a, const void *b) |
| Compare two flow vectors based on flow distance Used for sorting. | |
| static int | cmp_array (const void *a, const void *b) |
| Compare the rows of an integer (uint16_t) 2D array based on the first column. | |
| static void | manage_flow_features (struct image_t *img, struct opticflow_t *opticflow, struct opticflow_result_t *result) |
| static struct flow_t * | predict_flow_vectors (struct flow_t *flow_vectors, uint16_t n_points, float phi_diff, float theta_diff, float psi_diff, struct opticflow_t *opticflow) |
| void | opticflow_calc_init (struct opticflow_t opticflow[]) |
| Initialize the opticflow calculator. | |
| bool | calc_fast9_lukas_kanade (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow with fast9 and lukaskanade on a new image frame. | |
| bool | calc_edgeflow_tot (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow with EDGEFLOW on a new image frame. | |
| bool | opticflow_calc_frame (struct opticflow_t *opticflow, struct image_t *img, struct opticflow_result_t *result) |
| Run the optical flow on a new image frame. | |
Variables | |
| uint16_t | n_time_steps [2] = {10, 10} |
| uint16_t | n_agents [2] = {25, 25} |
| struct MedianFilter3Float | vel_filt |
| struct FloatRMat | body_to_cam [2] |
Estimate velocity from optic flow.
Definition in file opticflow_calculator.c.
| #define ACT_FAST 1 |
Definition at line 57 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| #define EXHAUSTIVE_FAST 0 |
Definition at line 56 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| #define FAST9_HIGH_THRESHOLD 60 |
Definition at line 202 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| #define FAST9_LOW_THRESHOLD 5 |
Definition at line 201 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| #define LINEAR_FIT 0 |
Definition at line 67 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| #define OPTICFLOW_ACTFAST_GRADIENT_METHOD 1 |
Definition at line 314 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_GRADIENT_METHOD_CAMERA2 1 |
Definition at line 318 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_LONG_STEP 10 |
Definition at line 294 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_LONG_STEP_CAMERA2 10 |
Definition at line 298 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_MIN_GRADIENT 10 |
Definition at line 324 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_MIN_GRADIENT_CAMERA2 10 |
Definition at line 328 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_SHORT_STEP 2 |
Definition at line 304 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_ACTFAST_SHORT_STEP_CAMERA2 2 |
Definition at line 308 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_PHI 0 |
Definition at line 335 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_PHI_CAMERA2 0 |
Definition at line 345 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_PSI -M_PI_2 |
Definition at line 341 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_PSI_CAMERA2 -M_PI_2 |
Definition at line 351 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_THETA 0 |
Definition at line 338 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_BODY_TO_CAM_THETA_CAMERA2 0 |
Definition at line 348 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_CORNER_METHOD ACT_FAST |
Definition at line 70 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_CORNER_METHOD_CAMERA2 ACT_FAST |
Definition at line 74 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION TRUE |
Definition at line 224 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION_CAMERA2 TRUE |
Definition at line 228 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X 1.0 |
Definition at line 234 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X_CAMERA2 1.0 |
Definition at line 238 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y 1.0 |
Definition at line 244 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y_CAMERA2 1.0 |
Definition at line 248 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_ADAPTIVE TRUE |
Definition at line 161 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_ADAPTIVE_CAMERA2 TRUE |
Definition at line 165 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_MIN_DISTANCE 10 |
Definition at line 181 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_MIN_DISTANCE_CAMERA2 10 |
Definition at line 185 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_NUM_REGIONS 9 |
Definition at line 284 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_NUM_REGIONS_CAMERA2 9 |
Definition at line 288 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_PADDING 20 |
Definition at line 191 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_PADDING_CAMERA2 20 |
Definition at line 195 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_REGION_DETECT 1 |
Definition at line 274 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_REGION_DETECT_CAMERA2 1 |
Definition at line 278 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_THRESHOLD 20 |
Definition at line 171 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FAST9_THRESHOLD_CAMERA2 20 |
Definition at line 175 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FEATURE_MANAGEMENT 0 |
Definition at line 264 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_FEATURE_MANAGEMENT_CAMERA2 0 |
Definition at line 268 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MAX_ITERATIONS 10 |
Definition at line 131 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MAX_ITERATIONS_CAMERA2 10 |
Definition at line 135 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MAX_TRACK_CORNERS 25 |
Definition at line 81 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MAX_TRACK_CORNERS_CAMERA2 25 |
Definition at line 85 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MEDIAN_FILTER FALSE |
Definition at line 254 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_MEDIAN_FILTER_CAMERA2 FALSE |
Definition at line 258 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_METHOD 0 |
Definition at line 206 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_METHOD_CAMERA2 0 |
Definition at line 210 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_PYRAMID_LEVEL 2 |
Definition at line 151 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_PYRAMID_LEVEL_CAMERA2 2 |
Definition at line 155 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_RESOLUTION_FACTOR 100 |
Definition at line 121 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_RESOLUTION_FACTOR_CAMERA2 100 |
Definition at line 125 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SEARCH_DISTANCE 20 |
Definition at line 101 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SEARCH_DISTANCE_CAMERA2 20 |
Definition at line 105 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SHOW_CORNERS 0 |
Definition at line 54 of file opticflow_calculator.c.
| #define OPTICFLOW_SHOW_FLOW FALSE |
Definition at line 369 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SHOW_FLOW_CAMERA2 FALSE |
Definition at line 373 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SUBPIXEL_FACTOR 10 |
Definition at line 111 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_SUBPIXEL_FACTOR_CAMERA2 10 |
Definition at line 115 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_THRESHOLD_VEC 2 |
Definition at line 141 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_THRESHOLD_VEC_CAMERA2 2 |
Definition at line 145 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_TRACK_BACK FALSE |
Definition at line 357 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_TRACK_BACK_CAMERA2 FALSE |
Definition at line 361 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_WINDOW_SIZE 10 |
Definition at line 91 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define OPTICFLOW_WINDOW_SIZE_CAMERA2 10 |
Definition at line 95 of file opticflow_calculator.c.
Referenced by opticflow_calc_init().
| #define SIZE_DIV 1 |
Definition at line 64 of file opticflow_calculator.c.
Referenced by calc_fast9_lukas_kanade().
| bool calc_edgeflow_tot | ( | struct opticflow_t * | opticflow, |
| struct image_t * | img, | ||
| struct opticflow_result_t * | result ) |
Run the optical flow with EDGEFLOW on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
| computation | successful |
Definition at line 1017 of file opticflow_calculator.c.
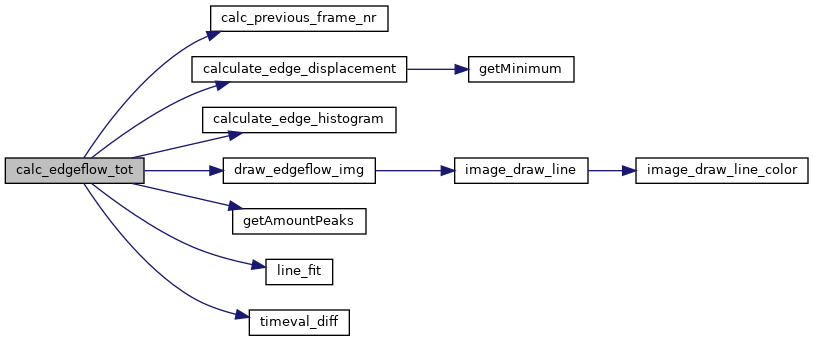
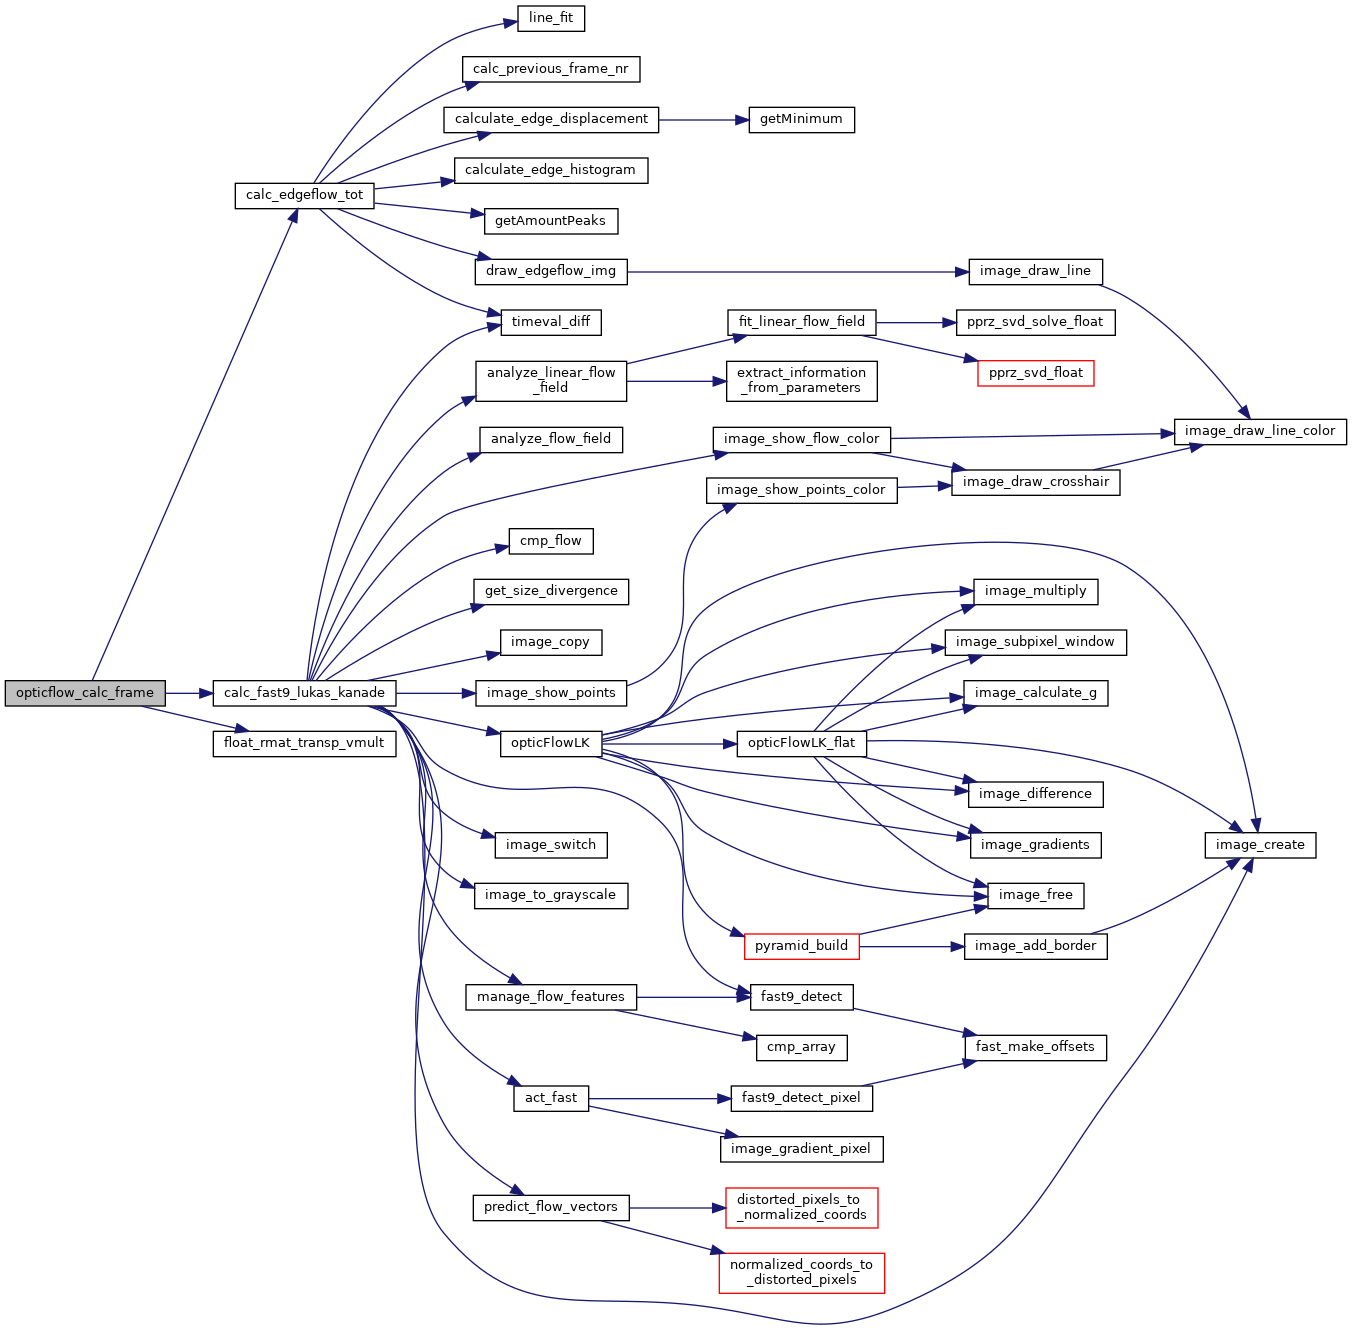
References agl_dist_value_filtered, calc_previous_frame_nr(), calculate_edge_displacement(), calculate_edge_histogram(), opticflow_result_t::camera_id, opticflow_result_t::corner_cnt, DISP_RANGE_MAX, opticflow_result_t::div_size, edge_flow_t::div_x, edge_flow_t::div_y, opticflow_result_t::divergence, draw_edgeflow_img(), edge_hist_t::eulers, image_t::eulers, FLOAT_EULERS_ZERO, opticflow_result_t::flow_der_x, opticflow_result_t::flow_der_y, edge_flow_t::flow_x, opticflow_result_t::flow_x, edge_flow_t::flow_y, opticflow_result_t::flow_y, opticflow_result_t::fps, edge_hist_t::frame_time, getAmountPeaks(), image_t::h, line_fit(), MAX_HORIZON, MAX_WINDOW_SIZE, opticflow_result_t::noise_measurement, opticflow, FloatEulers::phi, RES, opticflow_result_t::surface_roughness, FloatEulers::theta, timeval_diff(), opticflow_result_t::tracked_cnt, image_t::ts, UpdateMedianFilterVect3Float, opticflow_result_t::vel_cam, vel_filt, image_t::w, edge_hist_t::x, edgeflow_displacement_t::x, FloatVect3::x, edge_hist_t::y, edgeflow_displacement_t::y, FloatVect3::y, and FloatVect3::z.
Referenced by opticflow_calc_frame().
| bool calc_fast9_lukas_kanade | ( | struct opticflow_t * | opticflow, |
| struct image_t * | img, | ||
| struct opticflow_result_t * | result ) |
Run the optical flow with fast9 and lukaskanade on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
Definition at line 494 of file opticflow_calculator.c.
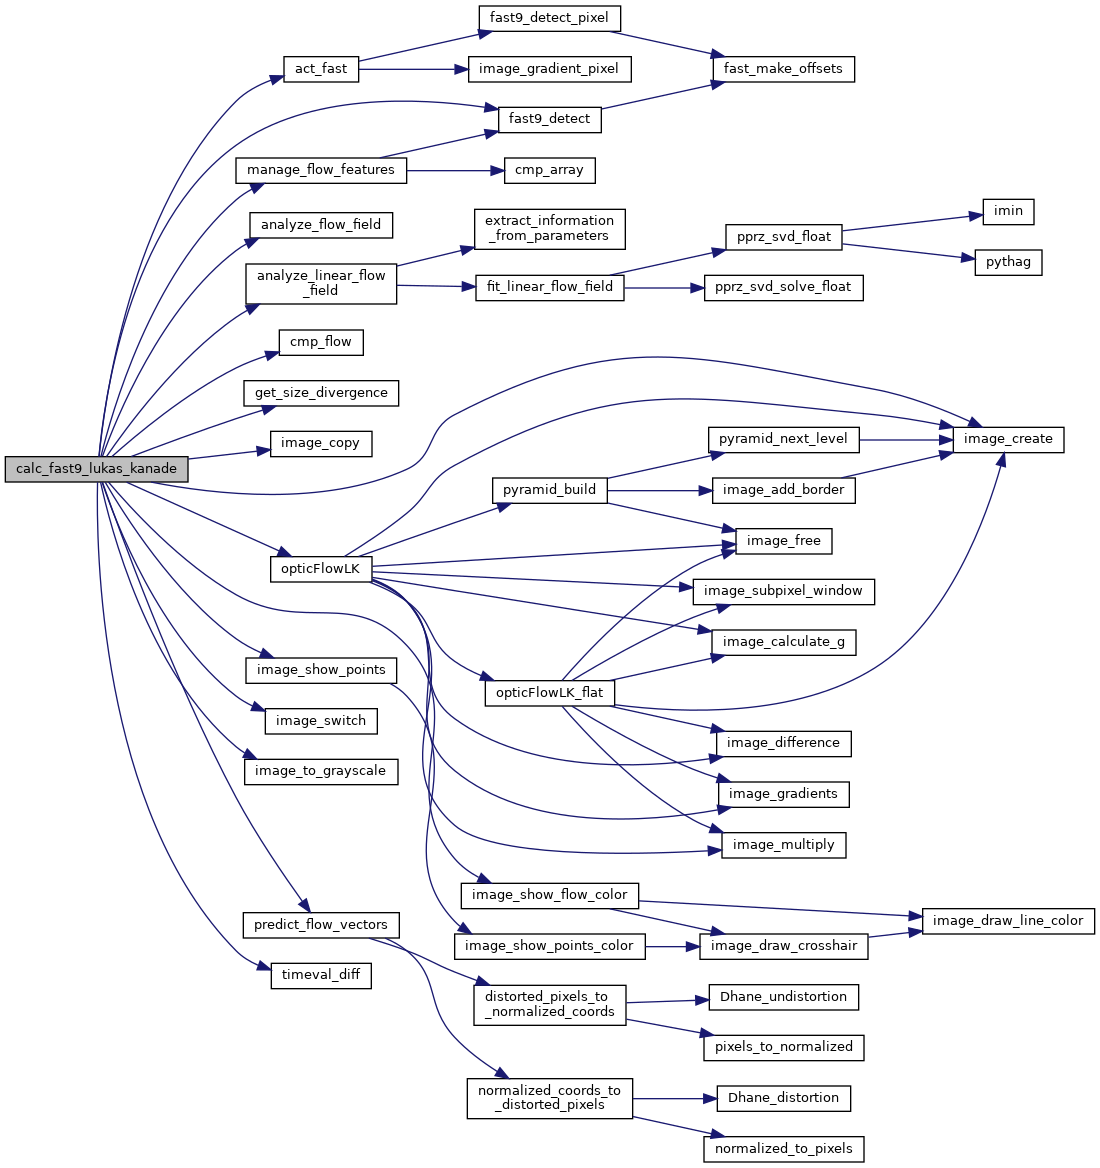
References ACT_FAST, act_fast(), agl_dist_value_filtered, analyze_flow_field(), analyze_linear_flow_field(), bottom_camera, opticflow_result_t::camera_id, cmp_flow(), opticflow_result_t::corner_cnt, point_t::count, opticflow_result_t::div_size, linear_flow_fit_info::divergence, opticflow_result_t::divergence, flow_t::error, EXHAUSTIVE_FAST, fast9_detect(), FAST9_HIGH_THRESHOLD, FAST9_LOW_THRESHOLD, opticflow_result_t::flow_der_x, opticflow_result_t::flow_der_y, flow_t::flow_x, opticflow_result_t::flow_x, flow_t::flow_y, opticflow_result_t::flow_y, opticflow_result_t::fps, get_size_divergence(), image_t::h, image_copy(), image_create(), IMAGE_GRAYSCALE, image_show_flow_color(), image_show_points(), image_switch(), image_to_grayscale(), InitMedianFilterVect3Float, LARGE_FLOW_ERROR, LINEAR_FIT, manage_flow_features(), MEDIAN_DEFAULT_SIZE, n_agents, n_samples, n_time_steps, opticflow_result_t::noise_measurement, opticflow, opticFlowLK(), flow_t::pos, predict_flow_vectors(), SIZE_DIV, linear_flow_fit_info::surface_roughness, opticflow_result_t::surface_roughness, timeval_diff(), opticflow_result_t::tracked_cnt, image_t::ts, UpdateMedianFilterVect3Float, VECT3_ASSIGN, opticflow_result_t::vel_body, opticflow_result_t::vel_cam, vel_filt, image_t::w, FloatVect3::x, point_t::x, FloatVect3::y, point_t::y, and FloatVect3::z.
Referenced by opticflow_calc_frame().
|
static |
Compare the rows of an integer (uint16_t) 2D array based on the first column.
Used for sorting.
| [in] | *a | The first row (should be *uint16_t) |
| [in] | *b | The second flow vector (should be *uint16_t) |
Definition at line 1249 of file opticflow_calculator.c.
References b.
Referenced by manage_flow_features().
|
static |
Compare two flow vectors based on flow distance Used for sorting.
| [in] | *a | The first flow vector (should be vect flow_t) |
| [in] | *b | The second flow vector (should be vect flow_t) |
Definition at line 1234 of file opticflow_calculator.c.
References b, flow_t::flow_x, and flow_t::flow_y.
Referenced by calc_fast9_lukas_kanade().
|
static |
Definition at line 903 of file opticflow_calculator.c.
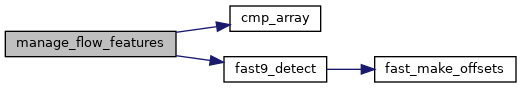
References c1, cmp_array(), opticflow_result_t::corner_cnt, fast9_detect(), image_t::h, opticflow, image_t::w, point_t::x, and point_t::y.
Referenced by calc_fast9_lukas_kanade().
| bool opticflow_calc_frame | ( | struct opticflow_t * | opticflow, |
| struct image_t * | img, | ||
| struct opticflow_result_t * | result ) |
Run the optical flow on a new image frame.
| [in] | *opticflow | The opticalflow structure that keeps track of previous images |
| [in] | *state | The state of the drone |
| [in] | *img | The image frame to calculate the optical flow from |
| [out] | *result | The optical flow result |
Definition at line 1181 of file opticflow_calculator.c.
References body_to_cam, calc_edgeflow_tot(), calc_fast9_lukas_kanade(), float_rmat_transp_vmult(), opticflow, opticflow_result_t::vel_body, and opticflow_result_t::vel_cam.
Referenced by opticflow_module_calc().
| void opticflow_calc_init | ( | struct opticflow_t | opticflow[] | ) |
Initialize the opticflow calculator.
| [out] | *opticflow | The new optical flow calculator |
Definition at line 397 of file opticflow_calculator.c.
References body_to_cam, FAST9_MAX_CORNERS, float_rmat_of_eulers, opticflow, OPTICFLOW_ACTFAST_GRADIENT_METHOD, OPTICFLOW_ACTFAST_GRADIENT_METHOD_CAMERA2, OPTICFLOW_ACTFAST_LONG_STEP, OPTICFLOW_ACTFAST_LONG_STEP_CAMERA2, OPTICFLOW_ACTFAST_MIN_GRADIENT, OPTICFLOW_ACTFAST_MIN_GRADIENT_CAMERA2, OPTICFLOW_ACTFAST_SHORT_STEP, OPTICFLOW_ACTFAST_SHORT_STEP_CAMERA2, OPTICFLOW_BODY_TO_CAM_PHI, OPTICFLOW_BODY_TO_CAM_PHI_CAMERA2, OPTICFLOW_BODY_TO_CAM_PSI, OPTICFLOW_BODY_TO_CAM_PSI_CAMERA2, OPTICFLOW_BODY_TO_CAM_THETA, OPTICFLOW_BODY_TO_CAM_THETA_CAMERA2, OPTICFLOW_CORNER_METHOD, OPTICFLOW_CORNER_METHOD_CAMERA2, OPTICFLOW_DEROTATION, OPTICFLOW_DEROTATION_CAMERA2, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_X_CAMERA2, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y, OPTICFLOW_DEROTATION_CORRECTION_FACTOR_Y_CAMERA2, OPTICFLOW_FAST9_ADAPTIVE, OPTICFLOW_FAST9_ADAPTIVE_CAMERA2, OPTICFLOW_FAST9_MIN_DISTANCE, OPTICFLOW_FAST9_MIN_DISTANCE_CAMERA2, OPTICFLOW_FAST9_NUM_REGIONS, OPTICFLOW_FAST9_NUM_REGIONS_CAMERA2, OPTICFLOW_FAST9_PADDING, OPTICFLOW_FAST9_PADDING_CAMERA2, OPTICFLOW_FAST9_REGION_DETECT, OPTICFLOW_FAST9_REGION_DETECT_CAMERA2, OPTICFLOW_FAST9_THRESHOLD, OPTICFLOW_FAST9_THRESHOLD_CAMERA2, OPTICFLOW_FEATURE_MANAGEMENT, OPTICFLOW_FEATURE_MANAGEMENT_CAMERA2, OPTICFLOW_MAX_ITERATIONS, OPTICFLOW_MAX_ITERATIONS_CAMERA2, OPTICFLOW_MAX_TRACK_CORNERS, OPTICFLOW_MAX_TRACK_CORNERS_CAMERA2, OPTICFLOW_MEDIAN_FILTER, OPTICFLOW_MEDIAN_FILTER_CAMERA2, OPTICFLOW_METHOD, OPTICFLOW_METHOD_CAMERA2, OPTICFLOW_PYRAMID_LEVEL, OPTICFLOW_PYRAMID_LEVEL_CAMERA2, OPTICFLOW_RESOLUTION_FACTOR, OPTICFLOW_RESOLUTION_FACTOR_CAMERA2, OPTICFLOW_SEARCH_DISTANCE, OPTICFLOW_SEARCH_DISTANCE_CAMERA2, OPTICFLOW_SHOW_FLOW, OPTICFLOW_SHOW_FLOW_CAMERA2, OPTICFLOW_SUBPIXEL_FACTOR, OPTICFLOW_SUBPIXEL_FACTOR_CAMERA2, OPTICFLOW_THRESHOLD_VEC, OPTICFLOW_THRESHOLD_VEC_CAMERA2, OPTICFLOW_TRACK_BACK, OPTICFLOW_TRACK_BACK_CAMERA2, OPTICFLOW_WINDOW_SIZE, and OPTICFLOW_WINDOW_SIZE_CAMERA2.
Referenced by opticflow_module_init().
|
static |
Definition at line 832 of file opticflow_calculator.c.
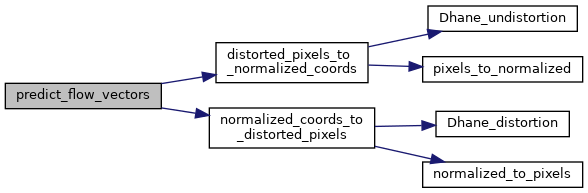
References A, B, distorted_pixels_to_normalized_coords(), flow_t::error, flow_t::flow_x, flow_t::flow_y, front_camera, K, LARGE_FLOW_ERROR, normalized_coords_to_distorted_pixels(), opticflow, flow_t::pos, point_t::x, and point_t::y.
Referenced by calc_fast9_lukas_kanade().
|
static |
Calculate the difference from start till finish.
| [in] | *starttime | The start time to calculate the difference from |
| [in] | *finishtime | The finish time to calculate the difference from |
Definition at line 1219 of file opticflow_calculator.c.
Referenced by calc_edgeflow_tot(), and calc_fast9_lukas_kanade().
| struct FloatRMat body_to_cam[2] |
Definition at line 382 of file opticflow_calculator.c.
Referenced by opticflow_calc_frame(), and opticflow_calc_init().
| uint16_t n_agents[2] = {25, 25} |
Definition at line 60 of file opticflow_calculator.c.
Referenced by act_fast(), and calc_fast9_lukas_kanade().
| uint16_t n_time_steps[2] = {10, 10} |
Definition at line 59 of file opticflow_calculator.c.
Referenced by act_fast(), and calc_fast9_lukas_kanade().
| struct MedianFilter3Float vel_filt |
Definition at line 381 of file opticflow_calculator.c.
Referenced by calc_edgeflow_tot(), and calc_fast9_lukas_kanade().
 1.15.0