|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
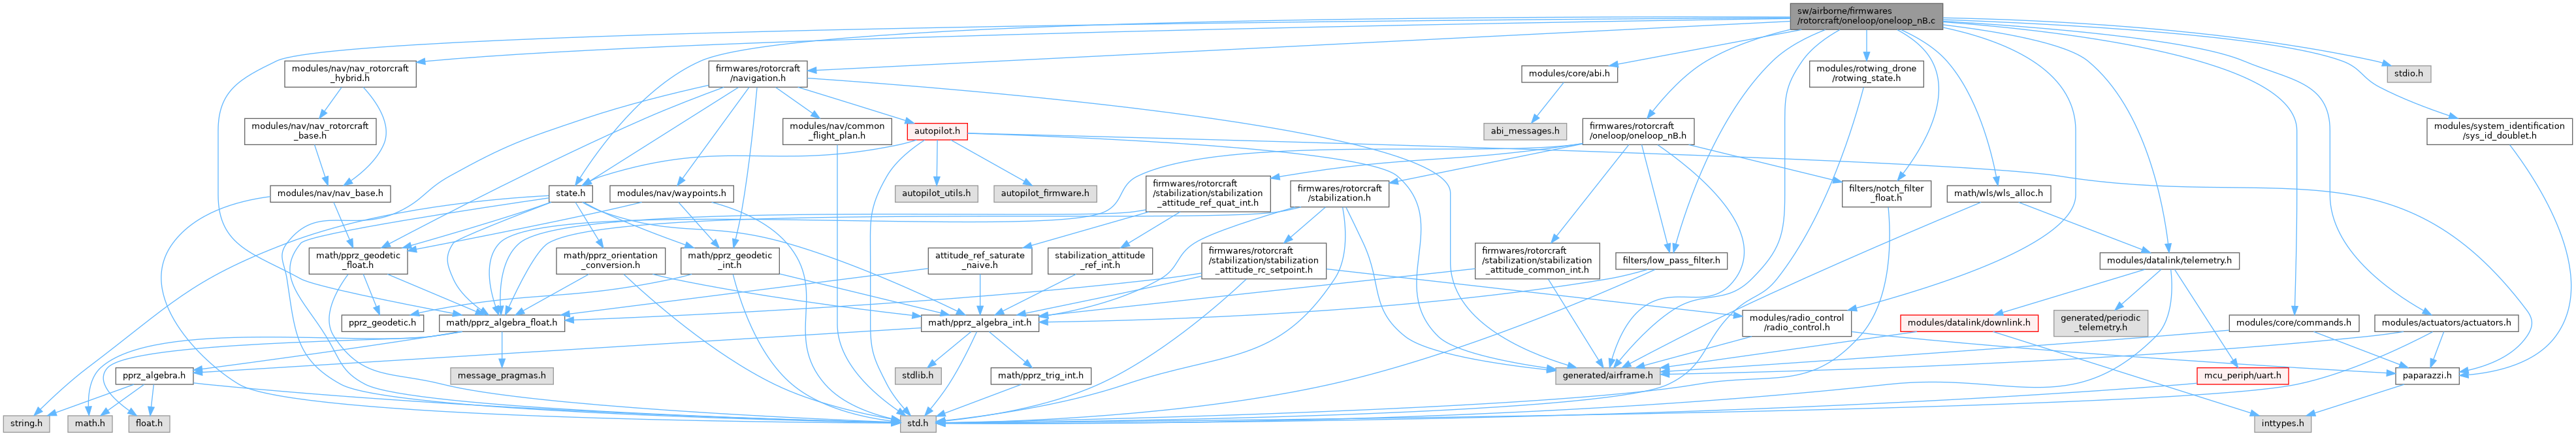
#include "firmwares/rotorcraft/oneloop/oneloop_nB.h"#include "math/pprz_algebra_float.h"#include "state.h"#include "generated/airframe.h"#include "modules/radio_control/radio_control.h"#include "modules/actuators/actuators.h"#include "modules/core/abi.h"#include "filters/low_pass_filter.h"#include "filters/notch_filter_float.h"#include "math/wls/wls_alloc.h"#include "modules/nav/nav_rotorcraft_hybrid.h"#include "firmwares/rotorcraft/navigation.h"#include "modules/rotwing_drone/rotwing_state.h"#include "modules/core/commands.h"#include "modules/system_identification/sys_id_doublet.h"#include <stdio.h>#include "modules/datalink/telemetry.h"Go to the source code of this file.
Enumerations | |
| enum | spin_man_state_t { SPIN_MAN_IDLE , SPIN_MAN_UP_RAMP , SPIN_MAN_UP_BLEND , SPIN_MAN_DOWN_SLOW , SPIN_MAN_DOWN_BLEND , SPIN_MAN_DOWN_RAMP } |
Functions | |
| PRINT_CONFIG_VAR (ONELOOP_NB_FILT_CUTOFF) | |
| PRINT_CONFIG_VAR (ONELOOP_NB_FILT_CUTOFF_Q) | |
| PRINT_CONFIG_VAR (ONELOOP_NB_FILT_CUTOFF_P) | |
| PRINT_CONFIG_VAR (ONELOOP_NB_FILT_CUTOFF_R) | |
| PRINT_CONFIG_VAR (ONELOOP_NB_MAX_THETA) | |
| void | init_poles (void) |
| Initialize Position of Poles. | |
| void | init_poles_att (void) |
| Initialize Position of Poles. | |
| void | init_poles_pos (void) |
| void | calc_normalization (void) |
| Calculate Normalization of actuators and discrete actuator dynamics. | |
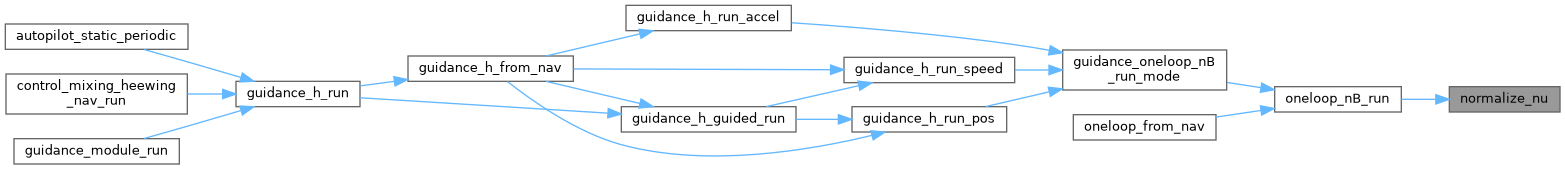
| void | normalize_nu (void) |
| Function to normalize the pseudo control vector. | |
| void | G1G2_oneloop (int ctrl_type) |
| Function that samples and scales the effectiveness matrix FIXME: make this function into a for loop to make it more adaptable to different configurations. | |
| void | get_act_state_oneloop (void) |
| Function to reconstruct actuator state using first order dynamics. | |
| void | oneloop_nB_propagate_filters (void) |
| Propagate the filters. | |
| void | init_filter (void) |
| Initialize the filters. | |
| void | init_controller_gains (void) |
| Initialize Controller Gains FIXME: Calculate the gains dynamically for transition. | |
| void | reinit_controller (void) |
| Re-Init function of controller variables. | |
| void | float_rates_of_euler_dot_vec (float r[3], float e[3], float edot[3]) |
| Attitude Rates to Euler Conversion Function ZYX. | |
| void | float_euler_dot_of_rates_vec (float r[3], float e[3], float edot[3]) |
| Attitude Euler to Rates Conversion Function ZYX. | |
| void | err_nd (float err[], float a[], float b[], float k[], int n) |
| Calculate Scaled Error between two 3D arrays. | |
| void | err_sum_nd (float err[], float a[], float b[], float k[], float c[], int n) |
| Calculate Scaled Error between two 3D arrays. | |
| void | float_vect_diff_euler (float err[3], float a[3], float b[3]) |
| Calculate Error between two 3D euler arrays with the psi normalized. | |
| void | integrate_nd (float dt, float a[], float a_dot[], int n) |
| Integrate in time 3D array. | |
| void | vect_bound_nd (float vect[], float bound, int n) |
| Scale a 3D array to within a 3D bound. | |
| void | acc_body_bound (struct FloatVect2 *vect, float bound) |
| Scale a 3D array to within a 3D bound. | |
| float | bound_v_from_a_vect (float e_x[], float v_bound, float a_bound, int n) |
| Calculate velocity limit based on acceleration limit for a vector From SUVAT we have that v^2 = u^2 + 2*a*s. | |
| float | bound_v_from_a (float e_x, float v_bound, float a_bound) |
| Calculate velocity limit based on acceleration limit for a float From SUVAT we have that v^2 = u^2 + 2*a*s. | |
| void | rm_3rd_attitude (float dt, float x_ref[3], float x_d_ref[3], float x_2d_ref[3], float x_3d_ref[3], float x_des[3], bool ow_psi, float psi_overwrite[4], float k1_rm[3], float k2_rm[3], float k3_rm[3], struct OneloopStabilizationRef bounds) |
| Reference Model Definition for 3rd order system with attitude conversion functions. | |
| void | rm_3rd_pos (float dt, float x_ref[], float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x_des[], float k1_rm[], float k2_rm[], float k3_rm[], float x_d_bound, float x_2d_bound, float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | rm_2nd_pos (float dt, float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x_d_des[], float k2_rm[], float k3_rm[], float x_2d_bound, float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | rm_1st_pos (float dt, float x_2d_ref[], float x_3d_ref[], float x_2d_des[], float k3_rm[], float x_3d_bound, int n) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | rm_3rd_nI (float dt, struct FloatVect3 *x_ref, struct FloatVect3 *x_d_ref, struct FloatVect3 *x_2d_ref, struct FloatVect3 *x_3d_ref, const struct FloatVect3 *x_des, const float k1_rm[3], const float k2_rm[3], const float k3_rm[3]) |
| void | ec_3rd_att (float y_4d[3], float x_des[3], float x_ref[3], float x_d_ref[3], float x_2d_ref[3], float x_3d_ref[3], float x[3], float x_d[3], float x_2d[3], float k1_e[3], float k2_e[3], float k3_e[3], struct OneloopStabilizationRef bounds, float fb[3]) |
| Error Controller Definition for 3rd order system specific to attitude. | |
| void | ec_3rd_pos (float y_4d[], float x_des[], float x_ref[], float x_d_ref[], float x_2d_ref[], float x_3d_ref[], float x[], float x_d[], float x_2d[], float k1_e[], float k2_e[], float k3_e[], float x_d_bound, float x_2d_bound, float fb[], int n) |
| Error Controller Definition for 3rd order system. | |
| float | oneloop_nB_sideslip (void) |
| Function to calculate corrections for sideslip DEPRECIATED. | |
| void | reshape_wind (void) |
| void | chirp_pos (float time_elapsed, float f0, float f1, float t_chirp, float A, int8_t n, float psi, float p_ref[], float v_ref[], float a_ref[], float j_ref[], float p_ref_0[]) |
| Reference Model Definition for 3rd order system specific to positioning with bounds. | |
| void | chirp_call (bool *chirp_on, bool *chirp_first_call, float *t_0_chirp, float *time_elapsed, float f0, float f1, float t_chirp, float A, int8_t n, float psi, float p_ref[], float v_ref[], float a_ref[], float j_ref[], float p_ref_0[]) |
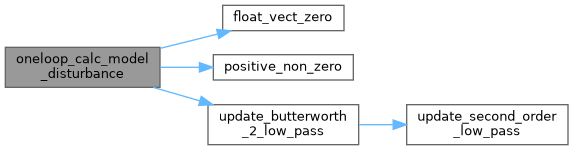
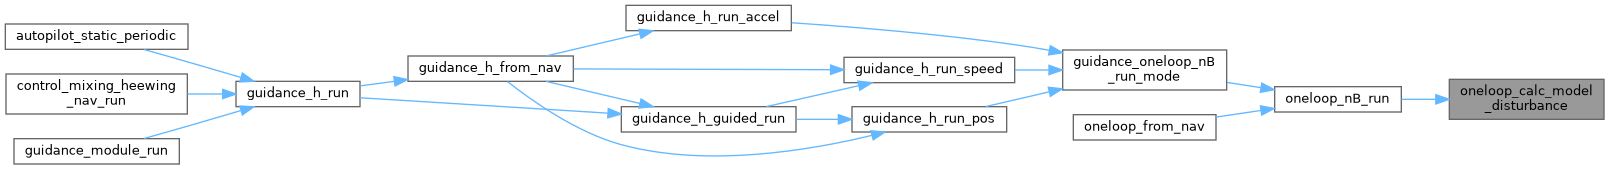
| void | oneloop_calc_model_disturbance (bool in_flight) |
| Function that calculates the model disturbance (Control Effort) The control effort is equalt to : EFF_MAT*u_filt where EFF_MAT is what is inverted and u_filt is the filtered actuator state. | |
| void | oneloop_nB_state_compensation (bool state_compensation_on) |
| Function that performs state compensation for gyroscopic effects. | |
| void | set_WLS_settings (void) |
| Function that sets the WLS settings for oneloop controller. | |
| void | drop_axis (void) |
| Function that drops control along selected axes. | |
| void | skew_symmetric (struct FloatRMat *out, const struct FloatVect3 *in) |
| void | oneloop_nB_calc_nB_states (void) |
| Function which estimates the nB states. | |
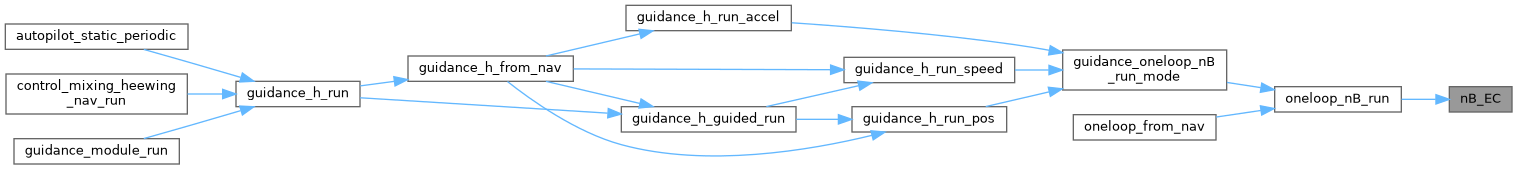
| void | nB_EC (struct FloatVect3 nB, struct FloatVect3 nB_d, struct FloatVect3 nB_2d, struct FloatVect3 mu_B, float k1_e[3], float k2_e[3], float k3_e[3], float dist[3], float nB_nu[3]) |
| void | calc_HB_matrix (float HB[3][3], struct FloatVect3 nB) |
| void | SpinQuad_overwrite (float gain, float ce_model, float *nu_stab_2) |
| float | cos_2n (float psi, float xi, int n) |
| float | phase_first_order (float r, float w) |
| float | xi_fun (float r, float w, float aN_des, float aE_des) |
| float | pusher_cmd_fun (float aN_des, float aE_des, float r, float psi, float w, int n) |
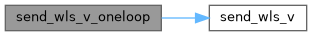
| static void | send_wls_v_oneloop (struct transport_tx *trans, struct link_device *dev) |
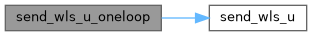
| static void | send_wls_u_oneloop (struct transport_tx *trans, struct link_device *dev) |
| static void | send_eff_mat_stab_oneloop_nB (struct transport_tx *trans, struct link_device *dev) |
| static void | send_eff_mat_stab_thrust_oneloop_nB (struct transport_tx *trans, struct link_device *dev) |
| static void | send_eff_mat_guid_oneloop_nB (struct transport_tx *trans, struct link_device *dev) |
| static void | send_oneloop_nB (struct transport_tx *trans, struct link_device *dev) |
| static void | send_oneloop_nB_ctrl (struct transport_tx *trans, struct link_device *dev) |
| static void | send_guidance_oneloop_nB (struct transport_tx *trans, struct link_device *dev) |
| static void | debug_vect (struct transport_tx *trans, struct link_device *dev, char *name, float *data, int datasize) |
| static void | send_oneloop_debug (struct transport_tx *trans, struct link_device *dev) |
| static void | spin_prot_bound_params (void) |
| Enforce valid spin protection / spin trim parameters (they can be changed in flight from the settings). | |
| static void | spin_man_reset (void) |
| Stop the spin manoeuvre and clear its GCS triggers (fault flags are left as they are). | |
| static void | spin_man_set_pair (uint8_t pair) |
| Select the motors of a pair (pitch: FRONT/BACK, roll: RIGHT/LEFT) for the blend. | |
| static void | spin_man_start_blend (void) |
| Start a bumpless transfer of the selected pair from the average of its last applied commands, so that both motors of the pair are commanded the same during the blend. | |
| static void | spin_man_ramp_ref (float target) |
| Move the yaw rate reference towards target at spin_man_ramp_rate. | |
| static bool | spin_man_rate_ctrl (void) |
| Yaw rate tracking is used by the manoeuvre (no fault active). | |
| static void | spin_man_update (bool in_flight, bool nb_ctrl) |
| Spin transition manoeuvre state machine. | |
| static float | positive_non_zero (float input) |
| Function to make sure that inputs are positive non zero vaues. | |
| static float | k_rm_1_3_f (float omega_n, float zeta, float p1) |
| Reference Model Gain Design. | |
| static float | k_rm_2_3_f (float omega_n, float zeta, float p1) |
| static float | k_rm_3_3_f (float omega_n, float zeta, float p1) |
| static bool | vec3_saturated (const float u_unsat[3], const float u_sat[3], float eps) |
| static void | ARW_ClampVec3 (const float err[3], const float u_unsat[3], const float u_sat[3], const float I_prev[3], const float I_cand[3], float I_next[3]) |
| static void | Vel_PID_ARW (float x_dot_des[3], const float x_dot[3], float k_P, float k_I, float k_D, float a_sp[3], float a_max, float v_max) |
| static void | Pos_KPID_ARW (const float x_des[3], const float x[3], const float x_dot[3], float k_K, float k_P, float k_I, float k_D, float a_sp[3], float a_max, float v_max) |
| static void | shape_vector (float a[3]) |
| static void | eul_of_acc (float a[3], float psi) |
| static float | ec_poles (float p_rm, float slow_pole, float k) |
| Calculate EC poles given RM poles. | |
| static void | init_filter_on_type (struct LP_t *filter, float x0) |
| Initialize a filter based on its type. | |
| static void | update_filter_on_type (struct LP_t *filter, float input) |
| Update a filter based on its type. | |
| static void | init_LP (struct LP_t *LP, float fc) |
| Initialize the Low Pass Filter Struct. | |
| static void | reinit_LP_synchronous (struct LP_t *LP, struct LP_t *f, bool reinit) |
| Reinitialize Low Pass filter if new frequency setting or if forced. | |
| static void | reinit_LP (struct LP_t *LP, bool reinit) |
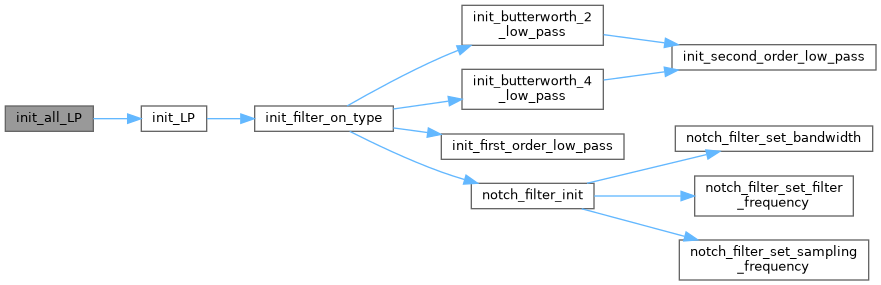
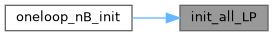
| static void | init_all_LP (void) |
| Initialize all Low Pass Filters. | |
| static void | reinit_all_LP (bool reinit) |
| Reinitialize all the Low Pass Filters. | |
| void | oneloop_nB_init (void) |
| Init function of Oneloop ANDI controller. | |
| void | oneloop_nB_enter (bool half_loop_sp, int ctrl_type) |
| Function that resets important values upon engaging Oneloop ANDI. | |
| void | oneloop_nB_RM (bool half_loop, struct FloatVect3 PSA_des, bool in_flight_oneloop) |
| Function to generate the reference signals for the oneloop controller. | |
| void | oneloop_nB_run (bool in_flight, bool half_loop, struct FloatVect3 PSA_des) |
| Main function that runs the controller and performs control allocation. | |
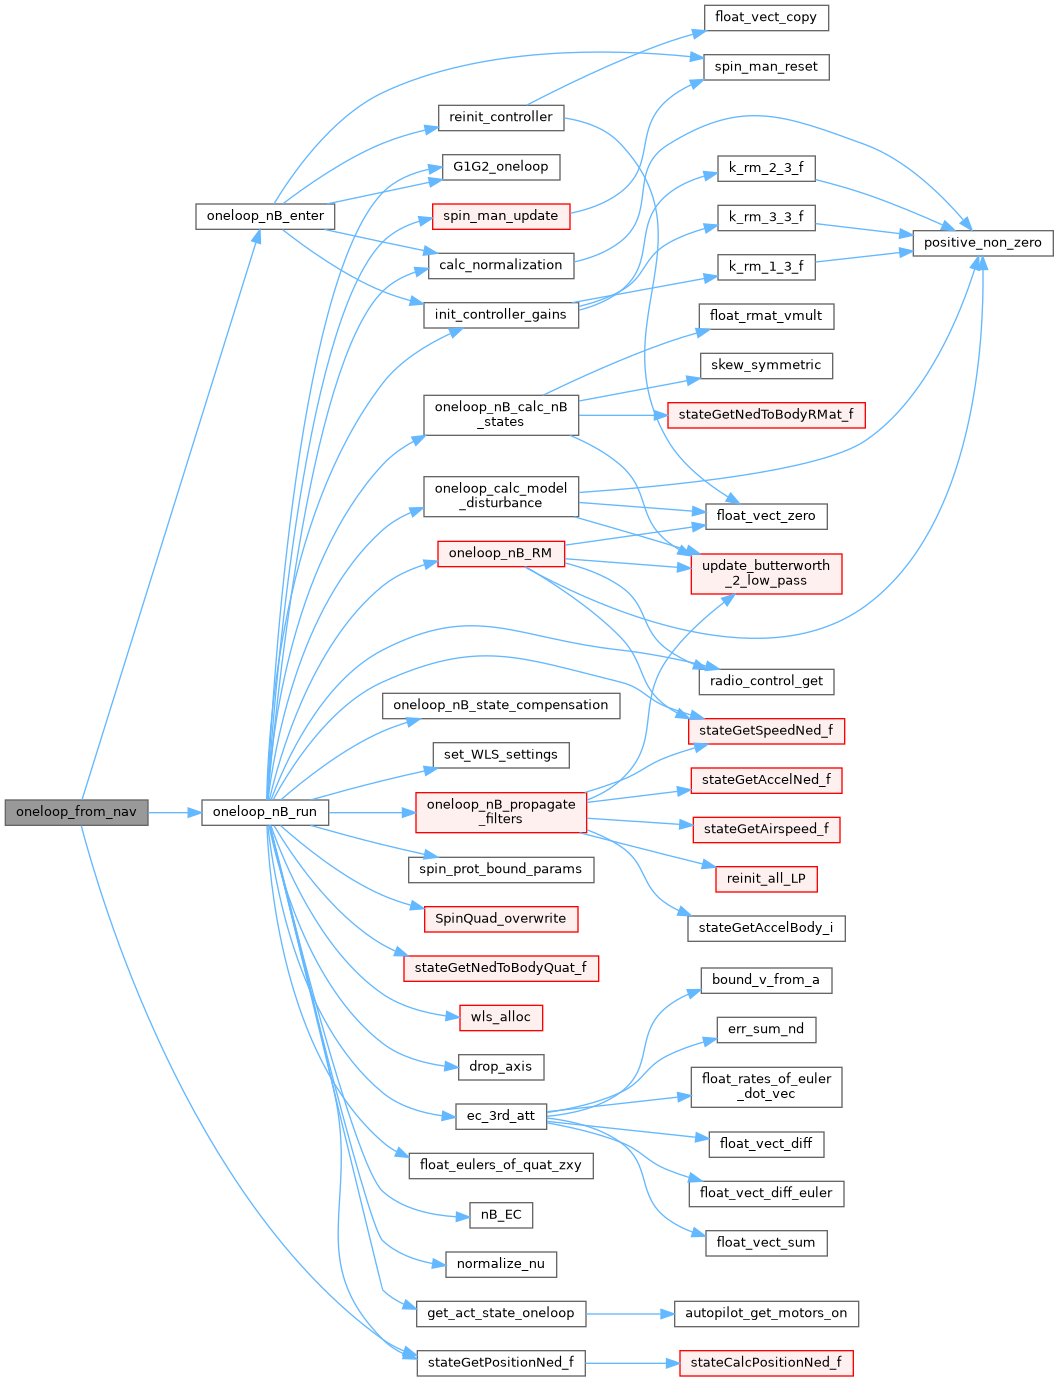
| void | oneloop_from_nav (bool in_flight) |
| Function that maps navigation inputs to the oneloop controller for the generated autopilot. | |
| bool | autopilot_in_flight_end_detection (bool motors_on UNUSED) |
| Quadplanes can still be in-flight with COMMAND_THRUST==0 and can even soar not descending in updrafts with all thrust off. | |
| void | guidance_set_min_max_airspeed (float min_airspeed, float max_airspeed) |
| void | guidance_set_max_bank_angle (float max_bank) |
| Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid). | |
| void | guidance_set_max_climb_speed (float max_climb_speed_quad, float max_climb_speed_fwd) |
| void | guidance_set_max_descend_speed (float max_descend_speed_quad, float max_descend_speed_fwd) |
| #define IDX_aD RW_aD - 2 |
Definition at line 118 of file oneloop_nB.c.
Referenced by calc_normalization(), drop_axis(), oneloop_nB_RM(), oneloop_nB_run(), and set_WLS_settings().
| #define IDX_ap RW_ap - 2 |
Definition at line 119 of file oneloop_nB.c.
Referenced by calc_normalization(), drop_axis(), G1G2_oneloop(), oneloop_nB_run(), oneloop_nB_state_compensation(), and set_WLS_settings().
| #define IDX_aq RW_aq - 2 |
Definition at line 120 of file oneloop_nB.c.
Referenced by calc_normalization(), drop_axis(), G1G2_oneloop(), oneloop_nB_run(), oneloop_nB_state_compensation(), and set_WLS_settings().
| #define IDX_ar RW_ar - 2 |
Definition at line 121 of file oneloop_nB.c.
Referenced by calc_normalization(), drop_axis(), G1G2_oneloop(), oneloop_nB_run(), send_oneloop_debug(), and set_WLS_settings().
| #define ONELOOP_NB_AIRSPEED_SWITCH_THRESHOLD 10.0 |
Definition at line 395 of file oneloop_nB.c.
Referenced by reshape_wind().
| #define ONELOOP_NB_DEBUG_MODE FALSE |
Definition at line 111 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| #define ONELOOP_NB_EC_K3 22.0 |
Definition at line 619 of file oneloop_nB.c.
| #define ONELOOP_NB_FAULT_AILERONS TRUE |
Definition at line 499 of file oneloop_nB.c.
| #define ONELOOP_NB_MAX_FAULT_MOT 3000.0 |
Definition at line 310 of file oneloop_nB.c.
| #define ONELOOP_NB_PID_A_MAX 0.6 |
Definition at line 626 of file oneloop_nB.c.
| #define ONELOOP_NB_PID_V_MAX_MANUAL 3.0 |
Definition at line 629 of file oneloop_nB.c.
| #define ONELOOP_NB_PID_V_MAX_NAV 3.0 |
Definition at line 632 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_BLEND_TIME 1.0 |
Definition at line 589 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_DONE_RATE 0.5 |
Definition at line 595 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_PAIR SPIN_MAN_PAIR_PITCH |
Definition at line 600 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_PITCH_DIR 1.0 |
Definition at line 603 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_RAMP_RATE 2.0 |
Definition at line 586 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_MAN_TRIM_RATE 300.0 |
Definition at line 592 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_PROT_MAX_CMD 4800.0 |
Definition at line 537 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_PROT_MAX_RATE 34.0 |
Definition at line 531 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_PROT_MIN_GAP 1.0 |
Definition at line 565 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_PROT_START_RATE 28.0 |
Definition at line 534 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_TRIM_BLEED_RATE 1000.0 |
Definition at line 554 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_TRIM_ON TRUE |
Definition at line 548 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_TRIM_RATE 1000.0 |
Definition at line 551 of file oneloop_nB.c.
| #define ONELOOP_NB_SPIN_TRIM_RELEASE_RATE 24.0 |
Definition at line 557 of file oneloop_nB.c.
| #define OVERRIDE_ATT_RM |
| #define SPIN_MAN_PAIR_PITCH 0 |
Definition at line 597 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
| #define SPIN_MAN_PAIR_ROLL 1 |
Definition at line 598 of file oneloop_nB.c.
Referenced by spin_man_set_pair(), spin_man_update(), and spin_prot_bound_params().
| #define STREAM_BWLS |
| #define USE_BW2 |
Definition at line 125 of file oneloop_nB.c.
| #define USE_ND_VELOCITIES |
Definition at line 428 of file oneloop_nB.c.
| enum spin_man_state_t |
| Enumerator | |
|---|---|
| SPIN_MAN_IDLE | |
| SPIN_MAN_UP_RAMP | |
| SPIN_MAN_UP_BLEND | |
| SPIN_MAN_DOWN_SLOW | |
| SPIN_MAN_DOWN_BLEND | |
| SPIN_MAN_DOWN_RAMP | |
Definition at line 642 of file oneloop_nB.c.
| void acc_body_bound | ( | struct FloatVect2 * | vect, |
| float | bound ) |
Scale a 3D array to within a 3D bound.
Definition at line 1487 of file oneloop_nB.c.
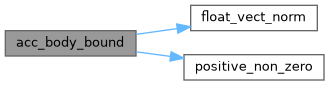
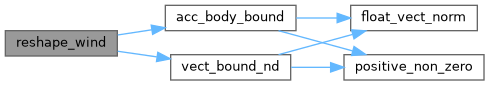
References float_vect_norm(), Min, positive_non_zero(), WLS_t::v, FloatVect2::x, and FloatVect2::y.
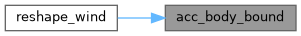
Referenced by reshape_wind().
|
static |
Definition at line 1237 of file oneloop_nB.c.
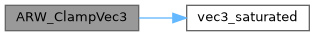
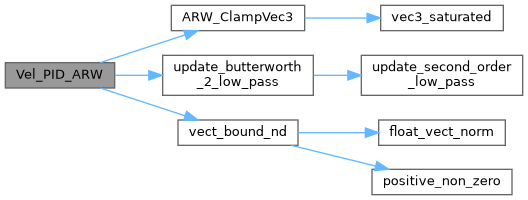
References vec3_saturated().
Referenced by Pos_KPID_ARW(), and Vel_PID_ARW().
| bool autopilot_in_flight_end_detection | ( | bool motors_on | UNUSED | ) |
Quadplanes can still be in-flight with COMMAND_THRUST==0 and can even soar not descending in updrafts with all thrust off.
Definition at line 3176 of file oneloop_nB.c.
References UNUSED.
| float bound_v_from_a | ( | float | e_x, |
| float | v_bound, | ||
| float | a_bound ) |
Calculate velocity limit based on acceleration limit for a float From SUVAT we have that v^2 = u^2 + 2*a*s.
Assuming a is constant we can calculate the velocity bound given the position error and the acceleration limit. This bounding also assumes that we want to arrive at the waypoint with zero velocity which might be untrue.
| e_x | Error in Position (always wrt the Desired) |
| v_bound | Safety bound on velocity |
| a_bound | Acceleration limit |
| n | Size of vector |
Definition at line 1534 of file oneloop_nB.c.
References xdot_lim_sf.
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| float bound_v_from_a_vect | ( | float | e_x[], |
| float | v_bound, | ||
| float | a_bound, | ||
| int | n ) |
Calculate velocity limit based on acceleration limit for a vector From SUVAT we have that v^2 = u^2 + 2*a*s.
Assuming a is constant we can calculate the velocity bound given the position error and the acceleration limit. This bounding also assumes that we want to arrive at the waypoint with zero velocity which might be untrue.
| e_x | Error in Position (always wrt the Desired) |
| v_bound | Safety bound on velocity |
| a_bound | Acceleration limit |
| n | Size of vector |
Definition at line 1518 of file oneloop_nB.c.
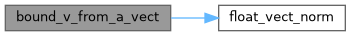
References float_vect_norm(), and xdot_lim_sf.
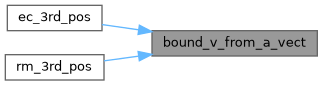
Referenced by ec_3rd_pos(), and rm_3rd_pos().
| void calc_HB_matrix | ( | float | HB[3][3], |
| struct FloatVect3 | nB ) |
Definition at line 3736 of file oneloop_nB.c.
References FloatVect3::x, FloatVect3::y, and FloatVect3::z.
| void calc_normalization | ( | void | ) |
Calculate Normalization of actuators and discrete actuator dynamics.
Definition at line 3051 of file oneloop_nB.c.
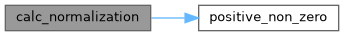
References act_dynamics, act_dynamics_d, act_max, act_max_norm, act_min, act_min_norm, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, dt_1l, IDX_aD, IDX_ap, IDX_aq, IDX_ar, max_j_lin, MAX_PPRZ, nu_norm_max, positive_non_zero(), ratio_u_un, ratio_vn_v, and sta_bounds.
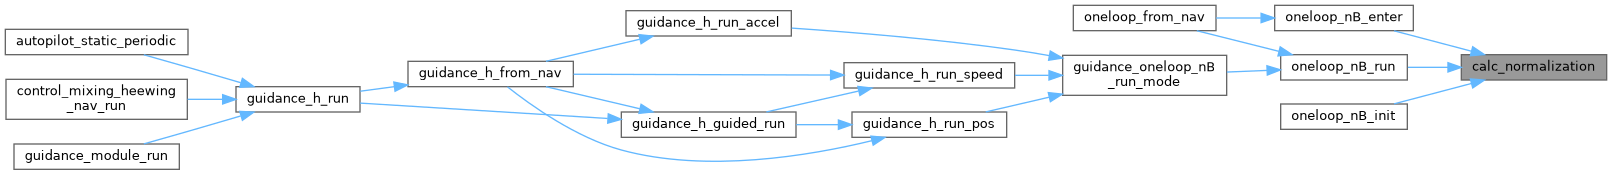
Referenced by oneloop_nB_enter(), oneloop_nB_init(), and oneloop_nB_run().
| void chirp_call | ( | bool * | chirp_on, |
| bool * | chirp_first_call, | ||
| float * | t_0_chirp, | ||
| float * | time_elapsed, | ||
| float | f0, | ||
| float | f1, | ||
| float | t_chirp, | ||
| float | A, | ||
| int8_t | n, | ||
| float | psi, | ||
| float | p_ref[], | ||
| float | v_ref[], | ||
| float | a_ref[], | ||
| float | j_ref[], | ||
| float | p_ref_0[] ) |
Definition at line 2810 of file oneloop_andi.c.
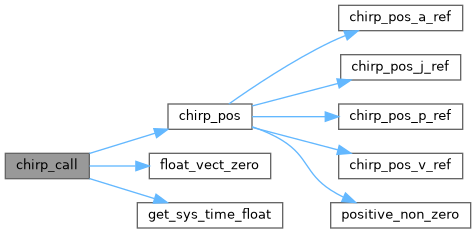
References A, chirp_first_call, chirp_on, chirp_pos(), drop_aD, drop_aE, drop_aN, drop_pitch, drop_roll, drop_yaw, float_vect_zero(), get_sys_time_float(), p_ref_0, and t_chirp.
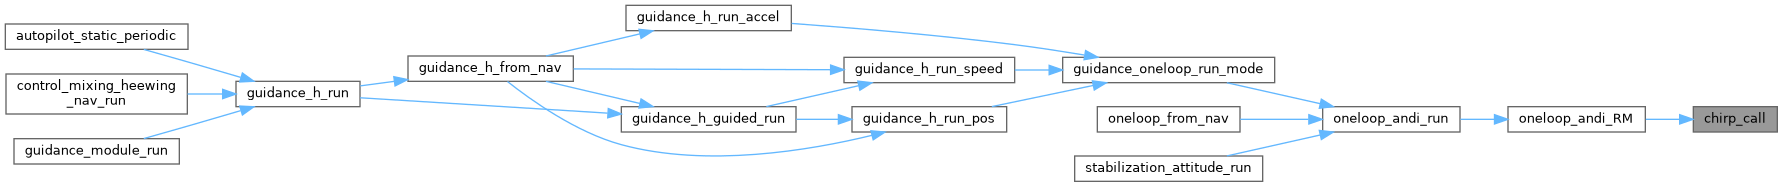
Referenced by oneloop_andi_RM().
| void chirp_pos | ( | float | time_elapsed, |
| float | f0, | ||
| float | f1, | ||
| float | t_chirp, | ||
| float | A, | ||
| int8_t | n, | ||
| float | psi, | ||
| float | p_ref[], | ||
| float | v_ref[], | ||
| float | a_ref[], | ||
| float | j_ref[], | ||
| float | p_ref_0[] ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | [s] time passed since start of the chirp |
| f0 | [Hz] initial frequency of the chirp |
| f1 | [Hz] final frequency of the chirp |
| t_chirp | [s] duration of the chirp |
| p_ref | [m] position reference |
| v_ref | [m/s] velocity reference |
| a_ref | [m/s2] acceleration reference |
| j_ref | [m/s3] jerk reference |
Definition at line 2676 of file oneloop_andi.c.
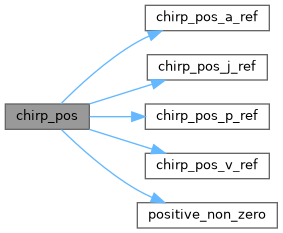
References A, chirp_pos_a_ref(), chirp_pos_j_ref(), chirp_pos_p_ref(), chirp_pos_v_ref(), drop_aE, drop_aN, oneloop_andi, oneloop_andi_sigma, oneloop_andi_sigma_max, oneloop_andi_sigma_min, p_ref_0, pitch_pref, positive_non_zero(), psi_des_rad, t_chirp, and theta_pref_max.
Referenced by chirp_call().
| float cos_2n | ( | float | psi, |
| float | xi, | ||
| int | n ) |
Definition at line 3795 of file oneloop_nB.c.
References c2, xi, and FloatVect3::y.
Referenced by pusher_cmd_fun().
|
static |
Definition at line 894 of file oneloop_nB.c.
References dev.
Referenced by send_oneloop_debug().
| void drop_axis | ( | void | ) |
Function that drops control along selected axes.
Definition at line 3326 of file oneloop_nB.c.
References ctrl_effort_model, drop_aD, drop_pitch, drop_roll, drop_yaw, IDX_aD, IDX_ap, IDX_aq, IDX_ar, and nu.
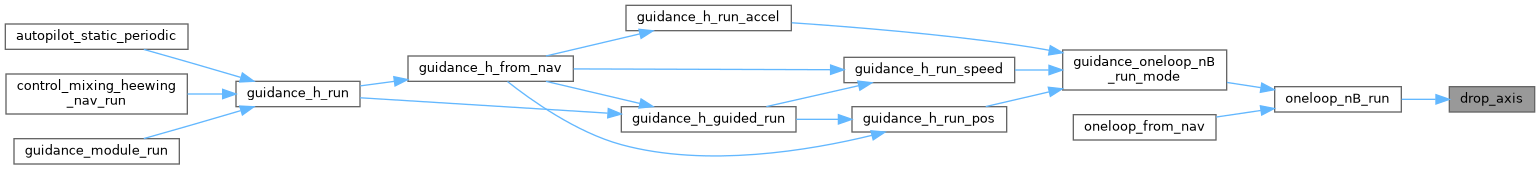
Referenced by oneloop_nB_run().
| void ec_3rd_att | ( | float | y_4d[3], |
| float | x_des[3], | ||
| float | x_ref[3], | ||
| float | x_d_ref[3], | ||
| float | x_2d_ref[3], | ||
| float | x_3d_ref[3], | ||
| float | x[3], | ||
| float | x_d[3], | ||
| float | x_2d[3], | ||
| float | k1_e[3], | ||
| float | k2_e[3], | ||
| float | k3_e[3], | ||
| struct OneloopStabilizationRef | bounds, | ||
| float | fb[3] ) |
Error Controller Definition for 3rd order system specific to attitude.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| x | Current 1st order signal |
| x_d | Current 2nd order signal |
| x_2d | Current 3rd order signal |
| k1_e | Error Controller Gain 1st order signal |
| k2_e | Error Controller Gain 2nd order signal |
| k3_e | Error Controller Gain 3rd order signal |
Definition at line 1746 of file oneloop_nB.c.
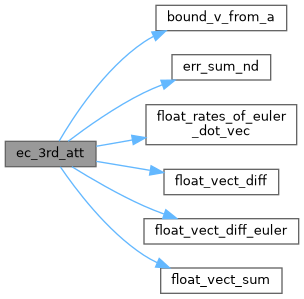
References OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_d, bound_v_from_a(), ec_headroom, err_sum_nd(), float_rates_of_euler_dot_vec(), float_vect_diff(), float_vect_diff_euler(), and float_vect_sum().
Referenced by oneloop_nB_run().
| void ec_3rd_pos | ( | float | y_4d[], |
| float | x_des[], | ||
| float | x_ref[], | ||
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x[], | ||
| float | x_d[], | ||
| float | x_2d[], | ||
| float | k1_e[], | ||
| float | k2_e[], | ||
| float | k3_e[], | ||
| float | x_d_bound, | ||
| float | x_2d_bound, | ||
| float | fb[], | ||
| int | n ) |
Error Controller Definition for 3rd order system.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| x | Current 1st order signal |
| x_d | Current 2nd order signal |
| x_2d | Current 3rd order signal |
| k1_e | Error Controller Gain 1st order signal |
| k2_e | Error Controller Gain 2nd order signal |
| k3_e | Error Controller Gain 3rd order signal |
Definition at line 1714 of file oneloop_nB.c.
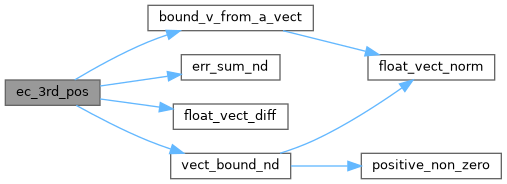
References bound_v_from_a_vect(), ec_headroom, err_sum_nd(), float_vect_diff(), and vect_bound_nd().
|
static |
Calculate EC poles given RM poles.
| p_rm | Reference Model Pole (3 coincident poles) |
| slow_pole | Pole of the slowest dynamics |
| k | EC / RM ratio |
| omega_n | Natural Frequency |
Definition at line 1796 of file oneloop_nB.c.
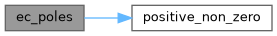
References positive_non_zero(), and slow_pole.
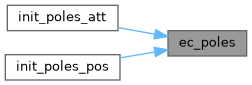
Referenced by init_poles_att(), and init_poles_pos().
| void err_nd | ( | float | err[], |
| float | a[], | ||
| float | b[], | ||
| float | k[], | ||
| int | n ) |
Calculate Scaled Error between two 3D arrays.
Definition at line 1118 of file oneloop_nB.c.
References b.
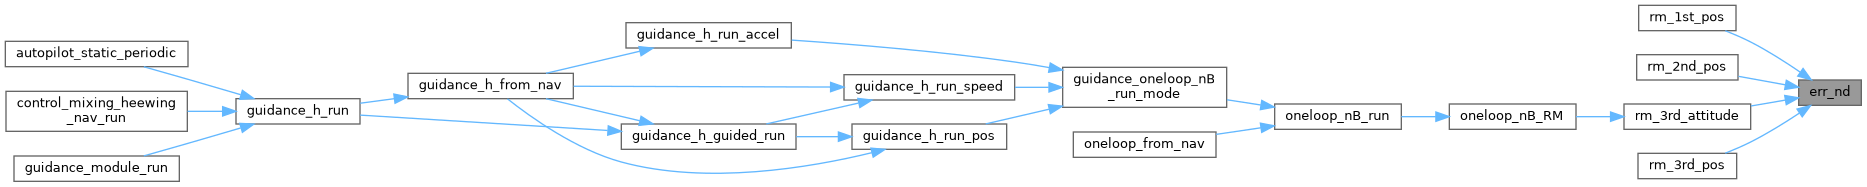
Referenced by rm_1st_pos(), rm_2nd_pos(), rm_3rd_attitude(), and rm_3rd_pos().
| void err_sum_nd | ( | float | err[], |
| float | a[], | ||
| float | b[], | ||
| float | k[], | ||
| float | c[], | ||
| int | n ) |
Calculate Scaled Error between two 3D arrays.
Definition at line 1127 of file oneloop_nB.c.
References b.
Referenced by ec_3rd_att(), and ec_3rd_pos().
|
static |
Definition at line 1403 of file oneloop_nB.c.
References eulers_zxy_des, max_phi, and max_theta.
Referenced by oneloop_nB_RM().
| void float_euler_dot_of_rates_vec | ( | float | r[3], |
| float | e[3], | ||
| float | edot[3] ) |
Attitude Euler to Rates Conversion Function ZYX.
Attitude Euler to Rates Conversion Function ZXY
Definition at line 1467 of file oneloop_nB.c.
Referenced by rm_3rd_attitude().
| void float_rates_of_euler_dot_vec | ( | float | r[3], |
| float | e[3], | ||
| float | edot[3] ) |
Attitude Rates to Euler Conversion Function ZYX.
Attitude Rates to Euler Conversion Function ZXY
Definition at line 1439 of file oneloop_nB.c.
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| void float_vect_diff_euler | ( | float | err[3], |
| float | a[3], | ||
| float | b[3] ) |
Calculate Error between two 3D euler arrays with the psi normalized.
Definition at line 1137 of file oneloop_nB.c.
References b.
Referenced by ec_3rd_att(), and rm_3rd_attitude().
| void G1G2_oneloop | ( | int | ctrl_type | ) |
Function that samples and scales the effectiveness matrix FIXME: make this function into a for loop to make it more adaptable to different configurations.
Definition at line 2970 of file oneloop_nB.c.
References act_dyn_ctrl, act_dynamics, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, bwls_1l, CTRL_ANDI, CTRL_INDI, CTRL_NB_ANDI, CTRL_NB_INDI, EFF_MAT_G, EFF_MAT_RW, fault_ailerons, fault_pitch_motors, fault_roll_motors, IDX_ap, IDX_aq, IDX_ar, nB_filt, ratio_u_un, and ratio_vn_v.
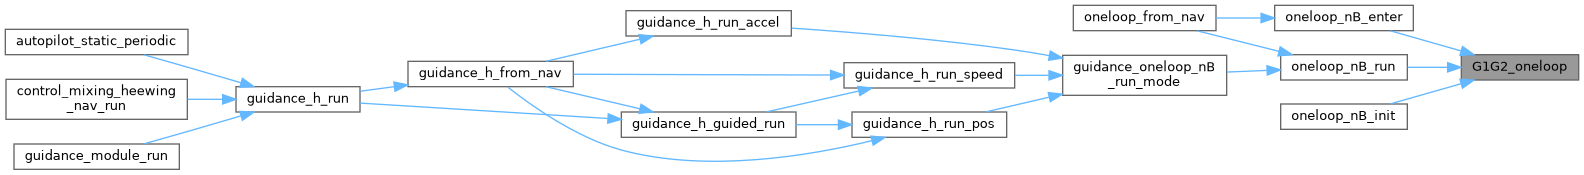
Referenced by oneloop_nB_enter(), oneloop_nB_init(), and oneloop_nB_run().
| void get_act_state_oneloop | ( | void | ) |
Function to reconstruct actuator state using first order dynamics.
Definition at line 2942 of file oneloop_nB.c.
References act_dynamics_d, act_max, act_min, actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, andi_u, autopilot_get_motors_on(), and oneloop_nB.
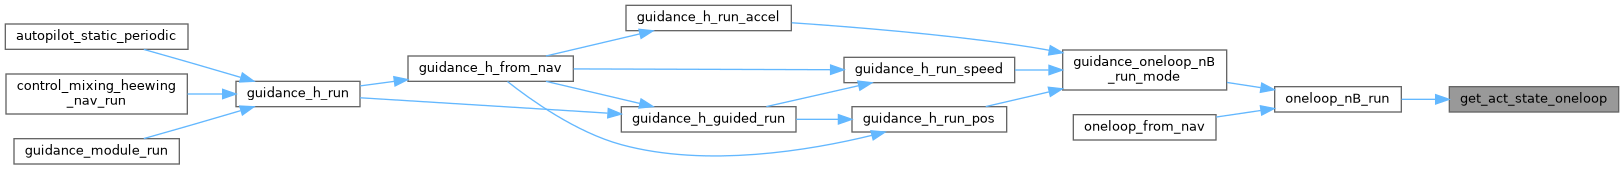
Referenced by oneloop_nB_run().
| void guidance_set_max_bank_angle | ( | float | max_bank | ) |
Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid).
The one loop controller uses its own limits, so these are no-ops here.
Definition at line 3774 of file oneloop_nB.c.
References max_bank.
| void guidance_set_max_climb_speed | ( | float | max_climb_speed_quad, |
| float | max_climb_speed_fwd ) |
Definition at line 3780 of file oneloop_nB.c.
| void guidance_set_max_descend_speed | ( | float | max_descend_speed_quad, |
| float | max_descend_speed_fwd ) |
Definition at line 3787 of file oneloop_nB.c.
| void guidance_set_min_max_airspeed | ( | float | min_airspeed, |
| float | max_airspeed ) |
Definition at line 3251 of file oneloop_nB.c.
References max_airspeed, max_as, and min_as.
|
inlinestatic |
Initialize all Low Pass Filters.
Definition at line 2109 of file oneloop_nB.c.
References init_LP(), LP, and oneloop_nB_filt_cutoff.
Referenced by oneloop_nB_init().
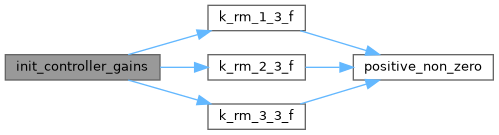
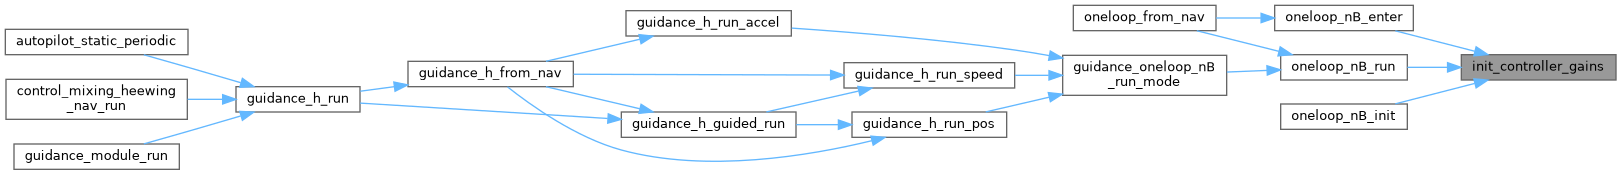
| void init_controller_gains | ( | void | ) |
Initialize Controller Gains FIXME: Calculate the gains dynamically for transition.
Definition at line 1872 of file oneloop_nB.c.
References ec_k3, k1_NE_tune, k2_NE_tune, k_att_e, k_att_e_indi, k_att_rm, k_pos_e, k_pos_e_indi, k_pos_rm, k_rm_1_3_f(), k_rm_2_3_f(), k_rm_3_3_f(), max_a_nav, max_bank, max_v_nav, nav_hybrid_max_bank, nav_hybrid_pos_gain, nav_max_acceleration_sp, nav_max_speed, p_alt_e, p_alt_rm, p_att_e, p_att_rm, p_head_e, p_head_rm, p_pos_e, p_pos_rm, and p_roll_e.
Referenced by oneloop_nB_enter(), oneloop_nB_init(), and oneloop_nB_run().
| void init_filter | ( | void | ) |
Initialize the filters.
Definition at line 2176 of file oneloop_nB.c.
References accely_filt, airspeed_filt, ANDI_NUM_ACT_TOT, init_butterworth_2_low_pass(), KPID_filt, KPID_vel_filt, nB_2d_filt, nB_3d_state_filt, nB_filt, oneloop_nB_filt_cutoff, oneloop_nB_filt_cutoff_v, push_PID_vel, push_PID_vel_d, and u_filt.
Referenced by oneloop_nB_init().
|
inlinestatic |
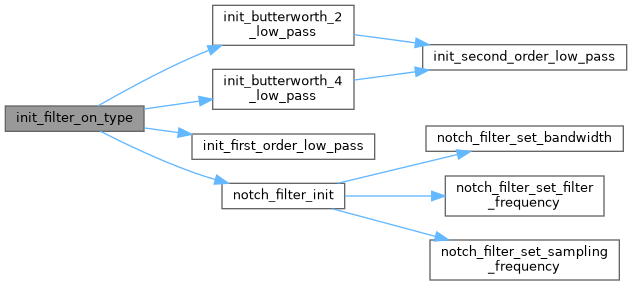
Initialize a filter based on its type.
Definition at line 2017 of file oneloop_nB.c.
References LP_t::bandwidth, BUTTERWORTH_2, BUTTERWORTH_4, LP_t::filter_type, LP_t::freq, init_butterworth_2_low_pass(), init_butterworth_4_low_pass(), init_first_order_low_pass(), LOWPASS_1, LP_t::meas_filt, NOTCH, notch_filter_init(), and LP_t::tau.
Referenced by init_LP(), reinit_LP(), and reinit_LP_synchronous().
|
inlinestatic |
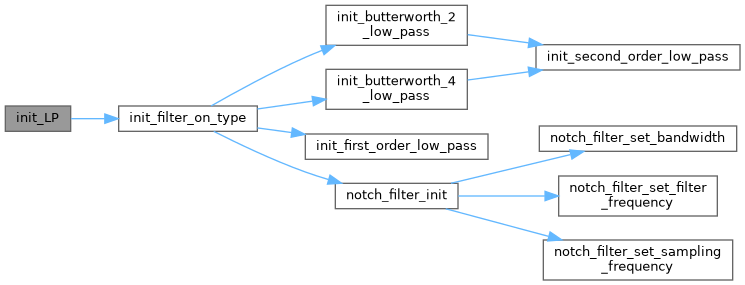
Initialize the Low Pass Filter Struct.
Definition at line 2069 of file oneloop_nB.c.
References BUTTERWORTH_2, BUTTERWORTH_4, init_filter_on_type(), LOWPASS_1, and LP.
Referenced by init_all_LP().
| void init_poles | ( | void | ) |
| void init_poles_att | ( | void | ) |
Initialize Position of Poles.
Definition at line 1810 of file oneloop_nB.c.
References ec_poles(), p_att_e, p_att_rm, p_head_e, p_head_rm, and slow_pole.
| void init_poles_pos | ( | void | ) |
Definition at line 1815 of file oneloop_nB.c.
References ec_poles(), p_alt_e, p_alt_rm, p_pos_e, p_pos_rm, and slow_pole.
| void integrate_nd | ( | float | dt, |
| float | a[], | ||
| float | a_dot[], | ||
| int | n ) |
Integrate in time 3D array.
Definition at line 1145 of file oneloop_nB.c.
Referenced by rm_1st_pos(), rm_2nd_pos(), rm_3rd_attitude(), and rm_3rd_pos().
|
static |
Reference Model Gain Design.
Definition at line 1171 of file oneloop_nB.c.
References positive_non_zero().
Referenced by init_controller_gains().
|
static |
Definition at line 1178 of file oneloop_nB.c.
References positive_non_zero().
Referenced by init_controller_gains().
|
static |
Definition at line 1185 of file oneloop_nB.c.
References positive_non_zero().
Referenced by init_controller_gains().
| void nB_EC | ( | struct FloatVect3 | nB, |
| struct FloatVect3 | nB_d, | ||
| struct FloatVect3 | nB_2d, | ||
| struct FloatVect3 | mu_B, | ||
| float | k1_e[3], | ||
| float | k2_e[3], | ||
| float | k3_e[3], | ||
| float | dist[3], | ||
| float | nB_nu[3] ) |
Definition at line 3648 of file oneloop_nB.c.
References FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by oneloop_nB_run().
| void normalize_nu | ( | void | ) |
Function to normalize the pseudo control vector.
Definition at line 3095 of file oneloop_nB.c.
References ANDI_OUTPUTS, nu, nu_n, ratio_vn_v, and WLS_one_p.
Referenced by oneloop_nB_run().
| void oneloop_calc_model_disturbance | ( | bool | in_flight | ) |
Function that calculates the model disturbance (Control Effort) The control effort is equalt to : EFF_MAT*u_filt where EFF_MAT is what is inverted and u_filt is the filtered actuator state.
Definition at line 3263 of file oneloop_nB.c.
References actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, ctrl_effort_model, EFF_MAT_G, float_vect_zero(), positive_non_zero(), ratio_u_un, ratio_vn_v, u_filt, and update_butterworth_2_low_pass().
Referenced by oneloop_nB_run().
| void oneloop_from_nav | ( | bool | in_flight | ) |
Function that maps navigation inputs to the oneloop controller for the generated autopilot.
Definition at line 3108 of file oneloop_nB.c.
References nav, NAV_SETPOINT_MODE_POS, NAV_SETPOINT_MODE_SPEED, NAV_VERTICAL_MODE_ALT, NAV_VERTICAL_MODE_CLIMB, oneloop_nB, oneloop_nB_enter(), oneloop_nB_run(), POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, SPEED_BFP_OF_REAL, SPEED_FLOAT_OF_BFP, stateGetPositionNed_f(), FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
| void oneloop_nB_calc_nB_states | ( | void | ) |
Function which estimates the nB states.
Definition at line 3471 of file oneloop_nB.c.
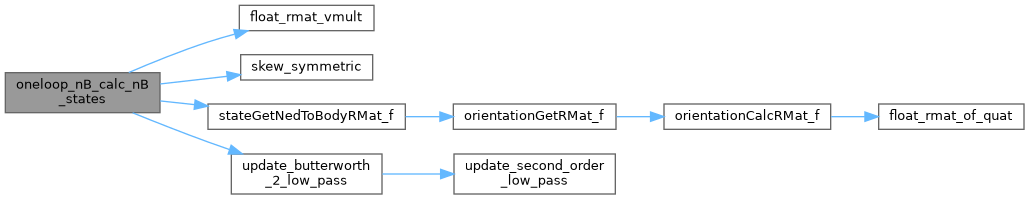
References A, B, D, debug_state, float_rmat_vmult(), FLOAT_VECT3_ZERO, LP, nB_2d_filt, nB_3d_state_filt, nB_filt, oneloop_nB, RW, skew_symmetric(), state_term, stateGetNedToBodyRMat_f(), t1, update_butterworth_2_low_pass(), VECT3_ADD, VECT3_SUB, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by oneloop_nB_run().
| void oneloop_nB_enter | ( | bool | half_loop_sp, |
| int | ctrl_type ) |
Function that resets important values upon engaging Oneloop ANDI.
FIXME: Ideally we should distinguish between the "stabilization" and "guidance" needs because it is unlikely to switch stabilization in flight, and there are multiple modes that use (the same) stabilization. Resetting the controller is not so nice when you are flying.
Definition at line 2352 of file oneloop_nB.c.
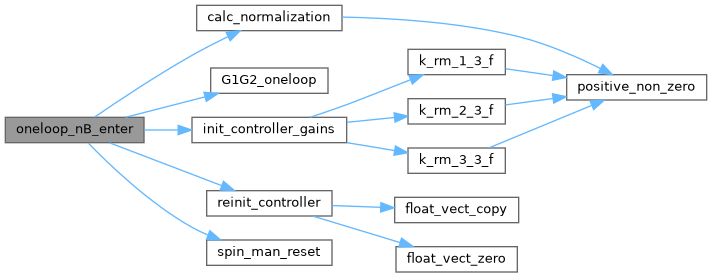
References calc_normalization(), eulers_zxy, G1G2_oneloop(), init_controller_gains(), oneloop_nB, psi_des_deg, psi_des_rad, reinit_controller(), safety_killer_trigger, and spin_man_reset().
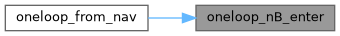
Referenced by oneloop_from_nav().
| void oneloop_nB_init | ( | void | ) |
Init function of Oneloop ANDI controller.
Definition at line 2291 of file oneloop_nB.c.
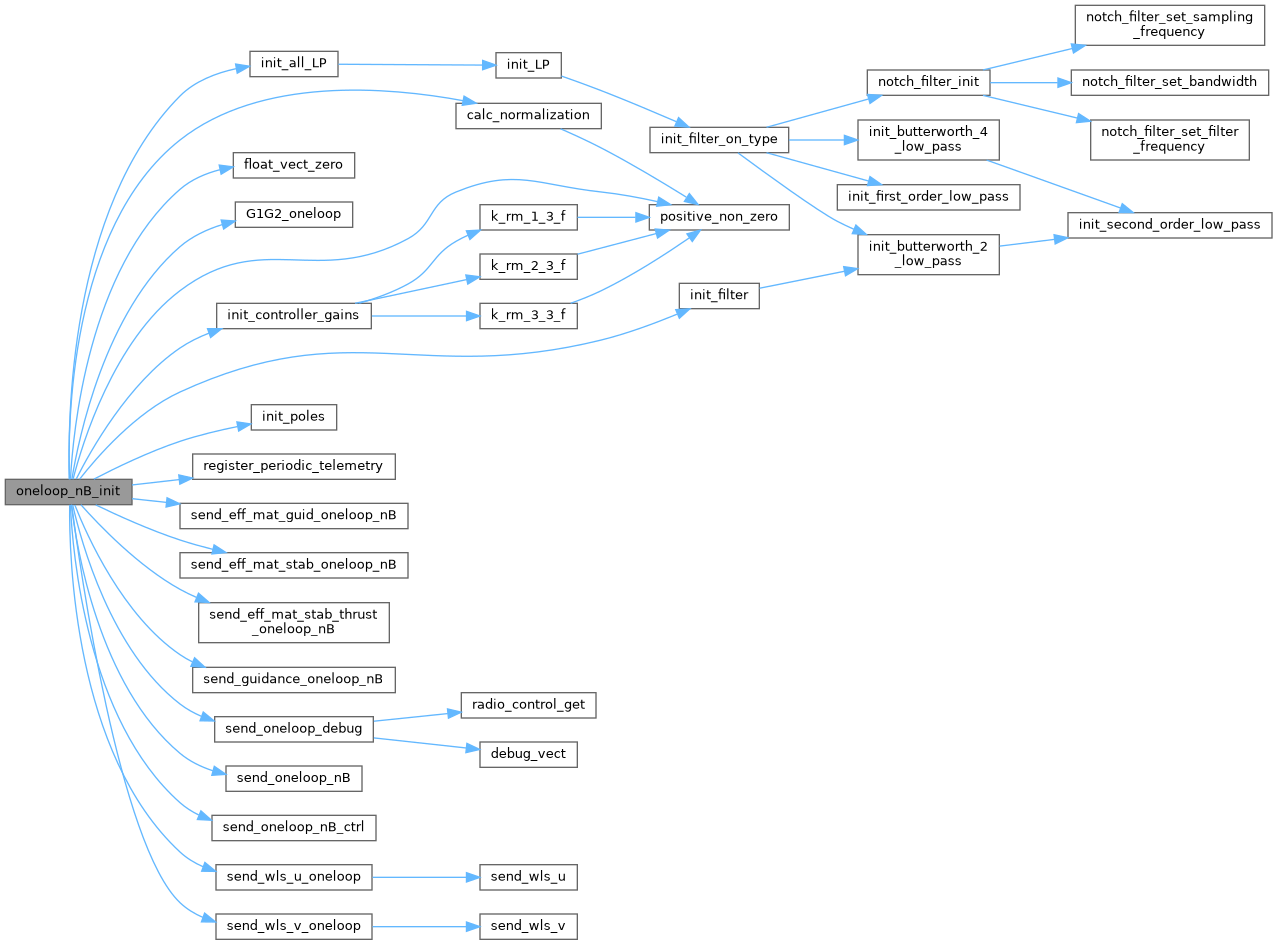
References act_dynamics, actuator_state_1l, andi_du, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, andi_u, andi_u_n, calc_normalization(), CTRL_ANDI, DefaultPeriodic, eulers_zxy_des, float_vect_zero(), G1G2_oneloop(), init_all_LP(), init_controller_gains(), init_filter(), init_poles(), nav_target, nav_target_new, nu, nu_n, oneloop_nB, positive_non_zero(), register_periodic_telemetry(), safety_killer_trigger, send_eff_mat_guid_oneloop_nB(), send_eff_mat_stab_oneloop_nB(), send_eff_mat_stab_thrust_oneloop_nB(), send_guidance_oneloop_nB(), send_oneloop_debug(), send_oneloop_nB(), send_oneloop_nB_ctrl(), send_wls_u_oneloop(), and send_wls_v_oneloop().
| void oneloop_nB_propagate_filters | ( | void | ) |
Propagate the filters.
Definition at line 2210 of file oneloop_nB.c.
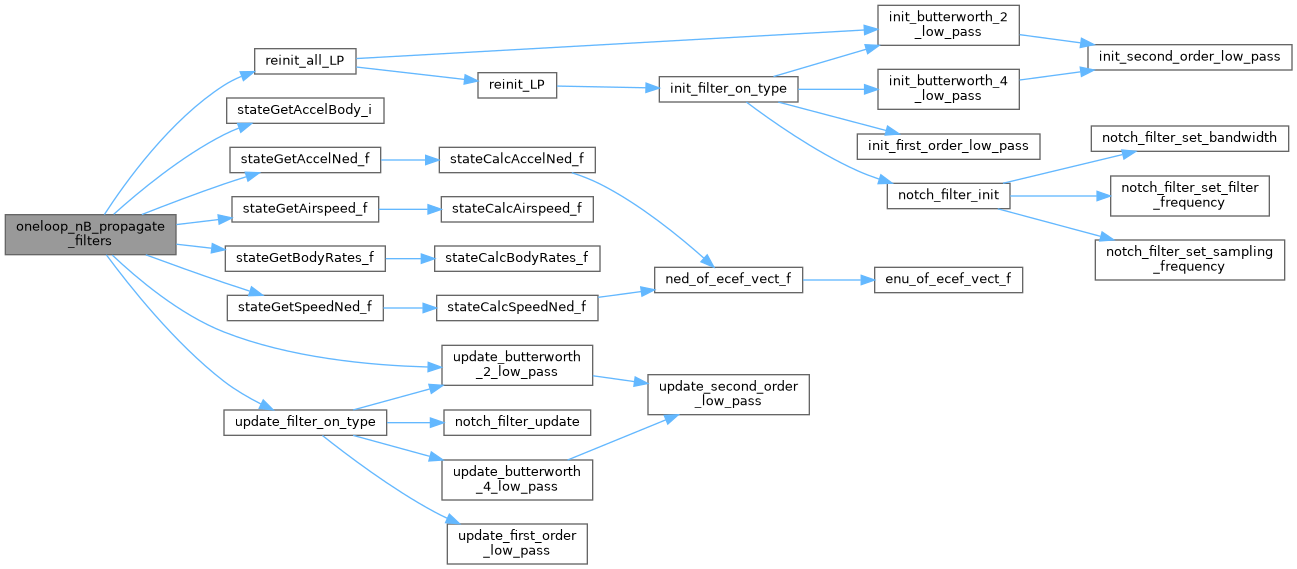
References ACCEL_FLOAT_OF_BFP, accely_filt, airspeed_filt, LP, FloatRates::p, FloatRates::q, FloatRates::r, reinit_all_LP(), stateGetAccelBody_i(), stateGetAccelNed_f(), stateGetAirspeed_f(), stateGetBodyRates_f(), stateGetSpeedNed_f(), update_butterworth_2_low_pass(), update_filter_on_type(), NedCoor_f::x, NedCoor_f::y, and NedCoor_f::z.
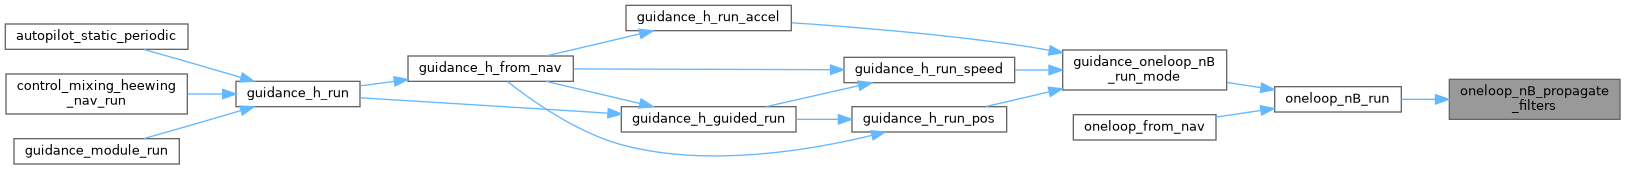
Referenced by oneloop_nB_run().
| void oneloop_nB_RM | ( | bool | half_loop, |
| struct FloatVect3 | PSA_des, | ||
| bool | in_flight_oneloop ) |
Function to generate the reference signals for the oneloop controller.
| half_loop | In half-loop mode the controller is used for stabilization only |
| PSA_des | Desired position/speed/acceleration |
Definition at line 2371 of file oneloop_nB.c.
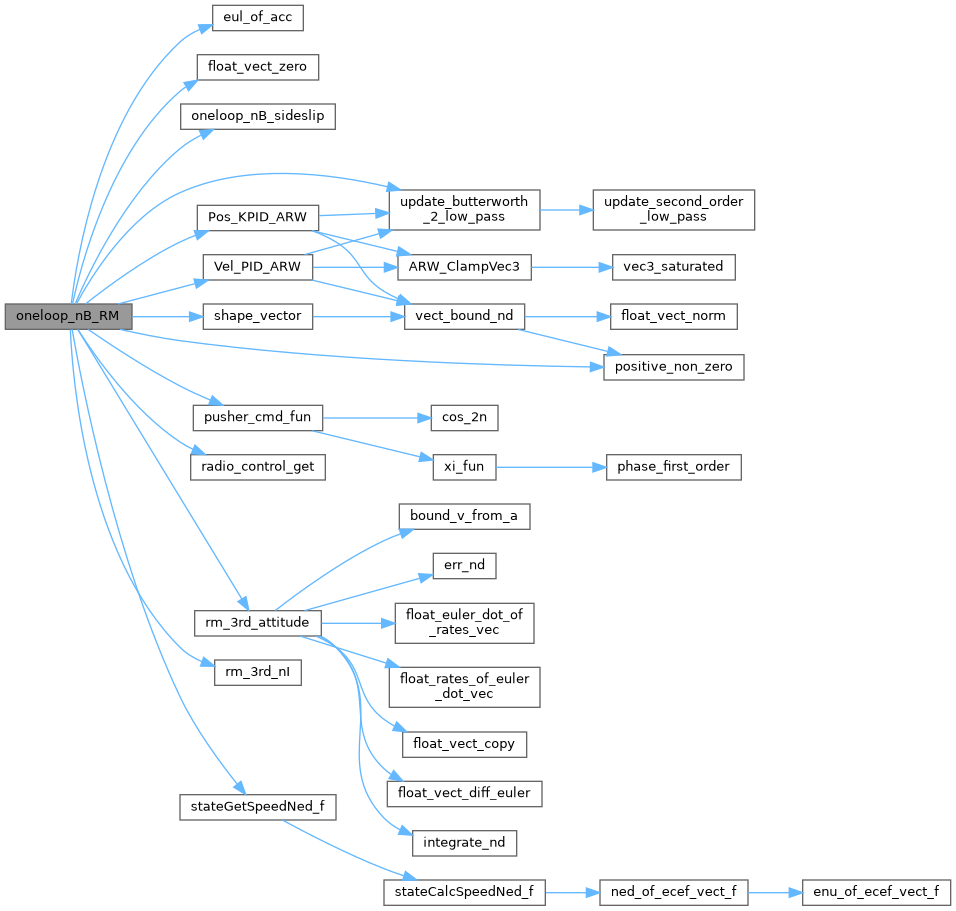
References a_thrust, ANDI_NUM_ACT, commands, CTRL_ANDI, ctrl_effort_model, CTRL_INDI, CTRL_NB_ANDI, CTRL_NB_INDI, ctrl_off, dt_1l, EFF_MAT_G, eul_of_acc(), eulers_zxy, eulers_zxy_des, fault_pitch_motors, fault_roll_motors, float_vect_zero(), heading_manual, IDX_aD, k_att_rm, k_D, k_I, k_K, k_P, k_pos_e, max_phi, MAX_PPRZ, max_pusher_cmd, max_r, max_theta, nav, nav_target, nu, oneloop_nB, oneloop_nB_sideslip(), oneloop_nB_Z_hold, pid_a_max, pid_v_max_manual, pid_v_max_nav, POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, Pos_KPID_ARW(), positive_non_zero(), psi_des_deg, psi_des_rad, psi_vec, push_PID_vel, push_PID_vel_d, pusher_cmd_fun(), radio_body_ctrl, radio_control_get(), RADIO_PITCH, RADIO_ROLL, RADIO_THROTTLE, RADIO_YAW, ratio_u_un, ratio_vn_v, rm_3rd_attitude(), rm_3rd_nI(), RW, shape_vector(), SPIN_MAN_IDLE, spin_man_state, SpinQuad, sta_bounds, stateGetSpeedNed_f(), temp_acc_des, update_butterworth_2_low_pass(), use_push_PID, use_push_Position, vel_ctrl_in_manual, Vel_PID_ARW(), FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, yaw_stick_in_auto, and FloatVect3::z.
Referenced by oneloop_nB_run().
| void oneloop_nB_run | ( | bool | in_flight, |
| bool | half_loop, | ||
| struct FloatVect3 | PSA_des ) |
Main function that runs the controller and performs control allocation.
| half_loop | In half-loop mode the controller is used for stabilization only |
| in_flight | The drone is in flight |
| PSA_des | Desired position/speed/acceleration |
Definition at line 2649 of file oneloop_nB.c.
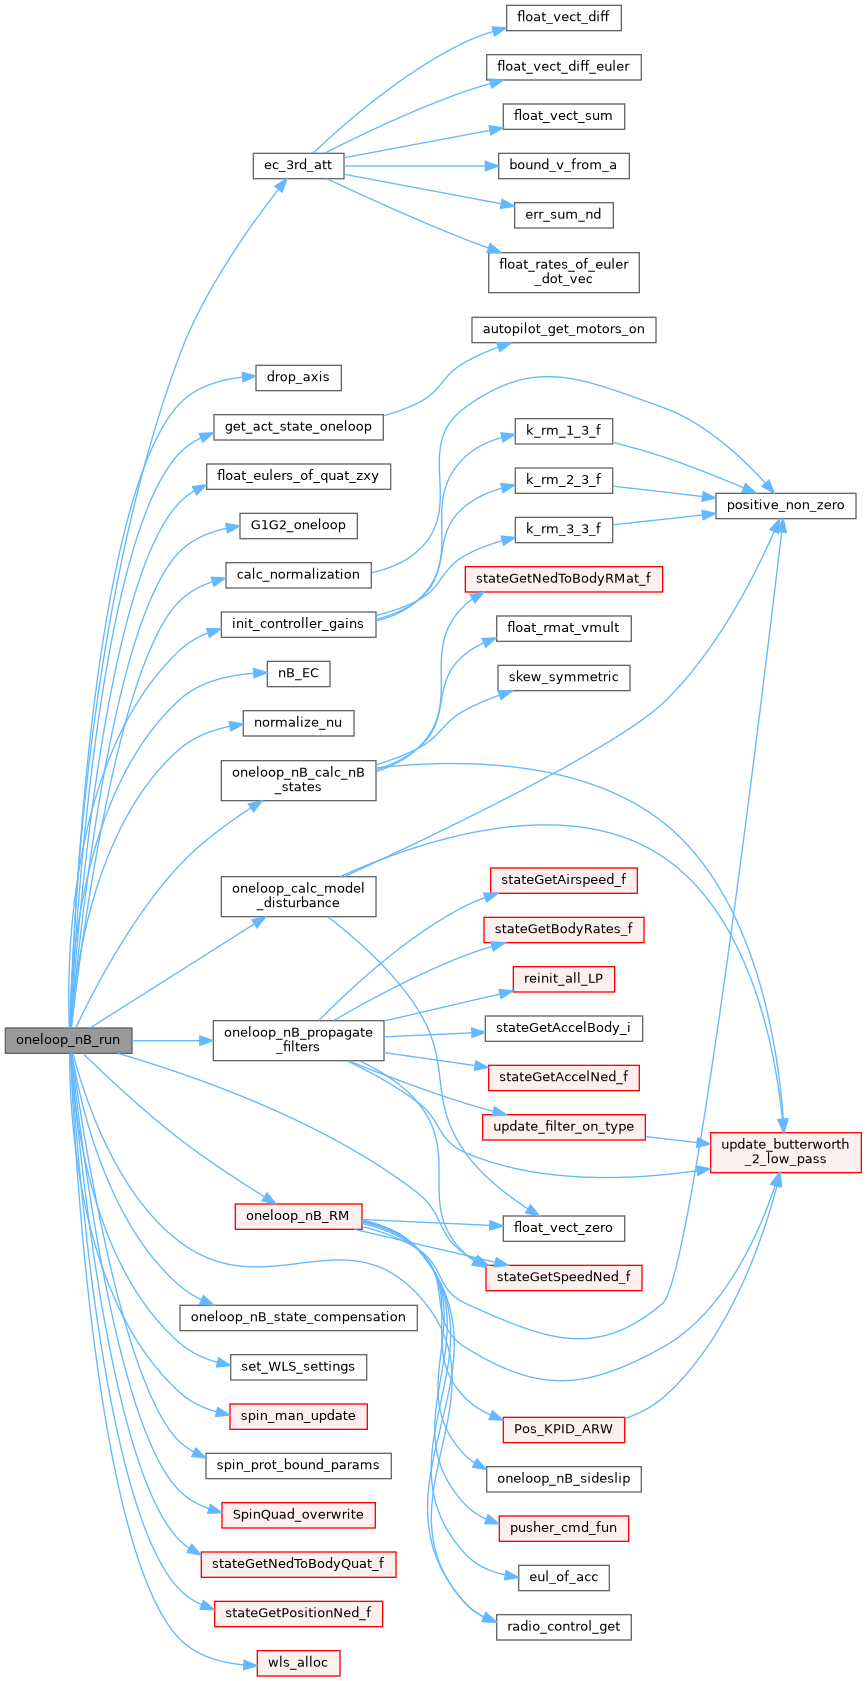
References act_dyn_ctrl, act_max, act_min, actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, andi_u, andi_u_n, auto_fault_cmd, autopilot, bwls_1l, calc_normalization(), COMMAND_PITCH, COMMAND_ROLL, commands, CTRL_ANDI, ctrl_effort_model, CTRL_INDI, CTRL_NB_ANDI, CTRL_NB_INDI, delta_fault, drop_axis(), ec_3rd_att(), eulers_zxy, eulers_zxy_des, fault_pitch_motors, fault_roll_motors, float_eulers_of_quat_zxy(), G1G2_oneloop(), g2_ff, G2_RW, get_act_state_oneloop(), heading_manual, IDX_aD, IDX_ap, IDX_aq, IDX_ar, init_controller_gains(), k_att_e, LP, max_fault_mot, max_phi, MAX_PPRZ, max_theta, nB_2d_filt, nB_3d_state_filt, nB_EC(), nB_jerk_des, normalize_nu(), nu, num_thrusters_oneloop, oneloop_calc_model_disturbance(), oneloop_nB, oneloop_nB_calc_nB_states(), ONELOOP_NB_DEBUG_MODE, oneloop_nB_propagate_filters(), oneloop_nB_RM(), oneloop_nB_state_compensation(), psi_des_deg, psi_des_rad, radio_control_get(), RADIO_THROTTLE, ratio_u_un, safety_killer_cutoff, safety_killer_trigger, set_WLS_settings(), spin_man_alpha, SPIN_MAN_DOWN_SLOW, spin_man_mot, spin_man_state, spin_man_trim_rate, spin_man_u_hold, spin_man_u_last, spin_man_update(), spin_prot_bound_params(), spin_prot_max_cmd, spin_prot_max_rate, spin_prot_ratio, spin_prot_start_rate, spin_trim, spin_trim_bleed_rate, spin_trim_on, spin_trim_rate, spin_trim_release_rate, SpinQuad_overwrite(), sta_bounds, stabilization, state_compensation_on, stateGetNedToBodyQuat_f(), stateGetPositionNed_f(), stateGetSpeedNed_f(), TestMotorIDX, u_filt, use_safety_killer, wls_alloc(), WLS_one_p, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
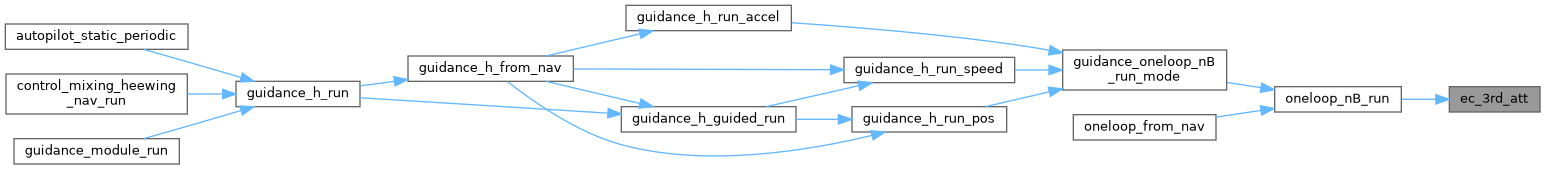
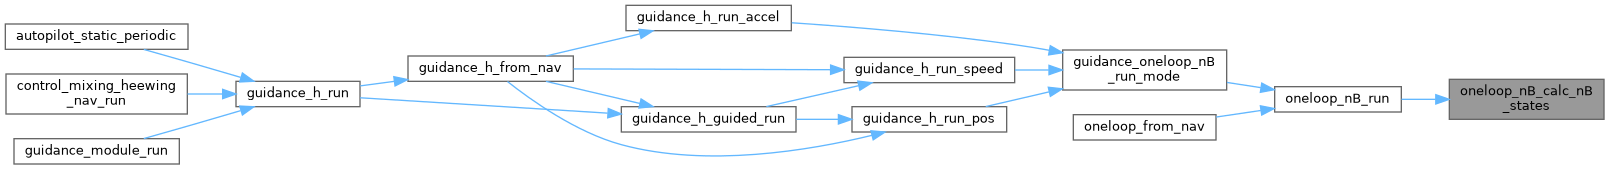
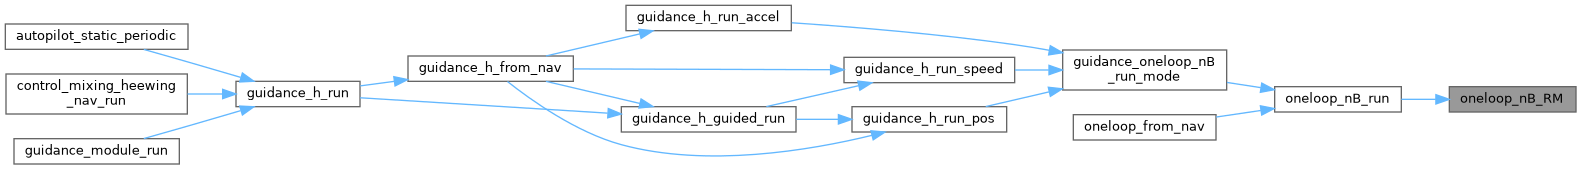
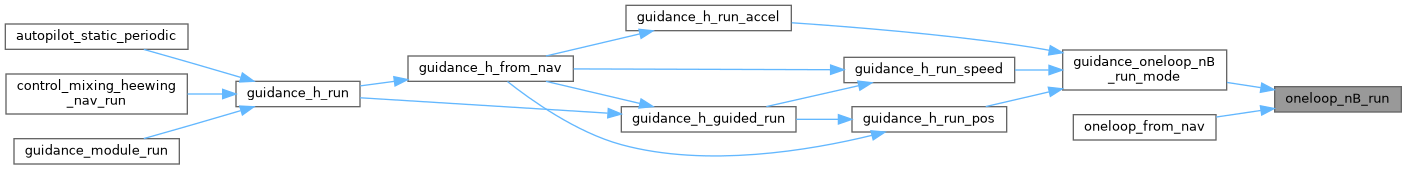
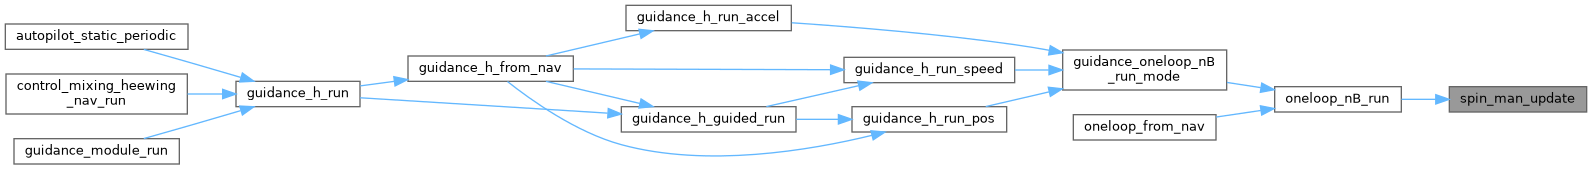
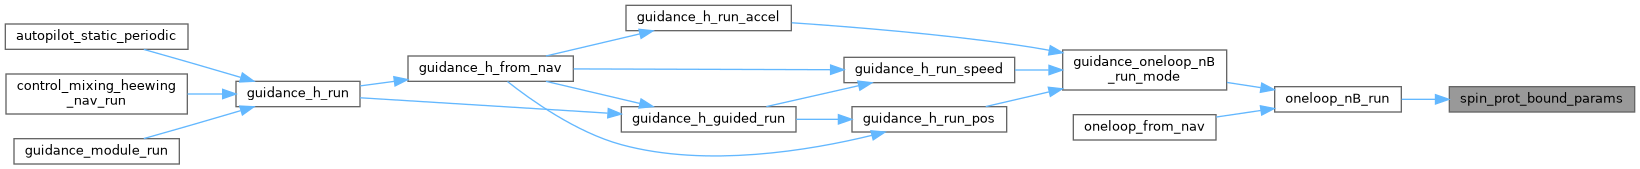
Referenced by guidance_oneloop_nB_run_mode(), and oneloop_from_nav().
| float oneloop_nB_sideslip | ( | void | ) |
Function to calculate corrections for sideslip DEPRECIATED.
Definition at line 3150 of file oneloop_nB.c.
References accely_filt, airspeed_filt, eulers_zxy, fwd_sideslip_gain, g, and max_phi.
Referenced by oneloop_nB_RM().
| void oneloop_nB_state_compensation | ( | bool | state_compensation_on | ) |
Function that performs state compensation for gyroscopic effects.
Definition at line 3309 of file oneloop_nB.c.
References IDX_ap, IDX_aq, nu, oneloop_nB, p, RW, and state_compensation_on.
Referenced by oneloop_nB_run().
| float phase_first_order | ( | float | r, |
| float | w ) |
Definition at line 3808 of file oneloop_nB.c.
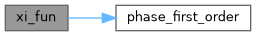
Referenced by xi_fun().
|
static |
Definition at line 1333 of file oneloop_nB.c.
References ARW_ClampVec3(), dt_1l, k_D, k_I, k_K, k_P, KPID_filt, KPID_vel_filt, update_butterworth_2_low_pass(), v_max, and vect_bound_nd().
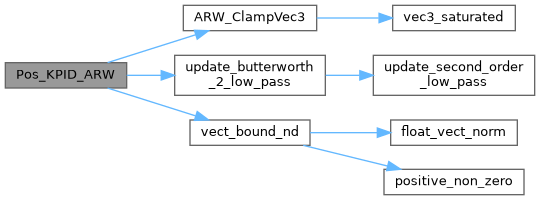
Referenced by oneloop_nB_RM().
|
static |
Function to make sure that inputs are positive non zero vaues.
Definition at line 1109 of file oneloop_nB.c.
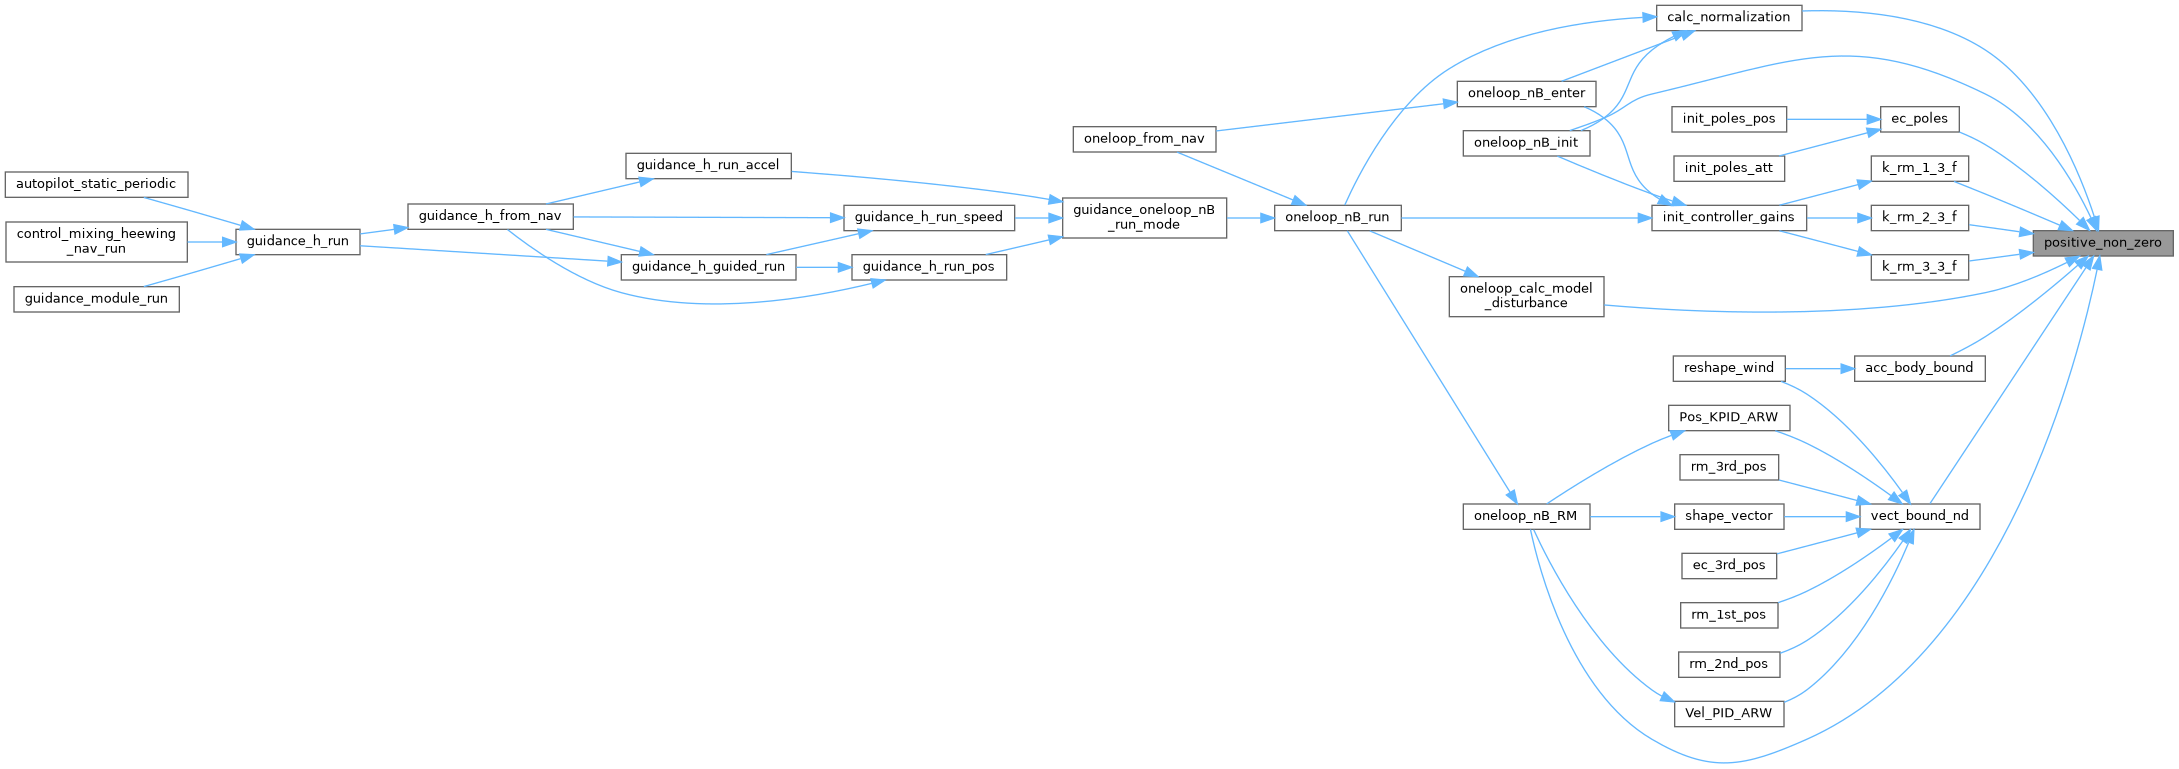
Referenced by acc_body_bound(), calc_normalization(), ec_poles(), k_rm_1_3_f(), k_rm_2_3_f(), k_rm_3_3_f(), oneloop_calc_model_disturbance(), oneloop_nB_init(), oneloop_nB_RM(), and vect_bound_nd().
| PRINT_CONFIG_VAR | ( | ONELOOP_NB_FILT_CUTOFF | ) |
| PRINT_CONFIG_VAR | ( | ONELOOP_NB_FILT_CUTOFF_P | ) |
| PRINT_CONFIG_VAR | ( | ONELOOP_NB_FILT_CUTOFF_Q | ) |
| PRINT_CONFIG_VAR | ( | ONELOOP_NB_FILT_CUTOFF_R | ) |
References ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, ANDI_NUM_VIRTUAL_ACT, ANDI_OUTPUTS, PRINT_CONFIG_MSG(), and PRINT_CONFIG_VAR().
| PRINT_CONFIG_VAR | ( | ONELOOP_NB_MAX_THETA | ) |
References max_bank, PRINT_CONFIG_MSG(), and PRINT_CONFIG_VAR().
| float pusher_cmd_fun | ( | float | aN_des, |
| float | aE_des, | ||
| float | r, | ||
| float | psi, | ||
| float | w, | ||
| int | n ) |
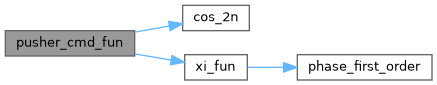
Definition at line 3823 of file oneloop_nB.c.
References cos_2n(), xi, and xi_fun().
Referenced by oneloop_nB_RM().
|
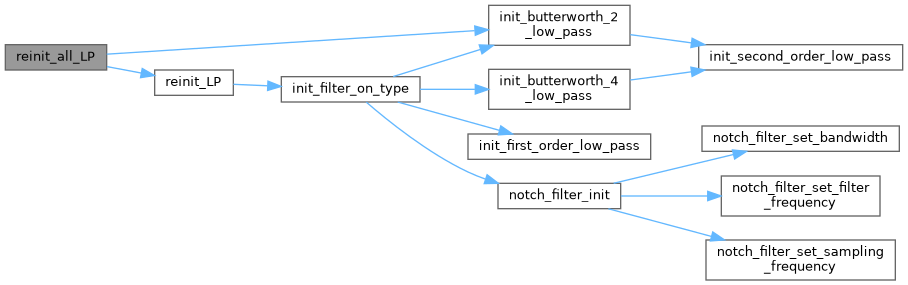
inlinestatic |
Reinitialize all the Low Pass Filters.
Definition at line 2126 of file oneloop_nB.c.
References ANDI_NUM_ACT_TOT, init_butterworth_2_low_pass(), LP, nB_2d_filt, nB_3d_state_filt, nB_filt, oneloop_nB_filt_cutoff, reinit_LP(), state_term, and u_filt.
Referenced by oneloop_nB_propagate_filters().
| void reinit_controller | ( | void | ) |
Re-Init function of controller variables.
Definition at line 2270 of file oneloop_nB.c.
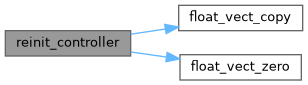
References eulers_zxy_des, float_vect_copy(), float_vect_zero(), and oneloop_nB.
Referenced by oneloop_nB_enter().
|
inlinestatic |
Definition at line 2098 of file oneloop_nB.c.
References init_filter_on_type(), and LP.
Referenced by reinit_all_LP().
Reinitialize Low Pass filter if new frequency setting or if forced.
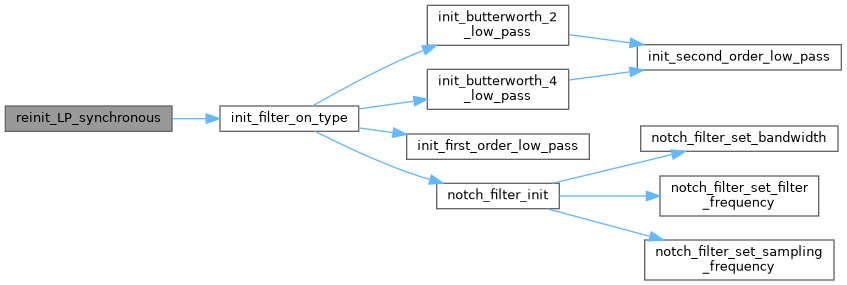
Definition at line 2088 of file oneloop_nB.c.
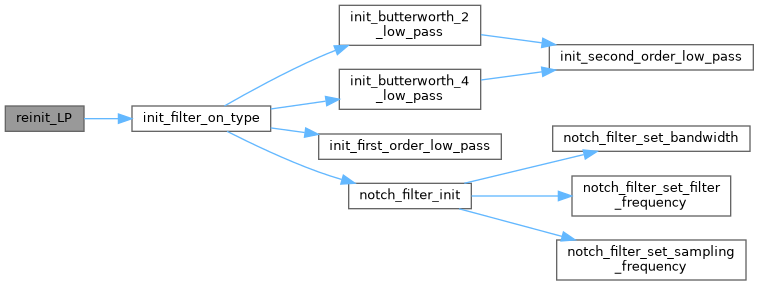
References f, init_filter_on_type(), and LP.
| void reshape_wind | ( | void | ) |
Definition at line 3183 of file oneloop_nB.c.
References acc_body_bound(), airspeed_filt, eulers_zxy, FLOAT_ANGLE_NORMALIZE, FLOAT_VECT2_NORM, force_forward, gi_unbounded_airspeed_sp, k_pos_rm, max_a_nav, max_as, min_as, nav_target, nav_target_new, oneloop_nB, ONELOOP_NB_AIRSPEED_SWITCH_THRESHOLD, VECT2_DIFF, vect_bound_nd(), FloatVect2::x, and FloatVect2::y.
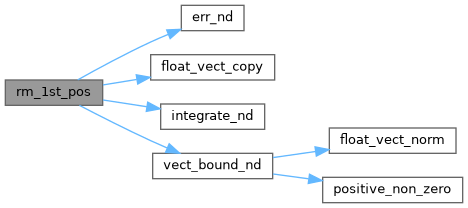
| void rm_1st_pos | ( | float | dt, |
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_2d_des[], | ||
| float | k3_rm[], | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_2d_des | Desired 3rd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
Definition at line 1689 of file oneloop_nB.c.
References err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
| void rm_2nd_pos | ( | float | dt, |
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_d_des[], | ||
| float | k2_rm[], | ||
| float | k3_rm[], | ||
| float | x_2d_bound, | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_d_des | Desired 2nd order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_2d_bound | Bound for the 3rd order reference signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
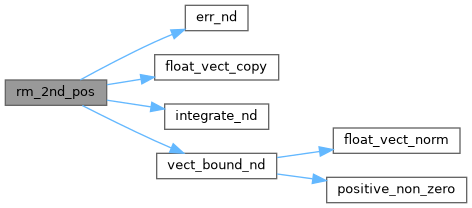
Definition at line 1666 of file oneloop_nB.c.
References err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
| void rm_3rd_attitude | ( | float | dt, |
| float | x_ref[3], | ||
| float | x_d_ref[3], | ||
| float | x_2d_ref[3], | ||
| float | x_3d_ref[3], | ||
| float | x_des[3], | ||
| bool | ow_psi, | ||
| float | psi_overwrite[4], | ||
| float | k1_rm[3], | ||
| float | k2_rm[3], | ||
| float | k3_rm[3], | ||
| struct OneloopStabilizationRef | bounds ) |
Reference Model Definition for 3rd order system with attitude conversion functions.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order (Attitude) |
| x_d_ref | Reference signal 2nd order (Angular Rate) |
| x_2d_ref | Reference signal 3rd order (Angular Acceleration) |
| x_3d_ref | Reference signal 4th order (Angular Jerk) |
| x_des | Desired 1st order signal (Desired Attitude) |
| ow_psi | Overwrite psi (for navigation functions) [bool] |
| psi_overwrite | Overwrite psi (for navigation functions) [values] |
| k1_rm | Reference Model Gain 1st order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| bounds | Bounds for the Reference Model |
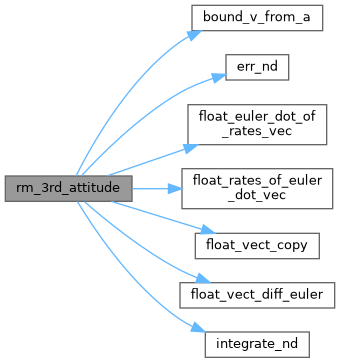
Definition at line 1559 of file oneloop_nB.c.
References OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_3d, OneloopStabilizationRef::att_d, bound_v_from_a(), err_nd(), float_euler_dot_of_rates_vec(), float_rates_of_euler_dot_vec(), float_vect_copy(), float_vect_diff_euler(), and integrate_nd().
Referenced by oneloop_nB_RM().
| void rm_3rd_nI | ( | float | dt, |
| struct FloatVect3 * | x_ref, | ||
| struct FloatVect3 * | x_d_ref, | ||
| struct FloatVect3 * | x_2d_ref, | ||
| struct FloatVect3 * | x_3d_ref, | ||
| const struct FloatVect3 * | x_des, | ||
| const float | k1_rm[3], | ||
| const float | k2_rm[3], | ||
| const float | k3_rm[3] ) |
Definition at line 3681 of file oneloop_nB.c.
References FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by oneloop_nB_RM().
| void rm_3rd_pos | ( | float | dt, |
| float | x_ref[], | ||
| float | x_d_ref[], | ||
| float | x_2d_ref[], | ||
| float | x_3d_ref[], | ||
| float | x_des[], | ||
| float | k1_rm[], | ||
| float | k2_rm[], | ||
| float | k3_rm[], | ||
| float | x_d_bound, | ||
| float | x_2d_bound, | ||
| float | x_3d_bound, | ||
| int | n ) |
Reference Model Definition for 3rd order system specific to positioning with bounds.
| dt | Delta time [s] |
| x_ref | Reference signal 1st order |
| x_d_ref | Reference signal 2nd order |
| x_2d_ref | Reference signal 3rd order |
| x_3d_ref | Reference signal 4th order |
| x_des | Desired 1st order signal |
| k1_rm | Reference Model Gain 1st order signal |
| k2_rm | Reference Model Gain 2nd order signal |
| k3_rm | Reference Model Gain 3rd order signal |
| x_d_bound | Bound for the 2nd order reference signal |
| x_2d_bound | Bound for the 3rd order reference signal |
| x_3d_bound | Bound for the 4th order reference signal |
| n | Number of dimensions |
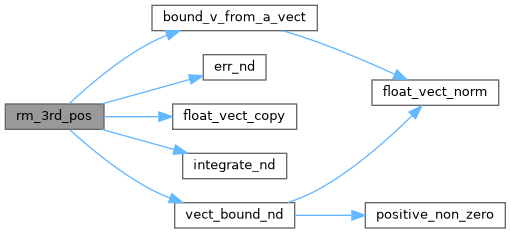
Definition at line 1635 of file oneloop_nB.c.
References bound_v_from_a_vect(), err_nd(), float_vect_copy(), integrate_nd(), and vect_bound_nd().
|
static |
Definition at line 801 of file oneloop_nB.c.
References ANDI_NUM_ACT_TOT, dev, and EFF_MAT_RW.
Referenced by oneloop_nB_init().
|
static |
Definition at line 768 of file oneloop_nB.c.
References ANDI_NUM_ACT, bwls_1l, dev, EFF_MAT_RW, and G2_RW.
Referenced by oneloop_nB_init().
|
static |
Definition at line 785 of file oneloop_nB.c.
References ANDI_NUM_ACT, bwls_1l, dev, and EFF_MAT_RW.
Referenced by oneloop_nB_init().
|
static |
Definition at line 846 of file oneloop_nB.c.
References dev, and oneloop_nB.
Referenced by oneloop_nB_init().
|
static |
Definition at line 900 of file oneloop_nB.c.
References andi_u, debug_vect(), dev, eulers_zxy, fault_pitch_motors, fault_roll_motors, IDX_ar, LP, nu, oneloop_nB, psi_des_rad, radio_control_get(), RADIO_THROTTLE, spin_man_alpha, spin_man_down, spin_man_r_ref, spin_man_state, spin_man_u_hold, spin_man_up, spin_prot_ratio, spin_trim, and SQ_r.
|
static |
Definition at line 808 of file oneloop_nB.c.
References actuator_state_1l, ANDI_NUM_ACT, dev, eulers_zxy_des, and oneloop_nB.
Referenced by oneloop_nB_init().
|
static |
Definition at line 822 of file oneloop_nB.c.
References dev, and oneloop_nB.
Referenced by oneloop_nB_init().
|
static |
Definition at line 764 of file oneloop_nB.c.
References dev, send_wls_u(), and WLS_one_p.
|
static |
Definition at line 760 of file oneloop_nB.c.
References dev, send_wls_v(), and WLS_one_p.
| void set_WLS_settings | ( | void | ) |
Function that sets the WLS settings for oneloop controller.
Definition at line 3348 of file oneloop_nB.c.
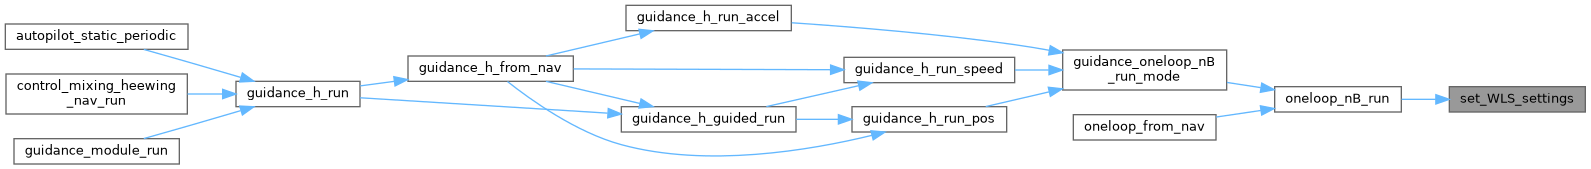
References act_max, act_min, ANDI_NUM_ACT_TOT, CTRL_NB_ANDI, CTRL_NB_INDI, drop_aD, drop_pitch, drop_roll, drop_yaw, fault_ailerons, fault_pitch_motors, fault_roll_motors, IDX_aD, IDX_ap, IDX_aq, IDX_ar, oneloop_nB, ratio_u_un, RW, u_pref, WLS_one_p, Wu_backup, and Wv_backup.
Referenced by oneloop_nB_run().
|
static |
Definition at line 1398 of file oneloop_nB.c.
References vect_bound_nd().
Referenced by oneloop_nB_RM().
| void skew_symmetric | ( | struct FloatRMat * | out, |
| const struct FloatVect3 * | in ) |
Definition at line 3665 of file oneloop_nB.c.
References FloatRMat::m, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Referenced by oneloop_nB_calc_nB_states().
|
static |
Move the yaw rate reference towards target at spin_man_ramp_rate.
Definition at line 1000 of file oneloop_nB.c.
References dt_1l, spin_man_r_ref, spin_man_ramp_rate, step, and target.
Referenced by spin_man_update().
|
static |
Yaw rate tracking is used by the manoeuvre (no fault active).
Definition at line 1007 of file oneloop_nB.c.
References SPIN_MAN_DOWN_BLEND, SPIN_MAN_DOWN_RAMP, spin_man_state, and SPIN_MAN_UP_RAMP.
Referenced by SpinQuad_overwrite().
|
static |
Stop the spin manoeuvre and clear its GCS triggers (fault flags are left as they are).
Definition at line 976 of file oneloop_nB.c.
References spin_man_alpha, spin_man_down, SPIN_MAN_IDLE, spin_man_state, and spin_man_up.
Referenced by oneloop_nB_enter(), and spin_man_update().
|
static |
Select the motors of a pair (pitch: FRONT/BACK, roll: RIGHT/LEFT) for the blend.
Definition at line 984 of file oneloop_nB.c.
References spin_man_mot, and SPIN_MAN_PAIR_ROLL.
Referenced by spin_man_update().
|
static |
Start a bumpless transfer of the selected pair from the average of its last applied commands, so that both motors of the pair are commanded the same during the blend.
Definition at line 992 of file oneloop_nB.c.
References spin_man_alpha, spin_man_mot, spin_man_u_hold, and spin_man_u_last.
Referenced by spin_man_update().
|
static |
Spin transition manoeuvre state machine.
Sets the fault flags and the yaw rate reference. Spin up: UP_RAMP -> (|r| >= release) fault spin_man_pair -> UP_BLEND -> IDLE Spin down: DOWN_SLOW -> (|r| < release - gap) unfault the faulted pair -> DOWN_BLEND -> DOWN_RAMP -> (|r| < done) IDLE
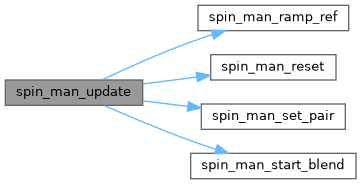
Definition at line 1016 of file oneloop_nB.c.
References dt_1l, fault_pitch_motors, fault_roll_motors, oneloop_nB, spin_man_alpha, spin_man_blend_time, spin_man_dir, spin_man_done_rate, spin_man_down, SPIN_MAN_DOWN_BLEND, SPIN_MAN_DOWN_RAMP, SPIN_MAN_DOWN_SLOW, SPIN_MAN_IDLE, spin_man_pair, SPIN_MAN_PAIR_PITCH, SPIN_MAN_PAIR_ROLL, spin_man_pitch_dir, spin_man_r_ref, spin_man_ramp_ref(), spin_man_reset(), spin_man_set_pair(), spin_man_start_blend(), spin_man_state, spin_man_up, SPIN_MAN_UP_BLEND, SPIN_MAN_UP_RAMP, spin_prot_min_gap, spin_prot_start_rate, and spin_trim_release_rate.
Referenced by oneloop_nB_run().
|
static |
Enforce valid spin protection / spin trim parameters (they can be changed in flight from the settings).
Order enforced: 0 <= release <= start - gap, start <= max - gap. The max rate is the safety limit and is never raised to fix an inconsistent setting, the lower rates are pushed down instead.
Definition at line 959 of file oneloop_nB.c.
References MAX_PPRZ, spin_man_blend_time, spin_man_done_rate, spin_man_pair, SPIN_MAN_PAIR_PITCH, SPIN_MAN_PAIR_ROLL, spin_man_pitch_dir, spin_man_ramp_rate, spin_man_trim_rate, spin_prot_max_cmd, spin_prot_max_rate, spin_prot_min_gap, spin_prot_start_rate, spin_trim_bleed_rate, spin_trim_rate, and spin_trim_release_rate.
Referenced by oneloop_nB_run().
| void SpinQuad_overwrite | ( | float | gain, |
| float | ce_model, | ||
| float * | nu_stab_2 ) |
Definition at line 3749 of file oneloop_nB.c.
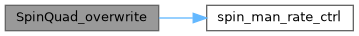
References k_att_e, MAX_PPRZ, oneloop_nB, RADIO_AUX4, radio_control, spin_man_r_ref, spin_man_rate_ctrl(), SpinQuad, SQ_r, and sta_bounds.
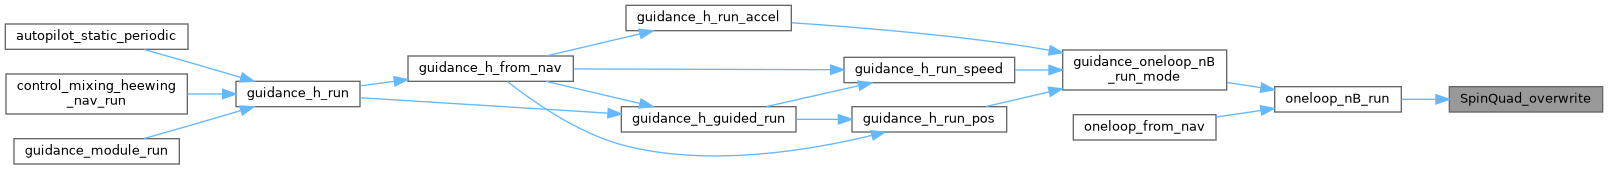
Referenced by oneloop_nB_run().
|
inlinestatic |
Update a filter based on its type.
Definition at line 2039 of file oneloop_nB.c.
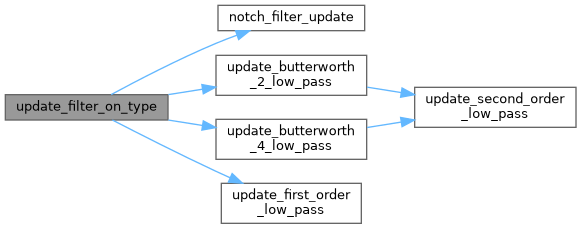
References BUTTERWORTH_2, BUTTERWORTH_4, LP_t::filter_type, LOWPASS_1, LP_t::meas_filt, NOTCH, notch_filter_update(), LP_t::out, update_butterworth_2_low_pass(), update_butterworth_4_low_pass(), and update_first_order_low_pass().
Referenced by oneloop_nB_propagate_filters().
|
inlinestatic |
Definition at line 1229 of file oneloop_nB.c.
Referenced by ARW_ClampVec3().
| void vect_bound_nd | ( | float | vect[], |
| float | bound, | ||
| int | n ) |
Scale a 3D array to within a 3D bound.
Definition at line 1154 of file oneloop_nB.c.
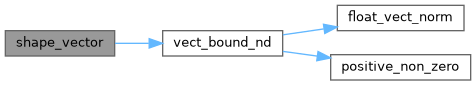
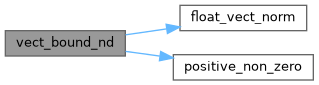
References float_vect_norm(), positive_non_zero(), and scale.
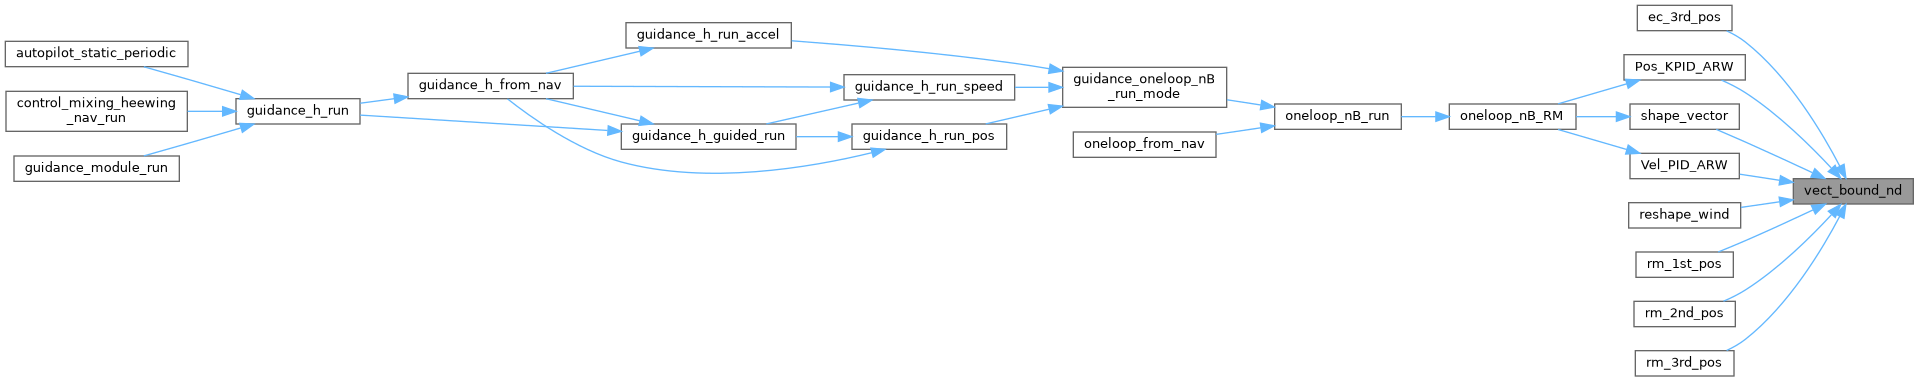
Referenced by ec_3rd_pos(), Pos_KPID_ARW(), reshape_wind(), rm_1st_pos(), rm_2nd_pos(), rm_3rd_pos(), shape_vector(), and Vel_PID_ARW().
|
static |
Definition at line 1275 of file oneloop_nB.c.
References ARW_ClampVec3(), dt_1l, k_D, k_I, k_P, KPID_filt, KPID_vel_filt, update_butterworth_2_low_pass(), v_max, and vect_bound_nd().
Referenced by oneloop_nB_RM().
| float xi_fun | ( | float | r, |
| float | w, | ||
| float | aN_des, | ||
| float | aE_des ) |
Definition at line 3815 of file oneloop_nB.c.
References oneloop_nB, and phase_first_order().
Referenced by pusher_cmd_fun().
|
static |
Definition at line 480 of file oneloop_nB.c.
|
static |
Definition at line 188 of file oneloop_nB.c.
| float act_dyn_ctrl[ANDI_NUM_ACT_TOT] = = {1} |
Definition at line 215 of file oneloop_nB.c.
| float act_dynamics[ANDI_NUM_ACT_TOT] = = {1} |
Definition at line 214 of file oneloop_nB.c.
|
static |
Definition at line 305 of file oneloop_nB.c.
| float act_max[ANDI_NUM_ACT_TOT] = = {MAX_PPRZ} |
Definition at line 221 of file oneloop_nB.c.
| float act_max_norm[ANDI_NUM_ACT_TOT] = = {1.0} |
Definition at line 233 of file oneloop_nB.c.
| float act_min[ANDI_NUM_ACT_TOT] = = {0.0} |
Definition at line 227 of file oneloop_nB.c.
| float act_min_norm[ANDI_NUM_ACT_TOT] = = {0.0} |
Definition at line 239 of file oneloop_nB.c.
| bool actuator_is_servo[ANDI_NUM_ACT_TOT] = {0} |
Definition at line 206 of file oneloop_nB.c.
| float actuator_state_1l[ANDI_NUM_ACT_TOT] |
Definition at line 306 of file oneloop_nB.c.
|
static |
Definition at line 189 of file oneloop_nB.c.
| float andi_du[ANDI_NUM_ACT_TOT] |
Definition at line 301 of file oneloop_nB.c.
| float andi_u[ANDI_NUM_ACT_TOT] |
Definition at line 300 of file oneloop_nB.c.
|
static |
Definition at line 302 of file oneloop_nB.c.
| bool auto_fault_cmd = false |
Definition at line 514 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| float* bwls_1l[ANDI_OUTPUTS] |
Definition at line 484 of file oneloop_nB.c.
| float ctrl_effort_model[ANDI_OUTPUTS] |
Definition at line 488 of file oneloop_nB.c.
Referenced by drop_axis(), oneloop_calc_model_disturbance(), oneloop_nB_RM(), and oneloop_nB_run().
| bool ctrl_off = false |
Definition at line 482 of file oneloop_nB.c.
| float debug_state[3] |
Definition at line 519 of file oneloop_nB.c.
Referenced by oneloop_nB_calc_nB_states().
| float delta_fault = 1000.0 |
Definition at line 524 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| bool drop_aD = false |
Definition at line 505 of file oneloop_nB.c.
| bool drop_pitch = false |
Definition at line 504 of file oneloop_nB.c.
| bool drop_roll = false |
Definition at line 503 of file oneloop_nB.c.
| bool drop_yaw = false |
Definition at line 502 of file oneloop_nB.c.
|
static |
Definition at line 115 of file oneloop_nB.c.
| float ec_headroom = 1.5 |
Definition at line 433 of file oneloop_nB.c.
| float ec_k3 = ONELOOP_NB_EC_K3 |
Definition at line 622 of file oneloop_nB.c.
Referenced by init_controller_gains().
| float EFF_MAT_G[ANDI_OUTPUTS][ANDI_NUM_ACT_TOT] |
Definition at line 485 of file oneloop_nB.c.
| struct FloatEulers eulers_zxy |
Definition at line 388 of file oneloop_nB.c.
| struct FloatEulers eulers_zxy_des |
Definition at line 387 of file oneloop_nB.c.
| bool fault_ailerons = ONELOOP_NB_FAULT_AILERONS |
Definition at line 501 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), and set_WLS_settings().
| bool fault_pitch_motors = false |
Definition at line 496 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), set_WLS_settings(), and spin_man_update().
| bool fault_roll_motors = false |
Definition at line 497 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), set_WLS_settings(), and spin_man_update().
| float fwd_sideslip_gain = 0.2 |
Definition at line 399 of file oneloop_nB.c.
|
static |
Definition at line 116 of file oneloop_nB.c.
|
static |
Definition at line 481 of file oneloop_nB.c.
| float gi_unbounded_airspeed_sp = 0.0 |
Definition at line 436 of file oneloop_nB.c.
| bool heading_manual = false |
Definition at line 333 of file oneloop_nB.c.
| float k1_NE_tune = 0.6 |
Definition at line 697 of file oneloop_nB.c.
| float k2_NE_tune = 1.85 |
Definition at line 698 of file oneloop_nB.c.
| struct Gains3rdOrder k_att_e |
Definition at line 690 of file oneloop_nB.c.
| struct Gains3rdOrder k_att_e_indi |
Definition at line 695 of file oneloop_nB.c.
| struct Gains3rdOrder k_att_rm |
Definition at line 691 of file oneloop_nB.c.
| float k_D = 0.2 |
Definition at line 703 of file oneloop_nB.c.
| float k_I = 0.4 |
Definition at line 702 of file oneloop_nB.c.
| float k_K = 0.6 |
Definition at line 700 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), and Pos_KPID_ARW().
| float k_P = 1.8 |
Definition at line 701 of file oneloop_nB.c.
| struct Gains3rdOrder k_pos_e |
Definition at line 692 of file oneloop_nB.c.
| struct Gains3rdOrder k_pos_e_indi |
Definition at line 696 of file oneloop_nB.c.
| struct Gains3rdOrder k_pos_rm |
Definition at line 693 of file oneloop_nB.c.
|
static |
Definition at line 185 of file oneloop_nB.c.
Referenced by init_filter(), Pos_KPID_ARW(), and Vel_PID_ARW().
|
static |
Definition at line 184 of file oneloop_nB.c.
Referenced by init_filter(), Pos_KPID_ARW(), and Vel_PID_ARW().
| struct Oneloop_LP_t LP |
Definition at line 182 of file oneloop_nB.c.
| float m_array[ANDI_NUM_ACT_TOT] |
Definition at line 487 of file oneloop_nB.c.
| float max_a_nav = 4.0 |
Definition at line 407 of file oneloop_nB.c.
| float max_as = 19.0f |
Definition at line 430 of file oneloop_nB.c.
| float max_bank = M_PI_6 |
Definition at line 264 of file oneloop_nB.c.
Referenced by guidance_set_max_bank_angle(), init_controller_gains(), oneloop_andi_read_rc(), oneloop_nB_read_rc(), and PRINT_CONFIG_VAR().
| float max_fault_mot = ONELOOP_NB_MAX_FAULT_MOT |
Definition at line 314 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| float max_j_lin = 500.0 |
Definition at line 413 of file oneloop_nB.c.
| float max_phi = M_PI_6 |
Definition at line 270 of file oneloop_nB.c.
Referenced by eul_of_acc(), guidance_indi_run(), oneloop_andi_sideslip(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_sideslip(), stabilization_attitude_read_rc_setpoint_eulers(), and stabilization_attitude_read_rc_setpoint_eulers_f().
| float max_pusher_cmd = 7500 |
Definition at line 518 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float max_r = RadOfDeg(180.0) |
Definition at line 319 of file oneloop_nB.c.
| float max_theta = M_PI_6 |
Definition at line 276 of file oneloop_nB.c.
Referenced by eul_of_acc(), oneloop_nB_RM(), and oneloop_nB_run().
| float max_v_nav = 5.0 |
Definition at line 419 of file oneloop_nB.c.
| float max_v_nav_v = 1.5 |
Definition at line 425 of file oneloop_nB.c.
| float min_as = 0.0f |
Definition at line 431 of file oneloop_nB.c.
| float n_array[ANDI_OUTPUTS] |
Definition at line 486 of file oneloop_nB.c.
|
static |
Definition at line 434 of file oneloop_nB.c.
|
static |
Definition at line 435 of file oneloop_nB.c.
|
static |
Definition at line 192 of file oneloop_nB.c.
Referenced by init_filter(), oneloop_nB_calc_nB_states(), oneloop_nB_run(), and reinit_all_LP().
|
static |
Definition at line 193 of file oneloop_nB.c.
Referenced by init_filter(), oneloop_nB_calc_nB_states(), oneloop_nB_run(), and reinit_all_LP().
|
static |
Definition at line 191 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), init_filter(), oneloop_nB_calc_nB_states(), and reinit_all_LP().
| float nB_jerk_des[3] |
Definition at line 307 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| float nu[ANDI_OUTPUTS] |
Definition at line 303 of file oneloop_nB.c.
| float nu_n[ANDI_OUTPUTS] |
Definition at line 304 of file oneloop_nB.c.
| float nu_norm_max = 1.0 |
Definition at line 245 of file oneloop_nB.c.
| float num_thrusters_oneloop = 4.0 |
Definition at line 198 of file oneloop_nB.c.
| struct OneloopGeneral oneloop_nB |
Definition at line 114 of file oneloop_nB.c.
Referenced by get_act_state_oneloop(), guidance_oneloop_nB_run_mode(), oneloop_from_nav(), oneloop_nB_calc_nB_states(), oneloop_nB_enter(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_state_compensation(), reinit_controller(), reshape_wind(), send_guidance_oneloop_nB(), send_oneloop_debug(), send_oneloop_nB(), send_oneloop_nB_ctrl(), set_WLS_settings(), spin_man_update(), SpinQuad_overwrite(), and xi_fun().
| float oneloop_nB_filt_cutoff = 2.0 |
Definition at line 130 of file oneloop_nB.c.
Referenced by eff_scheduling_rotwing_init(), init_all_LP(), init_filter(), init_RW_Model(), reinit_all_LP(), and update_attitude().
| float oneloop_nB_filt_cutoff_a = 2.0 |
Definition at line 136 of file oneloop_nB.c.
| float oneloop_nB_filt_cutoff_p = 20.0 |
Definition at line 149 of file oneloop_nB.c.
| float oneloop_nB_filt_cutoff_q = 20.0 |
Definition at line 156 of file oneloop_nB.c.
| float oneloop_nB_filt_cutoff_r = 20.0 |
Definition at line 163 of file oneloop_nB.c.
| float oneloop_nB_filt_cutoff_v = 30.0 |
Definition at line 142 of file oneloop_nB.c.
Referenced by init_filter().
| float oneloop_nB_yaw_dist_limit = 99999.f |
Definition at line 327 of file oneloop_nB.c.
| bool oneloop_nB_Z_hold = false |
Definition at line 510 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| struct PolePlacement p_alt_e |
Definition at line 684 of file oneloop_nB.c.
| struct PolePlacement p_alt_rm |
Definition at line 685 of file oneloop_nB.c.
| struct PolePlacement p_att_e |
Definition at line 677 of file oneloop_nB.c.
| struct PolePlacement p_att_rm |
Definition at line 679 of file oneloop_nB.c.
| struct PolePlacement p_head_e |
Definition at line 687 of file oneloop_nB.c.
| struct PolePlacement p_head_rm |
Definition at line 688 of file oneloop_nB.c.
| struct PolePlacement p_pos_e |
Definition at line 681 of file oneloop_nB.c.
| struct PolePlacement p_pos_rm |
Definition at line 682 of file oneloop_nB.c.
| struct PolePlacement p_roll_e |
Definition at line 678 of file oneloop_nB.c.
| float pid_a_max = ONELOOP_NB_PID_A_MAX |
Definition at line 639 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float pid_v_max_manual = ONELOOP_NB_PID_V_MAX_MANUAL |
Definition at line 640 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float pid_v_max_nav = ONELOOP_NB_PID_V_MAX_NAV |
Definition at line 641 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float psi_des_deg = 0.0 |
Definition at line 390 of file oneloop_nB.c.
| float psi_des_rad = 0.0 |
Definition at line 389 of file oneloop_nB.c.
|
static |
Definition at line 186 of file oneloop_nB.c.
Referenced by init_filter(), and oneloop_nB_RM().
|
static |
Definition at line 187 of file oneloop_nB.c.
Referenced by init_filter(), and oneloop_nB_RM().
| bool radio_body_ctrl = false |
Definition at line 509 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float ratio_u_un[ANDI_NUM_ACT_TOT] |
Definition at line 489 of file oneloop_nB.c.
| float ratio_vn_v[ANDI_OUTPUTS] |
Definition at line 490 of file oneloop_nB.c.
| float safety_killer_cutoff = 7500.0 |
Definition at line 516 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| bool safety_killer_trigger = false |
Definition at line 513 of file oneloop_nB.c.
Referenced by oneloop_nB_enter(), oneloop_nB_init(), and oneloop_nB_run().
| float slow_pole = 22.0 |
Definition at line 672 of file oneloop_nB.c.
Referenced by ec_poles(), init_poles(), init_poles_att(), and init_poles_pos().
|
static |
Definition at line 662 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), send_oneloop_debug(), spin_man_reset(), spin_man_start_blend(), and spin_man_update().
| float spin_man_blend_time = ONELOOP_NB_SPIN_MAN_BLEND_TIME |
Definition at line 656 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
static |
Definition at line 661 of file oneloop_nB.c.
Referenced by spin_man_update().
| float spin_man_done_rate = ONELOOP_NB_SPIN_MAN_DONE_RATE |
Definition at line 658 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
| bool spin_man_down = false |
Definition at line 652 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_reset(), and spin_man_update().
|
static |
Definition at line 663 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), spin_man_set_pair(), and spin_man_start_blend().
| uint8_t spin_man_pair = ONELOOP_NB_SPIN_MAN_PAIR |
Definition at line 653 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
| float spin_man_pitch_dir = ONELOOP_NB_SPIN_MAN_PITCH_DIR |
Definition at line 654 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
| float spin_man_r_ref = 0.0 |
Definition at line 660 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_ramp_ref(), spin_man_update(), and SpinQuad_overwrite().
| float spin_man_ramp_rate = ONELOOP_NB_SPIN_MAN_RAMP_RATE |
Definition at line 655 of file oneloop_nB.c.
Referenced by spin_man_ramp_ref(), and spin_prot_bound_params().
| uint8_t spin_man_state = SPIN_MAN_IDLE |
Definition at line 659 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), spin_man_rate_ctrl(), spin_man_reset(), and spin_man_update().
| float spin_man_trim_rate = ONELOOP_NB_SPIN_MAN_TRIM_RATE |
Definition at line 657 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
static |
Definition at line 664 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), send_oneloop_debug(), and spin_man_start_blend().
|
static |
Definition at line 665 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_man_start_blend().
| bool spin_man_up = false |
Definition at line 651 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_reset(), and spin_man_update().
| float spin_prot_max_cmd = ONELOOP_NB_SPIN_PROT_MAX_CMD |
Definition at line 541 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
| float spin_prot_max_rate = ONELOOP_NB_SPIN_PROT_MAX_RATE |
Definition at line 539 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
| float spin_prot_min_gap = ONELOOP_NB_SPIN_PROT_MIN_GAP |
Definition at line 567 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
| float spin_prot_ratio = 0.0 |
Definition at line 542 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and send_oneloop_debug().
| float spin_prot_start_rate = ONELOOP_NB_SPIN_PROT_START_RATE |
Definition at line 540 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), spin_man_update(), and spin_prot_bound_params().
| float spin_trim = 0.0 |
Definition at line 563 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and send_oneloop_debug().
| float spin_trim_bleed_rate = ONELOOP_NB_SPIN_TRIM_BLEED_RATE |
Definition at line 561 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
| bool spin_trim_on = ONELOOP_NB_SPIN_TRIM_ON |
Definition at line 559 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| float spin_trim_rate = ONELOOP_NB_SPIN_TRIM_RATE |
Definition at line 560 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
| float spin_trim_release_rate = ONELOOP_NB_SPIN_TRIM_RELEASE_RATE |
Definition at line 562 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), spin_man_update(), and spin_prot_bound_params().
| bool SpinQuad = false |
Definition at line 495 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), and SpinQuad_overwrite().
| float SpinQuadRate = 0.0 |
Definition at line 494 of file oneloop_nB.c.
| float SQ_r = 0.0 |
Definition at line 308 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), and SpinQuad_overwrite().
| struct OneloopStabilizationRef sta_bounds |
Definition at line 342 of file oneloop_nB.c.
| bool state_compensation_on = false |
Definition at line 506 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and oneloop_nB_state_compensation().
| float state_term[3] |
Definition at line 520 of file oneloop_nB.c.
Referenced by oneloop_nB_calc_nB_states(), and reinit_all_LP().
| float temp_acc_des[3] |
Definition at line 515 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| float temp_D_error[3] |
Definition at line 705 of file oneloop_nB.c.
| float temp_I_error[3] |
Definition at line 706 of file oneloop_nB.c.
| float temp_P_error[3] |
Definition at line 704 of file oneloop_nB.c.
| int8_t TestMotorIDX = 0 |
Definition at line 113 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| float theta_pref_max = RadOfDeg(20.0) |
Definition at line 280 of file oneloop_nB.c.
|
static |
Definition at line 190 of file oneloop_nB.c.
|
static |
Definition at line 251 of file oneloop_nB.c.
| bool use_push_PID = false |
Definition at line 507 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| bool use_push_Position = false |
Definition at line 508 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| bool use_safety_killer = false |
Definition at line 512 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
| bool vel_ctrl_in_manual = true |
Definition at line 511 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
| struct WLS_t WLS_one_p |
Definition at line 446 of file oneloop_nB.c.
|
static |
Definition at line 471 of file oneloop_nB.c.
| float Wu_quad_motors_fwd = 6.0 |
Definition at line 441 of file oneloop_nB.c.
|
static |
Definition at line 477 of file oneloop_nB.c.
| float xdot_lim_sf = 0.8 |
Definition at line 432 of file oneloop_nB.c.
| float xi = 0.0 |
Definition at line 517 of file oneloop_nB.c.
Referenced by cos_2n(), pusher_cmd_fun(), and RungeKutta().
| bool yaw_stick_in_auto = false |
Definition at line 339 of file oneloop_nB.c.
 1.15.0