|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
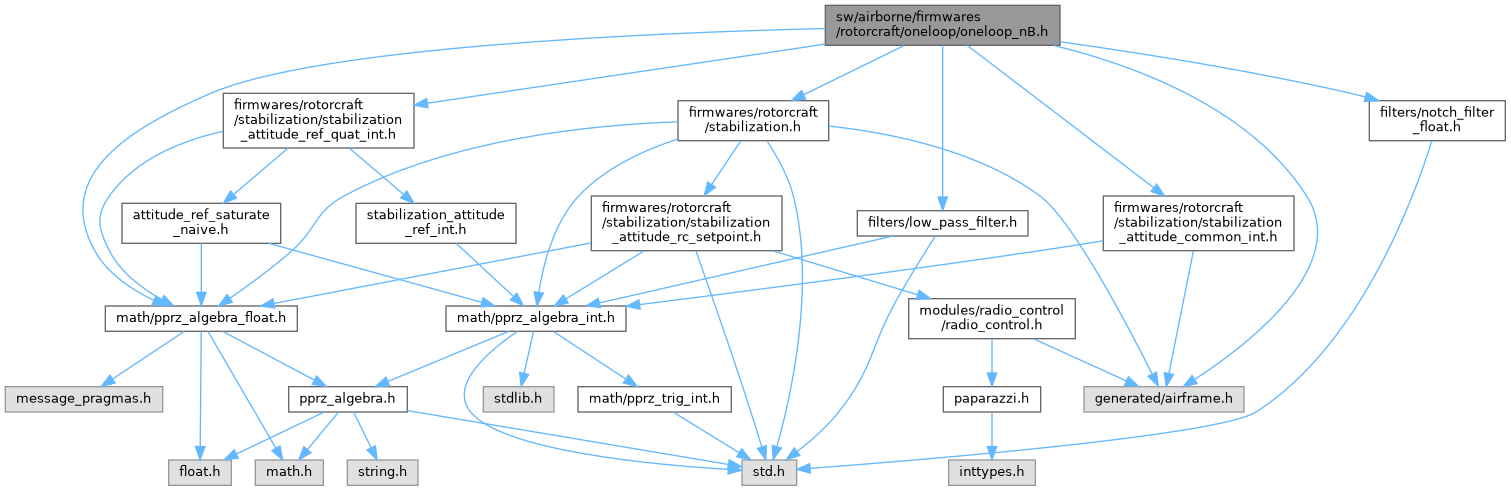
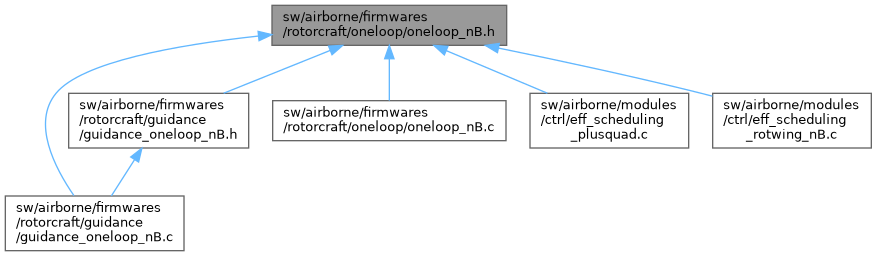
#include "math/pprz_algebra_float.h"#include "firmwares/rotorcraft/stabilization.h"#include "firmwares/rotorcraft/stabilization/stabilization_attitude_common_int.h"#include "firmwares/rotorcraft/stabilization/stabilization_attitude_ref_quat_int.h"#include "generated/airframe.h"#include "filters/low_pass_filter.h"#include "filters/notch_filter_float.h" Include dependency graph for oneloop_nB.h: This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | guidance_indi_hybrid_params |
| struct | OneloopGuidanceRef |
| struct | OneloopGuidanceState |
| struct | OneloopStabilizationRef |
| struct | OneloopStabilizationState |
| struct | OneloopStabilizationnBState |
| struct | OneloopPushnB |
| struct | OneloopGeneral |
| struct | PolePlacement |
| struct | Gains3rdOrder |
| struct | Gains2ndOrder |
| struct | LP_t |
| struct | Oneloop_LP_t |
| struct | Oneloop_DynFilt_t |
| union | LP_t.meas_filt |
Macros | |
| #define | ANDI_NUM_ACT COMMANDS_NB_REAL |
| #define | COMMANDS_NB_VIRTUAL 0 |
| #define | ANDI_NUM_VIRTUAL_ACT COMMANDS_NB_VIRTUAL |
| #define | ANDI_NUM_ACT_TOT (ANDI_NUM_ACT + ANDI_NUM_VIRTUAL_ACT) |
| #define | ANDI_OUTPUTS 6 |
| #define | ANDI_G_SCALING 1000.0f |
| #define | CTRL_ANDI 0 |
| Control types. | |
| #define | CTRL_INDI 1 |
| #define | CTRL_NB_ANDI 2 |
| #define | CTRL_NB_INDI 3 |
Enumerations | |
| enum | FilterType { LOWPASS_1 , BUTTERWORTH_2 , BUTTERWORTH_4 , NOTCH } |
Functions | |
| void | oneloop_nB_init (void) |
| Init function of Oneloop ANDI controller | |
| void | oneloop_nB_enter (bool half_loop_sp, int ctrl_type) |
| Function that resets important values upon engaging Oneloop ANDI. | |
| void | oneloop_nB_set_failsafe_setpoint (void) |
| void | oneloop_nB_run (bool in_flight, bool half_loop, struct FloatVect3 PSA_des) |
| Main function that runs the controller and performs control allocation. | |
| void | oneloop_nB_RM (bool half_loop, struct FloatVect3 PSA_des, bool in_flight_oneloop) |
| Function to generate the reference signals for the oneloop controller. | |
| void | oneloop_nB_read_rc (bool in_flight, bool in_carefree, bool coordinated_turn) |
| void | oneloop_from_nav (bool in_flight) |
| Function that maps navigation inputs to the oneloop controller for the generated autopilot. | |
| void | guidance_set_min_max_airspeed (float min_airspeed, float max_airspeed) |
| void | guidance_set_max_bank_angle (float max_bank) |
| Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid). | |
| void | guidance_set_max_climb_speed (float max_climb_speed_quad, float max_climb_speed_fwd) |
| void | guidance_set_max_descend_speed (float max_descend_speed_quad, float max_descend_speed_fwd) |
Definition in file oneloop_nB.h.
| struct guidance_indi_hybrid_params |
Definition at line 80 of file guidance_indi_hybrid.h.
| Data Fields | ||
|---|---|---|
| float | climb_vspeed_fwd | |
| float | climb_vspeed_quad | |
| float | descend_vspeed_fwd | |
| float | descend_vspeed_quad | |
| float | heading_bank_gain | |
| float | liftd_asq | |
| float | liftd_p50 | |
| float | liftd_p80 | |
| float | max_airspeed | |
| float | min_airspeed | |
| float | pos_gain | |
| float | pos_gainz | |
| float | speed_gain | |
| float | speed_gainz | |
| float | stall_protect_gain | |
| struct OneloopGuidanceRef |
| struct OneloopGuidanceState |
Definition at line 116 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | acc[3] | |
| float | pos[3] | |
| float | vel[3] | |
| struct OneloopStabilizationRef |
| struct OneloopStabilizationState |
Definition at line 127 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | att[3] | |
| float | att_2d[3] | |
| float | att_d[3] | |
| struct OneloopStabilizationnBState |
Definition at line 171 of file oneloop_nB.h.
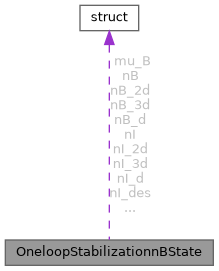
Collaboration diagram for OneloopStabilizationnBState:| Data Fields | ||
|---|---|---|
| struct FloatVect3 | mu_B | |
| struct FloatVect3 | nB | |
| struct FloatVect3 | nB_2d | |
| struct FloatVect3 | nB_3d | |
| struct FloatVect3 | nB_d | |
| struct FloatVect3 | nI | |
| struct FloatVect3 | nI_2d | |
| struct FloatVect3 | nI_3d | |
| struct FloatVect3 | nI_d | |
| struct FloatVect3 | nI_des | |
| struct OneloopPushnB |
| struct OneloopGeneral |
Definition at line 132 of file oneloop_andi.h.
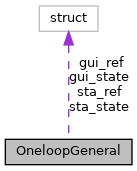
Collaboration diagram for OneloopGeneral:| Data Fields | ||
|---|---|---|
| int | ctrl_type | |
| struct OneloopGuidanceRef | gui_ref | |
| struct OneloopGuidanceState | gui_state | |
| bool | half_loop | |
| struct OneloopPushnB | push_nB | |
| struct OneloopStabilizationnBState | sta_nB_state | |
| struct OneloopStabilizationRef | sta_ref | |
| struct OneloopStabilizationState | sta_state | |
| struct PolePlacement |
Definition at line 143 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | omega_n | |
| float | p3 | |
| float | zeta | |
| struct Gains3rdOrder |
Definition at line 148 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | k1[3] | |
| float | k2[3] | |
| float | k3[3] | |
| struct Gains2ndOrder |
Definition at line 153 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | k2 | |
| float | k3 | |
| struct LP_t |
Definition at line 184 of file oneloop_andi.h.
| Data Fields | ||
|---|---|---|
| float | bandwidth | |
| enum FilterType | filter_type | |
| float | freq | |
| float | freq_set | |
| float | meas | |
| union LP_t | meas_filt | |
| union LP_t.meas_filt | meas_filt | |
| float | meas_prev | |
| float | out | |
| float | tau | |
| struct Oneloop_LP_t |
| struct Oneloop_DynFilt_t |
| union LP_t.meas_filt |
Definition at line 267 of file oneloop_nB.h.
| Data Fields | ||
|---|---|---|
| Butterworth2LowPass | bw2 | |
| Butterworth2LowPass | bw2 | |
| Butterworth4LowPass | bw4 | |
| Butterworth4LowPass | bw4 | |
| struct FirstOrderLowPass | lp1 | |
| struct FirstOrderLowPass | lp1 | |
| struct SecondOrderNotchFilter | notch | |
| struct SecondOrderNotchFilter | notch | |
| #define ANDI_G_SCALING 1000.0f |
Definition at line 57 of file oneloop_nB.h.
| #define ANDI_NUM_ACT COMMANDS_NB_REAL |
Definition at line 40 of file oneloop_nB.h.
| #define ANDI_NUM_ACT_TOT (ANDI_NUM_ACT + ANDI_NUM_VIRTUAL_ACT) |
Definition at line 51 of file oneloop_nB.h.
| #define ANDI_NUM_VIRTUAL_ACT COMMANDS_NB_VIRTUAL |
Definition at line 48 of file oneloop_nB.h.
| #define ANDI_OUTPUTS 6 |
Definition at line 55 of file oneloop_nB.h.
| #define COMMANDS_NB_VIRTUAL 0 |
Definition at line 44 of file oneloop_nB.h.
| #define CTRL_ANDI 0 |
Control types.
Definition at line 60 of file oneloop_nB.h.
| #define CTRL_INDI 1 |
Definition at line 61 of file oneloop_nB.h.
| #define CTRL_NB_ANDI 2 |
Definition at line 62 of file oneloop_nB.h.
| #define CTRL_NB_INDI 3 |
Definition at line 63 of file oneloop_nB.h.
| Enumerator | |
|---|---|
| LOWPASS_1 | |
| BUTTERWORTH_2 | |
| BUTTERWORTH_4 | |
| NOTCH | |
Definition at line 252 of file oneloop_nB.h.
Guidance limit setters called by rotwing_state (also implemented by guidance_indi_hybrid).
The one loop controller uses its own limits, so these are no-ops here.
Definition at line 388 of file guidance_indi_hybrid.c.
References foo, guidance_indi_max_bank, and max_bank.
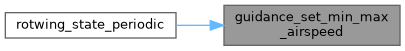
Referenced by rotwing_state_periodic().
Here is the caller graph for this function:Definition at line 392 of file guidance_indi_hybrid.c.
References guidance_indi_hybrid_params::climb_vspeed_fwd, guidance_indi_hybrid_params::climb_vspeed_quad, foo, and gih_params.
Referenced by rotwing_state_periodic().
Here is the caller graph for this function:
|
extern |
Definition at line 397 of file guidance_indi_hybrid.c.
References guidance_indi_hybrid_params::descend_vspeed_fwd, guidance_indi_hybrid_params::descend_vspeed_quad, foo, and gih_params.
Referenced by rotwing_state_periodic().
Here is the caller graph for this function:Definition at line 383 of file guidance_indi_hybrid.c.
References gih_params, max_airspeed, guidance_indi_hybrid_params::max_airspeed, max_as, guidance_indi_hybrid_params::min_airspeed, and min_as.
Referenced by rotwing_state_periodic().
Here is the caller graph for this function:Function that maps navigation inputs to the oneloop controller for the generated autopilot.
Definition at line 2568 of file oneloop_andi.c.
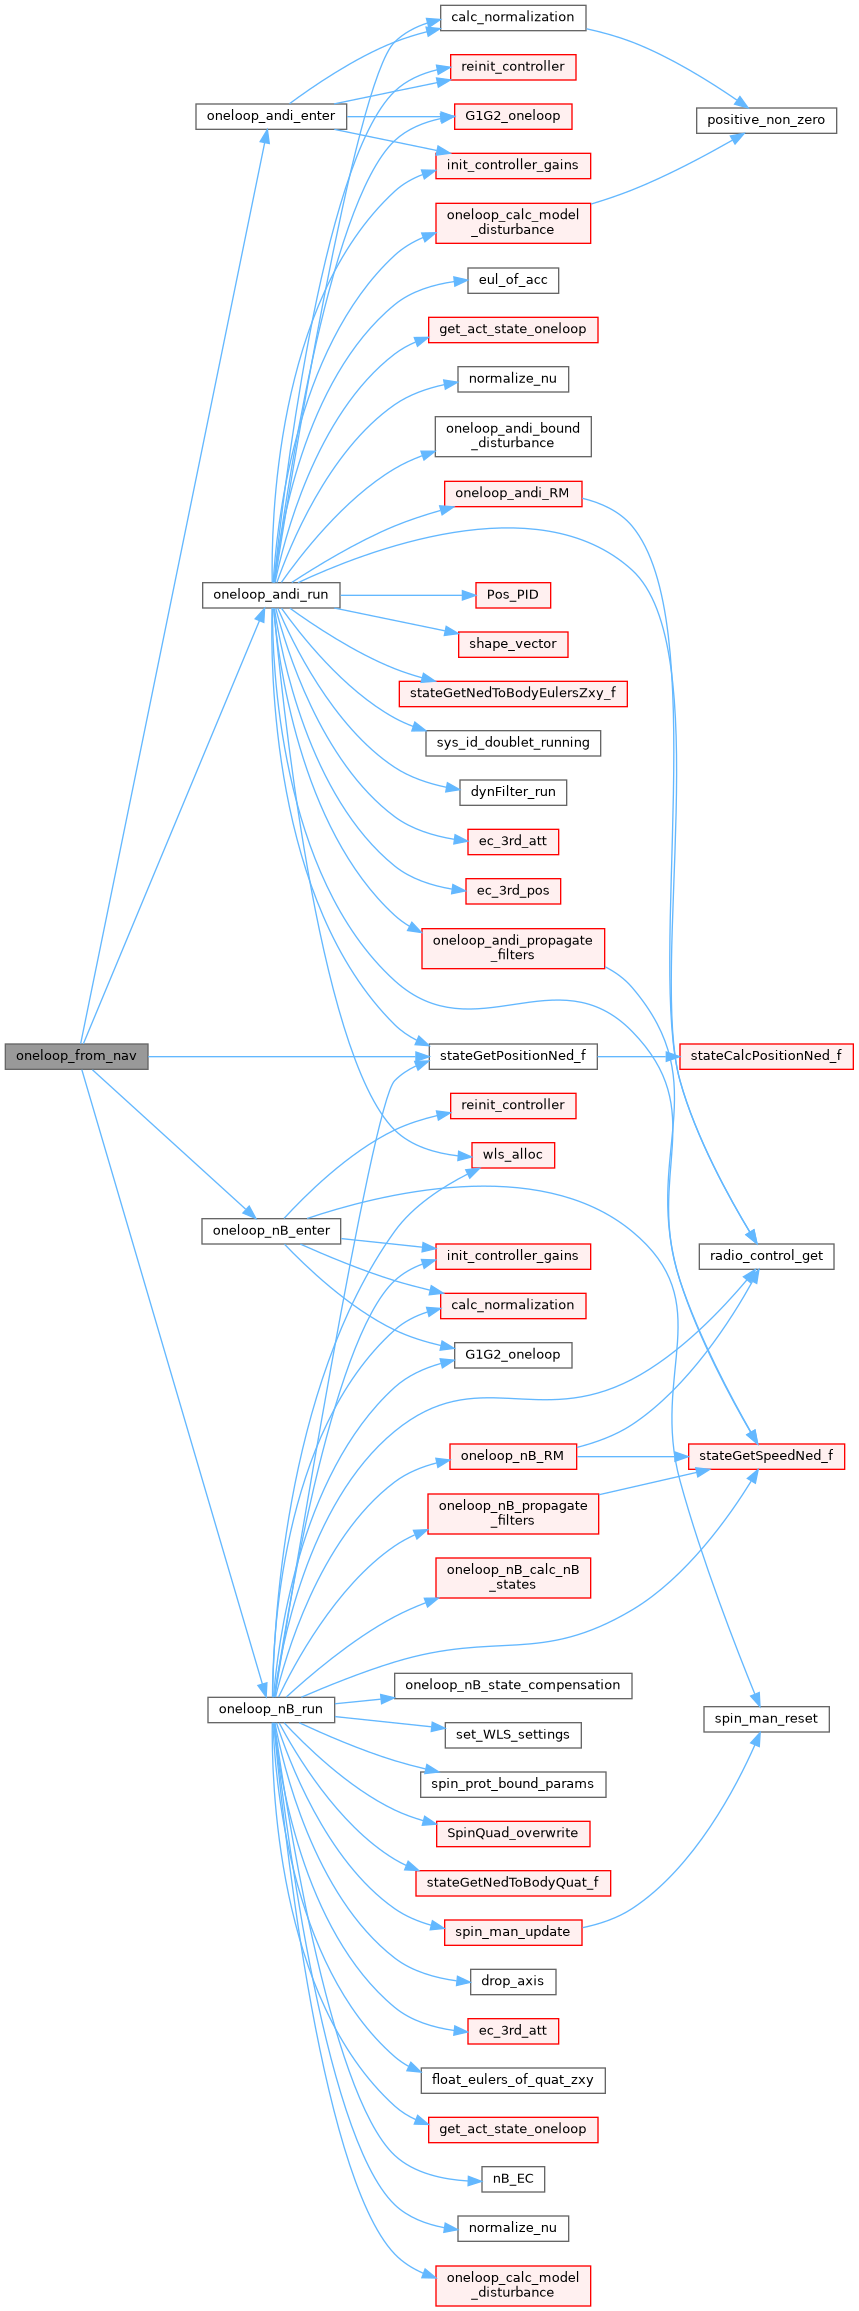
References RotorcraftNavigation::climb, OneloopGeneral::ctrl_type, foo, nav, RotorcraftNavigation::nav_altitude, NAV_SETPOINT_MODE_POS, NAV_SETPOINT_MODE_SPEED, NAV_VERTICAL_MODE_ALT, NAV_VERTICAL_MODE_CLIMB, oneloop_andi, oneloop_andi_enter(), oneloop_andi_run(), oneloop_nB, oneloop_nB_enter(), oneloop_nB_run(), POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, RotorcraftNavigation::setpoint_mode, RotorcraftNavigation::speed, SPEED_BFP_OF_REAL, SPEED_FLOAT_OF_BFP, stateGetPositionNed_f(), RotorcraftNavigation::target, RotorcraftNavigation::vertical_mode, FloatVect3::x, NedCoor_f::x, EnuCoor_f::x, NedCoor_f::y, EnuCoor_f::y, and NedCoor_f::z.
Here is the call graph for this function:Function that resets important values upon engaging Oneloop ANDI.
FIXME: Ideally we should distinguish between the "stabilization" and "guidance" needs because it is unlikely to switch stabilization in flight, and there are multiple modes that use (the same) stabilization. Resetting the controller is not so nice when you are flying.
Definition at line 2352 of file oneloop_nB.c.
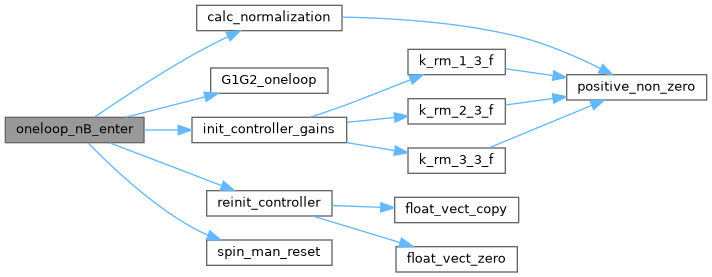
References calc_normalization(), OneloopGeneral::ctrl_type, eulers_zxy, foo, G1G2_oneloop(), OneloopGeneral::half_loop, init_controller_gains(), oneloop_nB, FloatEulers::psi, psi_des_deg, psi_des_rad, reinit_controller(), safety_killer_trigger, and spin_man_reset().
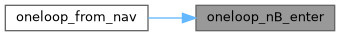
Referenced by oneloop_from_nav().
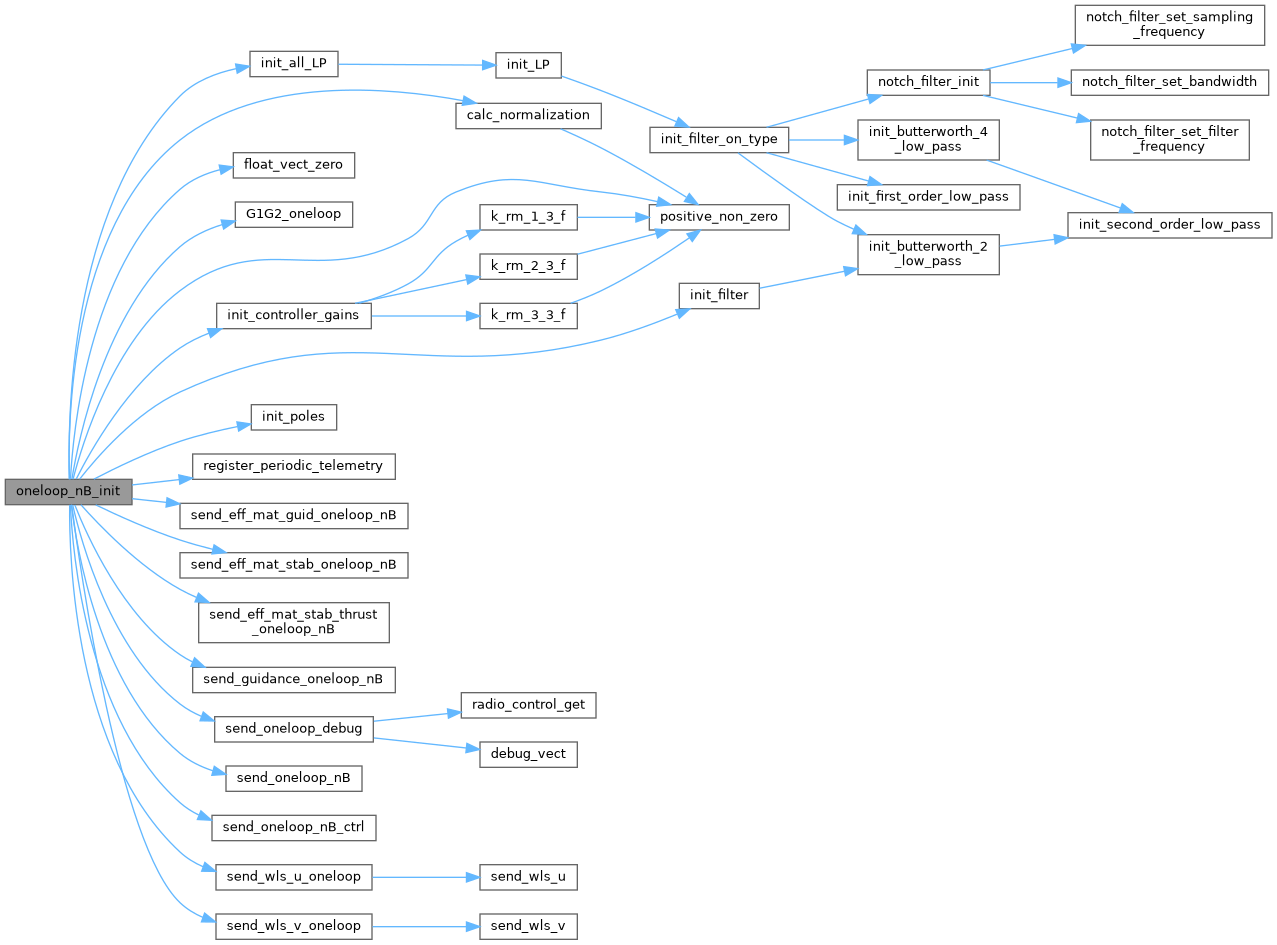
Here is the call graph for this function: Here is the caller graph for this function:Init function of Oneloop ANDI controller
Definition at line 2291 of file oneloop_nB.c.
References act_dynamics, actuator_state_1l, andi_du, ANDI_NUM_ACT_TOT, ANDI_OUTPUTS, andi_u, andi_u_n, OneloopStabilizationRef::att, OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_3d, OneloopStabilizationRef::att_d, calc_normalization(), CTRL_ANDI, OneloopGeneral::ctrl_type, DefaultPeriodic, eulers_zxy_des, float_vect_zero(), foo, G1G2_oneloop(), OneloopGeneral::half_loop, init_all_LP(), init_controller_gains(), init_filter(), init_poles(), nav_target, nav_target_new, OneloopStabilizationnBState::nI, nu, nu_n, oneloop_nB, FloatEulers::phi, positive_non_zero(), FloatEulers::psi, register_periodic_telemetry(), safety_killer_trigger, send_eff_mat_guid_oneloop_nB(), send_eff_mat_stab_oneloop_nB(), send_eff_mat_stab_thrust_oneloop_nB(), send_guidance_oneloop_nB(), send_oneloop_debug(), send_oneloop_nB(), send_oneloop_nB_ctrl(), send_wls_u_oneloop(), send_wls_v_oneloop(), OneloopGeneral::sta_nB_state, OneloopGeneral::sta_ref, FloatEulers::theta, FloatVect3::x, FloatVect3::y, and FloatVect3::z.
Here is the call graph for this function:
|
extern |
Function to generate the reference signals for the oneloop controller.
| half_loop | In half-loop mode the controller is used for stabilization only |
| PSA_des | Desired position/speed/acceleration |
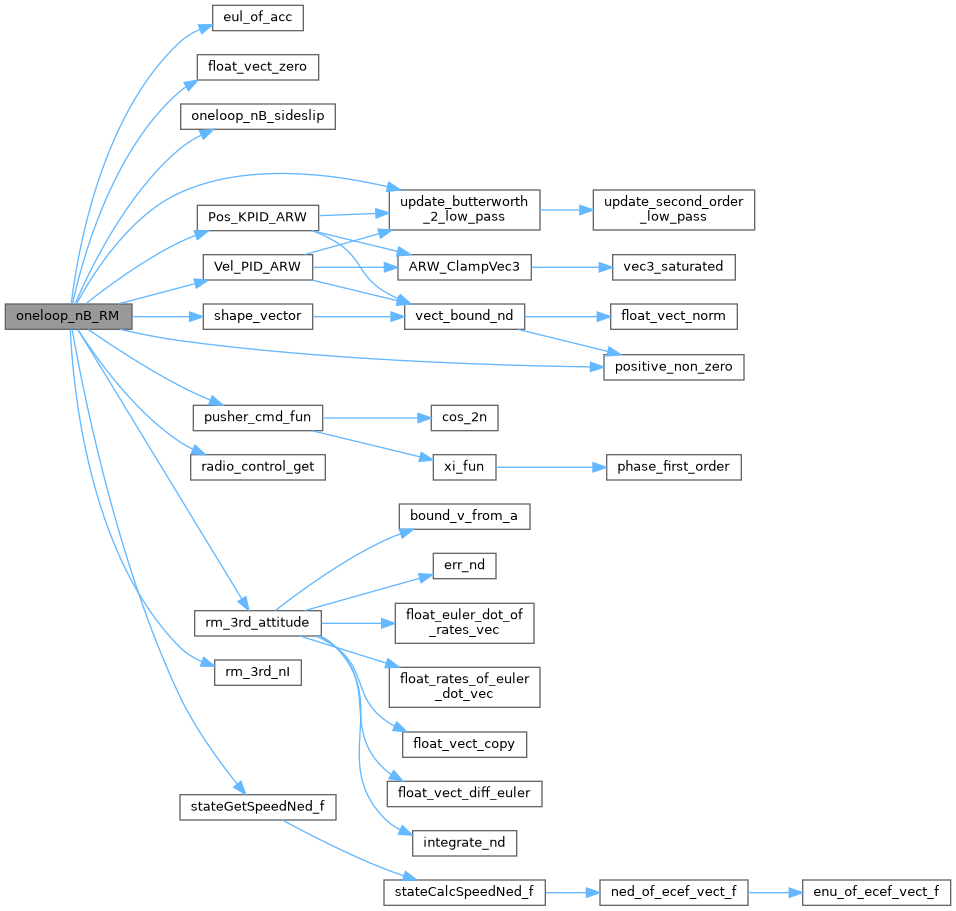
Definition at line 2371 of file oneloop_nB.c.
References a_thrust, OneloopGuidanceState::acc, ANDI_NUM_ACT, OneloopStabilizationRef::att, OneloopStabilizationState::att, OneloopStabilizationRef::att_2d, OneloopStabilizationRef::att_3d, OneloopStabilizationRef::att_d, OneloopStabilizationState::att_d, commands, CTRL_ANDI, ctrl_effort_model, CTRL_INDI, CTRL_NB_ANDI, CTRL_NB_INDI, ctrl_off, OneloopGeneral::ctrl_type, F_M_Body::dFdu, dt_1l, EFF_MAT_G, eul_of_acc(), eulers_zxy, eulers_zxy_des, fault_pitch_motors, fault_roll_motors, float_vect_zero(), foo, OneloopGeneral::gui_state, heading_manual, IDX_aD, Gains3rdOrder::k1, Gains3rdOrder::k2, Gains3rdOrder::k3, k_att_rm, k_D, k_I, k_K, k_P, k_pos_e, RW_Model::m, max_phi, MAX_PPRZ, OneloopPushnB::max_push_cmd, max_pusher_cmd, max_r, max_theta, OneloopPushnB::max_v_d, RW_Model::mP, OneloopPushnB::n, nav, RotorcraftNavigation::nav_altitude, nav_target, OneloopStabilizationnBState::nI, OneloopStabilizationnBState::nI_2d, OneloopStabilizationnBState::nI_3d, OneloopStabilizationnBState::nI_d, OneloopStabilizationnBState::nI_des, nu, SecondOrderLowPass::o, oneloop_nB, oneloop_nB_sideslip(), oneloop_nB_Z_hold, OneloopPushnB::pE, OneloopPushnB::pE_d, FloatEulers::phi, pid_a_max, pid_v_max_manual, pid_v_max_nav, OneloopPushnB::pN, OneloopPushnB::pN_d, OneloopGuidanceState::pos, POS_BFP_OF_REAL, POS_FLOAT_OF_BFP, Pos_KPID_ARW(), positive_non_zero(), FloatEulers::psi, psi_des_deg, psi_des_rad, psi_vec, OneloopPushnB::push_cmd, OneloopGeneral::push_nB, push_PID_vel, push_PID_vel_d, pusher_cmd_fun(), radio_body_ctrl, radio_control_get(), RADIO_PITCH, RADIO_ROLL, RADIO_THROTTLE, RADIO_YAW, ratio_u_un, ratio_vn_v, rm_3rd_attitude(), rm_3rd_nI(), RW, shape_vector(), SPIN_MAN_IDLE, spin_man_state, SpinQuad, sta_bounds, OneloopGeneral::sta_nB_state, OneloopGeneral::sta_ref, OneloopGeneral::sta_state, stateGetSpeedNed_f(), RotorcraftNavigation::target, temp_acc_des, FloatEulers::theta, update_butterworth_2_low_pass(), use_push_PID, use_push_Position, OneloopPushnB::varepsilon, OneloopPushnB::vE, OneloopPushnB::vE_d, OneloopPushnB::vE_d_filt, OneloopPushnB::vE_filt, OneloopGuidanceState::vel, vel_ctrl_in_manual, Vel_PID_ARW(), OneloopPushnB::vN, OneloopPushnB::vN_d, OneloopPushnB::vN_d_filt, OneloopPushnB::vN_filt, FloatVect3::x, NedCoor_f::x, EnuCoor_f::x, FloatVect3::y, NedCoor_f::y, EnuCoor_f::y, yaw_stick_in_auto, and FloatVect3::z.
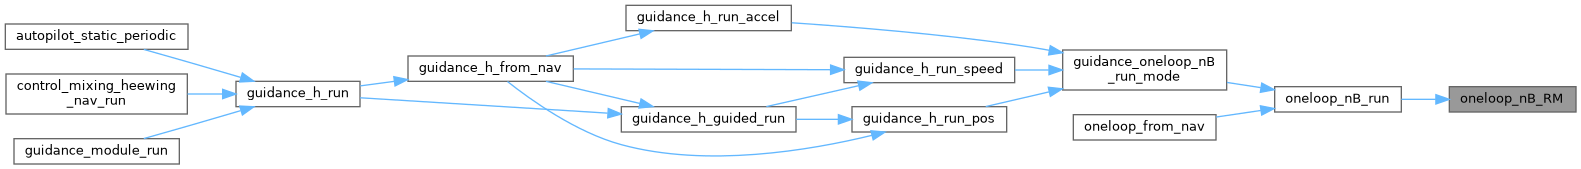
Referenced by oneloop_nB_run().
Here is the call graph for this function: Here is the caller graph for this function:
|
extern |
Main function that runs the controller and performs control allocation.
| half_loop | In half-loop mode the controller is used for stabilization only |
| in_flight | The drone is in flight |
| PSA_des | Desired position/speed/acceleration |
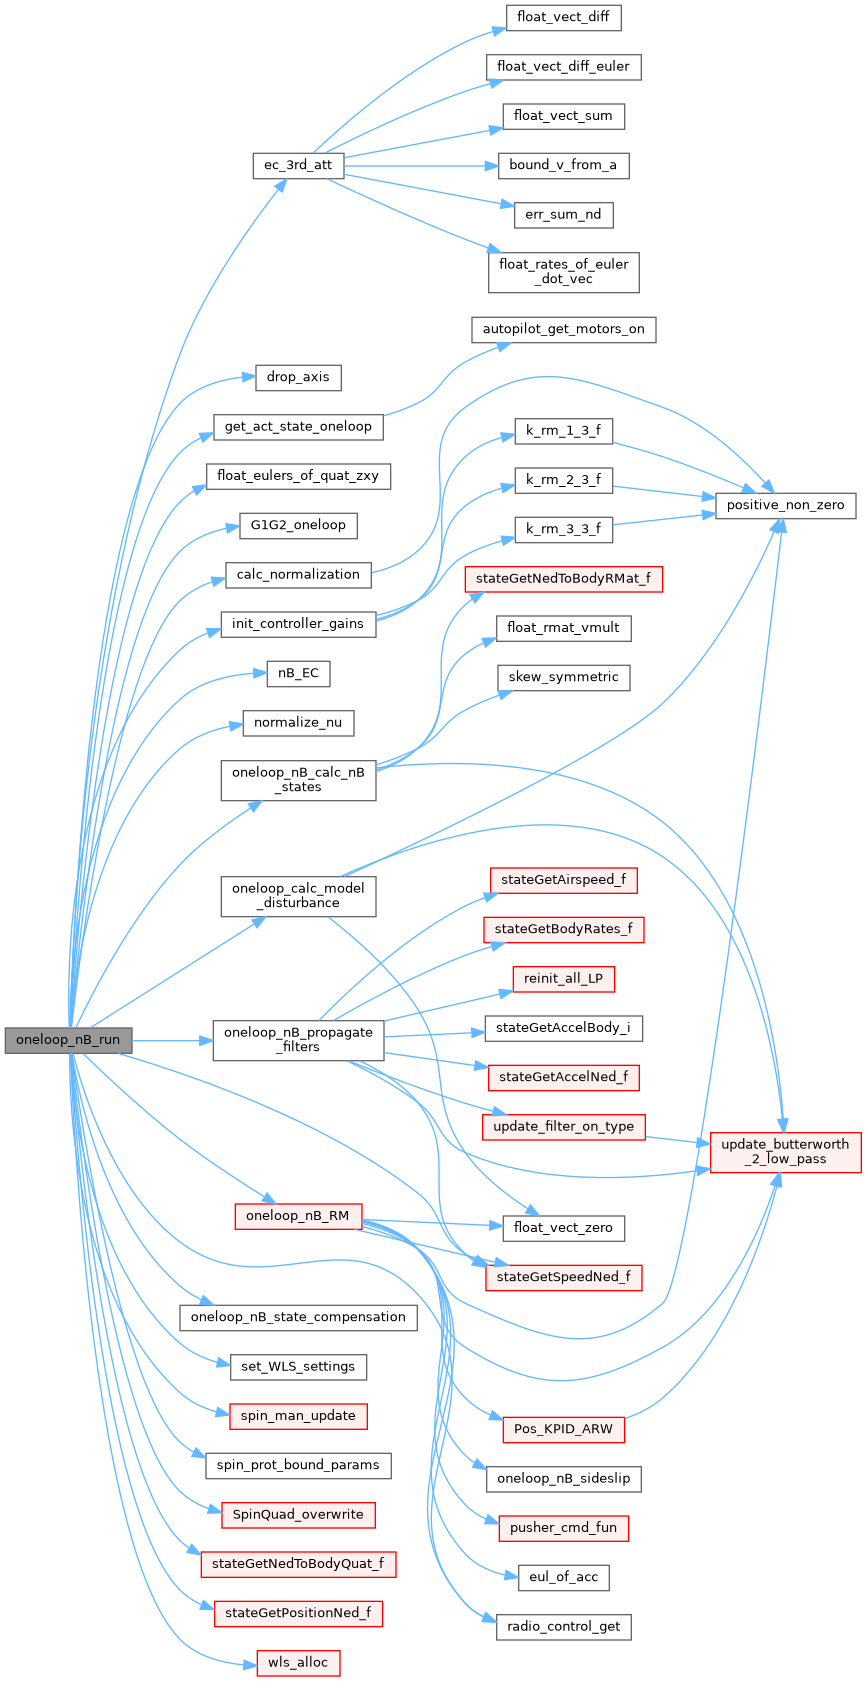
Definition at line 2649 of file oneloop_nB.c.
References OneloopGuidanceState::acc, act_dyn_ctrl, act_max, act_min, actuator_state_1l, ANDI_NUM_ACT, ANDI_NUM_ACT_TOT, andi_u, andi_u_n, OneloopStabilizationRef::att, OneloopStabilizationState::att, OneloopStabilizationRef::att_2d, OneloopStabilizationState::att_2d, OneloopStabilizationRef::att_3d, OneloopStabilizationRef::att_d, OneloopStabilizationState::att_d, auto_fault_cmd, autopilot, Oneloop_LP_t::ax, Oneloop_LP_t::ay, Oneloop_LP_t::az, bwls_1l, calc_normalization(), Stabilization::cmd, COMMAND_PITCH, COMMAND_ROLL, commands, CTRL_ANDI, ctrl_effort_model, CTRL_INDI, CTRL_NB_ANDI, CTRL_NB_INDI, OneloopGeneral::ctrl_type, delta_fault, drop_axis(), ec_3rd_att(), eulers_zxy, eulers_zxy_des, fault_pitch_motors, fault_roll_motors, float_eulers_of_quat_zxy(), foo, G1G2_oneloop(), g2_ff, G2_RW, get_act_state_oneloop(), OneloopGeneral::gui_state, heading_manual, IDX_aD, IDX_ap, IDX_aq, IDX_ar, init_controller_gains(), Gains3rdOrder::k1, Gains3rdOrder::k2, Gains3rdOrder::k3, k_att_e, LP, max_fault_mot, max_phi, MAX_PPRZ, max_theta, OneloopStabilizationnBState::mu_B, OneloopStabilizationnBState::nB, OneloopStabilizationnBState::nB_2d, nB_2d_filt, nB_3d_state_filt, OneloopStabilizationnBState::nB_d, nB_EC(), nB_jerk_des, normalize_nu(), nu, num_thrusters_oneloop, SecondOrderLowPass::o, oneloop_calc_model_disturbance(), oneloop_nB, oneloop_nB_calc_nB_states(), ONELOOP_NB_DEBUG_MODE, oneloop_nB_propagate_filters(), oneloop_nB_RM(), oneloop_nB_state_compensation(), LP_t::out, Oneloop_LP_t::p, Oneloop_LP_t::p_dot, FloatEulers::phi, OneloopGuidanceState::pos, FloatEulers::psi, psi_des_deg, psi_des_rad, Oneloop_LP_t::q, Oneloop_LP_t::q_dot, Oneloop_LP_t::r, Oneloop_LP_t::r_dot, radio_control_get(), RADIO_THROTTLE, ratio_u_un, safety_killer_cutoff, safety_killer_trigger, set_WLS_settings(), spin_man_alpha, SPIN_MAN_DOWN_SLOW, spin_man_mot, spin_man_state, spin_man_trim_rate, spin_man_u_hold, spin_man_u_last, spin_man_update(), spin_prot_bound_params(), spin_prot_max_cmd, spin_prot_max_rate, spin_prot_ratio, spin_prot_start_rate, spin_trim, spin_trim_bleed_rate, spin_trim_on, spin_trim_rate, spin_trim_release_rate, SpinQuad_overwrite(), sta_bounds, OneloopGeneral::sta_nB_state, OneloopGeneral::sta_ref, OneloopGeneral::sta_state, stabilization, state_compensation_on, stateGetNedToBodyQuat_f(), stateGetPositionNed_f(), stateGetSpeedNed_f(), TestMotorIDX, FloatEulers::theta, pprz_autopilot::throttle, WLS_t::u, u_filt, use_safety_killer, OneloopGuidanceState::vel, wls_alloc(), WLS_one_p, FloatVect3::x, NedCoor_f::x, FloatVect3::y, NedCoor_f::y, FloatVect3::z, and NedCoor_f::z.
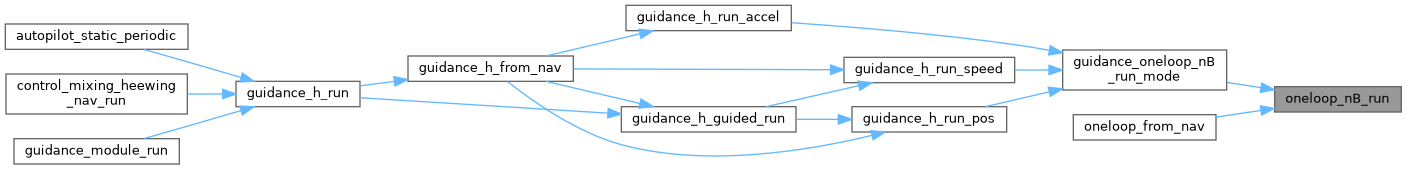
Referenced by guidance_oneloop_nB_run_mode(), and oneloop_from_nav().
Here is the call graph for this function: Here is the caller graph for this function:
|
extern |
|
extern |
Definition at line 290 of file oneloop_andi.c.
Referenced by calc_all_thrust_curve(), calc_G1_G2_RW(), get_act_state_oneloop(), oneloop_andi_init(), oneloop_calc_model_disturbance(), oneloop_nB_init(), oneloop_nB_run(), send_oneloop_andi(), and send_oneloop_nB().
|
extern |
Definition at line 285 of file oneloop_andi.c.
Referenced by oneloop_andi_init(), and oneloop_nB_init().
|
extern |
Definition at line 284 of file oneloop_andi.c.
Referenced by get_act_state_oneloop(), oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_run(), reinit_controller(), and send_oneloop_debug().
|
extern |
Definition at line 514 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 460 of file oneloop_andi.c.
Referenced by G1G2_oneloop(), oneloop_andi_run(), and oneloop_nB_RM().
|
extern |
Definition at line 524 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 475 of file oneloop_andi.c.
Referenced by chirp_call(), drop_axis(), G1G2_oneloop(), oneloop_andi_RM(), oneloop_andi_run(), and set_WLS_settings().
|
extern |
Definition at line 622 of file oneloop_nB.c.
Referenced by init_controller_gains().
|
extern |
Definition at line 362 of file oneloop_andi.c.
Referenced by eul_of_acc(), eul_of_acc(), oneloop_andi_init(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), reinit_controller(), send_oneloop_andi(), and send_oneloop_nB().
|
extern |
Definition at line 501 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), and set_WLS_settings().
|
extern |
Definition at line 496 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), set_WLS_settings(), and spin_man_update().
|
extern |
Definition at line 497 of file oneloop_nB.c.
Referenced by G1G2_oneloop(), oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), set_WLS_settings(), and spin_man_update().
|
extern |
Definition at line 376 of file oneloop_andi.c.
Referenced by oneloop_andi_sideslip(), and oneloop_nB_sideslip().
|
extern |
|
extern |
Definition at line 248 of file guidance_indi_hybrid.c.
Referenced by compute_accel_from_speed_sp(), reshape_wind(), rotwing_state_periodic(), and send_rotating_wing_state().
|
extern |
Definition at line 112 of file guidance_indi_hybrid.c.
Referenced by bound_vz_sp(), compute_accel_from_speed_sp(), guidance_indi_controller(), guidance_indi_get_liftd(), guidance_set_max_climb_speed(), guidance_set_max_descend_speed(), and guidance_set_min_max_airspeed().
|
extern |
Definition at line 309 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_RM(), and oneloop_nB_run().
|
extern |
Definition at line 505 of file oneloop_andi.c.
Referenced by init_controller_gains().
|
extern |
Definition at line 506 of file oneloop_andi.c.
Referenced by init_controller_gains().
|
extern |
Definition at line 498 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_run(), oneloop_calc_model_disturbance(), oneloop_nB_run(), and SpinQuad_overwrite().
|
extern |
Definition at line 499 of file oneloop_andi.c.
Referenced by generate_reference_attitude(), init_controller_gains(), oneloop_andi_RM(), and oneloop_nB_RM().
|
extern |
Definition at line 509 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
|
extern |
|
extern |
|
extern |
Definition at line 510 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
|
extern |
Definition at line 700 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), and Pos_KPID_ARW().
|
extern |
Definition at line 508 of file oneloop_andi.c.
Referenced by oneloop_andi_run(), oneloop_nB_RM(), Pos_KPID_ARW(), Pos_PID(), and Vel_PID_ARW().
|
extern |
Definition at line 500 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_run(), and oneloop_nB_RM().
|
extern |
Definition at line 501 of file oneloop_andi.c.
Referenced by init_controller_gains(), oneloop_andi_RM(), and reshape_wind().
|
extern |
Definition at line 189 of file oneloop_andi.c.
Referenced by init_all_LP(), init_all_LP(), init_LP(), init_LP(), oneloop_andi_propagate_filters(), oneloop_andi_run(), oneloop_nB_calc_nB_states(), oneloop_nB_propagate_filters(), oneloop_nB_run(), reinit_all_LP(), reinit_all_LP(), reinit_LP(), reinit_LP(), reinit_LP_synchronous(), reinit_LP_synchronous(), and send_oneloop_debug().
|
extern |
Definition at line 407 of file oneloop_andi.c.
Referenced by guidance_set_min_max_airspeed(), and reshape_wind().
|
extern |
Definition at line 264 of file oneloop_nB.c.
Referenced by guidance_set_max_bank_angle(), and init_controller_gains().
|
extern |
Definition at line 314 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 270 of file oneloop_nB.c.
Referenced by eul_of_acc(), guidance_indi_run(), oneloop_andi_sideslip(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_sideslip(), stabilization_attitude_read_rc_setpoint_eulers(), and stabilization_attitude_read_rc_setpoint_eulers_f().
|
extern |
Definition at line 518 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 276 of file oneloop_nB.c.
Referenced by eul_of_acc(), oneloop_nB_RM(), and oneloop_nB_run().
|
extern |
Definition at line 287 of file oneloop_andi.c.
Referenced by control_error_attitude(), control_error_rate(), control_error_thrust(), drop_axis(), normalize_nu(), oneloop_andi_init(), oneloop_andi_run(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_state_compensation(), and send_oneloop_debug().
|
extern |
Definition at line 114 of file oneloop_nB.c.
Referenced by get_act_state_oneloop(), guidance_oneloop_nB_run_mode(), oneloop_from_nav(), oneloop_nB_calc_nB_states(), oneloop_nB_enter(), oneloop_nB_init(), oneloop_nB_RM(), oneloop_nB_run(), oneloop_nB_state_compensation(), reinit_controller(), reshape_wind(), send_guidance_oneloop_nB(), send_oneloop_debug(), send_oneloop_nB(), send_oneloop_nB_ctrl(), set_WLS_settings(), spin_man_update(), SpinQuad_overwrite(), and xi_fun().
|
extern |
Definition at line 130 of file oneloop_nB.c.
Referenced by eff_scheduling_rotwing_init(), init_all_LP(), init_filter(), init_RW_Model(), reinit_all_LP(), and update_attitude().
|
extern |
Definition at line 510 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 492 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
|
extern |
Definition at line 493 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
|
extern |
Definition at line 485 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
|
extern |
Definition at line 487 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
|
extern |
Definition at line 495 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
|
extern |
Definition at line 496 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_att().
|
extern |
Definition at line 489 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
|
extern |
Definition at line 490 of file oneloop_andi.c.
Referenced by init_controller_gains(), init_poles(), and init_poles_pos().
|
extern |
Definition at line 639 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 640 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 641 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 365 of file oneloop_andi.c.
Referenced by oneloop_andi_enter(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_enter(), oneloop_nB_RM(), and oneloop_nB_run().
|
extern |
Definition at line 364 of file oneloop_andi.c.
Referenced by chirp_pos(), oneloop_andi_enter(), oneloop_andi_RM(), oneloop_andi_run(), oneloop_nB_enter(), oneloop_nB_RM(), oneloop_nB_run(), and send_oneloop_debug().
|
extern |
Definition at line 516 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 513 of file oneloop_nB.c.
Referenced by oneloop_nB_enter(), oneloop_nB_init(), and oneloop_nB_run().
|
extern |
Definition at line 656 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 658 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 652 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_reset(), and spin_man_update().
|
extern |
Definition at line 653 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 654 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 660 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_ramp_ref(), spin_man_update(), and SpinQuad_overwrite().
|
extern |
Definition at line 655 of file oneloop_nB.c.
Referenced by spin_man_ramp_ref(), and spin_prot_bound_params().
|
extern |
Definition at line 659 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), oneloop_nB_run(), send_oneloop_debug(), spin_man_rate_ctrl(), spin_man_reset(), and spin_man_update().
|
extern |
Definition at line 657 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
extern |
Definition at line 651 of file oneloop_nB.c.
Referenced by send_oneloop_debug(), spin_man_reset(), and spin_man_update().
|
extern |
Definition at line 541 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
extern |
Definition at line 539 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
extern |
Definition at line 567 of file oneloop_nB.c.
Referenced by spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 540 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 563 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and send_oneloop_debug().
|
extern |
Definition at line 561 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
extern |
Definition at line 559 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 560 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and spin_prot_bound_params().
|
extern |
Definition at line 562 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), spin_man_update(), and spin_prot_bound_params().
|
extern |
Definition at line 495 of file oneloop_nB.c.
Referenced by oneloop_nB_RM(), and SpinQuad_overwrite().
|
extern |
Definition at line 494 of file oneloop_nB.c.
|
extern |
Definition at line 506 of file oneloop_nB.c.
Referenced by oneloop_nB_run(), and oneloop_nB_state_compensation().
|
extern |
Definition at line 113 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 507 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 508 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 512 of file oneloop_nB.c.
Referenced by oneloop_nB_run().
|
extern |
Definition at line 511 of file oneloop_nB.c.
Referenced by oneloop_nB_RM().
|
extern |
Definition at line 315 of file oneloop_andi.c.
Referenced by oneloop_andi_RM(), and oneloop_nB_RM().
 1.9.8