|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
|
Paparazzi UAS v7.1_unstable
Paparazzi is a free software Unmanned Aircraft System.
|
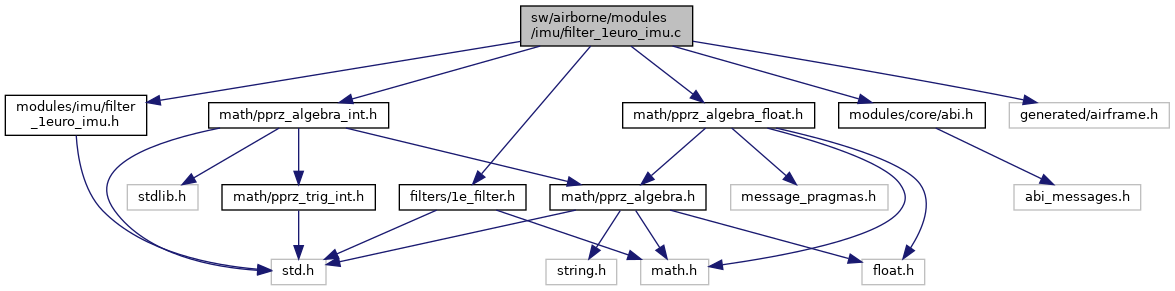
#include "modules/imu/filter_1euro_imu.h"#include "filters/1e_filter.h"#include "math/pprz_algebra_int.h"#include "math/pprz_algebra_float.h"#include "modules/core/abi.h"#include "generated/airframe.h"Go to the source code of this file.
Macros | |
| #define | FILTER_1EURO_ENABLED TRUE |
| Enable by default. | |
| #define | FILTER_1EURO_GYRO_MINCUTOFF 10.f |
| Default gyro min cutoff freq. | |
| #define | FILTER_1EURO_GYRO_BETA 0.1f |
| Default gyro beta coef. | |
| #define | FILTER_1EURO_GYRO_DCUTOFF 1.f |
| Default gyro dcutoff (not recommanded to change). | |
| #define | FILTER_1EURO_ACCEL_MINCUTOFF 0.1f |
| Default accel min cutoff freq. | |
| #define | FILTER_1EURO_ACCEL_BETA 0.01f |
| Default accel beta coef. | |
| #define | FILTER_1EURO_ACCEL_DCUTOFF 1.f |
| Default accel dcutoff (not recommanded to change). | |
| #define | FILTER_1EURO_FREQ PERIODIC_FREQUENCY |
| Auto freq if not defined. | |
| #define | IMU_F1E_BIND_ID ABI_BROADCAST |
| ABI bindings. | |
Functions | |
| static void | gyro_cb (uint8_t sender_id, uint32_t stamp, struct Int32Rates *gyro) |
| static void | accel_cb (uint8_t sender_id, uint32_t stamp, struct Int32Vect3 *accel) |
| static void | mag_cb (uint8_t sender_id, uint32_t stamp, struct Int32Vect3 *mag) |
| void | filter_1euro_imu_init (void) |
| Init and bindings. | |
| void | filter_1euro_imu_reset (float enabled) |
| settings handlers | |
| void | filter_1euro_imu_update_gyro_mincutoff (float mincutoff) |
| void | filter_1euro_imu_update_gyro_beta (float beta) |
| void | filter_1euro_imu_update_gyro_dcutoff (float dcutoff) |
| void | filter_1euro_imu_update_accel_mincutoff (float mincutoff) |
| void | filter_1euro_imu_update_accel_beta (float beta) |
| void | filter_1euro_imu_update_accel_dcutoff (float dcutoff) |
Variables | |
| struct Filter1eImu | filter_1e_imu |
| configuration structure | |
| static struct OneEuroFilter | gyro_1e [3] |
| array of 1 euro filters for gyrometer | |
| static struct OneEuroFilter | accel_1e [3] |
| array of 1 euro filters for accelerometer | |
| static abi_event | gyro_ev |
| static abi_event | accel_ev |
| static abi_event | mag_ev |
Definition in file filter_1euro_imu.c.
| #define FILTER_1EURO_ACCEL_BETA 0.01f |
Default accel beta coef.
Definition at line 60 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_ACCEL_DCUTOFF 1.f |
Default accel dcutoff (not recommanded to change).
Definition at line 65 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_ACCEL_MINCUTOFF 0.1f |
Default accel min cutoff freq.
Definition at line 55 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_ENABLED TRUE |
Enable by default.
Definition at line 35 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_FREQ PERIODIC_FREQUENCY |
Auto freq if not defined.
Definition at line 79 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_GYRO_BETA 0.1f |
Default gyro beta coef.
Definition at line 45 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_GYRO_DCUTOFF 1.f |
Default gyro dcutoff (not recommanded to change).
Definition at line 50 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define FILTER_1EURO_GYRO_MINCUTOFF 10.f |
Default gyro min cutoff freq.
Definition at line 40 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
| #define IMU_F1E_BIND_ID ABI_BROADCAST |
ABI bindings.
by default bind to all IMU raw data and send filtered data receivers (AHRS, INS) should bind to this prefilter module IMU (gyro, accel)
Definition at line 106 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init().
|
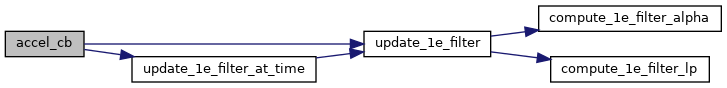
static |
Definition at line 143 of file filter_1euro_imu.c.
References accel_1e, ACCELS_BFP_OF_REAL, ACCELS_FLOAT_OF_BFP, filter_1e_imu, IMU_F1E_ID, update_1e_filter(), update_1e_filter_at_time(), FloatVect3::x, FloatVect3::y, and FloatVect3::z.
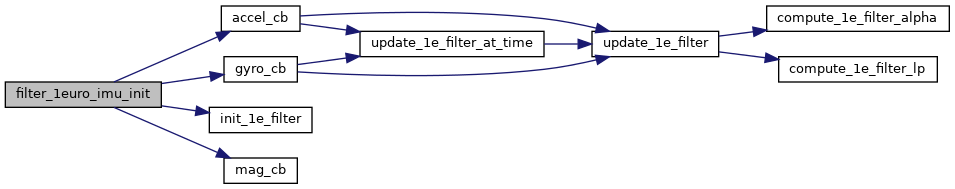
| void filter_1euro_imu_init | ( | void | ) |
Init and bindings.
Definition at line 185 of file filter_1euro_imu.c.
References accel_1e, accel_cb(), accel_ev, filter_1e_imu, FILTER_1EURO_ACCEL_BETA, FILTER_1EURO_ACCEL_DCUTOFF, FILTER_1EURO_ACCEL_MINCUTOFF, FILTER_1EURO_ENABLED, FILTER_1EURO_FREQ, FILTER_1EURO_GYRO_BETA, FILTER_1EURO_GYRO_DCUTOFF, FILTER_1EURO_GYRO_MINCUTOFF, gyro_1e, gyro_cb(), gyro_ev, IMU_F1E_BIND_ID, init_1e_filter(), mag_cb(), and mag_ev.
| void filter_1euro_imu_reset | ( | float | enabled | ) |
settings handlers
Definition at line 217 of file filter_1euro_imu.c.
References accel_1e, filter_1e_imu, gyro_1e, and reset_1e_filter().
| void filter_1euro_imu_update_accel_beta | ( | float | beta | ) |
Definition at line 258 of file filter_1euro_imu.c.
References accel_1e, and filter_1e_imu.
| void filter_1euro_imu_update_accel_dcutoff | ( | float | dcutoff | ) |
Definition at line 266 of file filter_1euro_imu.c.
References accel_1e, and filter_1e_imu.
| void filter_1euro_imu_update_accel_mincutoff | ( | float | mincutoff | ) |
Definition at line 250 of file filter_1euro_imu.c.
References accel_1e, and filter_1e_imu.
| void filter_1euro_imu_update_gyro_beta | ( | float | beta | ) |
Definition at line 234 of file filter_1euro_imu.c.
References filter_1e_imu, and gyro_1e.
| void filter_1euro_imu_update_gyro_dcutoff | ( | float | dcutoff | ) |
Definition at line 242 of file filter_1euro_imu.c.
References filter_1e_imu, and gyro_1e.
| void filter_1euro_imu_update_gyro_mincutoff | ( | float | mincutoff | ) |
Definition at line 226 of file filter_1euro_imu.c.
References filter_1e_imu, and gyro_1e.
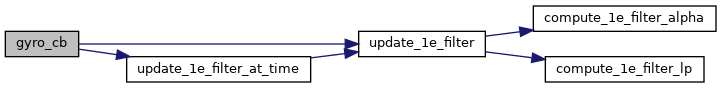
|
static |
Definition at line 114 of file filter_1euro_imu.c.
References filter_1e_imu, gyro_cb(), and IMU_F1E_ID.
|
static |
Definition at line 172 of file filter_1euro_imu.c.
References IMU_F1E_ID.
|
static |
array of 1 euro filters for accelerometer
Definition at line 96 of file filter_1euro_imu.c.
Referenced by accel_cb(), filter_1euro_imu_init(), filter_1euro_imu_reset(), filter_1euro_imu_update_accel_beta(), filter_1euro_imu_update_accel_dcutoff(), and filter_1euro_imu_update_accel_mincutoff().
|
static |
Definition at line 111 of file filter_1euro_imu.c.
| struct Filter1eImu filter_1e_imu |
configuration structure
Definition at line 86 of file filter_1euro_imu.c.
Referenced by accel_cb(), filter_1euro_imu_init(), filter_1euro_imu_reset(), filter_1euro_imu_update_accel_beta(), filter_1euro_imu_update_accel_dcutoff(), filter_1euro_imu_update_accel_mincutoff(), filter_1euro_imu_update_gyro_beta(), filter_1euro_imu_update_gyro_dcutoff(), filter_1euro_imu_update_gyro_mincutoff(), and gyro_cb().
|
static |
array of 1 euro filters for gyrometer
Definition at line 91 of file filter_1euro_imu.c.
Referenced by filter_1euro_imu_init(), filter_1euro_imu_reset(), filter_1euro_imu_update_gyro_beta(), filter_1euro_imu_update_gyro_dcutoff(), and filter_1euro_imu_update_gyro_mincutoff().
|
static |
Definition at line 110 of file filter_1euro_imu.c.
|
static |
Definition at line 112 of file filter_1euro_imu.c.
 1.15.0